
An all-electric bending machine system with grating ruler to compensate bending depth
A grating ruler and bending machine technology, applied in the field of all-electric bending machines, can solve the problems of reduced efficiency, overshoot, and failure to reach the position at one time, and achieve the effects of improving processing efficiency, high precision, and saving compensation time
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2022-07-08
Smart Images
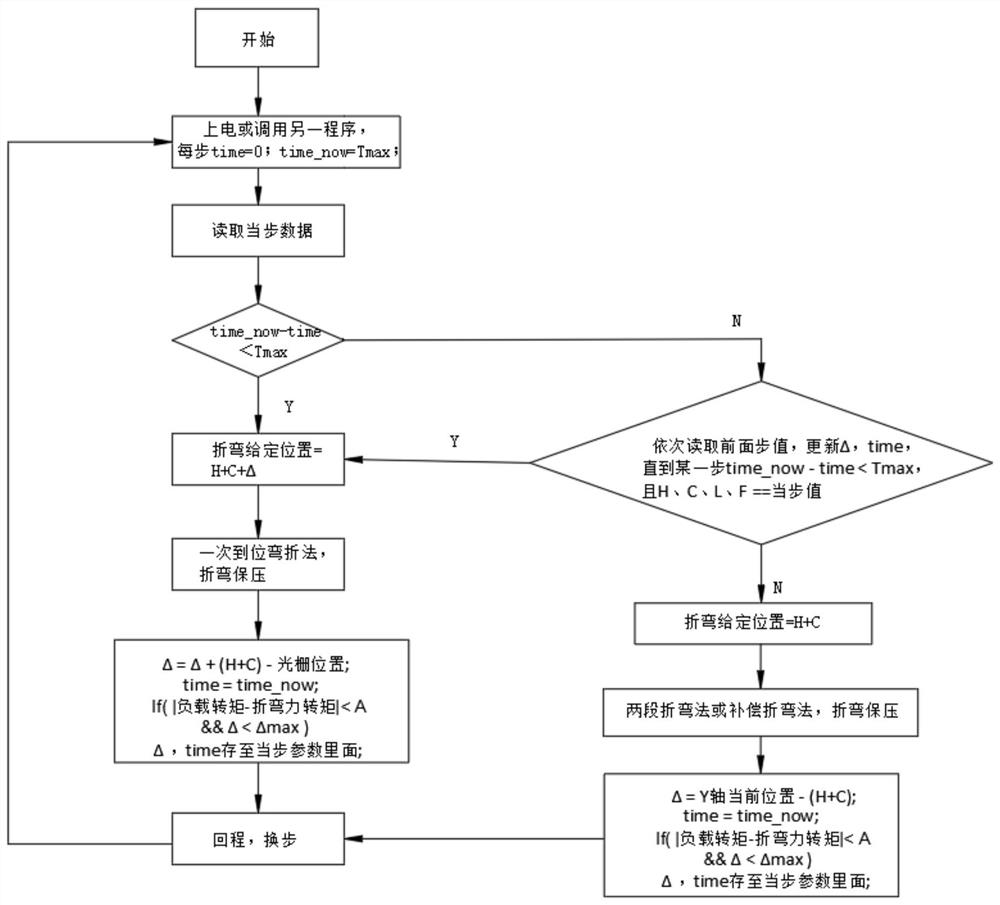
Figure 1
Abstract
Description
technical field
[0001] The invention relates to the technical field of all-electric bending machines, in particular to an all-electric bending machine system for compensating bending depth with a grating ruler. Background technique
[0002] The all-electric (servo) bending machine is two high-power servo motors installed on both sides of the machine. The pulley drives the screw to rotate, so that the slider moves up and down synchronously, so as to bend the workpiece and process the product. Due to the large pressure required for folding the plate, the frame is deformed or the belt is stretched and deformed, resulting in the position of the Y-axis servo encoder reaching the given bending position, but the actual slider position has not been reached. Due to the amount of deformation, there are many influencing factors , it is difficult to calculate theoretically, that is, it is difficult to predict, so it cannot be in place at one time
[0003] There are two existing solutio...
Examples
Embodiment
[0019] like figure 1 As shown, start the servo, edit the step, power on or call another program, time=0 for each step; time_now=Tmax; Tmax can be set to 5min or other empirical time, start, read the parameters of the current step, and judge the time_now-time and Tmax The size of the value between the two, if time_now-time