
Patents
Literature
83879 results about "Machine" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Machines employ power to achieve desired forces and movement. A machine has a power source and actuators that generate forces and movement, and a system of mechanisms that shape the actuator input to achieve a specific application of output forces and movement. Modern machines often include computers and sensors that monitor performance and plan movement, and are called mechanical systems. The meaning of the word "machine" is traced by the Oxford English Dictionary to an independently functioning structure and by Merriam-Webster Dictionary to something that has been constructed. This includes human design into the meaning of machine. The adjective "mechanical" refers to skill in the practical application of an art or science, as well as relating to or caused by movement, physical forces, properties or agents such as is dealt with by mechanics. Similarly Merriam-Webster Dictionary defines "mechanical" as relating to machinery or tools. Power flow through a machine provides a way to understand the performance of devices ranging from levers and gear trains to automobiles and robotic systems.
Real-Time Digital-Twin Structural Health Monitoring and Autonomous Maintenance System
A structural-health-monitoring system is disclosed for real-time detection and autonomous maintenance of physical structures. The system includes a sensor network comprising at least one strain gauge and one tri-axial accelerometer mounted on the structure to generate real-time sensor signals. A perception module filters and normalizes the signals and extracts numerical features such as peak amplitude and dominant frequency. A digital-twin module maintains a finite-element model updated in response to the extracted features. A data-driven surrogate model predicts sensor behavior and refines itself using machine-learning techniques. An anomaly-detection module computes an anomaly score from model residuals or classifier outputs. Upon exceeding a threshold, a maintenance module initiates a maintenance action, including generating an inspection schedule or issuing a control signal to an autonomous inspection or repair device. A learning module continuously improves system performance using reinforcement learning based on historical outcomes. The system supports predictive diagnostics, robotic repair, and automated optimization for long-term structural integrity.

Owner:VIKING DISCOVERIES LLC
Servo position control method and system applied to engraving and milling machine
The invention relates to the technical field of program control, in particular to a servo position control method and system applied to an engraving and milling machine. The method comprises the following steps that real-time temperature data and real-time load data of lead screws of all shafts in the engraving and milling machine are obtained; collecting multi-node temperature distribution data of the engraving and milling machine; obtaining cutting force data and resonant frequency characteristic values in the engraving and milling machine; constructing a screw rod reverse clearance prediction model based on the real-time temperature data and the real-time load data of the screw rod, and generating a clearance compensation value; performing pre-compensation control before the servo position direction of each axis is changed based on the clearance compensation value to obtain a correction position instruction; and performing thermal deformation simulation on the engraving and milling machine based on the multi-node temperature distribution data to generate thermal deformation compensation amounts of all shafts. Through multi-source data fusion and intelligent control, comprehensive optimization of the servo position system of the engraving and milling machine is achieved, the machining precision, dynamic response and stability are effectively improved, and efficient and reliable operation of high-speed and high-precision machining is guaranteed.

Owner:JIANGXI JINGSHENG CHUANGKE INTELLIGENT EQUIPMENT CO LTD
Four-foot robot mechanical arm tail end force feedback teleoperation control system and method
ActiveCN120791811AProgramme-controlled manipulatorInput/output for user-computer interactionControl engineeringMan machine
The invention belongs to the technical field of robot control, particularly provides a force feedback teleoperation control system and method for the tail end of a mechanical arm of a quadruped robot, and aims at the key challenges that control errors are caused by communication time delay and soft obstacles are difficult to recognize in a dynamic environment. Modeling and judgment are conducted on the contact state of the tail end of the mechanical arm in advance, and feedforward control and buffer adjustment oriented to communication time delay are achieved. And meanwhile, a dynamic semantic map is constructed in combination with multi-source sensing information, and soft obstacle reasoning and path optimization are performed by fusing a tail end force sense change trend, so that the recognition and avoidance capabilities of the system in a complex and invisible obstacle environment are remarkably improved. The system has good perspectiveness, self-adaptability and high redundancy safety characteristics, is suitable for multi-task inspection operation of industrial sites such as a thermal power plant, and is especially suitable for a remote man-machine cooperative operation scene in a narrow space.

Owner:武汉跨克信息技术有限公司
Dynamic coupling compensation method for thermal expansion and axial displacement
The invention belongs to the field of equipment coupling monitoring, and particularly relates to a dynamic coupling compensation method for thermal expansion and axial displacement, which comprises the following steps of: calculating a first characteristic value for representing reference dynamic offset of a sensor based on a three-dimensional thermal-structure coupling model by acquiring a thermal expansion parameter and axial displacement parameter sequence of a casing; calculating a second characteristic value representing the real position change of the rotor in combination with a rotor-casing axial thermodynamic model, establishing a piecewise coupling function considering a nonlinear effect, working condition self-adaption and cross interference, and eliminating the mechanical thermal inertia and measurement system lag influence through a dynamic delay compensation mechanism; an accurate axial displacement measurement total error compensation index is generated, and grading compensation actions are intelligently triggered according to error grades; the problem of measurement distortion caused by dynamic coupling of thermal expansion and axial displacement is effectively solved, and the accuracy and reliability of state monitoring of the rotating machine are remarkably improved.

Owner:SHANGHAI RUISHI INSTR & ELECTRONIC CO LTD
Robot control method, system and equipment based on multi-modal large model and medium
The invention relates to the technical field of robot control, and discloses a robot control method, system, equipment and medium based on a multi-modal large model, and the method comprises the steps: collecting the multi-source modal data of a scene where an operation task is located, and carrying out the processing through a machine learning model, obtaining a multi-modal feature, and carrying out the position coding and Transform fusion processing, multi-modal fusion features are obtained, the multi-modal fusion features and the constructed job task knowledge base are input into a large language model to decompose a target job task, a human-in-the-loop mechanism is introduced to optimize a decomposition result, and a sub-task sequence is obtained; according to a subtask type in the subtask sequence, processing the subtask sequence through a visual language action model or a reinforcement learning model, and generating a motion instruction to enable the robot to start an execution process of the target operation task; live-line work tasks are processed through the multi-modal large models LLM, VLA and the like, and the work efficiency of the autonomous distribution network live-line work robot is improved.

Owner:WENZHOU ELECTRIC POWER BUREAU +2
Heavy-load robot motion trail method and system based on machine learning
The invention relates to the technical field of robot control, and discloses a heavy-load robot motion trail method and system based on machine learning. The method comprises the steps that historical movement track data of the heavy-load robot in a working scene are collected, and the data comprise a joint position sequence, an end effector pose sequence and environment obstacle distribution information; the data is preprocessed, track features are extracted, a space-time correlation matrix is constructed, and the matrix is used for representing the dynamic coupling relation between joint movement and the tail end pose; training a trajectory prediction model containing a long and short-term memory network and an attention mechanism based on the matrix, and generating a collaborative mapping relation between a joint position and a tail end pose; obtaining a current task target pose sequence and an environment constraint condition in real time, and outputting a candidate track set meeting dynamic constraint through a model; and adopting a multi-objective optimization algorithm to screen candidate tracks, generating an optimal track instruction and issuing the optimal track instruction to an execution mechanism. The method adapts to the complex characteristics and variable working conditions of the heavy-load robot, and the track adaptability is improved.

Owner:NINGBO WELLLIH ROBOTS TECH CO LTD
Bayesian learning and piezoelectric ceramic driving numerical control machine tool thermal error compensation system and method
The invention discloses a Bayesian learning and piezoelectric ceramic driving numerical control machine tool thermal error compensation system and method. According to the system, a distributed temperature sensor array is arranged in heat sensitive areas such as a machine tool spindle, a ball screw, a guide rail and a bearing seat, whole-field temperature information is collected in combination with a thermal infrared imager, and multi-source thermal field sensing is achieved; meanwhile, a laser interferometer and a capacitive displacement sensor are used for constructing a dynamic pose monitoring network. The intelligent decision-making unit integrates a Bayesian online learning engine, fuses a physical model and a data driving model, dynamically predicts a thermal error and generates a compensation instruction. And the piezoelectric execution mechanism carries out nonlinear pre-compensation on a driving signal through a three-section Prantl-Ishlinskii hysteresis inverse model according to the instruction, so that high-precision pose adjustment is realized. The thermal error compensation precision is remarkably improved, the adaptability of the system to complex working conditions is enhanced, the service life of equipment is prolonged, and the method is suitable for various numerical control machine tools.

Owner:JIANGSU HAOXIONG INTELLIGENT EQUIPMENT CO LTD
Coal mine intelligent directional drill and drilling method therefor
The present invention relates to a coal mine intelligent directional drill and its drilling method, belonging to the technical field of coal mine drills. It comprises a moving platform, machine frame, clamper, main manipulator, power head, drill pipe storage system, control system, and hydraulic system. The power head structure is improved by adding an angle adjuster with accurate angle adjustment, locking, and anti-rotation functions. The angle adjuster is positioned on the gearbox side opposite the main motor, connected via a driving shaft. The control system includes a toolface azimuth detection and initialization system that works with the angle adjuster. This solves prior issues such as the absence of specialized toolface azimuth adjustment devices, low precision, low track adjustment efficiency, and challenges in achieving automatic directional drilling in the prior art. The invention enhances precision and efficiency, enabling automated, intelligent directional drilling.

Owner:CHINA COAL TECH & ENG GRP CHONGQING RES INST CO LTD
Sliding bearing frictional wear prediction method based on hydromechanics
The invention discloses a sliding bearing friction wear prediction method based on fluid mechanics, and relates to the technical field of mechanical state monitoring, and the method comprises the steps: collecting single-point temperature, local pressure, vibration time domain signals and a bearing pedestal inclination angle through a sensor, and generating sensor data; performing field reconstruction based on a fluid mechanics conservation equation on the sensor data to obtain multi-field data; performing spatial alignment on the multi-field data, inputting the multi-field data into a long short-term memory (LSTM) network, and generating wear state characteristics; training a sparse correlation vector machine regression model RVM by using the historical wear data, establishing a nonlinear mapping relationship between the wear state characteristics and the wear depth, taking the wear state characteristics as the input of the vector machine regression model RVM, and outputting the predicted wear depth; sensor data and the predicted wear depth are fused in real time through Kalman filtering, and when prediction deviation exceeds a covariance threshold value, vector machine regression model RVM parameters are updated.

Owner:ZHEJIANG ZHUJI BEARING PLANT CO LTD
Mechanical arm natural language instruction control system and method based on large language model
The invention discloses a mechanical arm natural language instruction control system and method based on a large language model, and belongs to the field of intelligent manufacturing. Aiming at the limitation that traditional mechanical arm control depends on pre-programming and a static rule library, a dynamic mapping mode from a natural language instruction to an atomic action sequence is designed, an atomic skill library including detection, grabbing, moving, placement and other operations is constructed, and semantic analysis and a multi-mode cooperation technology are combined, so that the atomic action sequence is obtained. And support is provided for man-machine cooperation of a flexible assembly task. The method specifically comprises the steps that a DeepSeek-Distil-Llam-8B large model and a LoRA fine tuning technology are adopted, and a natural language instruction is converted into an executable atomic action sequence; based on a transfer learning optimized YOLOv8 target detection technology and a binocular vision positioning technology, a sensing module adaptive to an assembly scene is constructed and is fused with a mechanical arm motion planning module, and positioning grabbing of parts and tools is achieved. And an interactive interface is built by combining a voice-to-text large model and a Gradio front-end framework, so that the convenience of man-machine interaction is improved. By optimizing large model reasoning and motion planning cooperation efficiency, response delay from instructions to execution is reduced, and an efficient and extensible solution is provided for man-machine cooperation in intelligent manufacturing.


Owner:BEIJING INST OF TECH
Self-adaptive flexible tightening intelligent robot with body and tightening process method
PendingCN120663107AProgramme-controlled manipulatorMetal working apparatusControl engineeringMachine
The invention relates to the technical field of body-equipped intelligent robots and intelligent equipment, in particular to a self-adaptive flexible tightening body-equipped intelligent robot which comprises a body-equipped moving platform, the top of the body-equipped moving platform is provided with a body-equipped lifting mechanism, and the top of the body-equipped moving platform is provided with a body-equipped articulated arm module. And a tightening actuator and a clamping jaw actuator are arranged at the tail end of the outer part of the body articulated arm module. According to the self-adaptive flexible tightening intelligent robot and the tightening process method, sensing and self-adaptive adjustment of external environment changes are achieved through multi-module integration, and the tightening process method based on a multi-mode sensing system and an intelligent control system is constructed; vision, force sense and touch sense data are fused, real-time monitoring and dynamic adjustment of the tightening process are achieved through a machine learning algorithm, and the intelligent level and quality stability of tightening operation are effectively improved.

Owner:DALIAN UNIV OF TECH
Double-arm robot autonomous control system and method based on remote operation and visual features
The invention discloses a double-arm robot autonomous control system and method based on teleoperation and visual features. The system comprises a teleoperation acquisition module, a multi-view visual perception module, a data synchronization and demonstration acquisition module, a strategy model training module, an autonomous strategy execution module, a track deviation detection and takeover module and a hybrid control interface module. Human demonstration is completed through teleoperation, multi-modal information of images, tracks, clamping jaws and muscle activation is collected, perception features are fused by adopting multi-view space-time alignment and a cross-view attention mechanism, strategy learning is completed in combination with an end-to-end large model, and in the autonomous operation stage, the multi-view space-time alignment and the cross-view attention mechanism are combined with the end-to-end large model. The risk of current operation is predicted and evaluated through track deviation detection and collision probability, the autonomous control proportion is dynamically adjusted, manual intervention is allowed when necessary, the safety and stability of the whole system are improved, the robot control mode of seamless switching between man-machine cooperation and autonomous and teleoperation is achieved, and the method is suitable for object control tasks in complex and highly variable environments.

Owner:ZHEJIANG SHENCHEN KAIDONG TECHNOLOGY CO LTD
Numerical control machine tool wear monitoring and intelligent compensation control method based on deep learning
The invention discloses a numerical control machine tool wear monitoring and intelligent compensation control method based on deep learning, and relates to the field of numerical control machine tool wear monitoring. Multi-source data are collected through a sensor, and are preprocessed and fused through edge calculation; deep features are extracted and enhanced through an improved network, the abrasion state is evaluated through a mixed expert model, and life is predicted in combination with survival analysis; based on enhanced transfer learning, generating an intelligent compensation strategy according to a processing target, and executing the intelligent compensation strategy after verification in a virtual environment; a closed-loop system is constructed, all modules are acquired, fed back and optimized, and full-process intelligent management of functions such as knowledge graph early warning and multi-machine-tool cooperation is integrated. According to the method, the wear monitoring accuracy is improved, and early wear is accurately recognized; machining parameters are intelligently compensated and optimized, precision is improved, and the service life of a tool is prolonged; closed-loop control and multiple technologies are fused, the response time is shortened, and shutdown is reduced; the operation efficiency and reliability of the numerical control machine tool are improved, and the cost is reduced.

Owner:JIANGSU ANTO INTELLIGENT EQUIP TECH CO LTD
Pump equipment state monitoring and fault diagnosis method based on artificial intelligence
The invention provides a pump equipment state monitoring and fault diagnosis method based on artificial intelligence, and relates to the technical field of data processing, and the method comprises the steps: obtaining a vibration signal of a target type of pump equipment based on a preset vibration sensor, and marking the vibration signal; extracting features of the vibration signal based on a preset dual-channel feature extraction model; iteratively training a preset basic fault diagnosis model based on the characteristics of the vibration signal until a preset training completion condition is reached; binding a preset number of fault diagnosis models to construct a pump equipment state reasoning model; acquiring an operation vibration signal of the pump equipment of the target category, inputting the operation vibration signal into the pump equipment state reasoning model, and outputting a fault category; through time-frequency dual-channel fusion and multi-scale perception, the fault identification precision is improved; the rationality and interpretability of the result are enhanced by using physical prior constraints; and through model integration optimization, the classification stability and reliability in a complex scene are improved.

Owner:SHANDONG ENERGY DIGITAL CLOUD TECH CO LTD
Man-machine exoskeleton cooperation method based on multi-modal signal fusion
The invention discloses a man-machine exoskeleton cooperation method based on multi-modal signal fusion, and relates to the technical field of exoskeleton program control. The method comprises the following steps that man-machine exoskeleton driving pre-pressure cold and hot mutation analysis is conducted in combination with man-machine exoskeleton man-machine cooperation components; and performing memory alloy spring pre-pressure optimization adjustment in combination with a man-machine exoskeleton driving pre-pressure cold and hot mutation analysis result. According to the invention, cold chain exoskeleton cooperative control is realized through multi-mode signal fusion, and three-level regulation and control are implemented based on a current threshold value and a myoelectricity state: graded current rising / falling and safety early warning are carried out in case of abnormal current; dynamic gain compensation or joint retardation protection is carried out when myoelectricity is abnormal; according to the man-machine exoskeleton cooperative control method and the man-machine exoskeleton cooperative control system, the effect of improving the accuracy of man-machine exoskeleton cooperative control for coping with cold-chain logistics is achieved, and the problem that the accuracy of man-machine exoskeleton cooperative control for coping with cold-chain logistics is disabled in the prior art is solved.

Owner:HEFEI HAIFENG HUIXIN INTELLIGENT TECHNOLOGY CO LTD
VLA model method of humanoid robot for long-range task
The invention relates to a long-range task-oriented VLA model method for a humanoid robot, which comprises the following steps of: S01, analyzing a natural language instruction through a space-time semantic analyzer to generate an atomic operation sequence with a space-time dependency relationship; s02, maintaining a task state machine by using a dynamic memory network, and tracking the task execution progress in real time; s03, integrating vision, language and sensor data through a multi-modal perception fusion engine; s04, calling a predefined action primitive based on an adaptive execution system and optimizing a motion track; and S05, performing online updating and optimization on the model through a continuous learning mechanism. According to the method, a natural language instruction is analyzed into a structured task sequence with space-time dependence through a space-time semantic analyzer, an execution sequence and preconditions are defined, the semantic understanding ability and the structuring degree of task planning are improved, and task decomposition and replanning in a dynamic environment are supported; according to the method, the LSTM and the knowledge graph are combined, and the task state is maintained in real time.

Owner:HUIZHOU BEIJIABAO ROBOT CO LTD
Intelligent cooling system and method of centerless grinding machine for difficult-to-machine materials
PendingCN120993827AProgramme controlRevolution surface grinding machinesFrequency spectrumAcoustic emission
The invention relates to the technical field of industrial control, in particular to an intelligent centerless grinding machine cooling system and method for difficult-to-machine materials, and the system comprises a multi-source sensing unit, an edge calculation module, a decision center module, a precise execution module and a digital immune memory bank; compared with the defects that in the prior art, monitoring depends on a single temperature sensor, thermal field sensing is incomplete, thermal damage early warning lags behind and the like, according to the scheme, grinding power frequency spectrum, acoustic emission signals, triaxial vibration and coolant mass spectrum data are collected in real time through a multi-source sensing unit, and a micron-sized temperature field is reconstructed in combination with an edge end space-time diagram convolutional network; full-dimensional monitoring of the grinding thermal-mechanical coupling effect is achieved, and thermal anomaly recognition sensitivity and early warning timeliness are remarkably improved.

Owner:WUXI JIANHE NUMERICAL CONTROL MACHINE TOOL
Systems and methods for dynamic object removal from three-dimensional data
Systems and methods for generating simulation data based on real-world environments are provided. A method includes obtaining multi-modal sensor data indicative of a dynamic object within an environment of a robotic platform. The multi-modal sensor data is associated with a plurality of timesteps including a first timestep and a second timestep. The method includes providing the multi-modal sensor data indicative of the dynamic object within the environment as an input to a machine-learned dynamic object removal model. And, the method includes receiving as an output of the machine-learned dynamic object removal model, in response to receipt of the multi-modal sensor data, a scene representation indicative of at least a portion of the environment including a reconstructed region based at least in part on removal of the dynamic object and multiple levels of granularity. The scene representation is used as a template for generating different simulations within the depicted environment.

Owner:AURORA OPERATIONS INC
High-precision monitoring system for tooth deviation in tooth cutting machining process
The invention relates to the technical field of numerical control machining monitoring, in particular to a tooth deviation high-precision monitoring system in a tooth cutting machining process, which comprises an online measurement module, a dynamic compensation module, a deviation calculation module and a result output module which are in signal connection with a numerical control system of a tooth cutting machine tool, the online measurement module, the dynamic compensation module, the deviation calculation module and the result output module are integrated on the processing element; the processing element is used for obtaining workpiece design parameters and constructing a theoretical workpiece model, the online measurement module is used for collecting tooth surface point cloud data in real time in the machining process, the dynamic compensation module is used for correcting vibration errors and temperature errors of the point cloud data, and the deviation calculation module is used for quantifying tooth surface deviation values. And the result output module is used for generating an early warning signal and a dynamic correction instruction and executing system self-calibration. The device and a numerical control system form a closed loop of machining, monitoring, correction and remachining, and finally high-precision real-time monitoring and dynamic correction of tooth deviation are achieved.

Owner:TIANJIN TIANHAI SYNC TECH CO LTD
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
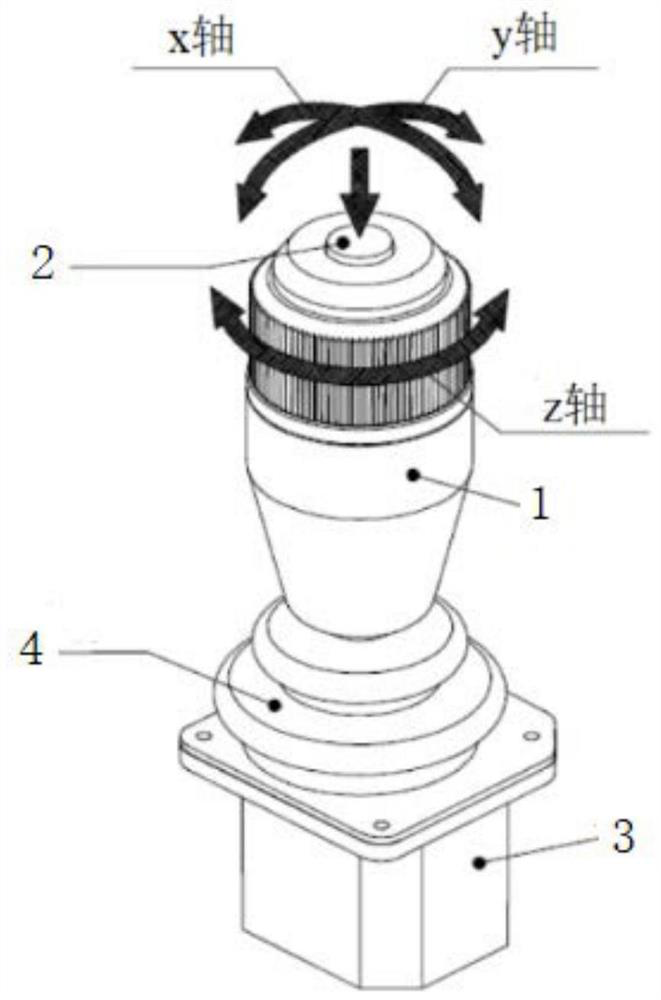
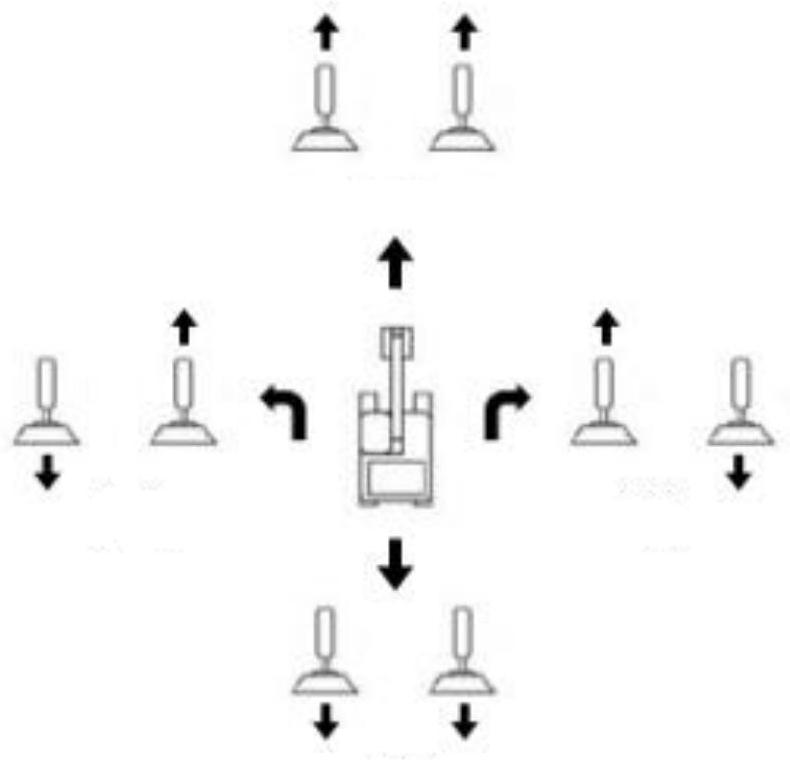
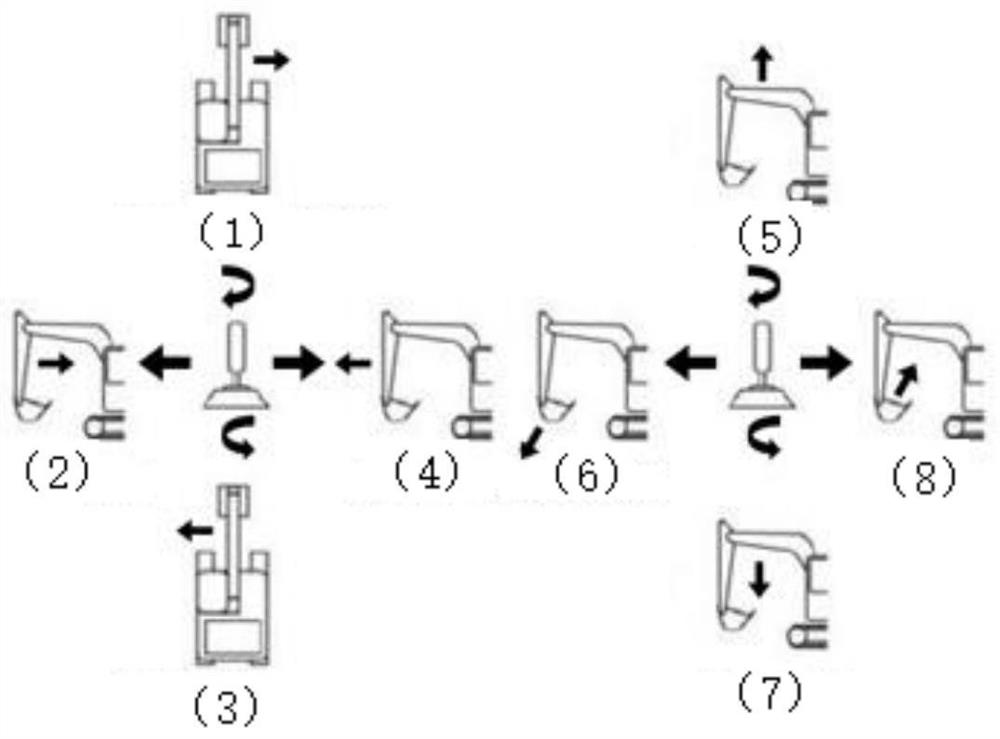
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Control system and method for welding process, and device, medium and program
PCT designated stageWO2025200574A1Programme controlWelding/cutting auxillary devicesControl systemControl engineering
Provided in the present disclosure are a control system and method for a welding process, and a device, a medium and a program. The control system comprises: a sensor module, which is configured to collect data during a welding process; a data analysis module, which is configured to preprocess the data during the welding process, extract key features from the preprocessed data, perform weighted fusion processing on the key features to obtain comprehensive features, and perform defect identification on the basis of the comprehensive features by means of a machine learning model to identify and obtain defect features; a knowledge graph module, which is configured to use a knowledge graph to obtain, on the basis of the defect features, a repair policy corresponding to the defect features; a control module, which is configured to transmit to the data analysis module the data in the welding process that is received from the sensor module, receive the repair policy, and generate a repair instruction on the basis of the repair policy; and a repair module, which is configured to automatically adjust welding parameters or control an actuation mechanism to perform a repair operation on the basis of the repair instruction.

Owner:JIANGSU XCMG CONSTRUCTION MACHINERY RESEARCH INSTITUTE LTD
Numerical control grinding machine product quality real-time monitoring optimization method based on Internet of Things
The invention relates to the technical field of machine tool equipment, in particular to a numerical control grinding machine product quality real-time monitoring optimization method based on the Internet of Things. The method comprises the following steps: acquiring multi-node real-time operation data of the numerical control grinding machine; working state parameters of key components of the grinding machine are counted according to the multi-node real-time operation data; the product machining quality fluctuation trend is determined based on the multi-node real-time operation data and the working state parameters of the key components of the grinding machine; according to the product machining quality fluctuation trend, the cooperative change rule of the grinding machine tailstock jacking force is detected; and determining the geometric accuracy limitation trend of the workpiece according to the cooperative change rule of the jacking force of the tailstock of the grinding machine. According to the method, the control parameter adjustment behavior, the system response state and the quality detection result of the numerical control grinding machine are associated and integrated, and the tracking and effect evaluation of the key control behavior are realized by constructing a historical contrast system of the adjustment behavior and the response data.

Owner:JIANGXI FENGCHENG PRECISION MASCH CO LTD
Determination of Task Plans for Robotic Devices
Technology is described for determining a task plan that is usable by a robotic device in a workspace. The method can include converting instructions received for the robotic device into temporal logic (TL) statements and to a non-deterministic Buchi Automaton. A task probabilistic machine learning model can be generated with feasible task plans using the non-deterministic Buchi Automaton. A plurality of task plans can also be created or generated using the task probabilistic machine learning model. A sensor probabilistic machine learning model of the workspace can be constructed using information from sensors of the robotic device. The task plans from the task probabilistic machine learning model can be compared with the sensor probabilistic machine learning model to select the task plan with a high probability of correlation to the workspace.

Owner:SARCOS CORP
Construction method of robot teleoperation body model and robot teleoperation system
The invention provides a construction method for a robot teleoperation body-sized model and a robot teleoperation system, and the method comprises the steps: carrying out the training and fine adjustment of a pre-trained body-sized model through master-slave robot control data, and obtaining a fine-adjusted body-sized model; deploying the fine-tuning body large model to provide robot control service, and collecting real machine execution data; obtaining scores of the real machine execution data, forming reinforcement learning training data pairs by the real machine execution data and the corresponding scores, and adding the reinforcement learning training data pairs into a reinforcement training data set; and performing reinforcement learning training on the fine-tuning body size model by using the reinforcement training data set. According to the method, the pre-training model is finely adjusted, the cost of manual intervention is effectively reduced, the reinforcement learning training data is collected by deploying the fine adjustment body model, the reinforcement learning method and the pre-training body model are organically combined, the advantages of the reinforcement learning method and the pre-training body model are fully played, and efficient learning and performance improvement of the robot in a complex environment are achieved.

Owner:BEIJING QIWU TECHNOLOGY CO LTD
Machine grabbing learning method fusing shape features, contact modeling and physical constraints
The invention provides a machine grabbing learning method fusing shape features, contact modeling and physical constraints, and the machine grabbing learning method is a robot grabbing posture learning method capable of differentiating. According to the method, a three-dimensional point cloud serves as input, a deep neural network based on sparse voxel convolution is adopted to extract multi-scale shape features, and potential grabbing points and attitude parameters thereof are predicted. The differential contact modeling is realized by constructing a local area of direction perception and extracting geometric features reflecting the contact relationship between the mechanical claw and the object. Furthermore, the collision probability of the grabbing posture is estimated based on an implicit neural network, and a differentiable collision detection module is constructed. Meanwhile, physical constraints such as friction closing, surface alignment and geometric symmetry are introduced to serve as regular terms to jointly optimize grabbing scores, collision risks and stability; according to the method, end-to-end training is supported, efficient, robust and deployable grabbing posture estimation is achieved, and the method is suitable for various automatic grabbing tasks such as industrial robots and service robots.

Owner:FUZHOU UNIV
Mechanical arm track optimization method and system based on deep learning and fuzzy algorithm
The invention relates to the technical field of intelligent mechanical arm control, and discloses a mechanical arm track optimization method and system based on deep learning and a fuzzy algorithm, and the method comprises the steps: building a kinematic model of a mechanical arm, determining the working space of the mechanical arm, carrying out the high-density random sampling, and generating a three-dimensional point cloud picture of a reachable region at the tail end of the mechanical arm; constructing a path planning model, designing a state space and an action space, and constructing a reward function; time-impact double-target optimization is carried out on the tail end path point sequence, a smooth joint trajectory is constructed, and balance between the shortest trajectory execution time and the minimum joint impact is achieved on the premise that speed and acceleration constraints are met; and tracking control is carried out on the trajectory, external disturbance and unmodeled dynamics are estimated and compensated in real time, a parameter adaptive law is designed, and the trajectory tracking precision of the system in a complex environment is improved. The autonomy, the accuracy and the anti-interference capability of the hot-line work mechanical arm in a complex environment are improved.

Owner:CHINA UNIV OF MINING & TECH
Injection molding size deviation monitoring method and system based on machine vision
The invention discloses an injection molding size deviation monitoring method based on machine vision, and the method comprises the steps: collecting geometric data of each region of an injection molding part through a sensor array, and generating original size distribution information; according to the geometric feature vector of each region, determining a dimensional deviation initial distribution state; analyzing the initial distribution state of the dimensional deviation by using a preset deviation feature library, and generating an abnormal region identifier set; determining a key process parameter combination causing deviation in combination with the production process parameter record; generating a parameter adjustment instruction for the abnormal area through the feedback control model, and updating the operation parameters of the injection molding equipment; and judging whether the correction effect reaches a preset standard or not, if the correction effect does not reach the preset standard, updating the deviation feature library, generating an optimized parameter adjustment instruction, and circularly executing the correction and monitoring process. Therefore, automatic identification, analysis and correction of the size deviation of the injection molding product can be realized, and the product quality stability and the production efficiency are improved.

Owner:SHENZHEN HAIJIE PRECISION MOULD & PLASTIC CO LTD
Shield tunneling intelligent control method and system based on ground-tunnel-machine-information-man adaptation level
The invention discloses a shield tunneling intelligent control method and system based on a ground-tunnel-machine-information-human adaptation level, and relates to the crossing field of underground engineering intelligent construction and information technology. Setting a first-level index and a second-level index; dividing the shield construction state into three levels of intelligent adaptation levels by combining the total score of the construction state with a dynamic threshold value; setting four targets of attitude intelligent control, settlement intelligent control, tunneling efficiency optimization and construction abnormity diagnosis; a machine learning prediction model is constructed, and the construction state parameters corresponding to the targets are predicted in real time; according to the shield intelligent adaptation level, the man-machine cooperation modes are divided into three classes of A level, B level and C level; and comparing actual data with a prediction result of the machine learning model, and dynamically correcting the control target parameters. Through real-time sensing of geological, mechanical and environmental multi-dimensional construction states and in combination with a dynamic weight distribution strategy, precise evaluation of the shield construction state is achieved, and meanwhile self-adaptive switching of the man-machine control right is achieved.

Owner:DALIAN UNIV OF TECH +2
Quadruped robot motion planning method and system based on height self-adaption
The invention relates to the field of mobile robot motion planning, and discloses a quadruped robot motion planning method and system based on height self-adaption. The method comprises the following steps: constructing 3D and 2D local obstacle maps according to coordinate transformation, and calculating a grid vertical distance through ray casting to generate a 2.5 D local obstacle map; determining an initial control sampling space by combining speed, acceleration and height constraints; discretizing a sampling space and simulation time, deducing a control value sequence and recursively calculating a local trajectory; then calculating a shaft alignment bounding box in a directed bounding box of the robot, screening grid units in the shaft alignment bounding box, comparing the height of a machine body with the allowable height of grids, and rejecting collision trajectories to obtain a feasible trajectory set; and finally selecting an optimal track by the evaluation function, extracting a control value and sending the control value to hardware for execution. According to the method, the 2.5 D local obstacle map containing height information is constructed, the four-dimensional control sampling space is designed, and the robot height self-adaptive adjustment is realized in combination with the collision detection and evaluation function.

Owner:EURASIA HIGH TECH DIGITAL TECH CO LTD +1
Transform fusion-based multi-modal posture recognition system
The invention relates to the technical field of multi-modal posture recognition, and relates to a multi-modal posture recognition system based on Transform fusion, which fully excavates the complementary advantages of visual information in spatial detail representation and inertial information in time sequence dynamic capture through space-time alignment of multi-modal data and deep fusion based on an attention mechanism. The accuracy and the stability of attitude estimation under the conditions of visual occlusion, rapid movement and complex illumination are obviously improved; posture optimization is carried out by introducing physical constraints such as bone length constancy and joint movement range limitation, and time domain smoothing and contact state correction are applied, so that the precision of the generated three-dimensional posture sequence is ensured, a solid technical foundation is laid for improving the naturalness, safety and intelligent level of man-machine interaction, and the method is suitable for popularization and application. And meanwhile, reliable application and deep development of the intelligent robot in key fields of service robots, virtual reality, remote cooperation and the like are powerfully promoted.

Owner:ZHENGZHOU UNIVERSITY OF LIGHT INDUSTRY