
Patents
Literature
999 results about "Reference line" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Definition of reference line. : an arbitrary fixed line (as an x-axis or a polar axis) from which coordinates of a point are computed.
Multi-source data fusion intelligent control method for logarithmic curved surface processing
The invention provides a multi-source data fusion intelligent control method for logarithmic curved surface machining, and relates to the technical field of data processing, and the method comprises the steps: 1, in a product machining process, through a geometric morphology detection sensor, a material characteristic perception sensor and a cutting state monitoring sensor, a cutting state is detected; obtaining multi-dimensional data reflecting the geometric morphology, the material characteristics and the cutting state of the curved surface, and forming a multi-source information stream; 2, carrying out real-time fusion on the multi-source information flow, and generating a comprehensive state description through space-time alignment and association of sensor data; the method comprises the following steps: converting data reflecting the geometric morphology of a curved surface into a point cloud set, identifying a feature point of a curvature mutation region as an original reference point, constructing two space reference straight lines, and calculating a space included angle between the two space reference straight lines to obtain an included angle region; through multi-source data fusion and intelligent control, the precision, efficiency and stability for logarithmic curved surface machining are improved, and the machining cost and the error rate are reduced.

Owner:ZHEJIANG SHENGXI PRECISION MASCH TECH CO LTD
Road surface flatness rapid detection method based on laser radar
The invention relates to the technical field of surface measurement, in particular to a road surface flatness rapid detection method based on a laser radar, which comprises the following steps: collecting vehicle attitude data to form a three-dimensional vector, mapping laser data to a space coordinate system, identifying a projection difference adjustment track, detecting a disturbance generation distribution area, and transversely distributing a translation direction line. Uniformly projecting to construct a reference line, extracting an echo and time index recombination time sequence segment, analyzing a point number trend to screen a stable segment, and extracting symmetric points to compare an included angle to generate a closed zone. According to the method, the attitude vectors of the vehicle in rolling, pitching and yawing states are obtained, the laser echo distance measurement data are mapped to the absolute space coordinate system, and the included angle difference between the distance measurement direction and the ground direction is accurately calculated, so that the space matching precision of a measurement path is remarkably improved, and a longitudinal section analysis result is closer to a real road state; and the space integrity, the track smoothness and the section structure rationality of the whole measurement process are comprehensively optimized.

Owner:NANJING VOCATIONAL UNIV OF IND TECH
Path planning method and apparatus, electronic device, medium, and autonomous vehicle
PCT designated stage expiredWO2025098069A1Instruments for road network navigationNavigational calculation instrumentsPathPingControl engineering
A path planning method and apparatus, an electronic device, a medium, and an autonomous vehicle. The path planning method comprises: determining a path planning area comprising a starting point and a destination point, wherein there are obstacles in the path planning area (S210); determining M reference lines, wherein the reference lines include reference lines between the obstacles and / or reference lines between the obstacles and boundaries of the path planning area, and M is a positive integer (S220); determining at least one sampling point from each reference line to obtain a sampling point set (S230); and generating a planned path from the starting point to the destination point on the basis of the sampling point set (S240).

Owner:BEIJING JINGDONG QIANSHITECHNOLOGY CO LTD
Underground cavern three-dimensional modeling method and system based on dynamic parametric node regulation and control
The invention provides an underground cavern three-dimensional modeling method and system based on dynamic parameterization node regulation, and the method comprises the steps: firstly obtaining a multi-source sensing data set which covers section contour point cloud, geological environment and real-time monitoring data, generating an initial section contour curve based on the section contour point cloud data, obtaining a dynamically adjusted curve and node regulation and control parameters through dynamic parameterization node regulation and control, and generating a stretching path reference line according to the cavern axis coordinate parameters; the adjusted section profile curve is axially stretched to generate a three-dimensional cavern curved surface containing a local three-dimensional curved surface set, finally, section stitching is conducted on the local three-dimensional curved surface set, a connection area topological structure is generated according to joint direction parameters and optimized, and therefore an optimized three-dimensional cavern model is generated. Therefore, more accurate and flexible underground cavern three-dimensional modeling is realized.

Owner:中国水利水电第七工程局有限公司
Path planning method and device, automatic driving equipment and readable storage medium
PendingCN120043544AInstruments for road network navigationInternal combustion piston enginesPathPingControl engineering
The invention discloses a path planning method and device, automatic driving equipment and a readable storage medium. The path planning method comprises the steps that path information and the starting point position of automatic driving equipment are acquired, the path information comprises a path reference line, and a to-be-optimized path point is determined based on the path reference line; determining a Frenet coordinate system based on the starting point position and the path reference line; based on the to-be-optimized path point, a cost function is established under a Frenet coordinate system, the cost function is a quadratic function, a first penalty term is introduced into the cost function, and the first penalty term is used for representing the deviation between the to-be-optimized path point and the transversely-biased path reference line; and solving the cost function based on a preset constraint condition, and obtaining a target path corresponding to the minimum cost function. According to the invention, when the distance between the travelable boundary and the path reference line is small due to the fact that the obstacle partially occupies the travelable area, the planned target path can be far away from the obstacle, so that the driving experience is improved.

Owner:APTIV ELECTRONICS (SUZHOU) CO LTD
Czochralski method-based crystal growth interface shape detection method and device
The invention relates to a czochralski method-based crystal growth interface shape detection method and device. The method comprises the steps that: a seed crystal temperature T and an interface electromotive force U at the same time in a crystal growth process are collected, and a T-U curve of the interface electromotive force U changing with the seed crystal temperature T is obtained; the change trend of the shape of a crystal growth interface in real time is judged by observing the deviation between the T-U curve and a reference line, wherein the reference line is a straight line passing through the starting point of the T-U curve, and the slope of the straight line is the Seebeck coefficient of the crystal. The invention also relates to a device used by the method. The detection method provided by the invention can detect the change trend of the shape of the crystal growth interface in real time in the crystal growth process, and can be applied to Czochralski method growth equipment for various single crystals such as lithium niobate, lithium tantalate, sapphire, yttrium aluminum garnet and the like.
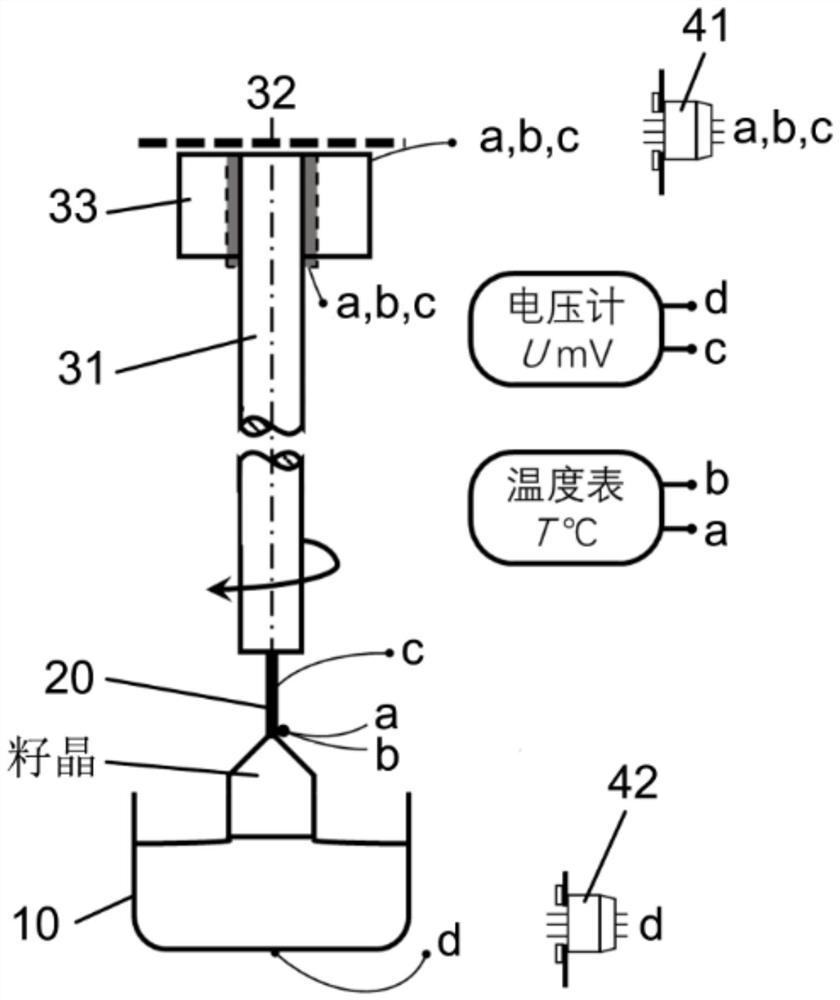
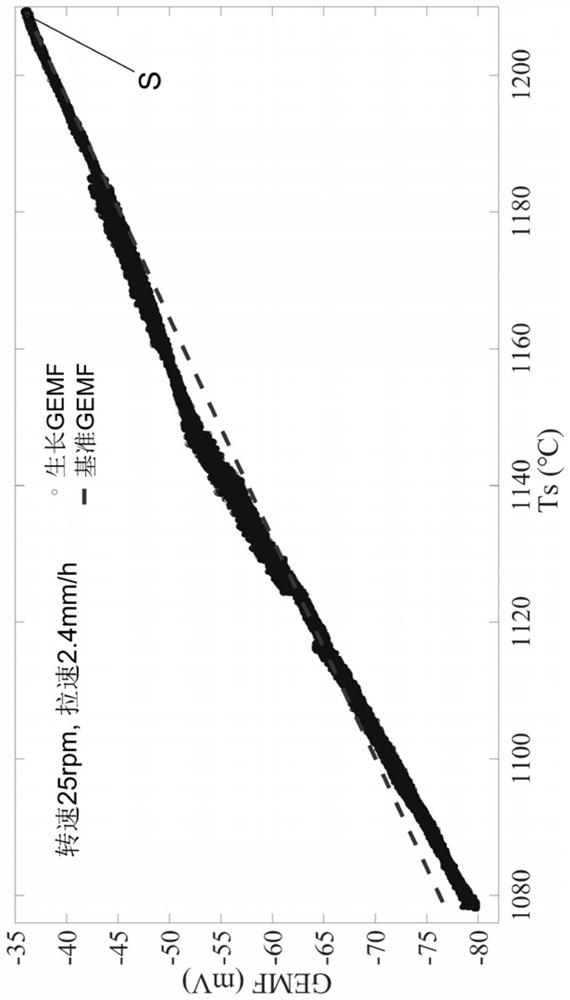
Owner:SUN YAT SEN UNIV
Global reference line generation method for autonomous vehicle and related device
The invention discloses a global reference line generation method for an automatic driving vehicle and a related device, and relates to the technical field of automatic driving navigation, and the method comprises the steps: generating a collision-free original path of the vehicle based on an improved A * algorithm according to a starting point position and a terminal point position of the vehicle in a grid map; removing redundant points in the collision-free original path of the vehicle to obtain an original reference path; numerical smooth optimization is carried out on discrete points of the original reference path, and a cubic spline interpolation method is adopted to generate a basic reference line meeting the geometric continuity of the vehicle; establishing a Frenet coordinate system based on the basic reference line, and carrying out transverse and longitudinal motion primitive sampling to obtain a vehicle kinematics constraint and a boundary constraint; according to the constraint, establishing a quadratic programming multi-objective optimization function; and solving the quadratic programming multi-objective optimization function to obtain a global reference line. According to the invention, the robustness and security of reference line generation in a complex scene can be improved.

Owner:BEIJING INST OF TECH
Battery cell detection method, battery cell detection device and battery cell deviation correction method
The invention relates to the technical field of batteries, and discloses a battery cell detection method, a battery cell detection device and a battery cell deviation rectifying method.The battery cell detection method comprises the steps that an end face image of a battery cell is obtained, two feature areas which are in one-to-one correspondence with tabs of two polarities are recognized, a datum point of the center of the end face is determined according to the end face image, and the datum point of the center of the end face is obtained; the two feature regions are respectively arranged on two sides of the reference point; rotating the end face image to enable the arrangement direction of the two characteristic areas and the reference line to form a set included angle, enabling the reference line to pass through the reference point, and initially adjusting the angle of the end face image to enable the two tabs with opposite polarities to be located in the middle position between the two forbidden areas theoretically; the two prohibited areas are not overlapped with the two prohibited areas under the condition that the alignment degree meets the requirement; and judging whether the two characteristic areas are overlapped with the two prohibited areas, if yes, judging that the battery cell is unqualified, preventing the battery cell with poor alignment from flowing out, and the two prohibited areas are located on the reference line and symmetrically distributed on the two sides of the reference point.

Owner:CHINA AVIATION LITHIUM BATTERY RES INST CO LTD +1
High-frequency vehicle track map matching method
PendingCN119555093Areduce inputReduce retrieval overheadMathematical modelsInstruments for road network navigationPattern recognitionOriginal data
The invention discloses a high-frequency vehicle track map matching method, which comprises the following steps of: (1) dividing a track T to be matched into a plurality of sub-tracks based on a reference line distance, and extracting key track points in the sub-tracks; (2) extracting a road where the key track point is located and a road type of the road, filtering the extracted road based on the road type, and storing filtered road data by adopting an R-Tree structure; and (3) matching an optimal matching path of the track T to be matched from the road data stored in the R-Tree structure through a hidden Markov probability matching model. From the perspective of reducing the scale of original data, trajectory and road network data are simplified. Then, space and direction analysis is carried out on the simplified trajectory, a micro-region splicing strategy is adopted to accelerate shortest path search, and a path deviation function is designed to improve the topology of a matching result; in addition, the extraction process of track motion key points is refined by fusing more road semantic information, so that a better matching result is obtained.

Owner:ANHUI NORMAL UNIV
Space field prediction method, device and equipment based on large model and weight loss function
The invention discloses a space field prediction method, device and equipment based on a large model and a weighted loss function, and relates to the field of fluid space field dynamic prediction. The method comprises the following steps: carrying out unstructured grid division on an object model for generating a three-dimensional fluid space field, simulating to generate space field data of an irregular grid at a plurality of historical moments, and mapping the space field data into a regular grid; calculating a time sequence mutual information amount of any two historical moments, and reserving space field data of the historical moments with the time sequence mutual information amount greater than a time sequence dependency degree threshold so as to assist in forming a training data set; determining the weight of each regular grid according to the Euclidean distance between each regular grid and the analysis reference line, and obtaining a weighted loss function; training a hybrid convolutional network according to the training data set and the weighted loss function, and constructing a large space field prediction model; and an iterative prediction mechanism is adopted to obtain space field distribution at future moments. The precision, efficiency and adaptability of dynamic prediction of the fluid space field can be improved.

Owner:NORTH CHINA ELECTRIC POWER UNIV
Snake-arm robot and joint therefor
A snake-arm robot assembly may include a first link and a second link with a joint formed therebetween including first and second contact portions in rolling contact with one another to allow the first and second links to pivot with respect to one another. The first and second contact portions are configured to contact one another at first and second contact points corresponding to a first orientation and third and fourth contact points corresponding to a second orientation. The joint may be configured such that a line of action of a net force acting on the joint is incident with a first reference line extending between the first and second contact points with the links in the first orientation, and the line of action is incident with a second reference line extending between the third and fourth contact points when the links are in the second orientation.

Owner:OLIVER CRISPIN ROBOTICS +1
Planning algorithm design fusing intention and target trajectory prediction
According to the invention, a planning algorithm design fusing intention and target trajectory prediction is realized, and the state information of the vehicle under the Frenet coordinate system is obtained in real time through mutual conversion between the Cartesian coordinate system and the Frenet coordinate system; determining a driving reference line of the vehicle by using the global path, and predicting a driving track of the dynamic obstacle by fusing a driving intention and a target track prediction network model; planning a track and a speed by adopting a dynamic planning and quadratic planning algorithm; and integrating the tracks of the current frame and the planning frame through a polynomial splicing technology, and transmitting the integrated track to a track tracker.

Owner:GUILIN UNIV OF ELECTRONIC TECH
Reference line generation method, automatic driving method, device, equipment and vehicle
PendingCN120122659AVehicle position/course/altitude controlPosition/direction controlSimulationMotion parameter
The invention provides a reference line generation method, an automatic driving method and device, equipment and a vehicle, and relates to the field of artificial intelligence, in particular to the field of automatic driving. According to the specific implementation scheme, for at least one obstacle located in a target area in a road, the category of the obstacle is determined according to a first motion parameter of the obstacle in a historical time period, and the category of the obstacle represents the relative relation between the obstacle and a target vehicle; under the condition that the at least one obstacle comprises the target obstacle belonging to the target category, determining any candidate node in a plurality of candidate nodes determined for the position of the target vehicle, and determining the total cost value of the candidate nodes according to the historical driving track of the target obstacle and the second motion parameter of the candidate node; determining a target region reference line according to a target node determined by using the total cost values of the plurality of candidate nodes; wherein the target area reference line is used for planning a target driving track of the target vehicle.

Owner:APOLLO INTELLIGENT DRIVING (BEIJING) TECHNOLOGY CO LTD
Navigation reference line generation method and apparatus, and electronic device
The invention provides a navigation reference line generation method and device and electronic equipment. The method comprises the following steps: acquiring dynamic target features, static target features and navigation features around a target vehicle; according to the dynamic target features, the static target features and the navigation features, determining fusion self-vehicle features; performing fusion processing on the navigation features and the fusion self-vehicle features to obtain long-distance self-vehicle navigation features; predicting track features of the target vehicle according to the fused vehicle features to obtain predicted track features; and determining a target navigation reference line according to the predicted trajectory features and the long-distance self-vehicle navigation features. According to the method, the navigation features and the fusion self-vehicle features are fused, so that the global navigation target and the local driving environment are organically combined, the target navigation reference line is determined by predicting the trajectory features and the long-distance self-vehicle navigation features, and the future driving trend and global navigation requirements of the vehicle are fully considered; and the generated navigation reference line is accurate and reliable.

Owner:GUANGZHOU AUTOMOBILE GROUP CO LTD
Road longitudinal slope estimation method based on unmanned aerial vehicle aerial photography video
A road longitudinal slope estimation method based on unmanned aerial vehicle aerial photography video includes: collecting and correcting the traffic flow video of the road; taking the center line of the road as the reference line, extracting pixels on the reference line, and outputting the pixel gray space-time image on the reference line; performing the contour extraction of pixel gray space-time image; through the trajectory contour information, obtaining the complete trajectory data set; identifying the vehicle speed change point by using the energy distribution of wavelet transform; constructing the data set of road slope estimation, and based on the assumption of the actual length distribution of road pixels and the value of road longitudinal slope, applying a Bayesian network and a machine learning algorithm to iteratively obtain an expected value and variance of the actual length of the road pixel point and an estimated value of the road longitudinal slope.

Owner:HEFEI UNIV OF TECH
Robot welding positioning method based on least square method
ActiveCN120038492AProgramme-controlled manipulatorWelding/cutting auxillary devicesThree-dimensional spaceClassical mechanics
The invention relates to a robot welding positioning method based on a least square method. The robot welding positioning method comprises the following steps that firstly, a discrete sampling point set of the edge contour of a workpiece to be welded is obtained through linear array scanning; performing curve fitting on the sampling point set by using an LLS algorithm to determine a reference line and calculate a deviation value, and performing down-sampling and introducing a weight factor to balance the influence of the sampling points during fitting; converting the polar coordinate data into a coordinate point set under a Cartesian coordinate system based on the datum line; a three-dimensional space welding track dynamic compensation model is constructed, specifically, a segmented cubic spline interpolation algorithm is adopted for smoothing a coordinate point set to generate a weld joint reference curve, thermal deformation is collected through a laser displacement sensor to establish a temperature-deformation coupling compensation matrix, and a corrected target path equation is generated through superposition operation; and the robot welding arm is controlled to work according to the corrected target path equation, so that various factors in the welding process are effectively coped with, and the welding quality and efficiency are improved.

Owner:SHENZHEN LAIYISHI AUTOMATION SYST INTEGRATION CO LTD
Tab excess material measuring method, device and system
The invention provides a tab excess material measuring method, device and system, and the method comprises the steps: firstly positioning a tab region of a tab image based on a gray threshold method and a morphological method, then judging the vertex angle shape of a tab based on the position coordinates of the tab region in the tab image, and then generating a boundary reference line of each boundary of the tab region; according to the intersection point position between the boundary reference lines, a plurality of detection areas capable of covering each boundary line of the tab area are generated, and then a gray threshold method and morphological operation are performed in the detection areas, so that the excess material boundary and the shape of each boundary are obtained. According to the tab excess material measurement method, excess material measurement of the corresponding tab, excess material determination and excess material size measurement can be completed only by shooting the to-be-detected tab image through the image acquisition device, in addition, the tab boundary is determined through the gray threshold value in the detection process, and therefore detection and measurement of tabs of different shapes can be met.

Owner:GUANGZHOU EHOLLY INTELLIGENT EQUIP CO LTD
Proximity-based generation of surface textures for simulated environmental systems and applications
PendingDE102025118083A1Cosmonautic condition simulationsDesign optimisation/simulationEnvironmental systemsRoad map
In various examples, a simulation platform generates a simulated driving environment by processing road map data to derive the location of wear-related visual artifacts for sections of a lane surface. Using map data, the simulation platform generates texture maps for aesthetic road rendering, which are used to apply textures to a 3D polygon topology mesh. The simulation platform generates visual artifacts representing the wear and tear of the road surface based on a calculation of one or more lane feature distances derived from the map data. The simulation platform calculates distances associated with reference line data derived from an image to render a texture of one or more lane features.The spacing is used to determine how the appearance of the texel is adjusted to include wear-related visual artifacts when displayed on a lane of the simulated driving environment.

Owner:NVIDIA CORP
Image encoding / decoding method and apparatus
An image encoding / decoding method and apparatus according to the present invention may: determine an intra prediction mode of a current block; determine one or more reference lines of the current block from among a plurality of reference line candidates available for the current block; generate a prediction sample of the current block on the basis of the intra prediction mode and the one or more reference lines, which have been determined; and correct the generated prediction sample.

Owner:KT CORP
Method and apparatus for determining the path of a concrete diagonal crack tip
ActiveCN116337895BMaterial analysis using microwave meansRadio wave reradiation/reflectionDiagonal crackRadar
The present application relates to a kind of method and device for judging the trend of concrete oblique crack tip, fill metal powder in the crack to be measured;Determine the beginning and end point of crack trend according to the opening trend of crack surface to be measured, draw the center line of the connecting line of beginning and end point as the first measuring line, respectively from the two end points of the first measuring line along the first measuring line to crack opening position detection using electromagnetic wave radar detector, record the position and depth of the first fluctuation point on radar development map;With the first measuring line as reference line, rotate to make several new measuring lines, obtain the position and depth of the first fluctuation point of each new measuring line;Fluctuation point is sorted according to measuring line sequence, draw the connecting line diagram, i.e. the trend curve of oblique crack tip.The present application is based on the essential characteristics such as the height and form of oblique crack tip position, combined with the measurement mode from far to near, multi-angle, multiple measuring points and the reflection law of radar wave by metal powder, the position and depth of multiple points of concrete oblique crack tip are measured, and then the trend of crack tip is effectively judged.

Owner:NANJING HYDRAULIC RES INST
Commodity bar code blank area comparator and detection method
ActiveCN119374446AMechanical measuring arrangementsManufacturing computing systemsBarcodeReference line
The invention discloses a commodity bar code blank area comparator and a detection method, and belongs to the technical field of bar code quality detection. The comparator comprises a transparent comparison ruler body, the surface of the comparison ruler body is provided with an X axis and a Y axis which are perpendicular to each other and intersect with each other, the two sides of the X axis serve as a left empty measurement area and a right empty measurement area respectively, and the left empty measurement area and the right empty measurement area are divided into a Z value measurement part and a blank area measurement part by the Y axis respectively. The two Z value measuring parts of the left empty measuring area and the right empty measuring area are adjacent to each other; the intersection point of the X axis and the Y axis is used as an original point, and the half shafts, located on the two sides of the original point, of the X axis and the Y axis are respectively provided with scale marks; the two Z value measuring parts are respectively provided with a multiplying power reference line, and the slopes of the two multiplying power reference lines are respectively a preset ratio of the width of the left blank area of the bar code to the Z value of the bar code and a preset ratio of the width of the right blank area of the bar code to the Z value of the bar code. According to the invention, the efficiency of barcode blank area width detection can be improved.

Owner:NANJING MUNICIPAL INSTITUTE (NANJING ORGANIZATION ORGANIZATION CODE MANAGEMENT CENTER)
Mine car path planning method, device and equipment based on reference line and storage medium
The invention relates to the technical field of automatic driving, and discloses a tramcar path planning method, device and equipment based on a reference line and a storage medium. According to the method, an improved A * search algorithm is combined with reference line discretization and smoothing processing, the node expansion number is reduced, the path smoothness is optimized, and the tramcar path planning efficiency is improved. Meanwhile, a double-factor heuristic function and dynamic constraint verification are utilized to ensure that the path is safe and feasible, and the method has the advantages of improving path planning efficiency, reducing path fluctuation, meeting special terrain and dynamic constraint requirements of a mining area and ensuring that the mine car stably travels along a predetermined reference line.

Owner:LUOBO NETWORK (HANGZHOU) INFORMATION TECHNOLOGY CO LTD
Ground satellite signal distributed cooperative processing method and system
The invention provides a ground satellite signal distributed cooperative processing method and system, and relates to the technical field of communication, and the method comprises the steps: extracting a user MAC address hash value, an emergency priority code and a spectrum occupancy matrix from a synchronous network, and generating a triple feature vector; transmitting the triple feature vectors through a double-layer Mesh network, selecting two reference target points with fixed geographic coordinates on the ground of the disaster area, obtaining three-dimensional coordinates of the reference target points, and constructing a space reference straight line; according to the real-time position data of each node, calculating a vertical projection distance from each node to the space reference straight line, and generating a node offset parameter; and dynamically generating a refraction correction coefficient of the signal propagation path based on a comparison result of the node offset parameter and a preset threshold value, and when the offset exceeds the threshold value, increasing a correction weight by adopting a piecewise linear interpolation method. According to the invention, high-reliability and low-delay emergency communication coverage can be realized.

Owner:BEIJING SIGONG HUIZHI TECHNOLOGY CO LTD
A vehicle obstacle avoidance trajectory planning method, system, vehicle and storage medium
ActiveCN116118780BInstruments for road network navigationInternal combustion piston enginesNatural coordinate systemClassical mechanics
The application relates to the technical field of automatic driving of vehicles, and provides a vehicle obstacle avoidance trajectory planning method, a vehicle obstacle avoidance trajectory planning system, a vehicle and a storage medium.The method comprises the following steps: obtaining coordinate point information of a lane line and coordinate point information of a lane center line according to vehicle positioning information; taking the lane center line of the lane where the vehicle is located as a reference line, and converting the position, heading, speed and acceleration of the vehicle into a longitudinal position, a lateral offset, a lateral speed, a longitudinal speed, a lateral acceleration and a longitudinal acceleration in a frenet coordinate system; taking obstacle information, if there is an obstacle, converting the obstacle coordinates into S obs ,L obs , if there are multiple obstacles, converting the coordinates of each obstacle into S obsi ,L obsi , and calculating a target point through dynamic programming by means of point sampling; converting the target point into coordinates in a natural coordinate system, smoothing the coordinates through a smoothing algorithm to obtain a trajectory point set, and fitting the trajectory point set to generate a trajectory equation. The application has a simple calculation process and lower cost.

Owner:CHONGQING CHANGAN TECH CO LTD
Image encoding / decoding method based on multiple reference lines, method for transmitting bitstream, and recording medium on which bitstream is stored
An image encoding / decoding method, a bitstream transmission method, and a computer-readable recording medium on which a bitstream is stored are provided. The method by which an image decoding device decodes an image, according to the present disclosure, may comprise: generating prediction values obtained by predicting a first reference line for the current block on the basis of each of a plurality of reference lines for the current block; calculating errors between the respective prediction values and a restoration value of the first reference line; and deriving, on the basis of the errors, at least one second reference line to be used for intra prediction of the current block from among the plurality of reference lines.

Owner:LG ELECTRONICS INC
Reference line generation method in vehicle driving path planning and electronic equipment
The invention discloses a method for generating a reference line in vehicle driving path planning and electronic equipment, and the method comprises the steps: obtaining initial data corresponding to an automatic driving vehicle, the initial data comprising driving map information, historical driving track information and vehicle parameter information; preprocessing the initial data to obtain target data; according to the target data, constructing boundary constraint information required by optimization based on the environment information; according to the initial reference line and the target boundary constraint information, generating target input information corresponding to a target reference line optimizer, and inputting the target input information to the target reference line optimizer, so that the target reference line optimizer performs reference line optimization processing according to the target input information to generate corresponding target output information, the target output information comprises a target reference line of the autonomous vehicle corresponding to a target driving road in the driving environment. Therefore, the reasonability and accuracy of the reference line can be improved.

Owner:NULLMAX INC
Tilt-rotor aircraft trajectory optimization method, device, equipment and medium
ActiveCN119759067AVehicle position/course/altitude controlPosition/direction controlFlight vehicleNon linear dynamic
The invention relates to a tilt-rotor aircraft trajectory optimization method and device, equipment and a medium. The method comprises the following steps: establishing a flight equation of a distributed power tilt-rotor aircraft, formulating flight criteria of forward transition and backward transition, and constructing a dynamic flight feasible region; in the dynamic flight feasible region, establishing a allowance feasible reference line which takes the flight speed as an independent variable and takes the tilt angle as a dependent variable, and constructing a longitudinal motion model; defining an objective function of transition process trajectory optimization in combination with a allowance feasible reference line and performance requirements, and defining an actuator range constraint and a system performance constraint; an aircraft is endowed with an initial state, a nonlinear dynamic optimal control problem is converted into a Bolza type optimal control problem, and a longitudinal motion model meeting flight criteria and ideal control variables meeting actuator range constraints and system performance constraints are solved to minimize a target function. By adopting the method, the transition safety of the tilt-rotor aircraft can be improved.

Owner:NAT UNIV OF DEFENSE TECH
Clock part etching quality detection method and system
ActiveCN119600024Aimprove accuracyImage analysisManufacturing computing systemsAlgorithmReference line
The invention relates to the technical field of etching quality detection, in particular to a clock part etching quality detection method and system. The method comprises the steps of obtaining a surface image of a clock etching piece; determining an etching connected domain based on the gradient distribution condition and the position distribution of pixel points around each pixel point in the surface image; obtaining each characteristic line segment according to the gray scale of the pixel points around the pixel points in the etching connected domain; determining a change direction vector of each feature line segment according to the gray values of the pixel points on each feature line segment and the adjacent pixel points, and further obtaining a reference line and a comparison line; and obtaining a direction change deviation factor according to the change direction vector difference between the reference line and the comparison line of each feature line segment, the change direction vector difference between each feature line segment and the reference line segment thereof, and the change direction vector difference between each feature line segment and the comparison line thereof, and further screening an etching region of a suspected defect. According to the invention, the accuracy of the etching quality detection result of the clock spare part is improved.

Owner:SHEN ZHEN SUNWAY IND CO LTD
Cursor position determination method and remote control equipment
ActiveCN119342258ASelective content distributionInput/output processes for data processingComputer hardwareRemote control
The embodiment of the invention provides a cursor position determination method and remote control equipment, and the method comprises the steps: under the condition that the pointing direction of the remote control equipment deflects, the remote control equipment determines a first deflection angle of the pointing direction of the remote control equipment relative to a first reference line, and the remote control equipment determines the pointing direction of the remote control equipment according to the first deflection angle and a first virtual cambered surface; a first offset distance is determined, the center position of the first virtual cambered surface is located on the first reference line, the tangent line of the center position of the first virtual cambered surface is perpendicular to the first reference line, and the remote control device determines the cursor position of a cursor corresponding to the remote control device in the screen device based on the center position of the screen device and the first offset distance. According to the method, when the distance between the remote control equipment and the screen equipment is different or the pointing direction of the remote control equipment is different, the remote control equipment is deflected by the same angle, the moving distance of the cursor on the screen equipment is still the same, and a user can accurately control the moving precision of the cursor.


Owner:HUAWEI TECH CO LTD
Multi-view three-dimensional reconstruction driven cattle body size on-line measuring method
The invention discloses a multi-view three-dimensional reconstruction driven cattle body size online measurement method, and relates to the technical field of animal husbandry three-dimensional measurement, and the method comprises the steps: extracting a ground reference plane, a segment elevation function, a guardrail reference line, a segment guardrail spacing, a periodic pitch and a hoof ground contact event, and generating a calibration opportunity score in combination with a pixel-level quality weight map; in the sliding window factor graph, jointly solving an external parameter rotation matrix, an external parameter translation vector and a global scale by taking the prior as a constraint, and outputting an uncertainty matrix; implementing hierarchical self-recovery according to the comprehensive health degree and the score, and replacing safe writing with double buffer atoms; carrying out weighted splicing under a unified measurement coordinate and carrying out profile robust measurement, forwards transmitting uncertainty to a body size layer and supporting individual multi-time column-passing convergence; the method is suitable for channel visibility interruption and structure variable scenes, and under the condition of uninterrupted release, measurement consistency is kept and auditable results are output.

Owner:YUNNAN ACAD OF GRASSLAND ANIMAL SCI