

Patents
Literature
145414 results about "Control system" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
A control system manages, commands, directs, or regulates the behavior of other devices or systems using control loops. It can range from a single home heating controller using a thermostat controlling a domestic boiler to large Industrial control systems which are used for controlling processes or machines.
Production and energy system based on new energy-powered submerged arc furnace, and related control method
PCT designated stage expiredWO2025043459A1Single network parallel feeding arrangementsAc network load balancingThermodynamicsEnergy control
The present invention relates to a production and energy system based on a new energy-powered submerged arc furnace, and a related control method. The production and energy system comprises a power transmission and distribution system, a renewable energy power generation system, an energy storage system, and a submerged arc furnace-based production system. The power transmission and distribution system is respectively connected to the renewable energy power generation system, the energy storage system, and the submerged arc furnace-based production system. The production and energy system further comprises an energy control system. The energy control system comprises: an integrated regulation and control system used for performing integrated regulation and control on the production and energy system by means of the power transmission and distribution system; a renewable energy power generation control system used for controlling operation of the renewable energy power generation system; an energy storage control system used for controlling operation of the energy storage system; and a submerged arc furnace-based production control system used for controlling operation of the submerged arc furnace-based production system. Compared with the prior art, the present invention has the advantages of optimizing energy utilization, achieving environmental protection and low-carbon development, improving the stability and reliability of the energy system, etc.

Owner:YUANJIAN WIND POWER JIANGYINENVISION ENERGY CO LTD +1
Ancient building risk prediction management and control method and system based on large model
ActiveCN119624136Aachieve perceptionDynamic response to risk changesGeometric CADData processing applicationsData acquisitionMulti source data
The invention discloses an ancient building risk prediction management and control method and system based on a large model, and relates to the technical field of ancient building protection. An ancient building risk prediction management and control system based on a large model comprises a multi-source data acquisition module, a multi-modal data fusion module, a large model risk prediction module, a risk assessment and early warning module, a digital twinborn dynamic management and control module and a repair decision module. According to the method, the structure state data, the visual image data and the environment data are fused, so that the state of the historic building is comprehensively perceived; the self-supervised learning pre-trained ViT-GPT model is combined with the LSTM time sequence model, so that the time sequence analysis capability and the multi-modal data processing capability of risk prediction are remarkably improved, the future damage probability and the risk trend of the historic building can be accurately predicted, and the defects of the prior art in long-time span risk prediction are overcome.

Owner:PUTIAN UNIV
Aerospace intelligent manufacturing large model construction method
The invention discloses an aerospace intelligent manufacturing large model construction method, which comprises the steps of collecting original data, performing preprocessing and data association, and constructing an aerospace intelligent manufacturing database; establishing a knowledge acquisition and structured conversion assembly line, a multi-dimensional associated domain knowledge graph, a knowledge quality control system and a dynamic updating mechanism, and constructing a professional knowledge base; aligning the cross-modal manufacturing data to generate a corpus; combining base general large model pre-training, injecting terminology semantics and multi-modal association capability, and completing knowledge migration; based on the pre-trained aerospace intelligent manufacturing large model, constructing an aerospace manufacturing cognitive agent, and forming a complex engineering problem solving framework; professional ability is optimized through a two-stage progressive multi-task training strategy, and dynamic adaptation of a production environment is realized in combination with an online learning and incremental updating mechanism. The intelligent level of aerospace intelligent manufacturing is remarkably improved.

Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Industrial robot walking control system based on obstacle recognition
ActiveCN120595816AVehicle position/course/altitude controlPosition/direction controlDecision modelEnvironmental perception
The invention relates to the technical field of industrial robots, in particular to an industrial robot walking control system based on obstacle recognition. Comprising an environment sensing unit; the obstacle analysis and decision-making unit is used for processing the multi-dimensional data output by the environment sensing unit based on a deep reinforcement learning framework, accurately identifying static obstacle and dynamic obstacle types, motion trails and interaction influences, constructing a two-dimensional decision-making model of static obstacle avoidance and dynamic obstacle avoidance, and carrying out obstacle avoidance and obstacle avoidance on the basis of the two-dimensional decision-making model. A differential obstacle avoidance strategy is triggered; the path planning unit is based on a dynamic game path algorithm under space-time constraint; and an instruction transceiving unit. Through the multi-modal fusion sensing technology and the adaptive parameter adjustment module, space-time alignment and feature fusion of multi-source data such as three-dimensional point cloud, texture features and vibration spectrum are realized, a high-dimensional environment state model is constructed, and the problem of insufficient data fusion depth in the prior art is effectively solved.

Owner:JIANGSU ZHENG MAO MFG CO LTD
Vehicle idling start and stop control system and method
InactiveCN108622068AReduce idle timeLow costExternal condition input parametersState of chargeFlywheel
The invention discloses a vehicle idling start and stop control system and method. The control system judges whether a vehicle has idling start and stop conditions by monitoring the water temperatureof an engine, the capacity of a storage battery, a safety belt and other information, judges whether the vehicle has conditions of stopping the engine by monitoring the rotating speed of the engine, the speed of the vehicle, the brake air pressure and other conditions, and judges whether the vehicle has conditions of starting the engine by monitoring the gear of a gearbox, the speed of the vehicle, a hand brake and other information. When the relevant conditions are met, start and stop work signals are sent to the engine though a CAN bus. In order to guarantee the reliability of frequent startand stop of the engine, the system strengthens flywheel gear rings of a starter and the engine. In order to ensure that the battery does not lose power, a storage battery capacity sensor is added tothe system on the basis of increasing the capacity of the storage battery, and the idling start and stop are allowed when the state of charge (SOC) of the storage battery satisfies a safe starting threshold. The idling start and stop control system has advantages of low cost and high reliability, and is especially suitable for commercial vehicles.
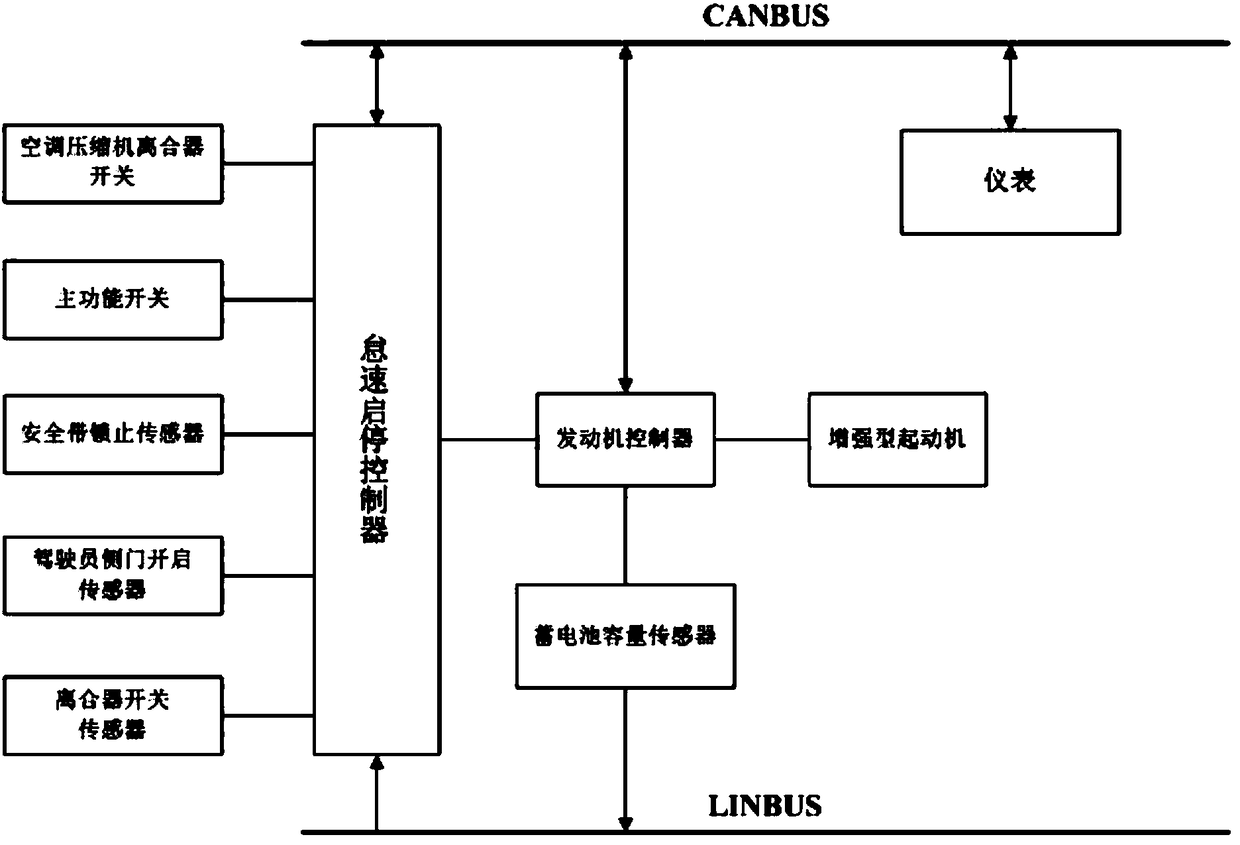
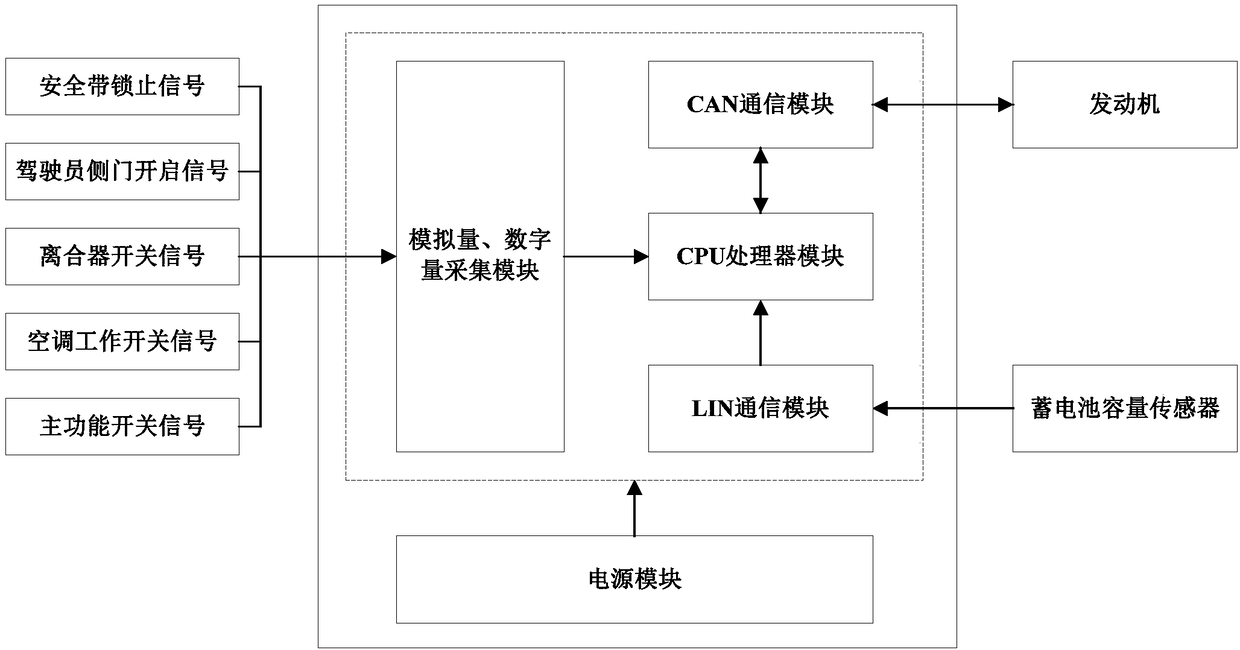
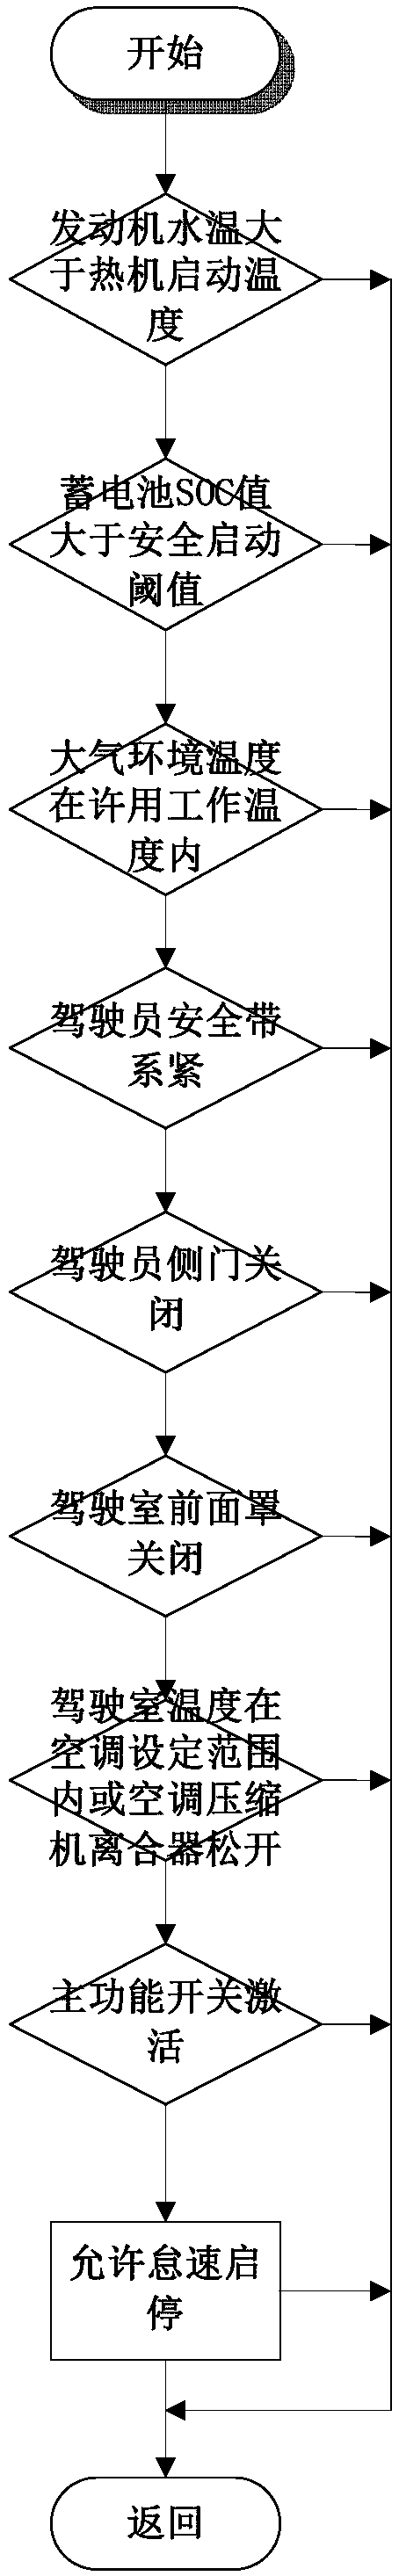
Owner:SHAANXI AUTOMOBILE GROUP
Method, system and device for monitoring multifunctional parameters of direct-current drilling machine
The invention discloses a method, a system and a device for monitoring multifunctional parameters of a direct-current drilling machine, and relates to the technical field of manufacturing of industrial automatic control system devices. The method, system and device for monitoring the multifunctional parameters of the direct-current drilling machine comprises the steps that S1, various data are collected and subjected to standardization and normalization processing, and a standardized working condition data set is constructed; s2, multi-dimensional disturbance characteristics are analyzed, and the stability level of a drilling system is quantified; s3, evaluating a dynamic evolution trend of a working condition, and updating a risk level, a response strategy and a monitoring priority; and S4, identifying an abnormal state based on the key disturbance value and the trend evolution value, and generating a monitoring report. The problems that an existing direct current drilling machine display device is insufficient in key working condition feature extraction capacity, deep understanding and trend analysis of the equipment operation state are difficult to support, and then the early warning timeliness and judgment accuracy of the abnormal state are limited are solved.

Owner:SHANGHAI CHENGXIANG ELECTROMECHANICAL EQUIP CO LTD
Automatic cooperative regulation and control system and method for smart home equipment
The invention relates to the technical field of smart home, and discloses an automatic coordinated regulation and control system and method for smart home equipment, and the system integrates a plurality of functional modules such as equipment access, environment perception and user behavior analysis. The equipment access module supports access of multiple protocols and endows the equipment with a unique identifier; the environment sensing module collects environment parameters in real time and compares the environment parameters with thresholds. The user behavior analysis module generates a user scene preference model by means of an algorithm, the cooperation strategy generation module synthesizes multiple factors to formulate a regulation and control strategy, and the dynamic priority management module allocates weights according to equipment and scene conditions. And the equipment control module executes the instruction and feeds back the state, and the abnormity detection module monitors the equipment state and triggers a strategy regeneration mechanism when abnormity occurs. The data storage module securely stores various data, and the user interaction module efficiently analyzes instructions. According to the invention, many problems of an existing smart home system are solved, automatic coordinated regulation and control of equipment can be realized, and user interaction experience is optimized.

Owner:NINGBO UTEC ELECTRIC CO LTD
Intelligent Internet of Things public security management and control system and method based on multi-source data fusion
The invention provides an intelligent Internet of Things public security management and control system and method based on multi-source data fusion, and belongs to the technical field of Internet of Things security. According to the system, unified collection and standardized processing of multi-source data are achieved by recognizing a system operation scene and loading corresponding model parameters and response strategies, and a unified semantic representation structure is constructed. And the system executes anomaly detection at an edge node, completes risk scoring and grading alarm judgment in combination with a semantic structure and anomaly feature information, and generates a control response instruction based on strategy matching. Meanwhile, dynamic optimization of the scoring model and identity authentication, behavior auditing and data compliance export in the operation process are supported. The system has intelligent identification, adaptive analysis and response closed loop capabilities, and improves the precision and credibility of public security management in the Internet of Things environment.

Owner:诚创智能科技(江苏)有限公司
Multi-layer distributed micro-grid control system and method based on edge cloud collaborative lightweight reinforcement learning
PendingCN120073869AResource allocationSingle network parallel feeding arrangementsEdge nodeElectric network
The invention relates to the technical field of micro-grid control, in particular to a multi-layer distributed micro-grid control system and method based on edge cloud collaborative lightweight reinforcement learning. The method comprises the following steps: a cloud management unit trains a DQN model by using historical environment data, generates a lightweight DQN model through pruning and quantification, issues the lightweight DQN model to an edge node unit, and formulates day-level and weekly-level optimization scheduling strategies based on a function layering + layering cooperation strategy; the edge node unit monitors electrical quantity and environmental parameters in real time through a sensor, deploys a lightweight DQN model to monitor abnormal conditions and trigger local early warning and emergency strategies, and makes a fast decision by using the lightweight DQN model; the micro-grid subgroup units collect data of the edge node units. According to the invention, through close cooperation of the edge node layer, the micro-grid subgroup layer and the cloud management layer, a distributed cooperative control mode of edge node real-time decision, subgroup cooperative management and cloud global optimization is realized.

Owner:YANTAI DEV ZONE DELIAN SOFTWARE CO LTD
Intelligent fault diagnosis method for numerical control machine tool
ActiveCN119472509Aimprove perceptionImprove efficiencyProgramme controlComputer controlNumerical controlData pack
The invention provides an intelligent fault diagnosis method for a numerical control machine tool, which is applied to a control system of the numerical control machine tool. The method comprises the steps of collecting multi-source sensor data in the operation process of the numerical control machine tool, wherein the multi-source sensor data comprises at least two of a vibration signal, a temperature signal, a current signal and a sound signal; performing preprocessing and feature extraction on the multi-source sensor data to obtain preprocessed data; based on the preprocessed data, constructing and training a machine tool dynamic model to obtain a target machine tool dynamic model; when abnormal operation of the numerical control machine tool is detected, fault state estimation is carried out based on the target machine tool dynamic model and a model prediction control method, and a fault estimation result is obtained; and based on the fault estimation result, constructing a fault evolution path by adopting a Monte Carlo tree search algorithm, and outputting a fault diagnosis result. The accuracy and efficiency of fault diagnosis of the numerical control machine tool can be improved.

Owner:SHENZHEN SHUOFANG PRECISION MASCH CO LTD
Multi-sensor fusion unmanned equipment agriculture monitoring method and system
InactiveCN119515029Asimple processLow investment and operating costsForecastingBiological modelsAgricultural engineeringInsect pest
The invention discloses a multi-sensor fusion unmanned equipment agricultural monitoring method and system, and belongs to the technical field of agricultural monitoring, and the method specifically comprises the steps: obtaining a farmland image and multispectral data through an image shooting device and a multispectral sensor carried by an unmanned aerial vehicle, and recognizing the features of diseases and pests through a deep learning model, generating a distribution diagram and statistical data, and performing early warning and risk assessment in combination with the multispectral data; formulating a pesticide management strategy according to an evaluation result, and pushing the pesticide management strategy to an unmanned equipment control system in real time; meanwhile, according to actual and operation requirements of the farmland, generating an optimal operation path by using a path planning algorithm, setting operation parameters, and allocating tasks by using a task allocation algorithm; in the operation process, environment changes are monitored in real time, an edge computing device is used for finding out abnormity in time and adjusting operation instructions, and efficient and accurate monitoring and intelligent operation management of farmland diseases and insect pests are achieved.

Owner:NANJING LANJIANG INTELLIGENT EQUIP TECH CO LTD
Automatic control method and system for plastic processing production line
InactiveCN120315399ATotal factory controlProgramme total factory controlAutomatic controlControl system
The invention relates to the technical field of production line control, and discloses an automatic control method and system for a plastic processing production line. The method comprises the steps of collecting technological parameters of a plastic processing production line and transmitting the technological parameters to a central control system to generate a database; multi-dimensional parameter correlation analysis is executed, a parameter and quality mapping relation is established through a CNN-LSTM hybrid network, and an optimization model is formed; calculating an optimal control parameter, generating a control strategy and issuing the control strategy to an execution unit; and monitoring a response result, updating the model in real time, and forming closed-loop adaptive control. According to the method, the mapping relation between the process parameters and the product quality is accurately established through the deep learning model, the optimal control parameters are automatically calculated, and closed-loop adaptive control based on production feedback is realized.

Owner:LUOYANG SHUANGZHENG PLASTICS CO LTD
Numerical control machine tool operation control system and double-station sawing and drilling integrated machine tool
InactiveCN119536129ARealize all-round monitoringImprove stabilityProgramme controlComputer controlNumerical controlDynamic models
The invention discloses a numerical control machine tool operation control system and a double-station sawing and drilling integrated machine tool, and relates to the technical field of numerical control machine tool operation. A multi-axis linkage state, a gas cylinder stress state, vibration frequency, cutting force and deformation data are acquired in real time through a data acquisition module; the dynamic modeling module constructs a digital twinborn model by using finite element analysis and real-time sensing data, and accurately simulates stress dynamic change and deformation trend; the intelligent error compensation module dynamically evaluates the multi-axis linkage precision by analyzing the machining data, generates an error compensation instruction and optimizes the operation parameters of the machine tool; the closed-loop feedback control module adjusts the cutting speed, the feeding depth and the clamping force in real time through a fuzzy logic algorithm, a closed-loop adjusting mechanism is formed, the machining precision and stability are greatly improved, the machining error and the workpiece surface damage risk are reduced, and the machining quality and efficiency of complex workpieces are effectively improved.

Owner:ZHEJIANG LANXI HAIJU INTELLIGENT EQUIP CO LTD
Remote monitoring and intelligent management and control system for fire-fighting equipment
The invention discloses a remote monitoring and intelligent management and control system for fire-fighting equipment, and belongs to the technical field of fire-fighting early warning, and the system specifically comprises the steps: deploying a multi-parameter sensor array, and enabling each sensor node to form a redundant monitoring network through a honeycomb topological structure; carrying out real-time fusion analysis on the sensor network data through an edge computing gateway, and triggering an abnormal region positioning module when detecting that any monitoring parameter exceeds a preset dynamic threshold value; the abnormal region positioning module constructs a three-dimensional thermodynamic diagram model based on the parameter gradient change of adjacent sensor nodes, and dynamically calculates the diffusion direction and the potential risk level of an abnormal region; the mobile inspection robot cluster receives the coordinates and risk parameters of the abnormal area, a multi-stage response path is automatically generated based on a building digital twin model updated in real time, a primary path quickly approaches along a preset main road, and a secondary path is dynamically adjusted according to field obstacle distribution; and the tail end path adopts a contact type detection module to recheck the abnormal area.

Owner:ANHUI HUIRUI ENG MANAGEMENT CO LTD
Affordance-based control system
Certain aspects of the present disclosure provide techniques and apparatus for processing data via a set of machine learning models to cause a device to perform a task. The method generally includes accessing data characterizing a physical environment in which a device is operating. A set of affordable actions is generated based on processing the data via a first set of machine learning models. A selected action to be performed in the physical environment is generated via a second set of machine learning models based on the set of affordable actions and a task. The device is then caused to execute the first selected action.

Owner:QUALCOMM INC
Intelligent building remote operation and maintenance management and control system based on large model and cloud edge collaborative architecture
InactiveCN120342896ANatural language translationSemantic analysisReverse proxySchema for Object-Oriented XML
The invention relates to the technical field of operation and maintenance management and control, and discloses an intelligent building remote operation and maintenance management and control system based on a large model and a cloud edge collaborative architecture, and the system comprises a configuration subsystem which is used for carrying out the reverse proxy and persistent connection configuration of edge gateway equipment in an intelligent building, and obtaining a TLS encryption bidirectional communication channel; the construction subsystem is used for constructing a cloud-edge-end three-layer cooperative computing architecture; the conversion subsystem is used for performing unified semantic abstraction and conversion on the heterogeneous protocol data to obtain semantic data in a standard JSON (JavaScript Object Notation) format; the rule processing subsystem is used for performing rule processing through a near-end decision engine of the edge gateway to obtain a local intelligent response result; the multi-dimensional analysis subsystem is used for carrying out multi-dimensional analysis through a cloud large model engine to obtain an equipment health score, a fault prediction result and an energy optimization strategy, seamless fusion and interoperation of heterogeneous system data are achieved through the system, and then global optimization and linkage control of the intelligent building are achieved.

Owner:SHENZHEN GEMDALE BUILDING ENG CO LTD
Abnormity detection and maintenance decision optimization method and system for automatic test equipment
InactiveCN120087939AMathematical modelsKnowledge representationQuantum evolutionary algorithmDecision model
The invention provides an anomaly detection and maintenance decision optimization method and system for automatic test equipment, and relates to the technical field of automation, and the method comprises the steps: deploying an edge calculation unit and a multi-level sensor network to collect equipment data, carrying out the fault diagnosis through a deep network model, and constructing a maintenance decision model in combination with equipment operation data. The model is input into a quantum enhancement dual-network system to calculate a reward value, and is used for training a maintenance strategy network under a federal reinforcement learning framework. And generating a maintenance resource configuration scheme through a quantum evolutionary algorithm, and generating a maintenance scheme through optimization of the multi-criterion evaluation model and the self-adaptive multi-target differential evolutionary algorithm. According to the scheme, a high-fidelity digital twin model and a multi-task deep transfer learning network are input for verification and updating, updated data are transmitted to a field control system through an industrial Internet of Things platform, and the updated data are recorded by using a block chain technology for updating a deep network model.

Owner:NANJING XINREN SOFTWARE TECHNOLOGY CO LTD
Control system for managing primary and secondary fusion circuit breaker
The invention belongs to the technical field of circuit breaker management, and discloses a control system for managing a primary and secondary fusion circuit breaker, and the system collects the electrical parameters, mechanical states and environmental conditions of the circuit breaker through multiple channels, and constructs a standardized operation data set; establishing a circuit breaker health characteristic spectrum based on deep characteristic learning; establishing an environmental adaptability control parameter library through environmental factor correlation analysis and multi-scene simulation; performing fault mode identification and predictive diagnosis in combination with the health characteristic spectrum, and generating a fault risk early warning matrix; optimizing a multi-circuit-breaker cooperative control strategy based on the early warning matrix, and generating an optimal control instruction sequence; and reliable execution and effect feedback of the control instruction are realized through security encryption verification and a hierarchical execution mechanism. The problems that a traditional circuit breaker control system is difficult in data integration, insufficient in environment adaptability, weak in fault prediction capacity, incomplete in cooperative control and the like are solved, and the safety and reliability of power grid operation are remarkably improved.

Owner:YIFA HLDG GRP
Satellite measurement and control data anomaly detection and intelligent diagnosis early warning method and system
InactiveCN119646586AEfficient integrationimprove accuracyBiological modelsInference methodsEngineeringNetwork model
The invention provides a satellite measurement and control data anomaly detection and intelligent diagnosis early warning method and system, and relates to the technical field of satellite measurement and control, and the method comprises the steps: obtaining multi-source heterogeneous data in a satellite measurement and control system, and carrying out the preprocessing of the multi-source heterogeneous data; constructing a multi-level space-time fusion network model, inputting the preprocessed multi-source heterogeneous data into the multi-level space-time fusion network model, and extracting high-dimensional space-time features; based on the extracted high-dimensional spatial-temporal features, designing a dynamic adaptive anomaly detection algorithm, and performing anomaly detection on the satellite measurement and control data; according to an anomaly detection result, performing intelligent diagnosis by using a pre-constructed multi-level satellite system knowledge graph; based on the intelligent diagnosis result, multi-level early warning information is generated; a distributed edge computing architecture is designed, and partial data processing and anomaly detection tasks are deployed to a ground station and a satellite end; and presenting the generated multi-level early warning information through a visual interface, and automatically triggering a corresponding emergency plan according to the early warning level.

Owner:西安衍舆航天科技有限公司
Induction control system of induction type LED illuminating lamp
ActiveCN119421297Ahigh sensitivityimprove intelligenceElectrical apparatusEnergy saving control techniquesControl systemEngineering
The invention relates to the field of inductive control of illuminating lamps, in particular to an inductive control system of an inductive LED illuminating lamp. The method comprises the following steps: the lighting scene module is used for identifying all LED lighting lamps in an area; calculating node positions of all the LED lighting lamps in the area one by one, and identifying use scenes in the area to construct a plurality of LED lighting scene sub-areas; the ambient light feature module is used for acquiring ambient light parameters of a scene sub-region; performing light spatial distribution tracking on the ambient light parameters of the scene sub-regions, and performing ambient light state feature mining to generate ambient light comprehensive state features; and the multi-area lighting cooperation module is used for carrying out dynamic light source output parameter adjustment and multi-area lighting cooperation smoothing on the plurality of LED lighting scene sub-areas based on the environment light comprehensive state characteristics so as to generate multi-area lighting cooperation control parameters. According to the invention, rapid and accurate induction control of the LED illuminating lamp is realized.

Owner:SHENZHEN BIAOMEI LIGHTING DESIGN ENG CO LTD
Unmanned aerial vehicle low-altitude intelligent traffic dynamic airspace management and control method and system
The invention provides an unmanned aerial vehicle low-altitude intelligent traffic dynamic airspace management and control method and system, and relates to the technical field of intelligent control, and the method comprises the steps: taking an electronic fence geographic coordinate set as a monitoring reference boundary, fusing ADS-B data, meteorological information and an unmanned aerial vehicle equipment state, generating a real-time risk thermodynamic diagram, and outputting a grading alarm instruction; receiving a real-time risk thermodynamic diagram and a grading alarm instruction, and combining wind speed prediction and dynamic airspace occupation data; when the grading alarm instruction is triggered, executing the following operations: constructing a route feasible solution space by taking a no-fly zone and a high-risk zone in the risk thermodynamic diagram as constraint conditions; and iterating an evolutionary path population through selection, intersection and mutation operations of a genetic algorithm by taking the lowest energy consumption as an optimization target, so as to output a global final obstacle avoidance bypassing path, and issuing a route updating instruction to an unmanned aerial vehicle flight control system. According to the invention, the utilization of airspace resources is maximized on the premise of ensuring safety.

Owner:HUNAN LIXIANG INTELLIGENT TECH CO LTD
Pentahedron machining center precision calibration method and system based on multi-sensor fusion
The invention relates to the technical field of program control systems, in particular to a pentahedron machining center precision calibration method and system based on multi-sensor fusion, and the method comprises the steps: a sensor system construction and calibration module is used for field calibration, drift correction and redundancy deployment to ensure data precision, and achieves the whole-course traceability of a calibration process through a block chain technology; the multi-source data preprocessing and fusion module is used for time-space synchronization of heterogeneous data and dynamic fusion of multi-source information; the intelligent modeling and state prediction module is used for performing real-time and multi-task prediction on key states such as tool wear and thermal deformation; based on the prediction result, the adaptive compensation and path optimization module is used for dynamically optimizing the tool path; meanwhile, through an online learning mechanism, the calibration model is continuously updated by utilizing a processing result; the distributed cooperative control module executes data processing and calibration algorithms locally and makes a cooperative decision with a numerical control system, and low-delay and intelligent response to machining abnormity is achieved.

Owner:ZHONGFU MECHANICAL & ELECTRICAL (ZHEJIANG) CO LTD
Systems and methods for entry point localization
A teleoperative system includes a first manipulator assembly, a second manipulator assembly, a first medical instrument movable by the first manipulator assembly, a second medical instrument movable by the second manipulator assembly, a first alignment component positioned on the first manipulator assembly, a second alignment component positioned on an entry port, and a control system configured to record a position of the first manipulator assembly in response to receiving a user input indicating that the first alignment component is aligned with the second alignment component. The second medical instrument is sized and shaped to fit and move within the first medical instrument.

Owner:INTUITIVE SURGICAL OPERATIONS INC
Patrol route self-adjusting method and system based on unmanned aerial vehicle inspection
ActiveCN120276483AVehicle position/course/altitude controlPosition/direction controlData setFeature extraction
The invention provides a patrol route self-adjusting method and system based on unmanned aerial vehicle patrol, and the method comprises the steps: firstly obtaining a multi-source environment perception data set of a target area, then carrying out the feature extraction of the multi-source environment perception data set, inputting a dynamic route planning model, generating an obstacle avoidance correction vector set and an environment adaptation parameter set, and carrying out the feature extraction of the multi-source environment perception data set; and carrying out spatial position offset compensation on the reference route based on the obstacle avoidance correction vector set to generate an initial correction path node set, carrying out path smoothness optimization processing on the initial correction path node set according to the environment adaptation parameter set to generate a final dynamic patrol route, and finally, carrying out dynamic patrol. The dynamic patrol route is converted into a waypoint control instruction stream which can be executed by the unmanned aerial vehicle flight control system, and the waypoint control instruction stream is transmitted to the airborne controller in real time to drive the unmanned aerial vehicle to execute the patrol task, so that dynamic self-adjustment of the unmanned aerial vehicle patrol route is realized, and the patrol flexibility and safety are improved.

Owner:DEYANG JINGKAI ZHIHANG TECH CO LTD
Portal crane grab bucket control system and method based on multi-sensor fusion
The invention discloses a portal crane grab bucket control system and method based on multi-sensor fusion, and particularly relates to the technical field of portal crane grab bucket control. Image acquisition equipment and multiple types of sensors are arranged in a portal crane operation area, a multi-dimensional input data set under a unified time sequence is constructed, an optimized visual detection model and an attention mechanism are combined, high-precision recognition and abnormity judgment of the grab bucket state are achieved, and the system not only can automatically plan a grabbing path and a posture adjusting instruction, but also can automatically adjust the grabbing posture of the grab bucket. And control parameters can be dynamically optimized according to the grabbing effect and pose feedback, the grab bucket recognition accuracy, the control stability and the system intelligence level are remarkably improved, and particularly higher robustness and reliability are shown in the small-size, complex-pose or multi-target operation environment.

Owner:AEROSPACE ELEVATOR CO LTD
Method for realizing high-efficiency low-consumption micro-aerobic hydrolytic acidification of petrochemical wastewater by regulating and controlling aeration rate in combination with space-time diagram neural network and reinforced learning
ActiveCN119430460AImprove predictive performanceImprove adaptabilityWater treatment parameter controlBiological treatment regulationAutomatic controlAeration rate
The invention discloses a method for realizing high-efficiency low-consumption micro-aerobic hydrolytic acidification of petrochemical wastewater by regulating and controlling the aeration rate in combination with a space-time diagram neural network and reinforced learning, and relates to a method for realizing high-efficiency low-consumption micro-aerobic hydrolytic acidification of petrochemical wastewater by regulating and controlling the aeration rate. The method comprises the following steps of: 1, collecting and cleaning data; 2, constructing a graph data set; 3, training the ST-GNN model; 4, constructing a deep Q reinforcement learning model; 5, the trained ST-GNN model is embedded into an automatic control system of a sewage treatment plant, and the model outputs the optimal aeration rate of the current time step and predicts the micro-aerobic hydrolytic acidification effect through interaction of the current working condition and historical data; and adjusting operation parameters of aeration equipment according to the output of the model, and carrying out hydrolytic acidification treatment. The method is high in regulation and control efficiency and low in operation error, and can be applied to the field of digital and intelligent management of sewage treatment plants.

Owner:NANJING TONGFANG WATER CO LTD
Dynamic balance system for wind, light, fire and nuclear storage integrated regulation and control of power grid in cold region
PendingCN119695852AForecastingPolyphase network asymmetry elimination/reductionData acquisitionGlobal optimization
The invention provides a dynamic balance system for wind, light, fire and nuclear storage integrated regulation and control of a power grid in a cold region, which relates to the technical field of power grid regulation and control and comprises an energy data acquisition and preprocessing module, a multi-energy coordinated regulation and control module, an energy storage system optimization management module, an energy scheduling optimization module, an intelligent decision and monitoring module and a system communication and safety module. A multi-level, multi-module and intelligent comprehensive framework is constructed, collaborative management and optimal scheduling of various energy sources are achieved, stable operation, efficient energy utilization and sustainable development of a cold region power grid are ensured, global optimization is achieved through deep reinforcement learning, local precise control is conducted through fuzzy logic, and the energy utilization efficiency is improved. The system can intelligently distribute the generated power of each energy source of wind, light, fire and nuclear storage according to the real-time state and environmental conditions of the cold region power grid, gives full play to the advantages of different energy sources, realizes the complementary utilization of the energy sources, realizes the collaborative optimization of multiple energy sources, and improves the utilization efficiency and stability of the energy sources.

Owner:PANJIN POWER SUPPLY COMPANY OF STATE GRID LIAONING ELECTRIC POWER SUPPLY +1
Intelligent operation and maintenance management and control system for information communication network
The invention discloses an intelligent operation and maintenance management and control system for an information communication network, and belongs to the technical field of communication. The system comprises the following modules: an intelligent sensing and data acquisition module which is responsible for real-time acquisition of multi-source network data, dynamic monitoring of cross-domain equipment states and conversion of heterogeneous data into a unified standard; the network intelligent analysis module integrates network performance prediction, fault risk assessment, abnormal behavior identification and security threat monitoring, and provides comprehensive network operation and maintenance insight; the intelligent resource scheduling module is used for realizing dynamic allocation of cross-domain network resources and ensuring efficient and safe utilization of the resources through multi-dimensional optimization and a real-time load balancing strategy; the intelligent decision support module is used for continuously optimizing an operation and maintenance strategy based on machine learning, analyzing a long-term operation trend and providing suggestions for management decisions; and the open integration and collaboration module provides integration of an open API interface and a third-party system, supports cross-domain collaboration management, and improves the flexibility and expansibility of the system.

Owner:东莞市大朗镇政务服务中心
Unmanned aerial vehicle real-time path planning system and method based on dynamic weight distribution and multi-source data fusion
ActiveCN120762452AVehicle position/course/altitude controlPosition/direction controlSimulationMulti source data
The invention relates to the technical field of unmanned aerial vehicle flight path planning, in particular to an unmanned aerial vehicle real-time path planning system and method based on dynamic weight distribution and multi-source data fusion. The system comprises a multi-source data fusion module, an integrated laser radar, a millimeter wave radar, a visual sensor and a Beidou positioning unit. The dynamic weight distribution module dynamically adjusts the weight coefficient of each sensor according to the environmental complexity, the threat level and the state of the unmanned aerial vehicle by adopting a mixed decision-making mechanism combining fuzzy logic and reinforcement learning; an improved RRT * algorithm and a Markov decision process are built in the real-time path planning module, and a global optimal path and a local obstacle avoidance track are generated by adopting a layered planning architecture; the unmanned aerial vehicle cooperative control module comprises a dual-redundancy flight control system and a dynamic obstacle avoidance unit; and the communication relay module supports 5G and low-orbit satellite dual-mode communication, updates an environment cognitive model of each unmanned aerial vehicle through federated learning, and realizes multi-source fusion real-time path planning based on dynamic weight distribution and the unmanned aerial vehicles.

Owner:四川电力设计咨询有限责任公司
Backlight effect image edge enhancement method based on intelligent identification
The invention relates to the technical field of image processing, and discloses a backlight effect image edge enhancement method based on intelligent identification, which comprises the following steps of: judging a field environment type; performing global optimization on the original image based on a set environment perception type enhancement mechanism according to the judged field environment type, and outputting a global pre-processing image; constructing a backlight area segmentation model for the globally preprocessed image; outputting a local enhanced image; designing a structure perception type local adaptive threshold algorithm for the local enhanced image, and outputting a binary image keeping structural continuity; extracting an edge image of the binarized image through an edge detection algorithm, and optimizing a topological structure of a contour in the binarized image; and comparing with a wood template processing standard feature library, outputting an edge quality evaluation result and feeding back to a processing control system. Defect detection and machining control depth linkage is achieved, passive detection is changed into active optimization, and the production efficiency and the yield are improved.


Owner:四川省建筑机械化工程有限公司