
Patents
Literature
14545 results about "Remote control" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
In electronics, a remote control or clicker is an electronic device used to operate another device from a distance, usually wirelessly. For example, in consumer electronics, a remote control can be used to operate devices such as a television set, DVD player or other home appliance, from a short distance. A remote control is primarily a convenience feature for the user, and can allow operation of devices that are out of convenient reach for direct operation of controls. In some cases, remote controls allow a person to operate a device that they otherwise would not be able to reach, as when a garage door opener is triggered from outside or when a Digital Light Processing projector that is mounted on a high ceiling is controlled by a person from the floor level.
Intelligent analysis and remote control algorithm based on digital twinning
The invention discloses an intelligent analysis and remote control algorithm based on digital twinning. The intelligent analysis and remote control algorithm comprises a digital twinning model building and dynamic updating module, an intelligent analysis algorithm module based on digital twinning, a self-adaptive remote control algorithm module and an algorithm process and implementation module. Through multi-dimensional modeling and data fusion, the precision of the digital twin model is improved, and the system state can be predicted more accurately. In combination with deep learning and a multi-objective optimization algorithm, intelligence and optimization of a control strategy are realized, and the operation efficiency and safety of the system are improved. Based on model predictive control and a distributed architecture, real-time and accurate remote control of a physical system is realized, and the dynamic adaptability of the system is enhanced. The algorithm framework has good generalization ability, can be suitable for different types of complex systems, and supports to adapt to new application scenarios through modular extension.

Owner:RENFANG ARCHITECTURAL DESIGN FIRM (SHANGHAI) CO LTD
Safety control method and system for remote control of Internet of Things
PendingCN121125250AKey distribution for secure communicationPublic key for secure communicationRemote controlThe Internet
The invention relates to the technical field of management of the Internet of Things, and discloses a security control method and system for remote control of the Internet of Things, and the system comprises a security remote control platform, a zero-trust gateway, an authentication module, a security policy engine, edge proxy equipment and an encryption communication module. And the authentication module is used for performing identity authentication on the equipment and the user. The security policy engine dynamic access control table comprises access rule entries and associated signature information, and is issued to the edge proxy device through the zero-trust gateway. And the edge proxy device stores the dynamic access control table, verifies the signature information based on the platform public key, and performs matching and verification according to the access rule entry when receiving the control instruction. And the encryption communication module is used for performing encryption transmission on the access control table, the control instruction and the execution result. According to the invention, the whole process of remote control of the Internet of Things is dynamic, secure and credible, and the anti-attack capability and operation reliability of the system are effectively improved.

Owner:JINLANCHEN (BEIJING) TECHNOLOGY CO LTD
Remote control method and system based on gold wire bonding equipment
The invention relates to the technical field of remote control, and discloses a remote control method and system based on gold wire bonding equipment, and the method comprises the steps: obtaining a high-precision multi-dimensional detection data set; processing the multi-modal original monitoring data to obtain a gold thread quality feature vector matrix; processing the multi-dimensional feature vector set to obtain unified quality index feature mapping; processing the uniform quality index feature mapping to obtain a multi-stage defect detection report; processing the historical quality data and the process parameters to obtain a parameter optimization suggestion report; processing the multi-source monitoring data to obtain an augmented reality interaction system; and the augmented reality interaction system receives an operation decision of a remote operator and remotely controls the gold wire processing equipment. By means of the remote control method and the high-precision remote control system based on the gold wire bonding equipment, millisecond-level response control over gold wire machining equipment is achieved, the instruction execution accuracy is improved, and operation delay is reduced; and potential quality problems are warned in advance.

Owner:FENGRUICHENG TECH (SHENZHEN) CO LTD +1
Crane remote instruction response delay detection and prior-prior compensation method and system
The invention provides a crane remote instruction response delay detection and in-advance compensation method and system, and relates to the technical field of cranes, and the crane remote instruction response delay detection and in-advance compensation method comprises the following steps: adopting an adaptive space-time alignment algorithm to map real-time operation data to a dynamic knowledge graph, and generating a feature vector; inputting the feature vector into a depth map neural network integrated with a causal reasoning mechanism to generate an incidence matrix; a multi-head attention network with a residual structure is adopted to extract time sequence features; constructing a hybrid decision system based on the delay prediction tensor, and outputting an optimal compensation strategy; and establishing a double-closed-loop evolution system with an online learning capability, and dynamically optimizing a prediction and compensation strategy according to a compensation effect. Through the dynamic knowledge graph, causal reasoning, the multi-head attention network and the double-closed-loop evolution system, the remote instruction response delay can be accurately predicted, effective compensation is carried out, and the real-time performance and safety of remote control of the crane are improved.

Owner:NINGBO SPECIAL EQUIP INSPECTION & RES INST
Electrical fire intelligent identification system based on multi-dimensional sensor fusion
The invention discloses an electrical fire intelligent identification system based on multi-dimensional sensor fusion. The system comprises the following steps: constructing a reference environment model through multi-sensor scanning, data dimension reduction and intelligent node deployment; multi-sensor time sequence alignment is carried out through edge calculation denoising and dynamic time warping, and high-priority data is processed in real time through a layering mechanism; establishing a fire feature modeling system through LSTM time sequence analysis, mutual information correlation mining and self-supervised learning; through multi-level data fusion, GAN abnormal data generation and fuzzy logic reasoning; through grading alarm, an intelligent fire extinguishing strategy and remote control, full-process coverage from fire detection to emergency response is realized. A fire scene is visualized by means of a three-dimensional thermodynamic diagram, flame dynamic analysis and an augmented reality technology. The system is suitable for fire detection, alarm and response in a complex industrial scene, and can be widely applied to intelligent management of electrical fire.

Owner:STATE GRID NINGXIA ELECTRIC POWER CO LTD MARKETING SERVICE CENT STATE GRID NINGXIA ELECTRIC POWER CO LTD METERING CENT
Camera remote control method and system based on portable WiFi
ActiveCN120091222ANetwork traffic/resource managementClosed circuit television systemsVideo transmissionRemote control
The invention relates to the technical field of camera remote control, and discloses a camera remote control method and system based on portable WiFi. The method comprises the following steps: acquiring position information, coverage range and signal intensity of camera nodes, and constructing a distributed network topology structure; according to the distributed network topology structure, scene analysis is carried out on video content collected by a camera, and an optimal coding parameter configuration table is calculated; dividing the video frame into different priority regions according to the optimal coding parameter configuration table, and executing differential compression processing to form a video data packet with a priority mark; according to the method, video data packets with priority marks are distributed to a multi-level transmission queue, data transmission is scheduled according to the current bandwidth state of the portable WiFi, and an ordered transmission stream is generated, so that the computing load and energy consumption of each camera node are effectively balanced, stable video transmission and control response can still be kept under the condition of network fluctuation, and the video transmission efficiency is improved. And the video lagging rate and the control delay are obviously reduced.

Owner:SHENZHEN NEW SAIBO TECHNOLOGY CO LTD
Intelligent tracking and positioning system for container wharf hazardous chemical transport vehicle
The invention discloses a container wharf hazardous chemical transport vehicle intelligent tracking and positioning system comprising a data acquisition module used for acquiring vehicle positioning, driving behaviors and environment state data; the data fusion and time synchronization module is used for performing time alignment on the multi-source data; the behavior modeling and trajectory prediction module is used for extracting driving behavior characteristics and predicting a driving trajectory; the risk assessment and anomaly detection module is used for calculating an anomaly score and predicting a driving risk; the security strategy optimization module is used for constructing a zero-sum game security control model and optimizing speed limit, path and early warning strategies; the remote control and intelligent intervention module is used for executing remote speed regulation, emergency braking, path optimization and alarm pushing in the intelligent dispatching system; and the cloud monitoring and data analysis module is used for storing a track, an environment, a driving score and a safety strategy and predicting a long-term risk trend. According to the invention, based on intelligent game and multi-modal fusion, accurate tracking and safety management and control of the hazardous chemical substance transport vehicle are realized.

Owner:BEIJING GUOXINZHIKE TECH DEV CO LTD
Intelligent traffic signal device and remote control method
The invention discloses an intelligent traffic signal device and a remote control method, and relates to the technical field of intelligent traffic control. The method is used for solving the problems of low emergency traffic efficiency and global and local control imbalance under sudden traffic events. The method comprises the following steps: firstly, fusing an emergency vehicle navigation path, accident point vehicle motion abnormal parameters and pedestrian aggregation distribution data, constructing a multi-dimensional event evolution feature vector through a space-time encoder, and accurately describing a traffic situation; an event influence domain boundary is delimited based on vehicle trajectory and flow direction consistency analysis, a dynamic evolution model is constructed in combination with an acceleration abrupt change propagation path, and a space-time conflict probability matrix is generated; then executing a hierarchical control strategy, dynamically adjusting an intersection signal period starting time difference in a global level to form an emergency green wave coordination band, and inserting an adaptive full red phase in a local level according to a balance relation between a vehicle arrival rate and a dissipation rate; and finally, reversely correcting model parameters through an actual pass error, updating a conflict probability generation rule, and forming a closed-loop feedback mechanism.

Owner:GUANGZHOU PINTONG INFORMATION TECH CO LTD
Intelligent house household electric appliance remote control system
The invention discloses an intelligent house household electric appliance remote control system, which relates to the technical field of intelligent homes, and comprises an instruction receiving module, an instruction analysis module, a priority judgment module, a decision processing module and a state verification and feedback module: the instruction receiving module is used for receiving control instructions from a plurality of users and an automatic program; by introducing authority priority management, multi-dimensional judgment and intelligent scheduling, the system effectively solves instruction conflicts, and stability and reliability are improved. In family and security scenes, high-priority instructions respond in time, low-priority instructions are delayed reasonably, and the correct equipment state is ensured. The transparent feedback mechanism improves the trust of the user, and optimizes the operation efficiency and experience at the same time.

Owner:ANHUI RONGPIN TECH RESIDENTIAL DEV CO LTD
Apartment network and intelligent device linkage method and system
The embodiment of the invention relates to the technical field of artificial intelligence, and provides a linkage method and system of an apartment network and intelligent equipment, and the method comprises the steps: collecting network operation data and equipment operation data of a target apartment in real time; based on the equipment operation data, determining currently achievable candidate service scenes of the target apartment; fusing the network operation data and the equipment operation data into a joint operation map of the target apartment through the space-time diagram attention network; a multi-agent depth deterministic strategy gradient algorithm is adopted to carry out network resource allocation and equipment control decision making on the joint operation map, scene adaptive optimization is realized in combination with candidate service scenes, and a linkage strategy of a target apartment is obtained; and generating a decision instruction based on the linkage strategy, and adopting the decision instruction to realize remote control of the network equipment and the intelligent equipment. Through deep fusion of the space-time diagram attention network and multi-agent reinforcement learning, dynamic collaborative management and control of the network and equipment are realized, and the resource utilization rate and the service response speed are improved.

Owner:LEHU WISDOM (BEIJING) LIFE TECHNOLOGY CO LTD
Remote-control system of stratospheric airship and control method thereof
ActiveCN106828860AImprove environmental adaptabilityImprove self-fault toleranceRigid airshipsPosition/course control in three dimensionsWork statusDecision-making
The invention relates to a remote-control system of a stratospheric airship and a control method thereof. The control system is divided to four levels: a decision-making level for executing the selection and switch of a remote-control flight mode according to the actual working state data, and sending a corresponding mode command; a planning level for dynamically planning and generating an airship motor drive command according to the mode command sent by the decision-making level; an executing level for realizing the drive control to an airship motor according to the motor drive command of the planning level; and a perceiving level for finishing the real-time monitoring and data collection of the airship working state, and providing the original data of the airship working state to the decision-making level. The four-level control system architecture design of the control system is capable of simplifying the control device, improving the control efficiency, and fundamentally solving the problems of the function, efficiency and reliability of the near space airship ground and airborne control system.


Owner:北京天恒长鹰科技股份有限公司
Intelligent system for completing sequence control through one-key operation
The invention discloses a system for completing sequence control through intelligent one-key operation, relates to the technical field of intelligent management, and automatically completes operation of a circuit breaker, an isolation switch and a grounding switch through a sequence control module according to a five-prevention rule and a real-time state; the state confirmation module doubly verifies the equipment state before and after operation, ensures that the logic is correct and deals with the exception in time; the remote control module supports omnibearing remote control of primary equipment and secondary equipment; the video linkage module assists quick response through real-time monitoring, video archiving and abnormity alarm linkage; the intelligent anti-misoperation module dynamically checks the safety of the operation instruction, locks an error instruction and provides a correction suggestion; and the unified task management module integrates complex tasks into a one-key task list, so that the efficient and coherent operation process is ensured, the operation efficiency and safety are remarkably improved, the human error risk is reduced, and a powerful guarantee is provided for the intellectualization and reliability of power equipment operation.

Owner:GUANGXI GUIGUAN KAITOU ELECTRIC POWER
Graphical user interface for enhanced unmanned aerial vehicle flight along computed splines
ActiveUS12271190B2Aircraft componentsRemote controlled aircraftGraphical user interfaceRemote control
Technology for generating and displaying a graphical user interface for operating an unmanned aerial vehicle (UAV) is disclosed herein that generates and updates a representation of a spline flight path. In various implementations, a graphical user interface detects user interactions with a remote control device directing the flight control subsystem of the UAV to record keyframes and to compute a spline based on the keyframes during flight. The graphical user interface displays a real-time perspective of the UAV with a representation of the spline and the keyframes overlaying the view. The graphical user interface continually updates the representation as the UAV flies and when the spline is updated as the keyframes are updated.

Owner:SKYDIO INC
Photovoltaic energy storage equipment health state intelligent diagnosis system and method based on Internet of Things
InactiveCN120033843APhotovoltaic monitoringData processing applicationsElectrical batteryThe Internet
The invention discloses a photovoltaic energy storage equipment health state intelligent diagnosis system and method based on the Internet of Things. Comprising a photovoltaic module monitoring module, an energy storage battery health monitoring module, an inverter operation monitoring module, an environmental data acquisition and analysis module, a fault early warning and prediction module, an energy management and optimization module, an equipment remote control and management module and a system self-learning and optimization module. The photovoltaic module monitoring module is used for monitoring the working state and the performance index of the photovoltaic module in real time, efficient and stable operation of the photovoltaic energy storage system is ensured through the comprehensive functions of data acquisition, intelligent analysis, fault early warning, optimal scheduling, remote control, self-learning optimization and the like, and the system can be used for monitoring the working state and the performance index of the photovoltaic module through data driving and an intelligent algorithm. The operation state of each device can be accurately monitored and optimized, potential faults are warned in advance, the occurrence frequency and the operation risk of the device faults are reduced, meanwhile, the energy utilization efficiency is improved, the operation and maintenance cost is reduced, and the reliability and the adaptability of the system are enhanced.

Owner:GUANGZHOU JULONG TECH CO LTD
Unmanned aerial vehicle flight path detection method and system
The invention relates to the technical field of unmanned aerial vehicle remote identification, in particular to an unmanned aerial vehicle flight path detection method and system, and the method comprises the following steps: obtaining an airspace broadcast signal, detecting a newly added signal, correcting a terminal time difference, recognizing an information source position, extracting a position sequence, reconstructing an unmanned aerial vehicle flight path, comparing a declaration path, and recognizing the identity of an unmanned aerial vehicle. And detecting an abnormal unmanned aerial vehicle and an abnormal flight path, extracting a broadcast time sequence, identifying a time overlapping interval, detecting a remote control end, and obtaining a control identification result. According to the invention, by monitoring the airspace signal in real time and dynamically detecting the newly added signal source, the monitoring precision of the signal source is improved, the time difference correction and space cross reconstruction of a plurality of monitoring terminals are combined, the positioning precision of the unmanned aerial vehicle position is optimized, and a track reconstruction method is adopted, so that the real-time monitoring capability of abnormal behaviors is enhanced; by identifying the information source of the control end and extracting the position information, the airspace safety management and illegal flight prevention capability is improved.

Owner:XIAMEN ANZHIDA INFORMATION TECH CO LTD
Oil-electric hybrid composite wing unmanned aerial vehicle system
PendingCN120117212APower plant arrangements/mountingVehicle position/course/altitude controlElectrical batteryFlight time
The invention relates to the technical field of unmanned aerial vehicles, and discloses a gas-electric hybrid composite wing unmanned aerial vehicle system, which comprises an intelligent energy management module, a gas-electric hybrid composite wing unmanned aerial vehicle control module and a gas-electric hybrid composite wing unmanned aerial vehicle control module, the self-adaptive flight control module is used for optimizing the flight attitude, dynamically adjusting the flight route and improving the flight safety; the task adaptive scheduling module is used for adaptively adjusting a task execution strategy according to the task category, the load condition and the environmental parameters; the data monitoring and remote control module is used for collecting the operation state of the unmanned aerial vehicle in real time and storing and analyzing flight data; the intelligent safety management module is used for improving the autonomous safety of the unmanned aerial vehicle; and the environment perception optimization module is used for perceiving external environment factors in real time. According to the invention, the intelligent energy management module realizes intelligent scheduling of fuel and electricity power, and dynamically optimizes the power distribution of the battery and fuel oil, so that the flight time of the unmanned aerial vehicle is greatly prolonged.

Owner:CIVIL AVIATION UNIV OF CHINA
Intelligent security remote inspection and control method based on AI
The invention relates to the technical field of security management, in particular to an AI-based intelligent security remote inspection and control method, which comprises the steps of front-end intelligent equipment deployment, intelligent inspection execution, data processing and intelligent analysis and remote control and linkage response. Compared with the defects of incomplete information and high false alarm rate due to the fact that equipment appearance anomaly detection mainly depends on single-modal data in the prior art, the scheme adopts multi-modal data preprocessing and feature extraction, constructs a cross-modal alignment network architecture, dynamically fuses laser radar, RGB-D images and IMU data by using a self-attention mechanism, and improves the detection accuracy of the equipment appearance anomaly. According to the method, more accurate equipment appearance abnormity identification is realized by combining environment self-adaptive adjustment, and the model is compressed and deployed to an edge end through a knowledge distillation technology, so that real-time reasoning and analysis are realized, the intelligent level of security inspection and the accuracy of abnormity detection are remarkably improved, the false alarm rate is reduced, and the practicability and reliability of the system are enhanced.

Owner:GUANGZHOU YOUSEN INFORMATION TECHNOLOGY CO LTD
Laser - based targeting and object detection system
A pest control system is disclosed comprising an optical, computational, and monitoring subsystem, optionally mounted on a mobile platform. The optical system may include a neutralizing laser or multi-wavelength light source, discovery and detail cameras (optionally stereo), a beam-steering mechanism, tunable focus, and optional thermal or depth sensors. The processor, such as a GPU or FPGA, identifies insect or biological targets, adjusts laser focus by depth, and controls beam activation. A monitoring system verifies safety by detecting humans or other non-target entities using environmental and thermal cameras; if detected, laser firing is inhibited. The mobile platform may use wheels, propellers, tracks, or cables, with GPS and data links for remote control. A visible light pre-flash may induce a blink reflex before firing. In some embodiments, a scouting drone transmits target coordinates to the neutralization unit, enabling coordinated, efficient, and safe laser-based pest control.


Owner:REYNTJENS NICK
Power plant equipment intelligent coordination control method and system based on multi-source heterogeneous data
The invention discloses an intelligent coordination control method and system for power plant equipment based on multi-source heterogeneous data, and belongs to the technical field of intelligent manufacturing and industrial automation, and the method comprises the steps: deploying a multi-mode sensor network in the power plant equipment, collecting the multi-source heterogeneous data in real time, and carrying out the real-time data preprocessing through an edge calculation node; carrying out collaborative modeling on the preprocessed data by adopting a hybrid analysis framework, predicting an equipment state trend, identifying a fault propagation path, positioning a root cause and optimizing a maintenance decision scheme; the equipment failure probability is evaluated through a fault diagnosis result, a grading early warning mechanism is triggered, and a rule base is updated and optimized in combination with a dynamic knowledge base; a three-dimensional model is constructed by using a digital twinning technology to carry out virtual simulation and remote control, and maintenance guidance is carried out through an augmented reality auxiliary technology. According to the method, efficient real-time monitoring and fault prediction are achieved, the fault diagnosis time and the operation and maintenance cost are remarkably reduced by combining the fault tree model and the digital twinning technology, and the equipment operation safety and reliability are improved.

Owner:HUANENG POWER INT INC YINGKOU POWER PLANT
Remote dosing control system for operation of steam boiler
The invention relates to the technical field of remote control, in particular to a steam boiler operation remote dosing control system which comprises a multi-source acquisition module, a state judgment module, a path switching module, a quality verification module and a health evolution module. According to the method, a monitoring system is constructed by fusing multi-dimensional parameters such as flow, pressure and temperature in real time, a single sensor error is eliminated through Kalman filtering, a heat transfer correlation model is established to quantify the water quality and thermal coupling relation, a pipeline blockage critical point is pre-judged based on grey correlation analysis, and non-inductive switching of a dosing path is achieved by adopting a double-electromagnetic-valve redundancy architecture. The stability of medicament conveying is verified by combining the flow offset of a standby path, closed-loop comparison of a concentration amplification value and a target value is synchronously executed to trigger self-calibration to correct the feeding deviation, a water quality adjustment-path switching-precision verification linkage control chain is formed, the abnormal response period is shortened, the scaling rate of a heat transfer surface is reduced, and the stability of the heat efficiency of the boiler is maintained. The equipment maintenance period is prolonged.

Owner:QUANZHOU BRANCH OF FUJIAN SPECIAL EQUIP INSPECTION & RES INST
Apartment security linkage method and system based on artificial intelligence
The embodiment of the invention relates to the technical field of artificial intelligence, and provides an apartment security linkage method and system based on artificial intelligence, and the method comprises the steps: enabling initial security data obtained in real time to form a security space data set matched with an apartment space according to a space-time association relation; performing conjoint analysis on the security space data set by adopting a security intelligent decision engine to generate a corresponding linkage strategy; sending the corresponding control instruction and the security control parameter to the corresponding target security equipment based on the linkage strategy; the linkage priority of the security and protection equipment is set according to the security and protection event type and the mapping relation between the security and protection equipment and the security and protection event emergency degree, and a control array containing all levels of target security and protection equipment is constructed according to the linkage priority in combination with the current security and protection event type. The control array preferentially triggers the core target security and protection equipment to respond to the indication of the linkage strategy, so that remote control and linkage response of the security and protection equipment are realized, and the intelligent level and the emergency processing capability of apartment security and protection are improved.

Owner:LEHU WISDOM (BEIJING) LIFE TECHNOLOGY CO LTD
Medical equipment remote control system based on Internet of Things data
The invention discloses a medical equipment remote control system based on Internet of Things data, relates to the technical field of equipment remote control, and realizes efficient safety protection of medical equipment remote control through four links of multi-source data acquisition and behavior baseline construction, real-time anomaly detection, risk grading evaluation and linkage processing, and adaptive safety strategy execution. Firstly, an operation log is collected and cleaned, a multi-dimensional label is added, and a baseline model M is constructed to judge the deviation degree; then, deviation degree calculation is carried out on the instructions in real time, suspicious instructions are screened, and a structured suspicious instruction set is formed; in the risk grading stage, performing multi-factor grading on suspicious instructions and screening medium-high risk objects; and finally, according to the risk vector, calculating the priority of a strategy and matching a predefined interval, implementing security protection through measures such as multi-factor authentication, secondary approval or temporary freezing, and continuously writing back and updating a disposal result to form a closed loop to improve the overall security management and control level.

Owner:ANNING FIRST PEOPLES HOSPITAL +1
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
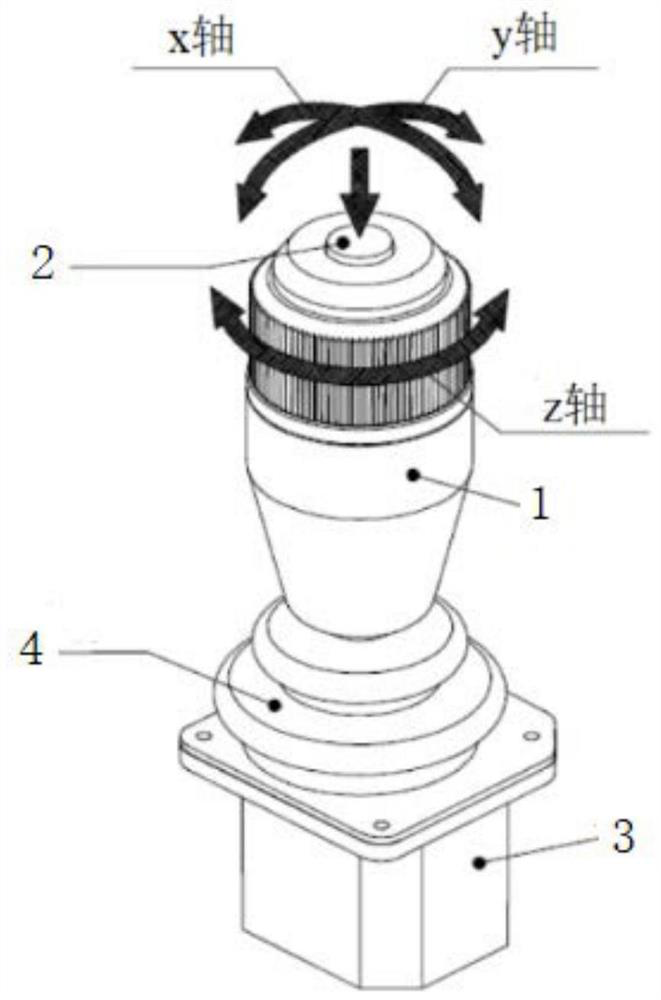
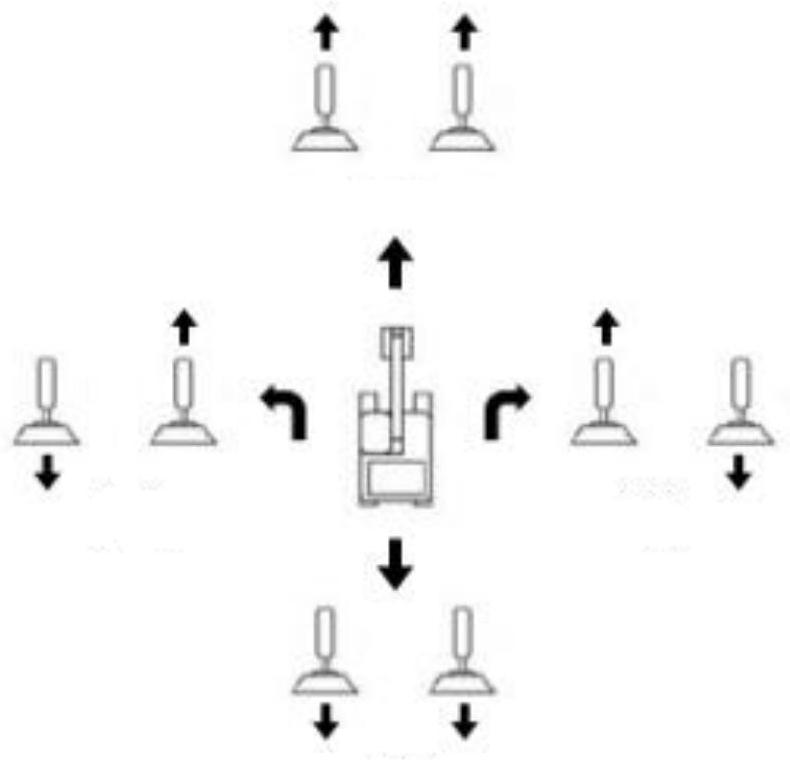
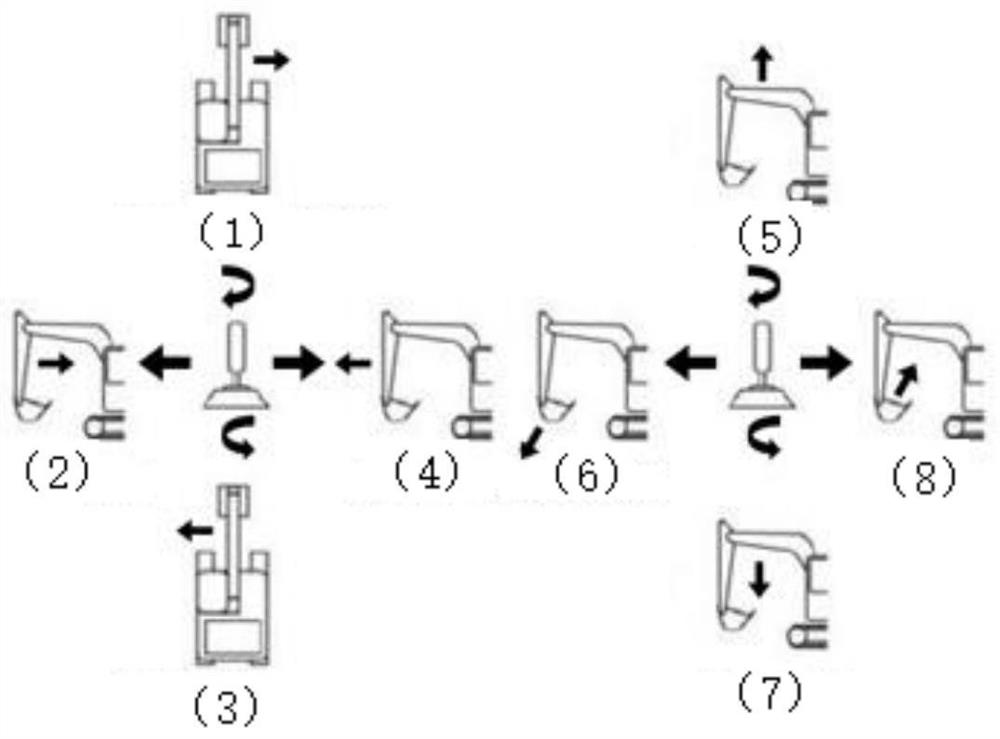
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Port task processing method of satellite test operation control system
The invention relates to the technical field of satellite telemetering and remote control, and discloses a port task processing method for a satellite measurement, operation and control system, which comprises the following steps of: 1, detecting all available network interfaces through a port scanner, and establishing a multi-path communication channel comprising a public network, a private network and a satellite link; step 2, acquiring packet loss rate, delay, bandwidth and jitter parameters of each path in the multi-path communication channel in real time, and updating the parameters based on a preset period; and step 3, generating a comprehensive score of each path according to the packet loss rate, the delay, the bandwidth and the jitter parameters. According to the method and the device, the technical scheme of dynamic scoring and switching of the multi-path communication channel is adopted, and the technical effect of automatically selecting the optimal path according to the real-time network performance is achieved; the problems of high transmission delay, large packet loss rate and incapability of adaptive adjustment caused by network fluctuation are solved.

Owner:BEIJING CREATUNION INFORMATION TECH CO LTD
Drainage pipe network hydraulic water quality monitoring equipment and control system
The invention discloses a hydraulic water quality monitoring control system for a drainage pipe network, which belongs to the field of data communication of a data center and comprises a rain gauge, a flow meter, a liquid level meter and a water quality monitor. The system also comprises an intelligent data analysis and diagnosis module, a remote control and automatic management module, an environment adaptability and safety protection design, a communication and data transmission optimization module, and an intelligent fault self-diagnosis and maintenance prompt module. A data analysis algorithm is adopted, data are transmitted to a central monitoring platform in real time through a wireless communication module, and centralized processing and analysis of the data are achieved. Meanwhile, the system has a remote control function and supports remote operation of drainage pipe network equipment through the intelligent tail end power supply controller. The environment adaptability design ensures that the equipment can stably operate in a severe environment, and the communication and data transmission optimization ensures the real-time performance and accuracy of data.

Owner:江苏长三角智慧水务研究院有限公司 +5
Antenna module for acoustic point defence system and acoustic system comprising said module
The main object of the invention is an antenna module for an acoustic point defence system (SAD) and an acoustic system comprising said module. The antenna module comprises at least one array of electroacoustic transmitting transducers (TX) and at least one array of electroacoustic receiving transducers (RX). The arrays of transmitting transducers and the arrays receiving transducers have the characteristic of being housed in a watertight container adapted to be submerged in water when the module is in operation, for example by means of a hoist or winch device (SMMR - Launching and Recovery System). The container has watertight accesses, for example via watertight connectors, for at least one cable for a power supply signal, connected or connectable with a power supply unit external to the container, and for at least one cable for a data signal, connected or connectable to a remote control unit adapted to send commands and receive target detection states and / or signals. The antenna module comprises a local control and calculation unit housed inside the container, which local control and calculation unit is equipped with an input for the power supply signal and a port for the data signal, and is interfaced with the arrays of transducers for controlling the signal transmitted by the arrays of transmitting transducers and processing the signals received by the arrays of receiving transducers on the basis of commands received by the data port.

Owner:LEONARDO SISTEMI INTEGRATI
Unmanned ship directional operation system cooperating with unmanned aerial vehicle to cruise
PendingCN120353226AVehicle position/course/altitude controlPosition/direction controlMarine engineeringRemote control
The invention relates to the technical field of unmanned systems, and discloses an unmanned ship directional operation system cooperating with unmanned aerial vehicle cruise, and the system comprises an unmanned aerial vehicle module which carries a high-precision sensor and is used for scanning a water area environment in real time and generating a high-precision map; the unmanned ship module is provided with a navigation system and an operation device and is used for executing water surface orientation operation according to the high-precision map; the cloud platform module is connected with the unmanned aerial vehicle module and the unmanned ship module through a wireless communication network and is used for data interaction, task scheduling and remote control; and the intelligent charging shore base is used for providing automatic charging support for the unmanned ship module. A high-precision water area map is generated in real time through the unmanned aerial vehicle module and is transmitted to the unmanned ship module, so that the unmanned ship can optimize the route and the obstacle avoidance operation according to the dynamically updated environment data, and the task execution precision is remarkably improved; therefore, the effectiveness of patrolling, cleaning and monitoring tasks is improved.

Owner:JIANGSU SHENWU ADVANCED TECH RES INST CO LTD
Roadway deformation monitoring device based on millimeter wave radar
ActiveCN120368890AMining devicesParticular environment based servicesDeformation monitoringLaser sensor
The invention discloses a roadway deformation monitoring device based on a millimeter wave radar. The roadway deformation monitoring device comprises a main shell, the millimeter wave radar, a laser sensor, a PCBA (Printed Circuit Board Assembly) and a bubble level, and an integrated multi-modal data fusion analysis module, a dynamic measurement range intelligent adjustment module, a real-time deformation prediction and control module and a self-calibration and fault diagnosis module. The multi-modal fusion system fuses radar and laser data through a Kalman filtering algorithm, and full-scale high-precision monitoring is realized by using median filtering, Gaussian fitting preprocessing and dynamic weight distribution; the dynamic range measurement module intelligently switches measurement and frequency sweeping ranges based on a decision tree algorithm according to mining progress, geological conditions and distance fluctuation coefficients; the real-time prediction module adopts an ARIMA model to predict the deformation in advance, and automatically adjusts the scanning angle and the acquisition frequency; the self-calibration module uses a high-precision reflecting plate to correct errors everyday; the system supports 5G communication and remote control, has the advantages of high precision, self-adaption and high reliability, and is suitable for long-term deformation monitoring of mine roadways.

Owner:ZHONGGAN (ANHUI) MINING TECH CO LTD
Intelligent equipment remote cooperative control method and system based on Internet of Things
The invention relates to the technical field of remote control, in particular to an intelligent device remote cooperative control method and system based on the Internet of Things, and the method comprises the following steps: monitoring and adjusting the CPU utilization rate and memory usage of an intelligent device based on an Internet of Things platform, optimizing the data collection and network resource distribution, and improving the intelligent device remote cooperative control efficiency. By analyzing equipment performance and a network load balance index, equipment connection priority ranking and task load management are realized, and task execution and connection frequency is dynamically adjusted, so that real-time task requirements are met, and system efficiency is improved. According to the method, the performance index of the equipment is monitored in real time, the data transmission interval is dynamically adjusted, the data processing speed is remarkably increased, resource waste is reduced, efficient use of network resources is ensured through real-time load analysis and optimization of network nodes, the problem of data delay caused by network congestion is avoided, and in the aspect of equipment connection management, the data transmission efficiency is improved. An intelligent priority decision mechanism allows the key device to quickly access the network in an emergency.

Owner:GUANGZHOU COLLEGE OF COMMERCE
Unmanned aerial vehicle edge intelligent analysis terminal based on single Beidou
InactiveCN119881997ANavigational calculation instrumentsNavigation by speed/acceleration measurementsNerve networkEmbedded system
The invention discloses an unmanned aerial vehicle edge intelligent analysis terminal based on a single Beidou, and relates to the technical field of satellite navigation and unmanned aerial vehicles, and the terminal comprises an edge calculation unit which is in communication connection with a high-definition image collection module, a high-precision positioning module, a Beidou short message communication module and a ground control station; the high-definition image acquisition module is used for acquiring high-definition image data through a CMOS (Complementary Metal Oxide Semiconductor) sensor; the high-precision positioning module is used for acquiring centimeter-level positioning data in the flight process of the unmanned aerial vehicle through an RTK technology and an INS system; the edge calculation unit is used for carrying out target recognition through a lightweight convolutional neural network in combination with a YOLOv5 target detection algorithm; the Beidou short message communication module is used for realizing short message communication between the unmanned aerial vehicle and a ground control station by using RDSS service; and the ground control station is used for creating a user interface by using Qt, carrying out data visualization through Tableau and adopting a security protocol. According to the scheme, remote control, remote information transmission and high-precision positioning functions in a complex environment of the unmanned aerial vehicle are realized.

Owner:XIAN TIANMAO DIGITAL TECH CO LTD