
Patents
Literature
11051 results about "Radar" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Radar is a detection system that uses radio waves to determine the range, angle, or velocity of objects. It can be used to detect aircraft, ships, spacecraft, guided missiles, motor vehicles, weather formations, and terrain. A radar system consists of a transmitter producing electromagnetic waves in the radio or microwaves domain, a transmitting antenna, a receiving antenna (often the same antenna is used for transmitting and receiving) and a receiver and processor to determine properties of the object(s). Radio waves (pulsed or continuous) from the transmitter reflect off the object and return to the receiver, giving information about the object's location and speed.
High-performance loosely-coupled multi-modal data fusion system for smart driving environmental perception system and vehicle-mounted device
PCT designated stageWO2025241308A1Image enhancementInstruments for road network navigationData setTracking model
Disclosed are a high-performance loosely-coupled multi-modal data fusion system for a smart driving environmental perception system and a vehicle-mounted device, comprising: a fusion detection model based on a modality-independent feature interaction strategy, which is configured for converting a LiDAR point cloud, a camera image, and a millimeter-wave radar point cloud into a unified bird's-eye view representation, and performing multi-modal fusion; and a fusion tracking model based on a motion-appearance feature cascaded coupling data association strategy, which is configured for performing subsequent trajectory tracking and matching according to multi-modal fusion feature information. A VoD data set and a K-Radar data set are selected for training, verifying, and testing the comprehensive performance of the models, and a TensorRT accelerated inference model is applied, then quantized, and deployed to a vehicle-mounted computational testing platform. The present invention is compatible with mainstream sensor deployment solutions, and achieves the efficient complementary fusion of multi-source heterogeneous sensor information, significantly improving the reliability, accuracy, and adaptability of vehicle-mounted perception systems, thereby effectively responding to extreme operating conditions such as complex traffic scenarios and inclement weather.

Owner:JIANGSU UNIV
Radar device
InactiveUS20060238404A1Accurately measure distanceAccurate distance measurementRadiating element housingsRadio wave reradiation/reflectionReflected wavesRadar
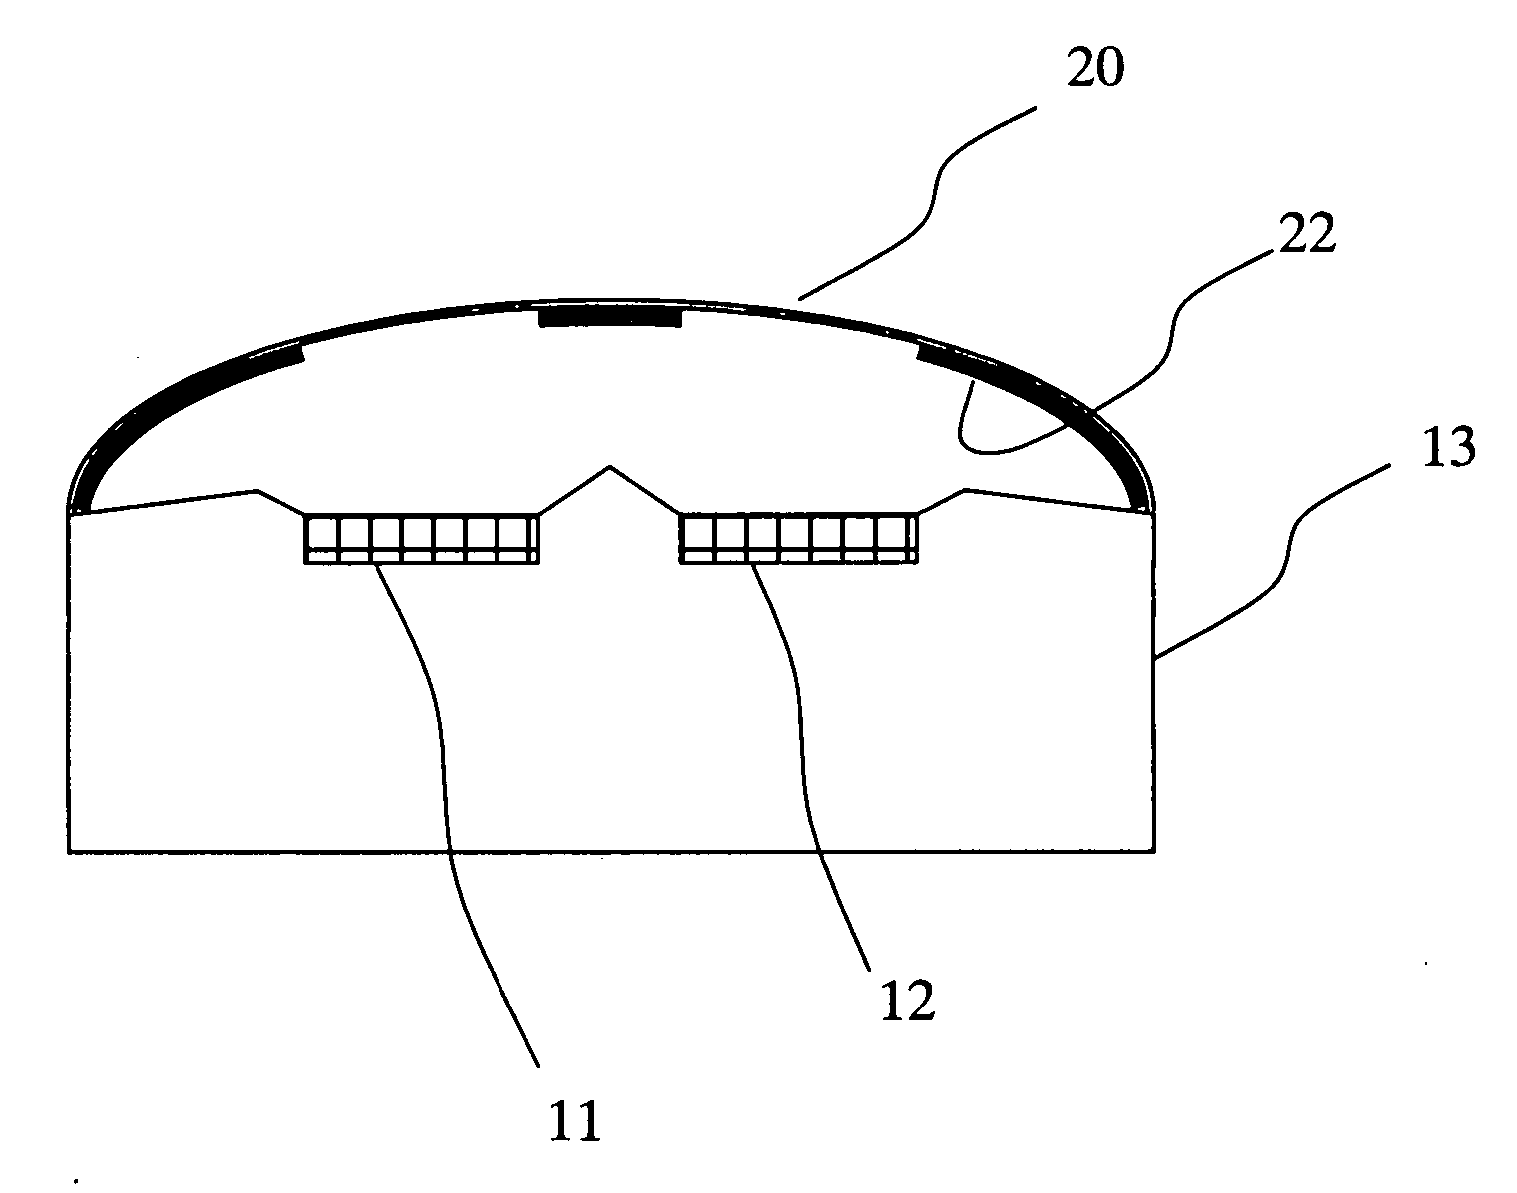
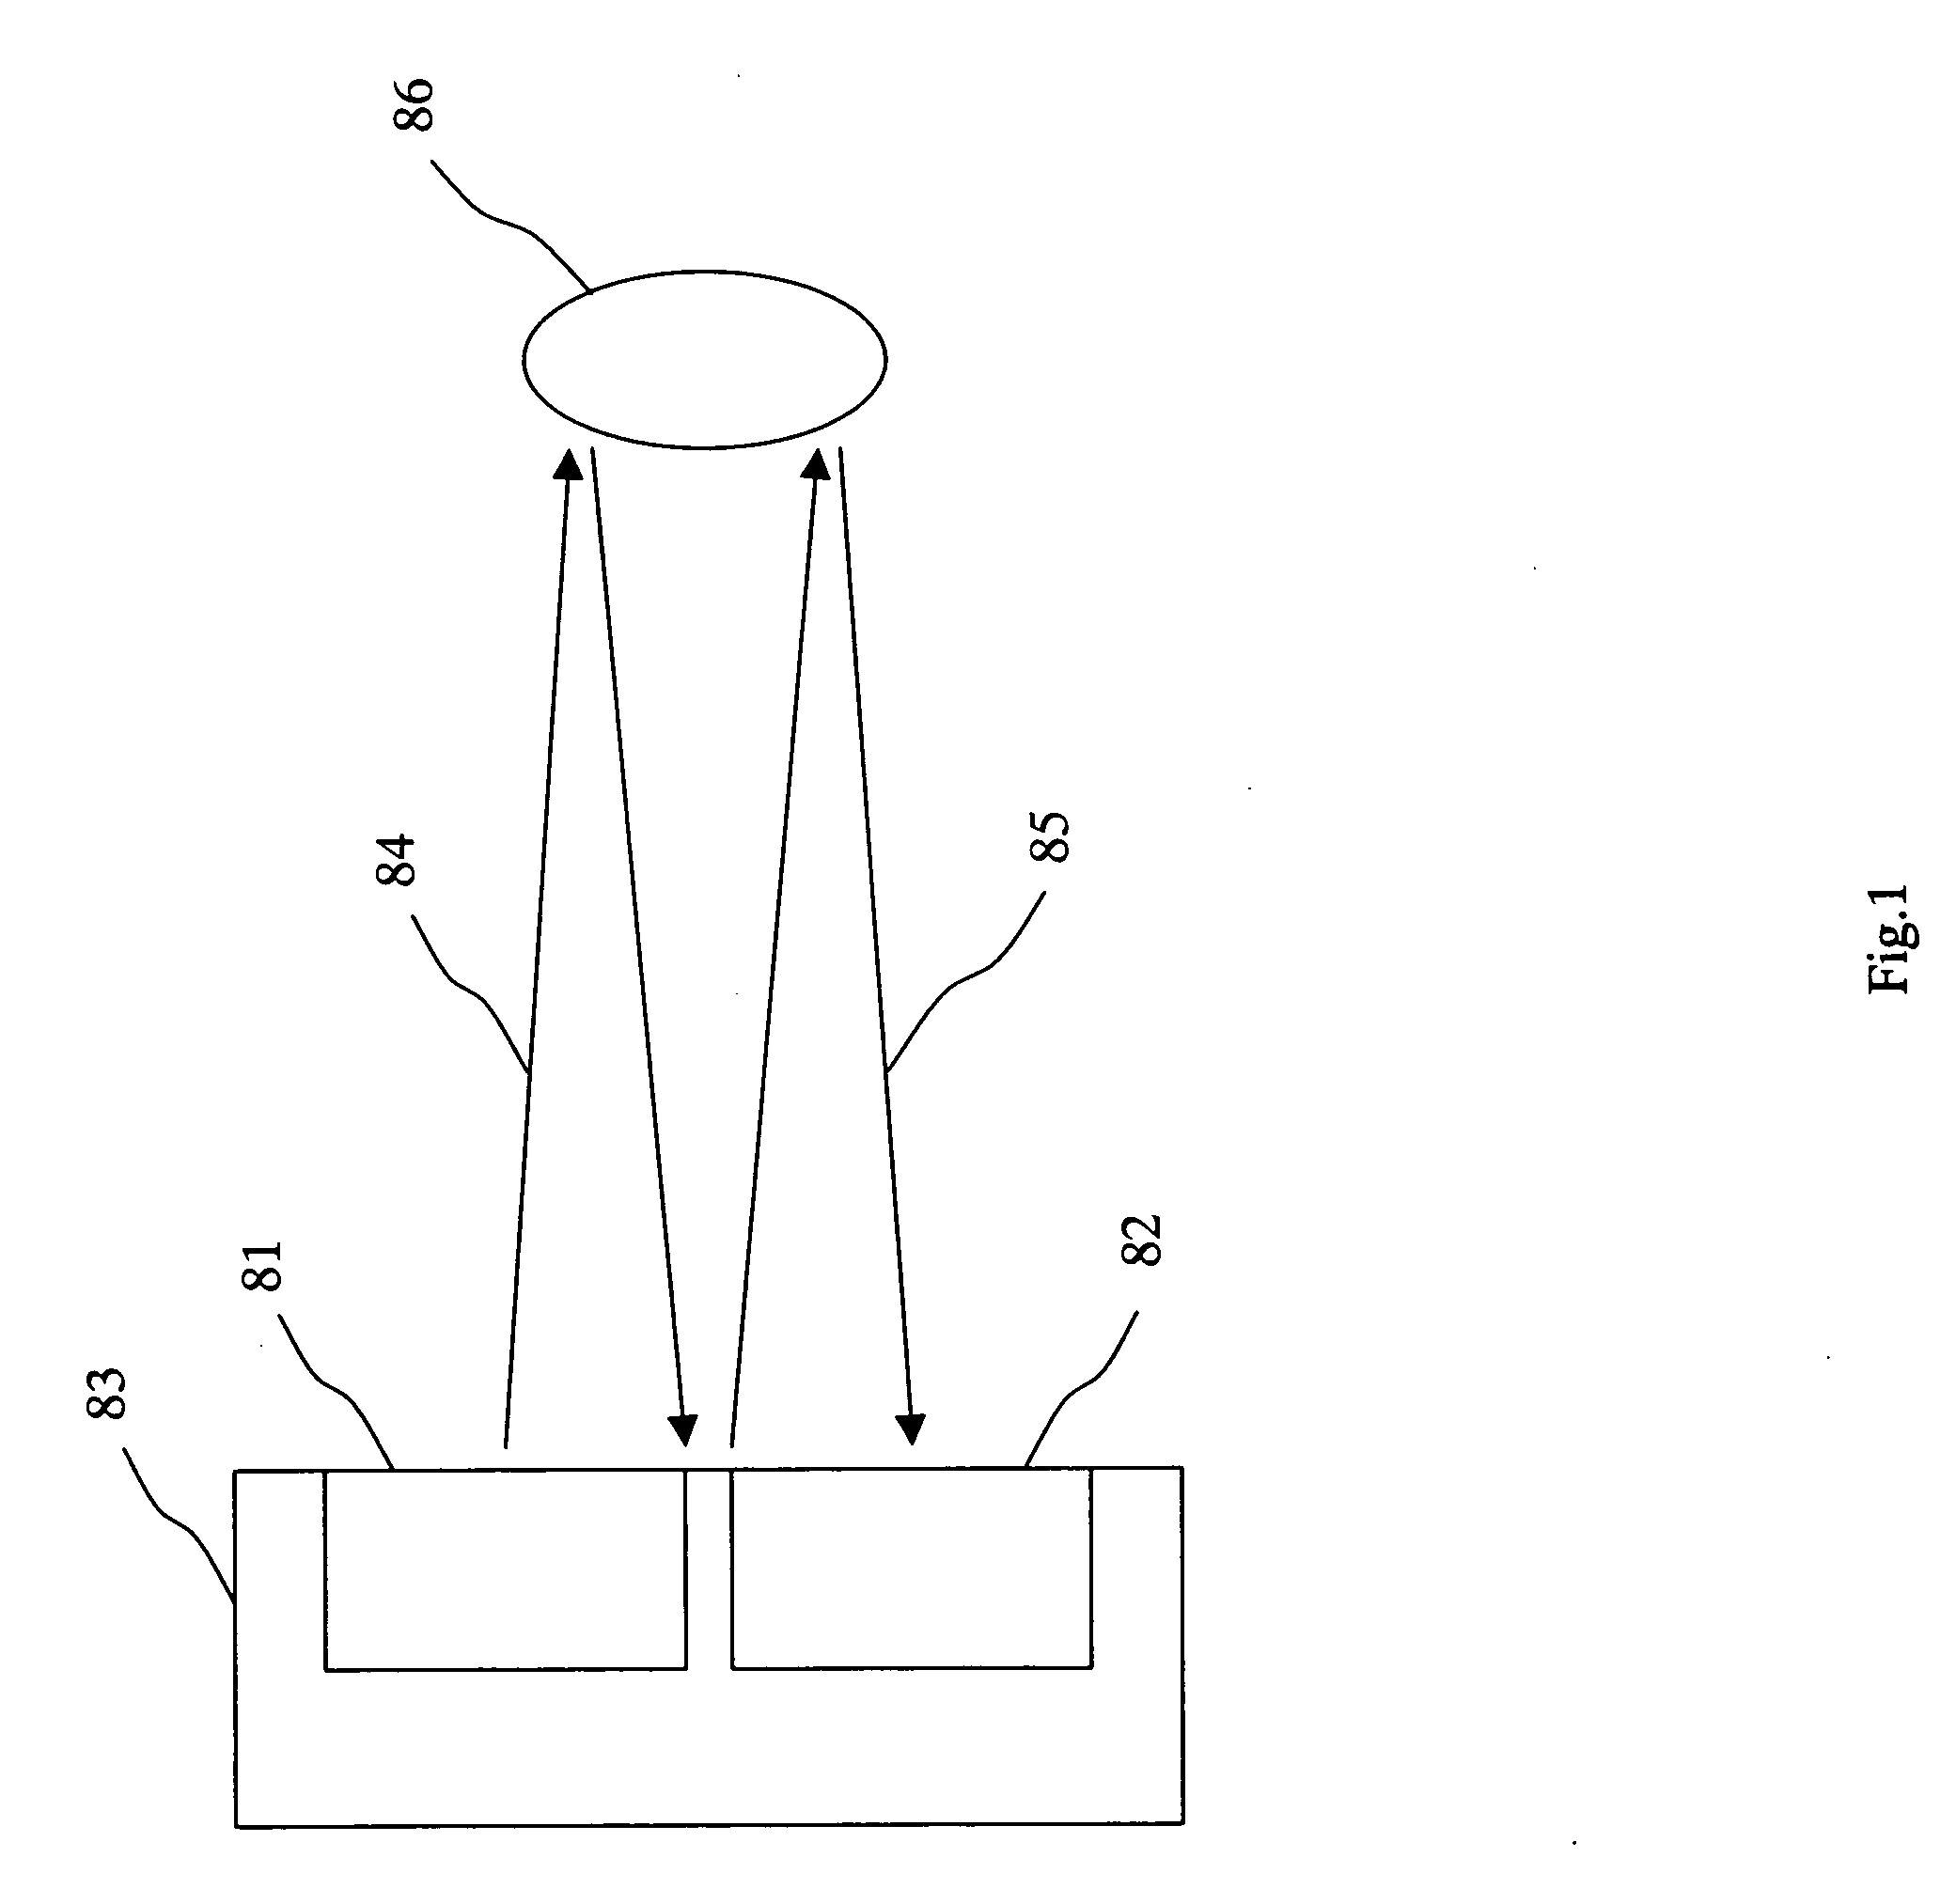
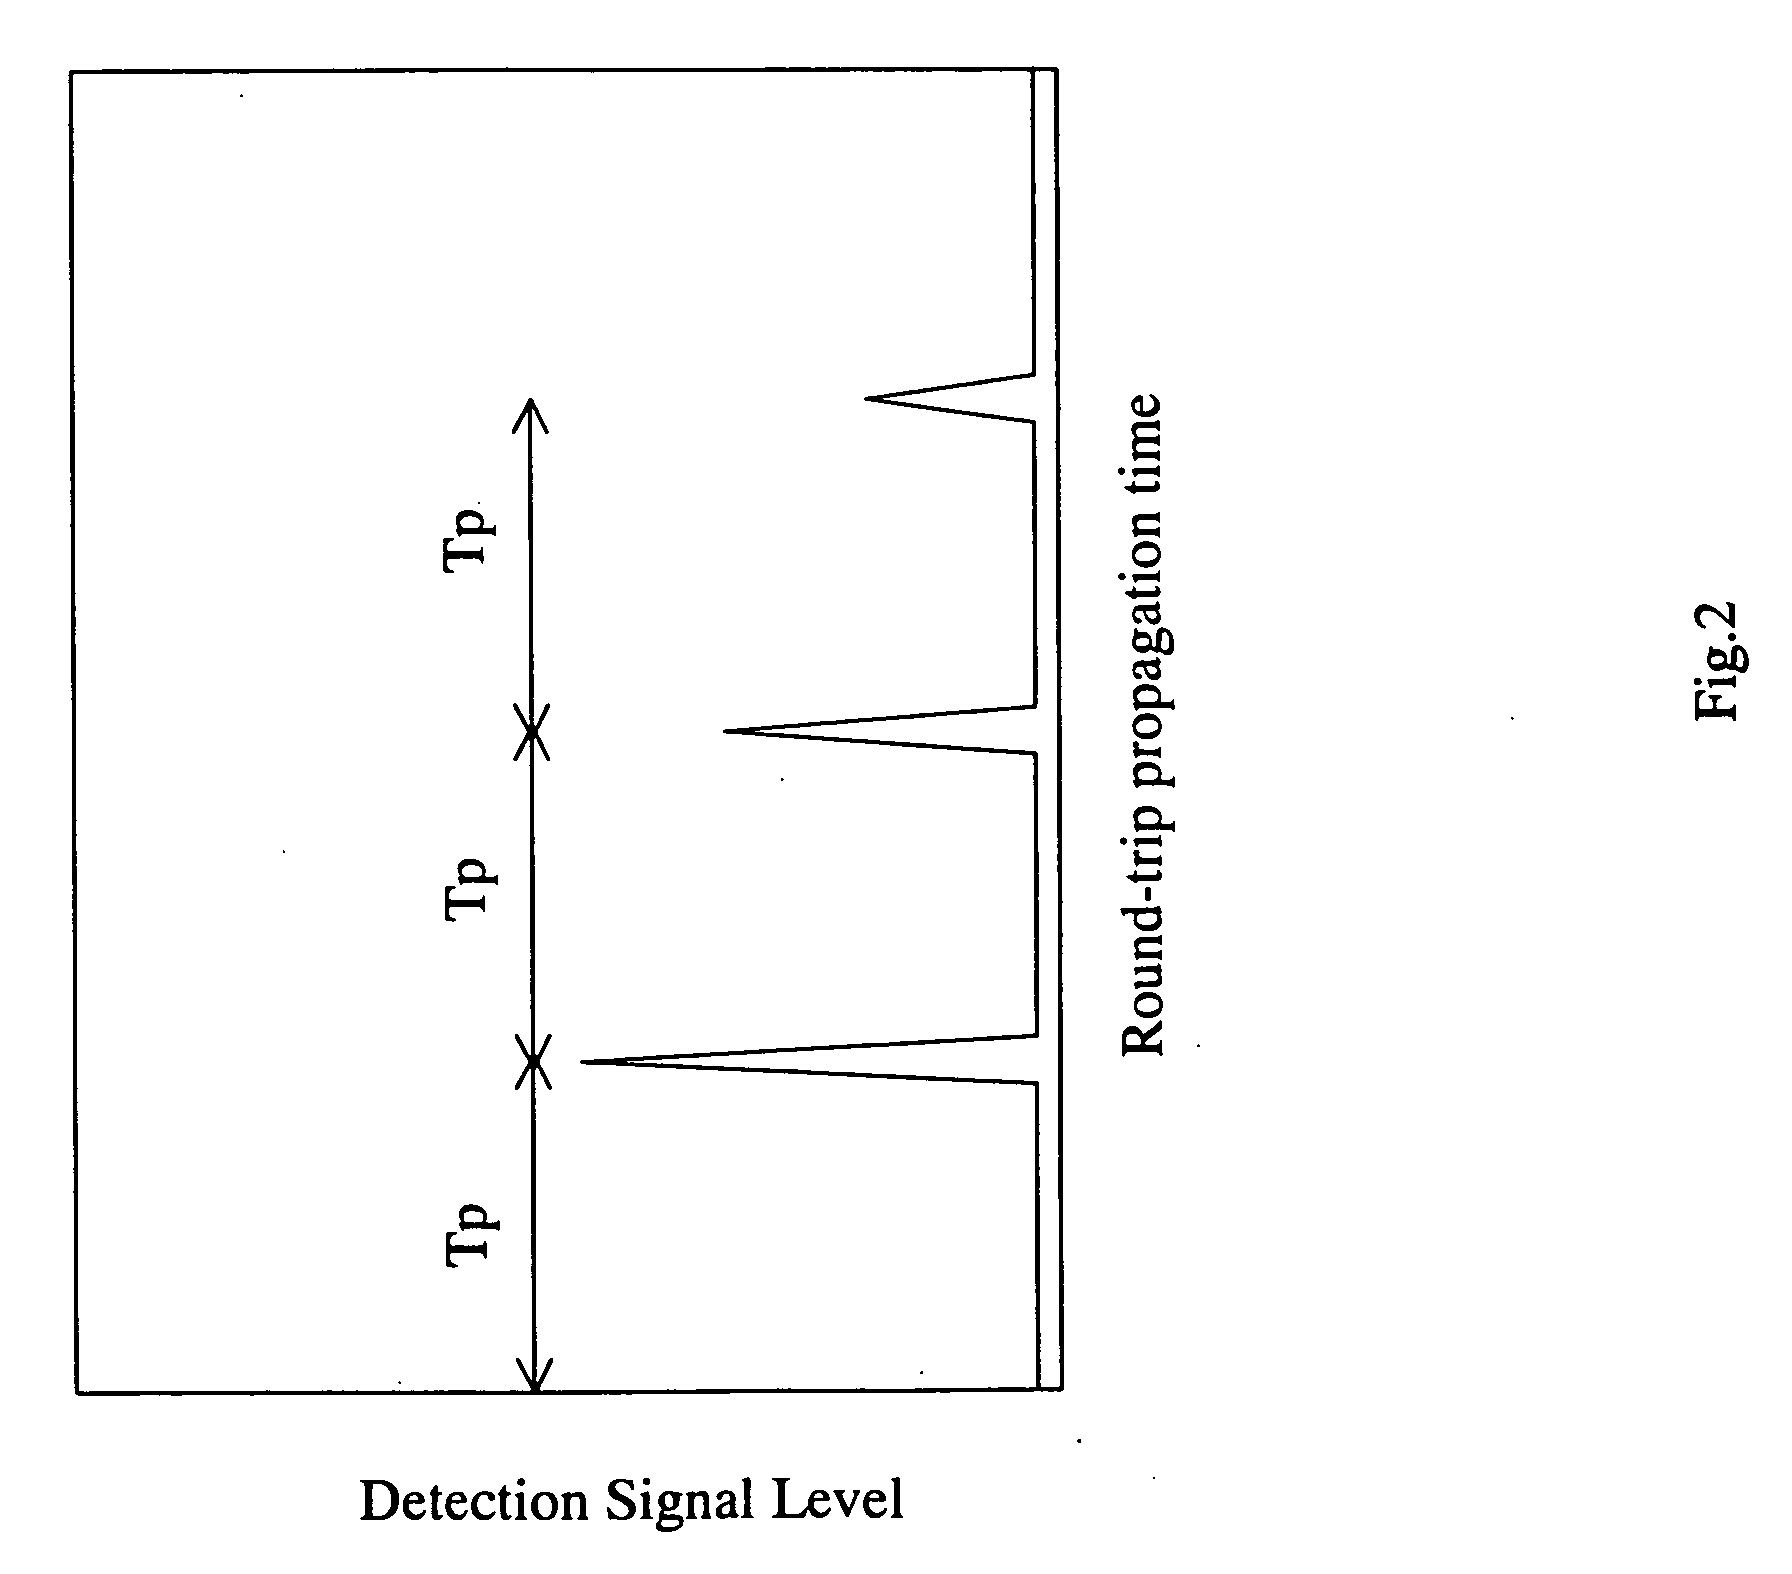
A radar device which is installed in a vehicle or the like needs to detect a target at a short distance from several tens of centimeters to several tens of meters and, therefore, has a problem that a reflected wave from the target may be reflected by a front case of the radar device and then reflected by the target again to be received as a secondary echo by itself. To solve this problem, it is an object of the present invention to provide a radar device again that can prevent multi-reflection to accurately measure a distance to a target in a short range. In a radar device according to the present invention, a surface of a frame body provided around a transmitting antenna and a receiving antenna is shaped so that a reflected wave from a target may not be returned in a direction in which a transmitting wave is transmitted from the transmitting antenna.
Owner:TDK CORPARATION
Digital twinning risk early warning system based on channel multi-source data fusion
PendingCN120853419AMarine craft traffic controlDesign optimisation/simulationVideo monitoringData acquisition
The invention relates to the technical field of channel safety management, and more specifically relates to a channel multi-source data fusion digital twinborn risk early warning system comprising a multi-source data acquisition module used for acquiring channel specific data types, comprising AIS data, radar data, video monitoring data, hydro meteorological data, channel surveying and mapping data, ship report data, shore-based sensor data and unmanned aerial vehicle patrol data, and comprehensive data support is provided for channel management through space-time alignment, dynamic weight adjustment and conflict resolution; a high-fidelity digital twin is constructed, fluid dynamics and a ship behavior model are fused, and a real channel scene is restored; intelligent risk early warning and traceability are realized by using deep learning, and decision scientificity is improved; efficient virtual-real interaction is realized through multi-terminal pushing and sand table deduction, and a management closed loop is formed; a cloud-edge-end framework and the like are adopted to optimize system performance, and real-time performance and safety in a large-scale scene are guaranteed.

Owner:THREE GORNAVIGATION AUTHORITY
Short temporary rainfall prediction method based on multi-source multi-temporal-spatial-feature fusion
The invention discloses a multi-source multi-temporal-spatial feature fusion short and temporary rainfall prediction method (M4Cester), which realizes layered temporal-spatial feature extraction through a multi-space multi-time aggregator (MMA), and comprises a multi-scale patch embedding (MSPE) module, a cross-scale perception optimization (CPR) module and a multi-time self-attention (MTS) module. The first and second spatial features are respectively used for capturing local-global spatial features, dynamically balancing cross-scale information and mining a time sequence dependency relationship; meanwhile, a bidirectional bridging fusion module (MSFM) is designed, bidirectional alignment and enhancement of radar and satellite features are realized by using a cross attention mechanism, and modal difference is relieved through residual connection. Experiments on a weather data set in the Yangtze River Delta region show that the key success index (CSI) reaches 0.267 and the HSS reaches 0.372 in heavy rainfall (greater than or equal to 50dBZ) prediction by the method, which are obviously improved compared with the existing advanced model, particularly, the limitation of single-source data is effectively overcome in the prediction of a convection initiation (CI) event, and a high-precision solution is provided for short and temporary rainfall prediction.

Owner:SOUTHEAST UNIV
Tunnel deep-buried drainage ditch rapid blasting excavation method based on vertical drilling
The invention discloses a tunnel deep-buried drainage ditch rapid blasting excavation method based on vertical drilling, which comprises the following steps: step 1, detecting the geology in front of a tunnel by using vertical drilling coring, geological radar and TSP seismic wave technology, and constructing a three-dimensional model; 2, generating an asymmetric hole net layout based on a geological model and AI, and setting a drilling-free vibration isolation belt; the design of dense inside and sparse outside is adopted, and vibration propagation is blocked; thirdly, a three-stage air spacer is arranged at the bottom of the blast hole, segmented charging is implemented, the explosive energy release time is prolonged, and the single-segment explosive quantity peak value is reduced; fourthly, an electronic detonator is adopted for millisecond detonation, and peak vibration is weakened through the waveform superposition offset effect; 5, arranging fiber grating sensors in the tunnel, collecting data in real time and transmitting the data to the cloud AI platform; dynamically adjusting parameters based on the monitoring data; and 6, evaluating a blasting effect through a three-dimensional laser scanner, generating an evaluation report in combination with data, updating a BIM model database, and continuously optimizing an AI algorithm.

Owner:CHINA RAILWAY NO 5 ENGINEERING GROUP CO LTD +2
Millimeter wave radar human body tumble detection method based on multi-feature fusion
The invention discloses a millimeter wave radar human body tumble detection method based on multi-feature fusion, and the method comprises the steps: obtaining an original point cloud frame from each radar, and carrying out the timestamp calibration and space coordinate system conversion; performing noise filtering, ground segmentation and human body point cloud extraction on each frame of point cloud; dividing the preprocessed point cloud into a static cluster and a dynamic cluster; filtering false dynamic clusters; extracting a residual dynamic cluster set, and identifying and tracking the human body dynamic clusters in continuous frames by adopting a tracking algorithm; extracting a corrected time sequence feature from the tracked human body cluster; inputting the time sequence characteristics into a pre-trained deep time sequence network, learning a falling time sequence dependency relationship, and outputting an abnormal index; and performing multi-source fusion with the abnormal index to obtain a comprehensive index to judge whether to trigger an alarm. The method can adapt to a complex home environment, improves the detection accuracy and real-time performance, and reduces the false alarm and missing alarm.

Owner:四川工程职业技术大学
Battlefield target behavior prediction method capable of being guided by micro-physical representation and thinking chain
The invention discloses a battlefield target behavior prediction method capable of being guided by micro-physical representation and a thinking chain, and the method comprises the steps: obtaining satellite images, radar / communication detection and open source text multi-source time sequence data, completing the entity recognition, relation extraction and event detection, and constructing a dynamic space-time knowledge graph; the maneuverability, sensor detection, weapon range and terrain accessibility mechanism are micronized to serve as a physical consistency constraint embedded prediction model; generating an intention-action-result causal priori chain and parameterizing the causal priori chain into a computable structure; performing multi-branch long-time-sequence situation deduction, and outputting a future target behavior track and a scene probability; and evaluating and explaining by integrating the causal confidence coefficient, the physical consistency and the data goodness of fit, and giving a key event probability and situation evolution report. According to the method, unified modeling of semantic causal and physical constraints is realized, and the method has explainable, verifiable and robust prediction capabilities, and is suitable for target behavior prediction and command information system decision support in a complex environment.

Owner:CHINA UNIV OF MINING & TECH
Multi-modal information fusion odometer construction method and system for star catalogue positioning
The invention discloses a multi-modal information fusion odometer construction method for star catalogue positioning, and relates to the technical field of star catalogue patroller positioning. The method comprises the following steps: carrying out space joint calibration on a monocular camera, a laser radar and an inertial measurement unit, reconstructing a laser radar point cloud by using a timestamp of a camera image, and realizing time synchronization of the camera image and the laser radar point cloud; establishing an IMU pre-integration error model; and performing motion compensation distortion removal on the laser point cloud by using an IMU pre-integration result, and extracting geometric features of the distorted laser point cloud based on a neighbor region smoothness calculation method of a fixed measurement distance. By researching a multimodal information fusion odometer method, the accumulative error of motion measurement is reduced, the positioning precision and stability are improved, technical support is provided for design and development of a star catalogue navigation system, and the problems that a single-modal star catalogue positioning method is weak in environment adaptive capacity and poor in algorithm generalization are solved.

Owner:DEEP SPACE EXPLORATION LABORATORY
Low-altitude safety emergency system based on large model application
The invention relates to the technical field of low-altitude safety emergency, and discloses a low-altitude safety emergency system based on large model application. The system comprises a low-altitude situation awareness module which constructs a dynamic situation prediction model based on historical flight data, collects a low-altitude target track coordinate sequence, radar echoes and communication signal characteristics in real time, and outputs a theoretical security situation value. The multi-source data fusion analysis module performs three-dimensional difference analysis on theoretical and actually measured situation values, which relates to time domain trend deviation, space domain coverage offset and event sequence matching degree, and generates a target-level difference feature matrix; and the risk propagation path deduction module inputs the matrix into a geographic topology analysis network, generates a probability thermal distribution diagram of an abnormal risk propagation path in combination with airspace node communication parameters and a target position, and locates a risk influence area. And the intelligent disposal strategy generation module configures parameters according to the graph, starts high-frequency monitoring for a high-probability area, and performs communication disturbance test on an adjacent target.

Owner:BEIJING ZHONGKE CHENJI TECHNOLOGY CO LTD
Intelligent channel management method and system based on multi-source data fusion
The invention relates to the field of channel management, in particular to an intelligent channel management method and system based on multi-source data fusion. The invention discloses an intelligent navigation channel management system based on multi-source data fusion. The system comprises a combined ship identification module, a positioning frequency updating module, a collision risk assessment module and an intervention management module. According to the invention, the system can sense multi-dimensional environmental parameters such as illumination intensity, visibility, AIS signal quality, radar echo signal-to-noise ratio and the like in real time by constructing a combined ship identification model containing AIS, radar, vision and infrared, and dynamically adjust the fusion weight of each sensor to compensate for the deficiency of a single sensor; according to the method, the robustness of ship dynamic monitoring is improved, high-precision tracking can be kept in severe weather, the data redundancy contradiction of a traditional multi-sensor system is avoided, and therefore continuous and stable target state input is provided for follow-up risk analysis.

Owner:GUANGDONG HONGSHENG SPACE INFORMATION TECH CO LTD
Bridge structure monitoring method and device based on microwave deformation radar
ActiveCN120831071AThermometers using physical/chemical changesFluid speed measurementThermal dilatationFeature set
The invention provides a bridge structure monitoring method and device based on a microwave deformation radar, and relates to the technical field of bridge structure monitoring, and the method comprises the steps: obtaining the multi-point three-dimensional displacement data of a bridge structure through the microwave deformation radar, carrying out the thermal expansion pseudo displacement compensation and multi-point space smoothing through combining with temperature information, and obtaining a displacement field after environment correction; secondly, extracting a vertical component and separating the vertical component into a static deformation component and a dynamic vibration component by adopting variational mode decomposition; further analyzing and identifying a decoupling region through a time window coherence coefficient, performing recursive quantitative analysis, bispectrum analysis and energy distribution entropy calculation on a dynamic signal of the region, and constructing a high-order damage sensitive feature set; and finally, the dynamic characteristics and the static curvature change are fused to form a comprehensive degradation degree index, the deviation degree is judged according to working condition classification and the mahalanobis distance, and multi-dimensional and cross-working-condition degradation identification and risk early warning of the bridge structure are achieved.

Owner:HUNAN UNIV
Low-altitude monitoring system based on multi-source heterogeneous sensing fusion and rule engine driving
The invention relates to the field of low-altitude airspace monitoring, and relates to a low-altitude monitoring system based on multi-source heterogeneous perception fusion and rule engine driving, which comprises a perception access layer used for completing data standardization and protocol adaptation and realizing data stream release through message middleware; the processing calculation layer is used for generating a structured alarm event; the application support layer is used for three-dimensional visual interactive display of target situation data and alarm events, unified access of multiple types of sensors such as radar, photoelectricity, radio frequency, ADS-B and meteorological sensors is realized through a plug-in protocol adapter, and target state estimation and track smoothing are realized by combining space-time registration and extended Kalman filtering. The limitation that an existing system can only process a single data source or simple superposition is overcome, and the target recognition precision and the track continuity are remarkably improved.

Owner:ZHONGKE BRILLIANT ROBOT (CHENGDU) CO LTD
Power control and beam management for communication and sensing
Methods and apparatuses for power control and beam management to enable coexistence of radar sensing and wireless communication. A method for a UE includes determining a sensing category or characteristics for a sensing application, and selecting a spatial filter for radar sensing transmission or reception based on determined sensing category or characteristics. The method further includes identifying a radar sensing transmission power and transmitting or receiving radar sensing signals using the spatial filter and the identified radar sensing transmission power. The method further includes reporting one of communication blockage, radar sensing beam information, or CSI adapted to the radar sensing beam information to a base station or neighboring UEs.

Owner:SAMSUNG ELECTRONICS CO LTD
Unmanned aerial vehicle autonomous obstacle avoidance system and method based on millimeter wave radar and multi-mode vision fusion
PendingCN120653016AVehicle position/course/altitude controlPosition/direction controlEngineeringVisual perception
The invention discloses an unmanned aerial vehicle autonomous obstacle avoidance system and method based on millimeter wave radar and multi-mode vision fusion, and the system comprises a millimeter wave radar module which is used for obtaining the distance, speed and point cloud data of an obstacle; the multispectral vision module comprises an RGB camera and an infrared camera and is used for extracting the texture, the category and the thermal characteristics of the obstacle; the embedded AI calculation unit is used for real-time data processing and fusion; the time-space synchronization module is used for aligning timestamps of radar and visual data through hardware trigger signals and unifying space coordinates based on joint calibration and an SLAM (Simultaneous Localization and Mapping) technology; and the feature level fusion module is used for fusing the radar point cloud features and the visual semantic features by adopting a lightweight network. Aiming at single sensor defects, complex environment challenges and hardware computing power limitation, a more efficient unmanned aerial vehicle autonomous obstacle avoidance system is constructed through multi-modal hardware fusion, lightweight feature processing, a dynamic adaptive mechanism and intelligent algorithm optimization, and all-weather and full-scene autonomous operation requirements are met.

Owner:SHANXI TAIYUAN GRID PROTECTION AUTOMATION SERVICE CENT
Sensing method and system based on millimeter radar waves
The invention relates to the technical field of radar sensing, and discloses a sensing method and system based on millimeter radar waves. The method comprises the steps that millimeter wave radar receiving signals are subjected to low-noise amplification, frequency bands are screened through a band-pass filter and then mixed with local oscillation signals to obtain distance and speed information, after analog-to-digital conversion digitization, features are extracted to distinguish a human body target in a closed / open space, and finally multi-scene adaptability analysis is executed to generate human body position state information. According to the invention, through construction of a signal processing link, from signal amplification, filtering, frequency mixing and digital processing to target identification and multi-scene adaptability analysis, comprehensive perception of a human body target is realized, a static human body and a non-human body interference source can be effectively distinguished, a processing strategy is automatically adjusted according to different space environment characteristics, and the processing efficiency is improved. And the accuracy and reliability of human body perception are greatly improved.

Owner:SHENZHEN HI LINK ELECTRONICS
Operation safety distance management method based on laser radar point cloud data
The invention relates to the technical field of safety monitoring, and particularly discloses an operation safety distance management method based on laser radar point cloud data, and the method comprises the steps: generating a dangerous point cloud set based on an initial three-dimensional point cloud model of a complete field environment; performing coordinate transformation on the point cloud data currently collected by the three-dimensional laser radar equipment based on the rigid body transformation matrix to obtain current point cloud data; registering the current point cloud data with the initial three-dimensional point cloud model and identifying all independent dynamic targets; determining a danger approaching trend of each independent dynamic target based on the motion prediction trajectory of each independent dynamic target; determining a dynamic safety distance threshold value of each dangerous dynamic target based on the danger approaching trend and the response delay of each independent dynamic target and the additional safety distance of the corresponding dangerous source area; triggering a corresponding alarm mechanism based on the dynamic safety distance threshold and the distance between the point cloud set of each independent dynamic target and the dangerous point cloud set; and the overall safety of a working site is improved.

Owner:内蒙古科安数图科技有限公司
Communication optical cable line intelligent inspection fault point rapid positioning method and device
PendingCN120658310ABiological modelsCharacter and pattern recognitionConfidence metricNavigation system
The invention relates to the technical field of communication engineering, in particular to a communication optical cable line intelligent inspection fault point rapid positioning method and device, and the method comprises the steps: obtaining optical cable line state data, constructing an intelligent fault detection model, recognizing an abnormal signal through wavelet transform and a threshold determination method, training an LSTM neural network in combination with historical fault data, and pre-judging a fault type. When a fault is detected, an unmanned aerial vehicle inspection unit is triggered, an inspection path is planned based on an improved Dijkstra algorithm according to the fault type and suspected fault area geographic information, an optical cable line is scanned and detected through a laser radar, physical fault features are recognized through a YOLOv5 algorithm, and geographic coordinates of a fault point are calibrated in combination with an inertial navigation system; and fusing sensor data and a detection result, evaluating a fault confidence level by adopting a DS evidence theory, and generating an alarm work order. Therefore, the problems of long positioning time consumption, high omission ratio, difficulty in distinguishing fault types and the like in the prior art are solved.

Owner:GAMMACOM COMMUNICATE SCHEME DESIGN CO LTD
Radar echo extrapolation method and system based on frequency domain enhancement
The invention discloses a radar echo extrapolation method and system based on frequency domain enhancement, and the method mainly comprises the following steps: obtaining and preprocessing a historical radar echo grayscale image sequence, generating a sequence sample through a sliding window, and dividing the sequence sample into a training set, a verification set and a test set; the method comprises the following steps: constructing a frequency domain enhanced U-Net network comprising an encoder-decoder structure, introducing a multi-scale deep convolution structure into an encoder and a decoder, and enhancing frequency domain features by using a frequency domain dynamic attention mechanism in jump connection; inputting the training set into the model for training by adopting a composite loss function comprising intensity weighted loss, frequency domain consistency loss and structural similarity loss; and inputting the test set into the trained model, and outputting a radar echo prediction result at a future moment. The method can be effectively applied to the fields of short-term and temporary weather forecast, severe convection monitoring and the like, and provides more accurate and reliable radar echo prediction support for meteorological disaster early warning.

Owner:HANGZHOU DIANZI UNIV
Three-dimensional multi-target tracking method fusing radar and vision multiple modes and related equipment
The invention discloses a radar and vision multi-mode fused three-dimensional multi-target tracking method and related equipment. The method comprises the following steps: establishing a three-dimensional constant turning rate and speed motion model for detecting a target vehicle; constructing a multi-modal measurement model, and obtaining a fusion target measurement result according to the point cloud data and the image data collected by the 4D millimeter wave radar; performing two-stage front and back frame matching and filtering according to a fusion target measurement result to obtain a matching target of the track; track life cycle management: newly building, confirming, keeping or deleting the track according to the matching result and the time step; according to the rule after track re-tracking, under the condition that the target is temporarily lost or shielded, a virtual track in the shielding period is constructed, state correction is conducted on the virtual track, the corrected state serves as the initial state of the current moment, and tracking continues. According to the invention, through fusion of complementary information of the 4D millimeter wave radar and the visual sensor, accurate sensing and tracking of three-dimensional multiple targets in a complex automatic driving environment are realized.

Owner:SOUTH CHINA UNIV OF TECH
Heterogeneous road structure cavity disease inspection method, device and equipment and storage medium
The invention discloses a heterogeneous road structure cavity disease inspection method, device and equipment and a storage medium, and the method comprises the steps: constructing a highly-simulated heterogeneous road structure model, and adaptively generating an irregular cavity disease meeting the horizon geometric constraint; the problems that electromagnetic wave reflection simulation is distorted due to the fact that a traditional homogeneous simplified model cannot reflect dielectric mutation between aggregate and a cementing material, and a regularized cavity form does not conform to a real stress distribution expansion mode are solved. According to the method, radar forward modeling simulation data containing complex heterogeneous backgrounds and randomly-shaped holes can be automatically generated in batches, a rich, real and diversified training data set is provided for intelligent identification of road internal diseases based on deep learning, and the bottleneck problem of lack of real disease radar image data is relieved.

Owner:CHANGSHA UNIVERSITY OF SCIENCE AND TECHNOLOGY
Landslide mass monitoring method based on unmanned aerial vehicle laser radar
The invention discloses a landslide mass monitoring method based on an unmanned aerial vehicle laser radar. The landslide mass monitoring method comprises the following steps: S1, constructing an exposed earth surface point cloud model of a first time phase; s2, constructing an exposed earth surface point cloud model of a second time phase; s3, establishing a standard point cloud data set; s4, constructing a multi-dimensional time sequence feature vector sequence; s5, introducing a fusion prediction model of the ARIMA and the neural network, and outputting a final prediction sequence of the deformation trend of the landslide mass; and S6, constructing a disaster chain propagation model, outputting a landslide early warning grade according to a preset grading threshold value, and performing real-time early warning information release and response linkage. According to the invention, through fusion of laser radar point cloud registration analysis and ARIMA-neural network prediction modeling, high-precision dynamic monitoring and early warning of tiny deformation of the landslide mass are realized, and the method is suitable for landslide early identification and disaster emergency response scenes in a complex terrain environment.

Owner:湖北煤炭地质物探测量队
Unmanned aerial vehicle positioning method and system in combination with environment characteristics
PendingCN120908842ANavigational calculation instrumentsNavigation by speed/acceleration measurementsDecision modelEngineering
The invention relates to the technical field of unmanned aerial vehicle positioning, in particular to an unmanned aerial vehicle positioning method and system combining environment characteristics. According to the technical scheme, the method comprises the steps that multi-modal data of the environment where the unmanned aerial vehicle is located are collected through a multi-source heterogeneous sensor, and the multi-modal data comprise GNSS signal data, visual image data, laser radar point cloud data, inertia measurement data and electromagnetic interference monitoring data; and carrying out cooperative processing on the multi-modal data by utilizing the fusion deep learning model. A comprehensive basis is provided for subsequent processing through multi-source data collection, data quality and feature matching reliability are improved through fusion processing, timely and accurate positioning is guaranteed through real-time calculation, safe and efficient flight is achieved through a decision-making model based on accurate positioning, and the flight speed is high. The method not only solves the traditional technical problems of signal shielding, interference, dynamic interferent influence and contradiction between real-time performance and precision in a complex environment, but also shows excellent positioning stability and adaptability in various complex scenes.

Owner:CHONGQING JIANZHU COLLEGE
Joint communication and sensing
There is disclosed a method of operating a radio node in a wireless communication network, the radio node being adapted for wireless communication, and being adapted for sensing and / or for radar operation. The method includes transmitting sensing signalling of a second type based on transmission and / or reception of sensing signalling of a first type. The disclosure also pertains to related devices and methods.

Owner:TELEFONAKTIEBOLAGET LM ERICSSON (PUBL)
Offshore platform anti-collision device and method based on multi-mode BEV perception
PendingCN121122073AWave based measurement systemsParticular environment based servicesNetwork communicationLidar
The invention discloses an offshore platform anti-collision device and method based on multi-mode BEV perception, and the device comprises a three-dimensional fusion distance measurement module, a UWB distance measurement module, a ship navigation state monitoring module, a platform marine environment monitoring module, and a central processing unit. The three-dimensional fusion ranging module comprises a holder, a laser radar and a camera, and is used for performing 360-degree three-dimensional scanning on the periphery of the offshore platform; the UWB distance measuring modules are installed on the periphery of a ship and pile legs of an offshore platform. The ship navigation state monitoring module is used for acquiring ship position, navigational speed and course information in real time; the platform marine environment monitoring module collects wind wave data and weather data near the offshore platform and route information of passing ships through network communication. The invention discloses an offshore platform anti-collision device with real-time monitoring and collision risk assessment functions, the anti-collision safety of an offshore platform is improved, and the occurrence rate of collision accidents is reduced.


Owner:CHINA NAT OFFSHORE OIL CORP +1
Radar lifting control method and system based on meteorological monitoring
ActiveCN120949534ASafety arrangmentsRadio wave reradiation/reflectionResidual neural networkPhysical model
The invention discloses a radar lifting control method and system based on meteorological monitoring, and relates to the technical field of radar lifting control, and the method comprises the steps: completing the switching of a power supply and communication after a radar is powered on, initializing a controller, collecting the data of a meteorological station, and generating a future fusion wind speed in real time through a Kalman filtering physical model and a residual neural network; future fused wind speed is converted into wind pressure for evaluation, the risk degree is judged according to the evaluation result, early warning is given out, and the controller is preheated to enter a lifting preparation state. The input stability is improved through meteorological data sliding window smoothing and feature extraction, wind speed dynamic prediction and uncertainty quantification are achieved through XGBoost prediction and residual variance estimation, the time sequence consistency and robustness are enhanced through remote API interpolation correction and adaptive extended Kalman filtering, residual correction is conducted through a neural network, the prediction precision is improved, and the prediction accuracy is improved. And a reliable decision basis is provided for radar lifting control.

Owner:ZHONGAN GUOTAI (BEIJING) TECH DEV CENT
Unmanned aerial vehicle intrusion real-time alarm and countering guidance system based on RID information
The invention discloses an unmanned aerial vehicle intrusion real-time alarm and countering guidance system based on RID information. The system comprises a multi-source information acquisition and fusion module, an intrusion detection and threat evaluation module, a real-time alarm and countering strategy generation module, a feedback evaluation and strategy iteration module, a signal loss prediction and compensation module, a comprehensive processing terminal module and the like. The system establishes a three-dimensional geofence model by analyzing remote identification information of the unmanned aerial vehicle and fusing radar, photoelectric, electromagnetic and other multi-source data, and performs dynamic judgment and multi-factor threat grading on a target intrusion state. Multi-mode alarm is automatically triggered according to the threat level, and a hierarchical countering scheme from broadcast alarm and electromagnetic interference to physical capture is generated; and when the RID signal is lost, the system realizes continuous tracking and state recovery of the target by using a motion prediction and probability association algorithm.

Owner:BAY AREA LOW ALTITUDE RESEARCH INSTITUTE (GUANGDONG) CO LTD
Unmanned aerial vehicle detection system and method based on vision, laser radar and sound waves
The invention relates to the technical field of unmanned aerial vehicle detection and recognition, in particular to an unmanned aerial vehicle detection system and method based on vision, laser radar and sound waves, and the system comprises a sensor unit, a data processing fusion unit and a target recognition tracking unit. The data processing fusion unit performs multi-source data alignment and weighted fusion to extract texture, shape and color features of the image, point cloud generates a depth map, sound wave signals are mapped into a two-dimensional feature map, and weights are dynamically distributed based on sensor reliability to generate a unified feature map; the target identification and tracking unit identifies the type of the unmanned aerial vehicle by using the optimized deep learning model and realizes accurate prediction and updating of position and speed states in combination with Kalman filtering, and the decision response unit triggers sound-light alarm and wireless alarm for the non-cooperative unmanned aerial vehicle in real time and transmits target dynamic information to the ground station. And the target detection accuracy of the unmanned aerial vehicle in a complex environment is improved.

Owner:TIANMUSHAN LABORATORY
Safety monitoring system of high transverse supporting system for cable-stayed bridge man-shaped tower column construction
ActiveCN121067747ANavigation by speed/acceleration measurementsBiological modelsData acquisitionLidar
The invention discloses a safety monitoring system of a high transverse support system for cable-stayed bridge man-shaped tower column construction, and relates to the technical field of bridge construction monitoring, the system comprises a creeping formwork integrated sensing module used for generating a point cloud model by using a mechanical arm integrated on a hydraulic creeping formwork platform and a laser radar scanning tower column curved surface, combining with a preset building information model coordinate, adaptively adjusting the mounting posture of the sensor, and outputting the mounting coordinate position of the sensor; the optical fiber sensing network module is used for collecting original strain and temperature data by using a distributed optical fiber sensor deployed along a main stress path of the support truss; an inertial navigation fusion positioning module; a digital twinning early warning module; and an edge calculation relay module. According to the invention, a full-process monitoring chain from data acquisition to risk early warning is constructed through cooperation of multiple modules, full-period and multi-dimensional dynamic control of construction of the human-shaped tower column high transverse support system is realized, and timely perception and overall control of potential risks are ensured.

Owner:CHINA COMMUNICATIONS COMMUNICATIONS SECOND AVIATION ADMINISTRATION JILIN CONSTRUCTION CO LTD +1
Laser radar point cloud data processing surveying and mapping method and system based on deep learning
The invention relates to the technical field of surveying and mapping, and discloses a laser radar point cloud data processing surveying and mapping method and system based on deep learning, and the method comprises the steps: obtaining original point cloud data collected by a laser radar, carrying out the preprocessing of the original point cloud data, and obtaining the preprocessed point cloud data; taking a U-Net network as a basic framework, and introducing residual connection and a multi-scale feature fusion mechanism to carry out de-noising processing on the preprocessed point cloud data to obtain de-noised point cloud data; inputting the denoised point cloud data into a Point CNN-GAT model to extract local geometric features and a global topological relation, introducing a dynamic cavity convolution module, and adaptively adjusting the sampling range of a convolution kernel; registering the comprehensive feature vector output by the Point CNN-GAT model, and generating a corresponding surveying and mapping result according to the registered point cloud data; according to the invention, the time cost of data circulation and manual intervention is reduced, and the overall processing efficiency is improved.

Owner:CHENGDU WELCH SPACE INFORMATION TECH CO LTD
Unmanned aerial vehicle autonomous decision reinforcement learning method, system and device based on multi-objective optimization, and storage medium
The invention relates to the technical field of unmanned aerial vehicle autonomous decision, provides an unmanned aerial vehicle autonomous decision reinforcement learning method, system and device based on multi-objective optimization, and a storage medium, and solves the problems of limited dynamic task distribution capability and poor decision capability of an unmanned aerial vehicle. The method comprises the steps that based on infrared data and radar data, a moving track prediction sequence of a suspicious target in a target area is generated, a moving probability thermodynamic diagram is constructed, and the target area comprises a patrolled area; performing Doppler frequency shift analysis on the radar data to generate a target velocity vector field; and in combination with the position data of the unmanned aerial vehicle, outputting an unmanned aerial vehicle autonomous decision reinforcement learning result of a dynamic segmentation scheme containing an unpatrolled region through a region re-division reinforcement learning model based on a reward function for multi-objective optimization. The reward function is used for reflecting area coverage rate maximization, target tracking success probability maximization and path energy consumption minimization. According to the invention, autonomous intelligent decision-making of the unmanned aerial vehicle on the unpatrolled area is realized.

Owner:ZHUHAI XIANG YI AVIATION TECH CO LTD