

Patents
Literature
25180results about "Instruments for road network navigation" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
System and method to notify a person of a traveler's estimated time of arrival
InactiveUS20050114014A1Instruments for road network navigationRoad vehicles traffic controlTime of arrivalThird party
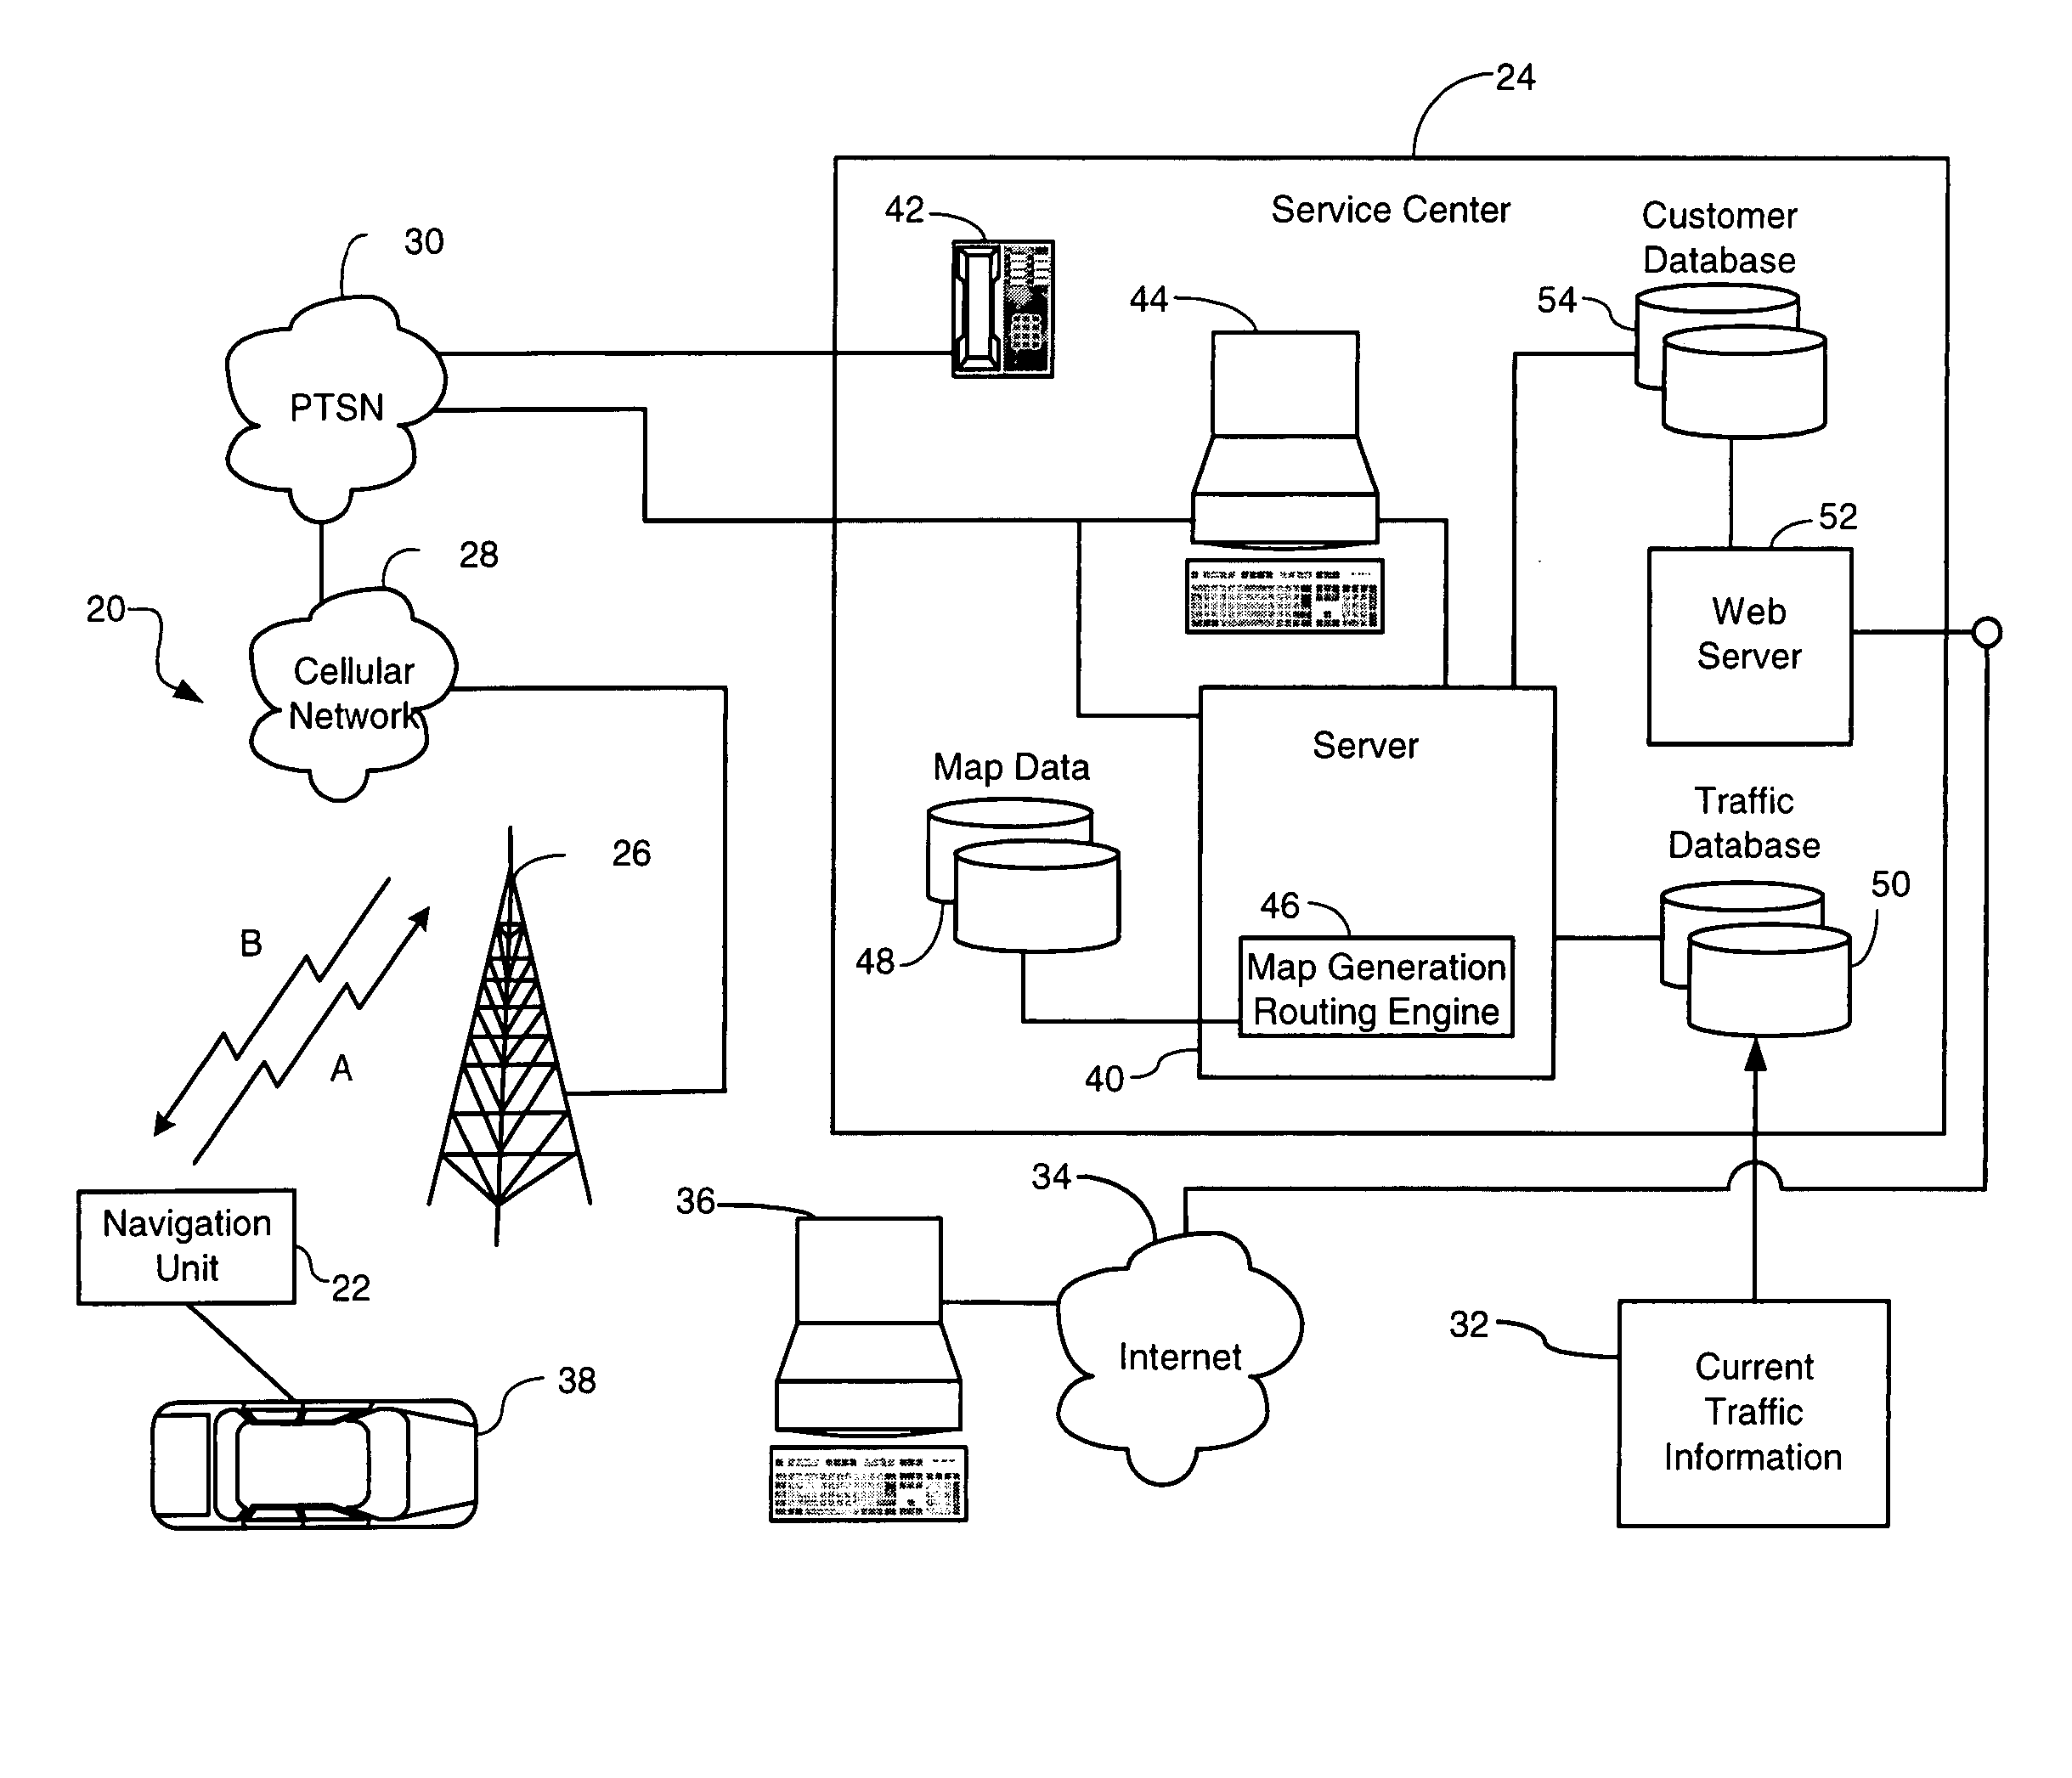
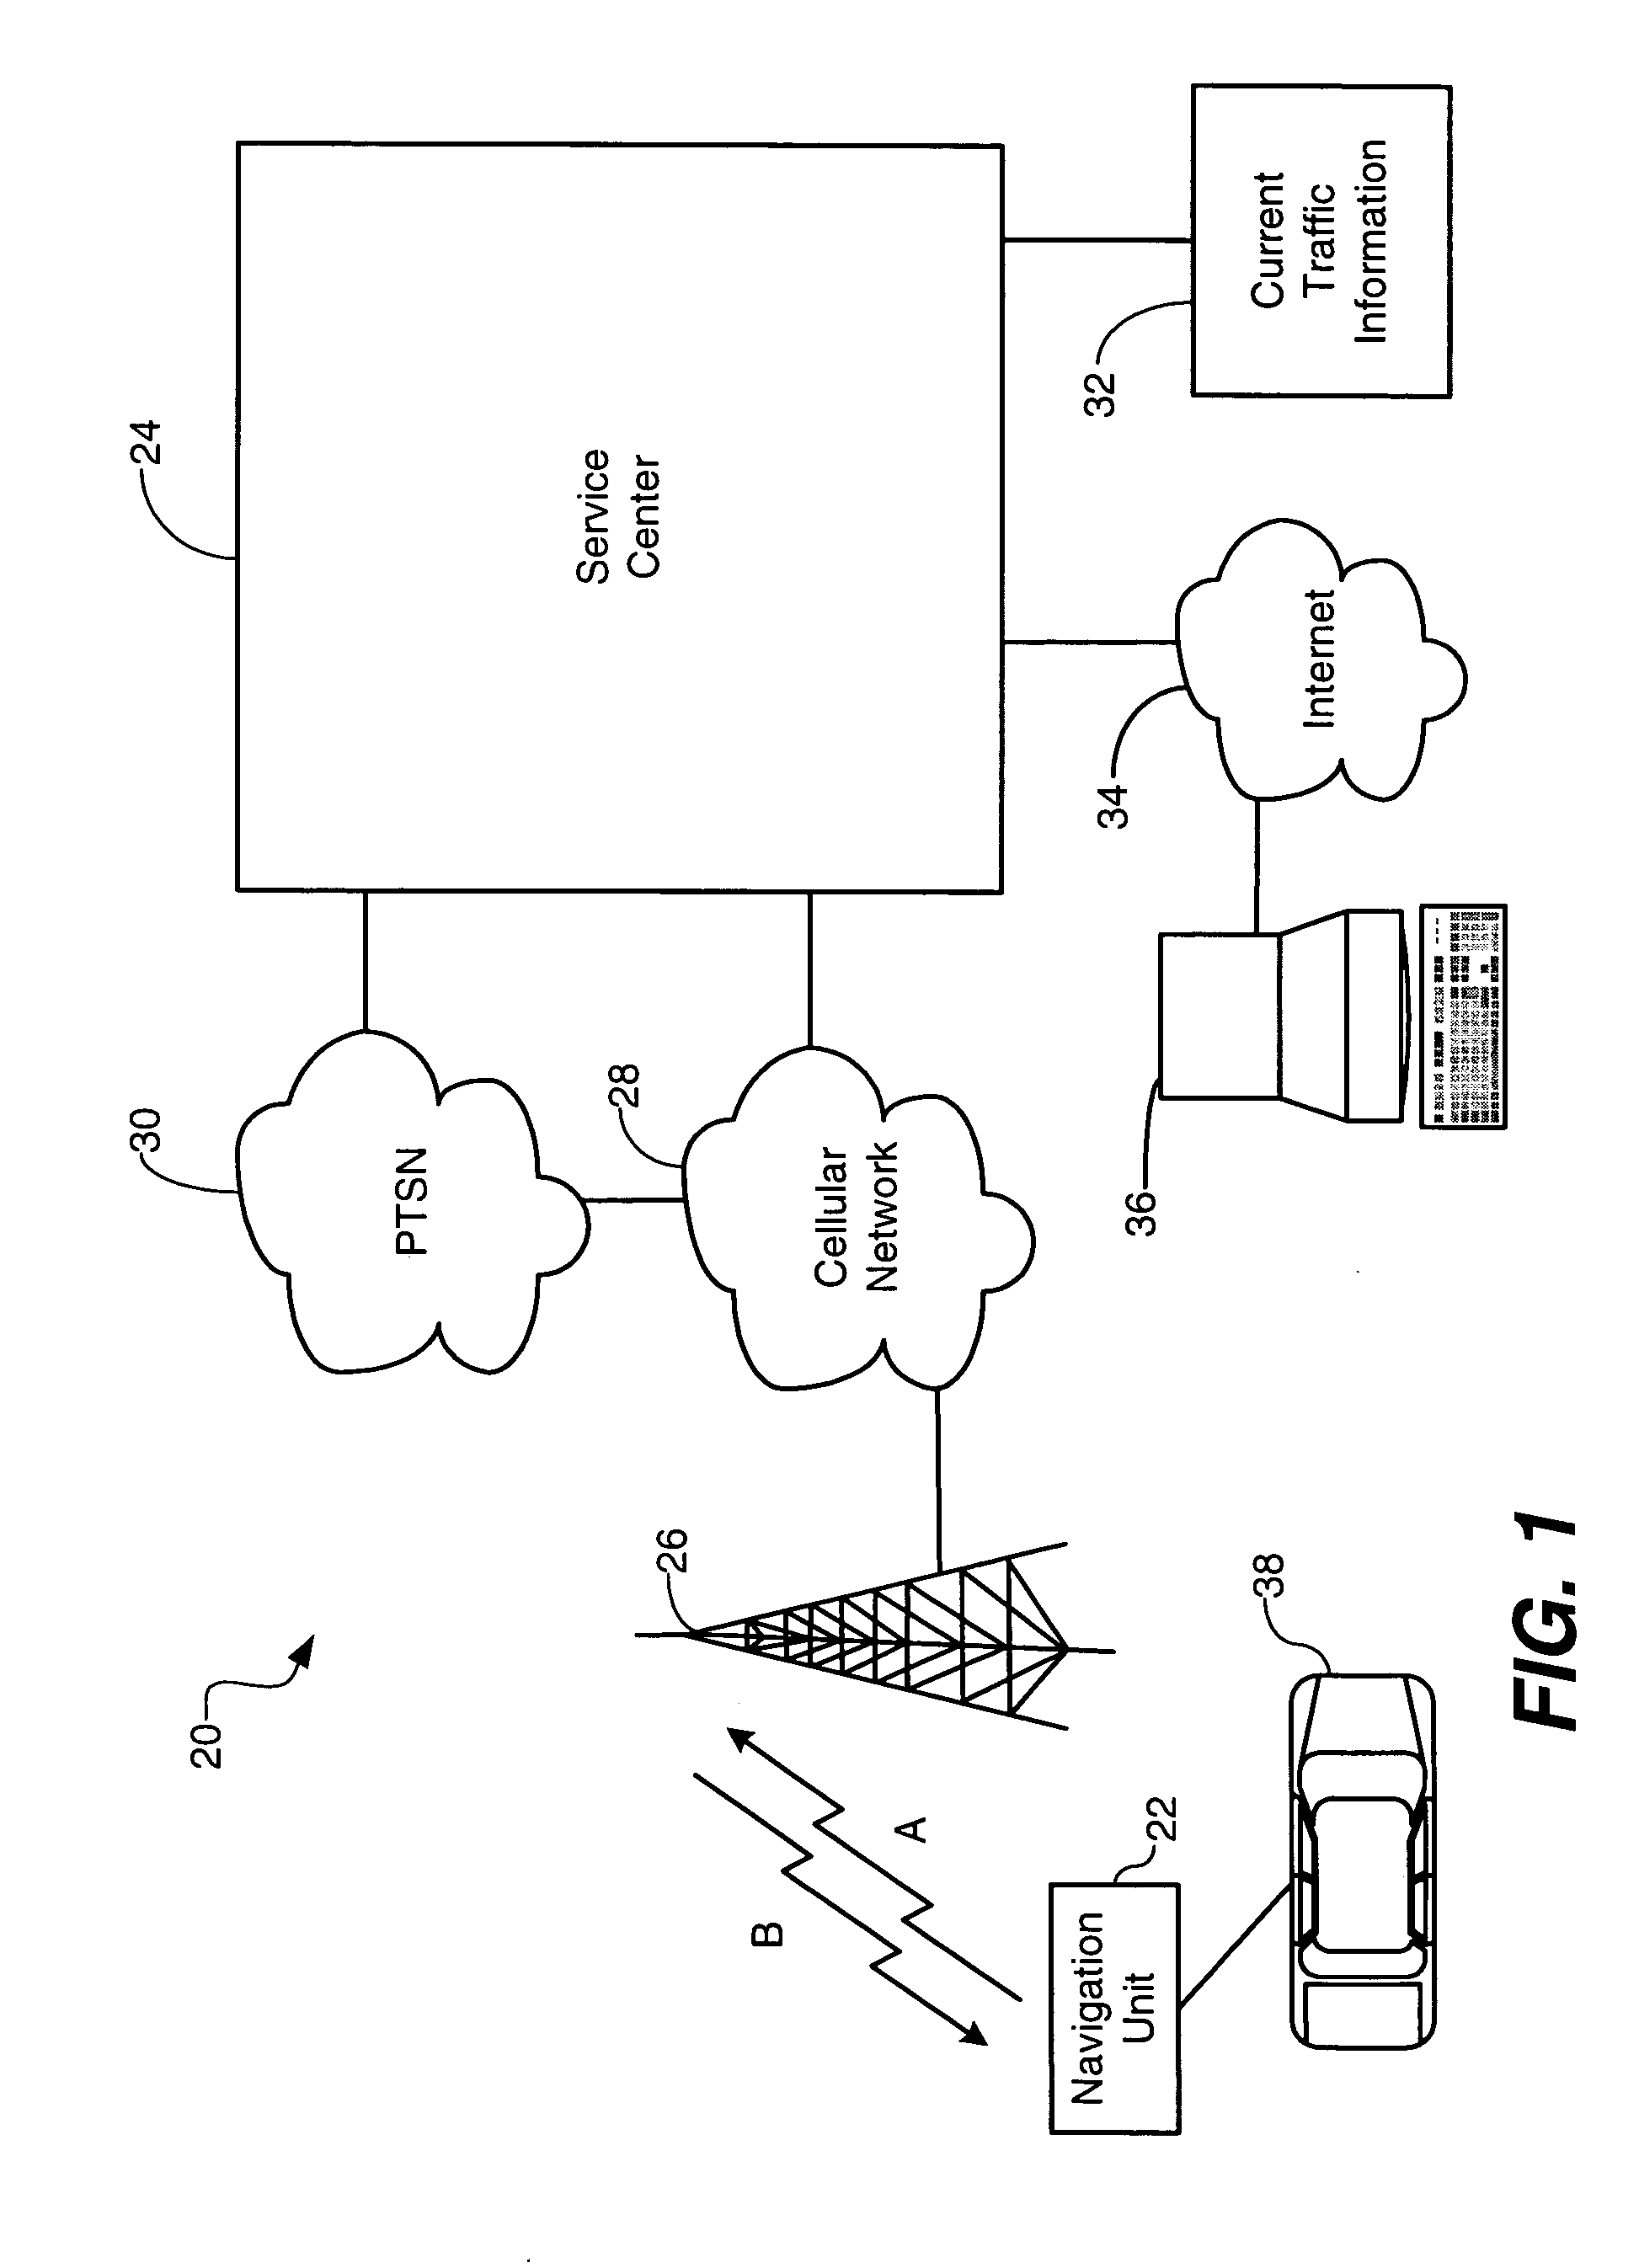
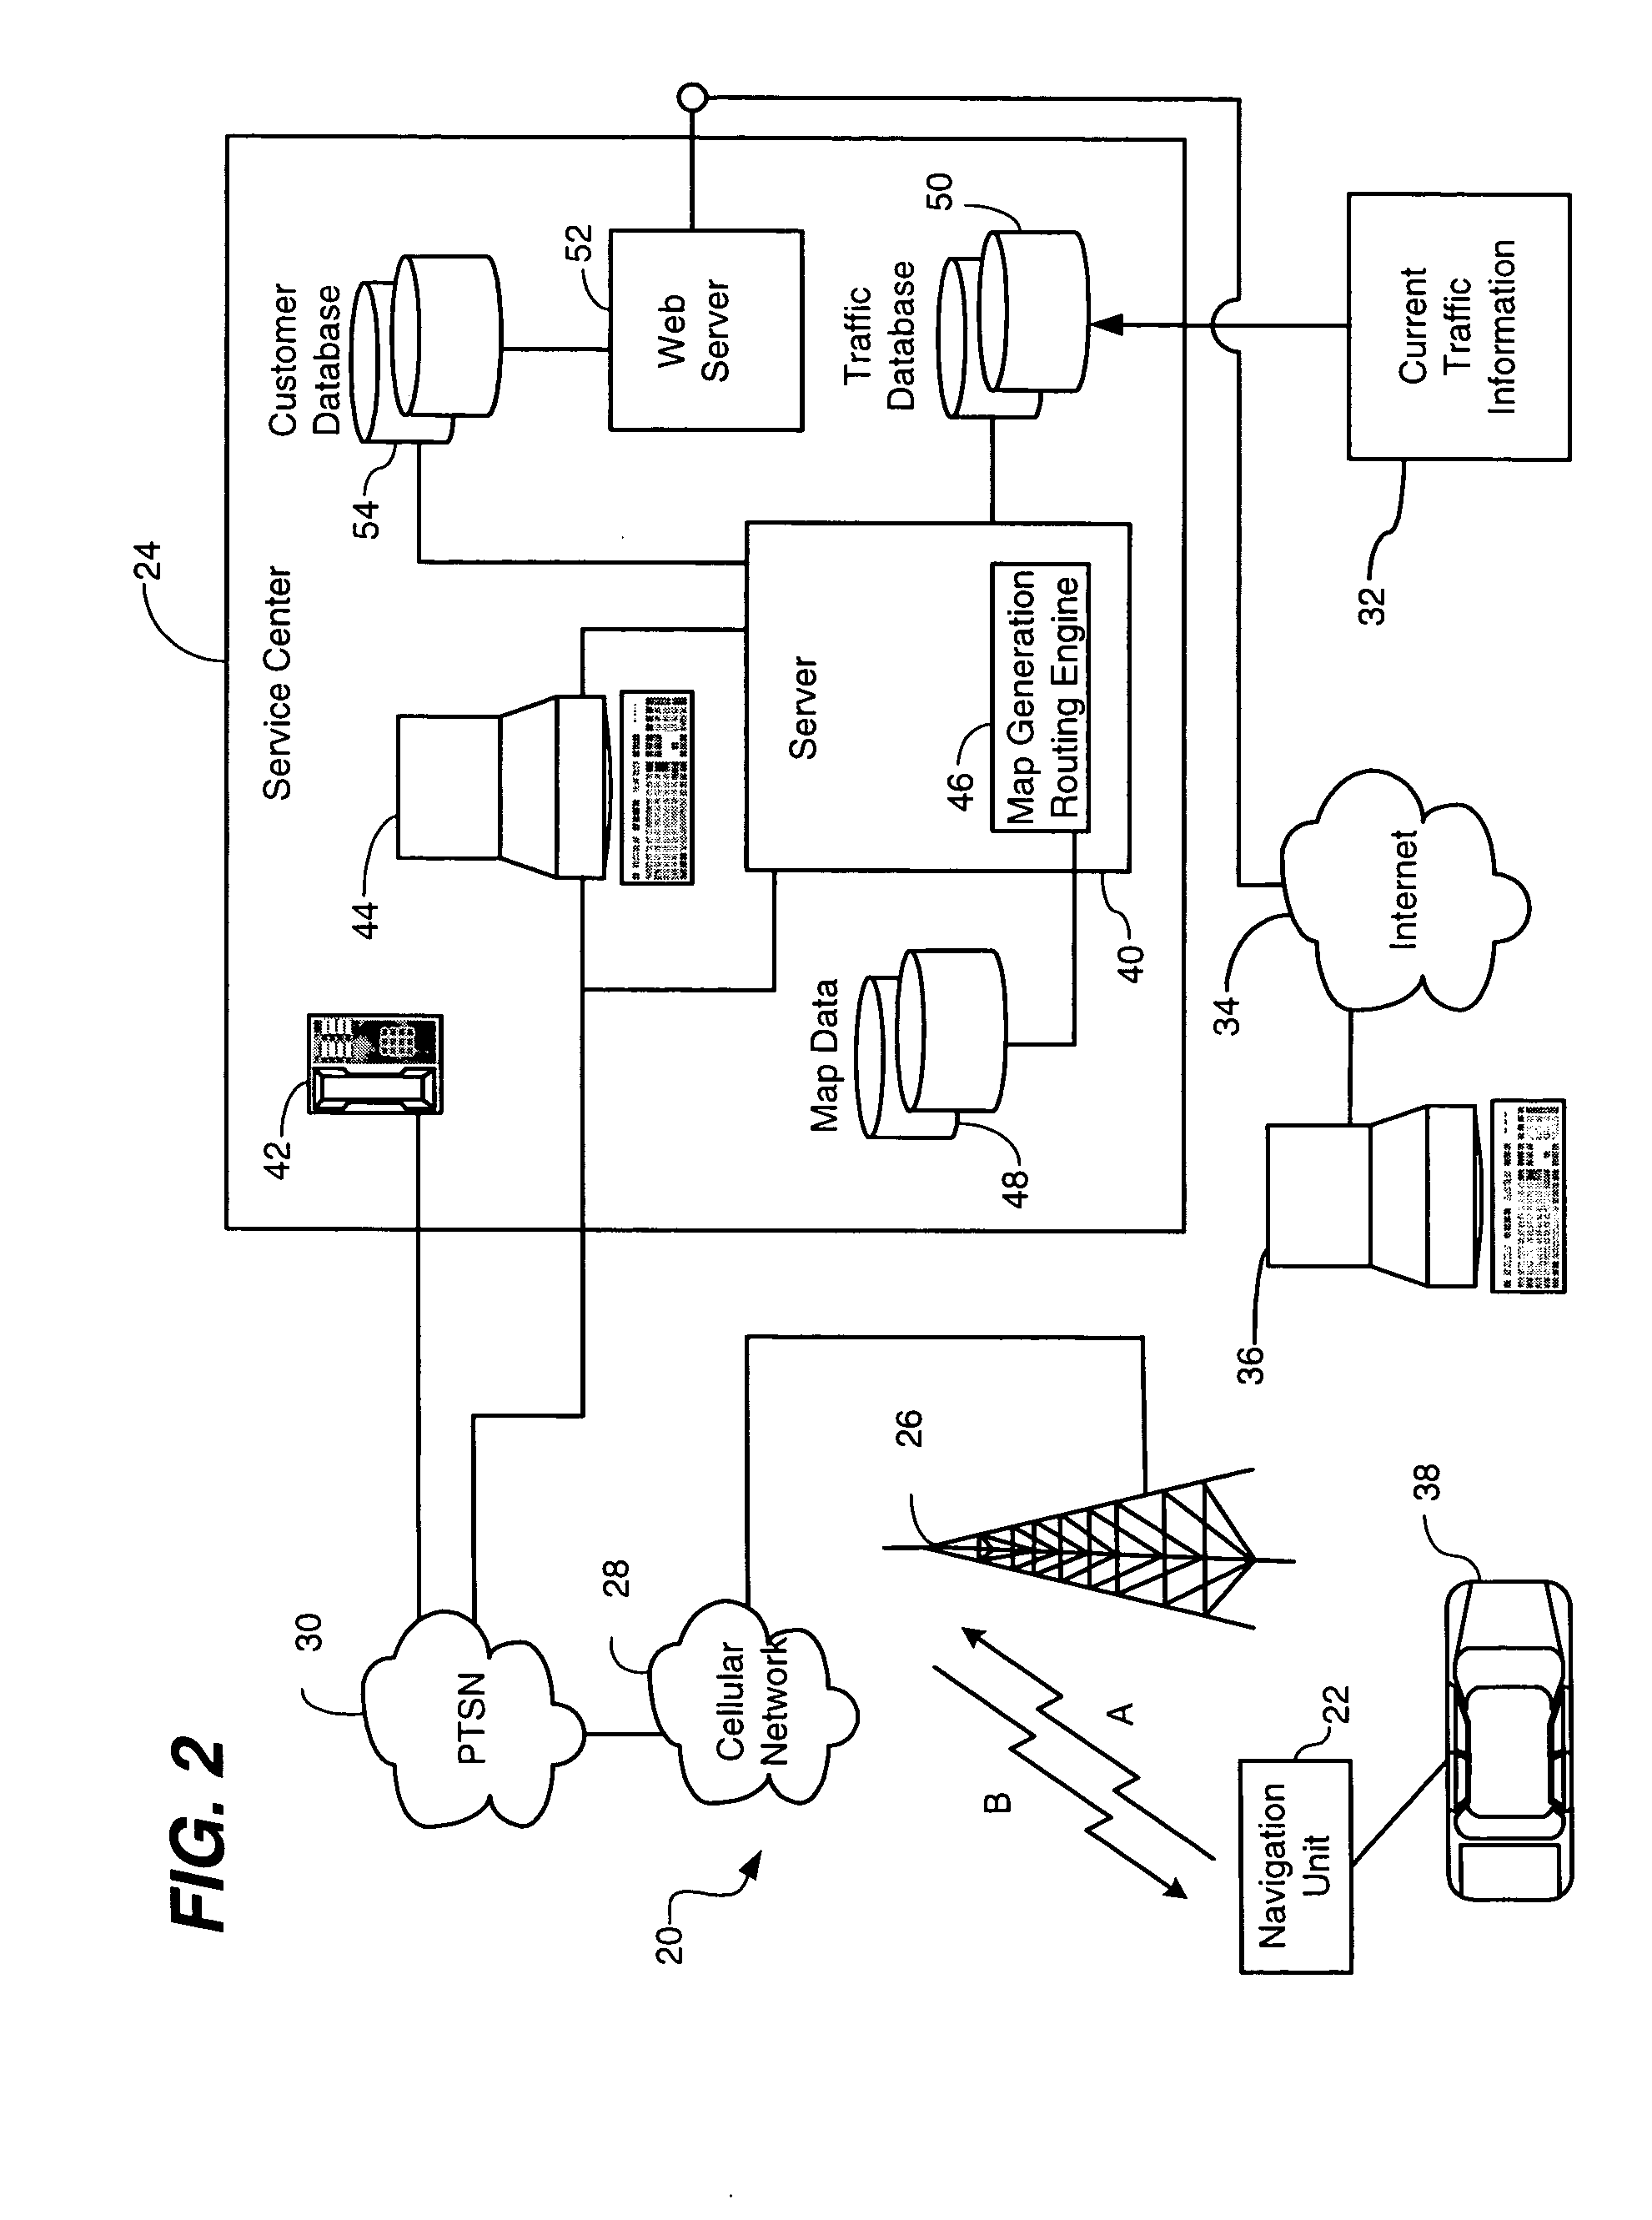
A system and method of calculating an estimated time of arrival for a traveler is provided, along with a notification of this estimated time that is sent to a third party. The traveler is equipped with a navigation unit having a global positioning sensor and a wireless communications device. The navigation unit communicates with a service center equipped with a server capable of generating a preferred navigational route for the traveler. The service center also includes a traffic database for maintaining current traffic information. Once the traveler has selected a predetermined time and frequency of notifications based upon a selected criterion, the navigation unit transmits the traveler's position and velocity to the service center. The service center then calculates the estimated time of arrival based upon the traveler's position, velocity, distance to be traveled and traffic and weather conditions. Once this time is calculated, the service center sends a notification to the third party.
Owner:MOTOROLA INC
Dynamic path planning method and system in intelligent traffic system
InactiveCN120252763AMathematical modelsInstruments for road network navigationData streamIntelligent transportation system its
The invention provides a dynamic path planning method and system in an intelligent traffic system, and relates to the technical field of intelligent traffic. Constructing a dynamic road network traffic capacity model based on a space-time diagram convolutional network; generating a multi-branch trajectory prediction result with a confidence score, adaptively starting an encryption parameter synchronization mechanism in combination with vehicle density, and generating a candidate path set through multi-agent collaborative game optimization; performing multi-dimensional deviation degree evaluation based on actual driving data and planning expectation; synchronously generating a multi-mode cooperative guidance signal; the system comprises a multi-source data fusion unit, a space-time modeling engine, a hierarchical decision-making system, a path verification and execution module, a closed-loop feedback controller, an event response system and a multi-mode man-machine interface. According to the method, the global resource utilization efficiency is improved through cooperation of data-driven modeling and hierarchical game decision, and the real-time performance, the safety and the system adaptability of path planning are improved through a closed-loop feedback and event response mechanism.

Owner:HEILONGJIANG COMM POLYTECHNIC
Vehicle-mounted Beidou positioning deviation self-calibration system fused with inertial navigation information
ActiveCN120369008AInstruments for road network navigationTime-division multiplexData streamFilter algorithm
The invention discloses a vehicle-mounted Beidou positioning deviation self-calibration system fused with inertial navigation information, and relates to the technical field of navigation and positioning. The method is used for solving the problems of positioning deviation accumulation and signal failure in a complex environment. The system realizes space-time alignment of inertial navigation and Beidou observation data through timestamp interpolation and coordinate system conversion, and constructs a multi-source synchronous data stream. A difference value between an inertial navigation calculation speed and a Beidou Doppler speed is analyzed based on a vehicle incomplete constraint model, and a weight factor is generated in combination with a confidence threshold to suppress abnormal observation. A geometric matching error is calculated through a high-precision lane map curvature and a vehicle steering angle, and candidate tracks are screened to generate transverse calibration parameters. The noise covariance is dynamically adjusted through a tight coupling filtering algorithm, the mode is switched to a lane constraint calibration mode when a Beidou signal is interrupted, inertial navigation errors are compensated through error boundary constraint, and stable output is achieved. Multi-source data deep fusion and adaptive robust calibration are realized, and system robustness and positioning continuity are improved.

Owner:SHANGHAI YIYAO INFORMATION TECH CO LTD
Systems and methods for vehicle control using terrain-based localization
PendingUS20250065894A1Instruments for road network navigationVehicle headlampsDriver/operatorLocalization system
Systems and methods described herein include implementation of road surface-based localization techniques for advanced vehicle features and control methods including advanced driver assistance systems (ADAS), lane drift detection, passing guidance, bandwidth conservation and caching based on road data, vehicle speed correction, suspension and vehicle system performance tracking and control, road estimation calibration, and others.

Owner:CLEARMOTION INC
High-performance loosely-coupled multi-modal data fusion system for smart driving environmental perception system and vehicle-mounted device
PCT designated stageWO2025241308A1Image enhancementInstruments for road network navigationData setTracking model
Disclosed are a high-performance loosely-coupled multi-modal data fusion system for a smart driving environmental perception system and a vehicle-mounted device, comprising: a fusion detection model based on a modality-independent feature interaction strategy, which is configured for converting a LiDAR point cloud, a camera image, and a millimeter-wave radar point cloud into a unified bird's-eye view representation, and performing multi-modal fusion; and a fusion tracking model based on a motion-appearance feature cascaded coupling data association strategy, which is configured for performing subsequent trajectory tracking and matching according to multi-modal fusion feature information. A VoD data set and a K-Radar data set are selected for training, verifying, and testing the comprehensive performance of the models, and a TensorRT accelerated inference model is applied, then quantized, and deployed to a vehicle-mounted computational testing platform. The present invention is compatible with mainstream sensor deployment solutions, and achieves the efficient complementary fusion of multi-source heterogeneous sensor information, significantly improving the reliability, accuracy, and adaptability of vehicle-mounted perception systems, thereby effectively responding to extreme operating conditions such as complex traffic scenarios and inclement weather.

Owner:JIANGSU UNIV
IMU (Inertial Measurement Unit) dynamic calibration and compensation method and device, vehicle-mounted navigation equipment and storage medium
The invention discloses an IMU (Inertial Measurement Unit) dynamic calibration and compensation method and device, vehicle-mounted navigation equipment and a storage medium. The IMU dynamic calibration and compensation method comprises the following steps: acquiring original data of an IMU, sampling and integrating with environmental parameters to obtain an initial measurement sequence; periodically decomposing and calculating the influence of environmental factors on an IMU output value to obtain a measurement supplementary sequence; carrying out segmented calibration and iteration to obtain a calibration reference value; an error change rule is analyzed, and a calibration mapping amount is obtained through feature analysis; performing environmental factor decomposition to obtain compensation factors; each compensation factor is dynamically checked, and a correction coefficient is obtained through threshold comparison; compensating the original data by using the correction coefficient, and reconstructing the data to obtain a correction sequence; carrying out stability analysis on the correction sequence, and obtaining a drift parameter according to a change trend; and carrying out difference analysis on the drift parameter and the calibration reference, and carrying out multi-point correction to obtain a final calibration result. According to the technical scheme, the IMU original data can be accurately obtained, the environmental influence is effectively processed, dynamic compensation is achieved, and long-term stability is guaranteed.

Owner:ZHUHAI MAGIC CUBE INTELLIGENT TECHNOLOGY CO LTD
Method and system for establishing and planning intelligent path of car in scenic spot based on AI algorithm
PendingCN119809067AInstruments for road network navigationData processing applicationsSimulationRoad networks
The invention provides an AI algorithm-based scenic spot car intelligent path establishing and planning method and system, and relates to the technical field of path planning, and the method comprises the steps: collecting scenic spot road geographic information data, and constructing a weighted road network model; collecting real-time positioning of the trolley and sensor data; using the reinforcement learning model to generate a real-time optimal path planning strategy; calculating an initial recommendation path; road condition changes are monitored, and a path is dynamically adjusted; and outputting the updated optimal path scheme and carrying out navigation. According to the method, intelligent and real-time path planning of the vehicles in the scenic area can be realized.

Owner:BEIJING SUBCUBIC TECH CO LTD
Vehicle gateway device and interactive map graphical user interfaces associated therewith
ActiveUS12140445B1Instruments for road network navigationGraphical user interfaceHuman–computer interaction
A system receives vehicle metric data from a gateway device connected to a vehicle. The vehicle gateway device gathers data related to operation of the vehicle and / or location data. The system receives data from multiple vehicles. The vehicle gateway device gathers vehicle metric data and correlates the metric data with location data. The system presents the correlated data in an interactive map graphical user interface.

Owner:SAMSARA INC
Quadruped robot autonomous navigation method and system for special environment
ActiveCN119469168AReliable design principleSimple structureInstruments for road network navigationInternal combustion piston enginesPoint cloudOdometer
The invention relates to the technical field of navigation, and particularly provides a quadruped robot autonomous navigation method and system for a special environment, and the method comprises the steps: generating a semantic tag for depth point cloud data corresponding to a depth image through employing a recognition result of a target detection network for the depth image; calculating local odometer information according to the laser point cloud data and the inertial sensor data by using a laser radar mileage calculation method; fusing the depth point cloud data with the semantic label, the laser point cloud data with the semantic label and the local speedometer information to obtain positioning data in a pre-constructed point cloud map; constructing a multi-layer cost map according to the pre-constructed point cloud map, the newly acquired depth image, the laser point cloud data and the inertial sensor data by using a sensing method of a region planner; and generating navigation path information according to the positioning data and the multi-layer cost map by using a global path planning algorithm and a local path planning algorithm. The method improves the navigation precision.

Owner:SHANDONG ENERGY GRP CO LTD +1
Using large language models for similarity determinations in content generation systems and applications
PendingUS20240419907A1Natural language translationInstruments for road network navigationFeature vectorLinguistic model
Approaches presented herein provide for the ability to process, store, index, and search geospatial information such as maps with flexible granularity. A set of observations, such as may include sensor data captured for a region of an environment, can be fed as input to a language model. The language model can generate a tokenized description of the region, as may include a text string of tokens encapsulating semantics, topology, geometry, and / or other aspects of the region. A feature vector or embeddings for the region can be generated based on the tokenized description, and a similarity search performed against a vector database, for example, to identify similar feature vectors corresponding to similar regions or domains. Labels or other information associated with these similar feature vectors can be automatically applied to the example region. Clustering of feature vectors or other embeddings can also be performed based in part on the similarity.

Owner:NVIDIA CORP
Cloud based multi vehicle path planner
ActiveUS20250224236A1Instruments for road network navigationRoad vehicles traffic controlCloud baseEngineering
Aspects presented herein relate to perception data collection and curation. In one aspect, a network entity receives, from a first set of user equipments (UEs), a first set of perception data collected by the first set of UEs. The network entity configures, for a second set of UEs based on the first set of perception data, at least one of: a set of planned routes and time plans for collecting a second set of perception data or a set of embeddings centroids. The network entity receives, from the second set of UEs, the second set of perception data based on at least one of the configured set of planned routes and time plans or the configured set of embeddings centroids.

Owner:QUALCOMM INC
Global static and local dynamic-based underwater tunnel path planning method
PCT designated stage expiredWO2024239414A1Instruments for road network navigationNavigational calculation instrumentsSimulationPath plan
A global static and local dynamic-based underwater tunnel path planning method, which is applied to the technical field of autonomous navigation of underwater robots. The global static and local dynamic-based underwater tunnel path planning method specifically comprises the following steps: on the basis of an A* global path planning algorithm, planning a global static path of a whole map; during driving along the global static path, continuously performing detection on obstacles, when an obstacle is detected, switching to a DWA local path planning algorithm within a local range for path planning, and bypassing the obstacle; and when there is no obstacle in an early-warning area around an underwater robot, selecting a waypoint which is generated by the global path planning algorithm and closest to a current position in an advancing direction, driving the underwater robot to advance to the selected waypoint, and returning to the global static path to continue traveling. In this way, the underwater robot may travel to a destination from a starting point without causing collisions during the process.

Owner:ENERGY STORAGE RES INST OF CHINA SOUTHERN POWER GRID PEAK-FREQUENCY MODULATION POWER GENERATION CO LTD
Multi-dimensional data fusion and intelligent decision-making-based real-time dynamic scheduling system for hazardous chemical vehicles in chemical industry park
A chemical industrial park hazardous chemical substance vehicle real-time dynamic scheduling system based on multi-dimensional data fusion and intelligent decision-making comprises a vehicle monitoring module used for collecting dynamic information of transport vehicles in real time and monitoring the running state of each vehicle; the risk assessment module is used for calculating the current risk level of the transportation task based on the data collected in real time in combination with a risk assessment model; the path optimization module is used for calculating and adjusting an optimal driving path through a dynamic A * path planning algorithm; and the emergency response module is used for automatically starting when the high-risk condition is detected, so that the safety in the dangerous chemical transportation process is ensured. The invention aims to realize real-time and dynamic scheduling of the hazardous chemical vehicles in the chemical industrial park through multi-dimensional data fusion and intelligent algorithm design. By integrating multi-dimensional data of vehicles, goods, external environment, time, space and the like, the system can be ensured to automatically adjust a scheduling scheme in an emergency, and an efficient emergency response mechanism is provided.


Owner:ZHONGKE XINGTU JINNENG (NANJING) TECH CO LTD
Logistics park vehicle path planning method and system
InactiveCN119245675AImprove the level of operation managementreduce wearInstruments for road network navigationNavigational calculation instrumentsVirtual vehicleCarriageway
The invention discloses a logistics park vehicle path planning method and system, and the method comprises the steps: obtaining the real-time position and task state information of a vehicle in a park, dynamically constructing a vehicle path planning network model, dividing a road into nodes and edges, and forming a directed weighted graph; according to the directed weighted graph, an improved multi-lane algorithm is adopted, the path length, the congestion degree and the vehicle characteristic factors are comprehensively considered, and the optimal path of each vehicle is calculated; for the optimal path, introducing a virtual lane and a time dimension, pre-judging occupation conditions of multiple vehicles on the virtual lane for each time slice, and constructing a conflict constraint matrix; obtaining park high-precision map data, extracting road network topology, lane lines and traffic sign marking elements, performing lane-level refinement on the optimal path, and generating a driving track; and through a multi-sensor fusion positioning technology, obtaining high-precision position and attitude information of the vehicle, matching the high-precision position and attitude information with the driving track, and calculating a track tracking error.

Owner:SHENZHEN ZHIHUI QICE TECH CO LTD
Robot path planning method based on parallel sampling point optimization RRT algorithm
PendingCN119146994Aspeed up fusionavoid generatingInstruments for road network navigationInternal combustion piston enginesPathPingAlgorithm
The invention discloses a robot path planning method based on a parallel sampling point optimization RRT algorithm. The robot path planning method mainly aims at the problems that the RRT algorithm is low in random tree search efficiency, the path is zigzag and discontinuous, and the algorithm adaptability to different environments is low. The method comprises the following steps: firstly, randomly sampling a plurality of nodes by adopting a multipoint parallel weighted heuristic sampling strategy, establishing an evaluation function introducing a distance factor and a corner factor, and selecting an optimal sampling node for expansion; a dual-tree guiding mechanism is constructed, information of newly-generated nodes is fully utilized, invalid sampling of a local space is reduced, and rapid fusion of the two trees is achieved; determining an extension step length according to the surrounding environment information of the node to obtain a collision-free path with low cost from a starting point to a target point; and then global and local rewiring optimization is performed on the initial path, a B spline curve is introduced for fitting smoothing, and finally an optimized path satisfying robot curvature constraint is generated. According to the method, the planning efficiency and the path quality can be improved, and the method has relatively high stability and robustness for different environments.

Owner:ANHUI NORMAL UNIV
Air-ground cooperative unmanned system high-reliability positioning navigation method
ActiveCN119860777AInstruments for road network navigationInternal combustion piston enginesPoint cloudSimulation
The invention belongs to the technical field of positioning and navigation, and discloses a high-reliability positioning and navigation method for an air-ground cooperative unmanned system. According to the method, a negative obstacle is accurately extracted by using an RANSAC algorithm and a region growing method, a two-dimensional grid map is generated through three-dimensional point cloud re-projection, a negative obstacle region is marked on the map, and a prior map is provided for an unmanned vehicle. The unmanned vehicle constructs a local map in combination with a sensor of the unmanned vehicle, and the local map is matched with a prior map through an ICP algorithm to accurately position a global pose. According to a priori map and real-time sensor data, a grid cost map containing static obstacles, dynamic obstacles and negative obstacles is generated, a TSCNN predicts dynamic obstacle tracks according to time sequence data, map cost values are updated, an A * algorithm carries out optimal path planning based on the updated dynamic cost map, and the optimal path planning is carried out based on the updated dynamic cost map. And dynamic obstacles and negative obstacles are avoided in real time. According to the invention, efficient, accurate and safe navigation and obstacle avoidance can be realized in a dynamic environment and a complex terrain.

Owner:SHANDONG UNIV OF SCI & TECH
Mobile robot visual language navigation method based on diffusion strategy
The invention relates to a mobile robot visual language navigation method based on a diffusion strategy. The method comprises the following steps: S1, constructing an RGB and deep space-time fusion coding module; s2, constructing a natural language instruction key semantic query coding module, and effectively condensing and compressing a natural language instruction; s3, fusing vision, language, local historical displacement and global displacement information, and constructing a multi-modal condition cross attention coding module; s4, constructing a conditional diffusion Transform decoding module, obtaining a noise vector based on conditional vector decoding, acting on a multi-step denoising process, and outputting a plurality of candidate multi-step navigation trajectories; s5, constructing a navigation trajectory discriminator based on a comparative learning method, wherein the navigation trajectory discriminator is used for efficiently and autonomously discriminating the matching score of the candidate trajectory and the target point; and the like. The method has the advantages that the anti-jamming capability is high, the task completion rate is high, the method can adapt to various complex environments and dynamic changes, the generalization capability and the expandability are high, and the method can stably run in diversified application scenes.

Owner:TONGJI UNIV
Artificial intelligence application assistant
ActiveUS12346712B1Instruments for road network navigationNatural language analysisUser deviceLinguistic model
An Applicant Assistant System may receive, from a user device, a user input indicating a query or task associated with information displayed in a user interface. The device may determine one or more components associated with the user interface and access component metadata of the determined one or more components, the component metadata for each of the one or more components indicating one or more of a fact, a data link, or an action. A prompt comprising at least some of the component metadata, at least some context information, and an indication of one or more available response elements may be provided to a large language model (LLM). The LLM may response with one or more response elements that may be processed by the System, such as to cause updates to the user interface on the user device.

Owner:SAMSARA INC
Vehicle occupant health monitoring application
ActiveUS20250029488A1Instruments for road network navigationError preventionMobile deviceHealth surveillance
An example operation includes one or more of accessing, by an application providing assistance to a vehicle, sensor data associated with an environment inside and outside of a vehicle and profile data associated with a vehicle occupant, determining, by the application, an initial condition of the vehicle occupant based on the sensor data and the profile data, responsive to the initial condition being above a health condition threshold, accessing, by the application, health data associated with the vehicle occupant from a mobile device, determining, by the application, an updated condition of the vehicle occupant based on the health data, creating, by the application, an alert to notify the occupant based on the updated condition and one or more current driving conditions of the vehicle identified by the sensor data, and performing, by the vehicle, one or more vehicle actions based on the alert and the one or more current driving conditions.

Owner:TOYOTA MOTOR NORTH AMERICA INC
Real-time map updating method and system based on multi-source geographic information data fusion
InactiveCN120427017AInstruments for road network navigationStill image data indexingVideo monitoringStreaming data
The invention provides a real-time map updating method and system based on multi-source geographic information data fusion. Wherein a three-dimensional model is constructed by integrating traffic flow data, remote sensing images and road network topology, the road traffic pressure is quantified, and a feature correlation index is established. And obtaining a vehicle displacement vector and a speed gradient in combination with laser point cloud and video monitoring data, generating a dynamic road feature data set, and establishing a mapping relationship with the index table. On the basis, a road state prediction model is constructed, and through correlation analysis of traffic pressure data and a real-time feature data set, deep correlation between vehicle motion features and road states is established. And dynamically adjusting a road network connection structure, synchronously updating mapping parameters and predicting model precision, and realizing real-time adaptive adjustment of the road network topology. According to the technical scheme provided by the invention, the real-time performance of map updating and the road condition prediction accuracy are remarkably improved, and the urban traffic congestion index can be reduced.

Owner:BEIJING GREATMAP TECH
Unmanned aerial vehicle route planning method and system based on airspace grid
ActiveCN118913292Aimprove securityImprove robustnessInstruments for road network navigationNavigational calculation instrumentsVehicle dynamicsSimulation
The invention discloses an airspace grid-based unmanned aerial vehicle route planning method and system. The method comprises the following steps of constructing an airspace grid unmanned aerial vehicle flight risk assessment system; constructing an unmanned aerial vehicle route risk cost model, calculating each risk cost value of the unmanned aerial vehicle flying in the grid to obtain a comprehensive risk cost value of the grid, and generating an unmanned aerial vehicle flight risk grid map in combination with the longitude and latitude of the grid; constructing an unmanned aerial vehicle route constraint condition; constructing an unmanned aerial vehicle dynamic route planning model, taking the flight starting and ending point longitude and latitude of the flight task, the unmanned aerial vehicle flight risk grid map, the route constraint condition and the preference characteristics of the flight task as the input of the unmanned aerial vehicle dynamic route planning model, and solving the optimal route path of the unmanned aerial vehicle by using an improved ant colony algorithm; wherein the preference characteristic of the flight mission comprises priority security or priority timeliness. According to the invention, the safety and robustness of route planning and the reliability of the result are improved.

Owner:PANDA ELECTRONICS
Unmanned logistics vehicle path planning method based on fusion of improved A* and improved DWA
The invention provides an unmanned logistics vehicle path planning method based on fusion of improved A * and improved DWA, and aims to improve the obstacle avoidance capability of an unmanned logistics vehicle in a complex environment, and the method comprises the following steps: initializing a grid map, and setting a starting point and a target point of path planning; performing global path planning in the initialized map based on an improved A * algorithm to form a preliminary global path: processing nodes in the preliminary global path by using a triple redundant point deletion method to generate a global optimized path; and obtaining a key turning point in the global optimization path and taking the key turning point as a local target point, and performing local path planning based on the improved DWA to obtain an optimal motion track. A search point optimization strategy is introduced to limit the search range, the search efficiency is improved, and meanwhile, a heuristic function is improved to enhance the obstacle avoidance of path selection. And reducing path turning points by deleting redundant points for three times. The safety of the path is improved by improving an evaluation function of the DWA, and an efficient, smooth and safe global optimal path is realized in combination with a global path.

Owner:CHANGCHUN UNIV OF SCI & TECH
Orchard inspection robot navigation method based on multi-sensor fusion
PendingCN118936480Aachieve perceptionImprove automationInstruments for road network navigationNavigational calculation instrumentsPattern recognitionSensing data
An orchard inspection robot navigation method based on multi-sensor fusion comprises the following steps: step 1, pre-storing sensor data required by an orchard inspection robot, including data of a two-dimensional laser radar, a GPS, a depth camera, a wheel type odometer and an inertial sensor IMU; step 2, processing pre-stored sensor data required by the orchard inspection robot; 3, fusing the data of the two-dimensional laser radar, the GPS, the depth camera, the wheel type odometer and the inertial sensor IMU through a Kalman filtering algorithm, obtaining environment information with higher precision and robot state estimation after filtering fusion, constructing a high-precision three-dimensional environment model based on the fused data, and identifying and positioning an obstacle; and step 4, generating an optimal inspection path based on the real-time environment sensing data and a predetermined inspection task. According to the invention, the automation and intelligence level of orchard inspection is improved.

Owner:ZHEJIANG UNIV OF TECH
Automatic driving vehicle path planning method and device based on large language model, equipment and medium
ActiveCN119756400AInstruments for road network navigationInternal combustion piston enginesPathPingLinguistic model
The invention relates to an automatic driving vehicle path planning method and device based on a large language model, equipment and a medium. The method comprises the steps that a traffic scene RGB image, a traffic scene depth image, laser radar point cloud data and inertial measurement unit data of an automatic driving vehicle are acquired; performing feature extraction on the traffic scene RGB image, the traffic scene depth image, the laser radar point cloud data and the inertial measurement unit data to construct multi-modal traffic scene information; calling a preset large language model to determine the motion state of the autonomous vehicle and natural language description of traffic targets around the autonomous vehicle according to the multi-mode traffic scene information; and determining the attention weight of the target node by adopting an attention mechanism in a large language model according to the natural language description of the traffic target, and determining the optimal driving path by adopting a preset path planning algorithm according to the attention weight of the target node, the motion state of the autonomous vehicle and the target position. According to the invention, the adaptive capability of path planning is obviously improved.

Owner:SOUTH CHINA AGRICULTURAL UNIVERSITY
Using a language model to localize and route plan for navigation systems and applications
PendingUS20240418515A1Natural language translationInstruments for road network navigationLinguistic modelEngineering
Approaches presented herein provide for the generation of a tokenized description of an environment for use in making decisions with respect to the environment. In particular, a large language model (LLM) can be used to generate a tokenized text string representation of an environment using sensor information captured at a specific location, as well as information about the semantics, topology, and geometry of the environment. A similarity-based search can be performed against tokenized descriptions for various locations until a single high-quality match is identified, and the geographic position of the match can be inferred to correspond to the current position of a vehicle that captured the sensor data. The current location and tokenized description can also be provided to a language model, along with a road-level route plan, in order to generate more detailed routing information that is optimized based on the additional information available in the tokenized description for a sequence of goals corresponding to the route plan.

Owner:NVIDIA CORP
Map updating method and apparatus, and autonomous moving apparatus and storage medium
PCT designated stage expiredWO2025050384A1Instruments for road network navigationNavigational calculation instruments
A map updating method and apparatus, and an autonomous moving apparatus and a storage medium, which relate to the technical field of autonomous navigation. The method comprises: acquiring a pre-constructed global map, a semantic map, the pose of an autonomous moving apparatus, and sensor data, wherein a static region and a dynamic region in the global map are labeled in the semantic map (S110); on the basis of the pose and the sensor data, periodically constructing a local map, so as to define the coverage range of the local map (S120); aligning the global map with the local map, so as to obtain a target local map aligned with the global map (S130); and on the basis of the global map, the semantic map and the target local map, updating the global map (S140). The consistency of a global map can be ensured, the quality of the global map is improved, and the efficiency and accuracy of updating a map are improved.

Owner:KUKA ROBOTICS GUANGDONG CO LTD +2
Training machine learning models using captured human reasoning
PendingUS20240419905A1Natural language translationInstruments for road network navigationData classLinguistic model
Approaches presented herein provide for the training of a language model to provide human-style reasoning or “train-of-thought” support for generated inferences. In at least one embodiment, a language model can be used to assist in the generation and / or annotation of content for a specific domain or type of data. This can include, for example, tasks such as performing quality checks for high definition (HD), standard definition (SD), and / or navigational maps. In the mapping context, a language model can be trained using a large set of rules relevant to the mapping domain, in order to become a domain expert. In addition to training the language model on domain-specific rules and data, the language model can be further trained based at least in part on human feedback, such as corrections made to map data by an authorized human.

Owner:NVIDIA CORP
Systems and methods for providing voice assistance in a vehicle
PendingUS20240411808A1Instruments for road network navigationDigital data information retrievalEngineeringHuman–computer interaction
Methods, computing systems, and technology are presented for providing voice assistance in a vehicle. For example, a computing system may be configured to access a first voice prompt indicative of a speech-based voice query provided by a user of the vehicle. The computing system may be configured to determine, based on the first voice prompt, a first prompt message corresponding to a text-based transcription of the first voice prompt. The computing system may be configured to process the first prompt message with a machine-learned large language model trained to generate a digital message response based on the first prompt message. The computing system may be configured to convert the digital message response to a speech-based voice response. The computing system may be configured to provide the speech-based voice response as audio output to the user of the vehicle.

Owner:MERCEDES BENZ GROUP AG
Multi-intelligent carrying AGV conflict coordination and dynamic obstacle avoidance cooperation path planning method
InactiveCN119124205AImprove efficiencyimprove accuracyInstruments for road network navigationControl engineeringTransportation scheduling
The invention provides a multi-intelligent carrying AGV conflict coordination and dynamic obstacle avoidance cooperation path planning method, and relates to the field of transportation scheduling, and the method comprises the steps: obtaining environment information, building a grid map, and setting starting point nodes and target nodes of a plurality of intelligent carrying AGVs; determining a global optimal path of each intelligent carrying AGV, and judging whether a conflict occurs or not; if the conflict is determined to be generated, based on the global optimal path of each intelligent carrying AGV, determining conflict types of space-time conflicts and time-space conflicts on the global optimal paths of the plurality of intelligent carrying AGVs; for each time-space conflict, determining the priority of the intelligent carrying AGV with the time-space conflict, and determining a conflict resolution strategy corresponding to the time-space conflict based on the priority of the intelligent carrying AGV with the time-space conflict and the conflict type of the time-space conflict; and based on the global optimal path of each intelligent carrying AGV and the conflict resolution strategy corresponding to each time-space conflict, a plurality of intelligent carrying AGVs are scheduled, and the method has the advantage of realizing collaborative carrying in a multi-carrying AGV scene.

Owner:INNER MONGOLIA UNIV OF TECH
Mine vehicle intelligent navigation and safe driving method and system based on inertial navigation
PendingCN119002482AHigh positioning accuracyImprove positional stabilityInstruments for road network navigationData processing applicationsMultiple sensorSteering control
The invention provides a mine vehicle intelligent navigation and safe driving method and system based on inertial navigation, and relates to the technical field of intelligent navigation. The method comprises the following steps: collecting motion and environment data of a vehicle through various sensors; fusing sensor data by adopting extended Kalman filtering to generate high-precision position information and a motion state; carrying out anomaly detection through mean shift detection and a Kalman filtering residual analysis algorithm; performing path planning based on the environmental perception information and a predetermined target; a PID controller or model prediction control is adopted to generate a speed and steering control instruction; and data transmission and remote monitoring between the vehicle and the control center are realized through the communication module. Through multi-sensor data fusion and an advanced control algorithm, high-precision navigation and safe driving of the mine vehicle in a complex environment are realized, the reliability and stability of the system are improved, and the safety and efficiency of mine operation are guaranteed.

Owner:XIAN SANHANG INTELLIGENT INFORMATION TECHNOLOGY CO LTD