
Patents
Literature
15330 results about "Driver/operator" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
AR-fused remote driving vehicle virtual-real interaction hardware-in-the-loop test system
The invention discloses an AR-fused remote driving vehicle virtual-real interaction hardware-in-the-loop test system, particularly relates to the technical field of automatic driving test, and is used for solving the problems of inaccurate coupling between a virtual scene and a real vehicle behavior and lack of AR prompt response evaluation. The method comprises the following steps: firstly, constructing a dynamic obstacle intention-driven prediction model based on time series data of a multi-modal sensor, and generating a trajectory probability distribution and risk thermodynamic diagram; then, space-time alignment of the virtual accident scene and the real environment is achieved through a dynamic binding algorithm, and the virtual-real shielding priority of an AR interface is dynamically adjusted; by simulating abnormal disturbance of a vehicle actuator, synchronously collecting control and watching responses of a driver, and extracting obstacle avoidance path deviation degree and takeover timeliness parameters; and finally, separating and compensating virtual and actual residual errors based on a path deviation index, realizing online correction of a virtual scene attitude and a dynamic trajectory, constructing a closed-loop optimization mechanism, and improving the precision and stability of a test system.

Owner:城市之光(深圳)无人驾驶有限公司
Driver identification using diverse driver assignment sources
ActiveUS12479446B1Character and pattern recognitionExternal condition input parametersDriver/operatorData source
A management server system may obtain data associated with a vehicle. The management server system may obtain the data from a plurality of data sources associated with the vehicle. The data may include a plurality of subsets of data that each correspond to correspond to a particular driver assignment category. Each subset of data may identify a particular persona as a driver of a vehicle. The management server system may determine a driver of the vehicle based on each subset of data and a hierarchical plurality of driver assignment categories. Based on the determination of the driver of the vehicle, the management server system can dynamically map the driver to a particular event. The management server system may generate a user interface identifying the driver and the event.

Owner:SAMSARA INC
Intelligent cabin interaction method and system combined with digital twinning
The invention discloses an intelligent cabin interaction method and system combined with digital twinning, and relates to the technical field of man-machine interaction, and the method comprises the steps: collecting the multi-dimensional perception data of a cabin, and constructing a layered cabin digital twinning model; performing scene analysis on the cockpit digital twin model, extracting driver state features, predicting driver potential interaction demands, generating a multi-modal interaction strategy set in combination with the driver potential interaction demands and a current driving scene, and performing simulation evaluation on the multi-modal interaction strategy set to obtain an interaction evaluation index set; performing multi-objective decision optimization under the driving safety constraint based on the interaction evaluation index set, and determining and adaptively executing an optimal interaction strategy; and acquiring actual execution data and driver feedback data of the optimal interaction strategy, and incrementally updating the hierarchical cabin digital twin model. According to the invention, the interaction adaptability and the safety reliability of the intelligent cabin system in a complex driving scene are obviously improved, and an effective technical support is provided for realizing intelligent man-machine cooperative driving.

Owner:GUANGZHOU KOMI CULTURE COMMUNICATION CO LTD
Apparatus and method for providing driver assistance of a vehicle
ActiveUS12391249B2Electromagnetic wave reradiationRadio wave reradiation/reflectionDriver/operatorVehicle driving
Aspects of the present invention relate to an apparatus for providing driver assistance of a vehicle, an autonomous system, a vehicle, a method, a controller and a non-transitory computer readable medium. The apparatus comprises a first sensor and a second sensor mounted on a vehicle. The first sensor is configured to transmit and receive electromagnetic radiation to detect the presence of an object in a first area, and the second sensor is configured to transmit and receive electromagnetic radiation to detect the presence of an object in a second area. The first area and the second area overlap to define an overlapping area forward of the vehicle. The first area extends from the overlapping area to a first extreme direction having a rearward component and a leftward component, and the second area extends from the overlapping area to a second extreme direction having a rearward component and a rightward component.

Owner:JAGUAR LAND ROVER LTD
Vehicle-mounted emotion interaction method and device based on multi-dimensional recognition
ActiveCN120951079ABiological modelsAcquiring/recognising facial featuresPersonalizationDriver/operator
The embodiment of the invention provides a vehicle-mounted emotion interaction method and device based on multi-dimensional recognition, and the method and device achieve the precise judgment of the emotion of a driver through innovatively constructing an emotion fusion recognition model and integrating the facial expression, voice emotion, driving behavior and physiological state features. And designing a scene-based self-adaptive interaction strategy, and establishing an interaction triggering threshold value for intelligent matching in combination with external environment data and a danger level. An interaction effect evaluation mechanism is introduced, an interaction strategy model is continuously optimized through an online learning module, and dynamic adjustment of personalized interaction content is achieved. According to the method, the defects of the traditional technology in the aspects of emotion recognition, interaction strategies, effect evaluation and the like are effectively overcome, and the intelligent level and the user experience of vehicle-mounted emotion interaction are remarkably improved.

Owner:SHENZHEN ZHI HUI LIN NETWORK TECH CO LTD
Intelligent driving system and method and electronic equipment
The invention provides an intelligent driving system and method and electronic equipment, relates to the technical field of intelligent driving, and realizes personalized improvement of driver ability and safety guarantee of a driving environment through three cooperative mechanisms including a teaching strategy module, a safety perception module and a behavior management module. Analyzing the multi-dimensional student data through a teaching strategy module by using a multi-modal large language model, and generating a personalized teaching strategy adaptive to the ability of the student; a driving environment is monitored through a safety sensing module, when a specific complex scene is detected, a multi-source heterogeneous sensor data fusion strategy is adjusted according to a scene type and a preset intervention degree, and then a safety coping strategy matched with environment interference is generated; the driving behavior data are recognized through the behavior management module, and multi-mode interaction feedback is generated in combination with the physiological data and the state data of the driver and used for guiding and correcting the driving behavior.

Owner:YIXIAN INTELLIGENCE
Electric forklift multi-mode driving switching method and system based on multivariable cooperation
The invention discloses an electric forklift multi-mode driving switching method and system based on multivariable cooperation, and relates to the technical field of industrial vehicle intelligent control. The method is used for solving the problems of one-sided working condition sensing, switching oscillation and safety fault tolerance deficiency in multi-mode driving. The method comprises the following steps: firstly, generating a dynamically weighted working condition feature vector through multi-source sensing data fusion, and quantifying a stability risk, an energy consumption constraint and a power demand; secondly, based on a stability risk trigger steering safety envelope, arbitrating a multi-mode priority and correcting a torque upper limit in combination with a fuzzy rule to form an anti-conflict execution sequence; then, torque distribution and a steering angle acceleration instruction are optimized in a rolling mode in the safe envelope boundary, center-of-gravity shift is synchronously restrained, the track precision is improved, and energy consumption is reduced; finally, the control authority is transferred adaptively according to the operation intensity of a driver, when the decision is abnormal, the load-ramp rule base is degraded, an instruction is transferred through an S-shaped curve, and a torque balancing strategy is executed at the high position of a pallet fork to maintain stable.

Owner:PENG INNOVATION ENERGY TECH (SHANGHAI) CO LTD
Method of controlling drift of vehicle
A method of controlling drift of a vehicle in which the vehicle more easily enters, maintains, releases, and transitions drift behavior, includes determining, by a controller, whether a current driving situation of the vehicle is a drift entry situation or a release situation based on vehicle driving information, and generating a drift index configured to indicate a current degree of drift from a determination result, determining, by the controller, a target yaw moment for left and right speed control depending on a driving situation or a braking situation of the vehicle and target yaw moments for drift assistance control depending on a driver input and a vehicle state in the drift entry situation, based on the vehicle driving information, and generating and outputting, by the controller, a target torque of a motor configured to drive each wheel of the vehicle based on the determined target yaw moments.

Owner:HYUNDAI MOTOR CO LTD +1
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
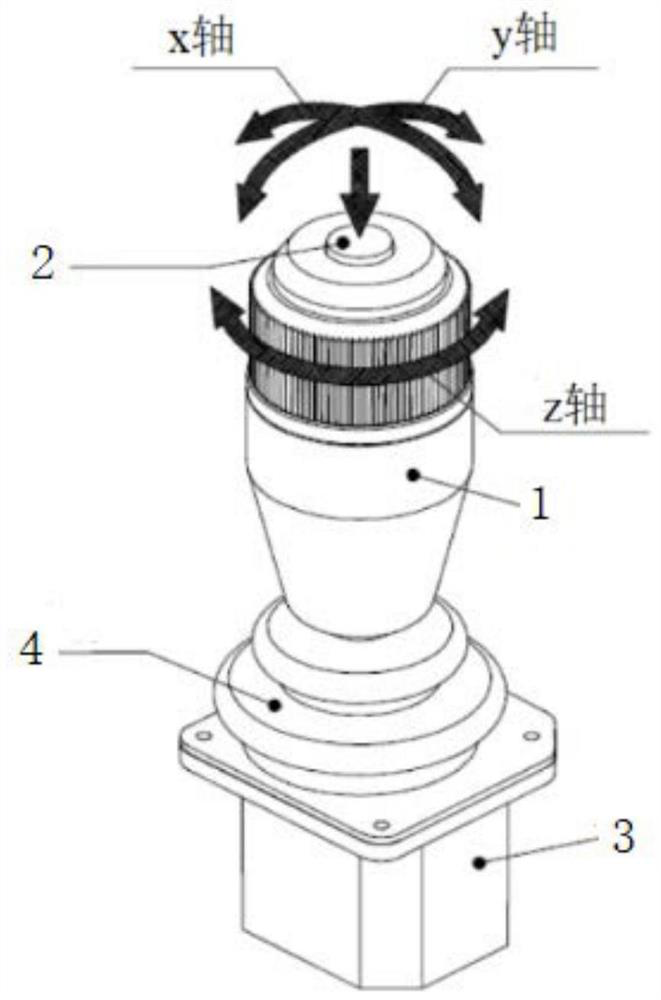
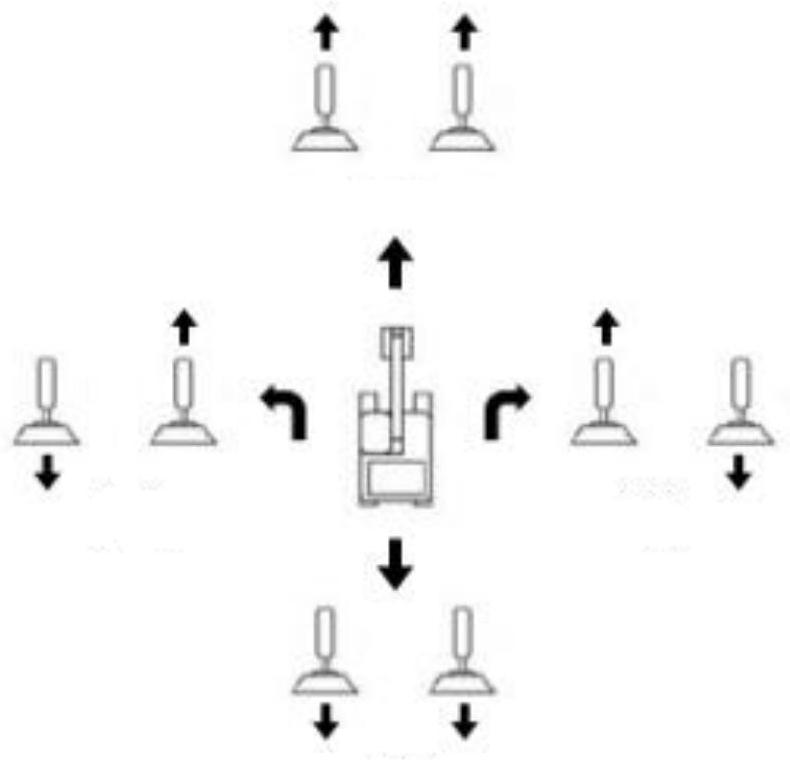
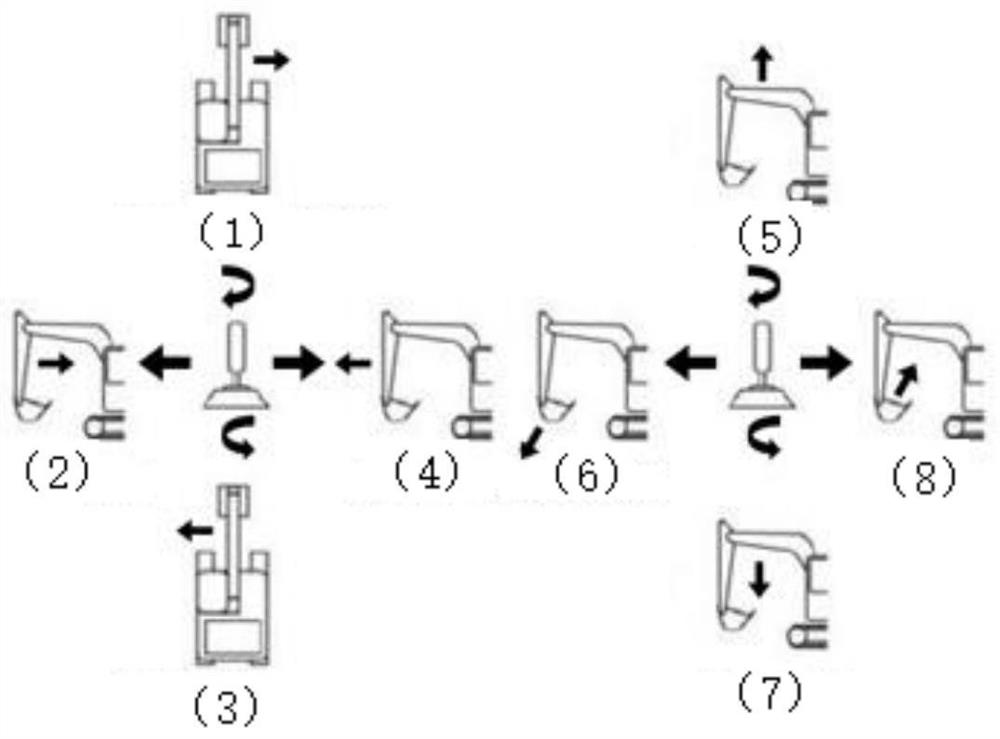
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Forward collision early warning device and method based on risk assessment and electronic equipment
The invention discloses a forward collision early warning device and method based on risk assessment, electronic equipment and a storage medium, and relates to the field of driving prediction, and the device comprises a sensing unit which is used for obtaining the relative position data of a detected object, and carrying out the modeling according to the relative position data of the recognized detected object; detecting a driving state of a driver; detecting the motion state of the vehicle in real time; the processing unit is used for processing the data of the sensing unit in real time, performing target classification, running a dynamic risk assessment algorithm and outputting an early warning level; the prompt unit is used for displaying prompt information on the instrument panel display module and the vehicle-mounted terminal; by means of the scheme, the problems that when a static vehicle or a low-speed obstacle is detected by an existing system, due to the conservative property of TTC calculation, the time window for triggering early warning is later, collision is difficult to avoid when the vehicle is close to the static vehicle, and potential safety hazards exist are solved.

Owner:FAW JIEFANG AUTOMOTIVE CO
New energy automobile brake pressure control method based on dynamic environment perception
According to the new energy automobile brake pressure control method based on dynamic environment perception, a multi-window environment perception dynamic time warping algorithm is constructed, so that the similarity of different driver brake sequences is analyzed more meticulously; according to the method, a pavement adhesion coefficient observer for optimizing variable structure Kalman filtering based on a deep reinforcement learning algorithm is provided to calculate a pavement adhesion coefficient; secondly, a slip rate dynamic adjustment factor is obtained through calculation based on a wheel dynamics model, a vehicle density correction coefficient is obtained through calculation based on vehicle density, a road adhesion correction coefficient is obtained based on a road adhesion correction parameter constraint expression, and influences of different external environments on the road adhesion coefficient can be fully considered; the brake pressure calculation is more reasonable, and the driving safety is improved. According to the method, classification results of different drivers are combined, a comprehensive self-adaptive brake pressure calculation model is constructed to cope with different types of drivers, and corresponding final brake pressure is obtained.

Owner:EAST CHINA JIAOTONG UNIVERSITY
Tunnel illumination control method considering visual adaptability of driver
PendingCN121510434AInput/output for user-computer interactionElectrical apparatusLight equipmentDriver/operator
The invention relates to a tunnel illumination control method considering visual adaptability of a driver, and belongs to the technical field of tunnel illumination control, and the method comprises the following steps: S1, employing a volume scattering point location method to obtain visual adaptability parameters of visual adaptation states of all segments in a tunnel; s2, dynamically constructing a predictive visual adaptation model of the driver group based on the visual adaptation parameters, and outputting expected visual states of the drivers according to the predictive visual adaptation model; s3, according to the expected visual state, a parameter control mechanism is adopted to control target illumination parameters of all the sections of the tunnel; s4, according to the target lighting parameters, the working state of lighting equipment in a corresponding section in the tunnel is regulated and controlled, so that the light environment in the tunnel is matched with the dynamic visual adaptability of a driver, and safe visual guidance is achieved; the method has the beneficial effects that the target illumination parameters of all the sections of the tunnel are controlled by adopting a parameter control mechanism according to the expected visual state according to the target illumination parameters.

Owner:SICHUAN HIGHWAY ENG CONSULTING & SUPERVISION CO LTD
Driver state sensing system based on physiological index and external behavior analysis
The invention discloses a driver state sensing system based on physiological indexes and external behavior analysis, which relates to the technical field of vehicle active safety control, and comprises a sensor group integrated in a driver contact or close area and a vehicle control part and used for collecting physiological signals and behavior characteristic signals of a driver in real time, the physiological signals at least comprise heart rate and skin electric signals, and the behavior characteristic signals at least comprise eyelid movement, head posture and steering wheel operation signals. According to the driver state sensing system, the comprehensiveness and accuracy of driver state sensing are remarkably improved by integrating physiological indexes and external behavior analysis, the limitation of single signal judgment is effectively overcome through a multi-source signal fusion mechanism, the reliability of state evaluation is ensured, and the advanced signal preprocessing technology adopted by the system is high in reliability. The data anti-interference capability is enhanced, the feature extraction precision is improved, and the robustness of the model is enhanced.

Owner:SICHUAN VOCATIONAL & TECHN COLLEGE OF COMM
Memory enhanced vision-language-motion submerged space dynamic fusion automatic driving method
The invention relates to a memory enhanced vision-language-action submerged space dynamic fusion automatic driving method. Comprising the following steps: generating a bird's-eye view feature map; extracting scene, agent and map marks from the aerial view feature map, and fusing the mark at the current moment and the previous i historical marks to generate memory enhanced visual marks; the memory enhanced visual mark and the vehicle state information are converted into a submerged space, text input of a driver is marked and unified into the submerged space, the submerged space is represented and fused, and fusion representation is generated; an automatic driving instruction data set is introduced for adjustment, and a large language model adapting to an automatic driving task is obtained; according to the fusion representation, track planning is carried out in an autoregression mode by using a large language model, and path point coordinates are obtained; and designing a transverse controller and a longitudinal controller based on PID (Proportion Integration Differentiation) to track and control the coordinates of the path points. According to the invention, the visual representation capability of end-to-end driving is improved, and the visual-language-action fusion effect is improved.

Owner:NANJING UNIV OF SCI & TECH
Emergency takeover triggering method and system based on environment perception and driver state recognition
The invention discloses an emergency takeover triggering method and system based on environment perception and driver state recognition, and relates to the technical field of emergency takeover, and the method comprises the following steps: obtaining environment perception data and driver state data, and carrying out the risk grade evaluation; judging whether to initiate a takeover request according to the risk level; if a takeover request is sent, instruction consistency detection is carried out based on game modeling, a driver and an automatic driving system are abstracted into two agents, and operation intentions of the two agents are inferred respectively; if the detection results are inconsistent, entering a conflict strategy processing flow, evaluating the advantages and disadvantages of the strategies of the two conflict parties according to the driver state confidence and the environmental risk level, and outputting a game reasoning result; the problems of lack of consistency judgment, high calculation complexity and difficulty in real-time response in the prior art are solved.

Owner:ZHONGZHI YIKE CHENGDU AUTOMOBILE CO LTD
Chassis coordination control method and system based on tire lateral deviation state evaluation
PendingCN120681116AExternal condition input parametersVehicle condition input parametersVehicle dynamicsDriver/operator
The invention discloses a chassis coordination control method and system based on tire side deviation state evaluation, and relates to the technical field of four-wheel steering four-wheel drive vehicle dynamics control. The method comprises the steps that an expected front wheel rotation angle is determined based on an expected steering wheel rotation angle input by a driver, and a front wheel rotation angle is determined; further determining a feed-forward front wheel steering angle, a feed-forward rear wheel steering angle and an additional yaw moment based on feed-forward control and feedback control, determining a first tire slip angle and a second tire slip angle based on a road adhesion coefficient, and further determining a wheel torque control weight, a feedback front wheel steering angle control weight and a feedback rear wheel steering angle control weight; and further determining a driving yaw moment, a feedback front wheel steering angle and a feedback rear wheel steering angle, determining a total longitudinal force based on an expected longitudinal acceleration input by a driver, and performing four-wheel torque distribution based on the total longitudinal force and the driving yaw moment to obtain a four-wheel driving torque. The driving stability of the vehicle under the limiting working condition can be improved.

Owner:ADVANCED TECH RES INST OF BEIJING UNIV OF TECH
Dangerous driving critical state identification method
The invention discloses a dangerous driving critical state identification method, and relates to the technical field of intelligent driving safety. According to the method, multi-mode signals of eye movement, electrocardio, skin electricity, vehicle operation and the like are collected and converted into a unified phase field, and the synchronous coherence of the unified phase field is analyzed; the individual phase dynamics manifold of the driver is learned on line by using a Shenchang differential equation, and a system instability precursor is identified by detecting the behavior that a state point escapes from a steady state attractor; further, multi-dimensional indexes such as synchronous collapse and topological fracture are fused, collapse time is estimated in combination with a Lyapunov index, and an advanced early warning instruction is generated; and finally, based on the model predictive control and the personalized phase response curve, generating and executing targeted multi-mode phase reset intervention, and forming a sensing-early warning-intervention active safety closed loop. According to the invention, normal form transformation from post-event alarm to beforehand regulation and control is realized, and early warning advancement and intervention accuracy are improved.

Owner:QINGHAI POLICE VOCATIONAL COLLEGE
Track prediction method based on adaptive interaction and dynamic intention
The invention relates to the technical field related to automatic driving, in particular to a trajectory prediction method based on adaptive interaction and dynamic intention, which comprises the following steps: firstly, constructing a heterogeneous interaction map, dividing a traffic scene into a vehicle grid, an environment grid and a non-driving area grid, and embedding multi-dimensional dynamic features; then dynamically adjusting a region of interest based on the behavior intention of the target vehicle, and extracting a high-correlation interaction subnet; modeling an interaction relationship by adopting a heterogeneous graph convolutional network, and processing the motion characteristics of the target vehicle and the neighbor vehicle through a sub-channel coding strategy; further realizing dynamic intention perception through a double-branch parallel attention architecture, and fusing macroscopic intention and dynamic intention information; and finally, iteratively generating a future trajectory prediction result based on a decoding architecture of a message passing mechanism. The method can effectively improve the long-term prediction performance in a lane changing scene, adaptively captures a dynamic interaction relationship, and improves the adaptability of a prediction system to the behavior intention change of a driver.

Owner:CHANGAN UNIV +1
Driver fatigue state monitoring system and method based on multi-modal biological feature fusion
The invention relates to the technical field of artificial intelligence, in particular to a driver fatigue state monitoring system and method based on multi-modal biological feature fusion, and the system comprises a sensing module, a data processing and analysis module, an environment risk assessment module, a personalized model module, a self-adaptive decision fusion module, and a vehicle interaction and vehicle control module. Compared with the prior art in which fatigue judgment is performed by adopting a fixed threshold value, the fatigue judgment cannot adapt to a complicated and changeable driving environment and may cause excessive alarm or missing alarm under a monotonous road condition in a dangerous road section, an environment perception and dynamic threshold value adjustment algorithm is introduced, so that the system can intelligently evaluate the environmental risk and monotonicity, and the fatigue judgment accuracy is improved. The alarm sensitivity is automatically adjusted, and the early warning accuracy and the scene adaptability are both improved.

Owner:SICHUAN VOCATIONAL COLLEGE OF CHEM TECH
Cooperative steering control method considering man-machine mutual reliability
The invention discloses a cooperative steering control method considering man-machine mutual reliability, and aims to solve the problem of man-machine conflict in an existing man-machine co-driving system. The invention relates to the field of intelligent driving. The system specifically comprises an expected path module, a man-machine steering conflict evaluation module, a driver experience evaluation module, a weight distribution module, a non-cooperative game module and a man-machine co-driving vehicle. The expected path module generates an expected path between the driver and the controller; the man-machine steering conflict evaluation module outputs the trust degree of the driver to the controller based on the steering action of the driver, the vehicle state and the expected path of the driver and the controller; the driver experience evaluation module outputs the driver trust degree of the controller based on the vehicle state; the weight distribution module is used for outputting a driver control weight; and the non-cooperative game module outputs an optimal turning angle in combination with the expected path of the driver and the controller and the control weight of the driver, and controls the man-machine co-driving vehicle to complete the cooperative steering action.

Owner:CHANGCHUN UNIV OF TECH
Driving fatigue monitoring auxiliary system based on Beidou satellite positioning and multi-modal data fusion technology
The invention provides a driving fatigue monitoring auxiliary system based on Beidou satellite positioning and a multi-modal data fusion technology, which relates to the field of electric digital data processing and comprises a multi-modal information sensing and acquisition module, a data preprocessing and quality assurance module, a fatigue state recognition and evaluation module and an intelligent early warning and adaptive optimization module. The multi-modal information perception and acquisition module is responsible for acquiring driver states, driving behaviors and environment information in real time, and the data preprocessing and quality assurance module is responsible for performing space-time alignment, quality evaluation and feature standardization on multi-source data. The fatigue state recognition and evaluation module is responsible for fusing multi-dimensional features and judging fatigue levels and risk trends, and the intelligent early warning and self-adaptive optimization module is responsible for implementing hierarchical intervention and continuously optimizing system performance; according to the system, the accurate space-time reference provided by Beidou satellite positioning is utilized, effective fusion of multi-source heterogeneous data is realized, and the accuracy, the real-time performance and the individuation level of fatigue monitoring are remarkably improved.

Owner:HUNAN AUTOMOTIVE ENG VOCATIONAL COLLEGE +1
Intelligent parking space guiding system for hospital parking lot
PendingCN120656335ADetection of traffic movementIndication of parksing free spacesDriver/operatorTransportation technology
The invention discloses an intelligent parking space guiding system for a hospital parking lot, relates to the technical field of intelligent traffic, and is used for solving the problems that the hospital parking lot is seriously jammed in peak hours and special vehicles lack exclusive passing authority. The system comprises a parking space monitoring module, a vehicle identification module, an intelligent guiding module and a user interaction module. The parking space state is monitored in real time through the multi-mode sensor array; recognizing entering and exiting vehicles through a deep learning recognition algorithm based on cameras deployed at entrances and exits, and obtaining corresponding vehicle information; based on parking space state information and vehicle identification information, a route optimal value is dynamically calculated, and a whole-course navigation service from an entrance to a target parking space is provided for a driver, so that accurate detection of the parking space state, special vehicle priority distribution, high-low peak dynamic route planning and whole-process intelligent guidance are realized, the hospital parking efficiency is remarkably improved, and the hospital parking experience is improved. And the congestion condition in the peak period is relieved.

Owner:FUJIAN ZHONGFEI AVIATION CO LTD
Multi-source information and dynamic regulation and control fused oil mass display method and system
The invention relates to the technical field of vehicle instrument display, in particular to an oil mass display method and system fusing multi-source information and dynamic regulation, and the method comprises the steps: carrying out the fusion processing of multi-source data collected in real time, and training a pre-established oil mass consumption prediction model based on the multi-source data after the fusion processing; through the trained fuel consumption prediction model and in combination with a navigation planning route, predicting the remaining fuel quantity and the travelable mileage of the vehicle when the vehicle travels to the destination; according to the oil mass states of the vehicle under different working conditions, a graded oil mass display strategy is executed, and oil mass display under each working condition is dynamically regulated and controlled; wherein the vehicle running state comprises a normal running working condition, a congestion working condition, a high-speed running working condition, a bumpy road section working condition and a slope parking working condition. According to the scheme, accurate, stable and comprehensive fuel quantity information is provided for a driver, and the driving experience and the driving safety are improved.

Owner:CHINA FAW CO LTD +1
Vehicle-road cloud collaborative mixed traffic flow optimization method, system and device
PendingCN120853378AInternal combustion piston enginesDetection of traffic movementData ingestionDriver/operator
The invention provides a vehicle-road cloud collaborative mixed traffic flow optimization method, system and device, and relates to the technical field of intelligent traffic, and the method comprises the steps: extracting a mixed traffic flow feature set containing a road environment, a vehicle state and a driver behavior through obtaining and synchronously fusing the multi-source traffic data of a cloud end, a road end and a vehicle end; according to the method, the intention of a driver is predicted by using a double-layer LSTM model, a vehicle trajectory is predicted in combination with an RNN-LSTM model, confidence fusion analysis of the intention and the trajectory is performed on this basis, accurate prediction of traffic conflict events is realized, and global optimization of traffic flow is supported. According to the method, the intention recognition and trajectory prediction precision in a complex mixed traffic environment is effectively improved, the intelligent decision-making capability of a traffic management system is enhanced, and an efficient technical means is provided for relieving traffic congestion, improving the traffic efficiency and guaranteeing traffic safety.

Owner:CHINA FAW CO LTD
Intelligent driving behavior identification method and system based on video analysis
The invention provides a driving behavior intelligent identification method and system based on video analysis, and the method comprises the steps: obtaining a driver face video stream and a road environment video stream collected by a vehicle-mounted camera, and reading the driving information recorded by a whole vehicle communication network; recognizing an eyelid closing state, a sight line direction and a head posture in the driver face video stream based on a posture recognition model, and performing fatigue distraction analysis to obtain driver state information; performing motion trail analysis on the road environment video stream and the driving information, and performing driving risk assessment in combination with the driver state information to obtain driving assessment information; and performing early warning construction according to the driving evaluation information, generating early warning prompt information, and synchronously writing the early warning prompt information, the driving evaluation information and the driver state information into a safety data protection memory. The fatigue and distraction states of the driver can be recognized more accurately, and the accuracy of state judgment is improved.

Owner:SHENZHEN ZHIJU CLOUD SERVICE TECH CO LTD
Centralized management method and system for smart vehicles
PendingCN120875466ADesign optimisation/simulationResourcesMulti objective optimization algorithmDriver/operator
The invention relates to the field of logistics vehicle management, in particular to a centralized management method and system for intelligent vehicles. The invention discloses a centralized management system for smart vehicles. The centralized management system comprises a task receiving module, a portrait construction module, a vehicle screening module, a sign-in verification module and a queue management module. According to the method, the vehicle multi-dimensional portrait model is constructed, and the transportation cost, the transportation efficiency and the like are subjected to multi-dimensional matching calculation based on the multi-objective optimization algorithm, so that intelligent vehicle dispatching decision-making from experience driving to data driving is realized; according to the method, the historical operation data, the real-time state and the driver behavior characteristics of the vehicle are comprehensively considered, a global optimal vehicle dispatching scheme can be output, the vehicle dispatching accuracy and the resource utilization efficiency are remarkably improved, and the limitation that a traditional method only depends on a single factor for dispatching is overcome.

Owner:JIANGXI TONGRUI INFORMATION TECH CO LTD +1
Torque adjusting method for parking motor of electric automobile
The invention relates to the technical field of electric vehicles, in particular to an electric vehicle parking motor torque adjusting method. The problems that an existing electric automobile parking system is insufficient in parking force control precision, lagged in response and low in energy consumption efficiency under complex working conditions are solved. According to the method, a multi-dimensional vehicle running state, a driver instruction and environment sensing data are collected in real time, a vehicle-environment coupling dynamic model is established and updated in real time, then an adaptive model predictive control (AMPC) strategy is utilized, the future movement trend of a vehicle is predicted based on the dynamic model and a target parking demand, and the vehicle-environment coupling dynamic model is established and updated in real time. And the optimal torque instruction of the parking motor in the current control period is optimized and calculated, and the parking motor is driven to generate corresponding torque. High precision, high adaptability, high safety and high stability of parking torque adjustment can be achieved, the energy efficiency is effectively improved, the service life of parts is effectively prolonged, and the intelligent level is enhanced.

Owner:YU CHUAN (SHANGHAI) TRANSMISSION TECH CO LTD
Fatigue driving behavior feature extraction and analysis method based on image recognition
The invention relates to the field of fatigue driving behavior analysis based on image recognition, in particular to a fatigue driving behavior feature extraction and analysis method based on image recognition, which comprises the following steps of: acquiring an initial state set of a driver in real time through an IMU (Inertial Measurement Unit), an RGB (Red, Green and Blue) camera and an MEMS (Micro Electro Mechanical System) vibration sensor, converting the initial state set into four images such as a head attitude angular velocity oscillogram, extracting image features and inputting the image features into corresponding preset models to obtain fused feature data, dynamically adjusting weights through scene context features, calculating cognitive load indexes and dividing processing modes; according to the method, multi-modal data fusion and dynamic weight adjustment are realized, the cognitive load of the driver can be accurately evaluated and graded intervention can be performed, and the driving safety is improved.

Owner:ZHONGWUYUN INFORMATION TECH (WUXI) CO LTD
Intelligent intervention system and method based on multi-modal driving behavior analysis
The invention discloses an intelligent intervention system and method based on multi-mode driving behavior analysis, and belongs to the field of intelligent traffic. The system comprises a multi-dimensional perception module, a behavior analysis engine, a risk assessment matrix and a self-adaptive intervention module. The multi-dimensional sensing module is integrated with a multi-source heterogeneous sensor and is used for acquiring physiological characteristics of a driver, driving operation data and environment information; the behavior analysis engine analyzes multi-modal data based on spatial-temporal feature fusion, and digs a driving behavior mode; the risk assessment matrix judges danger levels according to the multi-dimensional driving risk quantification result level by level; and the self-adaptive intervention module implements a grading progressive correction strategy. The system realizes active prevention and control of driving risks through cross-modal data association, behavior chain prediction and environment-behavior coupling analysis. The system solves the problems that a traditional system is single in sensing dimension, coarse in risk assessment, rigid in intervention strategy and the like, and effectively improves the driving safety.

Owner:BAODING VICTORY TRAFFIC FACILITIES ENG CO LTD
Real-time risk early warning and evaluation method in vehicle transportation process based on Internet of Things
The invention relates to the technical field of risk analysis, in particular to a real-time risk early warning and evaluation method in the vehicle transportation process based on the Internet of Things. The method comprises the steps that a time-varying Kalman filtering model is adopted, and the driving state deviation degree representing the deviation between the driver manipulation intention and the vehicle dynamic feedback is evaluated and quantified; inputting the vehicle IMU data and the cargo pressure distribution data into a preset vehicle-cargo rigid-flexible coupling dynamic model, and resolving a vehicle-cargo system instability index representing that the vehicle is under the current motion disturbance in real time; and fusing real-time traffic flow and meteorological data serving as dynamic attributes and road geometry and historical accident data serving as static attributes by using a space-time diagram convolutional network, and predicting a risk potential field value of each road section along a transportation line in a future time window. Compared with the prior art, the method has the advantages that a person-vehicle-cargo-road-environment multi-dimensional collaborative risk assessment system is constructed, and the accuracy and foresight of risk early warning are remarkably improved.

Owner:SHANDONG INSPUR AIGOU CLOUD CHAIN INFORMATION TECH CO LTD