
Patents
Literature
10381results about "Road vehicles traffic control" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
System and method to notify a person of a traveler's estimated time of arrival
InactiveUS20050114014A1Instruments for road network navigationRoad vehicles traffic controlTime of arrivalThird party
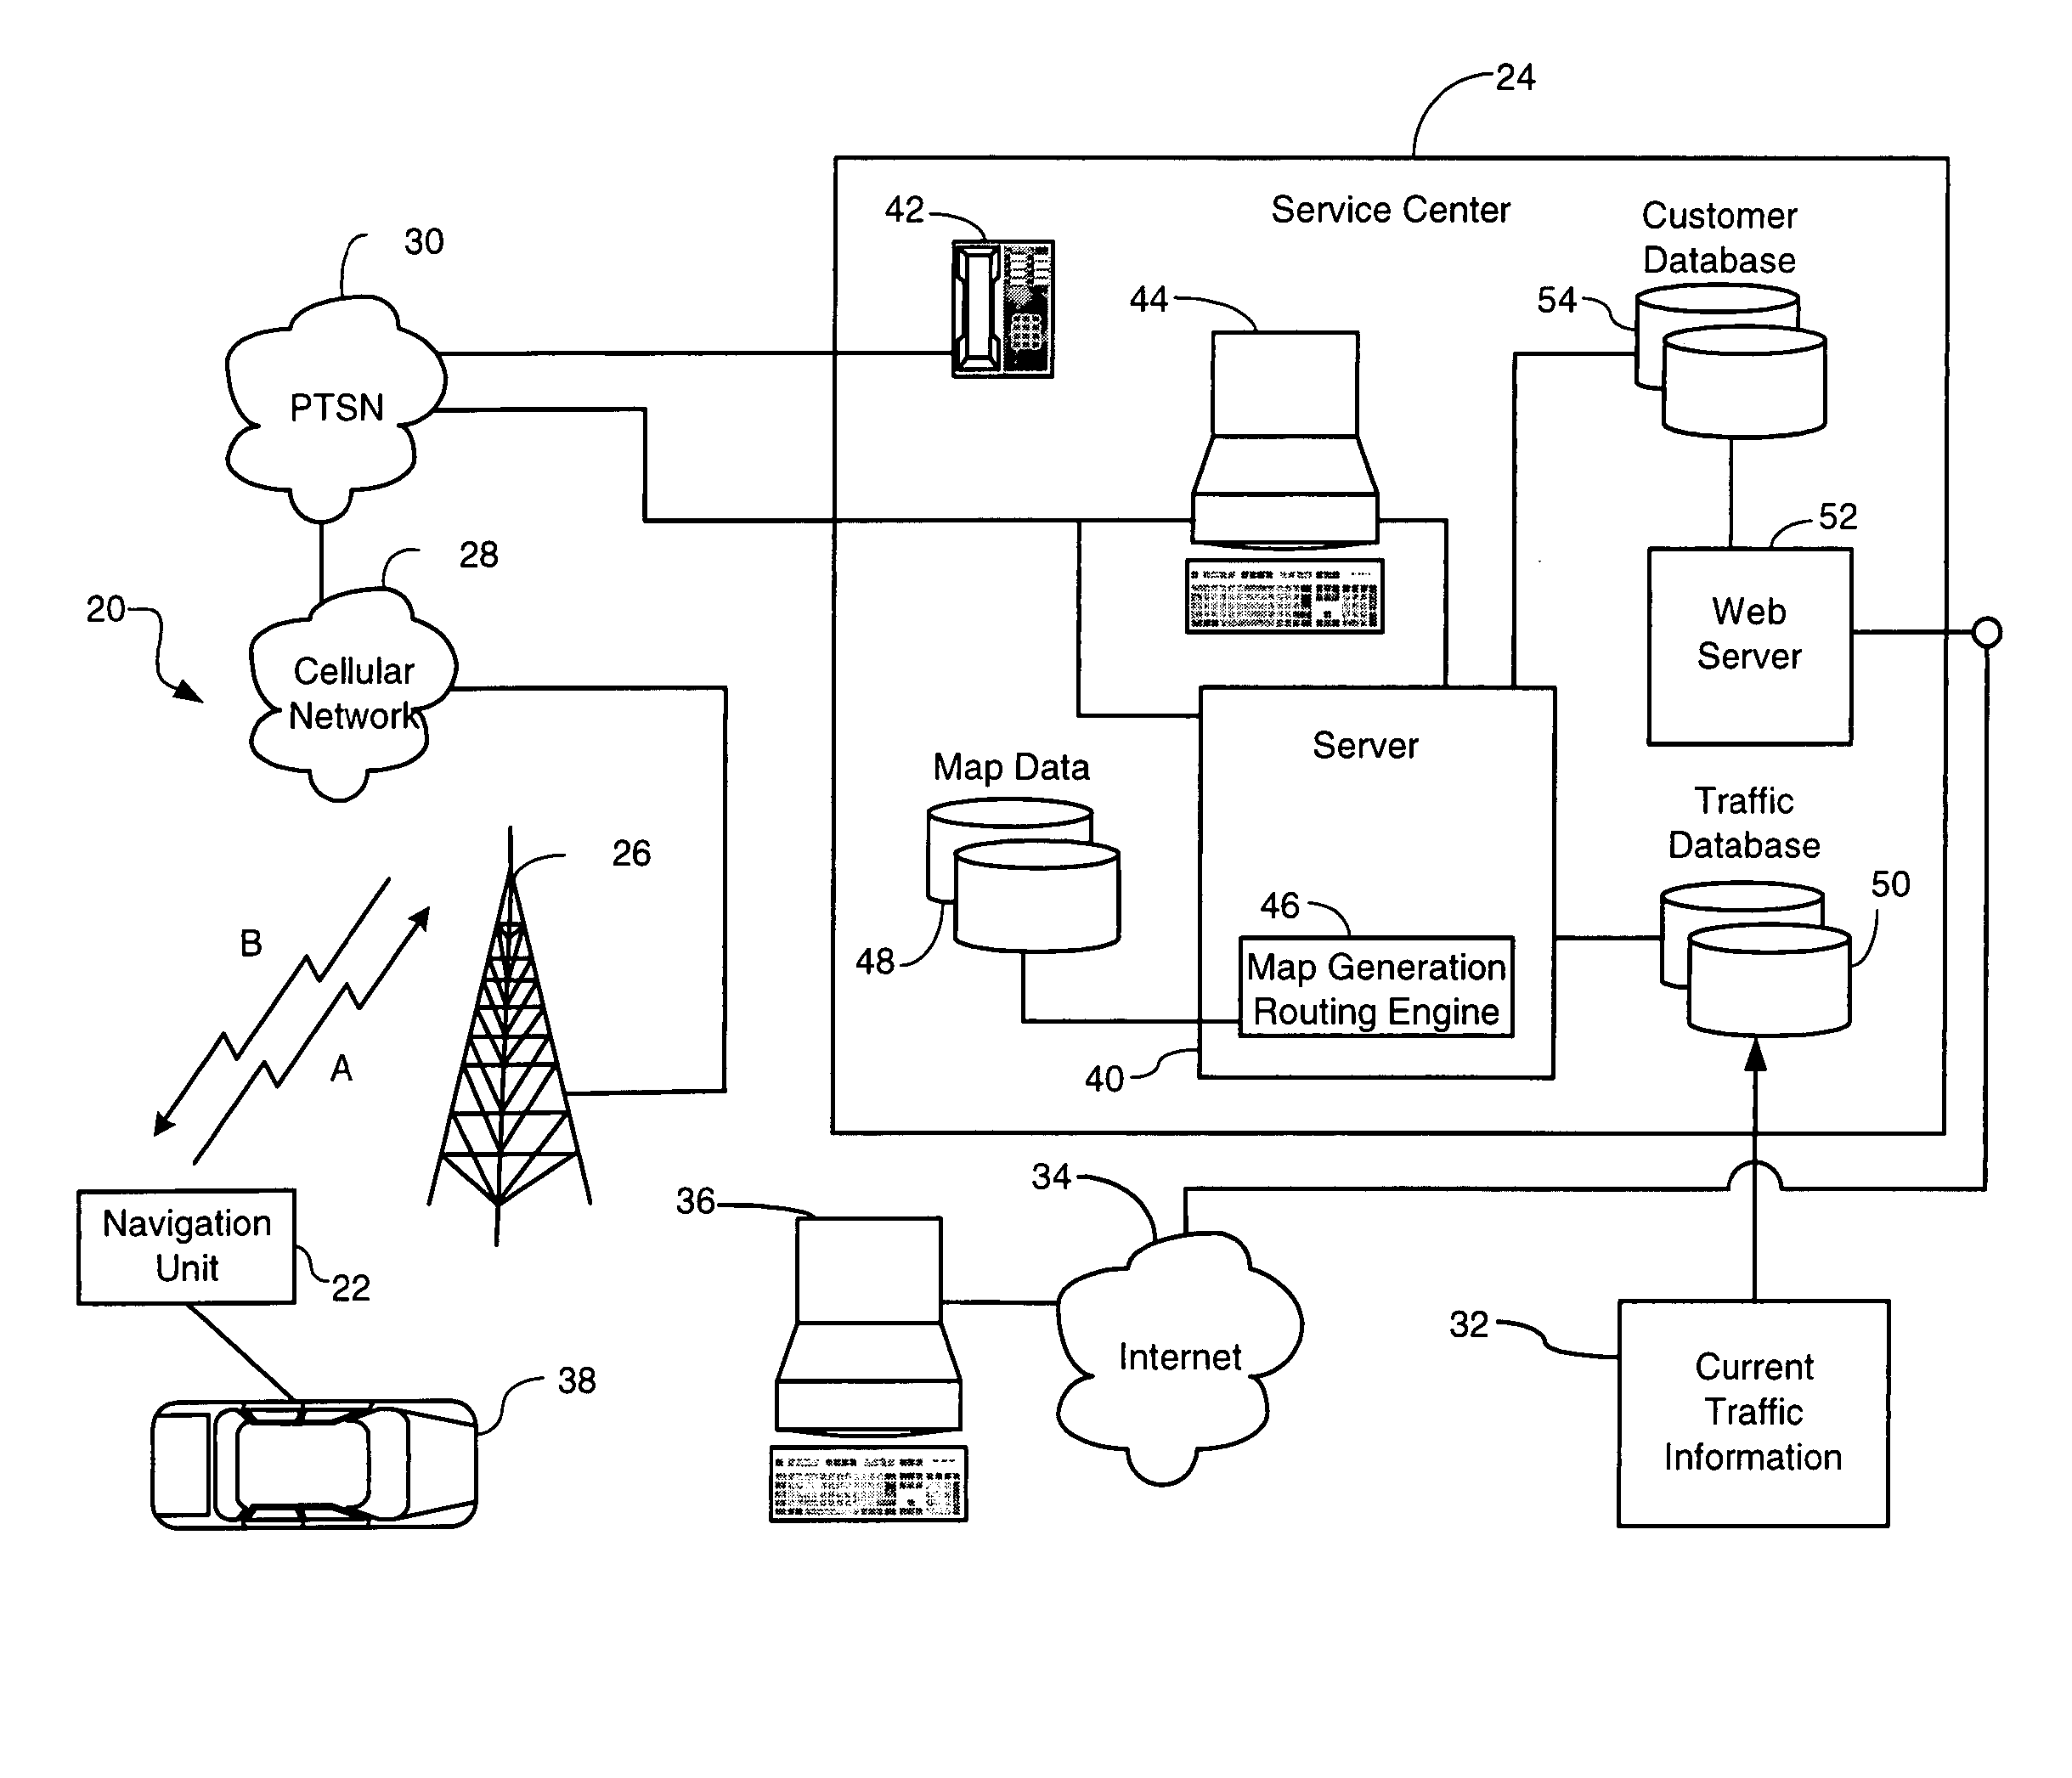
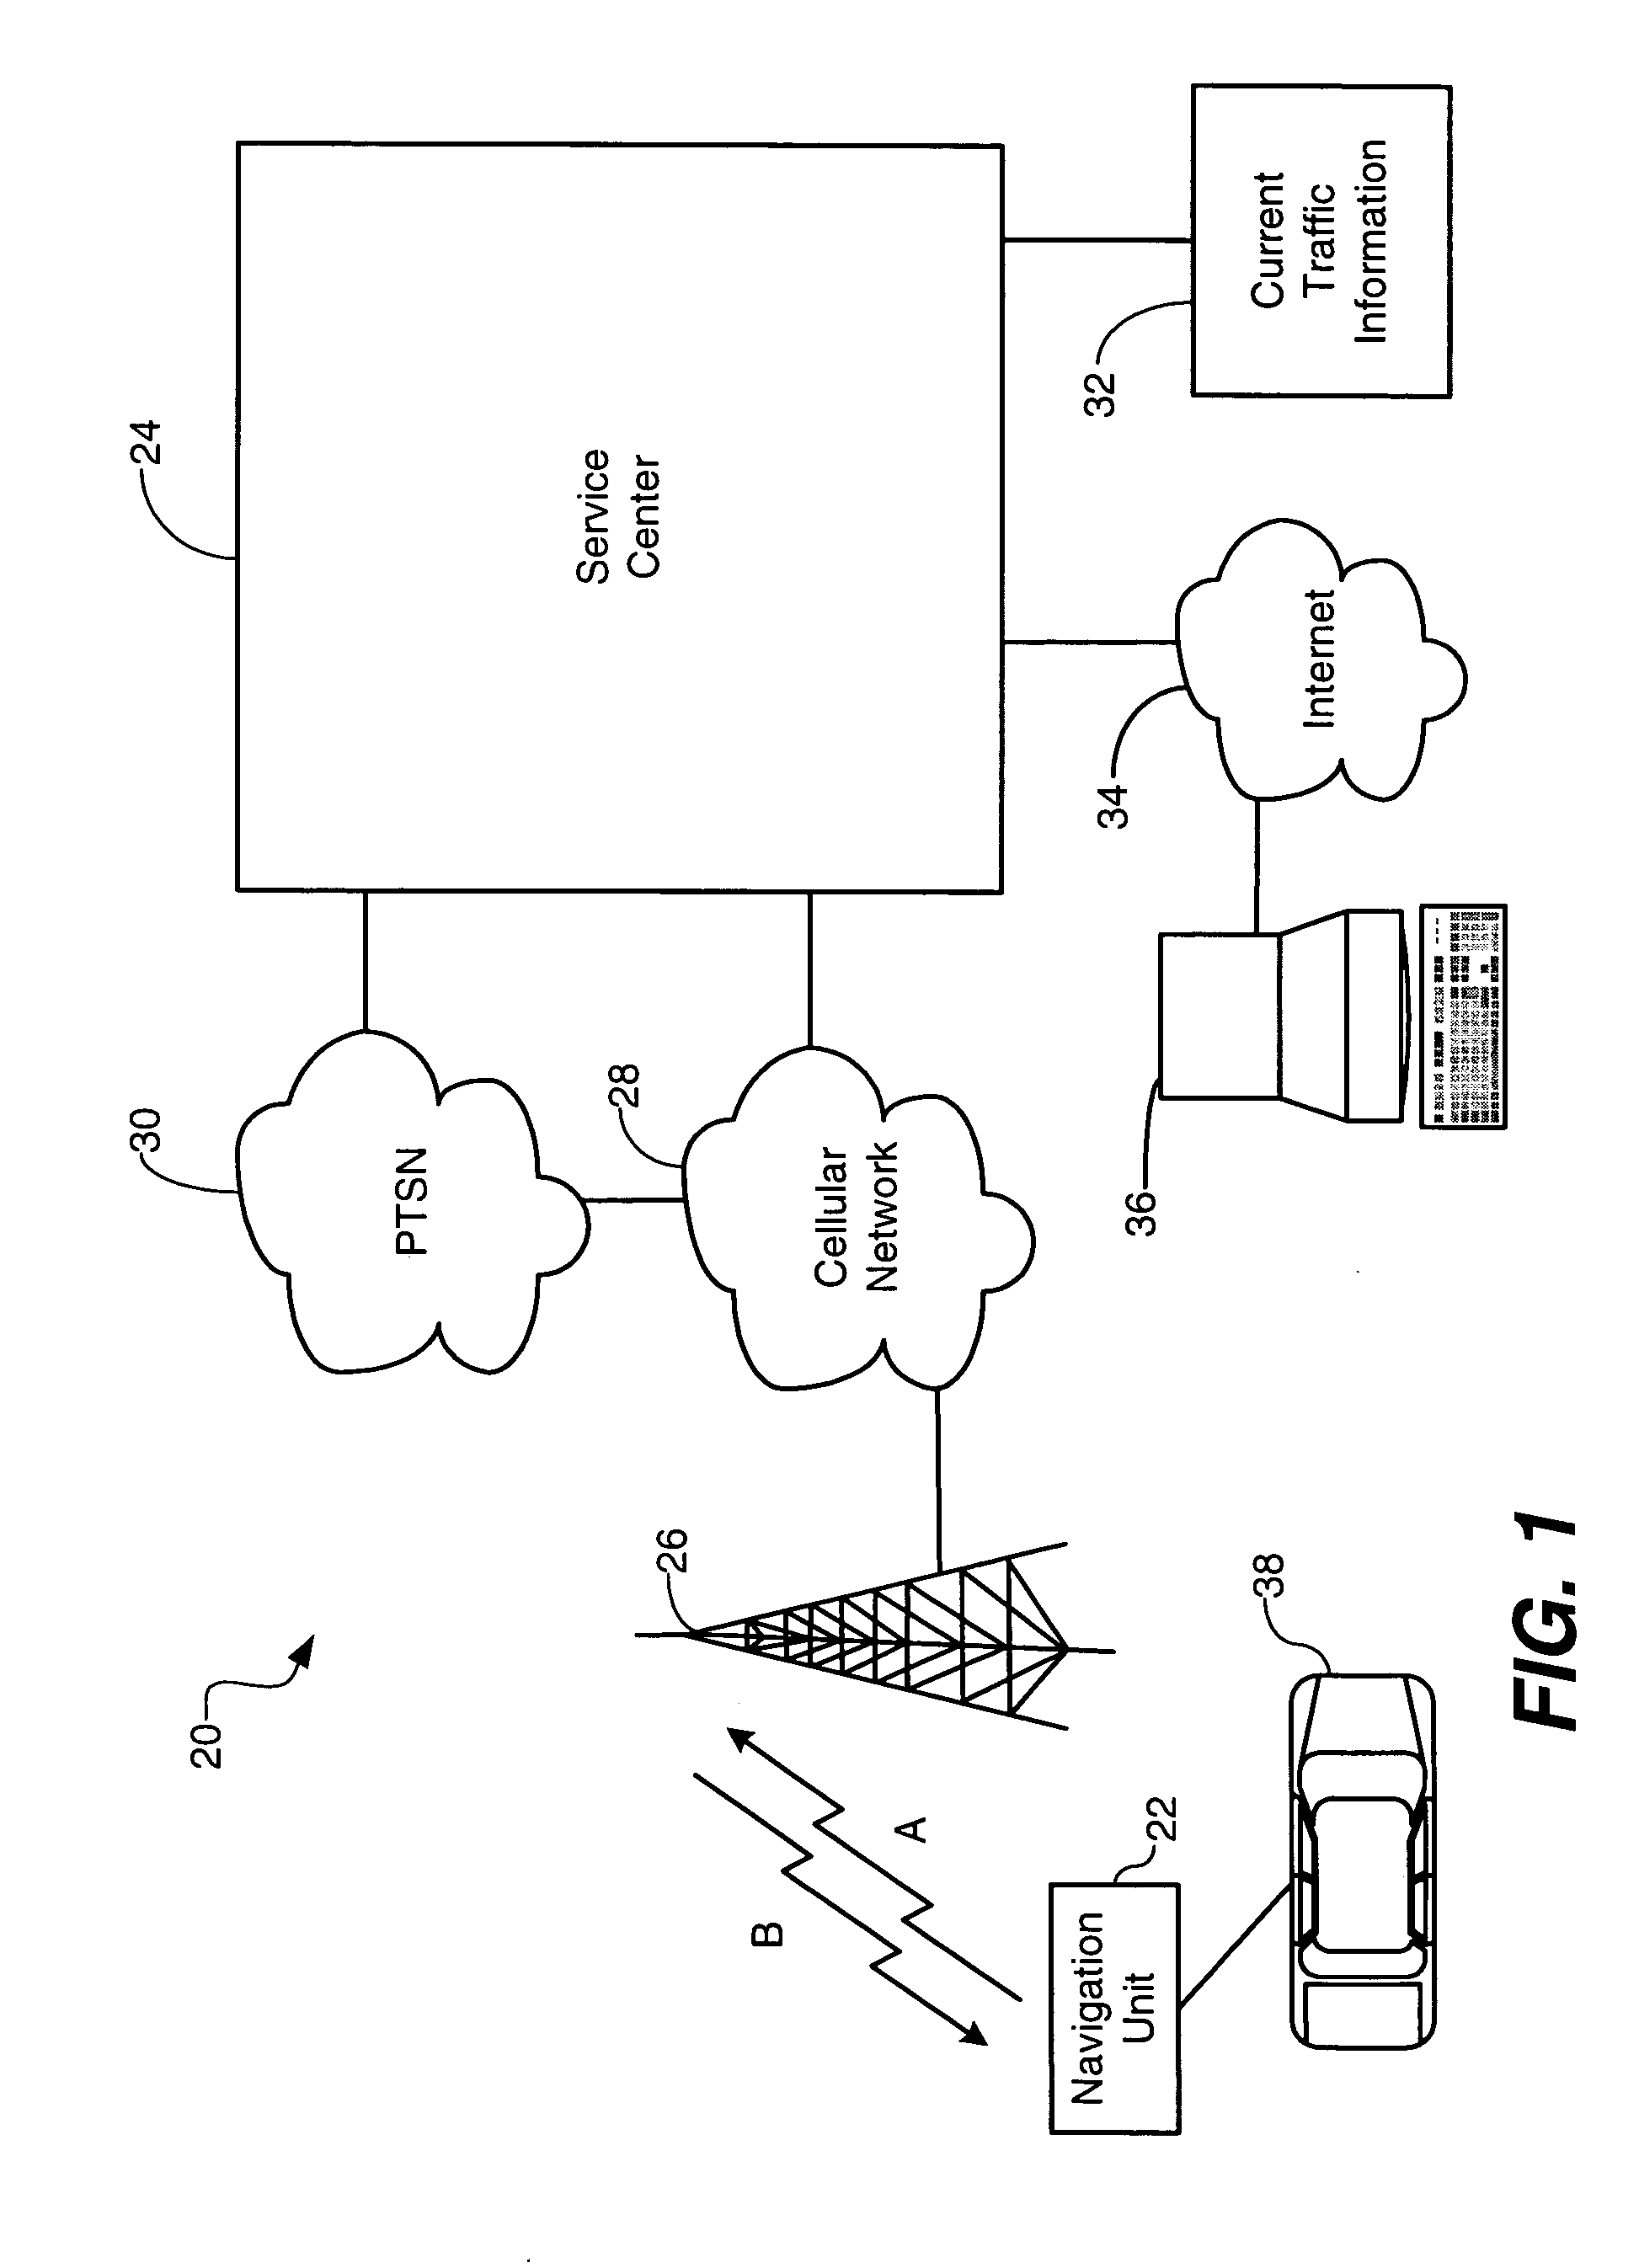
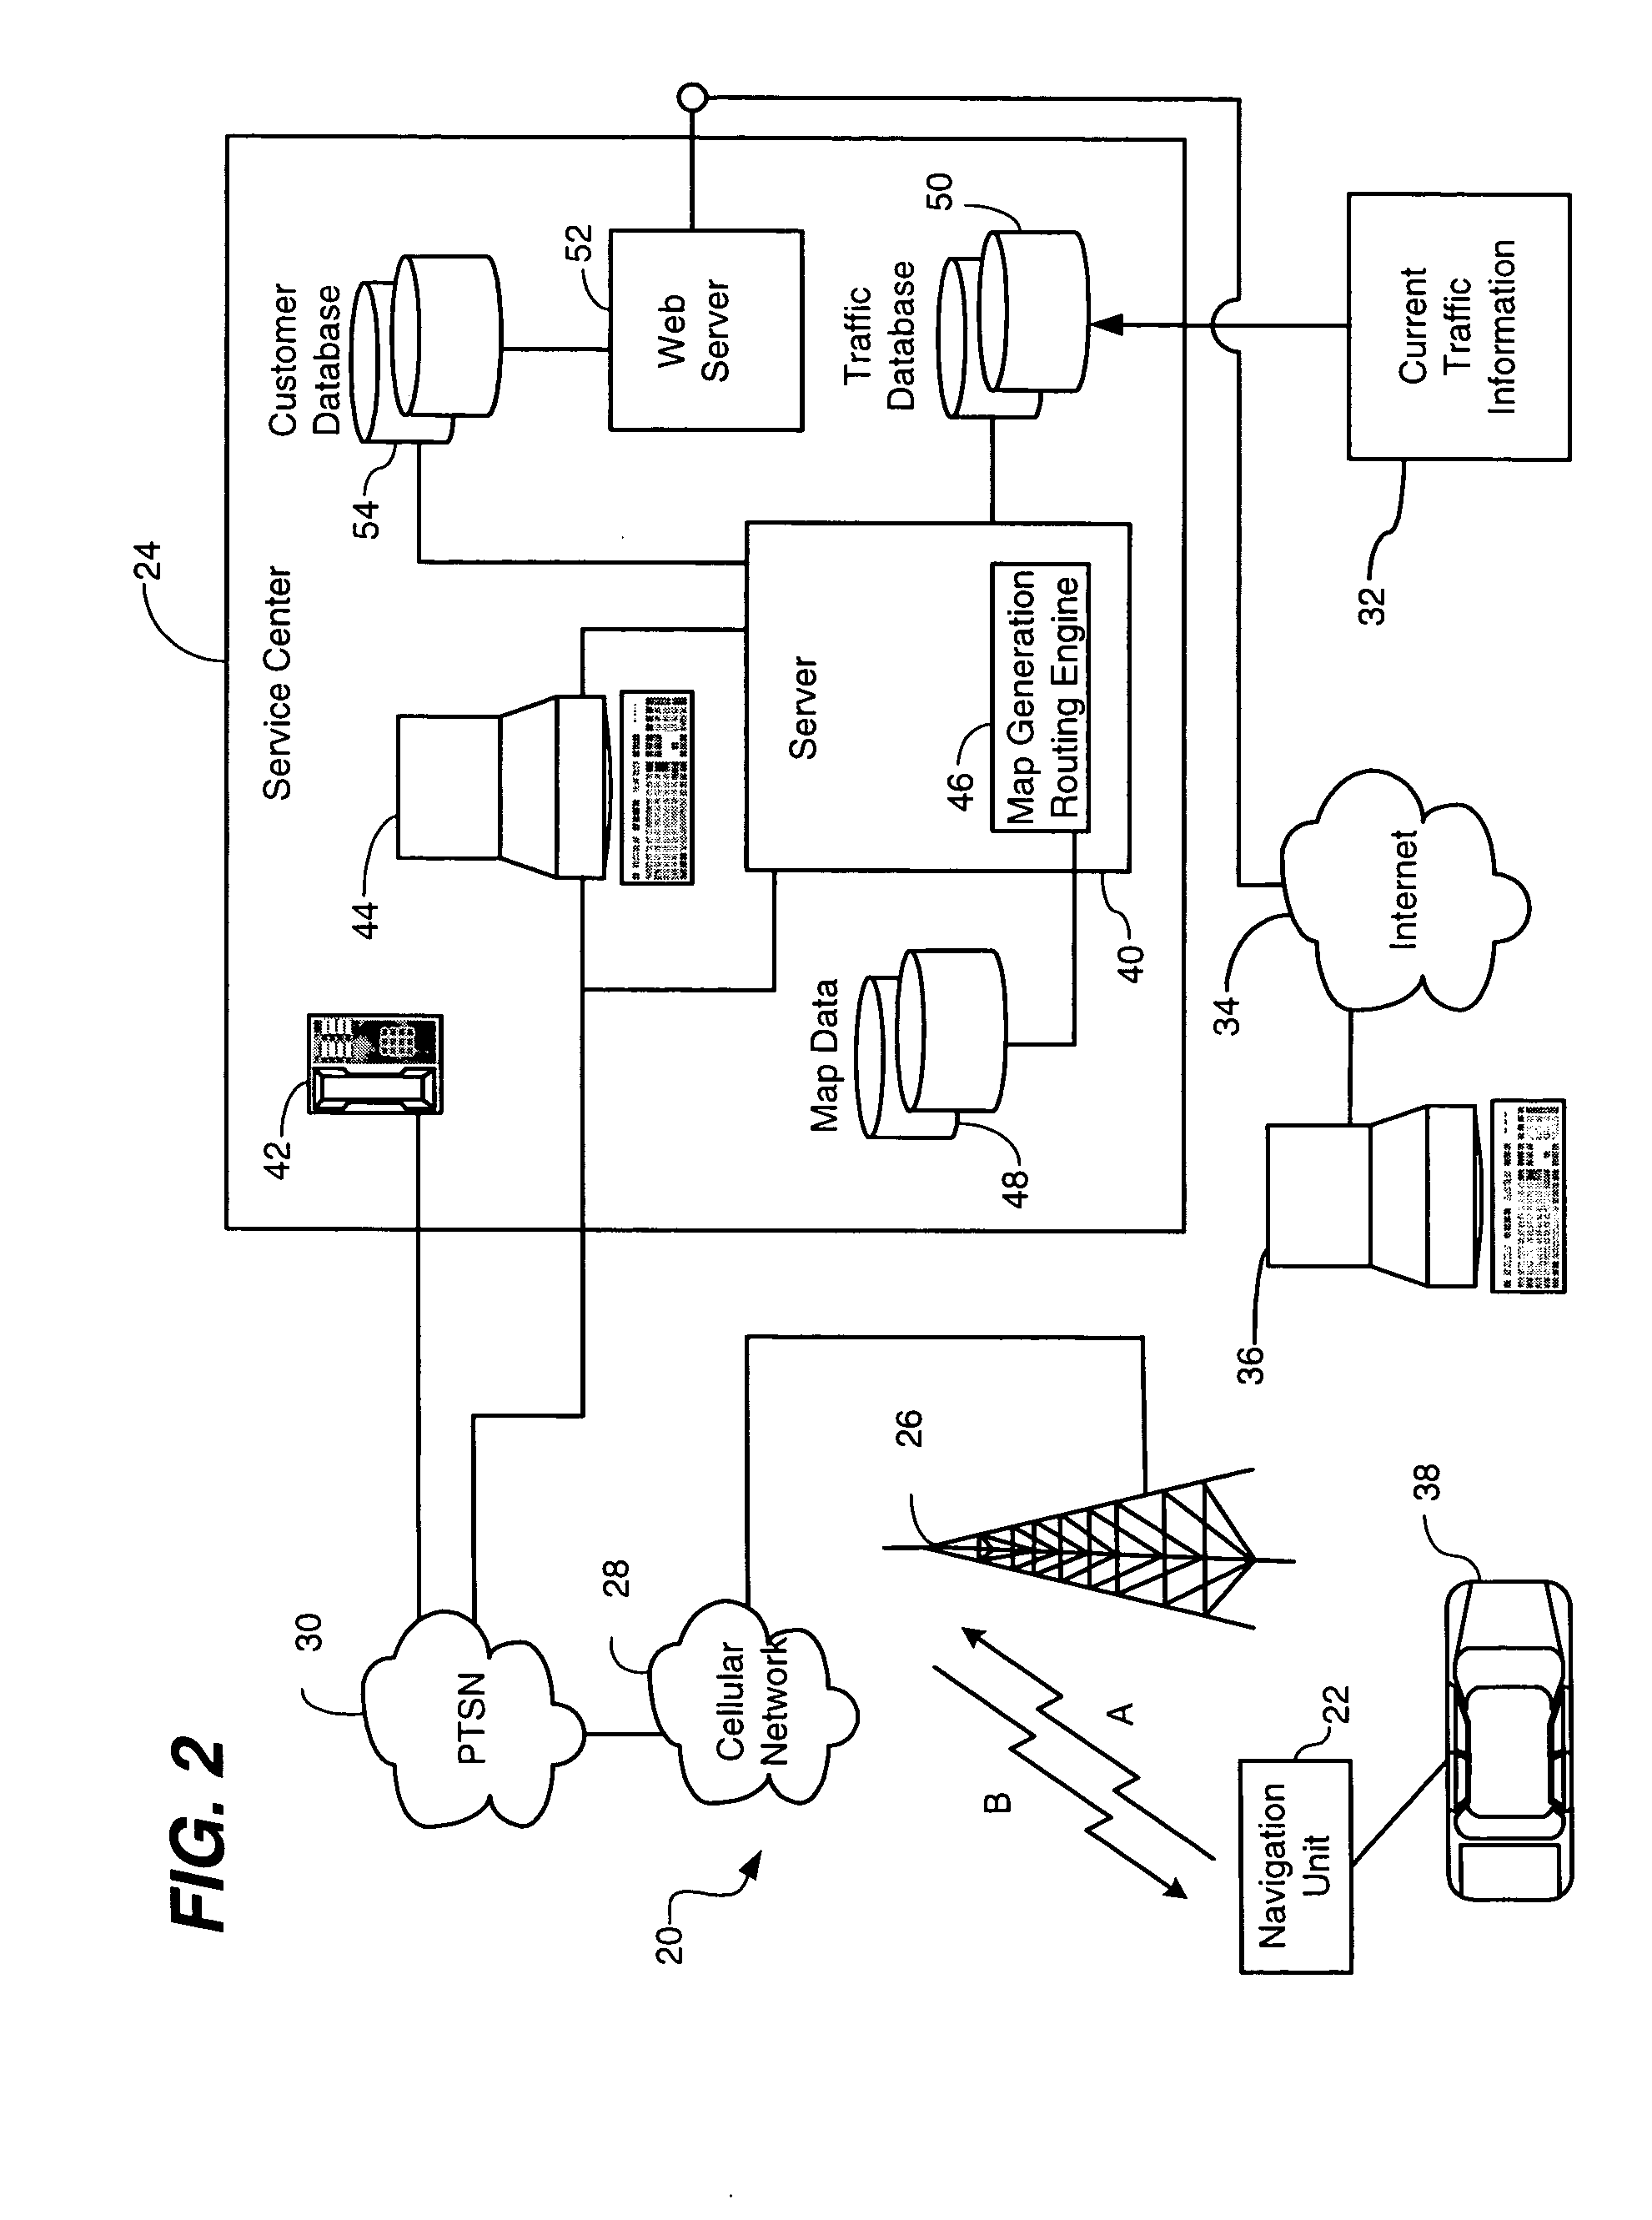
A system and method of calculating an estimated time of arrival for a traveler is provided, along with a notification of this estimated time that is sent to a third party. The traveler is equipped with a navigation unit having a global positioning sensor and a wireless communications device. The navigation unit communicates with a service center equipped with a server capable of generating a preferred navigational route for the traveler. The service center also includes a traffic database for maintaining current traffic information. Once the traveler has selected a predetermined time and frequency of notifications based upon a selected criterion, the navigation unit transmits the traveler's position and velocity to the service center. The service center then calculates the estimated time of arrival based upon the traveler's position, velocity, distance to be traveled and traffic and weather conditions. Once this time is calculated, the service center sends a notification to the third party.
Owner:MOTOROLA INC
Cloud based multi vehicle path planner
ActiveUS20250224236A1Instruments for road network navigationRoad vehicles traffic controlCloud baseEngineering
Aspects presented herein relate to perception data collection and curation. In one aspect, a network entity receives, from a first set of user equipments (UEs), a first set of perception data collected by the first set of UEs. The network entity configures, for a second set of UEs based on the first set of perception data, at least one of: a set of planned routes and time plans for collecting a second set of perception data or a set of embeddings centroids. The network entity receives, from the second set of UEs, the second set of perception data based on at least one of the configured set of planned routes and time plans or the configured set of embeddings centroids.

Owner:QUALCOMM INC
Artificial intelligence application assistant
ActiveUS12346712B1Instruments for road network navigationNatural language analysisUser deviceLinguistic model
An Applicant Assistant System may receive, from a user device, a user input indicating a query or task associated with information displayed in a user interface. The device may determine one or more components associated with the user interface and access component metadata of the determined one or more components, the component metadata for each of the one or more components indicating one or more of a fact, a data link, or an action. A prompt comprising at least some of the component metadata, at least some context information, and an indication of one or more available response elements may be provided to a large language model (LLM). The LLM may response with one or more response elements that may be processed by the System, such as to cause updates to the user interface on the user device.

Owner:SAMSARA INC
Integrated dispatch decision-making system and method for hub supporting multi-modal transportation coordination, and device
PCT designated stageWO2025232023A1Data processing applicationsRoad vehicles traffic controlOptimal decisionDecision model
The present invention relates to an integrated dispatch decision-making system and method for a hub supporting multi-modal transportation coordination, and a device. The system comprises: a multi-modal hub passenger flow data fusion and analysis module, which is used for arranging and classifying collected multi-modal hub passenger flow data, performing preprocessing, performing conversion and mapping to obtain normalized passenger flow data, and finally extracting a data fusion feature, and using a normalized transport passenger flow model to perform multi-dimensional data fusion and analysis computation; a hub transportation coordination decision-making module, which is used for performing transport capacity and volume assessment on the basis of the fusion and analysis of the multi-modal passenger flow data, and using an optimal decision-making model to compute an optimal strategy result; and a hub coordination dispatch and command application module, which is used for providing an intelligent command assistance function to a rail transit dispatch and command personnel on the basis of information access of hub-line-network, and the normalized transport passenger flow model. Compared with the prior art, the present invention has the advantages of improving the connectivity and coordinated dispatch of multi-modal transportation in a complex hub scenario, etc.

Owner:CASCO SIGNAL LTD
Community safety environment supervision system based on artificial intelligence
InactiveCN120769016ARoad vehicles traffic controlClosed circuit television systemsSystems managementData acquisition
The invention, which relates to the technical field of community safety supervision, discloses an artificial intelligence-based community safety environment supervision system comprising a data acquisition module, a data processing and analysis module, an intelligent decision module, an early warning response module and a system management module. The data acquisition module is used as a sensing layer of the system; the data processing and analysis module specifically comprises a feature extraction unit and a behavior recognition unit; the intelligent decision module is used for receiving the risk assessment result output by the data processing and analysis module; and the early warning response module generates the scheme according to the intelligent decision module. According to the community safety environment supervision system based on artificial intelligence, intelligent supervision of a community safety environment is realized through a complete closed loop of data acquisition, data processing, intelligent decision making, early warning response and system management; all the modules are in close cooperation, full-process automation from data collection to emergency response is ensured, and the efficiency and accuracy of community safety management are greatly improved.
Owner:TIANFU JIANGXI LAB
Driving vehicle road cloud cooperative safety control method and system based on trusted computing
PendingCN120301643ARoad vehicles traffic controlPublic key for secure communicationShardComputer network
The invention discloses a driving vehicle road cloud collaborative safety management and control method and system based on trusted computing, and the method comprises the steps: generating an HMAC-SM3 data fingerprint through employing an SM3 Hash algorithm engine, and proposing an LSTM lightweight dynamic trust evaluation model based on a TinyML framework; through a step-by-step Hash verification and rollback mechanism, through Geohash coding and SM3 Hash joint calculation, based on an aggregation signature of a BLS12-381 curve and public key aggregation, the communication overhead during multi-RSU collaborative signature is reduced; distributed private key fragmentation decryption is realized by adding a homomorphic aggregation ciphertext; aggregating and delaying the compressed ciphertext; dynamically evaluating the credibility of the nodes by a Krum dynamic defense mechanism; the system comprises a vehicle side credible sensing layer, a roadside credible broadcast layer and a cloud credible decision-making layer. According to the invention, through layered credibility verification, dynamic trust chain extension and a data privacy protection mechanism, the security and credibility problems of multi-node cooperation in an automatic driving scene are solved.

Owner:BEIJING INST OF TECH
End-to-end automatic driving control method and device based on multi-camera fusion
PendingCN120411902ARoad vehicles traffic controlCharacter and pattern recognitionNetwork architectureEngineering
The embodiment of the invention provides an end-to-end automatic driving control method and device based on multi-camera fusion, and multi-view target detection and tracking are realized through spatial transformation and coordinate mapping by combining front wide-angle camera information and left and right wide-angle camera information. A multi-view feature fusion network architecture is designed, the multi-view feature fusion network architecture comprises three sub-networks of feature extraction, dynamic weight distribution and feature fusion, and the fusion weight is dynamically adjusted based on image definition, detection confidence and view overlapping degree. A geometric consistency constraint between visual angles and a reconstruction loss function are introduced, a deep neural network model is constructed, abnormal conditions such as camera shielding are effectively handled, and an accurate control instruction is output. According to the method, the defects of the traditional technology in the aspects of multi-view information fusion, shielding processing and the like are overcome, and the sensing ability and the control reliability of the automatic driving system are remarkably improved.

Owner:ZHEJIANG WUWEN ZHIXING TECHNOLOGY CO LTD
Early warning method for running speed of vehicle on icy road in mountainous area based on physical information constraint
The invention discloses a mountainous area icy road vehicle driving speed early warning method based on physical information constraint, and relates to the technical field of intelligent traffic and vehicle safety, and the method comprises the steps: carrying out the multi-modal data collection and preprocessing, constructing a multi-modal feature extraction network to extract a high-dimensional vector, constructing a fusion module based on an attention mechanism to output a fusion feature vector, and carrying out the early warning of the driving speed of a mountainous area icy road. The method has the advantages that data such as environment, vehicle dynamics and road surface friction coefficients are collected through the multi-source sensor fusion technology, a multi-modal feature extraction and fusion network is constructed, and the real-time classification early warning is realized through the multi-modal feature extraction and fusion network; the method comprises environment, vehicle dynamic and road friction feature extraction sub-networks, deep extraction of different modal data features, a fusion network based on an attention mechanism, concerning of association, coupling and cooperative influence among data, and dynamic weighting of fusion features, so that the purposes of accurately sensing a complex environment, reducing false alarm and missing alarm and effectively improving early warning accuracy are achieved.

Owner:CHONGQING JIAOTONG UNIV
Cro-intentformer-based method and system for predicting surrounding vehicle trajectories by integrating driving intentions
ActiveUS20250128727A1Internal combustion piston enginesRoad vehicles traffic controlEngineeringMachine learning
The provided is a method and system for trajectory prediction based on Cro-IntentFormer. The method starts by preprocessing vehicle trajectory data collected by sensors to produce raw data suitable for model input. Vehicles are treated as nodes, and the distance between vehicles serves as the basis for determining whether there is an edge between two vehicle nodes. A physical relationship graph is constructed and, along with the raw data, input into a spatio-temporal feature extraction module to obtain the spatio-temporal features of the trajectory. The spatio-temporal feature matrix is then input into an intent prediction module to determine the predicted intentions of the vehicles. Based on the intent information output by the intent prediction module, a semantic relationship graph is reconstructed and input, along with the raw data, into the spatio-temporal feature extraction module to derive the semantic features of the trajectory.

Owner:JIANGSU UNIV
Configured artificial intelligence systems and methods for software-defined vehicles
PCT designated stageWO2026024858A1Semantic analysisRoad vehicles traffic controlTransit systemEngineering
The present disclosure relates to configured artificial intelligence methods and systems and related transportation systems and methods, including software-defined vehicles, for transportation systems using sensor and other data, and the integration of a transportation system with an AI convergence system of systems, providing a multi-layered system for intelligent automation and data-driven decision making across operational aspects of a transportation system.

Owner:STRONG FORCE TP PORTFOLIO 2022 LLC
Intelligent early warning method based on fusion of 5G Internet of Things and video monitoring
InactiveCN120766464AInternal combustion piston enginesRoad vehicles traffic controlVideo monitoringImage resolution
The invention belongs to the technical field of intelligent monitoring, and particularly relates to a 5G Internet of Things fused video monitoring intelligent early warning method, which comprises the following steps of: acquiring vehicle attribute information and environment perception data, constructing a 5G Internet of Things perception network, fusing a vehicle movement track and road condition environment data through a cross-modal attention mechanism, generating an enhanced environment perception graph, and simultaneously, carrying out early warning on the vehicle movement track and the road condition environment data. Optimizing the transmission efficiency by adopting a dynamic resolution adjustment algorithm; the method comprises the following steps: constructing a dynamic behavior prediction model by using a space-time diagram convolutional network, predicting a vehicle abnormal behavior probability and an evolution trajectory, calculating an early warning level through an adaptive risk quantification algorithm, simulating a risk diffusion coefficient by using a dynamic risk propagation model according to the road section vehicle density, the average vehicle speed and the road traffic capacity, and correcting early warning sensitivity parameters in real time. And transmitting to a command platform, performing situation deduction, triggering a grading early warning instruction, and generating thermodynamic diagram warning information. Therefore, the problems of insufficient positioning precision, weak analysis capability, poor transmission efficiency and the like in the prior art are solved.

Owner:HARBIN TUTONG TECH CO LTD
Hard shoulder driving and variable speed limit cooperative control method and system
ActiveCN119672981AInternal combustion piston enginesRoad vehicles traffic controlIntelligent transportation system itsRoad networks
The invention relates to the technical field of intelligent traffic systems, and discloses a hard shoulder driving and variable speed limit cooperative control method and system.The method comprises the steps that traffic data are collected, and the traffic data comprise traffic information and speed limit values; according to the hard shoulder lane-borrowing driving motivation, the lane-borrowing safety condition and the emergency or rescue vehicle requirement of the networked autonomous vehicle, whether the networked autonomous vehicle can run through the hard shoulder lane or not is judged; inputting the collected traffic data into a pre-constructed DDPG algorithm to determine a state, an action space and a reward function of the DDPG algorithm, and outputting an optimal speed limit value; and the optimal speed limit value of each lane of the control road section is generated through a DDPG algorithm, and the network-connected automatic driving vehicle adjusts the vehicle speed according to the optimal speed limit value. The method can be used for highway entrance ramp sections with serious congestion, the average travel time and carbon dioxide emission of the road network can be reduced, and a new method is provided for efficient and low-carbon targets of smart highways in China.

Owner:SOUTHEAST UNIV
Internet of Vehicles key information classification early warning method and vehicle-mounted device
InactiveCN112330972AEffective reminderNot too distractingRoad vehicles traffic controlCharacter and pattern recognitionIn vehicleInformation type
The invention provides an Internet of Vehicles key information classification early warning method and a vehicle-mounted device. The Internet of Vehicles key information classification early warning method comprises the steps: acquiring Internet of Vehicles information of a target vehicle; determining current driving state information of the target vehicle according to the Internet of Vehicles information; and determining the type of information sent to the target vehicle according to the driving state information. According to the invention, the information with different emergency degrees can be sent to the user according to the current driving state information, multi-channel grading early warning is realized according to the information type, and the effects of assisting driving, promoting safety and improving user experience are achieved.


Owner:TSINGHUA UNIV
Motion prediction and trajectory generation for mobile agents


Owner:FIVE AI LTD
Traffic flow prediction method based on dynamic sparse graph convolution GRU
ActiveCN119694142AInternal combustion piston enginesRoad vehicles traffic controlAlgorithmTheoretical computer science
The invention belongs to the technical field of traffic transportation, and particularly relates to a traffic flow prediction method based on a dynamic sparse graph convolution GRU, which integrates a space-time attention fusion scheme of a gating mechanism, adds a dynamic sparse graph convolution gating cycle unit DSGCN-GRU in a model, and is adaptive to a dynamic sparse graph convolution embedded gating cycle network. Dynamic spatial structure information diffusion is simulated, heterogeneous features and local features of spatial data are effectively captured, the irregularity and dynamic variability represented by spatial information are further reflected, the understanding of the model on local and global spatial-temporal features is improved through the spatial-temporal attention of a gating mechanism, and the spatial-temporal attention of the gating mechanism is optimized. Unified description of a multi-scale and long-distance space-time mode is realized, and the strain of the model to long-term traffic flow prediction and sudden traffic events is enhanced. Compared with an existing traffic flow prediction method, the traffic flow prediction accuracy can be effectively improved.

Owner:山西省智慧交通实验室有限公司 +3
Data processing method and system for iterative sensor fusion, computer program product and computer readable medium for implementing the method
PendingUS20250342176A1Road vehicles traffic controlParticular environment based servicesData setData source
The invention relates to a data processing method for iterative sensor fusion. The method comprises receiving sensor data from a first data source type and a second data source type. The first data source type is adapted for providing sensor data for exclusively determining an entity and the second data source type is adapted for providing sensor data of a tracked entity. The method further comprises generating a data source identifier for each of the sensor data. The data source identifier comprises a data source type identifier corresponding to a data source type from which the sensor data is received. A first data source type identifier corresponds to the first data source type and a second data source type identifier corresponds to the second data source type. The method further comprises compiling a dataset that comprises newest sensor data received, and iteratively performing a data association step on the dataset.

Owner:COMMSIGNIA KFT
Traffic flow prediction model for multilayer space-time structure correlation perception
The invention relates to the technical field of traffic prediction, in particular to a multi-layer space-time structure correlation perception traffic flow prediction model, which comprises a space-time structure decomposition layer for decomposing original traffic flow data into a road hierarchical structure feature matrix, a dynamic time period feature matrix and a hidden space topology feature matrix; the dynamic adjacency matrix generation layer is used for constructing a self-adaptive adjacency weight matrix based on the hidden space topological feature matrix; the cross-level correlation perception layer performs bidirectional feature modulation on the road hierarchical structure feature matrix and the dynamic time period feature matrix to generate a space-time coupling feature tensor; and the prediction layer inputs the space-time coupling feature tensor into a space-time diagram convolution prediction network and outputs a traffic flow prediction value in a future time period. According to the method, the expression ability of the model on potential heterogeneous association between the nodes is improved, and the generalization ability across regions and time periods is effectively improved.

Owner:ZHAOQING UNIV
Highway pavement ice condensation monitoring system
ActiveCN120217115ARoad vehicles traffic controlAutomatic recalibrationEnvironmental resource managementTraffic crash
The invention, which relates to the technical field of highway traffic safety monitoring, discloses an expressway pavement ice condensation monitoring system comprising a data acquisition module for acquiring environmental data and pavement icing state information on an expressway pavement; and the self-calibration module is connected with the data acquisition module, performs self-calibration on the data acquisition module according to the environment data acquired in real time and the road surface icing state information, and corrects sensor errors caused by external environment factors. According to the highway pavement ice condensation monitoring system, a self-calibration function is added in monitoring equipment and an intelligent algorithm is introduced, so that the monitoring system can automatically correct measurement errors caused by external environment changes in real time, and a machine learning model is combined to predict pavement conditions more accurately; the working stability of the system in severe weather can be improved, and the risk of icing of the road surface can be found earlier, so that more accurate early warning information is provided for a traffic management department, and the probability of traffic accidents is reduced.

Owner:SHAANXI EXPRESSWAY ENG TESTING INSPECTION & TESTING CO LTD
Machine learning model for predicting driving events
A processor retrieves data associated with a set of driving sessions and generates a training dataset by labeling a first subset of data that corresponds to driving sessions that included a first event and labeling a second subset of the data that corresponds to driving sessions that included an indication of an airbag activation. The processor then trains an artificial intelligence model using the training dataset, such that trained artificial intelligence model predicts a score indicative of a likelihood of a new driving session associated with a new driver being associated with at least the first event or an airbag activation. Once trained, the processor can augment the score using data retrieved after each driving session. The processor can also notify the driver if the driver's actions has caused their score to increase / decrease and provide an underlying reason.

Owner:TESLA INC
Systems and methods for determining driving scenario probability metrics and vehicle performance metrics
Techniques for determining a metrics associated with a vehicle are disclosed. The techniques may comprise receiving a driving simulation scenario associated with a simulated vehicle. Based at least in part on the scenario and a dataset of recorded driving associated with operation of a test vehicle, a plurality of driving events present in the dataset may be determined. Based at least in part on the plurality of driving events, a first metric associated with a likelihood of occurrence of the driving simulation scenario may be determined. A simulation may be instantiated based at least in part on the driving simulation scenario. Based at least in part on the simulation, a safety metric indicative of the safe performance of the simulated vehicle in the simulation may be determined. An aggregate safety metric may be determined based at least in part on the safety metric and the first metric.

Owner:ZOOX INC
Garbage truck real-time monitoring and remote scheduling method based on Internet of Things
ActiveCN119647912AImprove reliabilityImprove stabilityData processing applicationsRoad vehicles traffic controlDistribution matrixPathPing
The invention discloses a garbage truck real-time monitoring and remote scheduling method based on the Internet of Things, and the method comprises the following steps: S1, collecting the real-time data of the operation state of a garbage truck, and carrying out the preprocessing of the real-time data; s2, constructing a task prediction model based on an improved adaptive graph neural network, and generating a preliminary task distribution matrix and a path planning scheme; s3, optimizing the preliminary task allocation matrix and the path planning scheme by adopting an improved PPO algorithm; s4, the optimized task allocation matrix and the path planning scheme are sent to a garbage truck vehicle-mounted terminal, and the task completion rate and the path deviation value are calculated; s5, the operation state of the garbage truck is monitored in real time, and the monitoring result and the operation state data are transmitted to the cloud Internet of Things platform; and S6, dynamically updating the scheduling instruction. According to the method, the Internet of Things, the adaptive graph neural network and the improved PPO algorithm are fused, intelligent scheduling and real-time optimization of the garbage truck are realized, and the method has the advantages of high efficiency, stability and low-cost operation.

Owner:ANKANG XINYEFENG ENVIRONMENTAL TECH CO LTD
Multi-mode cooperative unmanned aerial vehicle highway illegal parking intelligent identification method and system
The invention discloses a multi-mode cooperative unmanned aerial vehicle highway illegal parking intelligent identification method and system. The system comprises a multi-mode sensing layer and a dynamic focusing control engine. The multi-mode sensing layer is connected with an unmanned aerial vehicle end, and the multi-mode sensing layer comprises a vehicle detection module, a lane semantic segmentation module and a vehicle tracking module; the vehicle detection module positions a vehicle target from an unmanned aerial vehicle cruise acquisition road video stream obtained from the unmanned aerial vehicle end; the lane semantic segmentation module can perform anti-distortion lane semantic perception; the vehicle tracking module establishes a motion model based on the target vehicle positioned by the vehicle detection module; the dynamic focusing control engine obtains a lane mask graph and a vehicle state according to the lane semantic segmentation module and the vehicle tracking module; and the dynamic focusing control engine is also used for performing illegal judgment and evidence generation and sending the illegal judgment and evidence generation to the traffic management law enforcement platform. According to the invention, precise identification and automatic law enforcement evidence collection of illegal parking targets in the highway scene are realized.

Owner:GUANGXI TRANSPORTATION SCI & TECH GRP CO LTD
Multi-terminal-fused discontinuous vehicle illegal parking detection method and system
ActiveCN120726825ARoad vehicles traffic controlCharacter and pattern recognitionSimulationParking space
The invention discloses a non-continuous vehicle illegal parking detection method and a non-continuous vehicle illegal parking detection system fusing multiple terminals. The method comprises the following steps: acquiring pictures of the same area shot by terminals carried on different devices in different time periods and on different routes, so as to obtain a plurality of non-continuous pictures; performing spatial-temporal clustering and correction, positioning a vehicle by using a static landmark extraction technology, determining a vehicle area, and constructing position fingerprints for cross-time comparison to determine whether the vehicle is in a static state; wherein on the basis of the corrected discontinuous picture, multi-view information fusion is carried out, so that complete scene description information is fused; when the vehicle is in a static state, determining a parking space area and environment characteristics; judging whether the vehicle has illegal parking behaviors or not; if yes, subdividing illegal parking types of the vehicles; and creating a structured illegal parking report. By implementing the method provided by the invention, comprehensive and efficient monitoring of different types of illegal parking behaviors can be realized, and meanwhile, the accuracy and reliability of monitoring data are ensured.

Owner:WINTOO INFORMATION TECHNOLOGY (HANGZHOU) CO LTD
System and method for road sign translation and display
A vehicle system is configured for translating and displaying signs. The vehicle system includes at least one computer configured to access to a database of model signs, where the database is stored local to the at least one computer and includes translations associated with the model signs. The system also includes a camera configured to generate image data, and transmit the image data to the at least one computer, where the at least one computer determines whether the image data indicates a detected sign, and whether the detected sign matches one of the model signs in the database. The system also includes a display operatively connected with the at least one computer for displaying a translation associated with a matching model sign in the database when the at least one computer determines that the image data indicates a detected sign that matches one of the model signs.

Owner:HONDA MOTOR CO LTD
Multi-link redundancy guarantee method for intelligent driving vehicle in extreme scene of highway
The invention relates to the technical field of intelligent traffic and automatic driving, and discloses a multi-link redundancy guarantee method for an intelligent driving vehicle in a highway extreme scene, which comprises the following steps: acquiring vehicle-mounted sensor data, roadside equipment data and cloud traffic data corresponding to a preset highway section, constructing a global traffic situation map according to the vehicle-mounted sensor data, the roadside equipment data and the cloud traffic data; according to the global traffic situation map, evaluating the risk level of each highway section, and determining the takeover control strategy of the intelligent driving vehicle in each highway section according to the risk level; under the condition that the takeover control strategy is a formation cooperation strategy, generating a formation cooperation instruction of intelligent driving vehicles in a corresponding highway section, and sinking the formation cooperation instruction to a roadside edge node; and sending the formation cooperation instruction to the intelligent driving vehicle based on a multi-link redundancy architecture.

Owner:GUANGDONG LEGEND COMM CO LTD
Utilizing GNSS risk analysis data for facilitating safe routing of autonomous drones
Disclosed is route planning using a worst-case risk analysis and, if needed, a best-case risk analysis of GNSS coverage. The worst-case risk analysis identifies cuboids or 2d regions through which a vehicle can be routed with assurance that adequate GNSS coverage will be available regardless of the time of day that the vehicle travels. The best-case risk analysis identifies cuboids or 2d regions through which there is adequate coverage at some times during the day. In case path finding using the worst-case risk analysis fails, a best-case risk analysis can be requested and used to find alternate potential path(s). Time dependent forecast data that covers regions along the alternate potential path(s) can be requested and used to route vehicles, including autonomous drones, from starting points to destinations. This includes generation, distribution and use of risk analysis data, implemented as methods, systems and articles of manufacture.

Owner:SPIRENT COMMUNICATIONS PLC
Autonomous vehicle driving path selection in the presence of emergency vehicle sounds
The described aspects and implementations support sound-based emergency vehicle detection, localization, and tracking for autonomous vehicle and driver-assist systems. The techniques include obtaining, using one or more audio detectors of a vehicle, a sound recording that includes a sound emitted by an emergency vehicle (EV). The techniques further include applying a sound localization (SL) model to the sound recording to obtain a SL output, which includes a first map of possible locations of the EV in a driving environment of the vehicle and can further include a second map of possible velocities of the EV. The techniques further include simulating, using the SL output, trajectories of simulated EV(s) in the driving environment of the vehicle, and causing, responsive to proximity of the simulated trajectories to a driving path of the vehicle, modification of the driving path of the vehicle.

Owner:WAYMO LLC
Validating a travel corridor for lateral guidance of a motor vehicle
The disclosure relates to validation of a driving corridor for lateral guidance of a motor vehicle by a driver assistance system. Based on environmental data, a driving corridor with corridor boundaries is determined, the corridor boundaries specifying a first track width for the lateral guidance of the motor vehicle. It is then checked whether there is more than one driving trajectory within the corridor boundaries, by determining whether there is more than one data point along a rear axle of the motor vehicle, each of which is assigned to a different driving trajectory. Based on a result of the determining, the driving corridor is validated and the first track width is used for the lateral guidance of the motor vehicle, or the driving corridor is falsified and a different, second track width is used for the lateral guidance of the motor vehicle.

Owner:CARIAD SE +1
Traffic flow prediction method and system based on feature fusion and frequency enhancement
The invention discloses a traffic flow prediction method and system based on feature fusion and frequency enhancement. The method comprises the following steps: acquiring traffic flow data of a traffic monitor and external meteorological data and carrying out preprocessing; a dynamic space-time diagram generation module constructs a dynamic space-time diagram fusing a geographic neighbor diagram and a function similar diagram based on the preprocessed traffic flow data; inputting the dynamic space-time diagram into a space-time attention convolution layer to obtain a space-time matrix; fusing the space-time matrix with the external meteorological data subjected to one or more times of long-short-term memory network processing, and executing near-time slicing processing on the fused data; and constructing a hierarchical encoder-decoder model based on Transform, and generating traffic flow prediction data after the data subjected to slicing processing passes through the model. According to the method, the traffic flow prediction precision can be improved, and a more reliable prediction result is provided.

Owner:XIAMEN UNIV
System and method for server based control
ActiveUS12316706B2Vehicle fittingsRegistering/indicating working of vehiclesLinear controlImaging processing
A system and method in a building or vehicle for an actuator operation in response to a sensor according to a control logic, the system comprising a router or a gateway communicating with a device associated with the sensor and a device associated with the actuator over in-building or in-vehicle networks, and an external Internet-connected control server associated with the control logic implementing a PID closed linear control loop and communicating with the router over external network for controlling the in-building or in-vehicle phenomenon. The sensor may be a microphone or a camera, and the system may include voice or image processing as part of the control logic. A redundancy is used by using multiple sensors or actuators, or by using multiple data paths over the building or vehicle internal or external communication. The networks may be wired or wireless, and may be BAN, PAN, LAN, WAN, or home networks.

Owner:SMART SPEAKER LLC