

Patents
Literature
109 results about "Marine navigation" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Navigation is a field of study that focuses on the process of monitoring and controlling the movement of a craft or vehicle from one place to another. The field of navigation includes four general categories: land navigation, marine navigation, aeronautic navigation, and space navigation.
System and method to notify a person of a traveler's estimated time of arrival
InactiveUS20050114014A1Instruments for road network navigationRoad vehicles traffic controlTime of arrivalThird party
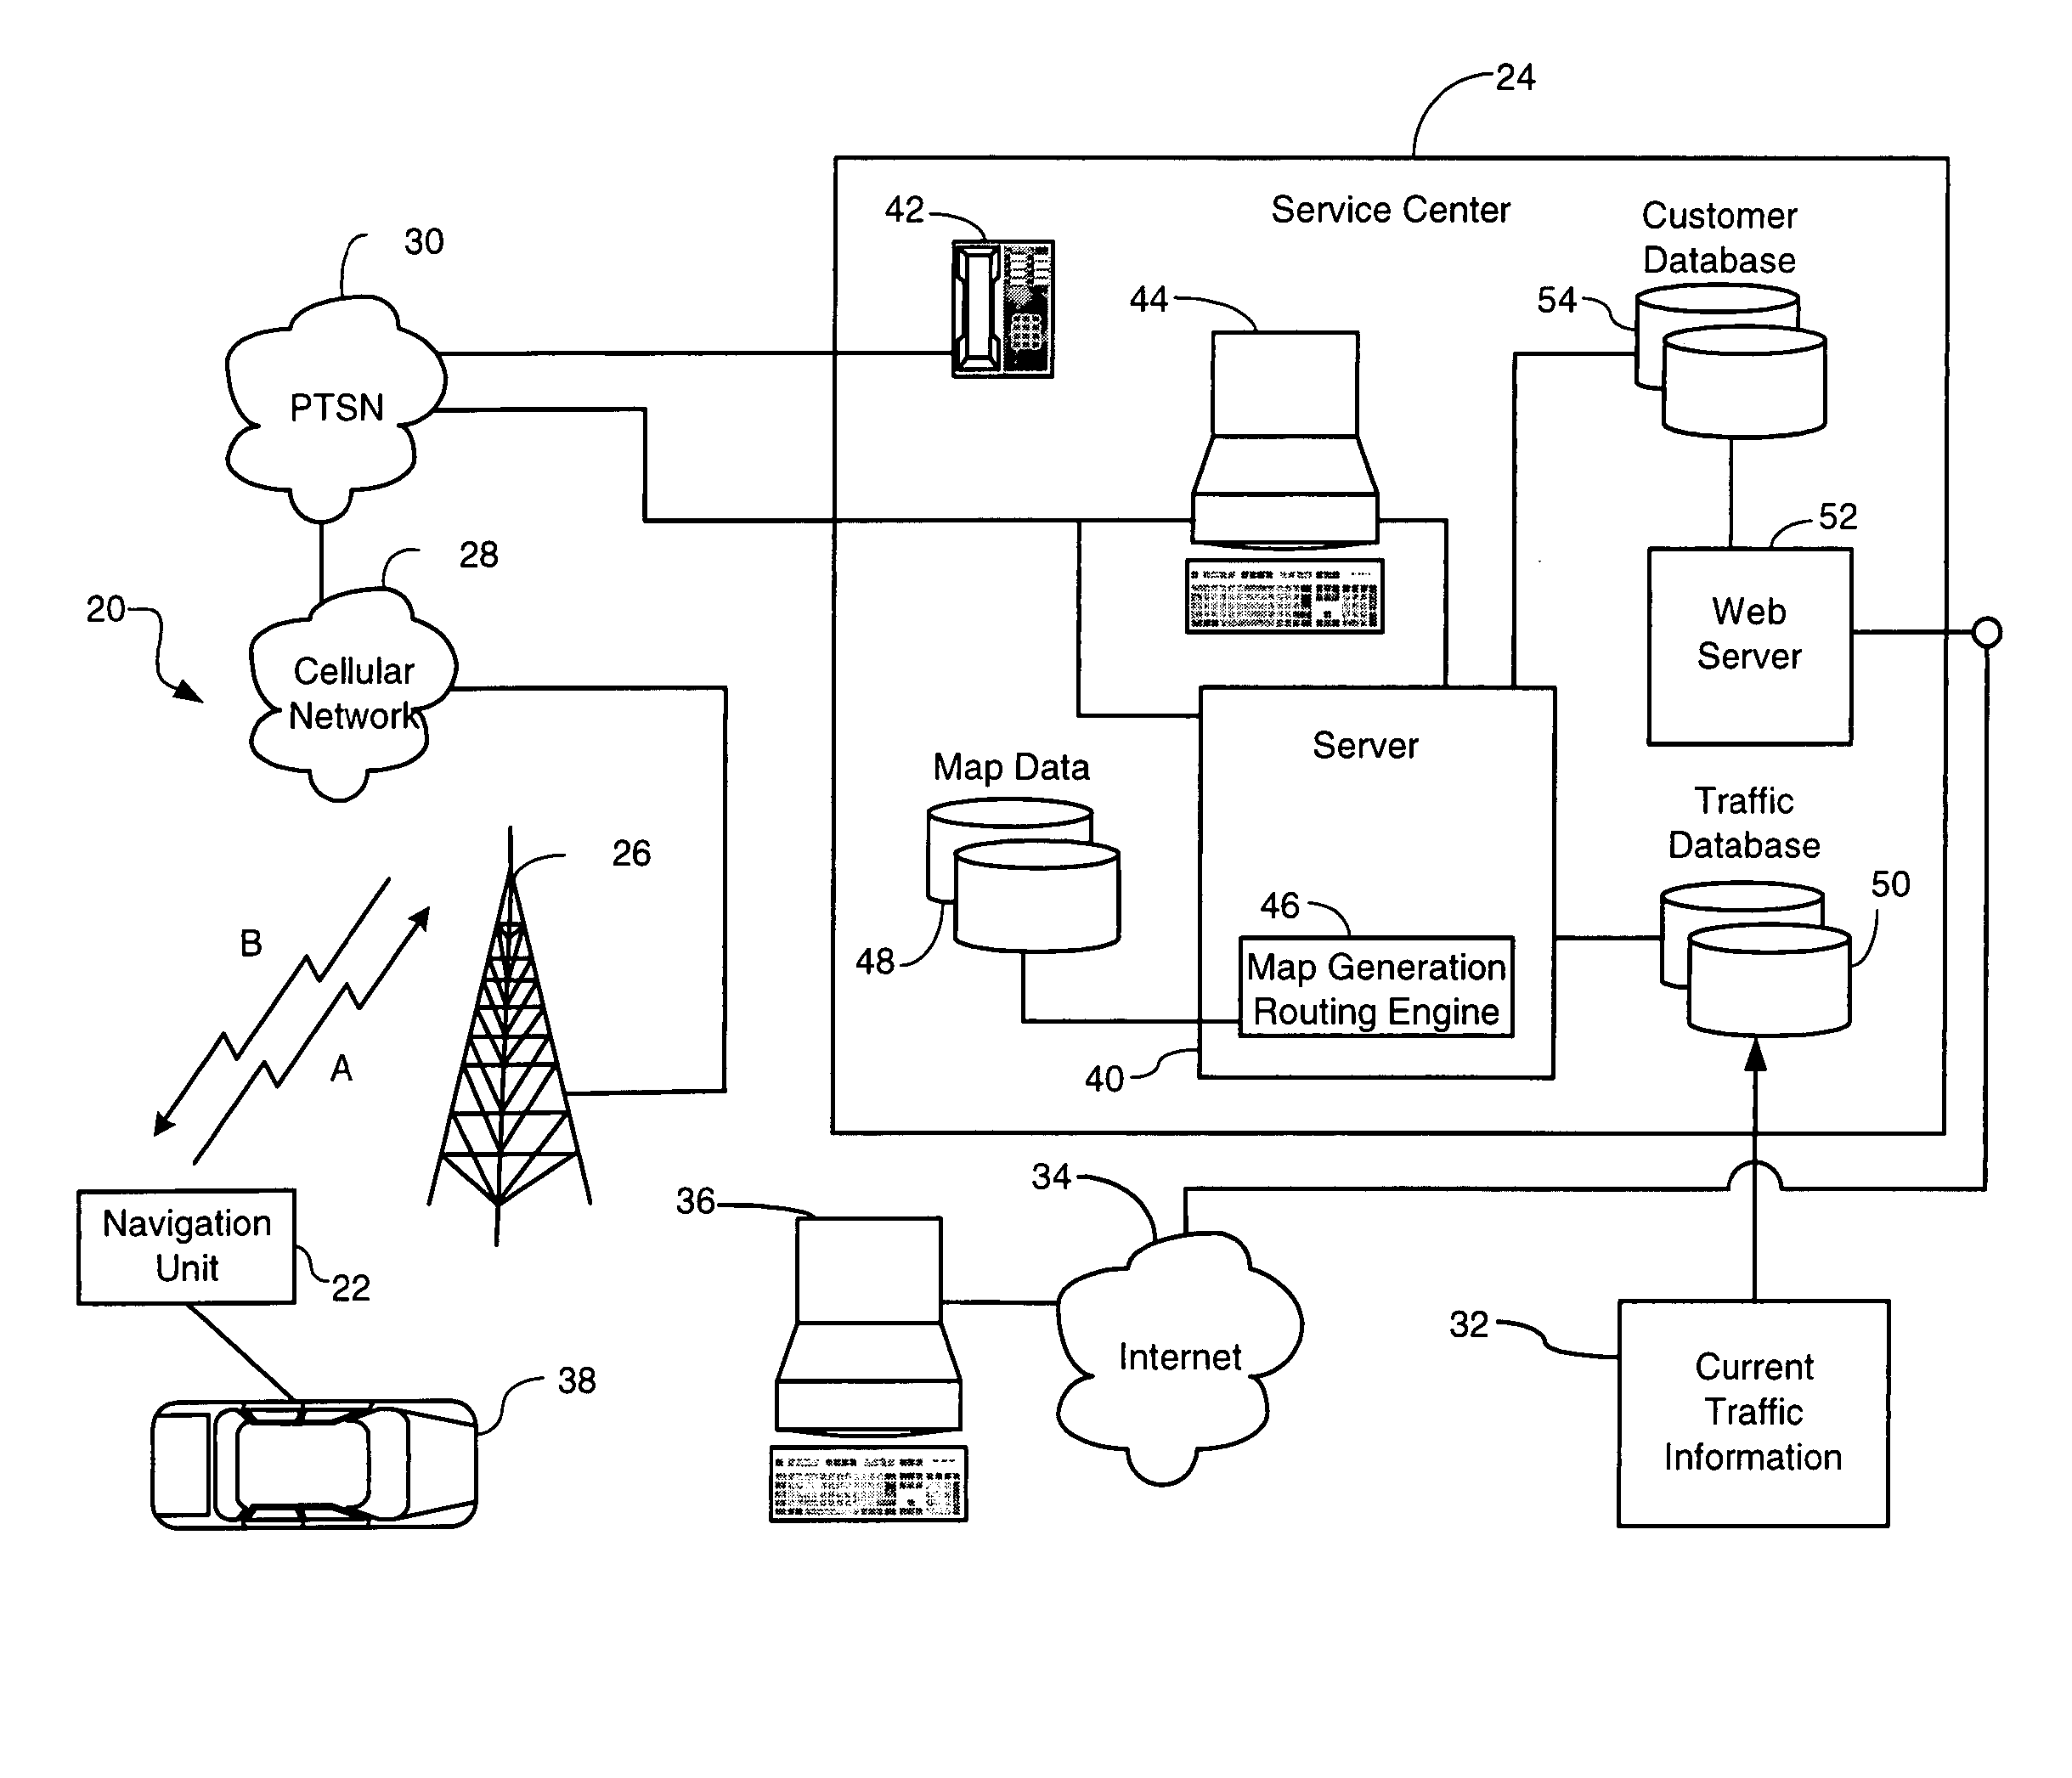
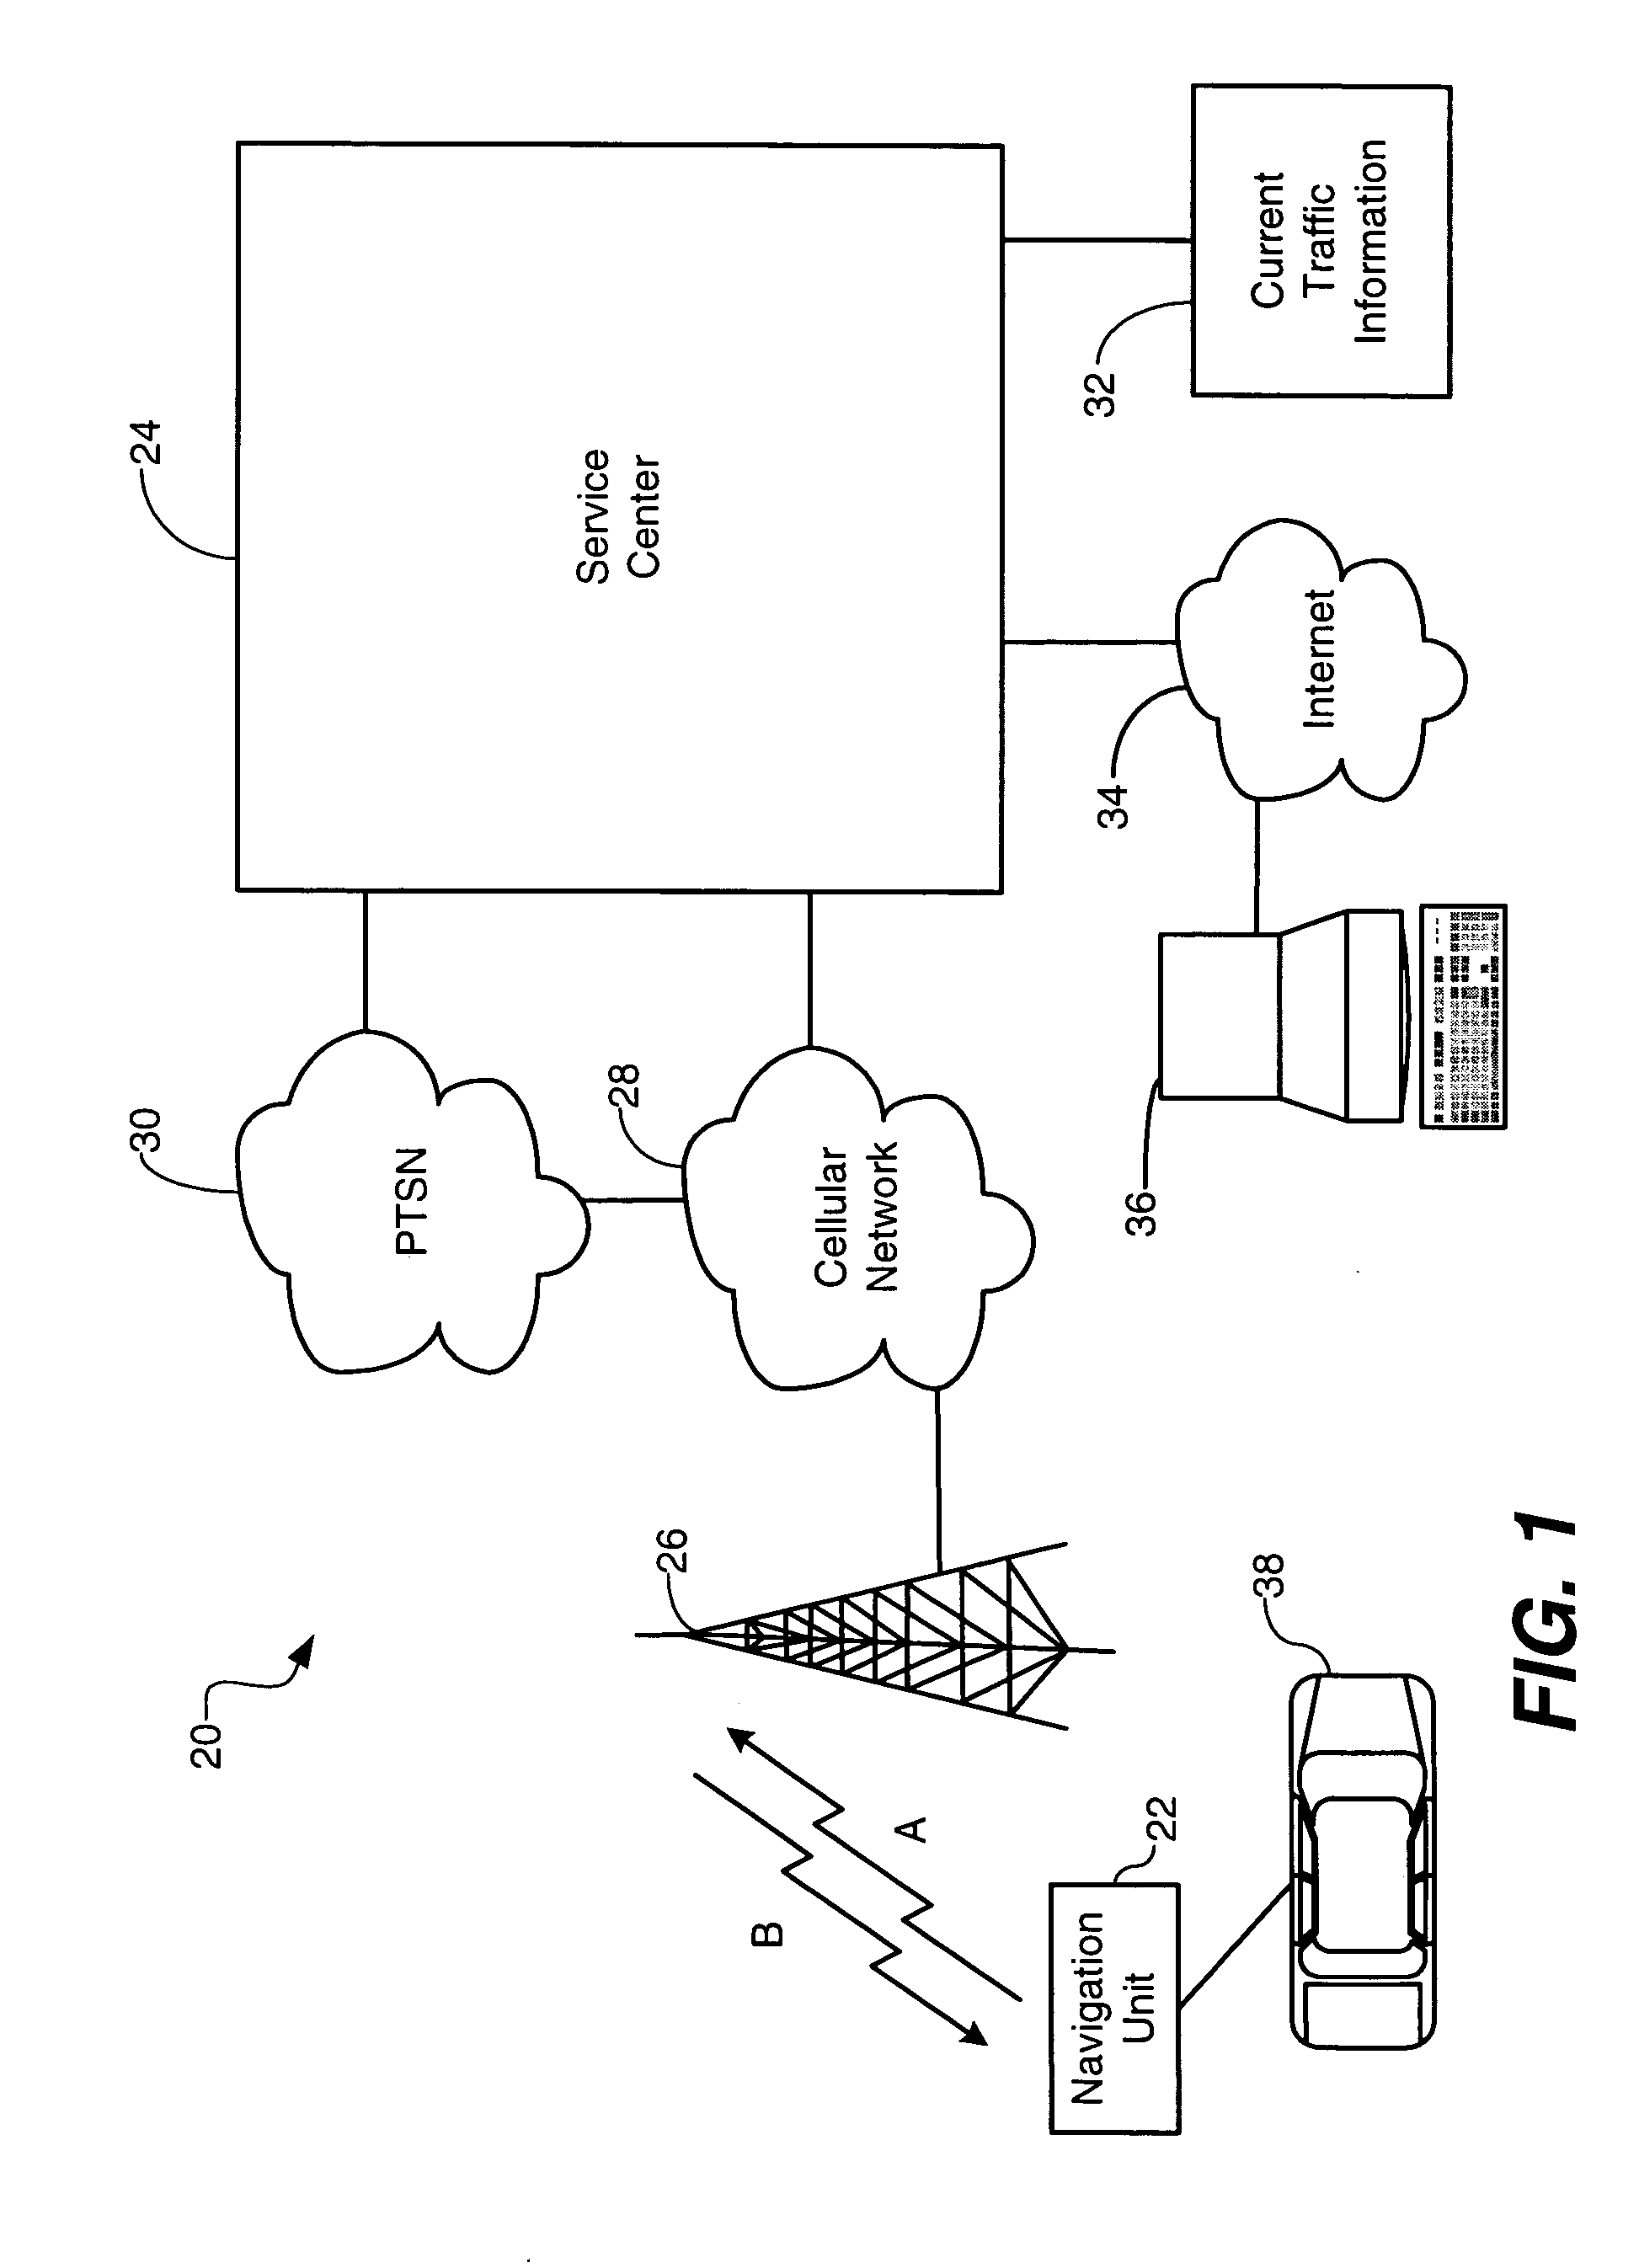
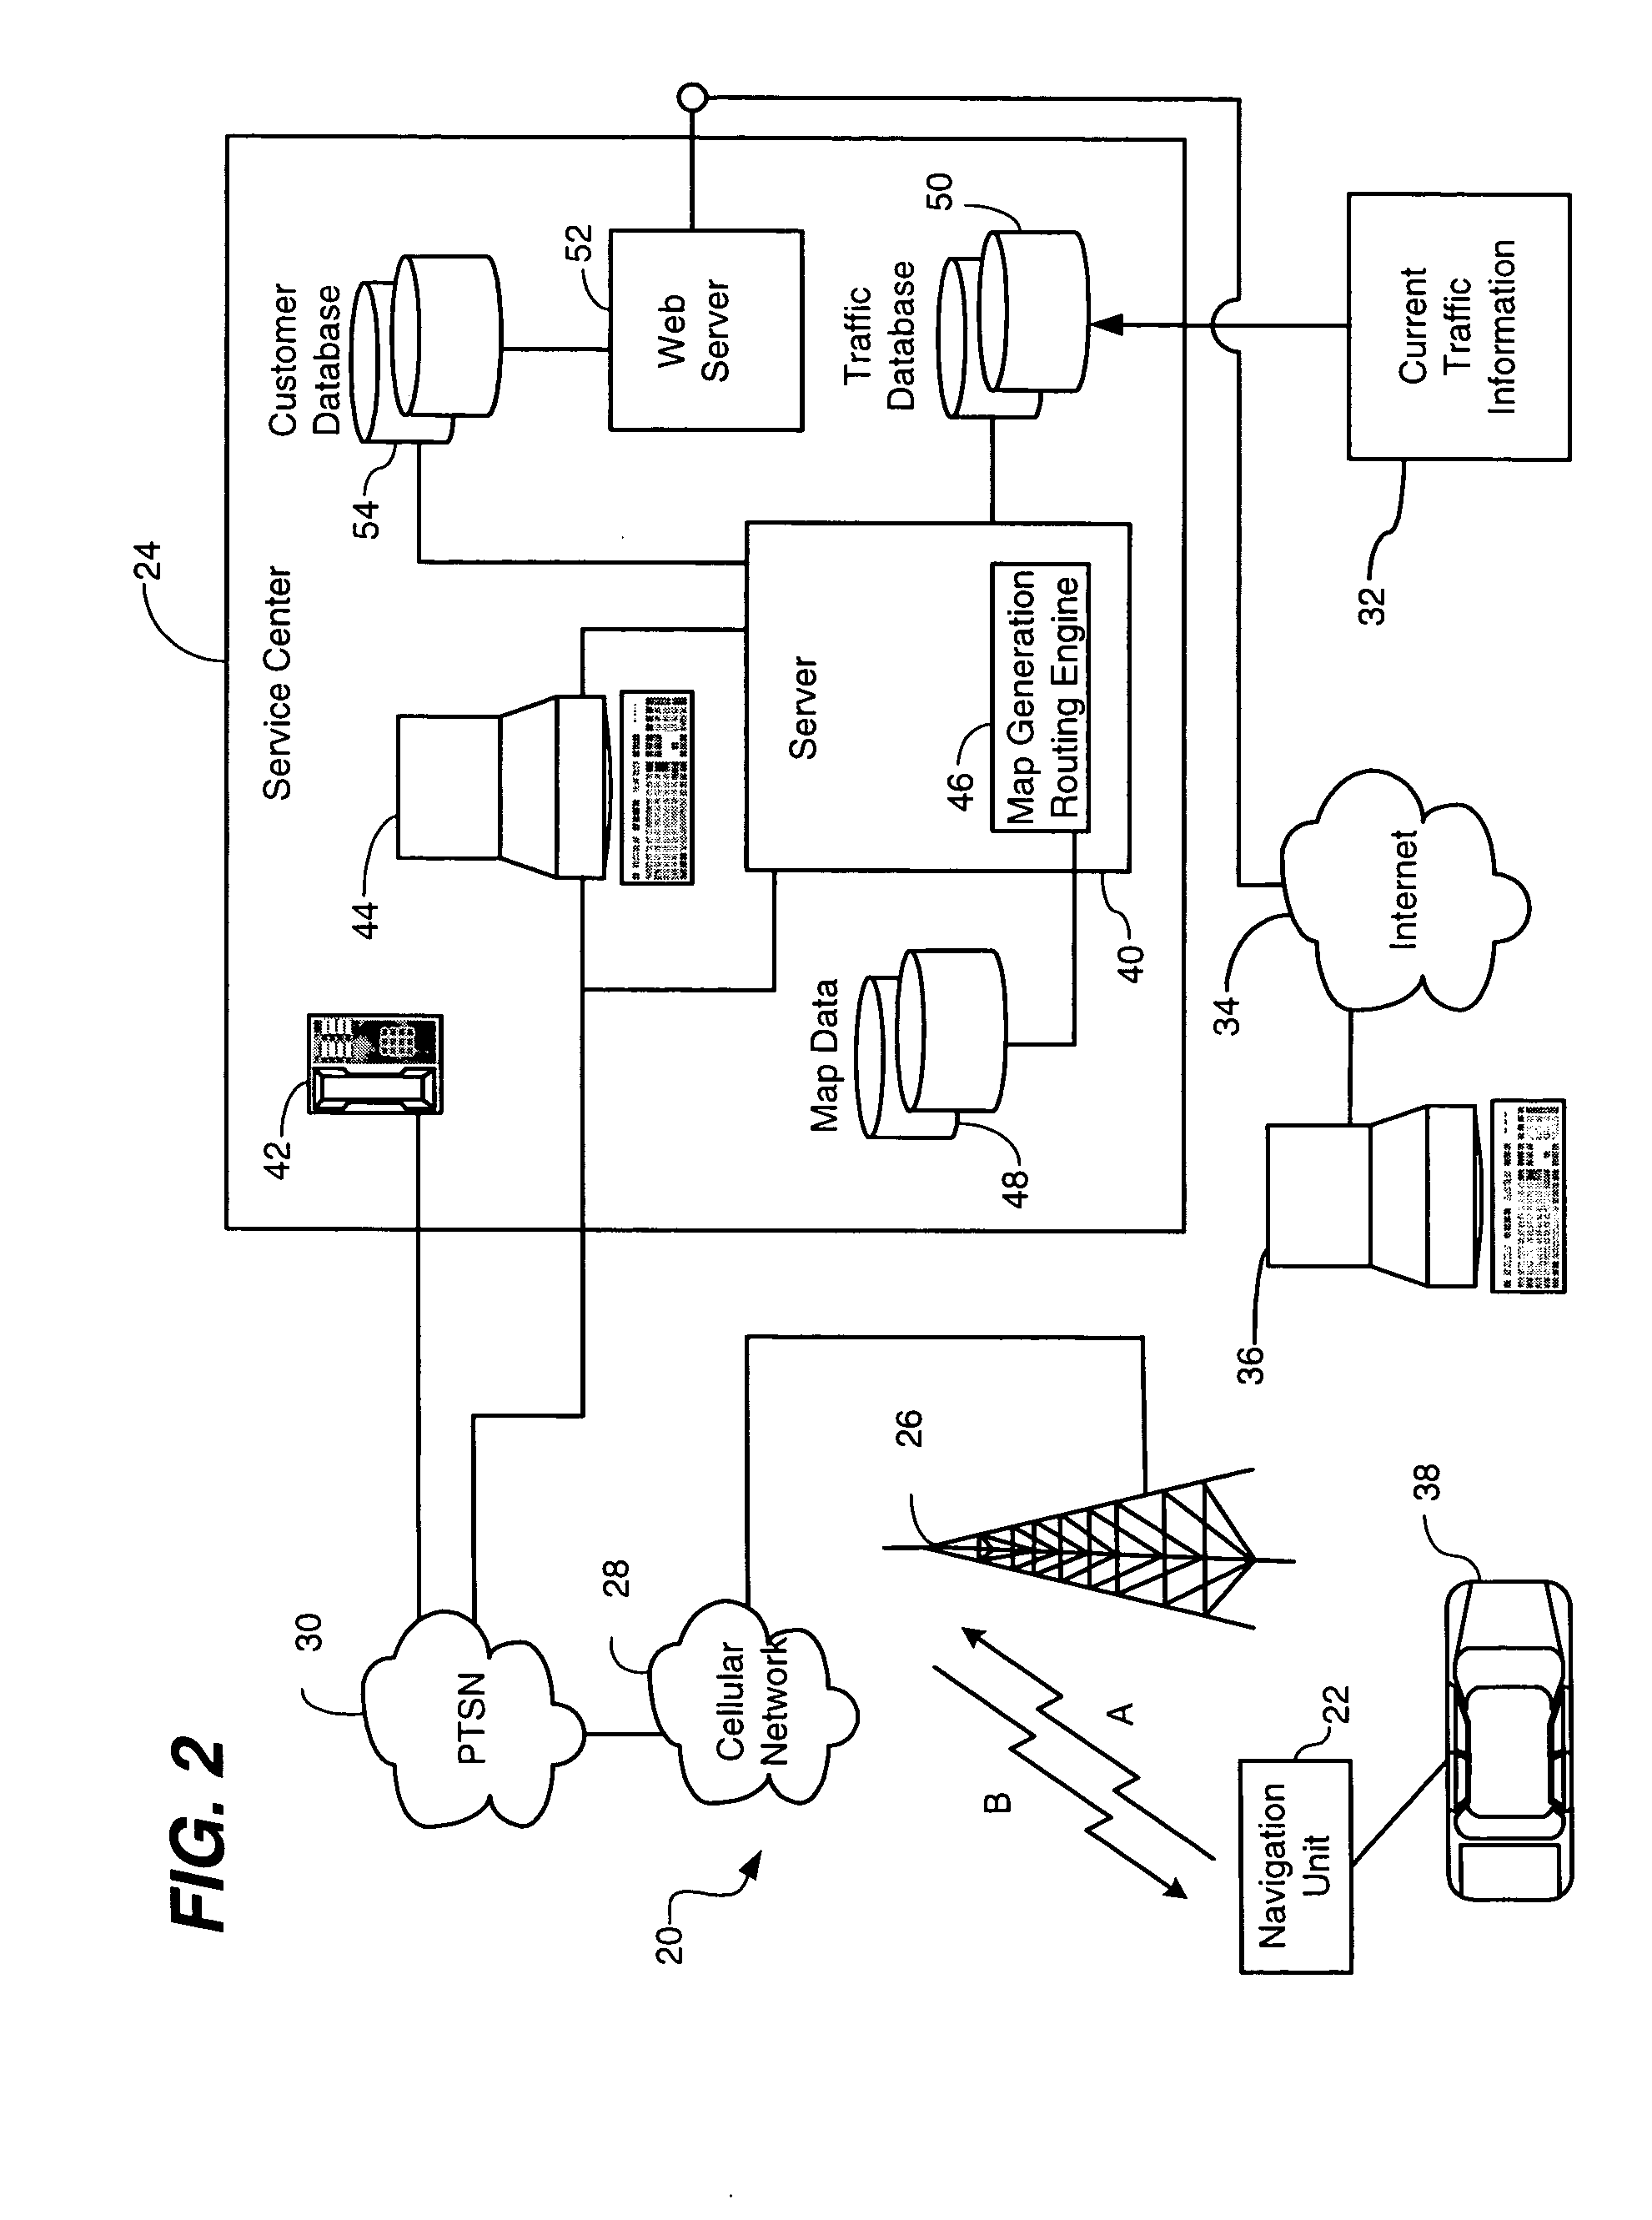
A system and method of calculating an estimated time of arrival for a traveler is provided, along with a notification of this estimated time that is sent to a third party. The traveler is equipped with a navigation unit having a global positioning sensor and a wireless communications device. The navigation unit communicates with a service center equipped with a server capable of generating a preferred navigational route for the traveler. The service center also includes a traffic database for maintaining current traffic information. Once the traveler has selected a predetermined time and frequency of notifications based upon a selected criterion, the navigation unit transmits the traveler's position and velocity to the service center. The service center then calculates the estimated time of arrival based upon the traveler's position, velocity, distance to be traveled and traffic and weather conditions. Once this time is calculated, the service center sends a notification to the third party.
Owner:MOTOROLA INC
Ship anti-collision early warning method based on multi-source heterogeneous information fusion
The invention discloses a ship anti-collision early warning method based on multi-source heterogeneous information fusion, and the method comprises the steps: S1, obtaining the multi-source target information of a ship navigation radar, an AIS, and an infrared camera, and unifying the targets of all sensors to a same coordinate system; s2, preprocessing the radar and the AIS target; s3, performing information fusion on the preprocessed radar and AIS target; s4, performing information fusion on the target after radar and AIS fusion and the infrared image recognition target; and S5, based on the dynamic information of the final fusion target and the state of the ship, calculating the relative distance and orientation with the ship, and when the target is located in a preset fan-shaped area right in front of the ship and the relative distance is smaller than a dynamic danger threshold value, triggering a multi-stage acousto-optic character alarm. According to the invention, various sensor information can be integrated to detect and track the water surface target, and the robustness and the detection rate are improved, so that a more accurate early warning effect can be achieved on the water surface obstacle when the ship sails.

Owner:THE 704TH RES INST OF CHINA STATE SHIPBUILDING CORP
High-precision combined attitude determination method based on multi-antenna GNSS and INS
PendingCN120576743ANavigational calculation instrumentsNavigation by speed/acceleration measurementsAlgorithmCarrier signal
The invention relates to a combined attitude determination technology, in particular to a high-precision combined attitude determination method based on a multi-antenna GNSS (Global Navigation Satellite System) and an INS (Inertial Navigation Satellite System), which comprises the following steps of: S1, fixing a GNSS receiver and the INS on a carrier; s2, calculating carrier position information and carrier speed information, and establishing a double-difference carrier phase observation model; s3, calculating a baseline vector predicted value between the antennas; s4, an LAMBDA algorithm model based on INS attitude information constraint is constructed; resolving the IC-LAMBDA algorithm model by using a least square method to obtain an optimal integer solution of the integer ambiguity; s5, calculating a baseline vector between the antennas; carrier attitude information is solved; and S6, fusing the GNSS navigation information and the INS navigation information by using an extended Kalman filter. The method solves the problems of low attitude measurement precision and poor scene adaptability of the existing integrated navigation technology, and is suitable for the fields of unmanned aerial vehicle control, unmanned vehicle driving, unmanned agricultural machinery seeding, marine navigation surveying and mapping and the like.

Owner:ZHONGBEI UNIV
Differential game theory-based formation dynamic interception path planning method and device
The invention relates to the field of intelligent control of marine navigation, and discloses a formation dynamic interception path planning method and device based on a differential game theory, and the method comprises the steps: constructing a differential game model comprising a formation and intercepted ships; designing revenue functions for the two parties; obtaining a Nash equilibrium strategy by solving a Hamiltonian-Jacobian-Bellman equation of the game, and solving an individual optimal control instruction of each formation member; and fusing state information among formation members through a consistency protocol, adjusting individual instructions to meet anti-collision and formation cooperative constraints, and generating a final control instruction. According to the method, historical adversarial data is learned by using the neural network, and the weight of the revenue function is adaptively and dynamically adjusted to cope with different tactical scenes; and the whole decision-making process is set under a model prediction control framework for rolling optimization, so that the real-time performance, the collaboration and the intelligent level of interception path planning are greatly improved, and the interception efficiency is effectively improved.

Owner:CHINA STATE SHIPBUILDING CORP NO 707 RES INST
A system and method for measuring real-time meteorological and oceanographic data using a buoyage network
PCT designated stage expiredWO2025115027A1BreakwatersWaterborne vesselsInternal memoryMooring system
The present invention provides a system for measuring real-time meteorological and oceanographic data using a buoyage network for smart ports and harbours. It consists of a moored floating station or moored buoy, or network of buoy-based measurement stations (A) moored at the port or harbour waters with the marine navigation and land-based measuring station (B) mounted at jetty or wharf or quay wall of port and harbours. The buoy-based system (A) is equipped with a cylindrical steel buoy structure featuring a mast (7) and is secured using a two-point mooring system. The present system comprises of an integrated monitoring and data transmission system that collects the real-time meteorological and oceanographic data from the sensors and processes the acquired data based on calibration, enabling accurate and reliable measurements. The processed data is then stored in the system's internal memory for analysis and transmitted to a remote-control station.

Owner:INDIAN INST OF TECH MADRAS
Marine navigation system
PendingUS20250044102A1Navigational calculation instrumentsNavigational aid arrangementsData controlMarine engineering
A marine navigation system for a marine vessel includes a positioning unit configured to detect a position of the marine vessel, a nautical chart database, a display being configured to present a view of a nautical chart information and a position of the marine vessel on the nautical chart, and a short range distance sensor module arranged on the marine vessel. The short range distance sensor module provides scanned data of a surrounding environment of the marine vessel. A control unit is operatively connected with the short range distance sensor module, the positioning unit, the nautical chart database and the display. The control unit processes the scanned data to provide a scanned view of the surrounding environment. The control unit is configured to present an augmented view of the nautical chart and scanned data on the display, and to indicate portions of the scanned data which does not match the nautical chart information in the augmented view.

Owner:VOLVO PENTA AB
Marine photovoltaic marine navigation monitoring system
PendingCN119863949AMarine craft traffic controlClosed circuit television systemsVideo monitoringRadar systems
The invention provides a maritime photovoltaic maritime navigation monitoring system, and relates to the technical field of maritime safety monitoring. The maritime photovoltaic maritime navigation monitoring system comprises a radar system, a video monitoring system, a ship automatic identification system, an electronic fence system, a very high frequency communication system, a hydro meteorology acquisition system, an acoustic optical driver isolation system and a processing device, the processing equipment is used for respectively acquiring first navigation data of the target ship detected based on the radar system, second navigation data of the target ship detected based on the video monitoring system and third navigation data of the target ship detected based on the ship automatic identification system; and fusing the first navigation data, the second navigation data and the third navigation data to determine target navigation data of the target ship. According to the invention, the comprehensiveness and accuracy of offshore safety monitoring can be improved.

Owner:NORTHWEST ENGINEERING CORPORATION LIMITED
Marine navigation event processing scheme recommendation method and system based on prediction intention
InactiveCN119475120AImprove predictive performanceReduce the burden onMathematical modelsKernel methodsMaritime navigationEngineering
The invention discloses a prediction intention-based marine navigation event processing scheme recommendation method and system, and the method comprises the steps: firstly building an intention prediction model based on a machine learning method, and obtaining the prediction intention of a ship through the intention prediction model according to the historical marine navigation data of the ship; according to the matching relation between intentions and events, the events corresponding to the prediction intentions are recognized, and the events are abnormal marine navigation events; and finally, calculating the similarity between the event and the historical event, and selecting the processing scheme corresponding to the historical event with the highest similarity for recommendation. The method can be widely applied to multiple scenes such as maritime supervision, port management and maritime search and rescue, and greatly improves the shipping safety and management efficiency.

Owner:THE 28TH RES INST OF CHINA ELECTRONICS TECH GROUP CORP
Marine navigation mark intelligent maintenance robot based on ship and self-adaptive operation method thereof
The invention discloses a marine navigation mark intelligent maintenance robot based on a ship and a self-adaptive operation method of the marine navigation mark intelligent maintenance robot, and belongs to the field of marine navigation mark maintenance. The marine navigation mark intelligent maintenance robot based on the ship comprises a base and a second telescopic arm, and further comprises a rotating disc rotationally connected to the end of the second telescopic arm, a driving motor is fixedly connected to the rotating disc, the output end of the driving motor is fixedly connected with a rotating shaft, and a rotating mechanism is arranged between the second telescopic arm and the rotating shaft; the second telescopic arm is used for driving the rotating disc to rotate; the sliding rails are evenly and fixedly connected to the rotating disc, clamping claws are arranged on the sides, away from the second telescopic arm, of the sliding rails, and a clamping mechanism is arranged between the sliding rails and the rotating shaft and used for driving the clamping claws to move along the sliding rails; the detection probe is fixedly connected to the turntable and is used for detecting the appearance of the beacon light and the position of the fixing bolt; the problems that when equipment on the buoy is maintained, potential safety hazards are large, the maintenance efficiency is low, and the maintenance difficulty is large can be solved.

Owner:XIAMEN NAVIGATION MARK OFFICE EAST CHINA SEA NAVIGATION SUPPORT CENT MINISTRY OF TRANSPORT
Optical fiber compass and magnetic compass integrated calibration method
PendingCN119469094AImprove reliabilityHigh precisionWater resource assessmentCompassesEngineeringMarine navigation
The invention relates to the field of marine navigation, in particular to an optical fiber compass and magnetic compass integrated calibration method, which comprises the following steps of: compensating a magnetic compass by using an optical fiber compass, and constraining course output of the optical fiber compass by using the magnetic compass as an observed quantity. According to the optical fiber compass and magnetic compass integrated calibration method provided by the invention, the working characteristics of the optical fiber compass and the magnetic compass are combined, so that the optical fiber compass and the magnetic compass are mutually complemented and mutually calibrated, the system reliability is improved, and the system precision can be improved through data fusion.

Owner:CSSC MARINE TECH CO LTD
Enteromorpha identification and density estimation method and system based on air-sea cooperation
The invention belongs to the technical field of marine environment monitoring, and particularly relates to an air-sea cooperation-based enteromorpha identification and density estimation method and system, and the method comprises the steps: carrying out the aerial survey of a target sea area through an unmanned plane, collecting a sequence image, processing the sequence image based on a deep learning model, and generating an enteromorpha distribution probability graph and a density estimation graph; carrying out marine navigation and fixed-point sampling through an acoustic sensor carried by an unmanned ship to obtain actually measured density data of enteromorpha; the unmanned aerial vehicle sends the generated enteromorpha distribution probability graph and / or density estimation graph to the unmanned ship, the unmanned ship receives the enteromorpha distribution probability graph and / or density estimation graph, plans a navigation path and sampling points according to the enteromorpha distribution probability graph and / or density estimation graph, and goes to a high-probability or high-uncertainty area for fixed-point sampling; and the unmanned aerial vehicle receives actually measured density data returned by the unmanned ship and fuses the actually measured density data with own identification and estimation results so as to update and optimize the deep learning model and form an air-sea collaborative monitoring closed loop.

Owner:QILU UNIVERSITY OF TECHNOLOGY (SHANDONG ACADEMY OF SCIENCES)
Attention-BiLSTM-based ship track prediction method
PendingCN119669797AHigh filling accuracyAchieving Precise ForecastingNavigational calculation instrumentsBiological modelsFeature vectorMaritime navigation
The invention discloses a ship track prediction method based on Attention-BiLSTM, and relates to the technical field of ship track prediction. The method comprises the following steps: acquiring ship AIS data, weather data and date attribute data; carrying out abnormal data detection and elimination on the ship track data, and filling missing data after elimination; establishing a ship track feature input candidate set, selecting a feature input variable influencing the ship track, determining a delay order between the ship track and the feature input variable, and constructing a feature vector; dividing the feature vector into a limited number of sub-model action ranges, and performing boundary division and boundary estimation; and establishing a ship track prediction model for each sub-model action range, and realizing rolling prediction of the ship track through the ship track prediction model. Accurate high-quality data and reasonable action range division are provided for ship track prediction, the ship track prediction precision is guaranteed, and the purposes of ship reasonable path planning, resource optimization scheduling and marine navigation safety improvement are achieved.

Owner:THE 54TH RESEARCH INSTITUTE OF CHINA ELECTRONICS TECHNOLOGY GROUP CORPORATION
Ship-borne satellite communication blind area self-adaptive optimization system
The self-adaptive dynamic optimization system comprises a plurality of key modules, a signal acquisition and monitoring module receives signals through a multi-band antenna, acquires ship and environment data and then transmits the ship and environment data to an analysis and decision module, and the analysis and decision module judges the condition of a blind area through an intelligent algorithm, formulates a strategy and issues an instruction; the antenna adaptive adjustment unit regulates and controls antenna parameters and detects and corrects when encountering obstacles; the communication link intelligent switching unit ensures stable switching of links; the data dynamic optimization processing module optimizes transmission; the power management and energy-saving module performs intelligent power management; and the man-machine interaction and early warning module realizes information interaction and storage. The problem of a ship-borne communication blind area is solved, the system stability is enhanced, the energy efficiency is improved, and marine navigation, operation and scheduling are guaranteed.

Owner:DITAI (ZHEJIANG) COMM TECH CO LTD
Multi-sensor integrated marine navigation mark data transmission method and system
The invention provides a multi-sensor integrated marine navigation mark data transmission method and system, and relates to the technical field of data transmission, and the method comprises the steps: pre-arranging a plurality of distributed monitoring nodes in a marine navigation mark data collection box, and carrying out the cascade topology connection with a plurality of marine environment modal sensors through an isolated serial bus; in a polling return process of mapping acquired data by taking a plurality of reference return periods as constraints, performing return data chaos monitoring based on a plurality of dynamic self-adaptive baselines, and outputting a plurality of spectrum disturbance vectors; performing shrinkage compensation to obtain a plurality of update return periods; and executing asynchronous priority arbitration return to the remote Internet of Things service platform. According to the method, the technical problem that the confidence coefficient of the marine navigation mark data is reduced due to the fact that the marine navigation mark data transmission method in the prior art usually uses a fixed return period and cannot effectively cope with the dynamic change of the marine environment is solved.

Owner:GUANGDONG LANKUN MARINE TECH CO LTD
Real-time health monitoring method for inertial device of modulation type inertial measurement unit
The invention belongs to the technical field of inertial navigation, discloses a real-time monitoring method for the health state of an inertial device of a modulation type inertial measurement unit, and is suitable for application scenes such as aviation navigation and marine navigation. The relative output information of the two inertial navigation systems is cooperatively used to construct constraint observation, a joint error state adaptive filter is established as a state monitoring filter, a real-time state monitoring criterion is established based on the estimated output of the filter, a diagnosis threshold is determined, health state monitoring is performed, and the method has a wide application prospect. Meanwhile, an azimuth gyroscope drift variation fitting method is provided to monitor the abnormal state of the azimuth gyroscope. The inertial device health state monitoring method provided by the invention does not need the assistance of accurate reference information, and provides reliable guarantee for the safety and reliability of long-endurance navigation in a GNSS denial environment.

Owner:NAT UNIV OF DEFENSE TECH
Marine diesel engine interactive intelligent agent device based on large and small model collaboration and temporary repair method
The embodiment of the invention provides a marine diesel engine interactive intelligent agent device based on cooperation of large and small models and a temporary first-aid repair method, and aims to solve the problems of rapid diagnosis, emergency decision and first-aid repair guidance when a marine diesel engine breaks down suddenly. The device comprises a large language model serving as a core and responsible for task decomposition, decision generation and information integration; the professional small model carries out optimization analysis on tasks such as fault positioning, emergency decision making, spare part replacement and time prediction; the interactive agent core module supports voice and text input and provides real-time feedback; the multi-modal data real-time fusion module integrates various data sources and dynamically allocates weights; and the knowledge graph and inference engine module provides accurate first-aid repair guidance. The large language model is innovatively taken as a core to be deeply cooperated with a plurality of professional small models, so that the rapid diagnosis, emergency decision and temporary repair guidance of sudden faults of the marine diesel engine in the marine navigation process are realized, and the blank of the intelligent temporary repair technology of the marine diesel engine is filled.

Owner:THE 711TH RES INST OF CHINA STATE SHIPBUILDING CORP
Solar vector orientation method, device and computer equipment based on heat-sensitive vision
The present application relates to the technical field of photoelectric detection and navigation, and discloses a solar vector orientation method, device and computer equipment based on thermal sensitive vision, to solve the problem of signal attenuation and low reliability of existing visible light or polarized light solar detection technology under complex weather. The method comprises: acquiring a thermal infrared image of a sky area by using a near-infrared thermal sensitive vision sensor; performing image preprocessing to enhance the solar target information; detecting and segmenting the solar target area in the image, and accurately positioning the solar center coordinates by using a centroid estimation or ellipse fitting method; converting the image coordinates into the solar position observation vector in the carrier coordinate system of the bearing sensor according to the sensor calibration parameters and installation parameters; and combining the theoretical solar vector calculated by an astronomical algorithm to solve the orientation information of the carrier. The present application is suitable for complex lighting conditions, has the advantages of strong anti-interference and high precision, and can be used for attitude determination in aerospace and marine navigation.

Owner:NAT UNIV OF DEFENSE TECH
Marine navigation signal lamp control panel
ActiveCN223652486UCasings/cabinets/drawers detailsEnergy saving control techniquesControl theoryMechanical engineering
The utility model relates to the technical field of control panels, and discloses a marine navigation signal lamp control panel which comprises a control panel, square plates are fixedly connected to the left side and the right side of the top end of the control panel, Y-shaped grooves are formed in the middles of the square plates, motors are fixedly connected to the outer walls of the square plates, and the output ends of the motors are rotationally connected with rotating frames. One end of the rotating frame is fixedly connected with a polygonal block, the outer wall of the polygonal block is fixedly connected with a connecting rod, the top end of the polygonal block is fixedly connected with a fixing plate, and the outer wall of the polygonal block is fixedly connected with a clamping column. A square plate at the top end of the console is provided with a Y-shaped groove, a motor drives a rotating frame to rotate, a clamping column on the outer wall of a multilateral block at one end of the rotating frame is clamped with the Y-shaped groove, the multilateral block is connected through a connecting rod, a fixing plate is arranged at the top end of the multilateral block, and due to the shape of the Y-shaped groove, the multilateral block drives the fixing plate to ascend and then turn over, so that a waterproof cover is automatically opened; and normal waterproof performance of the control panel is ensured.

Owner:ANYANG ANGJIA ELECTRIC APPLIANCE CO LTD
Method for evaluating energy-saving effect of energy-saving device in waves
ActiveCN119429021Aaccurate assessmenteffective evaluationWaterborne vesselsMarine engineeringEconomic benefits
The invention discloses a method for evaluating the energy-saving effect of an energy-saving device in waves, test evaluation is performed through a ship model and the energy-saving device, the ship model is equipped with a self-propulsion power system, and a self-propulsion method in waves commonly adopted at present is replaced by a load self-propulsion method in still water, so that the energy-saving effect of the energy-saving device in the waves is evaluated. The method solves the problems of high uncertainty, high test cost and the like when a self-propulsion model test is directly carried out in waves at present, and achieves more accurate and efficient evaluation of the energy-saving effect of the energy-saving device in the waves under the condition of more controllable test conditions through a load self-propulsion method. According to the method, the energy-saving effect of the energy-saving device under the real marine navigation condition can be reflected, the energy-saving device can play the best effect under different marine conditions through design optimization, the ship can meet the strict requirements of environmental protection laws and regulations, the fuel cost in the operation cost can be remarkably reduced, and the energy-saving effect of the energy-saving device is improved. And long-term economic benefits are brought to ship owners.

Owner:RES INST 708 OF CHINA STATE SHIPBUILDING CORP
Ship navigation system based on compass direction finding and satellite fusion
The present application relates to the field of marine navigation technology of ship, specifically relates to a ship marine navigation system based on compass direction finding and satellite fusion, comprising a data acquisition module, a disturbance correlation analysis module, a pseudo course determination module, a navigation credibility evaluation module, a dynamic fusion weight adjustment module and a stable heading output module;Through collecting the compass heading data, satellite positioning data and ship body attitude data of the target ship, the correlation between the heading change and the roll disturbance is analyzed, and the pseudo heading change caused by the sea state disturbance is identified in combination with the track change state;Based on the disturbance correlation result, the credibility of the compass navigation and satellite navigation is dynamically evaluated, and the fusion weight of different navigation data is adaptively adjusted to generate stable heading information, which is beneficial to reduce the influence of ship body attitude disturbance on the heading measurement result under complex sea state conditions, and improve the continuous stability and navigation reliability of ship heading navigation.

Owner:ZHEJIANG HAIYAN TECHNOLOGY CO LTD
Wind power detection alarm device for ship navigation
ActiveCN224163688USpeed/acceleration/shock instrument detailsAlarmsMarine engineeringMechanical engineering
The utility model discloses a wind power detection alarm device for ship navigation, which relates to the technical field of ship navigation and comprises a bottom table, a boss mounted at the upper end of the bottom table, a support column rotatably connected to the boss, a three-color audible and visual alarm mounted on the boss, a circular truncated cone mounted on a support rod of the three-color audible and visual alarm, and a support table mounted on the circular truncated cone. A wind cup type wind speed sensor is installed on the supporting table, a ring block is arranged on the bottom side of the circular truncated cone, the supporting column is rotationally matched with the ring block, and a wind direction plate is installed on one side of the supporting column. The problem that in the prior art, the supporting column of the warning device is bent by strong wind is solved, the supporting column is driven by the wind direction plate to rotate around the boss and the ring block, the smooth face of the supporting plate is parallel to the wind direction, it is guaranteed that the strong wind is not vertically blown to the arc-shaped face of the supporting plate, and the impact force of airflow is weakened; when airflow flows through the supporting plates, lift force from inside to outside can be generated and is counteracted by atmospheric pressure, and deformation of the supporting plates is avoided.

Owner:WEIHAI OCEAN VOCATIONAL COLLEGE
A test device for an outboard motor
This invention provides a testing device for outboard motors, belonging to the field of outboard motor testing technology. It includes a simulation component and an outer water tank. The simulation component is located inside the outer water tank, and the outboard motor can be installed inside the simulation component. The simulation component can test the outboard motor. This invention uses a simulation component to fix the outboard motor on a clamping platform and injects liquid water suitable for the working water depth into the inner water tank. Simultaneously, sea salt is supplied as needed to adjust the salinity of the liquid water. Then, a first deflection mechanism drives the outboard motor, causing it to deflect back and forth along an arc-shaped positioning guide rail. A worm gear assembly drives the outboard motor to sway left and right, and a damping slide achieves lateral displacement. The salinity in the inner water tank is maintained, stably simulating the marine navigation environment and forming a multi-dimensional composite swaying scenario. This enables accurate testing of the outboard motor under all operating conditions, reducing the data distortion problems caused by single swaying and freshwater testing in traditional devices.

Owner:NINGBO JINYAO MACHINERY
Interactive collaborative navigation decision-making method and device, electronic equipment and storage medium
PendingCN119323901AEnsure navigation safetyMarine craft traffic controlInference methodsVisual interpretationGraph generation
The invention discloses an interactive collaborative navigation decision-making method and device, electronic equipment and a storage medium, and belongs to the technical field of marine navigation, and the method comprises the steps: determining a navigation decision-making scheme according to real-time target navigation data; generating a visual interpretation graph according to the decision scheme, the visual interpretation graph comprising a decision behavior graph generated according to the decision opportunity and decision behavior of the decision scheme, a navigation risk evolution graph generated according to the navigation risk of the decision scheme, and a feature contribution graph generated according to the correlation between the data features of the decision scheme and the decision scheme; a feature importance index graph is generated according to the feature contribution degree graph, and an inter-feature dependency degree graph is generated according to a non-linear relationship between the decision scheme features; and based on the visual interpretation graph, performing man-machine interaction cooperative judgment on the decision scheme, adjusting the decision scheme, and generating a final decision scheme. According to the method, the visual interpretation graph is generated according to the decision scheme, and the decision scheme and the visual interpretation graph are interactively and cooperatively judged and determined to determine the navigation decision.

Owner:WUHAN UNIV OF TECH
A real-time health monitoring method for inertial devices of a modulated inertial measurement unit
The present application belongs to the technical field of inertial navigation, and discloses a kind of modulation type inertial measurement unit's inertial device health state real-time monitoring method, suitable for aviation navigation, marine navigation and other application scenarios.The present application cooperates with the relative output information of two sets of inertial navigation system to construct constraint observation, establishes a joint error state adaptive filter as a state monitoring filter, establishes a real-time state monitoring criterion based on the estimated output of the filter, clearly defines the diagnostic threshold and performs health state monitoring, and proposes a bearing gyro drift change quantity fitting method to realize abnormal state monitoring of the bearing gyro.The inertial device health state monitoring method proposed by the present application does not require accurate reference information assistance, providing a reliable guarantee for the safety and reliability of long-time navigation in GNSS denial environment.

Owner:NAT UNIV OF DEFENSE TECH
Method for detecting offshore wind driven generator by maritime radar
The invention discloses a method for detecting an offshore wind driven generator by a maritime radar, which comprises the following steps of: 1, starting the maritime radar and preheating the maritime radar, and starting scanning by an antenna; 2, during antenna scanning, recording N pulse echo powers of a given distance gate in a certain direction in a coherence interval; 3, periodically detecting and analyzing non-stationary signals of the time sequence; 4, obtaining a periodic index through the periodic detection analysis in the step 3; 5, the periodic indexes are judged; 6, when the periodic index is larger than or equal to a preset threshold value, the target in the specific distance door is judged to be the offshore wind turbine; according to the method, the power time sequence data is acquired through the single and multiple scanning speed modes of the antenna, the characteristic indexes are comprehensively extracted in combination with multiple periodic detection algorithms, the wind driven generator target can be accurately identified, and the method has the characteristics of improving the detection accuracy, reducing the radar false alarm rate, guaranteeing the marine navigation safety and being wide in applicability.

Owner:JIMEI UNIV
Marine navigation radar
The utility model discloses a marine navigation radar, which comprises a navigation radar, a plurality of matching blocks are fixed on the navigation radar, each matching block is hinged and installed on a support assembly, each support assembly is hinged and installed on a connecting block, each connecting block is arranged on a placing frame, and the placing frame is arranged on the support. And a driving adjusting assembly is fixed on the placement frame, so that the height of the navigation radar can be adjusted conveniently, and the detection range of the navigation radar is widened.

Owner:WUXI GREAT SCI-TECH CO LTD
Marine propulsion control systems and methods with buffer zone adaptation
A propulsion control system includes at least one marine drive configured to propel the marine vessel, a proximity sensor system configured to measure proximity of objects in a marine navigation area around the marine vessel to generate proximity measurements, and a control system. The control system is configured detect that an extendable element on the marine vessel is in an extended position, define an extended buffer zone around the marine vessel based on the extended position of the extendable element, and control the at least one marine drive based on the proximity measurements and the buffer zone so as to avoid the objects in the marine navigation area entering the extended buffer zone.

Owner:BRUNSWICK CORP
Duckweed assembly
The utility model mainly provides a duckweed assembly which comprises a cabin body, a duckweed assembly and a balance weight piece, the duckweed assembly is movably connected with the peripheral side of the cabin body, and the balance weight piece is connected with the bottom of the cabin body; the navigation aiding assembly is arranged on the top of the cabin body. The duckweed assembly can well help the marine navigation aid mark to resist storm waves so as to keep stability.

Owner:RENMIN UNIVERSITY OF CHINA
Marine environment prediction method based on principal component analysis-converter fusion model
InactiveCN119940123ADesign optimisation/simulationICT adaptationData setPrincipal component analysis
The invention discloses a marine environment element prediction method based on a principal component analysis-converter fusion model. The method comprises the following steps: performing quality control and data cleaning on a marine environment element data set to realize time-space dimension unification of heterogeneous data; building a prediction model on the basis of a converter network, taking day-by-day data after quality control and data cleaning as a target variable of the model, performing dynamics mechanism analysis based on an observation time sequence of the target variable, and selecting a dynamics prediction factor; dimensionality reduction processing is carried out on the high-dimensional forecasting factors through principal component analysis, and key feature information is effectively extracted; and inputting the optimized features into a converter network for modeling prediction. Compared with a traditional converter model, the average prediction relative error of the fusion model provided by the invention is reduced by 30%, and the prediction precision is remarkably improved. According to the invention, a new thought is provided for improving the marine environment element prediction precision through deep fusion, and more reliable decision support can be provided for the fields of marine navigation safety and the like.

Owner:TIANJIN UNIV
Marine navigation equipment
ActiveCN222157764Uavoid moving locationGuaranteed tightnessNavigational aid arrangementsNavigation instrumentsBraced frameMarine engineering
The utility model relates to the technical field of navigation equipment, and discloses marine navigation equipment, which comprises an equipment main body, a functional part arranged on the surface of the equipment main body, a protection assembly arranged on the surface of the equipment main body, a supporting frame, a touch display screen fixedly connected to the front surface of the supporting frame, and a sliding groove formed in the bottom of the supporting frame, fixing devices are slidably connected to the inner walls of the sliding grooves, and springs are fixedly connected to the bottoms of the fixing devices. The spring can be deformed by pulling the two fixers, the telescopic rod can stretch out and draw back through extension of the spring, the distance between the two fixers can be increased through changes of the spring and the telescopic rod, the two fixers can be fixed at proper positions at the moment, and the device can be fixed at the moment. And the device is prevented from moving, so that the device can move at any time.

Owner:NAVAL UNIV OF ENG PLA