

Patents
Literature
21510results about "External condition input parameters" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Systems and methods for cooperative sensor fusion by parameterized covariance generation in connected autonomous vehicles
PendingUS20250026371A1Particular environment based servicesExternal condition input parametersSimulationSensor fusion
A system disclosed herein applies a parameterized sensing and localization error model for use by connected devices to improve cooperative sensor fusion by estimating errors using key prediction factors (e.g., distance and velocity) at different tiers. The parameterized sensing and localization error model implements a local sensor fusion process for fusing measurements from sensors of a connected device and a global sensor fusion process for fusing measurements from many connected devices. The local sensor fusion process generates a covariance matrix that incorporates a measured distance and the global sensor fusion process generates a covariance matrix that incorporates a measured velocity combined with the local sensor fusion result. Results show an average improvement of 1.42× in RMSE vs. a typical fixed error model on a 1 / 10 scale test-bed.

Owner:THE ARIZONA BOARD OF REGENTS ON BEHALF OF THE UNIV OF ARIZONA
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Systems and methods for vehicle control using terrain-based localization
PendingUS20250065894A1Instruments for road network navigationVehicle headlampsDriver/operatorLocalization system
Systems and methods described herein include implementation of road surface-based localization techniques for advanced vehicle features and control methods including advanced driver assistance systems (ADAS), lane drift detection, passing guidance, bandwidth conservation and caching based on road data, vehicle speed correction, suspension and vehicle system performance tracking and control, road estimation calibration, and others.

Owner:CLEARMOTION INC
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Vehicle idling start and stop control system and method
InactiveCN108622068AReduce idle timeLow costExternal condition input parametersState of chargeFlywheel
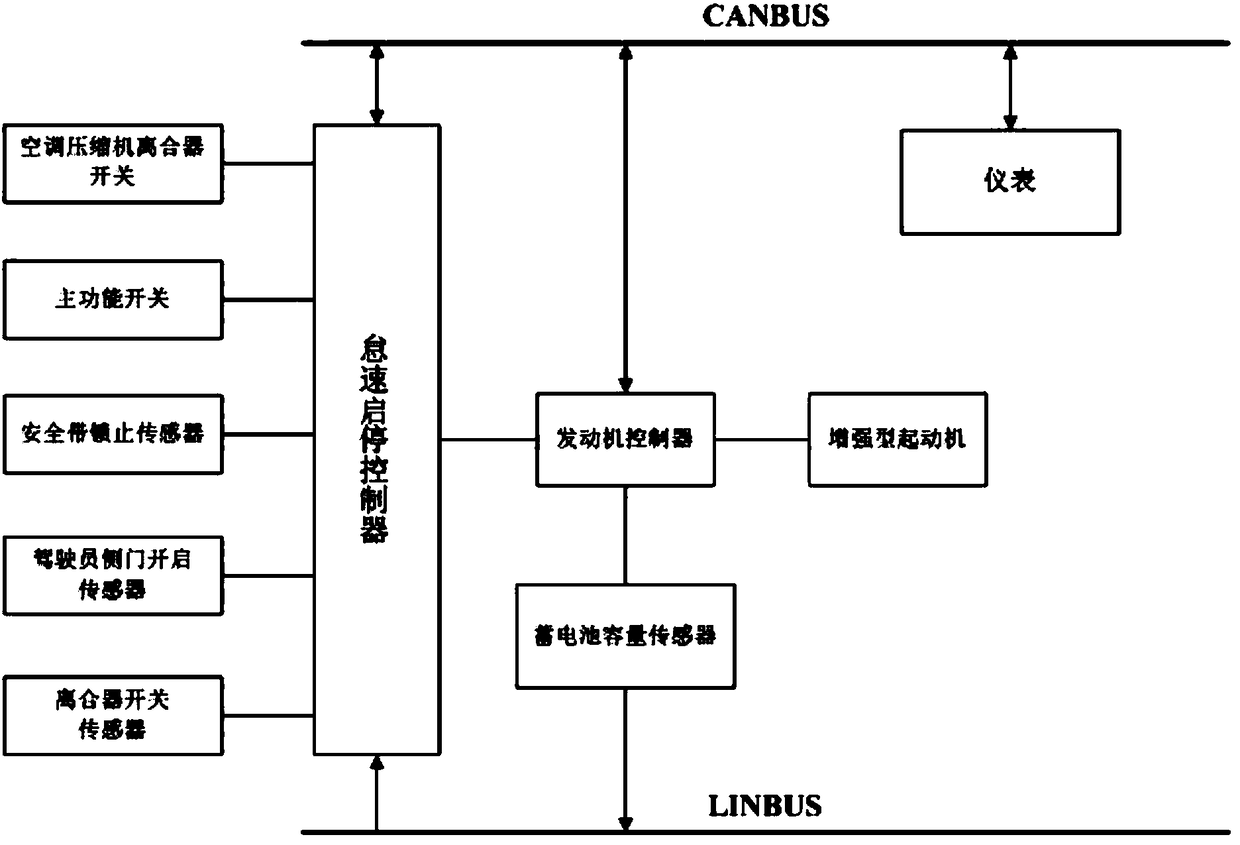
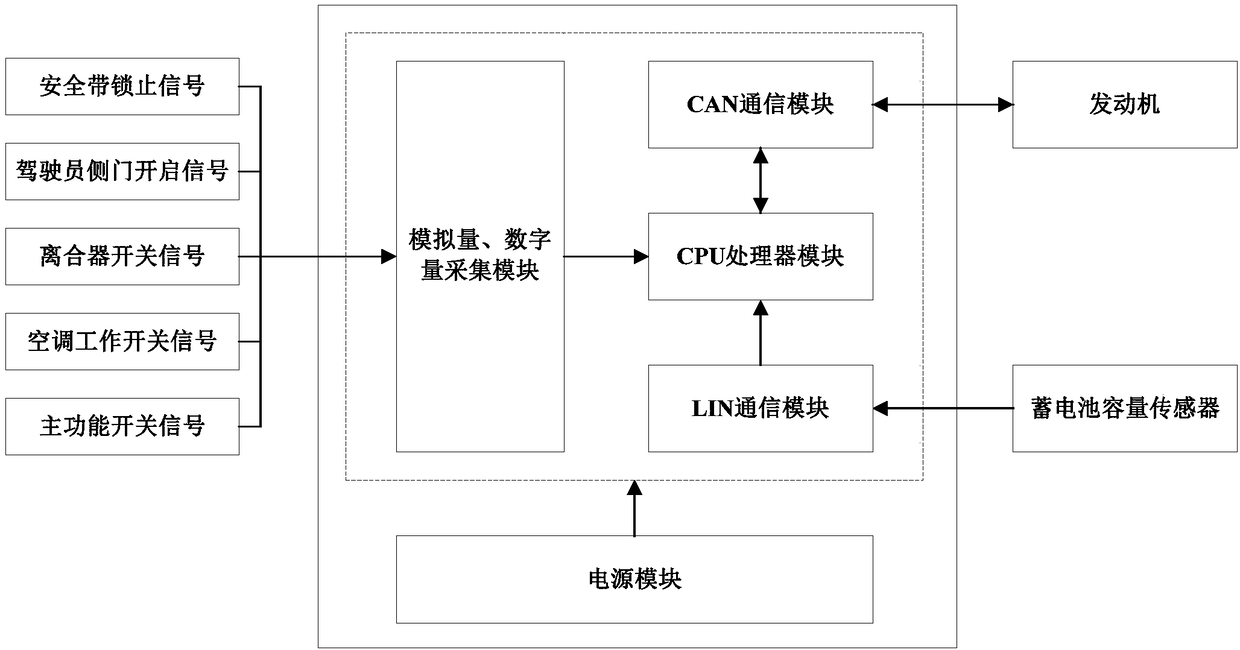
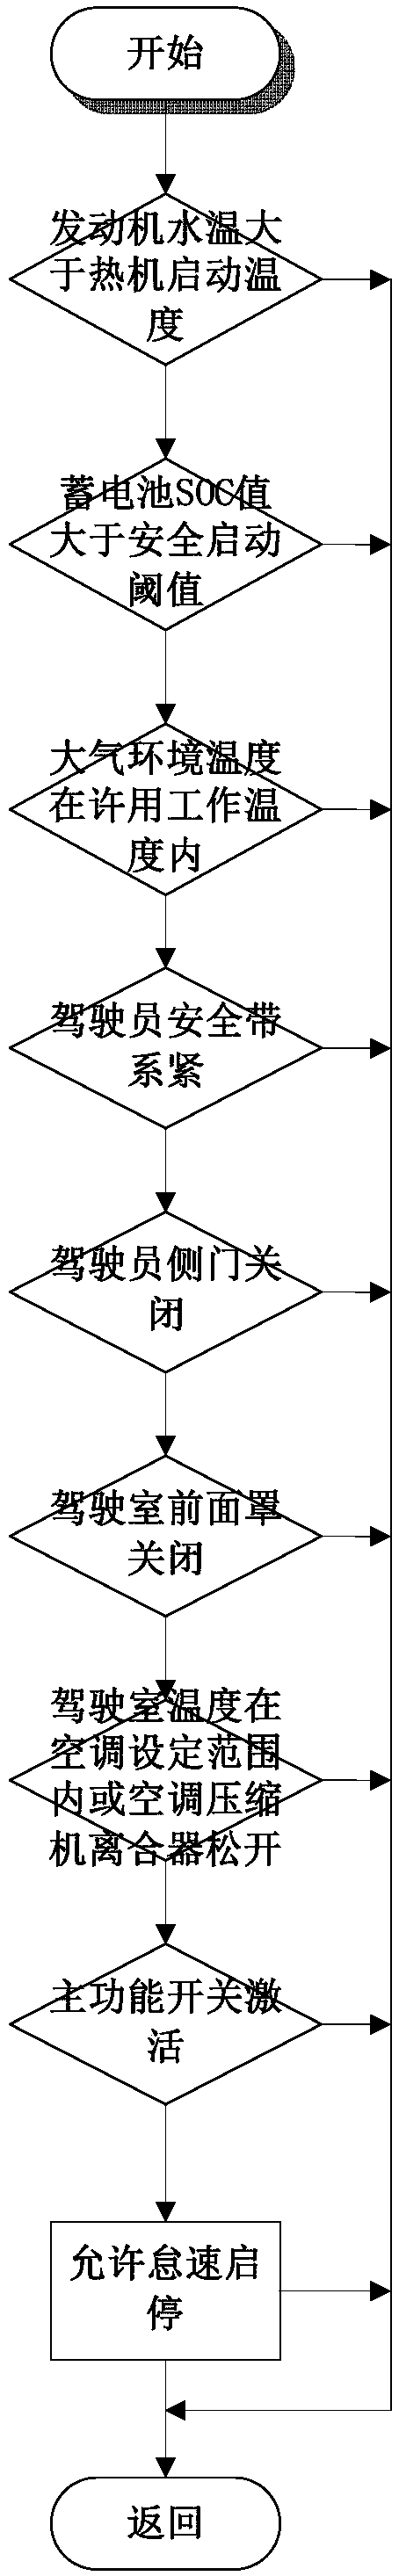
The invention discloses a vehicle idling start and stop control system and method. The control system judges whether a vehicle has idling start and stop conditions by monitoring the water temperatureof an engine, the capacity of a storage battery, a safety belt and other information, judges whether the vehicle has conditions of stopping the engine by monitoring the rotating speed of the engine, the speed of the vehicle, the brake air pressure and other conditions, and judges whether the vehicle has conditions of starting the engine by monitoring the gear of a gearbox, the speed of the vehicle, a hand brake and other information. When the relevant conditions are met, start and stop work signals are sent to the engine though a CAN bus. In order to guarantee the reliability of frequent startand stop of the engine, the system strengthens flywheel gear rings of a starter and the engine. In order to ensure that the battery does not lose power, a storage battery capacity sensor is added tothe system on the basis of increasing the capacity of the storage battery, and the idling start and stop are allowed when the state of charge (SOC) of the storage battery satisfies a safe starting threshold. The idling start and stop control system has advantages of low cost and high reliability, and is especially suitable for commercial vehicles.
Owner:SHAANXI AUTOMOBILE GROUP
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Unmanned driving dynamic path planning method and system based on multi-source data fusion
ActiveCN120552911AExternal condition input parametersExternal condition output parametersSteering anglePoint cloud
The invention belongs to the technical field of path planning, and discloses an unmanned driving dynamic path planning method and system based on multi-source data fusion, and the method comprises the steps: collecting an ice and snow pavement friction coefficient, a curve curvature and an obstacle point cloud, constructing a sensor confidence coefficient matrix, generating a fused semantic map, and constructing a dynamic environment semantic model. Outputting a real-time friction coefficient field and a risk thermodynamic map layer; the roadside unit broadcasts coordinates of opposite vehicles in a blind area of a curve to a vehicle end, constructs an ice and snow pavement offset crowdsourcing map, and generates a global-local fusion topology; fusing the real-time friction coefficient field and the global-local fusion topology to generate a smooth trajectory set, and further generating a risk optimal path instruction set; a steering angle and torque instruction is decomposed, positioning drift is compensated in real time, and a normal mode for updating the vehicle positioning state and a degradation mode when the millimeter wave radar fails are constructed; and generating execution logs and health state vectors, and aggregating the execution logs and the health state vectors of multiple vehicles to form closed-loop iterative update.

Owner:HENAN HAIRONG SOFTWARE CO LTD
Vehicle risk avoidance method and system, vehicle, and storage medium
PendingEP4497644A1External condition input parametersExternal condition output parametersSimulationArtificial intelligence
Disclosed in the embodiments are a vehicle risk avoidance method and system, a vehicle, and a storage medium in the technical field of intelligent driving. The method includes the following steps: obtaining first motion state information of a target vehicle and obstacle information of a target obstacle at a plurality of consecutive moments, the obstacle information including two or more of an obstacle type, an obstacle location, obstacle boundary information, and second motion state information; executing a risk assessment strategy corresponding to the obstacle type according to the first motion state information and the obstacle information corresponding to each moment, to determine a risk assessment result of whether the target vehicle collides with the target obstacle; and determining, if a plurality of risk assessment results corresponding to the plurality of moments satisfy a risk condition, a target risk assessment result from the plurality of risk assessment results, and generating a target security protection strategy corresponding to the target risk assessment result to avoid a collision risk.


Owner:CHONGQING CHANGAN AUTOMOBILE CO LTD
Vehicle speed management
ActiveUS12269498B1Particular environment based servicesExternal condition input parametersIn vehicleEmbedded system
An improved system and method of defining speeding severity levels, receiving over a wireless network from a vehicle device speed data and metadata, determining associated speeding severity levels, based at least in part on the determined associated speeding severity levels, determining whether an alert communication is to be transmitted the vehicle device, and in response to determining that an alert communication is to be transmitted the vehicle device, transmitting the alert communication via a wireless interface to the vehicle device, the alert communication configured to cause the vehicle device to provide a corresponding in-vehicle alert.

Owner:SAMSARA INC
Driving situation prediction and adaptive strategy generation system based on cloud multi-mode large model
InactiveCN119408566Aavoid confictimprove securityForecastingExternal condition input parametersSimulationData acquisition
The invention discloses a driving situation prediction and adaptive strategy generation system based on a cloud multi-mode large model. Comprising a multi-modal data acquisition and situation prediction module, a self-adaptive strategy generation and remote optimization module, a collaborative driving and multi-vehicle strategy coordination module, a cloud driving intelligent monitoring and feedback module and a dynamic risk assessment and path optimization module. Various input data from the vehicle and the environment are processed through the cloud, risk factors such as sudden obstacles, weather deterioration and complex traffic conditions in the automatic driving situation are predicted in advance, cloud computing provides powerful data processing capacity and storage resources, a large model deployed at the cloud can train data collected by the vehicle, and the risk factors can be predicted in advance. Therefore, the perception and prediction capabilities of the automatic driving system are improved, various coping strategies aiming at the risks are generated, and the vehicle is helped to make a safer and more intelligent driving decision in a complex scene through dynamic generation and remote optimization of an adaptive strategy.

Owner:GUANGZHOU SMART BODY TECH CO LTD
Method to detect and manage icy uphill roads in autonomous vehicles
InactiveUS20240416949A1Anti-collision systemsCharacter and pattern recognitionRoad surfaceTransport engineering
An embodiment related to a system, wherein the system is operable to determine a road surface condition, wherein the road surface condition is at least one of an ice, wet, and snow; adjust, a safe distance value of the host vehicle based on the road surface condition; detect a vehicle type, a speed, and a visible roof area of a target vehicle; determine an uphill road that the host vehicle is approaching; determine that the target vehicle is slowing down based on a change in speed of the target vehicle in real-time; and determine, a collision avoidance action for the host vehicle to avoid a collision with the target vehicle.

Owner:VOLVO CAR CORP
Intelligent network connection automobile safety control method and system based on active and passive safety information fusion
ActiveCN119176143AInternal combustion piston enginesExternal condition input parametersIntelligent NetworkSafety control
The invention discloses an intelligent network connection automobile safety control method and system based on active and passive safety information fusion. The system comprises an environment detection module, a risk prediction module and a cooperative control module. Wherein the environment detection module comprises a passenger state monitoring part, a vehicle system monitoring part and a traffic environment sensing part, the risk prediction module comprises a vehicle collision risk prediction part and a passenger injury risk prediction part, and the cooperative control module comprises an in-vehicle intelligent restraint system, a vehicle steering system and a control execution part of a braking system. The vehicle collision risk probability and the passenger injury probability are calculated in real time according to the established vehicle risk prediction model and the passenger injury risk prediction model by fully utilizing the early warning capability of an active safety system for potential risks. When the system encounters unavoidable dangerous working conditions, the system adjusts the state of the restraint system to enable the restraint system to reach the optimal state of current passenger protection, and extra risks, caused by non-cooperation of the active safety system and the restraint system, of passengers are avoided.

Owner:JIANGSU UNIV
Systems and methods for navigating a vehicle on a covered road
ActiveUS20250065900A1Navigational calculation instrumentsRoad vehicles traffic controlComputer graphics (images)Engineering
A system for navigating a host vehicle, includes at least one processor comprising circuitry and a memory, wherein the memory includes instructions that when executed by the circuitry cause the at least one processor to perform operations comprising: receiving from a camera onboard the host vehicle at least one captured image representative of an environment of the host vehicle; detecting, based on analysis of the at least one captured image, a presence of a road covering material on a road segment surface; determining, based on analysis of the at least one captured image, a distance between the camera onboard the host vehicle and the road covering material; and determining a thickness profile of the road covering material based on the determined distance between the camera onboard the host vehicle and the road covering material, and also based on stored three-dimensional profile information associated with the road segment surface.

Owner:MOBILEYE VISION TECH LTD
Selectable multi-mode policy control for an autonomous vehicle
PendingUS20250115279A1External condition input parametersOther vehicle parametersImaging analysisAutopilot
System and methods are disclosed for navigating a host vehicle. In one implementation, at least one processing device may be programmed to receive an image representative of an environment of the host vehicle, identify, based on the image analysis, a target vehicle, select a safe navigation mode among a plurality of available safe navigation, each of the safe navigation mode being associated with a corresponding safe navigation distance, determine a planned navigational action for the host vehicle that if taken would result in a next-state distance between the host vehicle and the target vehicle greater than or equal to the selected safe navigation mode safe navigation distance, and implement the planned navigational action by controlling one or more actuators associated with the host vehicle. The at least one processing device may be further programmed to select a safe navigation mode based on a detected location or condition of the host vehicle.

Owner:MOBILEYE VISION TECH LTD
Trajectory Planning in a Three-Dimensional Search Space with a Space-Time Artificial Potential Field
ActiveUS20250033661A1Steering partsExternal condition input parametersComputer graphics (images)Computer vision
This document describes trajectory planning in a three-dimensional (3D) search space with a space-time artificial potential field. An example system includes a processor that obtains an initial pose, a goal pose, and an obstacle map for an environment. The processor uses a parking trajectory algorithm to determine a trajectory by searching in a space-time artificial potential field. The trajectory includes a series of 3D waypoints, including two-dimensional (2D) positional coordinates and time coordinates, to navigate from the initial pose towards the goal pose. Operation of the host vehicle is then controlled to maneuver along the trajectory using an assisted-driving or autonomous-driving system. In this way, path searching is performed in the entire 3D search space rather than iterating between two 2D search planes. This allows motion planning for autonomous parking, especially with static and dynamic objects present, to determine an optimal trajectory in a single iteration.


Owner:APTIV TECHNOLOGIES AG
Trajectory generation for mobile agents
A method of generating at least one trajectory in scenario comprising an agent navigating a mapped area, the method comprising: receiving an observed state of the agent and map data of the mapped area; generating a set of multiple trajectory basis elements from the observed state of the agent based on the map data; processing one or more scenario inputs in a neural network to generate a set of weights, each weight corresponding to one of the trajectory basis elements; and generating a trajectory for the agent by weighting each trajectory basis element by its corresponding weights and combining the weighted trajectory basis elements.

Owner:FIVE AI LTD
Prediction of object intent and conflicts using time-invarient diverse paths
A machine-learned architecture may predict multiple paths that an object could take in the future without regard to time at which the object may occupy positions identified by one of those paths. These time-invariant paths may be used by an autonomous vehicle to filter detected objects by relevance to an autonomous vehicle's plans, improve prediction of an object's reaction to a vehicle candidate trajectory, determine right-of-way between object(s) and the autonomous vehicle, match detected objects to lanes, and / or improve prediction of odd or out-of-turn object behavior of an object.

Owner:ZOOX INC
Safe and scalable model for culturally sensitive driving by automated vehicles using a probabilistic architecture
The invention relates to a method and system which determine certainty, e.g. an aleatoric certainty score, as well as an uncertainty score, e.g. an epistemic uncertainty, based on input data. The input data includes static and dynamic data. A trained behavioral model generates trajectory predictions and the certainty and uncertainty score. A vehicle-based function is controlled based in the certainty score and the uncertainty score, e.g. increase following distance or hand over to a human driver.

Owner:MOBILEYE VISION TECH LTD
Techniques for adaptive driving using language models
PendingUS20250153735A1Character and pattern recognitionNatural language data processingSimulationIndustrial engineering
One embodiment of a method for controlling a vehicle includes receiving first text that includes a description of a scene and a first plan for driving a vehicle, extracting at least one portion of a set of traffic rules based on the description of the scene and the first plan, generating a first prompt that requests driving instructions and includes the description of the scene, the first plan, and the at least one portion of the set of traffic rules, processing the first prompt via a first trained language model to generate a second plan for driving the vehicle, and generating driving instructions based on the second plan.

Owner:NVIDIA CORP
Method to detect and manage situations where a large vehicle may hit a vehicle when turning
An embodiment related to a system, wherein the system is operable to: detect an intersection and a target vehicle near the intersection; determine a current location of a host vehicle and the target vehicle; detect a target turn lane; estimate parameters of the target vehicle, wherein the parameters of the target vehicle comprise a vehicle type, a vehicle model, a steering angle, and a turn radius; predict a trajectory of motion of the target vehicle; establish a boundary for an impact zone by the host vehicle; and determine a collision avoidance action for the host vehicle to avoid the impact zone.


Owner:VOLVO CAR CORP
System and method for electric vehicle operational optimization
ActiveUS20250296580A1Ensemble learningRegistering/indicating working of vehiclesElectric vehicleReal-time computing
A system and method for electric vehicle operational optimization is disclosed. The system comprises a memory storing processor-executable instructions and a processor, communicably coupled with the memory. The system obtains input data and predict health and performance parameters. The system generates computer simulated instances which emulate a behavior and a performance of the electric vehicle. The system, further, validates the health and the performance parameters by simulating the computer simulated instances in a virtual environment. The system determines a behavior status, a performance status and a health status of the electric vehicle. Thereafter, the system determines abnormality associated with the electric vehicle, followed by determining action for rectifying the abnormality. Consequently, the system controls an operation by performing the determined action at the electric vehicle.

Owner:ACCENTURE GLOBAL SOLUTIONS LTD
Vehicle abnormal driving identification early warning method and system
ActiveCN119399997Aimprove traffic safetyImprove driving experienceControlling traffic signalsInternal combustion piston enginesDriver/operatorData acquisition
The invention relates to the technical field of traffic safety management, in particular to a vehicle abnormal driving recognition and early warning method and system. The method comprises the following steps: firstly, acquiring vehicle position, speed, direction and driver operation data in real time, then correcting time sequence data by adopting a smooth denoising method of adaptive segmented clustering, generating an information confirmation code through standardization, and then carrying out weighted fusion on multi-source data to obtain a multi-source data fusion model; the strategy decision-making module is used for extracting vehicle speed change rate, lane deviation degree and driver behavior characteristic key indexes, identifying and grading abnormal driving behaviors by setting a threshold value, calculating a comprehensive abnormal score, and generating a grading intervention strategy for slight, medium and serious anomalies according to a comparison result of the abnormal score and the set threshold value. And finally, combining automatic intervention in the vehicle with global coordinated intervention of a road manager. According to the invention, the intervention strategy is generated based on multi-source data acquisition, processing, analysis and decision, so that the vehicle driving safety and the road management efficiency are improved.

Owner:HEFEI YUEMING TRANSPORTATION ELECTRONIC TECH CO LTD
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Systems and methods of sensor data fusion
Systems and methods of sensor data fusion including sensor data capture, curation, linking, fusion, inference, and validation. The systems and methods described herein reduce computational demand and processing time by curating data and calculating conditional entropy. The system is operable to fuse data from a plurality of sensor types. A computer processor optionally stores fused sensor data that the system validates above a mathematical threshold.

Owner:DIGITAL GLOBAL SYSTEMS INC
Infrastructure-based collaborative automated parking and location management
Systems and techniques for location management are described herein. In an example, a system may include at least one processor and at least one memory with instructions stored thereon that when executed by the processor, cause the processor to obtain data originating from one or more sensors proximate to the location. A trained activity-based detection model may identify an activity at the location and perform a determination of a service to be offered at the location based on the detected activity. The system may then send a message to a user offering the service to the user, and in response to receiving an authorization accepting the service from the user, cause the service to be implemented at the location, which may include classifying the service as a service type, matching the service type to a service provider, and sending a notification to the service provider.

Owner:INTEL CORP
Apparatus and methods for driver assistance and vehicle control
InactiveUS20250065902A1External condition input parametersElectromagnetic wave reradiationDriver/operatorControl engineering
Systems and methods described herein include implementation of road surface-based localization techniques for advanced vehicle features and control methods including advanced driver assistance systems (ADAS), lane drift detection, passing guidance, bandwidth conservation and caching based on road data, vehicle speed correction, suspension and vehicle system performance tracking and control, road estimation calibration, and others.

Owner:CLEARMOTION INC
Occupancy prediction using forward-backward view transformation
Apparatuses, systems, and techniques of using one or more machine learning processes (e.g., neural network(s)) to predict occupancy using an image input. In at least one embodiment, image data is processed using a neural network to predict occupancy in a 3D voxel space. In at least one embodiment, image data is processed using a neural network to detect objects in a 3D space.

Owner:NVIDIA CORP