

Patents
Literature
8137 results about "Airframe" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
The mechanical structure of an aircraft is known as the airframe. This structure is typically considered to include the fuselage, undercarriage, empennage and wings, and exclude the propulsion system.
Electric tilt rotor aircraft and control system thereof
PCT designated stage expiredWO2024255724A1Power plant arrangements/mountingWith power amplificationNacelleFlight direction
An electric tilt rotor aircraft and a control system thereof. The aircraft comprises a fuselage (1), wings (2), horizontal stabilizers (3) and a landing gear system (4), wherein the fuselage (1) comprises a fuselage body and a rudder (10) for controlling and adjusting a flight direction of the aircraft; the wings (2) each comprise an integral wing box section (21), an aileron (22), a wing left / right nacelle (23) and a supporting rod left / right nacelle (24); left and right supporting rods are integrated on front sides of the integral wing box sections (21); the wing left / right nacelle (23) is connected to the integral wing box section (21) by means of a tilting shaft (25), and the wing left / right nacelle (23) rotates around the tilting shaft (25); the horizontal stabilizers (3) each comprise a horizontal stabilizer box section (31) and a horizontal stabilizer left / right nacelle (32); the horizontal stabilizer left / right nacelle (32) is connected to the horizontal stabilizer box section (31) by means of the tilting shaft (25), and the horizontal stabilizer left / right nacelle (32) rotates around the tilting shaft (25); the landing gear system (4) uses a tricycle landing gear system, and comprises a nose landing gear (41) and two main landing gears (42); brake systems are integrated in the main landing gears (42); and the nose landing gear (41) plays a role in balancing and controlling direction. By using the electric tilt rotor aircraft, urban air traffic can be realized.

Owner:SHANGHAI TCAB TECHNOLOGY CO LTD
Dynamic path planning and self-adaptive control method and system for coating robot
ActiveCN121165427AProgramme-controlled manipulatorNavigational calculation instrumentsIndustrial engineeringAirplane
The invention discloses a dynamic path planning and self-adaptive control method and system for a coating robot, and relates to the technical field of coating automation. The method comprises the following steps: acquiring point cloud data through three-dimensional scanning equipment, constructing a dynamically updated workpiece curved surface model, and extracting curvature, edge and high-curvature mutation region features; a spraying path is generated based on a reinforcement learning algorithm, and path density, speed and coating supply are dynamically adjusted for a high-curvature area; distance, force feedback and environment parameters are fused, and mechanical arm and spray gun parameters are dynamically adjusted; dividing operation sub-areas and distributing tasks based on robot capability characteristics to realize multi-machine cooperation; and fault redundancy control and multispectral imaging are added to optimize the coating quality. The system comprises a sensing module, a decision-making module, an execution module, a redundancy control module and a communication module. According to the invention, the uniformity of the complex curved surface coating, the multi-machine cooperation efficiency and the system anti-interference capability are improved, and the method is suitable for spraying large workpieces such as aircraft fuselages and high-speed rail vehicle bodies.

Owner:GUANGDONG CHUANGZHI INTELLIGENT EQUIP CO LTD
Blended wing body tailsitter UAV
The present disclosure relates to an aircraft including two or more propulsive devices, and a fuselage integrated with a pair of wings to create a Blended Wing Body (BWB) structure, wherein an orientation of the fuselage and the pair of wings change based on a transition of the aircraft from a vertical position to a horizontal position. Further, each wing of the pair of wings includes a lower winglet and an upper winglet that are identical and coupled to each other at a wing tip. The aircraft further includes a plurality of elevons controlled by two or more propellers associated with the two or more propulsive devices.

Owner:AIRBOUND INTERNATIONAL INC
Aircraft
ActiveCN222432593Uless power consumptionPower plant arrangements/mountingFlight vehicleElectrical battery
The utility model discloses an aircraft, and relates to the field of aircrafts, the aircraft comprises a fuselage, wings are symmetrically arranged on two sides of the fuselage, and an empennage is arranged at the tail part of the fuselage; the plurality of first mounting seats are arranged on the wings and / or the empennages; the plurality of first-class motor systems and the plurality of second-class motor systems are arranged on the plurality of first mounting seats in a one-to-one correspondence manner; and the plurality of battery units are respectively and correspondingly connected with the plurality of first-type motor systems and the plurality of second-type motor systems. According to the technical scheme, the balance of the batteries of the aircraft is improved.

Owner:SICHUAN AEROFUGIA TECH DEV CO LTD
Multi-rotor unmanned aerial vehicle stability control method suitable for multiple environments
InactiveCN119126829Astable flightSolve the unstable flight attitudeVehicle position/course/altitude controlPosition/direction controlUncrewed vehicleControl theory
The invention discloses a multi-rotor unmanned aerial vehicle stability control method suitable for multiple environments, and relates to the technical field of unmanned aerial vehicle stability control, and the method comprises the following steps: obtaining the environmental factor data of the height of an unmanned aerial vehicle in a flight stage and the internal detection data of a fuselage; establishing an evaluation coefficient of height flight attitude stability of the unmanned aerial vehicle according to the factor data of the environment where the unmanned aerial vehicle is located and the fuselage internal detection data; and comparing the flight attitude stability evaluation coefficient with a preset flight stability coefficient, judging whether the unmanned aerial vehicle flies stably at the height or not, and warning and adjusting the unstable flight attitude in time. The problem that when the unmanned aerial vehicle continuously rises in the flight process, the flight attitude cannot be kept or adjusted to be stable in time is solved.

Owner:淮滨县雨顺农业科技有限公司
Vertical takeoff and landing personal land to air vehicle
A land to air vehicle with lower extendable wings and upper extendible wings, a body, a front hood fan, a rear fan and wheels. The wheels include wheel bases, exterior tires circumscribing the wheel bases, and a fan wheel assembly within each wheel base. The wheel assembly includes extendible fans, a rotor outer rim with teeth for holding a stator inner rim, a propeller shroud configured to house a variety of fan blades, at least one fan within the propeller shroud, a hinge fixedly attached to the outer rotor rim and the propeller shroud, a wheel motor platform and a wheel motor. The hinge is structured to allow the propeller shroud with fans to extend distally from the wheel base interior to navigate the land to air vehicle.

Owner:SPANN MAKEEVA
High-speed tiltrotor aircraft having a variable-sweep wing
A variable-sweep wing for a tiltrotor aircraft includes a fuselage link coupled to the fuselage and a pylon link coupled to a pylon. A wing airframe has a root end pivotably coupled to the fuselage link and a tip end pivotably coupled to the pylon link. A driveshaft is coupled between the fuselage link and the pylon link and is positioned within the wing airframe. The driveshaft is operable to transmit torque from the main gearbox to a proprotor gearbox. A crank is coupled between the fuselage link and the pylon link and is positioned within the wing airframe. The fuselage link, the pylon link, the driveshaft and the crank form a linkage such that pivoting the crank relative to the fuselage link causes the wing airframe to shift between a substantially straight wing configuration for low-speed forward flight and a swept wing configuration for high-speed forward flight.

Owner:TEXTRON INNOVATIONS INC
An unmanned aerial vehicle (UAV) for facilitating aerial deliveries of cargo
Disclosed herein is an unmanned aerial vehicle (UAV) for facilitating aerial deliveries of cargo. Accordingly, the UAV may include a body defining a receptacle with a receptacle opening within the body. Further, the UAV may include a propulsion assembly attached to the body. Further, the UAV may include a compartment defining element. Further, the compartment defining element may be configured for defining at least one compartment in the receptacle. Further, each of the at least one compartment may include a compartment interior space and a compartment opening leading into the compartment interior space. Further, the UAV may include a lid coupled to the body. Further, the UAV may include a locking device coupled to the lid. Further, each of the locking device may be configured to be transitioned from a locked state to an unlocked state based on a code.

Owner:AIRHIVE INC
Liquid Hydrogen Feed System for Fuel Cell Powered Aircraft
ActiveUS20250058890A1Fuel cell heat exchangePower plant arrangements/mountingFuel cellsStructural engineering
An aircraft comprises a fuselage; wings; engines connected to the wings; a set of liquid hydrogen tanks; a vent located on the tail on the fuselage; a conduit system connecting the liquid hydrogen tanks to the vent; and a controller. The controller is configured to control the conduit system to remove gaseous hydrogen in the set of liquid hydrogen tanks to travel through the conduit system and exit at the vent in response to pressure in the set of liquid hydrogen tanks being greater than a specified tolerance.

Owner:THE BOEING CO
Folding wing structure of unmanned aerial vehicle
PendingCN111470031AReduce in quantityEasy to processWing adjustmentsRoller bearingStructural engineering
The invention discloses a folding wing structure of an unmanned aerial vehicle, which comprises a rotating shaft embedded in a vehicle body, wherein a lower wing elastic sheet and an upper wing elastic sheet are mounted in an inner cavity of the rotating shaft from bottom to top, a first locking block and a second locking block are respectively arranged at the free ends of the lower wing elastic sheet and the upper wing elastic sheet, the first locking block and the second locking block are respectively matched with a first notch and a second notch which are formed in the rotating shaft, the outer side of the rotating shaft is sequentially sleeved with a lower wing and an upper wing from bottom to top, the upper surface of the lower wing and the lower surface of the upper wing are each provided with a groove, the two grooves are oppositely formed to form a torsional spring groove, a torsional spring is arranged in the torsional spring groove, and the upper inner sides of the lower wingand the upper wing are provided with a first locking groove and a second locking groove correspondingly; and the outer side of the rotating shaft is further sleeved with a roller bearing, a baffle isinstalled at the top of the rotating shaft, and the roller bearing is located between the upper wing and the baffle. The processing cost of the unmanned aerial vehicle is reduced, the folding wing structure is insensitive to the structural size, and the folding wing structure can adapt to a more miniaturized barrel-shooting unmanned aerial vehicle.
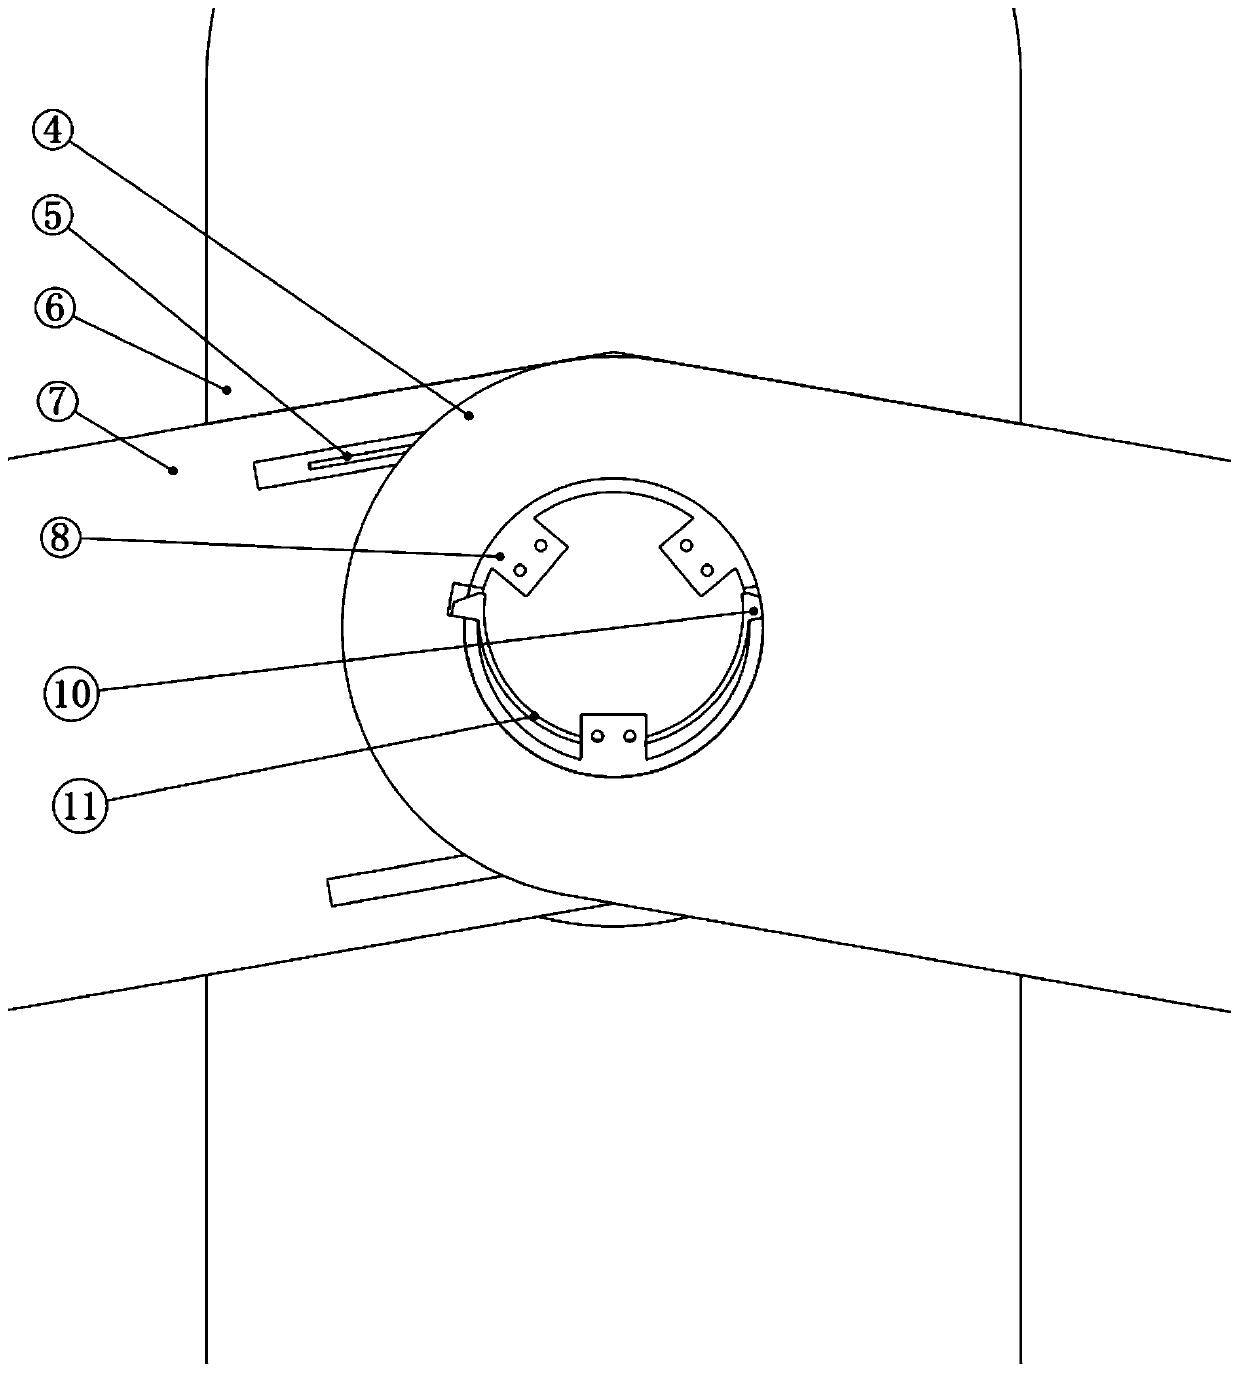
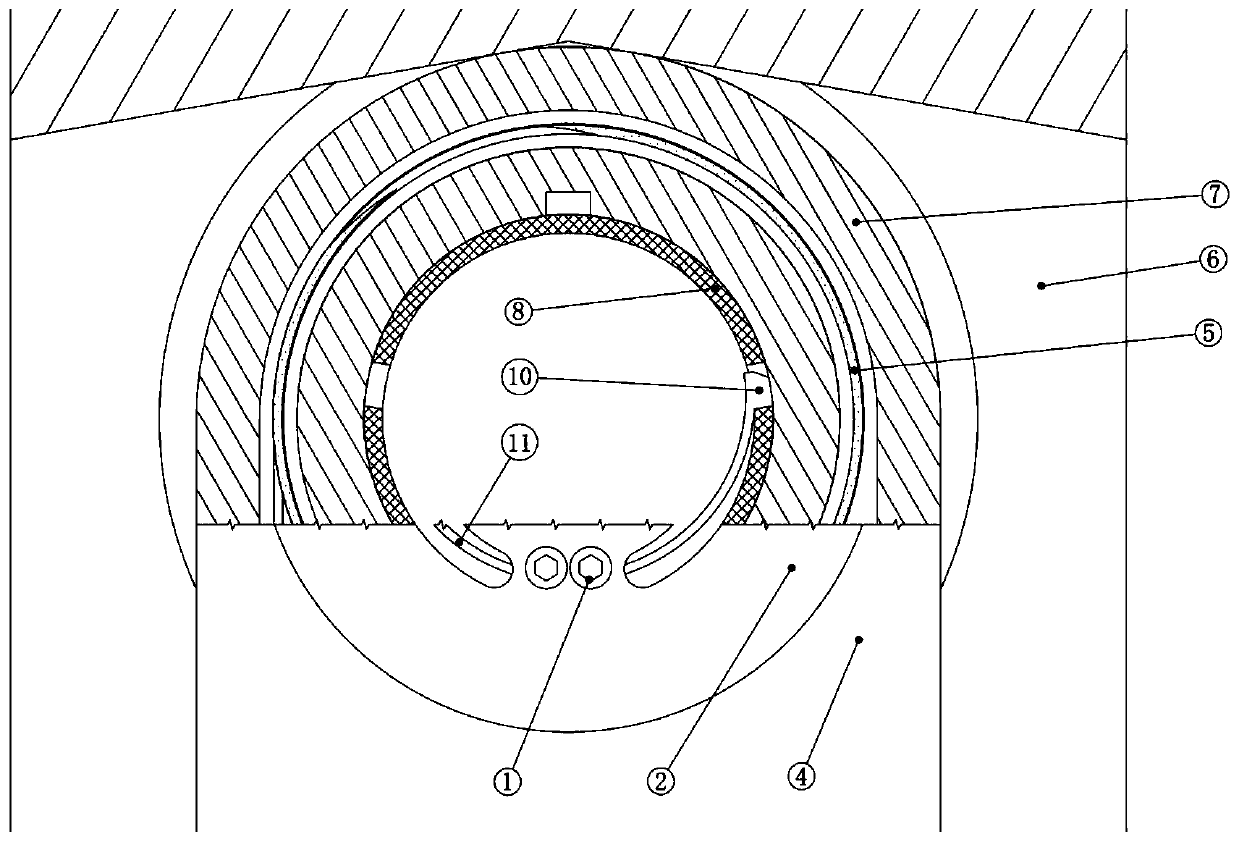
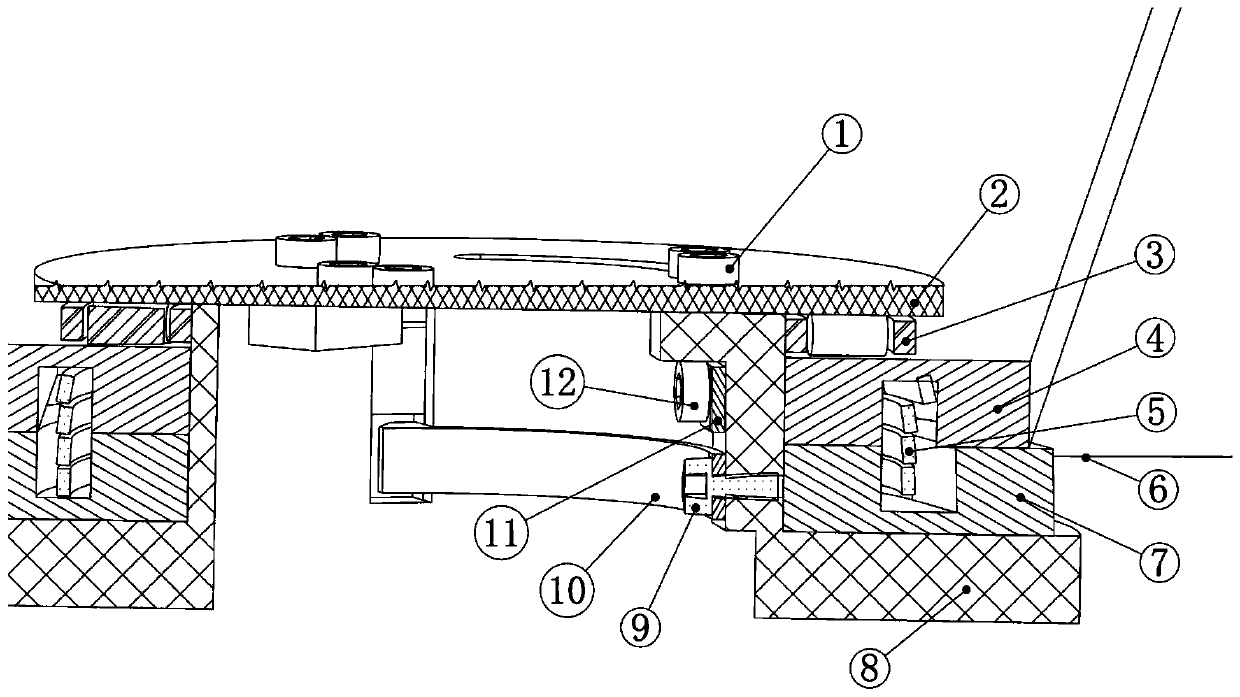
Owner:西安深瞳智控技术有限公司
Cleaning robot
ActiveCN222398168UEnsure balanceMachine detailsFloor sweeping machinesDrive wheelStructural engineering
The utility model provides a cleaning robot which comprises a robot body and an advancing assembly, the advancing assembly comprises a driving wheel, a supporting unit and an obstacle crossing wheel, the obstacle crossing wheel is arranged on the supporting unit, and the supporting unit can rotate around the driving wheel so that the advancing assembly can be switched between an advancing state and an obstacle crossing state; when the advancing assembly is in an advancing state, the driving wheels abut against the ground to drive the machine body to advance; when the advancing assembly is in the obstacle crossing state, the supporting units drive the obstacle crossing wheels to make contact with the ground, the driving wheels are made to break away from the ground, and the obstacle crossing wheels drive the machine body to advance. By means of the structure, the obstacle crossing wheels can be driven by the supporting units to make contact with the ground to support the machine body when a preset distance exists between the obstacle crossing device and an obstacle, so that the front end of the machine body is far away from the ground, the rear end of the machine body is close to the ground, and the whole machine body is in an inclined state; the distance between the front end of the robot body and the ground is far larger than the ground clearance of the robot body, and therefore the obstacle crossing capacity of the cleaning robot is improved.

Owner:DREAM INNOVATION TECH (SUZHOU) CO LTD
Door management
A door management system on an aircraft includes a fuselage extending along a longitudinal axis in a fore-aft direction parallel to forward flight, an opening in a sidewall of the fuselage, a door mounted on the sidewall to slide in the fore-aft direction between a closed position covering the opening and an open position revealing the opening, a cable attached to the fuselage and the door and a speed governor operatively coupled to the cable to limit a velocity of the door as it moves between the open position and the closed position.

Owner:TEXTRON INNOVATIONS INC
Loitering Craft
A craft is provided comprising: a propulsion system; a fuselage coupled with the propulsion system, wherein the fuselage is configured to carry a payload and fuel for the propulsion system; and a pre-assembled wing coupled with the fuselage; wherein the craft is designed to take-off without using a runway and does not have landing gear to land.

Owner:REGENT CRAFT INC
Robot suitable for plant protection spraying operation in hilly and mountainous regions
The embodiment of the invention provides a robot suitable for plant protection spraying operation in hills and mountains. The quadruped robot comprises a main body machine body and four independent leg structures which are connected to the main body machine body through joints and have multiple motion freedom degrees. The pesticide box is mounted on the main body; the pesticide pump is installed on the main machine body and comprises a pesticide suction opening and a pesticide injection opening, and the pesticide suction opening is communicated with a liquid outlet of the pesticide box through a first connecting pipeline; the mechanical arm is installed at the preset position of the main machine body through a base, the mechanical arm is in a multi-joint series connection mode, and the mechanical arm comprises a plurality of driving joints capable of rotating or swinging and a rigid connecting rod for connecting the joints. The stable moving and obstacle crossing ability is achieved through the four-foot structure, continuous pesticide supply is provided through the pesticide box and the pesticide pump, the precise spraying and metamorphic functions are achieved through the multi-degree-of-freedom mechanical arm, and therefore the excellent performance and effect are shown in plant protection spraying operation in hills and mountains.

Owner:SHANGHAI INST OF TECH
Aircraft and aircraft system using same
Provided are: an aircraft that can fly stably even when water is discharged from a hose installed on the airframe thereof; and an aircraft system that uses the aircraft. This aircraft system comprises: a master aircraft 10; three slave aircrafts 20; and a remote control device 30 that is for making the aircraft fly as a unit. Each slave aircraft 20 has: four rotary blade portions that have propellers 221; and a suspending means 23 that is for suspending a prescribed part of a hose 50 that is for discharging water. The master aircraft has: four first rotary blade portions that have first propellers 121 that have been arranged to rotate in a horizontal plane; four second rotary blade portions that have second propellers 131 that have been arranged to rotate in a vertical plane; and a nozzle 15 on which a tip end part of the hose 50 is installed. The direction of the center axis of the nozzle 15 is parallel to the direction of the rotational axes of the second propellers 131.

Owner:WEEFEES LLC
Snakelike robot for internal inspection of small pipeline
A snakelike robot for internal inspection of small pipelines comprises a head machine body and a tail machine body which are connected through a cross universal joint. Three groups of crawling driving mechanisms are uniformly distributed and fixedly mounted on each of the head machine body and the tail machine body; a supporting shaft is fixedly installed at the front end of the head machine body, a rolling brush mechanism is rotationally installed on the supporting shaft, and a rolling brush driving mechanism is fixedly installed on one side of the supporting shaft. A sealed cabin is fixedly installed at the top end of a supporting shaft on the head machine body, and a camera assembly is fixedly installed in the sealed cabin. A cleaning mechanism for the sealed cabin is detachably and fixedly mounted on the rolling brush mechanism of the head machine body, and the cleaning mechanism is in rotating contact with the sealed cabin; according to the utility model, the problem that the camera assembly is blocked by foreign matters such as chippings in the pipeline is effectively avoided, and the shooting detection sight of the camera assembly is ensured; meanwhile, through the arrangement of the rolling brush mechanism, cleaning of the inner wall of the pipeline in the advancing process is achieved, and smooth crawling of the robot is guaranteed.

Owner:SHENZHEN WUJIANG MARINE TECH CO LTD
Drone mechanism including foldable arm and compressible gripper
An unmanned aerial vehicle includes a body. The body has an upper side and a lower side opposite the upper side. At least one rotor is coupled to the body to generate lift in an upward direction. A mechanism is mounted to the lower side of the body. The mechanism includes a landing gear, a storage system, a robotic arm housing, a counterweight housing, a robotic arm, an actuator, and an end effector. The actuator is coupled to the robotic arm to move the robotic arm between a retracted position and an extended position. The end effector is coupled to the distal end of the robotic arm. The end effector includes a gripper with a pair of opposing compressible elements for gripping an object between the pair of compressible elements.

Owner:IDAHO STATE UNIVERSITY
Water-air amphibious bionic flapping-wing robot with chordwise dual modes
ActiveCN119262358ASolve technical difficultiesReduce projected areaOrnithoptersAircraft convertible vehiclesFlapping wingMachine
The invention belongs to the related technical field of bionic flapping-wing robots, and discloses a water-air amphibious bionic flapping-wing robot with chordwise bimodal flapping wings, which comprises a main body, the chordwise bimodal flapping wings, an empennage, a cross-medium mechanism, a control unit and a flexible skin, the main machine body is a main supporting component of the robot, and the chordwise bimodal flapping wings are installed on the left side and the right side of the main machine body and oscillate up and down in a reciprocating mode to drive the flexible skin covering the chordwise bimodal flapping wings to generate power. The empennage is fixed to the rear end of the main fuselage to assist the robot in posture adjustment. The cross-medium mechanism is installed at the front end of the main machine body and used for providing impulsive force for cross-medium movement of the robot. And the control unit is connected with each component through a signal line. The bionic flapping-wing robot has an overwater motion mode and an underwater motion mode in the chordwise direction of the flapping wing, the overwater motion mode is beneficial to generation of lift force in the air, the underwater motion mode is beneficial to reduction of power consumption in water and concentration of power in the thrust direction, and the use environment and scene of the bionic flapping-wing robot are expanded.

Owner:HUAZHONG UNIV OF SCI & TECH
Solar powered stratospheric glider
ActiveUS20250011013A1GlidersAircraft stabilisation by gravity apparatusFixed wingMechanical engineering
A glider system capable of sustained long-term flight includes a fixed-wing glider having a dual fuselage system. The top surface of the glider is covered with a plurality of photovoltaic cells capable of powering onboard sensors, propeller systems, and / or onboard processers. The glider includes wing spars with a composite material covering an inner foam core, with the type of foam core or use of reinforcement materials differs along the length or width of the wing spars. The glider is able to downward facing sacrificial winglets to provide a landing system without the need for bulkier landing gear.

Owner:SOLARIS SUBORBITAL INC
System for large-range high-efficiency detection of building facade
ActiveCN223139428UAnalysing solids using sonic/ultrasonic/infrasonic wavesOptically investigating flaws/contaminationControl engineeringControl theory
The utility model discloses a system for large-range high-efficiency detection of a building facade. The system comprises a wall-climbing robot and a remote controller, the wall-climbing robot comprises a robot body, a climbing module, a propeller propelling module, a detection module and a control module, the control module is in communication connection with the remote controller; and the control module is suitable for controlling the climbing module to drive the wall-climbing robot to climb or descend along the rope, controlling the propeller propelling module to propel the wall-climbing robot to be tightly attached to the building facade and controlling the detection module to carry out large-range damage detection on the building facade in the climbing or descending process of the wall-climbing robot under an instruction of the remote controller. According to the utility model, the wall-climbing robot is controlled to climb up and down stably on the vertical facade through the remote controller, and the large-range detection of the crack damage of the building facade is realized.

Owner:TONGJI UNIV
Semi-folding wing automatic unfolding and locking device and unmanned aerial vehicle
The invention provides a semi-folding wing automatic unfolding and locking device and an unmanned aerial vehicle. The locking device comprises a fuselage wing and a locking device, the folding wings are hinged to the fuselage wings; the hinge mechanism comprises a hinge shaft and a hinge torsion spring, the folding wings are hinged to the fuselage wings through the hinge shaft, the hinge torsion spring is arranged on the hinge shaft in a sleeving mode, the hinge torsion spring is connected with the folding wings and the fuselage wings, and when the folding wings are folded relative to the fuselage wings, the hinge torsion spring is in a deformation state; the first locking mechanism is arranged on the fuselage wings; the first locking mechanism is arranged on the folding wing, the second locking mechanism is arranged on the folding wing, the first locking mechanism is movably connected with the second locking mechanism, and when the folding wing is unfolded relative to the fuselage wing, the first locking mechanism and the second locking mechanism are in a locking state. Due to the fact that the fuselage wings are hinged to the folding wings through the hinge mechanisms, the semi-folding wings can be placed in a launching box with small width and regular appearance to be stored and launched in the folded state, and storage and transportation of the semi-folding wings are facilitated.

Owner:AEROSPACE SHENZHOU AIRCRAFT
Articulated hinge assembly for an aircraft door
An articulated hinge assembly for connecting a door to a fuselage of an aircraft includes an articulated hinge arm having a first hinge member pivotably coupled to a second hinge member at an elbow. A fuselage fitting is pivotably coupled to a fuselage bracket and a door fitting is pivotably coupled to a door bracket of the door. The articulated hinge arm is movable from a collapsed position to an expanded position to move the door from a door closed position to a door open position. The articulated hinge assembly includes a linkage assembly coupled to the articulated hinge arm, the fuselage fitting and the door fitting controlling movement of the first hinge member and the second hinge member relative to each other and relative to the fuselage fitting. The linkage assembly controls positioning of the door.

Owner:THE BOEING CO
Aerial vehicle
An aerial vehicle configured to fly with a load suspended therefrom includes a lift generator configured to generate lift for flight, a plurality of supports configured to support the load, an attachment to which the supports are attached, and a relay to relay and support the supports between the load and the attachment. One of the attachment and the relay is outward of, in an airframe of the aerial vehicle, an other one of the attachment and the relay in a plan view.

Owner:KUBOTA CORP
Five-rotor aircraft with incongruent rotor inclination angles
An undercarriage, a middle large rotor and a middle large motor are connected to the lower portion of a fuselage body and sequentially connected to the top of a middle small tower, and the right front portion, the left front portion, the left rear portion and the right rear portion of the fuselage body are correspondingly connected with a right front fuselage arm, a left front fuselage arm, a left rear fuselage arm, a right rear fuselage arm and a power assembly. The connecting line of the rotating centers of the rotors of the four power assemblies is square or rectangular, the rotating directions of the rotors of the power assemblies at the same opposite angles are the same, the rotating directions of the rotors of the power assemblies at different opposite angles are opposite, and the rotating faces of the two rotors opposite to the middle large rotor in rotating direction incline around the axes of the respective arms. The included angle between the rotating surfaces of the two rotors and the horizontal plane is an acute angle beta, the rotating surfaces of the two rotors with the same rotating direction as the middle large rotor incline around respective arm axes, the included angle between the rotating surfaces of the two rotors and the horizontal plane is an acute angle theta, beta is larger than theta, the reaction torque and the horizontal component torque of the rotors jointly drive the aircraft to steer, and the aircraft has the advantages of being long in endurance time, large in load and high in wind resistance. And a universal flight platform is formed.

Owner:江富余
Unmanned aerial vehicle dynamic obstacle avoidance method based on multi-sensor fusion
The invention relates to the technical field of unmanned aerial vehicle control, in particular to an unmanned aerial vehicle dynamic obstacle avoidance method based on multi-sensor fusion. Comprising the steps of receiving an image sequence, a depth point cloud set, a pose state parameter and a flight speed parameter; calculating an illumination distortion gradient value and a speckle noise entropy value based on the image sequence and the depth point cloud set; performing coordinate registration and feature extraction on the image sequence, the depth point cloud set and the pose state parameter, and outputting a visual feature set and a radar feature set; generating a weighted visual feature set and a weighted radar feature set through a weight adjustment function, and generating a joint heterogeneous feature tensor through alignment splicing; and generating a body attitude and thrust control instruction by using the combined heterogeneous feature tensor through a probability prediction model and a model prediction control algorithm device. According to the method, through cross-domain multiplexing and deep coupling of the body physical parameters in the data stream, error accumulation and decision delay caused by multi-stage series calculation are avoided, and global performability of an obstacle avoidance task is facilitated.

Owner:NANJING RING TECHNOLOGY CO LTD
Separable cargo hold unmanned transport plane
PendingCN119460107Aquick changereduce structural weightFreight handlingAviationStructural engineering
According to the unmanned transport plane with the separable cargo hold, rapid replacement of different aviation task cabins can be achieved, a plane body longitudinal beam serves as a structure for bearing the overall weight of the plane, a locking structure used for locking the separable cargo hold is arranged at the bottom of the plane body longitudinal beam, and the separable cargo hold is of a universal module structure. The locking structure is opened after the separated cargo hold is supported, the airplane core structure composed of the airplane body longitudinal beams, the front airplane body, the rear airplane body and the airplane wings and the separated cargo hold are respectively replaced with different cargo holds, and the cargo hold structures of the same specification for bearing different tasks are replaced, so that high freight efficiency is achieved; the fuselage longitudinal beams are adopted as main bearing beams, the front fuselage and the rear fuselage only play a role in rectification and do not participate in bearing, the structural weight of the aircraft is reduced to the maximum extent, the loading capacity of the aircraft is greatly improved, meanwhile, standardized, universal and modular accessories are adopted, and all large components have interchangeability, so that the economical efficiency of the aircraft is improved.

Owner:AVIC XAC COMMERCIAL AIRCRAFT CO LTD
Electric VTOL aircraft with tilting propellers and lifting propellers
A vertical take-off or landing (VTOL) aircraft is disclosed that includes a propulsion system comprising at least four tilting propulsion assemblies and two or more lifting propulsion assemblies. Actuation of the tilting mechanisms can convert the aircraft from a hover configuration, in which all propellers produce thrust generally upward to counteract the aircraft's weight, to a forward flight configuration, in which the four or more tilting propellers produce thrust generally in a forward direction parallel to the fuselage to overcome drag in cruise flight and the lifting propellers produce no thrust or a level of thrust generally less than that required in the hover configuration.

Owner:UNITED STATES OF AMERICA AS REPRESENTED BY THE ADMINISTRATOR NAT AERONAUTICS & SPACE ADMINISTRATION +1
Flow measurement method for engine body air inlet duct fan coupling test
The invention belongs to the technical field of integrated test of airplanes and engines, and discloses a flow measurement method for coupling test of an airframe air inlet duct fan. The flow measuring method for the engine body air inlet duct fan coupling test comprises the steps that the pressure value of a pressure measuring point is calculated through CFD; calculating slope screening pressure measuring points; carrying out an air inlet channel wind tunnel test; training a neural network; carrying out an engine body air inlet duct fan integrated wind tunnel test; calculating a pressure correction coefficient; calculating a predicted flow coefficient; and correcting the flow coefficient. According to the flow measurement method for the engine body air inlet duct fan coupling test, the flow coefficient-surface pressure distribution matching characteristic of an air inlet duct is obtained through a wind tunnel test, and then the flow coefficient is obtained through the matching characteristic and the engine body surface and air inlet duct inner surface pressure distribution in an engine body air inlet duct fan integrated model; the method can accurately predict the air inlet flow and has engineering practical value.

Owner:INST OF HIGH SPEED AERODYNAMICS OF CHINA AERODYNAMICS RES & DEV CENT
Modular airframe tent
A modular tent includes an airframe that is inflatable to provide structural support to the modular tent and an inner tent supported on an inside part of the airframe. The modular tent also includes an outer shell supported on an outside part of the airframe. A tent with a tent body having a doorway disposed therein. The tent also includes an inflatable door hingedly connected to the tent body.

Owner:GOOD INTENTS LLC
Assembled shell and flying life buoy using same
The invention discloses an assembled shell and a flight life buoy using the same, and relates to the technical field of unmanned aerial vehicles. The shell comprises a fuselage part and a wing part which are detachable, the fuselage part and the wing part are connected through a main rod and an auxiliary rod, the overall weight of the shell is effectively reduced, a mounting groove used for mounting an electronic speed regulator is further reserved in the fuselage part, and an avoiding opening communicated with the mounting groove in an aligned mode is reserved in the wing part. Therefore, when the shell is used for the flying life buoy, the air flow formed in the wing part can effectively reduce the temperature of the electronic speed regulator, and the running stability of the flying life buoy is improved.

Owner:NANJING KAITIANYAN UAV TECH CO LTD