

Patents
Literature
470results about "Position/course control in three dimensions" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Pod operating system for a vertical take-off and landing (VTOL) unmanned aerial vehicle (UAV)
ActiveUS12330811B2Vertical landing/take-off aircraftsPosition/course control in three dimensionsClassical mechanicsUncrewed vehicle
A vertical take-off and landing (VTOL) unmanned aerial vehicle (UAV) storage and launch system includes a UAV pod having a UAV pod processor and a UAV selectively enclosed in the UAV pod, the UAV having only two rotors.

Owner:AEROVIRONMENT INC
Adaptive learning approach for a drone
ActiveUS20240411314A1Scene recognitionPosition/course control in three dimensionsAdaptive learningMonitoring - action
One example method of operation may include identifying a likelihood of an object presence at one or more locations within a predefined distance of locations explored by a drone during one or more monitoring actions performed by the drone during a mission including a number of mission requirements, selecting one or more new monitoring actions to perform by the drone based on the likelihood of the object presence to satisfy the mission requirements, and performing the one or more new monitoring actions by the drone.

Owner:METROSTAR SYST LLC
Remote-control system of stratospheric airship and control method thereof
ActiveCN106828860AImprove environmental adaptabilityImprove self-fault toleranceRigid airshipsPosition/course control in three dimensionsWork statusDecision-making
The invention relates to a remote-control system of a stratospheric airship and a control method thereof. The control system is divided to four levels: a decision-making level for executing the selection and switch of a remote-control flight mode according to the actual working state data, and sending a corresponding mode command; a planning level for dynamically planning and generating an airship motor drive command according to the mode command sent by the decision-making level; an executing level for realizing the drive control to an airship motor according to the motor drive command of the planning level; and a perceiving level for finishing the real-time monitoring and data collection of the airship working state, and providing the original data of the airship working state to the decision-making level. The four-level control system architecture design of the control system is capable of simplifying the control device, improving the control efficiency, and fundamentally solving the problems of the function, efficiency and reliability of the near space airship ground and airborne control system.


Owner:北京天恒长鹰科技股份有限公司
Methods and Systems for Generating a Mission Plan that Guides a Spacecraft to Orbiting Target Objects
ActiveUS20240425206A1Cosmonautic vehiclesPosition/course control in three dimensionsMission planCollision free
An example method executed by a controller onboard a spacecraft generates a mission plan in real-time that guides the spacecraft along a space autonomous mission to rendezvous with two or more orbiting target objects. The method includes establishing potential permutations for all possible unique maneuver sequences in which to visit the two or more orbiting target objects, and for each potential permutation, determining a collision-free maneuver plan for defining orbit trajectories to intercept each of the two or more orbiting target objects for each of the possible unique maneuver sequences. An optimal permutation is determined that meets viewing constraints of the two or more orbiting target objects, a viewing priority, and fuel constraints of the spacecraft. A mission visit plan is generated using the optimal permutation, and the spacecraft executes the plan to rendezvous with and inspect the two or more orbiting target objects.

Owner:THE BOEING CO
Intelligent optimization of spacecraft missions
Intelligent optimization of mission planning and execution for spacecraft through intelligent analysis of mission objectives and payload operation is disclosed. Values for mission objectives, payload operation, and / or vehicle conditions may be defined during given time periods, including variable values for repeat operations or other factors. These values may then be used through a vehicle / mission simulation agent to optimize the mission plan through maximizing the mission score according to the values. The simulation agent may identify possible mission plans based on vehicle capability, and then score the mission plan based on the total objective score.

Owner:AEROSPACE CORP
Smart drone rescue and mission rescheduling on a swarm of drones
According to one embodiment, a method, computer system, and computer program product for rescuing a malfunctioning drone is provided. The present invention may include responsive to detecting a total failure in a malfunctioning drone comprising a drone fleet, operating one or more rescue drones to physically or virtually attach to the malfunctioning drone; reconfiguring sub-missions comprising a mission assigned to the drone fleet based on an absence of the malfunctioning drone and the one or more rescue drones; and transporting, by the one or more rescue drones, the malfunctioning drone to a safe landing location.

Owner:INTERNATIONAL BUSINESS MACHINE CORPORATION
Suspended load stability systems and methods
Load stability systems and methods for stabilizing swinging motions of suspended loads. The load stability systems include a fully automated, self-powered device that employs thrust to counteract and control lateral and rotational motion of an external load. The device is a temporary installment on the load, cable, or boom, and is agnostic to the platform from which it is suspended.

Owner:VITA INCLINATA IP HOLDINGS LLC
Work vehicle perception systems and rear modules
ActiveUS12181604B2Wave based measurement systemsPedestrian/occupant safety arrangementThermodynamicsVehicle driving
A rear perception module is utilized in conjunction with a work vehicle having a work vehicle cabin and a cabin roof. In an embodiment, the rear perception module includes an environmental depth perception (EDP) sensor system including a first EDP device having a field of view encompassing an environmental region to a rear of the work vehicle, a rear module housing mounted to an upper trailing edge portion of the cabin roof, and vents formed in exterior walls of the rear module housing to facilitate airflow through the rear module housing along a cooling airflow path. A heat-generating electronic component is electrically coupled to the first EDP device and positioned in or adjacent the cooling airflow path such that excess heat generated by the heat-generating electronic component is dissipated by convective transfer to airflow conducted along the cooling airflow path during operation of the rear perception module.

Owner:DEERE & CO
Machine room inspection robot
PendingCN111123981AAvoid damageExpand the scope of monitoringPosition/course control in three dimensionsDistance sensorsEngineering
Provided is a machine room inspection robot, comprising a robot body, propellers, supporting rods, a top protection plate, a protection ring, elastic pieces, a control part, distance sensors, connecting rods, walking wheels and rotating shafts. The robot body is an unmanned aerial vehicle of a circular structure when overlooked. Propellers are respectively arranged on two sides of the top of the robot body. A supporting rod is arranged at the top of the robot body. A top protection plate is arranged at the tops of the supporting rods. A protective ring is arranged on the periphery of the robotbody. The protection ring is connected with the robot body through an elastic piece, a distance sensor is arranged on the periphery of the top of the robot body, a control part is arranged in the robot body, the distance sensor is electrically connected with the control part through a cable, connecting rods are symmetrically arranged at the bottom of the robot body relative to the center line, and walking wheels are arranged at the bottom ends of the connecting rods. The robot has the advantages that the inspection mode that a traditional inspection robot can only shuttle and walk on the ground for inspection is changed, the moving range of the robot is not limited by ground obstacles, and certain flexibility is achieved.
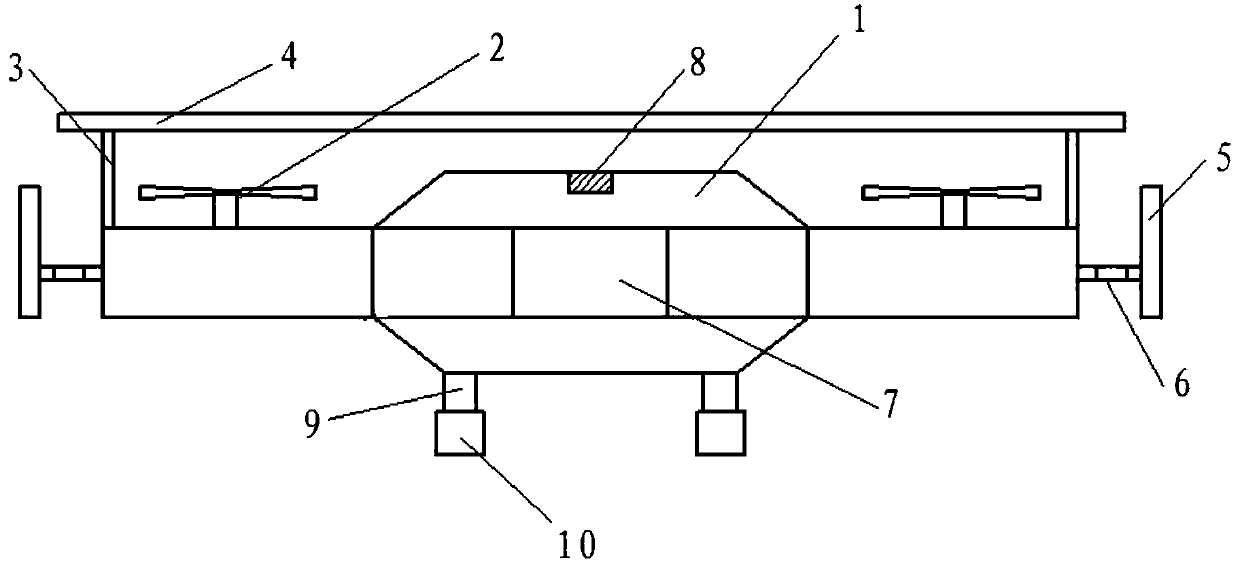
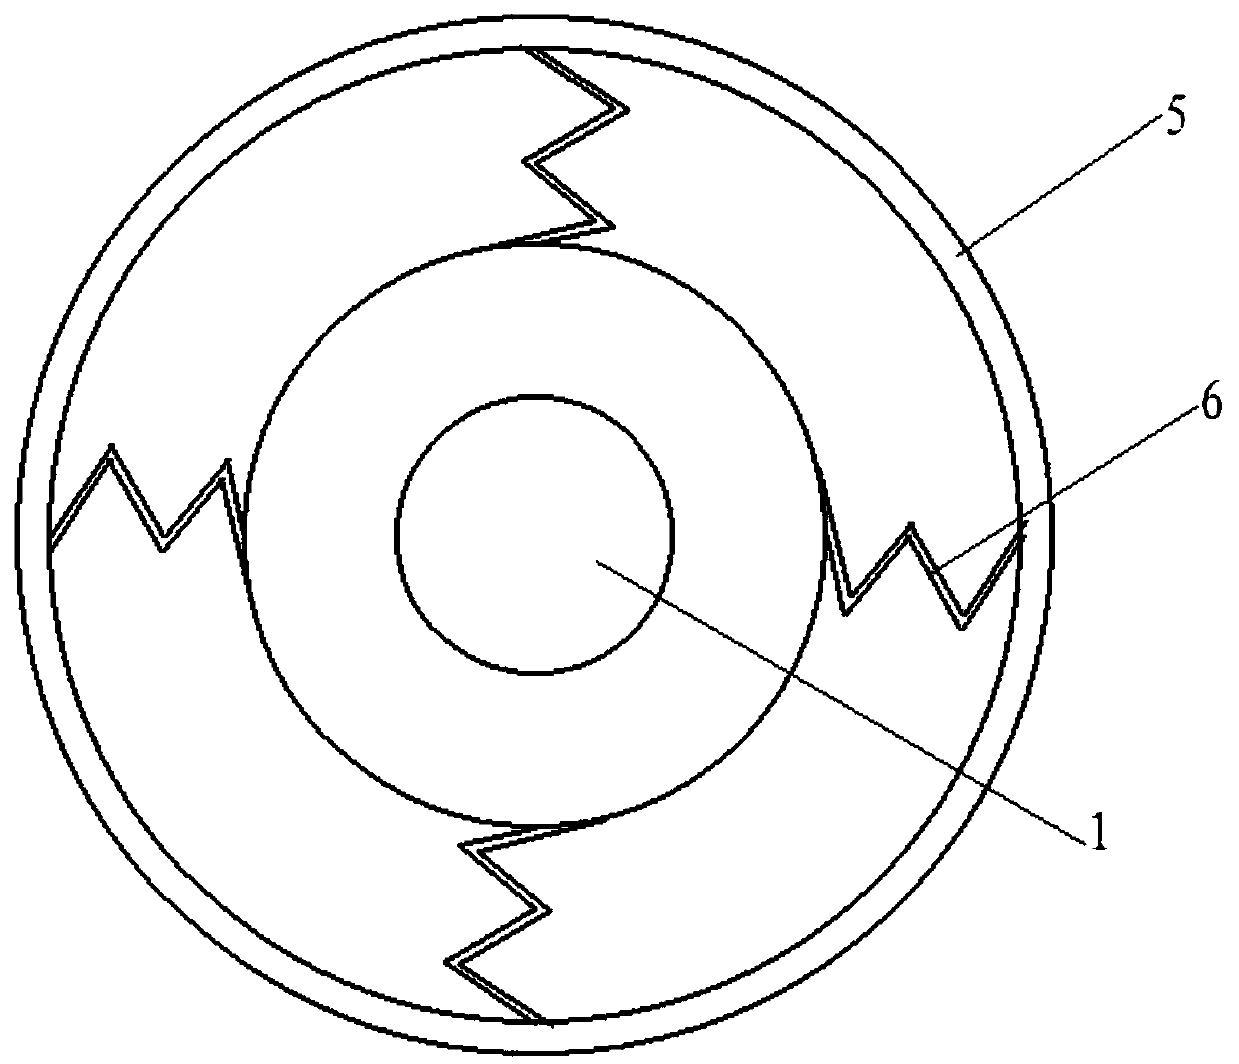
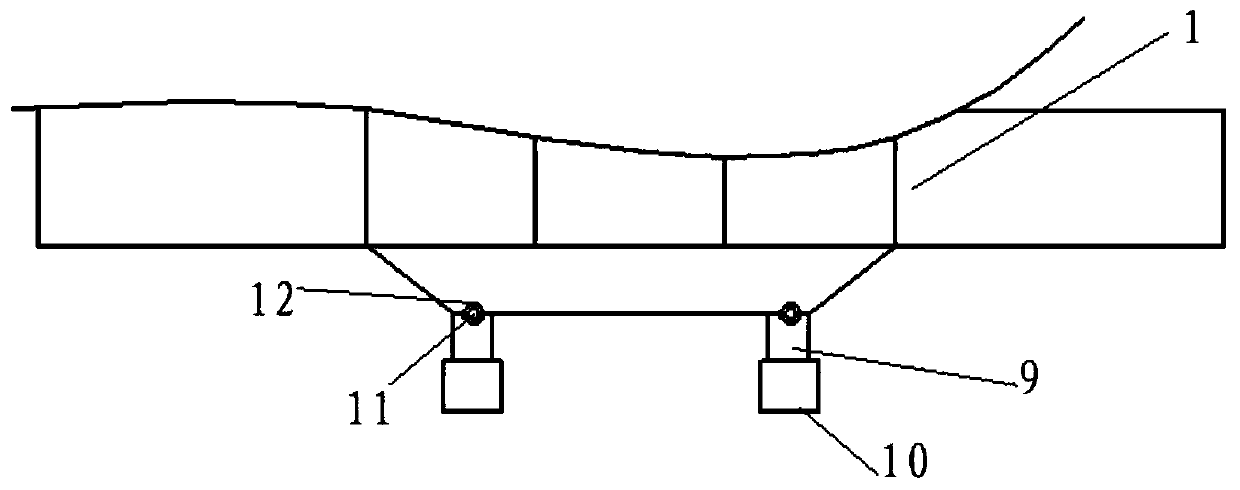
Owner:天津市远畅科技有限公司
3D scene reconstruction using multi-static cluster receivers
Various embodiments of the present technology relate to synthetic aperture radar image capturing and scene reconstruction using a cluster of multi-static satellite receivers. More specifically, in some embodiments, the cluster of receivers retrieves a flight path over a communication network. Flying in-formation, a lead or main satellite sends radio or wave pulses to a target area and additional satellites capture an echo of the wave pulses after the waves bounce off the target area to capture SAR radar data. The radar data can be transmitted from the cluster of satellites to a radar stations or to the main satellite. The radar stations or the main satellite receive the SAR radar data and mapping to reconstruct the data as SAR image data that can be reconstructed as 2D or 3D landscapes and scenes using the SAR image data.

Owner:R2 SPACE LLC
Automated Discovery and Monitoring of Uncrewed Aerial Vehicle Ground-Support Infrastructure
ActiveUS20240418530A1Navigation instrumentsPosition/course control in three dimensionsFlight vehicleGeolocation
A computing system in an infrastructure support network for uncrewed aerial vehicles (UAVs) may receive, from a UAV, aerial observation data of a ground-based cluster of charging pads for UAVs, the cluster comprising assets including the charging pads arranged in a layout and fiducial markers distributed across the layout. The aerial observation data may comprise position measurements of the UAV at aerial geolocations above the cluster, and vector positions of one or more assets with respect to the aerial geolocations. The computing system may generate a map graph from the aerial observation data, the map graph comprising (i) nodes corresponding to both the aerial geolocations and vector positions, and (ii) edges between pairs of selected nodes, the edges corresponding to distances between selected nodes and including measurement uncertainties. The computing system may generate a spatial map of cluster assets of the cluster by computationally optimizing the map graph.

Owner:WING AVIATION LLC
Route generation device, route generation method, and recording medium
InactiveUS20250029500A1Data processing applicationsNavigational calculation instrumentsSimulationUncrewed vehicle
To enable a route that satisfies a request of a user who operates an unmanned aerial vehicle to be presented in a style according to a predetermined format, the present invention involves: acquiring departure location information indicating the departure location of an unmanned aerial vehicle and destination location information indicating the destination location thereof; generating a plurality of candidate routes from the departure location to destination location of the unmanned aerial vehicle; executing processing for outputting route information indicating candidate routes that satisfy a predetermined condition among the plurality of generated candidate routes; and outputting the route information in a style that enables output of the routes, which are indicated by the candidate routes that satisfy the predetermined condition, according to the predetermined format.

Owner:NEC CORP
Work management system
InactiveJP2024173326AGuiding agricultural machinesPosition/course control in three dimensionsPositioning equipmentManagement system
To provide a work management system that causes an unmanned airplane to appropriately fly and also makes monitoring by the unmanned airplane easier.SOLUTION: A work management system according to one mode of an embodiment has: a plurality of working vehicles that works while performing reciprocal travelling by repeating a staring process and a turning process; an unmanned airplane that has a camera and is capable of flying around the plurality of working vehicles; and a monitoring device that communicates with the plurality of working vehicles and the unmanned airplane. The working vehicle includes a first positioning device that detects its own vehicle position information. The unmanned airplane includes a second positioning device that detects its own airplane position information. The unmanned airplane flies based on a history of the vehicle position information and the airplane position information in a manner such as to photograph a route at which the staring process ended and transmits a photographed image to the monitoring device in a case where the starting process performed by the working vehicle has ended.SELECTED DRAWING: Figure 8

Owner:ISEKI & CO LTD
Warehouse location numbering conversion for aerial inventory drone
ActiveUS20240418511A1Image analysisNavigational calculation instrumentsNumbering systemTransformation algorithm
A robotic control system may be configured to translate a first set of location coordinates based on a first location numbering system to a second set of location coordinates based on a unified location numbering system. A robotic control system may receive layout data of a warehouse, the layout data containing a plurality of location coordinates of racks and storage locations. The location coordinates may be of a first format based on the first location numbering system that is specific to the warehouse. The robotic control system may analyze the format of the location coordinates to select, from a plurality of candidate conversion algorithms, a suitable conversion algorithm to translate the plurality of location coordinates of the first format to a second format based on the unified numbering system. The robotic control system may store the translated location coordinates for use in generating a topometric map of the warehouse.

Owner:BROOKHURST GARAGE INC
Systems and methods for calculating refueling tanker boom 3D position for aerial refueling
Disclosed herein is methods, systems, and aircraft for performing image analysis for aiding refueling operations. A tanker aircraft includes a camera, a refueling boom, a camera configured to generate a two-dimensional (2D) image of the refueling boom, a processor, and non-transitory computer readable storage media storing code. The code is executable by the processor to perform operations including receiving the two-dimensional (2D) image from the camera, determining 2D keypoints of the refueling boom located within the 2D image based on a predefined point model of the refueling boom, determining a 6 degree-of-freedom (6DOF) pose using the 2D keypoints and the corresponding three-dimensional (3D) space 3D keypoints, optimizing 3D keypoints associated with moveable components of the refueling boom in response to a plurality of boom control parameters to produce optimized 3D keypoints, and estimating a position of a tip of the refueling boom based on the 6DOF pose.


Owner:THE BOEING CO
Data-analysis-based control optimization for hot-air balloon flight
Hot-air balloon flight is facilitated by obtaining a data-analysis-based control to selectively redirect the flight path of the hot-air balloon, where the hot-air balloon includes a positioning system to facilitate repositioning the hot-air balloon. The data-analysis-based control includes simulating a digital twin model of the hot-air balloon and one or more environmental conditions to potentially effect the hot-air balloon on a projected flight path, and based on the simulated digital twin model, forecasting presence of an adverse environmental condition to effect the hot-air balloon on the projected flight path. Further, the data-analysis-based control includes controlling the positioning system of the hot-air balloon to reposition the hot-air balloon onto a different flight path than the projected flight path to mitigate impact of the adverse environmental condition on the hot-air balloon.

Owner:INTERNATIONAL BUSINESS MACHINE CORPORATION
On-board redundant controller and standby aviation sensors in-flight reconfigurable autonomous flight system
ActiveUS20250138529A1Position/course control in three dimensionsPosition/direction controlAviationControl signal
The present invention relates to an on-board redundant controller and standby aviation sensors in-flight reconfigurable autonomous flight system, which includes UAV, primary autopilot module, secondary autopilot module and switching module. The primary autopilot module and secondary autopilot module are equipped with first aviation sensing module and second aviation sensing module. The primary autopilot module produces response signal according to the request signal produced by the secondary autopilot module. When the first response signal is no longer produced by the primary autopilot module for a preset time, the first switching module switches controls of the flight control module from the primary autopilot module to the secondary autopilot module, and the secondary autopilot module uses the aviation data of the second aviation sensing module to provide flight control signals to the flight control module.

Owner:NAT FORMOSA UNIV
Systems and methods for using reinforcement learning agents to track targets based on a reward including an information metric reward
An estimated target position is generated based on agent data received from an agent sensor system of a reinforcement learning (RL) agent and teammate data received from a plurality of teammate RL agents. An information metric reward is generated based on a confidence level associated with the estimated target position. The confidence level is based on the estimated target position and historical estimated target positions. A distance metric reward is generated based on an agent position and the estimated target position. A combined reward is generated based on the information metric reward and the distance metric reward. A movement action is generated for the RL agent based on the agent position, the estimated target position, and the combined reward in accordance with a multi-agent reinforcement learning (MARL) algorithm.

Owner:GENERAL DYNAMICS MISSION SYSTEMS INC
Unmanned aircraft control using engine torque control system
An aircraft control system includes a longitudinal control module, an engine torque control module, and an actuator control system. The longitudinal control module is configured to generate a desired torque value and a desired elevator position value for an aircraft based on a desired airspeed value, a desired altitude value, an actual airspeed value, and an actual altitude value. The engine torque control module is configured to generate a desired power lever position value based on the desired torque value and a measured engine torque value that indicates a measured engine torque in the aircraft. The actuator control system is configured to generate a power lever position command and an elevator position command for the aircraft based on the desired power lever position value and the desired elevator position value.

Owner:JOBY AERO INC
Information processing device, information processing method, and information processing system
ActiveJP2025050235APosition/course control in three dimensionsAircraft traffic controlInformation processingFlight time
To appropriately set an area where a flight device can fly.SOLUTION: An information processing device 1 sets a flight route of a flight device. The information processing device includes: a registration section 131 for registering performance or a purpose of usage of the flight device; a schedule acquisition section 132 for acquiring flight schedule data indicating a scheduled route for the flight of the flight device; a setting section 134 for setting an upper limit range of a flight possible area of the flight device based on the performance or the purpose of usage registered in the registration section 131; and an area determination section 135 for determining the flight possible area of the flight device based on the flight schedule data and the upper limit range.SELECTED DRAWING: Figure 4

Owner:KDDI CORP
Crane, and path generation system for crane
ActiveUS12172872B2Load-engaging elementsPosition/course control in three dimensionsControl engineeringPath generation
A crane in which a boom that is capable of derricking and extending / retracting is provided to a swiveling base includes: an operable-range-setting unit that sets an operable range in which a load being transported can be transported, the operable range being set according to the weight of the load; a path generation unit that generates, within the set operable range, a plurality of nodes through which the load can pass and a plurality of paths connecting adjacent nodes; and a transport path determination unit that determines a transport path of the load on the basis of a priority sequence for actuating a plurality of actuators of the crane, the transport path satisfying a prescribed condition, and being determined from the generated plurality of nodes and plurality of paths.

Owner:TADANO LTD
Aircraft survival kit glider
A supply glider is disclosed herein. The supply glider includes a body having a first end and a second end, the body being configured to be coupled to a host aircraft, a container disposed between the first end and the second end of the body, wings coupled to the body between the first end and the second end, and stabilators coupled to the body adjacent the second end.

Owner:ROCKWELL COLLINS INC
Building rooftop intelligence gathering and decision-support system and methods of augmented-reality supported building inspection
A building intelligence gathering, assessment and decision-support system including a GPS system deployed about the Earth and supporting a plurality of GPS satellites for transmitting GPS signals to the surface of the Earth. A building data sensor network, including a plurality of GPS-tracked rooftop-mounted sensors, are mounted on the rooftop surface of the building, and adapted for collecting GPS-indexed data specifying conditions on the rooftop surface at particular dates and times of the year. The building rooftop conditions includes one or more conditions selected from the group consisting of snow load conditions, windspeed and direction, and temperature. The system also includes one or more hand-held mobile augmented-reality (AR) based rooftop navigation and inspection devices, each configured for communication with communication servers within a data center over a wireless data communication network. Each hand-held mobile AR-based inspection device is capable displaying digital images of objects and scenery captured in its field of view (FOV) while the user is moving about the rooftop surface, along with graphical indications of GPS-tracked rooftop-mounted sensors collecting data regarding conditions on the building rooftop surface. By virtue of the present invention, users can now navigate building rooftops, inspect rooftop situations, identify where GPS-tracked rooftop-mounted sensors have been installed, and quickly determine where particular conditions have been automatically detected during rooftop inspections.

Owner:2KR SYSTEMS LLC
Multi-Payload Drone Delivery System and Method
Disclosed herein is an unmanned aerial vehicle (UAV) delivery system. The UAV, equipped for vertical takeoff and landing, has a specially designed external frame made of durable and lightweight materials. This frame can hold one or more internal frames, each tailored to store and selectively release packages. The delivery system also features a dynamic drop container that can automatically receive and store packages based on their identifiers, maintaining their temperature with an integrated regulation system. The invention further incorporates a mobile application, enabling users to track packages, interact with the system's components, and exercise limited control over the delivery process. Users can categorize deliveries based on urgency, with specific weight limits defined for each. Vendors prepare the items in specialized drone delivery packets, which can be configured to maintain specific temperatures. This UAV-based solution streamlines and elevates the package delivery process, offering flexibility, efficiency, and user engagement.

Owner:ALAM SOHAIL
Auxiliary data for controlling a satellite
The present disclosure relates to a method of generating auxiliary data for controlling a satellite travelling in orbit around Earth, the method comprising: receiving tracking data for the satellite; applying an orbit determination algorithm including: estimating an orbit for the satellite based on the tracking data; and predicting, based on the estimated orbit, future ephemerides data of the satellite; generating auxiliary data comprising predicted future ephemerides data; and transmitting the auxiliary data to the satellite for use in the satellite's attitude and orbit control.

Owner:ICEYE OY
Systems and Methods for Cloud Avoidance
Systems and methods for cloud avoidance are presented. For example, a computing system may be configured to obtain image data from a forward-looking sensor of a satellite, wherein the satellite is traveling along a current trajectory. The computing system may be configured to determine, using a model and based on the image data, an imaging target and cloud coverage associated with the imaging target. The computing system may be configured to determine a comparison between the cloud coverage associated with the imaging target and a threshold level of cloud coverage. The computing system may be configured to determine an updated trajectory for the satellite based on the current trajectory and the comparison. The computing system may be configured to generate one or more command instructions to control a motion of the satellite based on the updated trajectory.

Owner:PLANET LABS PBC
Acoustic positioning method and system
To provide an acoustic positioning method and a system that enable simultaneously position locations of a plurality of objects while eliminating cumbersome pre-processing as much as possible on the basis of an acoustic pulse a pinger transmits.SOLUTION: An acoustic positioning system 1 includes: a plurality of pingers 10 that transmits an acoustic pulse; a receiver 20 that positions a location of each pinger 10 on the basis of the acoustic pulse of the pinger. A cycle of a time slot transmitting the acoustic pulse is registered in a cycle setting part 101 of the pinger 10. The time slot cycle to be set to each pinger 10 is different from each other. Each pinger 10 is configured to transmit the acoustic pulse every time slot cycle. The receiver 20 mainly consists of a pulse reception unit 202, and a positioning unit 203, which are provided with at least three hydrophones 201. The positioning unit 203 is configured to calculate a direction and depth of each pinger 10 on the basis of the acoustic pulse each hydrophone 201 receives; and position the location of each pinger 10 on the basis of a calculation result.SELECTED DRAWING: Figure 1


Owner:KDDI CORP
Systems and visualization interfaces for orbital paths and path parameters of space objects
A display system can be configured to receive, via a user interface, a first identifier associated with a first space object and determine a first maneuver of the first space object. The first maneuver can include a perturbation of the path of the first space object. Based on the first identifier and the first maneuver, the display system can identify one or more path parameters associated with a path of the first space object and generate a display interface. The display interface can include a longitude-time graph having a longitude axis spanning from a lower-longitude limit to an upper-longitude limit and a time axis spanning from the lower-time limit to the upper-time limit and an indication of the one or more path parameters.

Owner:EXOANALYTIC SOLUTIONS INC
Technology for calculating stationary wind speed from a moving vehicle
ActiveUS20240427338A1Autonomous decision making processIndication of weather conditions using multiple variablesMobile vehicleAtmospheric sciences
A vehicle and / or fleet of vehicles that are equipped with: (i) a wind velocity detection device (for example, an ultrasonic wind velocity detection device); and (ii) a vehicle velocity detection device (for example, lidar or a speedometer and compass). Computer hardware performs two dimensional, or three dimensional, vector calculations in order to net out a stationary wind velocity from the measurements made at each vehicle. The computer hardware and software for performing the vector calculations and outputting stationary wind speed may be located in the vehicle or remotely from it (for example, at the headquarters of a weather prediction company).

Owner:INTERNATIONAL BUSINESS MACHINE CORPORATION
Defense system
To provide a defense system capable of photographing an intruder who enters a working area in a factory, a warehouse or the like.SOLUTION: A defense system 1 comprises a first unmanned flying body 100-1, a second unmanned flying body 100-2, a moving body 200, and a management device 300, with the first unmanned flying body 100-1 comprising a detection part for detecting an intruder X who enters a working area 10, the second unmanned flying body 100-2 comprising a photographing part for photographing the intruder X, and the moving body 200 comprising an illumination part for outputting a dazzling light for obstructing a visual field of the intruder X. When the first unmanned flying body 100-1 detects the intruder X, the management device 300 makes the moving body 200 output the dazzling light until the second unmanned flying body 100-2 photographs the intruder X.SELECTED DRAWING: Figure 1

Owner:MITSUBISHI LOGISNEXT CO LTD