

Patents
Literature
1176 results about "Joystick" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
A joystick is an input device consisting of a stick that pivots on a base and reports its angle or direction to the device it is controlling. A joystick, also known as the control column, is the principal control device in the cockpit of many civilian and military aircraft, either as a center stick or side-stick. It often has supplementary switches to control various aspects of the aircraft's flight.
Virtual Game Controller
A game controller can provide input to a video game played on a mobile computing device. Some games require a touch input on the touch screen of a mobile computing device, but a game controller may not have its own touch screen to receive and provide the required touch input. The game controller can be manually configured by a user of the game controller to convert an actuation of a control surface (e.g., a button, joystick, etc.) of the game controller to a touch screen input. However, this can be a very cumbersome and frustrating process for the user and has several limitations. The embodiments described herein can overcome this problem by providing a map that is automatically configured, without user configuration, to convert an input representing an actuation of the control surface into a touch screen input.

Owner:BACKBONE LABS INC
Custom TouchSync Editor for a Game Controller
A game controller can provide input to a video game played on a mobile computing device. Some games require a touch input on the touch screen of a mobile computing device, but a game controller may not have its own touch screen to receive and provide the required touch input. The game controller can be manually configured by a user of the game controller to convert an actuation of a control surface (e.g., a button, joystick, etc.) of the game controller to a touch screen input.

Owner:BACKBONE LABS INC
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
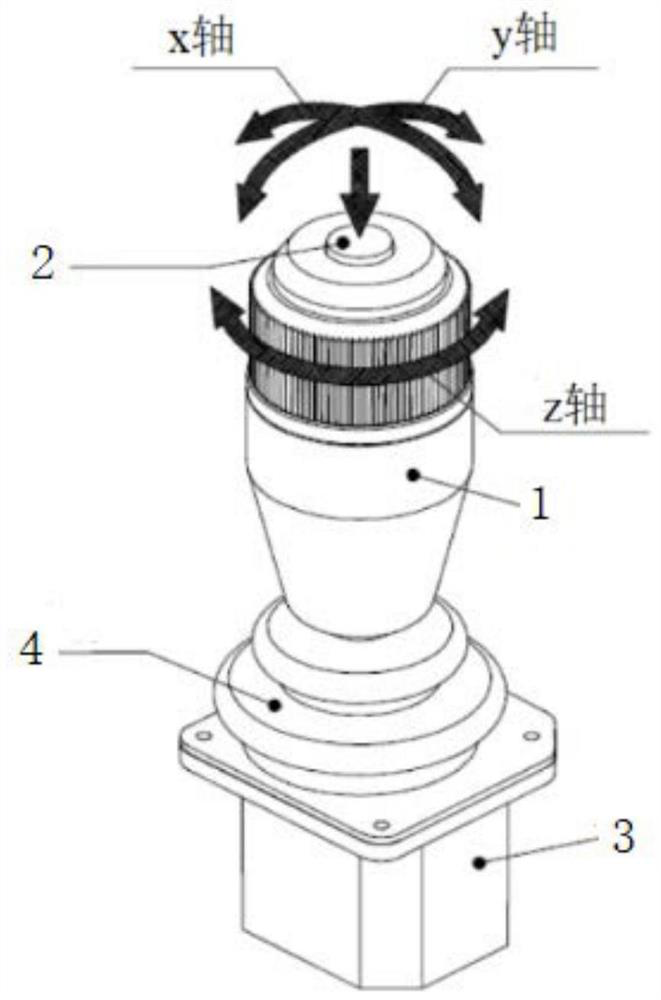
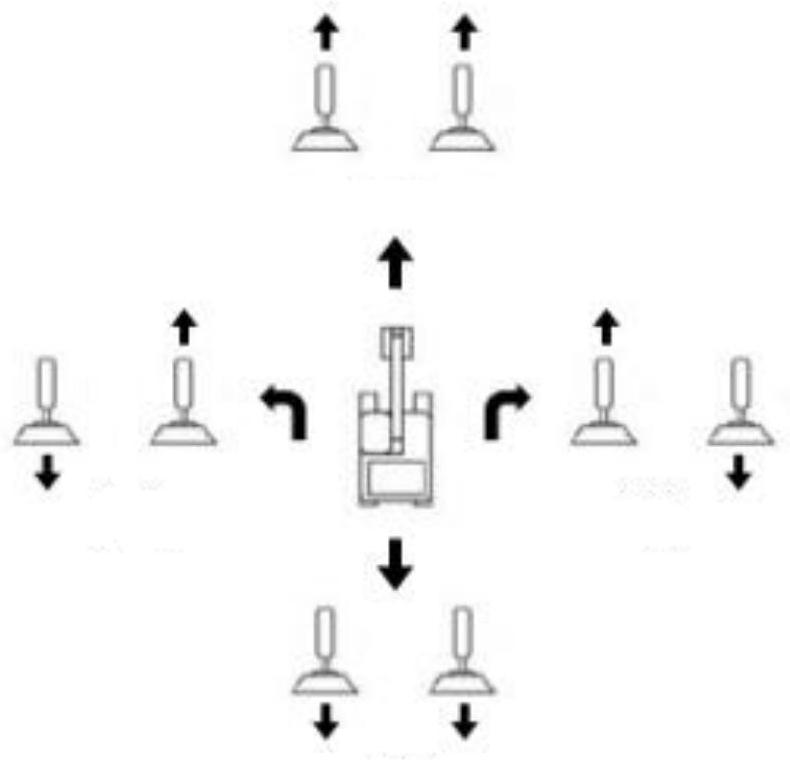
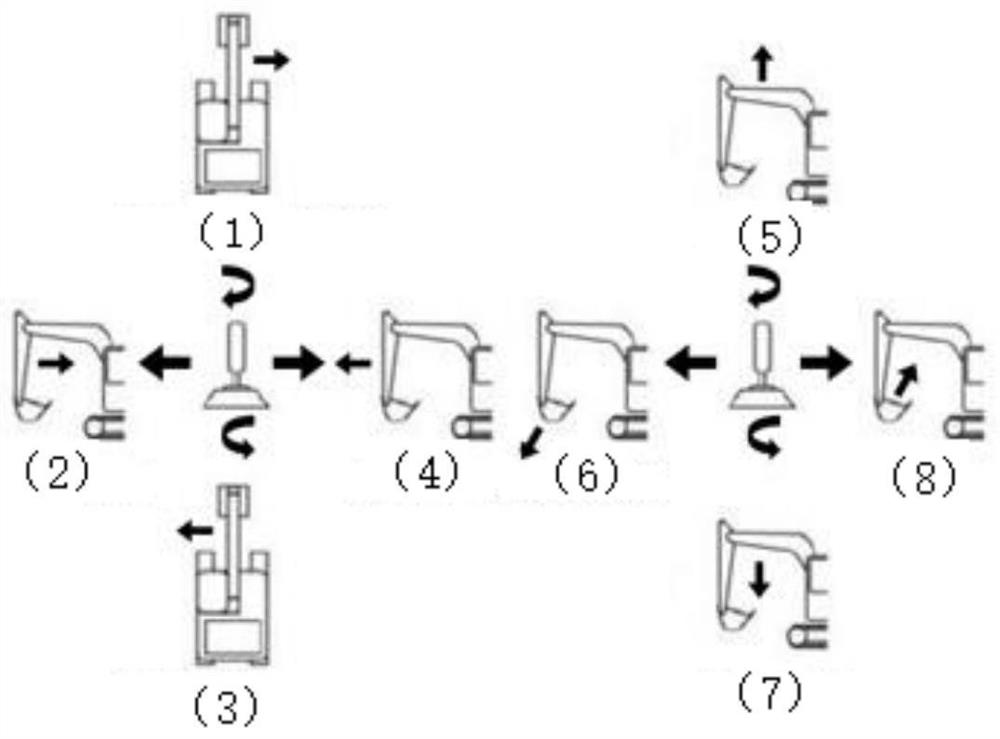
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Dynamic neutral position and boundary self-calibration method and system of joystick
The invention discloses a dynamic neutral position and boundary self-calibration method and system of a joystick, and belongs to the technical field of engineering machinery and mining equipment control, and the method comprises the following steps: S1, electrifying equipment, and selecting a mode; s2, calibrating a dead zone; s3, setting a threshold value; s4, data storage; and S5, exiting and applying. According to the dynamic median and boundary self-calibration method and system of the joystick, when the joystick works, a physical manipulated variable is converted into an original electric signal through a joystick sensing unit, then the original electric signal is received through a signal processing module and subjected to signal conditioning, and an analog signal is converted into a digital signal which can be processed by a microprocessor; all logical judgments are executed through the main control unit, a user issues an instruction through a user configuration interface and directly inputs the instruction to the main control unit, the main control unit and the nonvolatile memory carry out bidirectional data interaction to realize permanent storage and calling of dead zone parameters, and the main control unit generates a final control instruction to be output after processing all information. And the actuating mechanism is driven.

Owner:SHENZHEN XIAOLONG ELECTRIC CO LTD
Dry bag for game controller
A dry bag for game controllers is described. The dry bag may include one or more joystick protrusions that receive the joystick(s) of the game controllers to allow the user to move (and preferably rotate) the joystick(s) while the game controller is in the dry bag. The protrusion(s) may be surrounded by an accordion fold(s) that allows movement of the joystick protrusion(s) and joystick(s) in a 360 degree manner.

Owner:PATEL NAYAN ARVIND
Stick device
InactiveUS20240393822A1Manual control with multiple controlled membersManual control with single controlling memberJoystickMechanical engineering

Owner:COPAL CO LTD
Hall joystick
A Hall joystick is disclosed, including: a main body having a first side surface and a second side surface; a first side cap and a second cap that are respectively fixed to the first side surface and the second side surface; a first rotating member and a second rotating member that are rotatably connected to the first side cap and the second side cap, where each of the first and the second rotating member has a magnet; a stick partly received in the main body and having a lower end rotatably connected to the main body; a transmission member movably arranged in the main body and used to transmit a rotational motion from the stick to the first rotating member and the second rotating member; and a first Hall element arranged within the first side cap, and a second Hall element arranged within the second side cap.

Owner:SHENZHEN GULI TECHNOLOGY CO LTD
Reset sensitivity setting method of game joystick, gamepad and storage medium
The invention belongs to the field of game joystick reset, and discloses a reset sensitivity setting method of a game joystick, a gamepad and a storage medium. Comprising the steps that a key parameter set is designed, the reset sensitivity of the game joystick is judged, the state of the game joystick is obtained, and a corresponding program is started; carrying out primary processing on the real-time data set to obtain a quality-improved data set; if the state of the game joystick is noise abnormity, dynamic center point calibration is carried out by using a quality increase data set; if the state of the game joystick is sensor drift abnormity, signal filtering and noise suppression are carried out by using a quality-increasing data set; if the state of the game joystick is that the response speed is abnormal, signal prediction compensation is carried out by using the quality increase data set; and if the rocker is recognized to return to the ideal center point, the maintenance processing is stopped, and if the rocker is recognized not to return to the ideal center point, the above steps are repeated until the rocker returns to the ideal center, and sensitivity adjustment of game rocker resetting is achieved.

Owner:SHENZHEN JIERUIHONG ELECTRONICS CO LTD
Joystick mechanism and gamepad
A joystick mechanism and a game pad are provided. The joystick mechanism includes a mounting base, a circuit board, a first rocker assembly, and a second rocker assembly. The circuit board is disposed in the mounting base, and the circuit board includes a first sensor and a second sensor. The first rocker assembly includes a first rocker and a first sensing component, and the first rocker assembly is capable of swinging around a first direction to drive the first sensing component to swing with respect to the first sensor. The second rocker assembly includes a second rocker and a second sensing component, the second rocker assembly is capable of swinging around a second direction to drive the second sensing component to swing with respect to the second sensor, the second direction is perpendicular to the first direction.

Owner:SHENZHEN GULI TECHNOLOGY CO LTD
Flight training system
The invention relates to the technical field of flight training, in particular to a flight training system. The flight joystick receives operation action data input by a target user based on a preset training instruction; the button control table receives button action data input by a target user based on a preset training instruction; the electronic equipment receives parameter setting data which is input by a target user based on a preset training instruction and is used for setting flight parameters; the multi-axis gravity seat performs six-degree-of-freedom movement based on the operation action data, the button action data and the parameter setting data so as to simulate the flight attitude of the aircraft; and the electronic equipment generates a target virtual driving scene based on the operation action data, the button action data and the parameter setting data, and controls the dynamic scene display equipment to display the target virtual driving scene. The target virtual driving scene is combined with the actual operation process. And the training effect is improved in the flight training process.

Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Rocker output and shaft self-correction device and method of unmanned aerial vehicle control terminal
PendingCN120578156AVehicle position/course/altitude controlPosition/direction controlInformation processingJoystick
The invention discloses a rocker output and shaft self-calibration device and method of an unmanned aerial vehicle control terminal, the rocker output and shaft self-calibration device is composed of a rocker information acquisition unit, a rocker signal processing unit and a characteristic parameter storage unit, and zero calibration and extreme value calibration are executed when a rocker is started each time. After the rocker is calibrated, the information processing unit stores special parameters such as the zero position and the extreme value of the rocker into the data storage unit, and the special parameters are used for follow-up rocker processing including amplitude limiting, filtering, dead zone processing and output mapping. The device can reduce the drifting of the output result of the rocker caused by the aging of a rocker device, the voltage attenuation of a control terminal and the continuous friction loss between the mechanical structures of the rocker. The calibration device has no special requirements on rocker types, can be basically suitable for various rockers, is a rocker output and self-calibration device of an unmanned aerial vehicle control terminal with a self-calibration function and good universality, and can realize miniaturization, low cost and fitting engineering practice as much as possible by selecting a proper MCU (Microprogrammed Control Unit) chip.

Owner:XIAN MODERN CONTROL TECH RES INST
QAR data-based main pilot effective manipulation analysis method and system
ActiveCN120196963ACosmonautic condition simulationsRegistering/indicating working of vehiclesJoystickFlight training
The invention provides a QAR data-based main pilot effective manipulation analysis method and system, and belongs to the technical field of flight training. Comprises: acquiring flight decoding data; performing initialization correction on the joystick force in the flight decoding data, and limiting a data analysis range; constructing a control stick data analysis logic, and executing the control stick data analysis logic in a limited data analysis range to analyze the initialized and corrected control stick force so as to judge whether the main pilot is effectively manipulated or not; matching the flight decoding data with the task book information to judge whether the control rate of the main pilot reaches the standard or not; and according to the effective control of the main pilot and the standard control rate, the actual effective control condition of the main pilot is judged. The method can accurately quantify the manipulation performance of the pilot and the flight condition of the captain of the instructor, and provides scientific guidance for the evaluation of the driving level of the pilot.

Owner:SHANDONG AIRLINES CO LTD
Multi-player claw machine
A multi-player claw machine includes a coin slot, a first controller, a second controller, a third controller, and a fourth controller. The first controller has a first joystick configured to actuate a first claw unit. The second controller has a second joystick configured to actuate a second claw unit. The third controller has a third joystick configured to actuate a third claw unit. The fourth controller has a fourth joystick configured to actuate a fourth claw unit. The coin slot is connected to a coin acceptor. The coin acceptor is able to generate a playable value. Any one of the first controller, the second controller, the third controller and the fourth controller can be actuated to play a game.

Owner:FA TENG TECH CO LTD
Virtual object control method and apparatus, terminal, and storage medium
A virtual object control method is described. A skill type of a skill is obtained in response to a first click / tap operation on a skill control. In response to determining that the obtained skill type of the skill is a target skill that supports selecting a casting position based on a screen click / tap, a castable region of the skill in a virtual scene is displayed according to a position where a controlled virtual object is located and a casting range of the skill. In response to a second click / tap operation in the castable region, the controlled virtual object is controlled to cast the skill at a casting position indicated by the second click / tap operation. Thus, a complex drag operation based on a wheel virtual joystick need not be performed, simplifying the operation of accurate aiming by a user. Apparatus and non-transitory computer-readable counterpart embodiments are also provided.

Owner:TENCENT TECHNOLOGY (SHENZHEN) CO LTD
Operating panel for a three-dimensional measuring machine
This product is used by connecting it to a three-dimensional measuring machine, and the three-dimensional measuring machine is driven by operating a touch panel display, joystick, and various knobs provided on the flat surface.


Owner:MITUTOYO CORP
Intelligent efficient vertical axis wind turbine with variable flaps and propeller pitches
An intelligent efficient vertical axis wind turbine with variable flaps and propeller pitches comprises blades, blade sliding rings, a main body sliding ring, a motor, a connecting rod, a connecting disc, an intermediate shaft, a motor connecting shaft and a rolling bearing. The blade comprises a flap, a flap connecting rod, a connecting rod, a rudder arm, a steering engine, a blade shaft and a blade front part, wherein the flap, the flap connecting rod, the connecting rod, the rudder arm and the rudder mechanism form a parallelogram-shaped connecting rod mechanism; the steering engine is a driving rocker, rotates by a certain angle under the driving of electric power, and can drive a driven rocker composed of a flap and a flap connecting rod to rotate by a certain angle. The invention further provides a method for controlling the variable flaps of the vertical axis wind turbine through the deep reinforcement learning algorithm. According to the invention, the pitching moment generated after the flap is driven by the steering engine to deflect is indirectly regulated and controlled. Under driving of methods such as deep reinforcement learning, the flap angle can be intelligently adjusted in a closed-loop mode along with the rotor phase and the incoming flow direction, and real-time optimization of the lift resistance and the direction of the blade is achieved.

Owner:AIR FORCE UNIV PLA
Concrete drum control, property prediction, and monitoring systems and methods
A concrete mixer vehicle includes a chassis, a cab, a drum system, and a control system. The drum system includes a mixer drum coupled to the chassis and a drum driver configured to rotate the mixer drum. The control system includes an operator interface disposed within the cab and one or more processing circuits. The operator interface includes a display and a joystick. The one or more processing circuits have programed instructions to control the display to provide a graphical user interface. The graphical user interface provides a graphical representation of the mixer drum, a settings button, a temperature output, a pressure output, a slump output regarding a slump of contents within the mixer drum, a speed output regarding a rotational speed of the mixer drum, a revolution counter regarding a number of revolutions of the mixer drum, and a mode indicator regarding an operational mode of the drum system.

Owner:OSHKOSH CORPORATION
Flying vehicle
ActiveUS12182336B2Input/output for user-computer interactionAircraft componentsJoystickFlight vehicle
A transport method includes providing a cab having a moveable actuator coupled to the propulsion unit to move the propulsion unit between a first position above the cab during take-off and a second position during lateral flight; receiving a hand control from a controller or stick, and flight data captured by a plurality of cameras or sensors, wherein hand grip or movement represents a control request; and determining control options based on a current state of the control request and the environment of the cab.

Owner:TRAN HA
Hall joystick
PendingUS20250231576A1Manual control with multiple controlled membersVideo gamesJoystickHall element
A Hall joystick includes: a main body having a first side surface and a second side surface; a first side cap and a second cap that are respectively fixed to the first side surface and the second side surface; a first rotating member and a second rotating member that are rotatably connected to the first side cap and the second side cap, each of the first rotating member and the second rotating member having a magnet; a stick partly received in the main body and having a lower end rotatably connected to the main body; a transmission member movably arranged in the main body and configured to transmit a rotational motion from the stick to the first rotating member and the second rotating member; and a first Hall element arranged within the first side cap, and a second Hall element arranged within the second side cap.

Owner:SHENZHEN GULI TECHNOLOGY CO LTD
Multifunctional earphone charging case and control method therefor, and terminal control system
The present disclosure provides a multifunctional earphone charging case configured with a charging case mode, a joystick mode and a mouse mode, and comprises: a case body; a charging module provided in the case body; a sensor module provided on the case body; a user inputting module provided on the case body; a main controller electrically connected to the charging module, the sensor module and the user inputting module respectively, the main controller is configured for controlling the charging module, the sensor module, and the user inputting module to work according to a mode selection signal triggered by a user, such that the multifunctional earphone charging case works in at least of the following modes: the charging case mode, the joystick mode, and / or the mouse mode.

Owner:GOERTEK INC
Joystick fastening device
The present invention discloses a joystick fastening device and a joystick application assembly, comprising the components: an reception cavity whose one end has a joystick receiving opening; a connection, of which one end opposite to the reception cavity shell has a first connecting portion; and an extension having a second connecting portion and connected with the first connecting portion via the second connecting portion to realize the special movement of the joystick via the extension. The present invention can prevent the joystick from releasing, significantly reduce shake-off of the joystick, and provide better gaming experience.

Owner:WU JINHONG
Configuration-variable tandem helicopter cockpit
ActiveCN119408691Areduce iteration timeImprove efficiencyFuselage framesSeating arrangementsJoystickStructural engineering
The invention discloses a serial helicopter cockpit with a variable configuration. A front cabin and a rear cabin are sequentially arranged from front to back to form a serial structure; the rear cabin floor is erected and installed through a rear cabin structural framework and a rear cabin wall plate in the rear cabin windshield assembly, so that the height of the rear cabin floor is adjusted, and the rear cabin floor is higher than the front cabin floor. The front cabin windshield assembly, the front cabin instrument assembly and the rear cabin instrument assembly are adjustable in the height direction and the heading direction, the rear cabin floor and the rear cabin windshield assembly are adjustable in the height direction, and the front cabin seat and the rear cabin seat are adjustable in the height direction and the heading direction. Control boards and control lever systems in the front cabin control assembly and the rear cabin control assembly are adjustable; by adjusting the height, front-back position or roll angle of each component in the tandem helicopter cockpit, the tandem helicopter cockpit is placed in a to-be-assessed configuration for implementation of assessment. According to the method, the problem that instance evaluation and onboard verification are difficult to perform on the appearance of the cockpit and the arrangement of cockpit equipment at the initial stage of design is solved.

Owner:CHINA HELICOPTER RES & DEV INST
Flight control device, aircraft control method and vertical take-off and landing aircraft
ActiveCN119284148AEasy to operatereduce complexityActuated personallyRotocraftJoystickControl vector
The invention discloses a flight control device, an aircraft control method and a vertical take-off and landing aircraft, and relates to the technical field of aircraft control. The first joystick is configured to receive manipulation information input by a pilot; the second joystick is configured to receive manipulation information input by a pilot; and the processor is configured to generate a vector control instruction by using a signal corresponding to the control information received from the first control rod and / or the second control rod and combining a preset control mapping relation, and control the aircraft to perform vector motion according to the vector control instruction. And when the vector control instruction is an aircraft course control instruction, controlling the aircraft to perform yawing motion at least through tilt angle differential control and / or rotor speed differential control and / or lifting rudder deflection. According to the scheme, the control complexity of the aircraft can be effectively reduced, and then the operation burden of a pilot is relieved.

Owner:SICHUAN AEROFUGIA TECH DEV CO LTD
Low-cost transportable system for UUV path planning and control experiment
PendingCN120986640AVehicle position/course/altitude controlUnderwater vesselsTelecommunications linkJoystick
The invention discloses a low-cost transportable system for UUV path planning and control experiments. The low-cost transportable system comprises a shore-based unit, a buoy unit, an underwater vehicle unit, a zero-buoyancy cable and a software stack, the UWB tag, the router, the GNSS and the rocker receiver are integrated in the buoy, a sealing waterproof design is adopted, and the buoy can stably float on the water surface and is in wired connection with the underwater vehicle through the zero-buoyancy cable; the three-dimensional position of the underwater vehicle is obtained, the upper computer and the UWB base station are deployed on a shore base, the upper computer interacts the calculated position with the router in the buoy through wireless communication, and a stable and efficient communication link is constructed. The system can be quickly arranged in indoor and outdoor environments, supports closed-loop path planning and control experiments, can effectively replace expensive USBL or indoor dynamic capturing and positioning systems, remarkably reduces experiment cost, and improves experiment flexibility and portability.

Owner:HARBIN ENG UNIV
Pod aiming simulation method and system in army unmanned aerial vehicle simulation system
The invention provides a pod aiming simulation method and system in an army unmanned aerial vehicle simulation system. The nacelle aiming simulation method in the army unmanned aerial vehicle simulation system comprises the following steps: acquiring a real-time angle of a nacelle turret by using the control quantity of an operating lever of an unmanned aerial vehicle and the angular rate of the turret; the rotation of the turret is driven in real time by using the longitude and latitude height parameters of the target object and the longitude and latitude height and attitude angle data of the unmanned aerial vehicle; and laser ranging operation is carried out through a dichotomy method, and laser ranging operation is completed. The system comprises modules corresponding to the steps of the method.

Owner:BEIJING LINGWEI JUNRONG TECH CO LTD
Configurable dead zone-based joystick control precision improvement method and system
The invention discloses a method and a system for improving the control precision of a control lever based on a configurable dead zone, and relates to the field of electronic control and signal processing, and the method comprises the following steps: carrying out median calibration sampling, precisely obtaining an electrical median value, and temporarily storing a calculation result; boundary calibration sampling is carried out, a rocker is pushed to the limit position in sequence, and the maximum value and the minimum value of an original ADC are monitored and updated in real time; calculating and storing calibration parameters, calculating proportionality coefficients and offset key parameters of an X axis and a Y axis by utilizing the temporarily stored median value and boundary value in combination with a target output range, and generating and solidifying mapping parameters; and writing the parameters into FLASH: permanently storing the finally calculated calibration parameters into a nonvolatile memory FLASH. According to the control lever control precision improving method and system based on the configurable dead zone, the output data of the control lever caused by abrasion and aging can be stabilized within the range specified by a standard protocol again without disassembling equipment and special tools, the full-stroke control capability of the control lever is recovered, and control hidden dangers are eliminated.

Owner:SHENZHEN XIAOLONG ELECTRIC CO LTD
Fatigue detection and operator alert system
A fatigue detection and operator alert system is disclosed for detecting operator fatigue in a machine having a cab, a seat, and a joystick. The fatigue detection and operator alert system comprises an optic sensor positioned non-obstructively facing an operator and configured to output a first signal consisting of images captured of an operator; a pressure sensor configured to provide a second signal indicative of a pressure of an operator hand on the joystick; a thermal sensor configured to provide a third signal indicative of a temperature of the operator; a load sensor configured to provide a fourth signal indicative of a load of an operator foot; and a controller configured to: receive the sensor signals; detect instances of operator fatigue based on the received sensor signals during non-hauling operation; and actuate an alert device to alert the operator when instances of operator fatigue are detected.

Owner:CATERPILLAR INC
Procedural animation engine and editor for sample-based design of stylized walking gaits for bipedal robots
A robot design and control system including a procedural animation engine and a graphical animation editor that enable animators to author stylized walking gaits achievable by physical robotic characters, including bipedal robots of varying design. The animation engine generates dynamically feasible reference trajectories for omnidirectional walking given a desired walking velocity that may be input from a joystick or an artificial intelligence (AI) planner. This allows a legged robot to walk along an arbitrary path while expressing a custom animation “style,” e.g., a happy walk, a sneaky walk, or other manner of walking. The stylized walking motion or gait is generalized by the animation engine from a small number of animation samples that are defined at key walking velocities and tracked using a whole-body controller. The set of samples that are used as input to define a walking style is authored by an animator using the animation editor.

Owner:DISNEY ENTERPRISES INC
Fixed horizontal tail type fly-by-wire aircraft leveling control law design method
ActiveCN119225230Aassurance controlavoid mutationProgramme controlComputer controlJoystickControl engineering
The invention provides a fixed horizontal tail type fly-by-wire aircraft leveling control law design method, which comprises the following steps of: when an aircraft meets a condition of entering a leveling control law, recording a flight control law integral channel instruction ELNMINT at a triggering moment; generating an elevator control command component ELFLAREFWD through a forward command shaping module based on the joystick displacement signal; the method comprises the following steps: introducing an integral channel instruction ELNMINT into a leveling control law, and obtaining a bias instruction component ELFLAREOFFSET under the leveling control law after the integral channel instruction ELNMINT passes through an instruction amplitude limiting module; subtracting the bias instruction ELFLAREOFFSET from the integral channel instruction ELNMINT to obtain an instruction initial value ELFLAREFADER0 which needs to be faded during instruction transition; after the instruction initial value ELFLAREFADER 0 passes through a desalting device module, a real-time control surface control instruction component ELFLAREFADER is formed; and an elevator control instruction ELCMD under the leveling control law is obtained. According to the method, the switching transient state can be reduced by introducing the flight control law integral channel instruction component into the leveling control law, and the method has remarkable advantages in the aspects of improving the flight safety, optimizing the flight quality, enhancing the system flexibility, improving the automation level and the like.

Owner:AVIC GENERAL HUANAN AIRCRAFT IND CO LTD
Civil helicopter instrument longitudinal static stability verification flight test method
The invention belongs to the technical field of airworthiness verification of aircrafts, and particularly relates to a test flight method for verifying longitudinal static stability of a civil helicopter instrument. Comprising the following steps: S1, determining a relation between a longitudinal control lever force and a longitudinal control position of a control lever; s2, verifying the longitudinal joystick force gradient of the acceleration section of the helicopter through a flight test; s3, verifying the longitudinal joystick force gradient of the helicopter deceleration section through a flight test; s4, verifying the balancing speed recovery characteristic of the acceleration section of the helicopter through a flight test; and S5, verifying the balancing speed recovery characteristic of the deceleration section of the helicopter through a flight test.

Owner:CHINA HELICOPTER RES & DEV INST