
A Rotor Position Estimation Method for Permanent Magnet Direct Drive Wind Turbines
A wind turbine and rotor position technology, which is applied in the direction of generator circuit layout control, generator control, motor generator control, etc., can solve the problem of low rotor position estimation accuracy, and achieve faster system response speed and high rotor position estimation. accuracy, the effect of accurate rotor position estimation
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2022-05-13
Smart Images
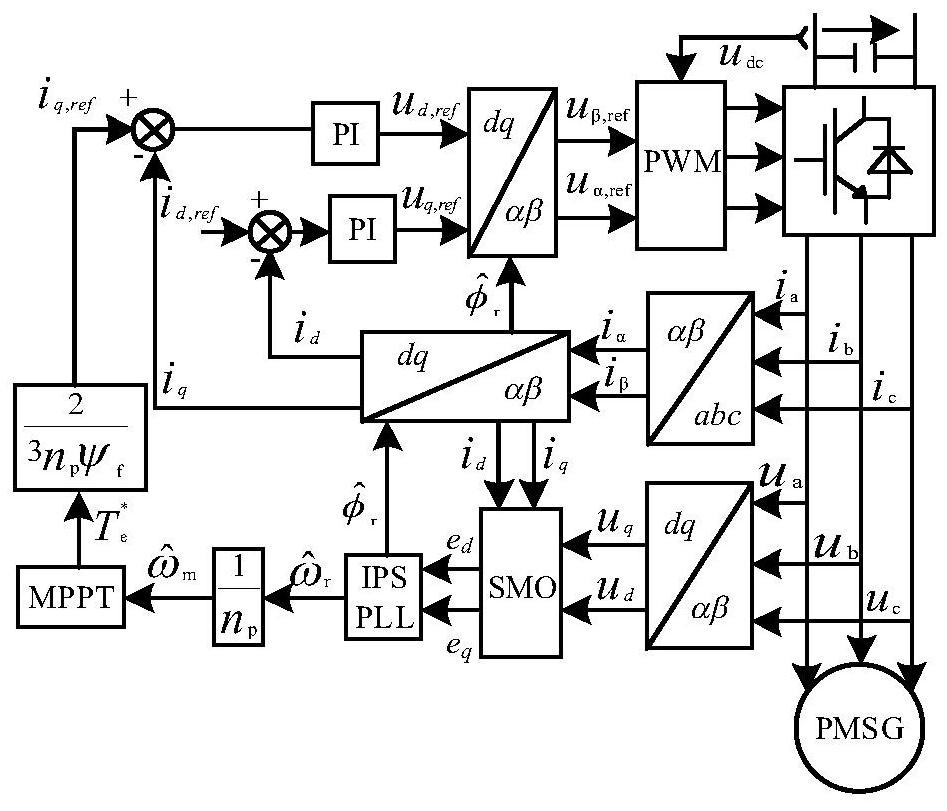
Figure 1 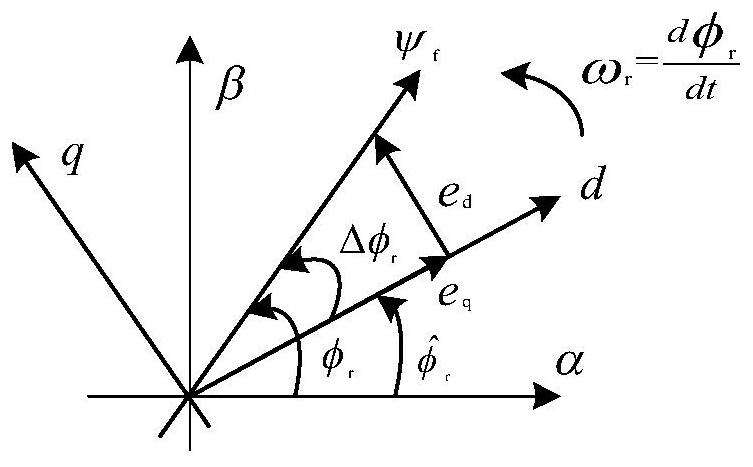
Figure 2 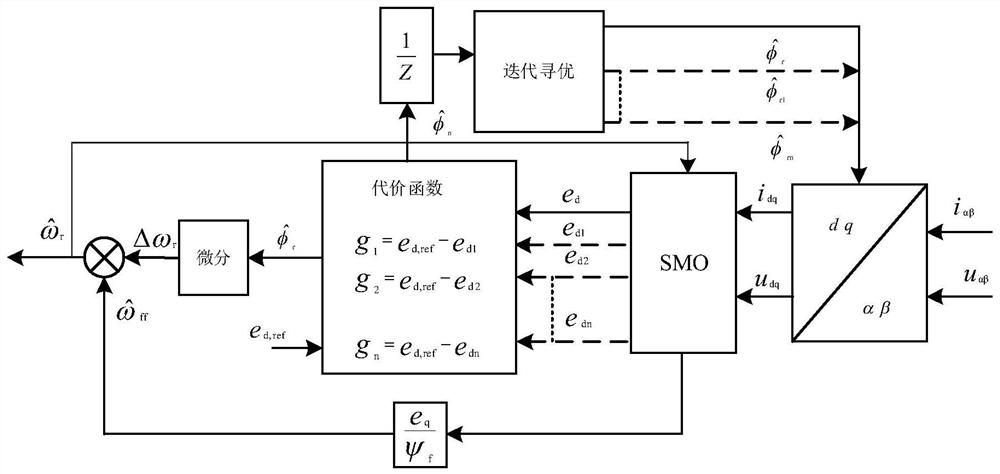
Figure 3
Abstract
Description
technical field
[0001] The content of the present invention relates to a method for estimating the rotor position of a permanent magnet direct drive wind power generator, which can realize accurate estimation of the rotor position of the permanent magnet wind power generator. It can be used to improve the maximum wind energy capture of the wind power generation system and realize the precise control of the machine-side converter of the permanent magnet wind power generator. Background technique
[0002] In the study of wind power generation, researchers at home and abroad hold a positive attitude towards partial curtailment of wind to maintain the output stability of the wind power generation system. Then the maximum wind energy capture in the wind power generation system has become an important factor that can reduce the curtailed wind volume but still maintain the output stability of the power system; and the precise control of the machine-side converter will bring a relat...
Examples
Embodiment Construction
[0034] The permanent magnet synchronous wind turbine is connected to the machine-side full-power back-to-back converter, and connected to the grid through the DC bus and the grid-side converter. The machine-side converter is used to realize the maximum power tracking (MPPT) of the permanent magnet synchronous wind turbine. . By sampling the voltage u αβ and current i αβ The dq-axis voltage and current are obtained through coordinate transformation, the counter electromotive force is calculated by the sliding mode observer, and the rotational speed is estimated by the IPS-PLL method. by omega r =n p ω m will estimate the rotational speed Converted to actual mechanical speed ω m . Then calculate the reference torque where the constant k p is the maximum wind energy capture coefficient. The control loop consists of adjusting the d-axis and q-axis currents of the PMSG, and the d-axis reference current i d,ref Set to 0, use the reference torque to calculate the q-axis ...