
Collaborative robot modular joint
A technology of modular joints and robots, which is applied in the direction of manipulators, manufacturing tools, joints, etc., can solve the problems of difficult wiring of the external drive of the servo drive board, low machining accuracy of the input shaft of the reducer, and high professional level of debugging personnel, and achieves Ease of after-sales maintenance, reduction of brake heat, and compact structure
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2018-10-16
Smart Images
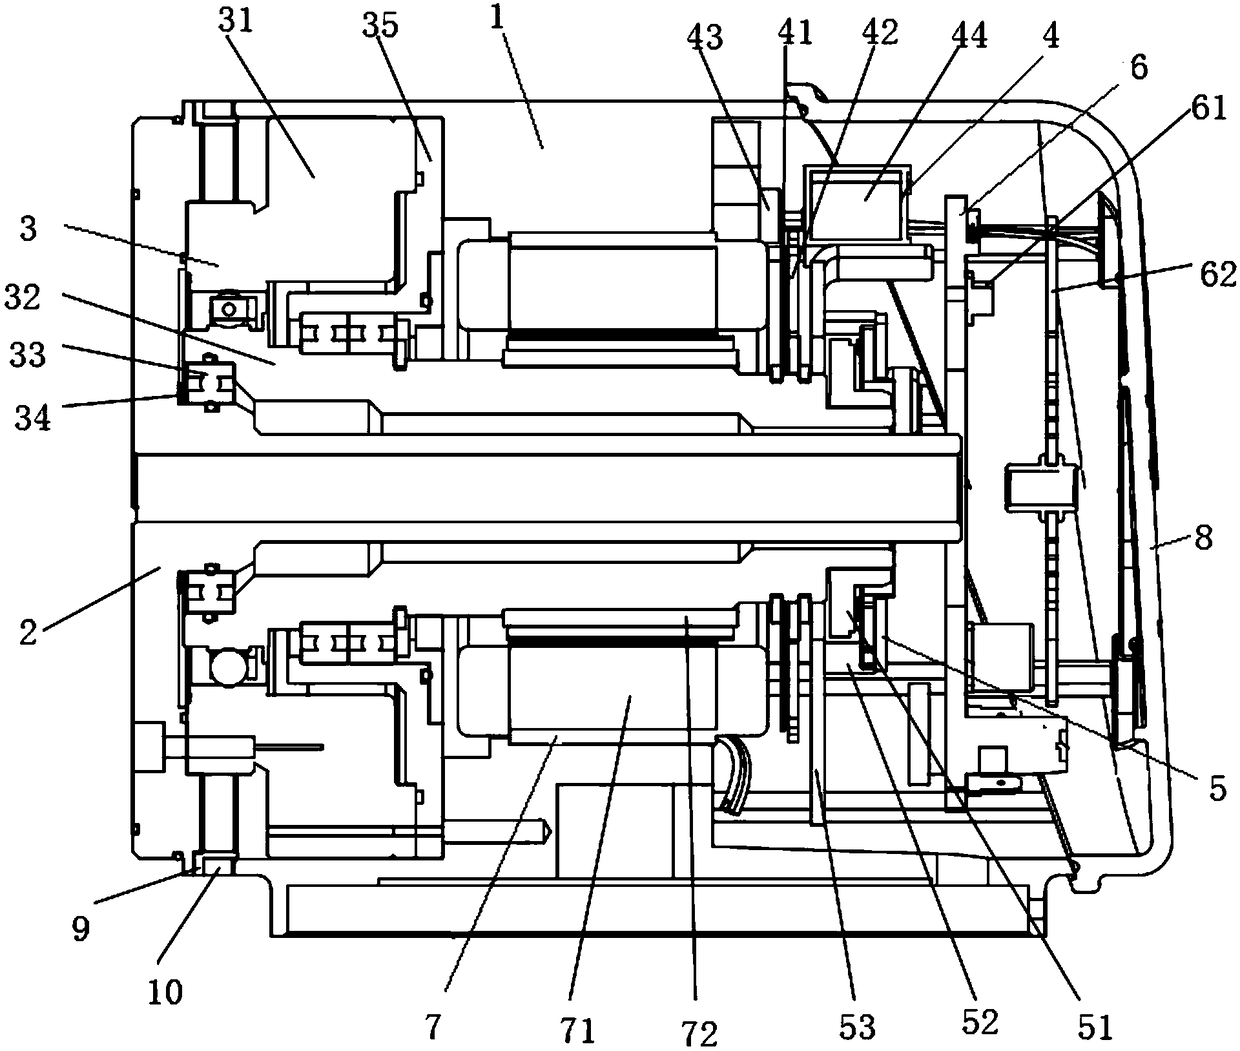
Figure 1 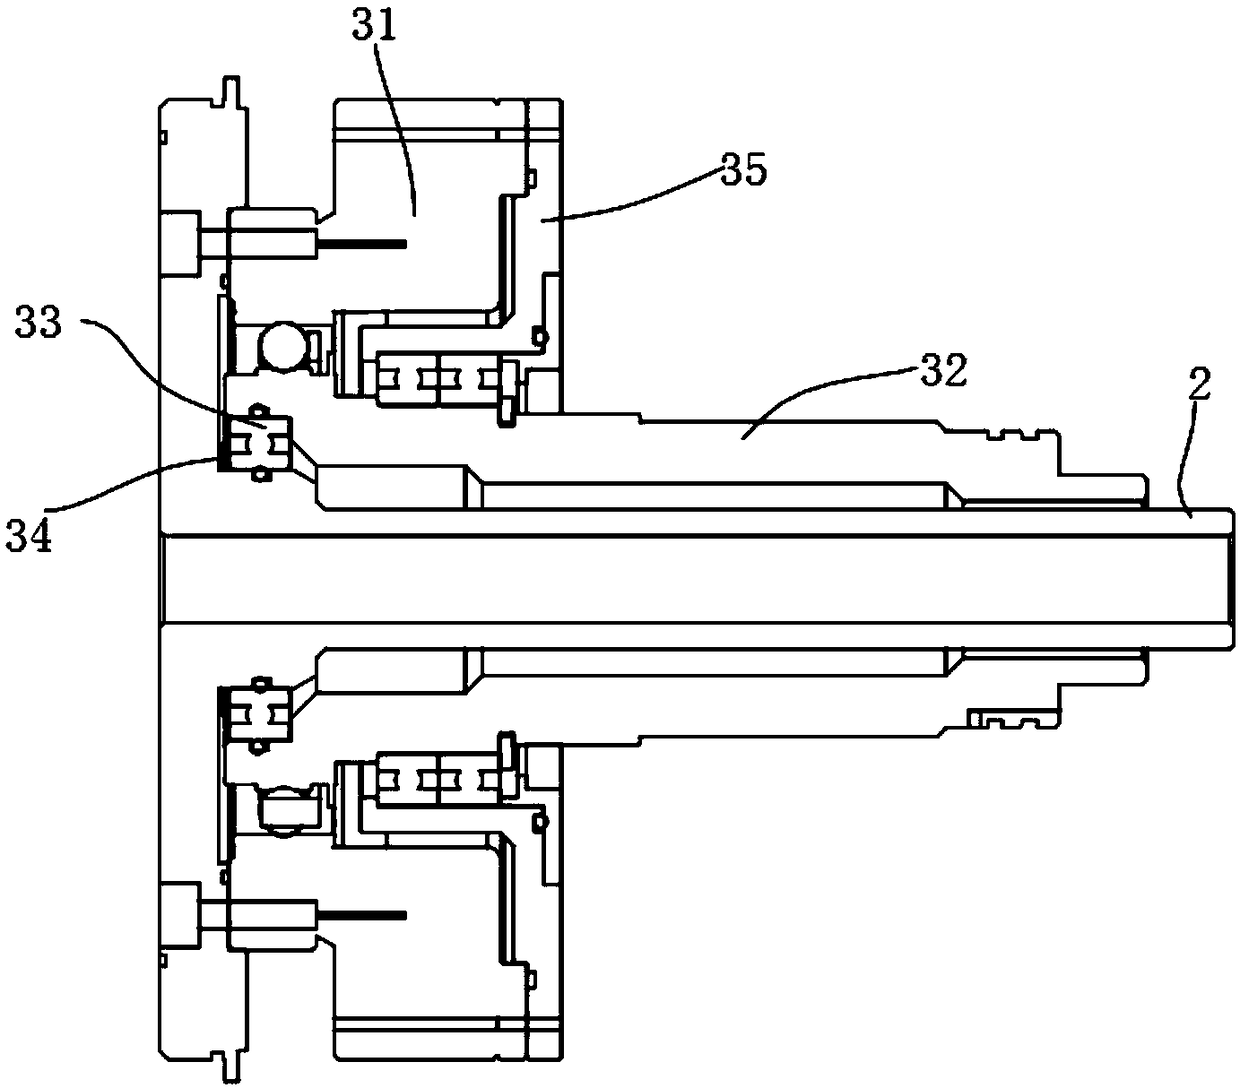
Figure 2 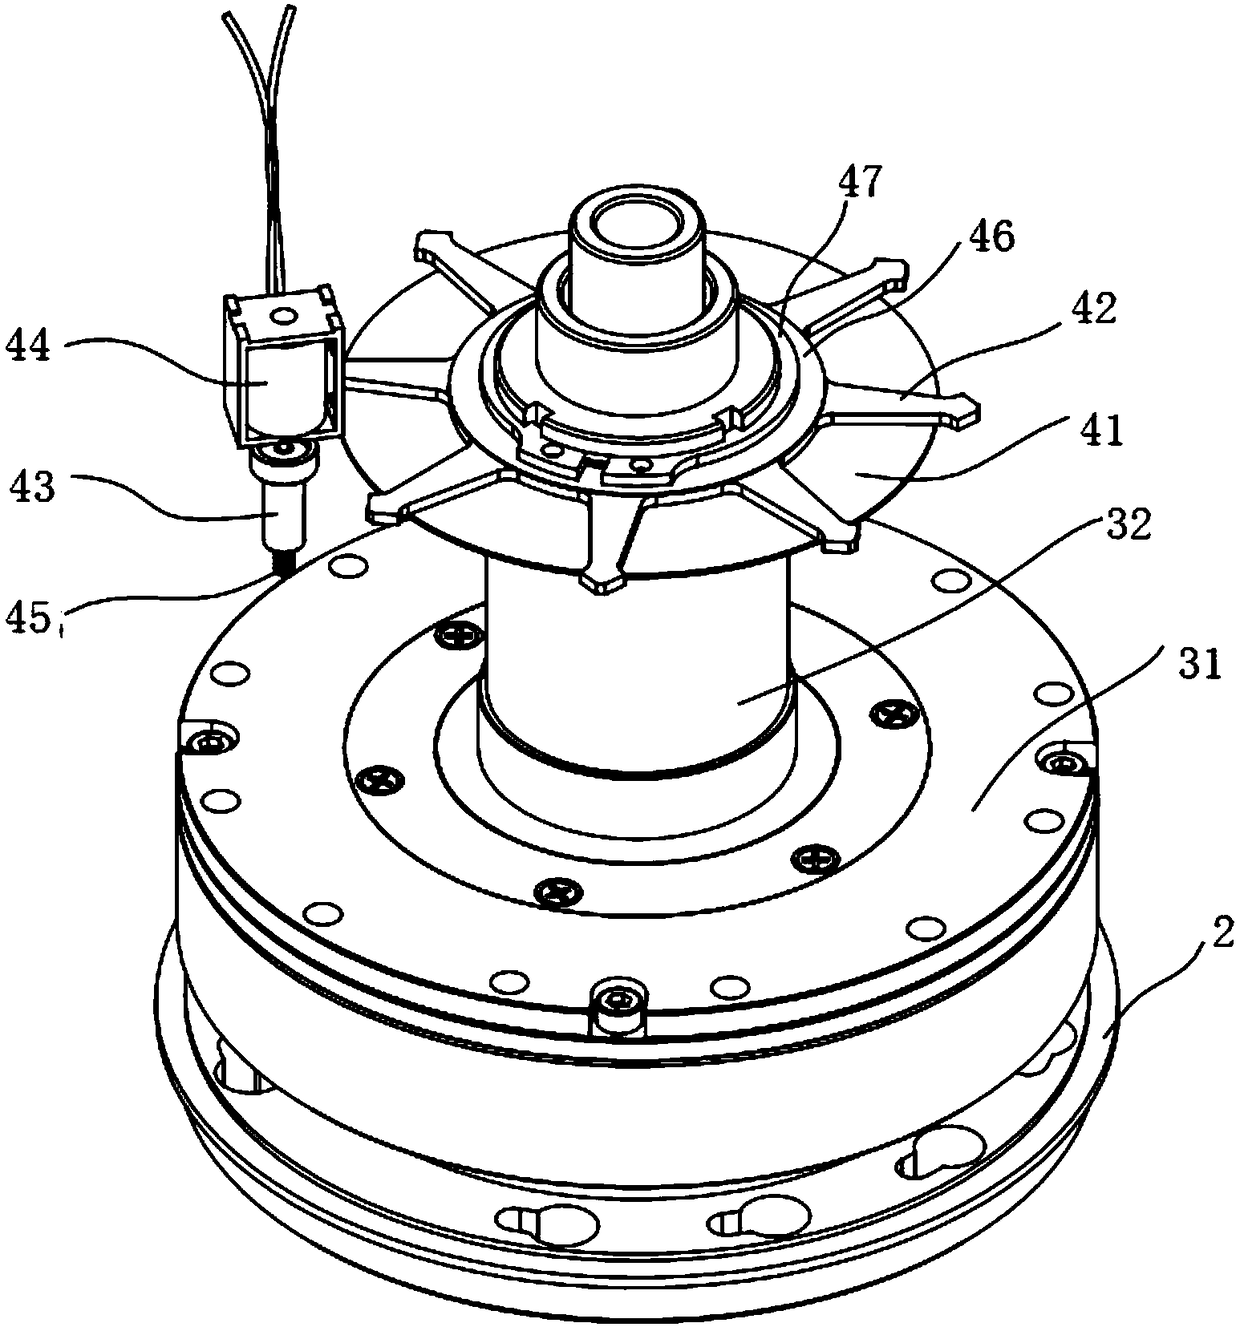
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of collaborative robots, in particular to a modular joint of a collaborative robot. Background technique
[0002] With the proposal and widespread promotion of "Industry 4.0" and "Made in China 2025", the state and enterprises pay more attention to the development of key technologies for intelligent manufacturing. Traditional robots have been widely used in various industries, and can gradually replace monotonous, highly repetitive, and dangerous tasks in the production process, and have achieved great results, improving the degree of automation and reducing labor costs.
[0003] With the continuous development of science and technology, new industries require robots to be able to realize human-machine cooperation, that is, robots can be as flexible as humans, realize dragging and teaching, and cooperate with humans to complete some special tasks, and do not need to use safety fences for isolation, so as to ...
Examples
Embodiment Construction
[0093] The implementation of the present invention will be illustrated by specific specific examples below, and those skilled in the art can easily understand other advantages and effects of the present invention from the contents disclosed in this specification.
[0094] It should be noted that the structures, proportions, sizes, etc. shown in the drawings attached to this specification are only used to match the content disclosed in the specification, for those who are familiar with this technology to understand and read, and are not used to limit the implementation of the present invention. Limiting conditions, so there is no technical substantive meaning, any modification of structure, change of proportional relationship or adjustment of size, without affecting the effect and purpose of the present invention, should still fall within the scope of the present invention. The disclosed technical content must be within the scope covered. At the same time, terms such as "upper"...