
Foot structure of biped robot and all-terrain pavement adaptation method thereof
A biped robot and adaptive method technology, applied in the field of robotics, can solve problems such as difficulty in maintaining balance and dumping, and achieve the effects of reducing impact, cushioning, shock absorption, and force feedback capabilities, and improving walking stability
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2020-06-12
Smart Images
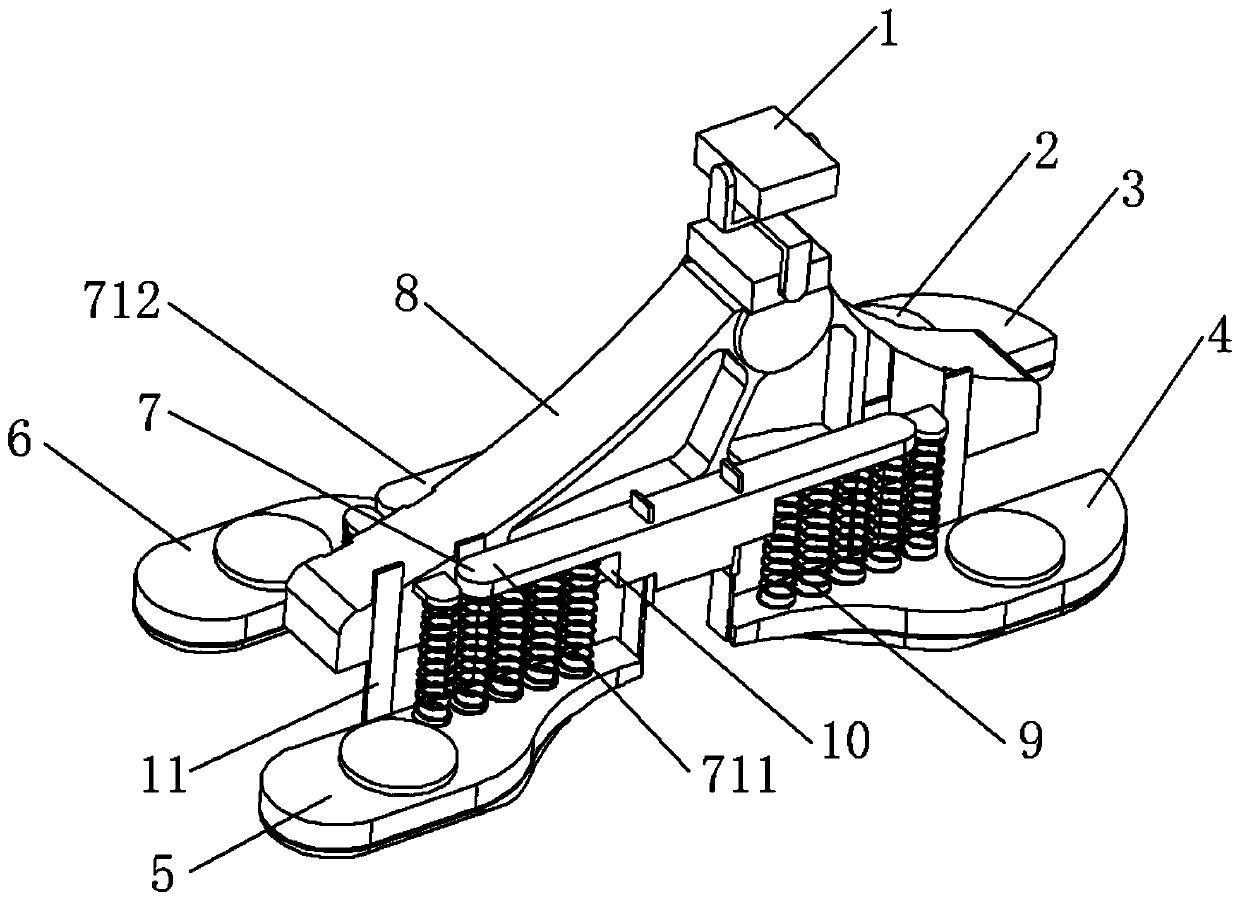
Figure 1 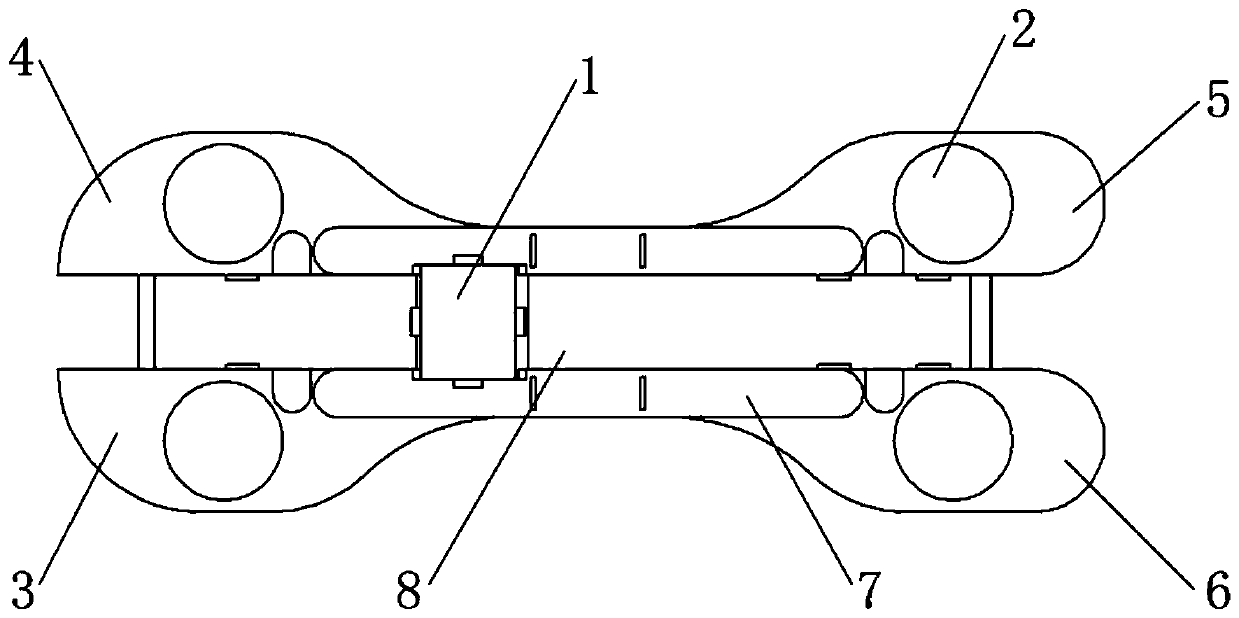
Figure 2 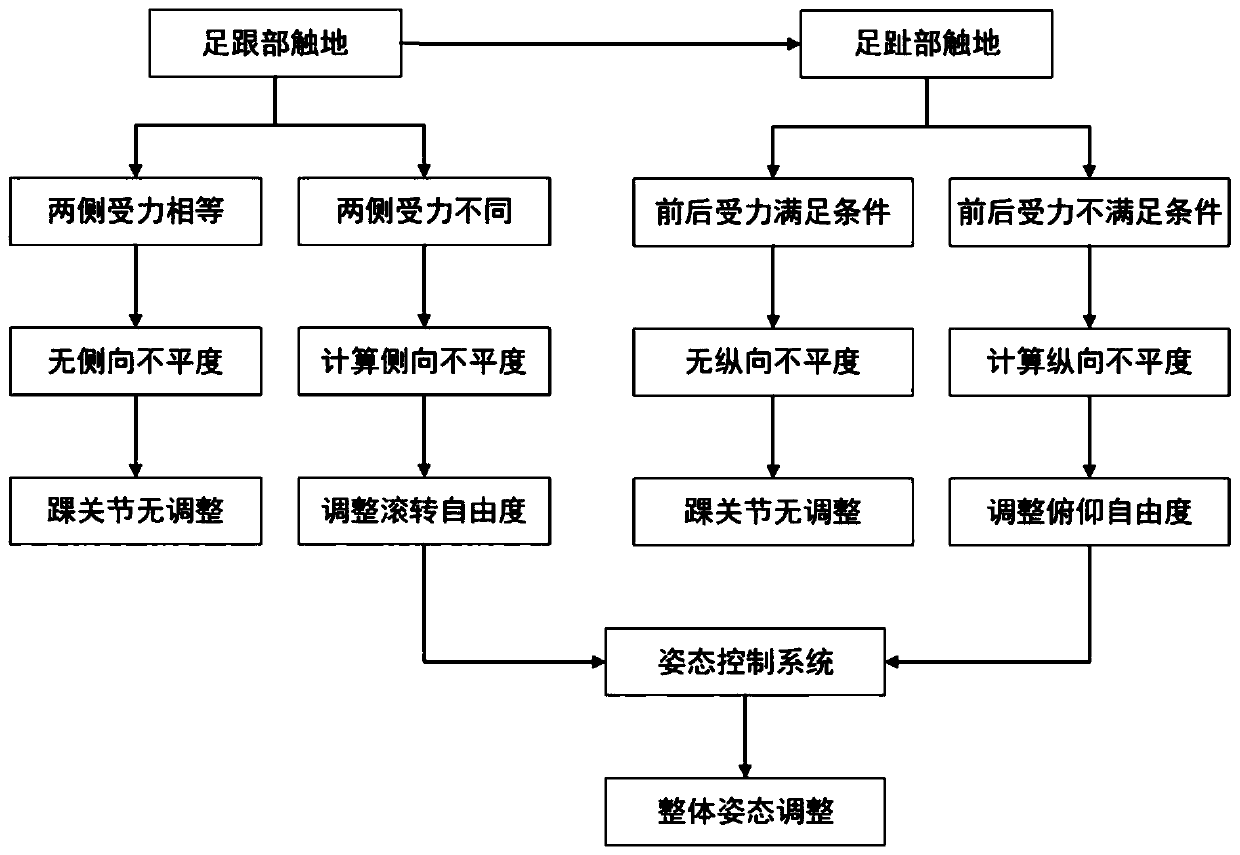
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a foot structure of a biped robot and an all-terrain road adaptation method thereof, belonging to the technical field of robots. Background technique
[0002] The biped robot is a robot that imitates the human body structure and walking gait. Its advantages lie in the excellent obstacle-surmounting ability and powerful movement ability brought by the leg-foot structure. The current biped robots have the ability to walk stably on flat roads. Some biped robots can imitate human walking gait to a certain extent, and the design of the foot structure is also various, but most of the foot The integrated structure is adopted, and the ankle joint motor is often used for frequent adjustments when encountering uneven road surfaces, or only the elastic deformation of the sole material and the deflection of the ankle joint are used to resist the impact caused by uneven road surfaces. The former has high requirements on the control of the ...
Examples
Embodiment Construction
[0037] The present invention will be further described below in conjunction with accompanying drawing.
[0038] refer to Figure 1-2 , the foot structure adapted to the three-dimensional all-terrain road surface of the biped robot, including the arch of the foot, the toe fixed at the front end of the arch of the foot, the heel fixed at the rear end of the arch of the foot, and the ankle joint fixed at the top of the arch of the foot1 , the arch of foot includes the arch of foot body 8, the elastic element 9 and the connecting mechanism 7, the connecting mechanism 7 is fixed on the side of the arch of foot body 8, wherein the left connecting mechanism 711 is fixed on the left side of the arch of foot body 8 , the right connecting mechanism 712 is fixed on the right side of the arch body 8; the toe and heel respectively include two foot modules; respectively the right heel module 3, the left heel module 4, the left toe module 5, The right toe module 6; the right toe module 6 an...