
In-orbit calibration method of star sensor lens distortion and satellite attitude determination method based on starlight vector correction
A technology of lens distortion and star sensor, which is applied in the field of satellite attitude determination, can solve the problems of low precision and inability to calibrate the lens temperature distortion term of the star sensor, and achieves the effect of eliminating satellite attitude determination errors.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2013-08-07
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
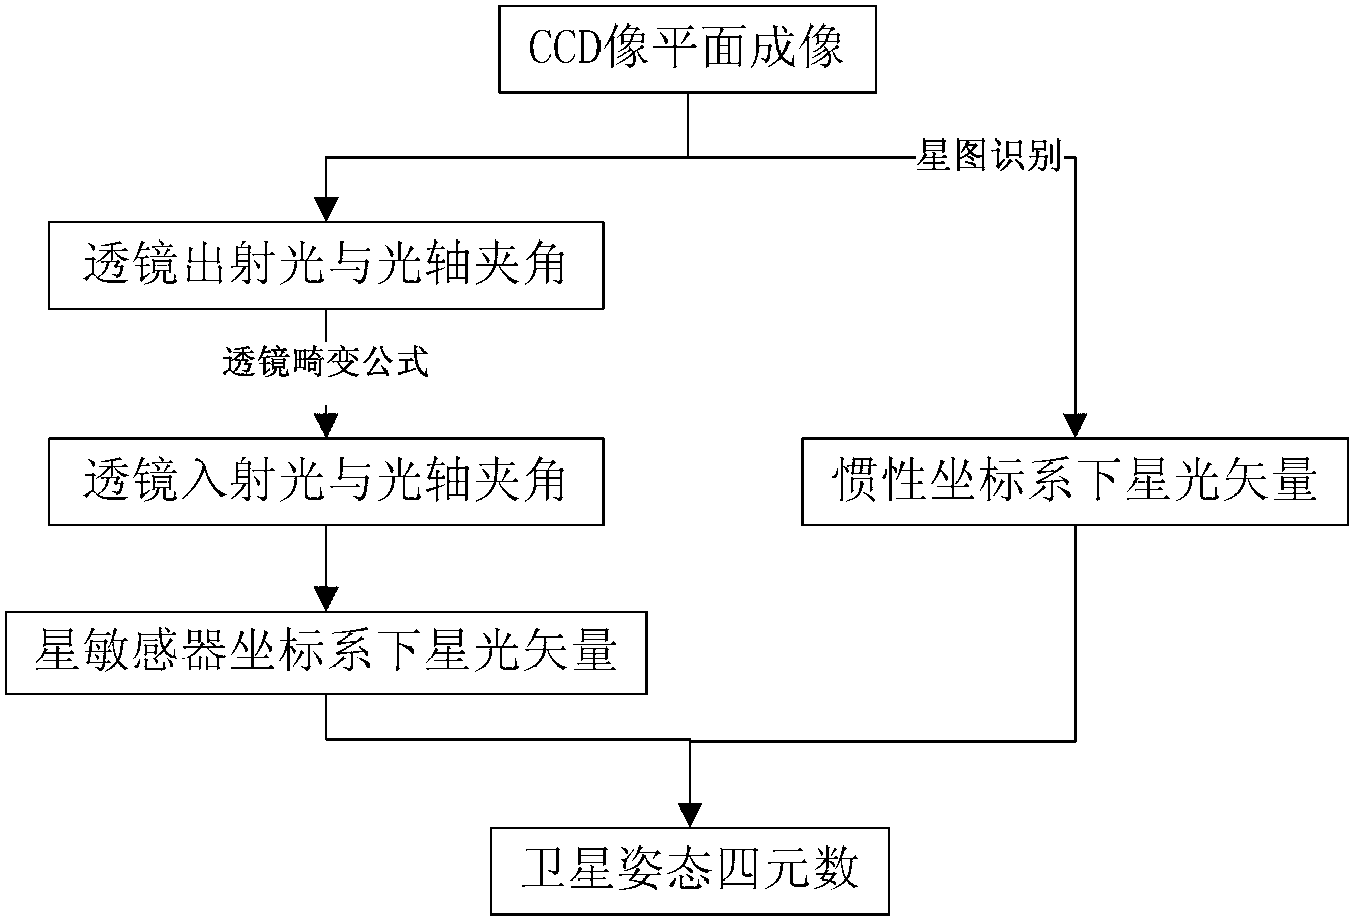
Figure 1 
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of satellite attitude determination, in particular to a method for on-orbit calibration of star sensor lens distortion based on starlight vector correction and a satellite attitude determination method. Background technique
[0002] Among various satellite attitude sensors, star sensors have the highest attitude determination accuracy. With the further exploration of space, higher requirements are placed on satellite attitude determination and control accuracy. Therefore, star sensors are used in satellite attitude determination. The system is used more and more. The star sensor lens will produce serious lens distortion after working for a long time in the harsh space working environment. In addition, the drastic change of ambient temperature in space will cause real-time changes in the degree of distortion of the star sensor lens. However, the existing star sensor lens distortion calibration method cannot ...
Examples
specific Embodiment approach 1
[0040] Embodiment 1: The present invention corrects multiple star sensor lens distortions including temperature distortion coefficients by using the principle of equal star angle distance, and the method for on-orbit calibration of star sensor lens distortion based on starlight vector correction is carried out in the following steps :
[0041] Step 1. Calculate the derivative of the measured star angle distance between the i-th target star and the j-th target star to the lens distortion coefficient, the specific expression is as follows, where a is the lens distortion coefficient, x i 、x j 、y i 、y j are the x and y coordinates of the imaging points of the i-th target star and the j-th target star respectively, α i 、α j are the angles between the incident light of the i-th target star and the j-th target star and the optical axis of the lens,
[0042] ∂ ∂ a W i T ...
specific Embodiment approach 2
[0056] Specific implementation mode two: the present invention introduces a lens distortion model in the process of determining the target star starlight vector by the coordinates of the star sensor imaging point, and its process is shown in the appendix figure 1 , the satellite attitude determination method based on star sensor lens distortion proceeds in the following steps:
[0057] Step 1. The star sensor images the target star to obtain the coordinates (x, y, f) of the imaging point in the star sensor coordinate system, where x and y are the coordinates of the imaging point in the x and y directions respectively, and f is the star sensor The focal length of the device lens; the angle β between the outgoing light of the lens and the optical axis of the lens is obtained from the coordinates of the imaging point, and the specific calculation formula is:
[0058] β = arccos f x 2 ...