
Special wrench for high-voltage line inspection robot operation
A technology for inspecting robots and high-voltage lines, which is applied in the direction of wrenches, hand-held tools, wrenches, etc., can solve the problems of lack of dexterity of the end effector of the operating arm, difficulty in using ordinary wrenches, and difficulty in direct operation of the operating arm, etc., to achieve convenience for robots Effects of operation, reduced range of motion, and ease of use
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2015-12-30
Smart Images
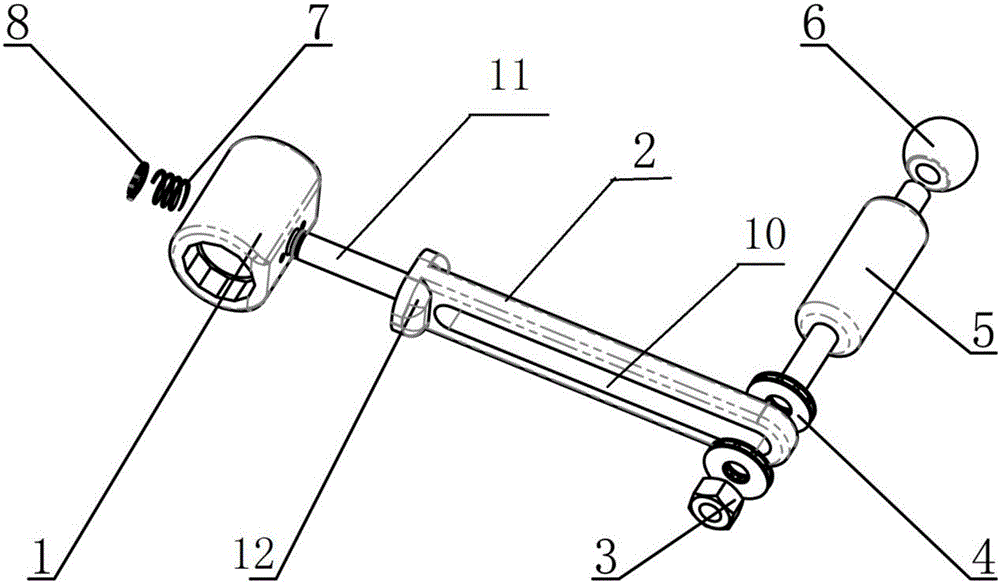
Figure 1 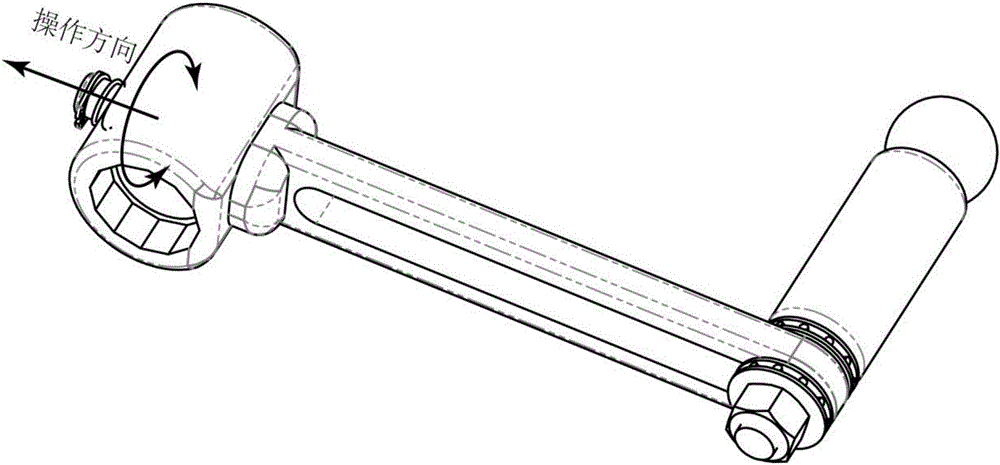
Figure 2 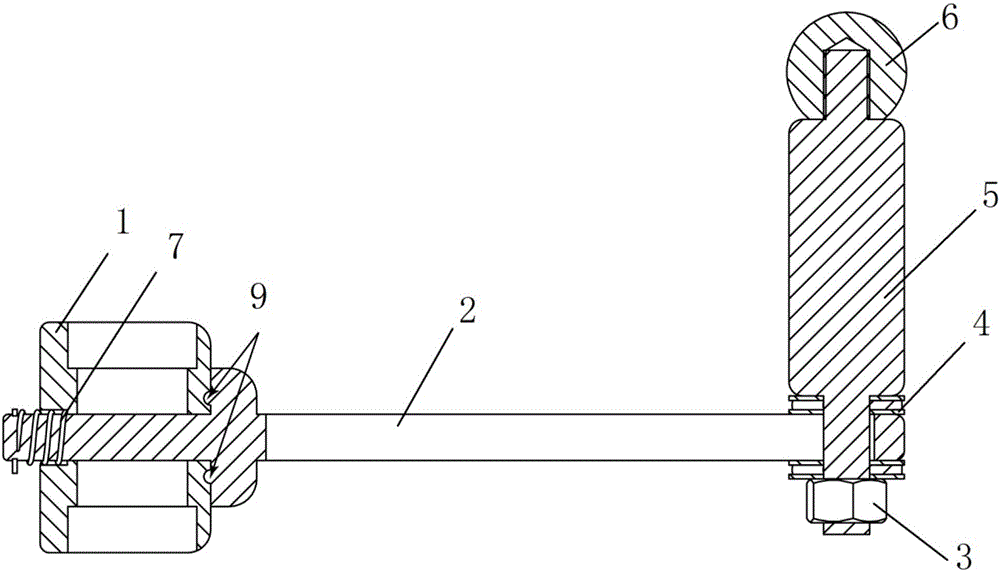
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a robot operation and hardware tool, in particular to a special wrench for high-voltage line inspection robot operation, which can be used for operations such as dismantling anti-vibration hammers on high-voltage transmission lines, and can also be used as a manual tool. Background technique
[0002] High-altitude operations such as daily maintenance of high-voltage transmission lines are basically done manually. These high-altitude operations include adjusting anti-vibration hammers, removing hanging objects on high-voltage lines, and winding pre-twisted wires. Due to the challenging and dangerous nature of such work at heights, the use of robots will be an effective solution to perform these tasks in place of humans.
[0003] At present, some high-voltage line inspection robots have been developed at home and abroad, but they often only have the function of moving along the line and lack of operation functions. When adjustin...
Examples
Embodiment Construction
[0034] The present invention will be further described below in conjunction with the accompanying drawings and embodiments.
[0035] like figure 1 The exploded view of the special wrench is shown, and the parts include wrench head 1, wrench arm 2, handle 5, handle ball 6, thrust needle roller bearing 4, etc. The handle ball 6 is a spherical body provided with threaded holes along its radial direction, and the threaded holes are blind threaded holes. The handle ball 6 is fixed on the handle 5 through threads, the handle 5 is fixed on the chute 10 of the wrench arm 2 through the thrust needle roller bearing 4 and the nut 3, the wrench head 1 is pressed on the wrench arm 2 through the compression spring 7, and the wrench as a whole is Zigzag.
[0036] There is a chute 10 on the wrench arm 2 along its length direction, and the chute 10 is a transparent elongated groove along the front and back sides of the wrench arm 2 length direction. The handle 5 is installed in the chute 10...