
A three-axis hybrid drive robotic arm
A hybrid drive and robotic arm technology, applied in manipulators, program-controlled manipulators, manufacturing tools, etc., can solve the problems of clumsy movement, complex mechanism, low transmission efficiency, etc., and achieve the effect of dexterous movement, high transmission efficiency, and smooth movement.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2016-05-11
Smart Images
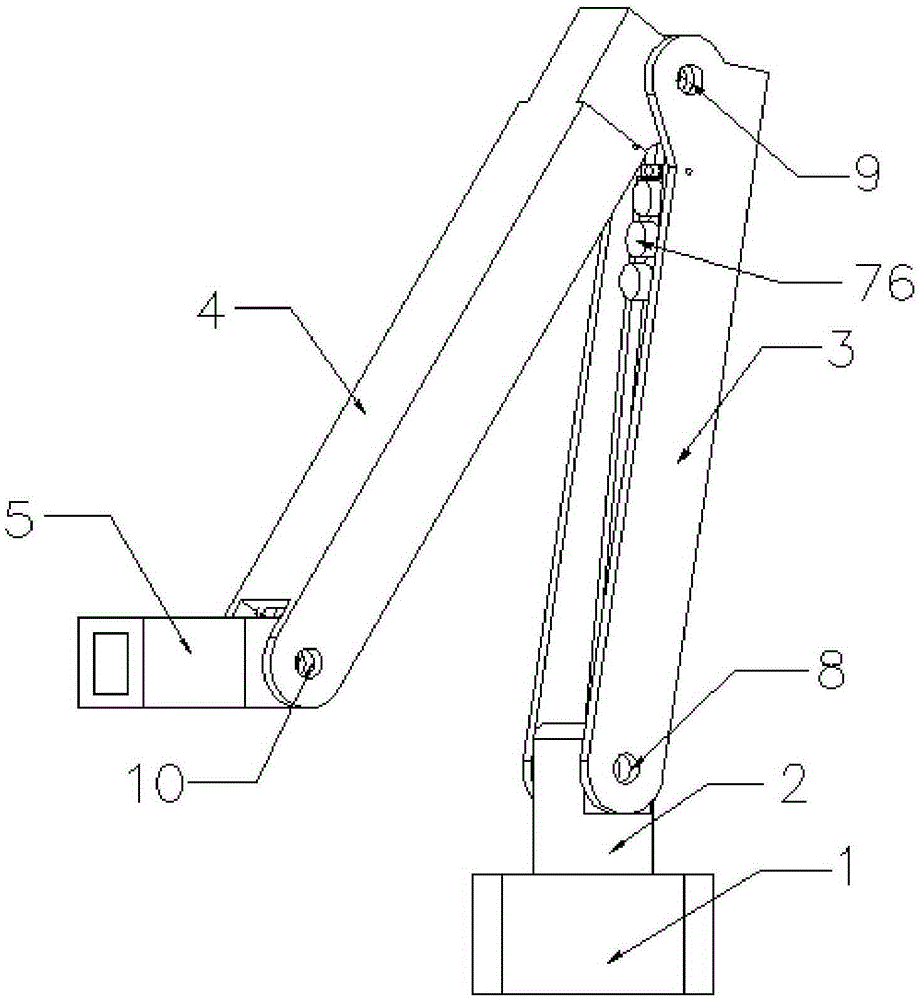
Figure 1 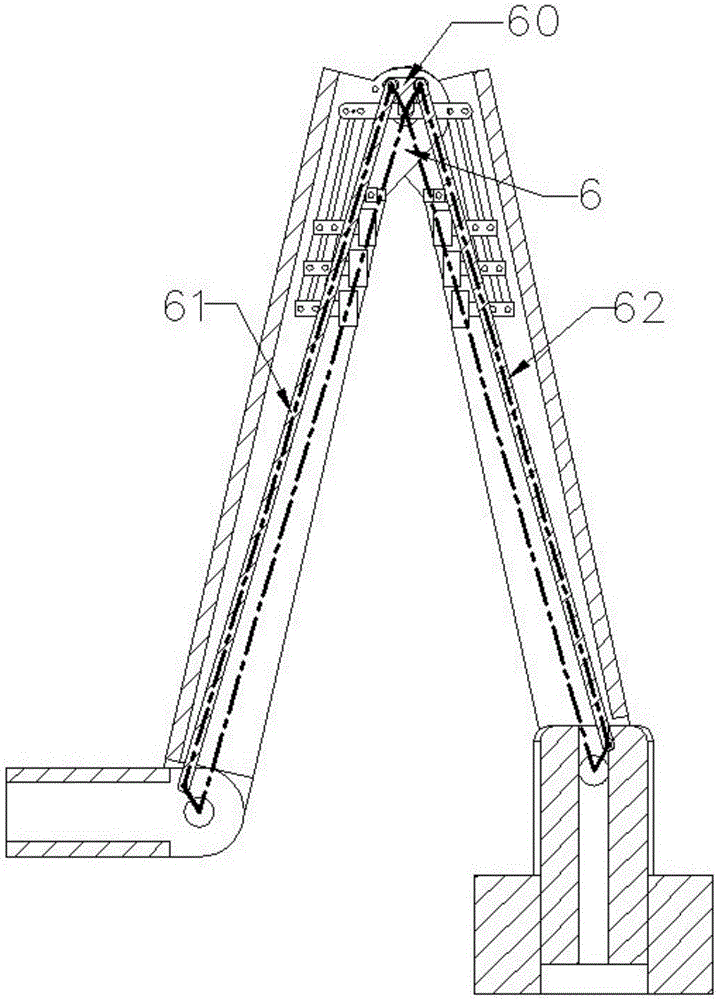
Figure 2 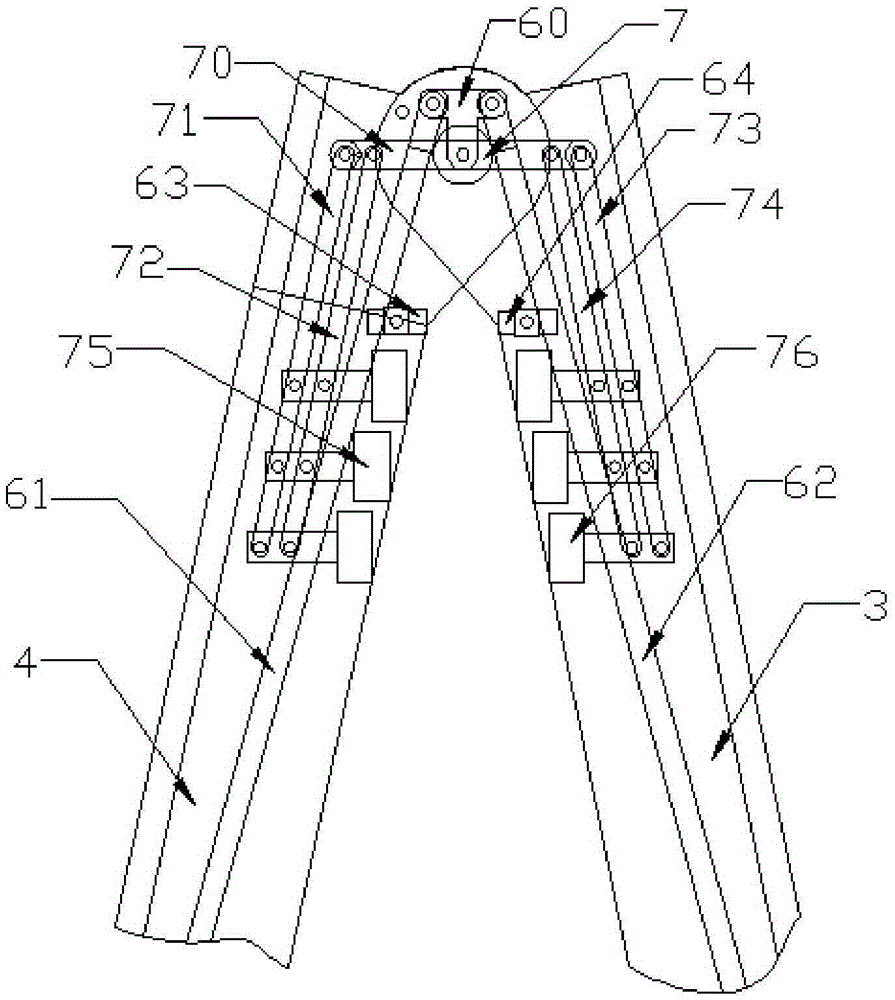
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a three-axis mixed-drive mechanical arm, which is applied to stacking, transportation and other occasions. technical background
[0002] With the rapid development of logistics and other industries, the labor cost of simple and repetitive work has gradually increased, and mechanisms for replacing manual handling have been continuously designed and applied to workplaces, such as palletizing robots. There are many design schemes for palletizing robots, but most of them are motor-driven and realize palletizing tasks through a variety of mechanical structures. The mechanism is complicated, the movement is clumsy, and the transmission efficiency is low. Contents of the invention
[0003] The present invention overcomes the above-mentioned shortcomings of the prior art, and provides a three-axis hybrid drive mechanical arm with simple mechanism, dexterous movement and high transmission efficiency.
[0004] Three-axis hybrid drive ...
Examples
Embodiment Construction
[0020] Refer to the attached figure 1 -5 further illustrate the present invention:
[0021] The three-axis hybrid drive mechanical arm of the present invention includes a base 1, a support 2, a rear arm 3, a forearm 4, and a palm 5, and is characterized in that the support 2 is hinged around the vertically upward first axis On the base 1, the lower end of the rear arm 3 is hinged on the support 2 around the second horizontal axis 8, and the upper end of the front arm 4 is hinged on the rear arm 3 around the third axis 9 , the lower end of the forearm 4 is hinged to the palm 5 around the fourth axis 10, and the second axis 8, the third axis 9, and the fourth axis 10 are parallel to each other;
[0022] The palm 5 is connected to the first link mechanism, and the first link mechanism 6 includes a first intermediate link 60 whose middle part is hinged on the third shaft 9, a forearm link 61 extending in the forearm 4, and a forearm link 61 extending in the forearm 4. The rear a...