

Patents
Literature
985 results about "Hybrid drive" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
In computing, a hybrid drive (solid state hybrid drive – SSHD) is a logical or physical storage device that combines a faster storage medium such as solid-state drive (SSD) with a higher-capacity hard disk drive (HDD). The intent is adding some of the speed of SSDs to the cost-effective storage capacity of traditional HDDs. The purpose of the SSD in a hybrid drive is to act as a cache for the data stored on the HDD, improving the overall performance by keeping copies of the most frequently used data on the faster SSD.
Regional soil moisture dynamic distribution prediction method and system
InactiveCN119623259Aimprove performanceForecastingDesign optimisation/simulationData setSoil science
The invention provides a regional soil moisture dynamic distribution prediction method, belongs to the field of soil moisture content prediction, and provides a sequential hybrid drive method (mRestart-EnKF-ML), the method combines a modified ensemble Kalman filter (mRestart-EnKF) and a machine learning model (ML), and the dynamic distribution of the regional soil moisture is predicted. And dynamically updating soil hydraulic parameters by assimilating data of a plurality of observation stations in real time, and generating a soil moisture profile data set with any temporal-spatial resolution. Through machine learning model training, the method can accurately predict the soil water content SMC at no observation point, and has high adaptability and expandability. Therefore, the technology provided by the invention has remarkable advantages in the aspects of improving SMC prediction precision, expanding temporal-spatial resolution, coping with complex terrains and meteorological conditions and the like, and an efficient and practical solution can be provided for dynamic monitoring and management of soil moisture.

Owner:NORTHWEST A & F UNIV
Lithium ion battery variable working condition SOH evaluation method based on model-data hybrid driving
The invention discloses a model-data hybrid driving-based lithium ion battery variable working condition SOH (state of health) evaluation method, relates to a lithium ion battery state of health evaluation method, and aims to solve the problems of poor applicability and low precision of an existing battery fixed working condition SOH evaluation method. The method comprises the following steps: 1, accelerating aging of a battery under working conditions I and II and acquiring information; 2, aiming at the constant-current discharge curve of the battery under the working condition, performing SP + model parameter identification by using a particle swarm optimization algorithm to obtain a degradation track of the model parameter within the battery health degree of 100%-80%; 3, selecting model parameters with high relevancy with the SOH of the battery as health features, and inputting the health features into a BP neural network algorithm to estimate the SOH of the battery, wherein the first working condition data and the second working condition data are respectively a training set and a test set; 4, according to the BPNN model obtained through data training of the first working condition, after SP + model parameters of the second working condition obtained through simulation are input, the SOH of the battery under the second working condition is output, and evaluation is completed. The invention can be used in battery field.

Owner:HARBIN INST OF TECH
Physical and data hybrid driven mechanical arm dynamic model identification method
PendingCN120562257AProgramme-controlled manipulatorDesign optimisation/simulationDynamic modelsObservation matrix
The invention discloses a physical and data hybrid driven mechanical arm dynamic model identification method which is characterized by comprising the following steps: S1, acquiring parameters of each axis of a robot, establishing a dynamic model of a mechanical arm, and linearizing the dynamic model according to a minimum inertia principle to obtain a dynamic minimum parameter set and a corresponding regression matrix; s2, an excitation track of the mechanical arm is designed based on the finite Fourier series; s3, the mechanical arm runs the designed excitation track, angles, angular velocities, angular accelerations and torque data of all joints of the mechanical arm in the movement process are collected and filtered, and an observation torque vector and an observation matrix are calculated; s4, performing preliminary estimation on the minimum parameter set by using an iterative reweighted least square method; and S5, aiming at the dynamic characteristics of LuGre friction force in the movement process of the mechanical arm, establishing a mechanical arm dynamic model under physical and data hybrid driving.

Owner:NANJING YINGQI INTELLIGENT TECH CO LTD
Chainless hybrid electric bicycle
InactiveUS20250033736A1Propulsion using engine-driven generatorsMotorcyclesElectrical batteryDrive motor
A chainless hybrid electric bicycle includes a bicycle body. A generator, a battery pack, a driving motor and a manual switch are mounted on the bicycle body. The generator is coaxially mounted with the pedal transmission unit, so that the generator generates an electric power when the rider works the pedals. The battery pack is electrically connected to the generator for storing the electric power generated by the generator. The driving motor drives the wheels of the bicycle body to run. The rider selects the electric power from the generator or the battery pack through the manual switch to drive the driving motor to run, which in turn drives the bicycle body to move forward. The chainless hybrid electric bicycle has the advantage of a hybrid power drive system, without using traditional mechanical transmission components such as chains and chainrings.

Owner:CHAI FU +1
Photovoltaic array life prediction method based on physical model and data hybrid driving
The invention discloses a photovoltaic array life prediction method based on hybrid driving of a physical model and data. The method comprises the following steps: defining failure time and residual life of a photovoltaic array; preprocessing data; degeneration trend extraction: separating a trend term, a seasonal term and a residual term of output power through block median filtering and seasonal effect correction, and eliminating the influence of environmental fluctuation on degeneration analysis; residual life prediction based on data driving; parameter prediction based on a physical model: identifying degradation parameters of the double-diode model; a degradation parameter trajectory model is established, an output power attenuation curve is inverted, and the remaining life is predicted; and result fusion: comparing data driving and physical model prediction results, and outputting a final residual life value through weighted average or confidence interval fusion. According to the invention, a set of complete photovoltaic array residual life prediction system is constructed, a whole-process closed loop from data acquisition, mechanism analysis to life prediction is realized, and an efficient and accurate solution is provided for reliability evaluation of a photovoltaic system.

Owner:HOHAI UNIV CHANGZHOU
Parallel task scheduling method based on node dynamic load and task relevance measurement
ActiveCN119806771AProgram initiation/switchingResource allocationGlobal schedulingResource virtualization
The invention discloses a parallel task scheduling method based on node dynamic load and task relevance measurement. The parallel task scheduling method comprises the following steps: constructing a global scheduler for computing resource virtualization, sample allocation based on reinforcement learning and a local scheduler based on hybrid drive model scheduling on a server; in the preprocessing stage, computing resources are counted, and computing resource virtualization, GPU virtualization multiplexing technology, GPU acceleration and the like are carried out; a global scheduling stage oriented to test task parallel optimization: performing sample scheduling feasibility analysis containing fuzzy time, computational node selection based on an EXP3 algorithm, and sample scheduling oriented to node load; and a multilevel model parallelization stage based on domain knowledge and data hybrid driving, wherein a model cohesion coupling degree measurement mechanism, a model coupling mode knowledge base and a multilevel model parallelization method are included. According to the method, the global scheduler and the local scheduler are comprehensively utilized, the parallelism degree between samples and parallelism between models in the samples are achieved, and the method has wide application value and use prospects in all fields.

Owner:NO 8511 RES INST OF CASIC
Active and passive hybrid driving module and method for rope cluster of space flexible mechanical arm
The invention discloses a space flexible mechanical arm rope cluster active and passive hybrid driving module and method.The space flexible mechanical arm rope cluster active and passive hybrid driving module comprises a rope cluster multi-axis driving module, the rope cluster multi-axis driving module comprises a plurality of rope cluster driving modules, each rope cluster driving module comprises a rope driving mechanism and a driving rope, one end of each driving rope is connected with the corresponding rope driving mechanism and is driven by the corresponding rope driving mechanism to linearly move, and the other end of each driving rope is driven by the corresponding rope driving mechanism; the other end of the driving rope is connected with a kinematic pair of any arm section in the arm section; and the segmented equal-curvature linkage module provides constraint for all the arm sections in the arm sections, the same-direction moving shafts of all the arm sections in the arm sections are coupled together through linkage ropes, and all the arm sections are driven to synchronously move at equal angles under the driving action of the rope cluster multi-shaft driving module. The problems that the motion state of the under-actuated flexible mechanical arm is not unique, and the number of driving units of the full-drive flexible mechanical arm is large are fundamentally solved, and the overall number, quality and power consumption of the driving units are greatly reduced while the motion flexibility, the tail end precision and the structural rigidity are guaranteed.


Owner:启元实验室
Longitudinal front-drive hybrid driving system and vehicle
The utility model provides a longitudinal front-drive hybrid drive system and a vehicle. The drive system comprises a transmission, a first electric drive system, a second electric drive system, an internal combustion engine drive system and a drive axle, and the transmission comprises an input shaft, a first output shaft and a clutch device; the first electric driving system comprises a first motor and a first transmission shaft, the first motor is connected with the first transmission shaft, and the first transmission shaft is in transmission connection with the input shaft; the second electric driving system comprises a second motor and a second transmission shaft, the second motor is arranged on one end side of the input shaft and connected with the second transmission shaft, and the second transmission shaft is in transmission connection with the first output shaft; the internal combustion engine driving system comprises a longitudinal internal combustion engine which is located on the other end side, opposite to the second motor, of the input shaft, and a rotating shaft of the internal combustion engine is in transmission connection with the input shaft. The input end of the drive axle is in transmission connection with the first output shaft. According to the utility model, the power transmission link of the hybrid power driving system can be shortened, and the driving efficiency of the hybrid electric vehicle is improved.

Owner:GETRAG JIANGXI TRANSMISSION
Permanent magnet synchronous motor temperature monitoring method based on digital-analog hybrid drive
PendingCN121276319AMachine part testingElectric motor controlPermanent magnet synchronous motorControl theory
The invention discloses a permanent magnet synchronous motor temperature monitoring method based on digital-analog hybrid drive, and the method specifically comprises the steps: dividing a motor into a plurality of heat source nodes, including a stator winding, a stator tooth part, a rotor core and the like, connecting the nodes through a thermal resistance and thermal capacity network, building a thermal network model of the motor, and carrying out the thermal network model; calculating the initial values of thermal resistance and thermal capacity of each component of the motor, and optimizing parameters in a thermal network model by using a differential evolution algorithm based on the lumped parameter thermal network model and in combination with a data-driven strategy. Furthermore, temperature rise prediction is dynamically adjusted according to motor state data (such as stator current, rotating speed and the like) collected in real time so as to realize real-time temperature estimation. The method is high in temperature estimation precision, does not affect the performance of the motor, is simple in calculation, is good in real-time performance, and has physical interpretability. The temperature rise of the motor can be predicted in real time under different working conditions, early warning is given out, motor faults caused by too high temperature rise are effectively avoided, and the reliability and safety of the motor are improved.


Owner:CHINA STATE RAILWAY GRP CO LTD +4
Flying and crawling cross-domain multimode robot
PCT designated stage expiredWO2025020161A1Aircraft convertible vehiclesAircraftsClassical mechanicsRotor (electric)
A flying and crawling cross-domain multimode robot, comprising vector rotor modules, vector magnetic force modules, wheel-track drive modules, a tailwheel module and the like, the robot having multiple modes such as flying, crawling, hybrid drive, takeoff and landing. The vector rotor modules have a function of folding rotors, and, in the crawling mode, can fold the rotors to reduce the robot size, thus preventing impact on crawling operations; the vector magnetic force modules and the tailwheel module can provide attraction force for robot crawling, and, in the flying mode, can act as momentum swing arms to maintain the balance stability of the robot; a plurality of robots are combined in series via mechanical-electrical integrated interface modules, and a single robot can achieve expansion of vector rotor modules via the mechanical-electrical integrated interface module; the robot can flexibly and quickly switch between the crawling mode and the flying mode.

Owner:GUANGDONG UNIV OF TECH
Method for predicting residual service life of aero-engine based on data and model hybrid drive
The invention discloses an aero-engine remaining service life prediction method based on data and model hybrid drive, and relates to the field of aero-engine service life prediction, and the method comprises the steps: collecting the operation data of an aero-engine; preprocessing the data to obtain a training sample; inputting the training sample into an auto-encoder based on a time convolutional network, taking the deviation between time windows as a health index of the aero-engine, and ensuring the effectiveness of the constructed health index by using three evaluation indexes; and carrying out degradation modeling and RUL prediction by using a random effect Wiener process model with an acceleration factor to obtain an RUL predicted value of the aero-engine and a corresponding probability density function thereof. According to the hybrid driving method, the advantages of a statistical data driving method and a deep learning method are combined, and the problems that current deep learning lacks transparency and interpretability and is relatively limited in uncertainty quantification capability, and the statistical data driving method is limited in capability of processing and monitoring big data are solved.

Owner:SOUTHWEST PETROLEUM UNIV
Physical-data hybrid drive vehicle driving state estimation method
The invention relates to a physical-data hybrid drive vehicle driving state estimation method, and belongs to the technical field of intelligent vehicle chassis dynamics state estimation. Constructing a mapping relation between the state estimation vector and sensor data by adopting a ridge regression method so as to explicitly express a vehicle movement mechanism; secondly, constructing a data driving model to implicitly extract vehicle sensor data features, and constructing an enhanced LSTM neural network with a double-stage attention mechanism as the data driving model; then, performing dynamic weighted fusion on an output result of the physical model and a sensor sample sequence output by the data driving model to realize deep coupling of physical mechanism knowledge and data driving characteristics; according to the method, the superiority of the method compared with other methods is verified through simulation testing and real vehicle testing.


Owner:GUANGXI UNIV
Polishing sand feeding mechanism of sand blasting polishing machine
ActiveCN222609213Uachieve cleaning effectReduce settlementAbrasive feedersAbrasive machine appurtenancesThermodynamicsSand blasting
The utility model provides a polishing sand feeding mechanism of a sand blasting and polishing machine, belongs to the technical field of sand blasting and polishing machines, and aims to solve the problem that the mixing efficiency of the sand is influenced as the conventional sand is easy to agglomerate with a solution. Comprising a liquid distribution cylinder, a sand inlet pipe, a liquid inlet pipe, a discharging pipe, a hybrid driving motor, a stirring shaft, a filtering piece, a stirring and mixing mechanism and a distribution anti-blocking mechanism, the sand inlet pipe is fixedly connected to the upper part of the liquid distribution cylinder; the hybrid driving motor is fixedly connected to the lower part of the liquid distribution cylinder; the stirring shaft is rotationally connected to the interior of the liquid distribution cylinder, and the stirring shaft is coaxially and fixedly connected to the upper end of a rotating shaft of the hybrid drive motor; the filter part is arranged at the upper end of the interior of the liquid distribution cylinder and is of a conical filter screen structure; the stirring and mixing mechanism is arranged in the liquid distribution cylinder; and the distribution anti-blocking mechanism is arranged at the upper end of the stirring shaft, so that full mixing of sand and a solution is ensured, caking of the sand is reduced, and uniform mixing of the sand and the solution is ensured.

Owner:CHONGQING YONGLIANG MASCH MFG CO LTD
Augmented reality and digital twin hybrid drive equipment maintenance method and system
The invention discloses an augmented reality and digital twin hybrid drive equipment maintenance method and system, and relates to the technical field of equipment maintenance, and the method comprises the steps: obtaining the feature data of target equipment; inputting the feature data into a preset equipment digital twinborn model, and generating a digital mirror image of the target equipment, namely a target equipment twinborn body; a hybrid drive maintenance mode is established through augmented reality hardware equipment and target equipment twin; making a maintenance strategy of the target equipment based on the hybrid drive maintenance mode; and the target equipment is maintained through the maintenance strategy that the augmented reality hardware equipment projects the target equipment step by step. The maintenance efficiency and quality can be improved, and the maintenance cost is reduced.

Owner:NAVAL AVIATION UNIV
Hybrid power driving system, vehicle and driving system control method
ActiveCN119659302AEliminate brake safety hazardsAvoid overheating and demagnetization failureHybrid vehiclesGas pressure propulsion mountingReduction driveGear wheel
The invention relates to a hybrid power driving system, a vehicle and a driving system control method. The hybrid power driving system comprises an engine, a first motor, a first connection and disconnection device, a planetary gear mechanism, a second motor, a first shaft, a second shaft, an intermediate shaft, an intermediate shaft gear, a main reduction driving gear, a main reduction driven gear, a motor driving gear, a parking gear and a differential mechanism. The vehicle can be parked by locking the parking gear; the planetary gear mechanism comprises a sun gear, a planet gear, a planet carrier and a gear ring, the first shaft is connected between a rotor of the first motor and the sun gear, the engine is connected with the planet carrier, and a gear ring outer gear meshed with the intermediate shaft gear is arranged on the gear ring; the first connecting and disconnecting device is connected between the sun gear and the static component and used for selectively connecting or disconnecting the sun gear and the static component. According to the hybrid power driving system, EPB abrasion can be reduced, and therefore the potential safety hazards of vehicle braking are eliminated.

Owner:GUANGZHOU AUTOMOBILE GROUP CO LTD
A lateral velocity estimation method for a hybrid driving model based on transfer learning
ActiveCN118333136BImprove training efficiencyreduce mistakesBiological modelsFeature extractionAlgorithm
The present invention is applicable to the technical field of vehicle parameter estimation, and provides a lateral velocity estimation method of a hybrid drive model based on transfer learning, comprising the following steps: using a kinematic model and a dynamic model to respectively estimate the lateral velocities and, taking them as inputs of an LSTM neural network to form a data-mechanism hybrid drive model, namely, LVENN; using the hybrid drive model to estimate the lateral velocity, the fusion method can significantly reduce the root mean square error and the maximum error of the lateral velocity estimation; by designing a transfer learning algorithm, fine-tuning parameters in a feature extraction layer and retraining in a fitting output layer to increase the transfer learning capability, the present invention can utilize the training data in the source domain to reduce the amount of labeled data in the target domain, and improve the efficiency of model training.

Owner:JILIN UNIVERSITY
Method for determining the thermal state of an electric motor in a hybrid drive of a motor vehicle
ActiveDE112015000788B4Hybrid vehiclesElectric motor controlThermodynamicsPermanent magnet synchronous machine
The invention relates to a method for determining the thermal state of an electric motor in a hybrid drive of a motor vehicle, wherein the electric motor is preferably a permanent magnet synchronous machine, in which a mean stator winding temperature is calculated in a temperature model to determine the thermal state of the electric motor. In a method in which the accuracy of the temperature model is improved, an estimated mean stator winding temperature is determined from at least one electrical parameter measured on the electric motor, which is then compared with the calculated mean stator winding temperature to calibrate the temperature model.

Owner:SCHAEFFLER TECHNOLOGIES AG & CO KG
Hybrid drive system for a motor vehicle, and a motor vehicle, in particular a motor car
A hybrid drive system for a motor vehicle includes an internal combustion engine supplying first torques via a drive shaft to drive the motor vehicle and an electric machine having a rotor via which second drive torques can be supplied by the electric machine to drive the motor vehicle. An axle drive has an axle drive input gear wheel via which the axle drive can be driven. The system includes a gearbox having a first partial gearbox and a second partial gearbox. The first partial gearbox has a first planetary gear set having a first element, a second element, and a third element, The first partial gearbox also has a second planetary gear set having a fourth element, a fifth element, and a sixth element.

Owner:MERCEDES BENZ GROUP AG
Saddle-ride type vehicle with hybrid propulsion
The present invention relates to saddle-ride type vehicle, motorcycle or motorbike, comprising a frame (2), at least a steering wheel (3) rotatably connected to the frame and a single driving wheel (4). The vehicle further comprises a motor assembly (10) and a transmission unit (T) that mechanically connects the motor assembly (10) to the driving wheel. The motor assembly comprises a thermal engine (MT) including a crankshaft (11), an electric machine (E) including a stator (S) and a rotor (R), and a clutch (C) including a driving shaft (C1) and a driven shaft (C2). The motor assembly (10) further comprises a gearbox (G) provided with an input shaft (111) and an output shaft (112). According to the present invention the crankshaft (11) of the thermal engine (MT), the rotor (R) of the electric machine (E) and the two shafts (C1, C2) of the clutch are coaxial so as to rotate around a common rotation axis (101) which is parallel to a longitudinal direction (Y) of the vehicle and parallel to the rotation axis of the output shaft (112) of said gearbox (G).

Owner:PIAGGIO & C SPA
Paddle-leg hybrid-driven underwater adhesion robot
The invention discloses a paddle-leg hybrid driven underwater adhesion robot, and relates to the technical field of underwater robots, propeller thruster driving, six-foot crawling movement and hydrogel bionic suckers of foot bottom equipment respectively have the advantages of long-distance cruise driving, stable crawling in unstructured terrain and reliable adhesion detection on near wall surfaces. Therefore, the adaptability problem of a single-mode underwater robot in a complex operation scene is solved. According to the invention, the six groups of multi-degree-of-freedom mechanical feet cooperate with the control system through the modular driving units, so that the robot can realize multi-modal motion functions such as seabed crawling, obstacle crossing and climbing, posture adjustment and the like; the robot can stably crawl on a vertical surface or an inverted surface through cooperation between the hydrogel bionic suction cups arranged at the foot ends and the six-foot crawling gaits. Through vector combination of the three vertical propellers and the two horizontal propellers, the robot can meet the multi-degree-of-freedom motion control requirements of advancing, retreating, ascending, sinking, yawing, pitching, pitching and hovering. According to the paddle leg hybrid drive underwater adhesion robot, the underwater hybrid drive potential is developed to the maximum extent, the underwater maneuverability is improved in various challenging underwater environments, and the underwater robot is promoted to develop towards multiple modes and high efficiency.

Owner:LANZHOU JIAOTONG UNIV
Hybrid power driving method transformed by adding motor to automobile engine
The invention discloses a method for improving hybrid power drive by adding a motor to an automobile engine, and relates to the technical field of automobile hybrid power drive systems, an independent PO motor is added to a gasoline car, and a drive controller, a group of high-capacity power batteries and a 12V DC-DC power supply module are added to the gasoline car. A vehicle networking data interface and a hardware interface of an AI algorithm processing unit are reserved in the vehicle control module, and the system has the advantages that the vehicle networking communication unit and the AI algorithm processing unit are integrated in the vehicle control module, real-time traffic flow, road condition parameters and driving behavior data are collected, a road condition prediction model is constructed by using an LSTM neural network, and the driving behavior data are predicted by using the LSTM neural network. The dynamic power distribution strategy is generated in combination with the driving habits of the user, the defects that in the prior art, an energy management strategy is fixed and cannot adapt to road conditions and driving behavior changes are overcome, fuel consumption is reduced by predicting the energy requirement of the front road condition in advance, and the intelligence and economical efficiency of the hybrid power driving system are enhanced.

Owner:SHENZHEN HUPUS ENERGY TECHNOLOGY CO LTD
Hybrid drive type bionic light-weight nursing mechanical arm
PendingCN120439358AProgramme-controlled manipulatorJointsPhysical medicine and rehabilitationGear wheel
The invention relates to a hybrid drive type bionic light-weight nursing mechanical arm which comprises a shoulder joint module, a rope-driven elbow joint module and a rope-driven wrist joint module which are connected in sequence. The shoulder joint module is of a series-parallel structure, a first servo motor directly drives a center linkage platform to achieve forward flexion and backward extension of the shoulder, and a second servo motor and a third servo motor cooperatively drive a closed-loop structure formed by a driven branch chain unit to achieve adduction, abduction, internal rotation and external rotation of the shoulder. The elbow joint module achieves elbow bending and stretching and inward and outward rotation driven by a fifth servo motor through rope wheel transmission and gear meshing. The wrist joint module achieves forward flexion, backward extension, abduction and adduction of the wrist through a rope winding path and bevel gear meshing. Compared with the prior art, the adaptability and efficiency of the mechanical arm in rehabilitation nursing are improved, it is ensured that all the joints can work precisely and cooperatively under multi-degree-of-freedom movement, and the control precision and stability of a driving system are optimized while the high-load bearing capacity is ensured.

Owner:UNIV OF SHANGHAI FOR SCI & TECH
Aerial vehicle with hybrid drive and rotor unit including rotor shafts coupled by inclined synchro gear wheels
ActiveUS12221217B2Gas turbine type power plantsEfficient propulsion technologiesGear wheelRotor (electric)
An aerial vehicle is disclosed having a hybrid drive unit and a rotor unit wherein the hybrid drive unit includes at least a combustion engine, a generator and a first electric motor and the rotor unit includes a first rotor. The combustion engine is configured to drive the generator to produce electricity, and the generator is coupled to the first electric motor in such a way that the first electric motor is feedable with electricity from the generator. The rotor unit includes a second rotor and the hybrid drive unit includes a second electric motor, wherein the generator is coupled to the second electric motor in such a way that the second electric motor is feedable with electricity from the generator. The first rotor is driven by the first electric motor and the second rotor is driven by the second electric motor.

Owner:SWISSDRONES OPERATING AG
Multi-speed hybrid transmission and transmission operating method
A hybrid transmission system with a multi-speed gearbox. The multi-speed gearbox is configured to rotationally couple a prime mover and an electric machine to different gear ratios during a hybrid drive mode. The multi-speed gearbox includes an electric drive interface gear positioned coaxial to a first primary shaft and a second primary shaft and idly mounted, free to spin, to the second primary shaft and an output shaft that includes an output shaft gear which is fixedly coupled thereto meshes with a gear on a secondary shaft.

Owner:DANA PERFORMANCE TRANSMISSIONS SRL
Series hybrid power gearbox with longitudinally-arranged engine
PendingCN120207086AGas pressure propulsion mountingPlural diverse prime-mover propulsion mountingGear wheelDrive motor
The invention relates to the technical field of hybrid power gearboxes, in particular to a series hybrid power gearbox with a longitudinally-arranged engine, which comprises a longitudinally-arranged engine, a generator and a driving motor, the gear clutch transmission system is connected with the three power sources, transmits power of the three power sources and realizes power generation and driving; the gear clutch transmission system comprises a power generation system, a drive motor pure electric drive system, a generator two-gear pure electric drive system, an engine two-gear drive system and a front drive transfer system. On one hand, rear wheel two-gear driving and double-motor pure electric driving with the engine arranged longitudinally can be achieved, on the other hand, four-wheel hybrid driving is achieved through the built-in front-drive transfer shaft, and meanwhile parts such as a hydraulic control wet clutch or a driving motor and a gear thereof, the front-drive transfer shaft and the like are omitted; various hybrid power transmission products with different functions can be designed on the same platform and produced on the same line, and the requirements of different users and vehicle types are met.

Owner:KUNTAI VEHICLE SYST CHANGZHOU CO LTD
Shield tunneling machine attitude prediction method and system
The invention discloses a shield tunneling machine attitude prediction method and system, and relates to the field of shield tunneling machine construction.The shield tunneling machine attitude prediction method comprises the steps that firstly, shield tunneling machine construction parameters, geological environment parameters and tunnel planning parameters are obtained and preprocessed, and related characteristics are extracted; secondly, mapping the extracted features into nodes by using a heterogeneous graph model, and updating node features in real time through weighted processing of a graph attention mechanism; then, the node features and the connection relation are input into the trained hybrid drive prediction model, and time sequence, physical and space prediction values of the attitude angle of the shield tunneling machine are obtained; and finally, constructing a Bayesian causal graph to quantify the influence of each factor on the attitude angle, carrying out dynamic weighted fusion based on a quantization result, and outputting a final predicted value and a confidence interval. The problem that the prediction effect is poor under the complex geological condition due to the fact that prediction only depends on single shield tunneling machine parameters in the prior art is solved, and accurate prediction of the attitude angle of the shield tunneling machine can be achieved.

Owner:YUSHUN ECOLOGICAL CONSTR
Steering engine and piezoelectric patch hybrid driven variable camber wing
The invention relates to a steering engine and piezoelectric patch hybrid driven variable camber wing, belongs to the technical field of aerospace, and solves the problems of poor wing surface deformation continuity and poor transmission effect in the prior art. The plurality of flexible trailing edge deflection modules are arranged in the straight wing main body; the skin structure is arranged on the outer surfaces of the straight wing main body and the flexible trailing edge deflection module; the module connecting structure is connected with the plurality of flexible trailing edge deflection modules; wherein the straight wing main body comprises a front edge D-shaped structure wing box, a plurality of wing ribs arranged on the rear side of the front edge D-shaped structure wing box, and a bearing rear wall arranged on the rear sides of the wing ribs; each flexible trailing edge deflection module comprises a driving rib assembly fixed to the bearing rear wall, driven rib assemblies arranged on the two sides of the driving rib assembly, carbon rods sequentially connected with the driving rib assembly and the driven rib assemblies, an inhaul cable driving mechanism and a piezoelectric driving mechanism, and the driving rib assembly and the driven rib assemblies are sequentially arranged in the longitudinal direction of the variable-camber wing.

Owner:BEIHANG UNIV
Systems and methods for drive mode control
PendingUS20250222916A1Hybrid vehiclesInstruments for road network navigationCarbon footprintMode control
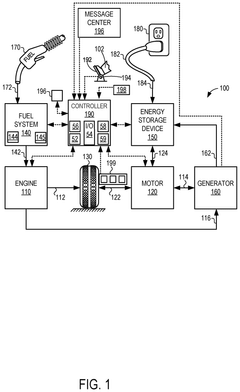
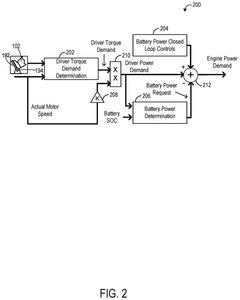
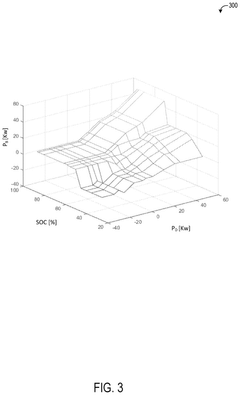
Methods and systems are provided for selectively controlling hybrid drive modes of a hybrid vehicle to reduce emissions. In one example, a method may include using route planning and vehicle operating conditions to identify emissions reducing opportunities. In one example, in response to a route distance not exceeding an electric range, the method includes suppressing an operation of an engine based on the route data, ambient temperature, and cabin pre-conditioning. In response to the route distance exceeding the electric range, further in anticipation of a fuel station along the route, where the fuel station has a fuel with a carbon footprint less than a low carbon threshold, the method includes operating the hybrid vehicle in a charge sustaining or charge increasing mode prior to a refueling event at the fuel station.
Owner:FORD GLOBAL TECH LLC
Lithium battery remaining service life prediction method based on intelligent hybrid drive model
The invention discloses a lithium battery remaining service life prediction method based on an intelligent hybrid drive model, and the method comprises the steps: carrying out the modeling of a long-term degradation trend of a target system through a double-index degradation model (DEDM), and fitting model parameters through a nonlinear least square method; performing dynamic learning on the residual fluctuation of the actual observation data and the degradation trend through a fuzzy random configuration network (F-SCN); and finally, integrating trend prediction and residual prediction results through Gaussian process regression (GPR) to realize high-precision residual life prediction. According to the method, through collaborative optimization of the physical model and the data-driven model, the problem that trend fitting and local fluctuation are difficult to consider under limited data in a traditional method is solved, and the prediction precision and reliability are remarkably improved.

Owner:HUAIYIN INSTITUTE OF TECHNOLOGY
Power inspection exoskeleton modular structure
The invention discloses an electric power inspection exoskeleton modular structure, and belongs to the technical field of human body exoskeleton machine assistance, the electric power inspection exoskeleton modular structure comprises a supporting system, the supporting system comprises a back supporting plate, a waist supporting frame and thigh supporting rods, and a main body supporting frame is formed; the modular interface system comprises at least one group of mechanical interfaces, electrical interfaces and data interfaces which are uniformly distributed on a force transmission path of the support system; the functional module comprises a plurality of interchangeable power assisting modules, operation modules and protection modules, and the functional module is detachably connected with the supporting system through the modular interface system; a hybrid drive system includes a rigid driver and a flexible driver for providing position control and compliance force control, respectively. By means of the modular interface system, plug-and-play of functional modules such as power assisting, operation and protection is achieved, needed exoskeleton configuration can be rapidly assembled, multiple sets of exoskeleton equipment do not need to be arranged, and the equipment utilization rate and task adaptability are greatly improved.

Owner:STATE GRID HENAN ELECTRIC POWER CO LUSHI COUNTY POWER SUPPLY CO