
A moving robot with three degrees of freedom
A technology for handling robots and moving supports, applied in the field of robotics, can solve problems such as difficult to guarantee position and attitude accuracy, high manufacturing cost of five-axis robots, and narrow working space range of the mechanism, so as to achieve clear motion trajectory and position accuracy, simple structure, The effect of low inertia
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2016-07-06
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
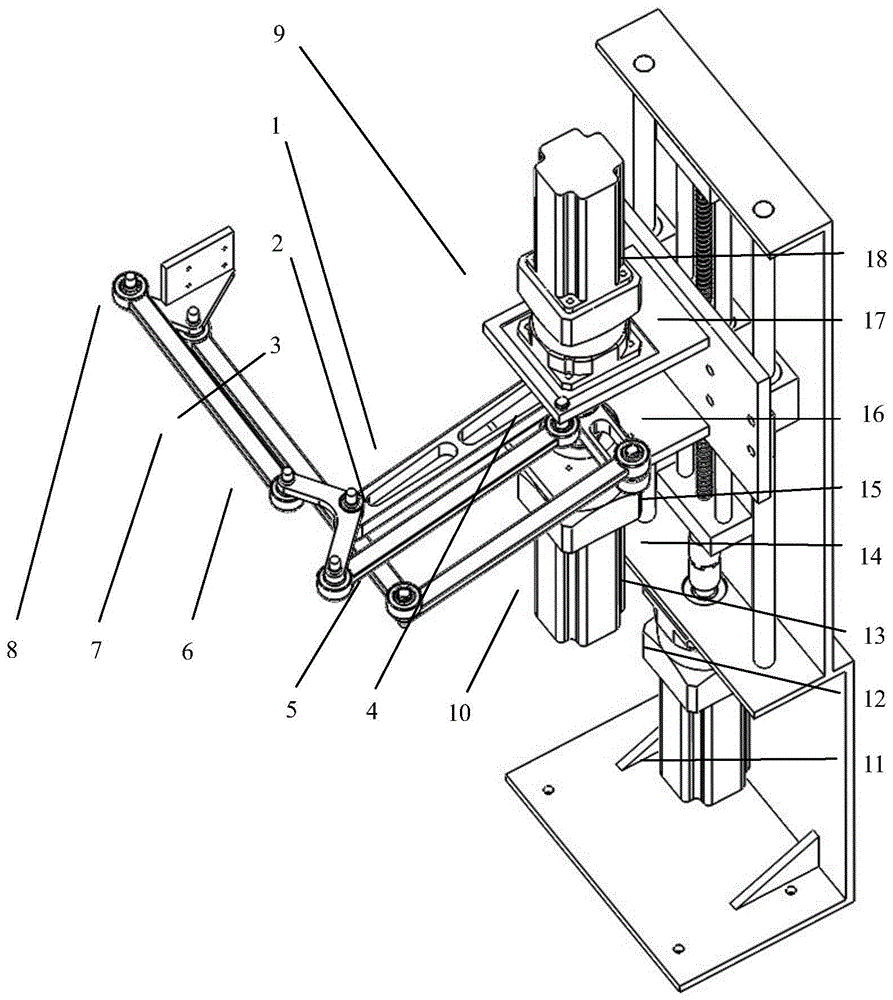
Figure 1 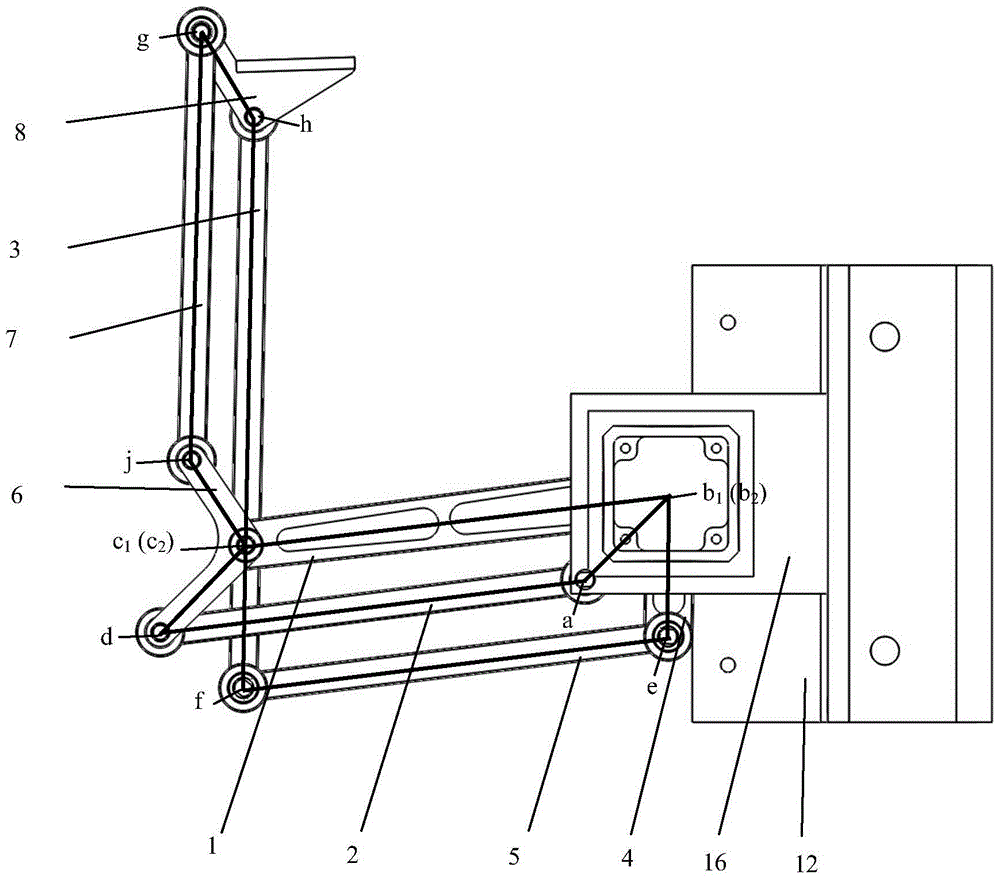
Figure 2 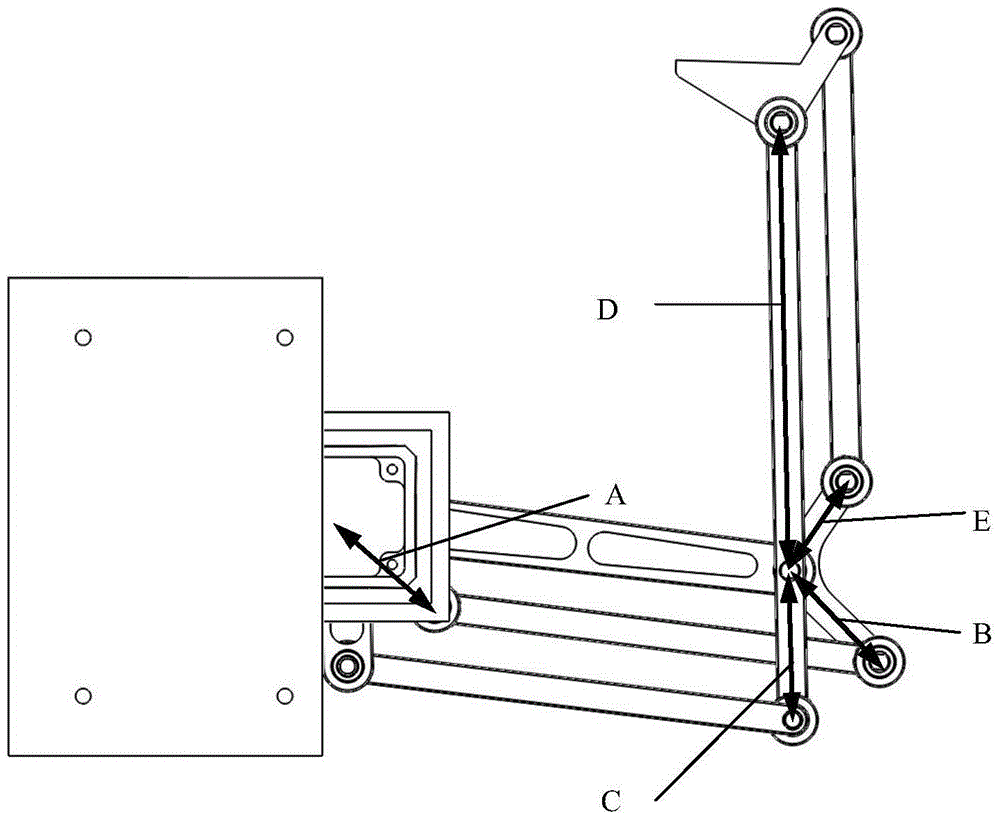
Figure 3
Abstract
Description
Technical field:
[0001] The invention belongs to the technical field of robots, and in particular relates to a three-degree-of-freedom handling robot of a movable support. Background technique:
[0002] In the automated production lines of light industry, medicine, food and electronics industries, such as sorting, packaging and packaging, especially in repetitive, boring and dangerous tasks such as material handling and machine tool loading and unloading, in order to reduce human labor Intensity, improve work efficiency, in the operation process, it is often necessary to place repetitive work robots in the space, but it is unnecessary to use multi-degree-of-freedom space parallel manipulators, or the manufacturing cost is too high, such as the traditional SCARA robot due to its own Factors, three motors and a ball screw are installed on the arm, which limits its range of action, and the manufacturing cost of the serial five-axis robot is too high. However, in the translatio...
Examples
Embodiment Construction
[0024] The present invention will be further described below in conjunction with the accompanying drawings.
[0025] like figure 1 , figure 2 , image 3 , Figure 4 , Figure 5 , Image 6 , Figure 7 As shown, a moving frame three-degree-of-freedom handling robot includes a frame 12 , a ball screw linear slide table, a moving frame 16 , a driving device, a motion branch chain, and a moving platform 8 . The driving device includes a first driving device 9, a second driving device 10, and a third driving device 11; the ball screw linear slide table includes a base 14, a slider 17, a screw 18, and a slide rod 15, and the ball screw linear slide table drives The moving bracket 16 moves in the vertical direction; the motion branch chain includes the first active branch chain, the second active branch chain and the driven branch chain, and the interaction between the active branch chain and the driven branch chain drives the translational movement of the moving platform 8 . ...