
A transient control method for dynamic surface of manipulator servo system based on dead zone and friction compensation
A servo system and control method technology, applied in manipulators, program-controlled manipulators, manufacturing tools, etc., can solve problems such as dead zone and friction, explosive complexity of inversion methods, and uncertainty of model parameters.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2018-09-21
Smart Images
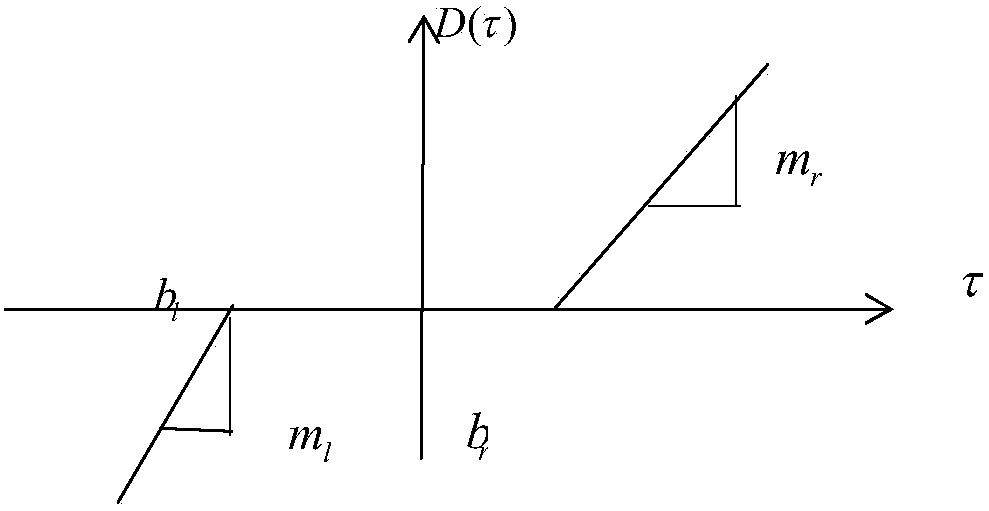
Figure 1 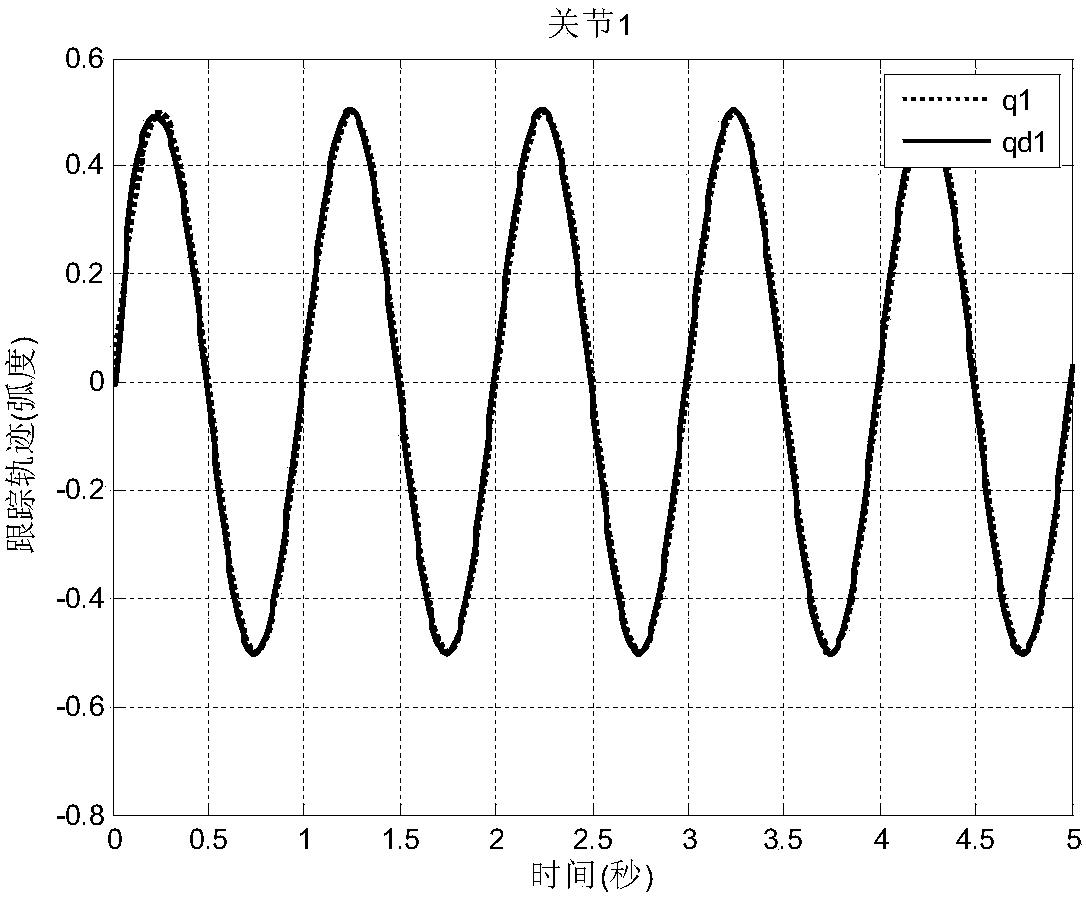
Figure 2 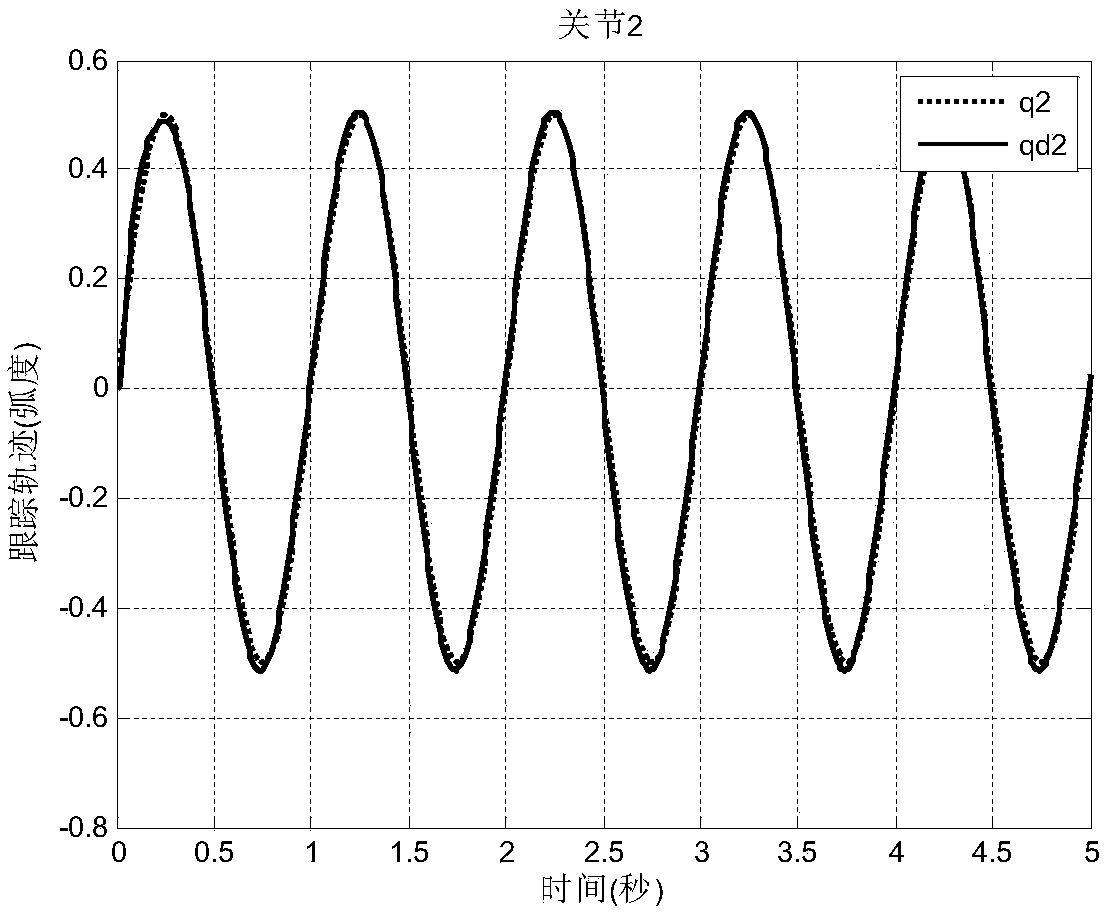
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a dynamic surface transient control method of a mechanical arm servo system based on a dead zone and friction compensation, in particular to an adaptive control method of a mechanical arm servo system with a neural network. Background technique
[0002] The servo system of the manipulator has been widely used in high-performance systems such as robots and aviation vehicles. How to realize the fast and precise control of the servo system of the manipulator has become a hot issue. However, the friction force and unknown dead zone that widely exist in the servo system of the manipulator often lead to the reduction of the efficiency of the control system or even failure. Therefore, in order to improve the control performance, compensation and control methods for dead zone and friction force are essential. The traditional method to solve the nonlinearity of the dead zone is generally to establish an inverse model or an approximate ...
Examples
Embodiment Construction
[0100] The present invention will be further described below in conjunction with the accompanying drawings.
[0101] refer to Figure 1-Figure 5 , a dynamic surface transient control method of a manipulator servo system based on dead zone and friction compensation, comprising the following steps:
[0102] Step 1, establish the dynamic model of the servo system of the manipulator, initialize the system state, sampling time and control parameters, the process is as follows:
[0103] 1.1 The expression form of the dynamic model of the manipulator servo system is
[0104]
[0105] where, q, and are the positions, velocities and accelerations of the manipulator joints; M(q)∈R n×n is the symmetric positive definite inertia matrix of each joint; is the centrifugal Coriolis matrix for each joint; Diagonal positive definite matrix representing the damping friction coefficient; G(q)∈R n×1 stands for gravitational term; T L ∈ R n×1 is the interference term of the motor; τ...