
A Angular Momentum Unloading Method for Electric Propulsion Considering Thruster Arc Loss
A technology of angular momentum unloading and thrusters, which is applied in the direction of aerospace vehicle propulsion system devices, aerospace vehicle guidance devices, etc., and can solve problems such as limited arrangement of electric thrusters, reduced unloading accuracy, and inability to form force couples
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2019-05-24
Smart Images
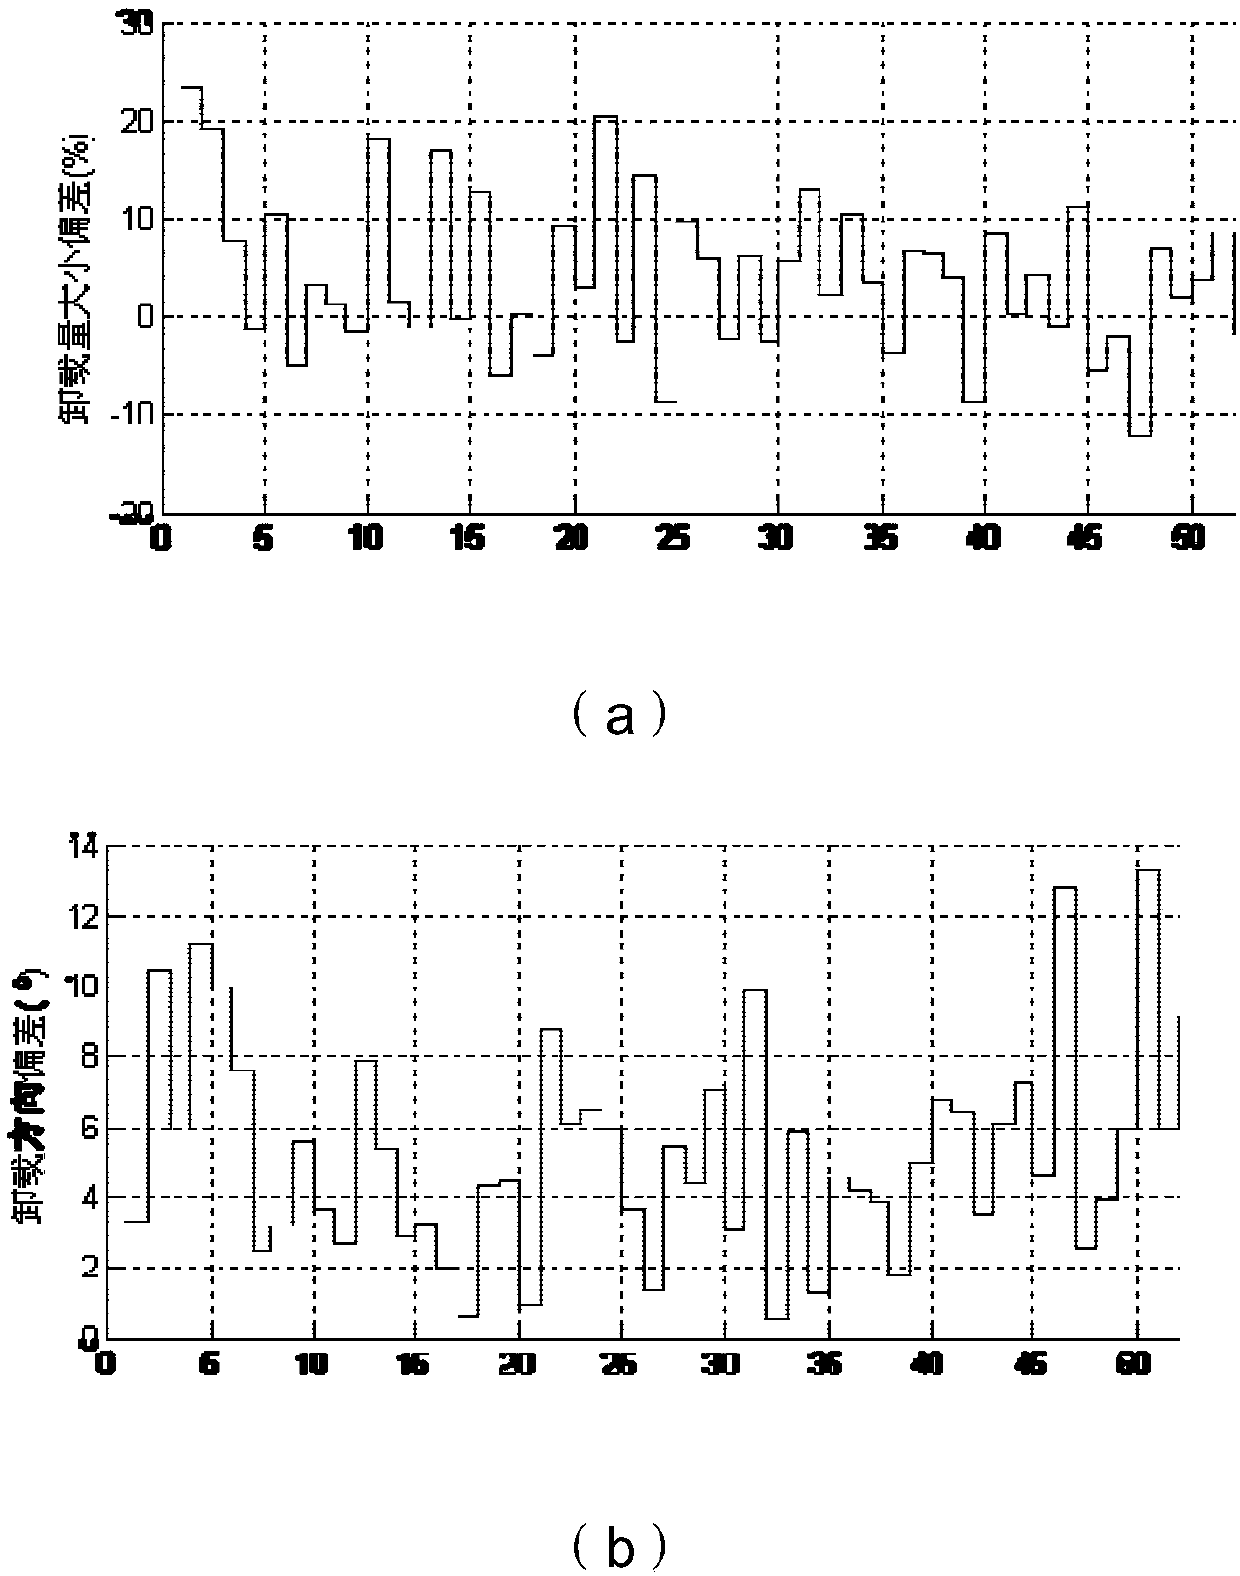
Figure 1 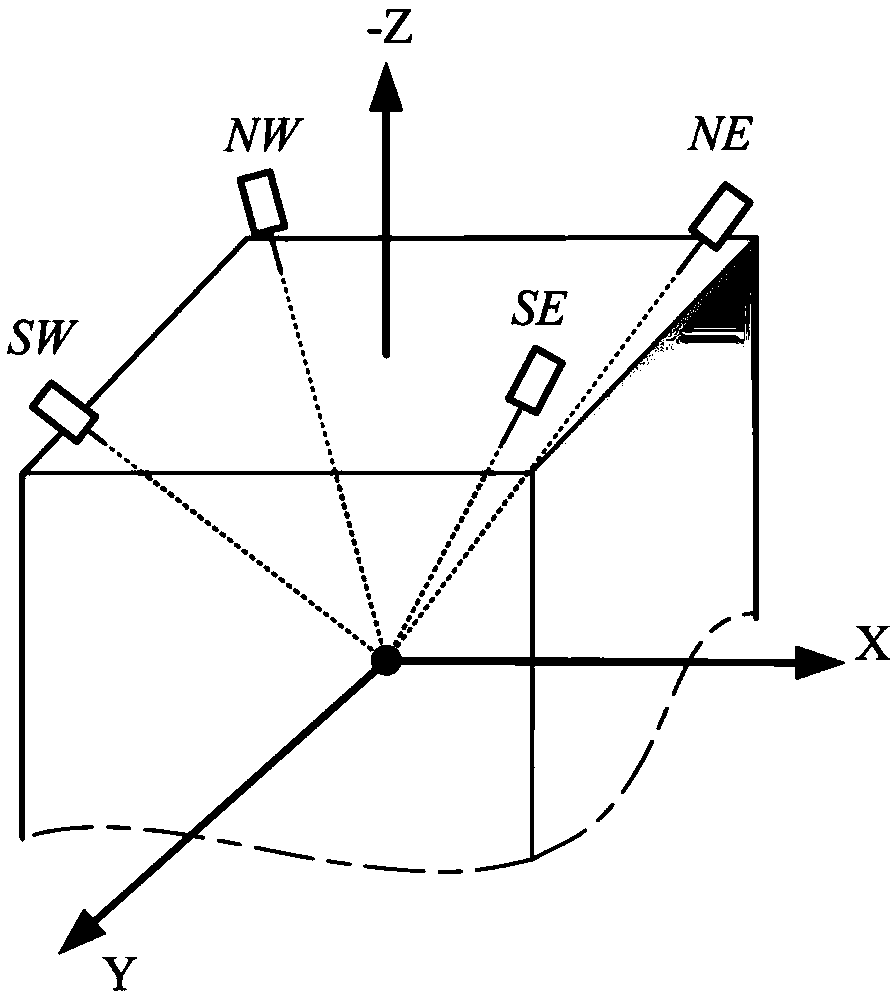
Figure 2 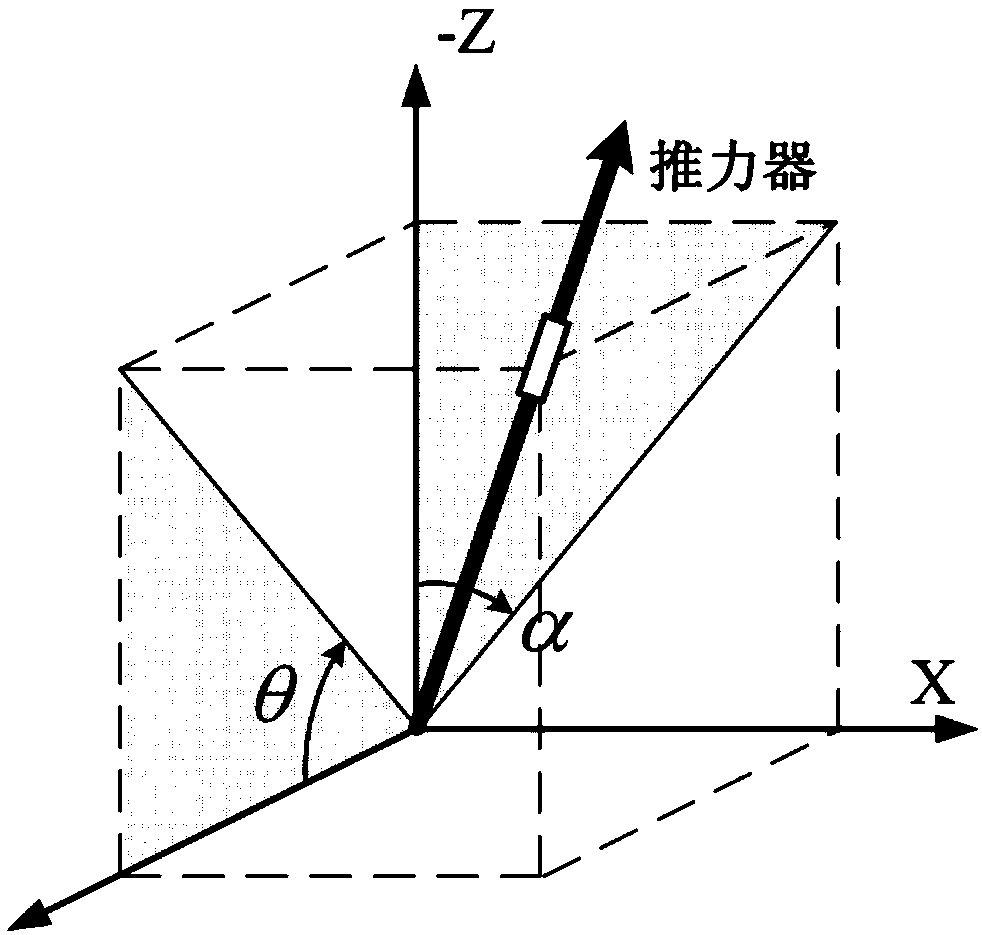
Figure 3
Abstract
Description
technical field
[0001] The invention relates to an electric propulsion angular momentum unloading method considering the arc section loss of the thruster, which is mainly used on the geosynchronous orbit electric propulsion satellite with a conical layout, and is used for the electric propulsion angular momentum unloading of the angular momentum exchange actuator on the star . Background technique
[0002] Electric propulsion is the development trend of communication satellites and deep space probes in recent years, which can significantly reduce fuel consumption during space missions and improve the life of spacecraft. For orbiting satellites, the installation configuration of electric thrusters often adopts a conical layout, and four electric thrusters are installed in pairs and symmetrically on the four sides of the back floor of the satellite. Under this thruster layout, the electric propulsion angular momentum unloading needs to be carried out simultaneously with the o...
Examples
Embodiment
[0155] An electric propulsion angular momentum unloading method considering the loss of the arc section of the thruster is disclosed. The method is suitable for the layout of the conical electric thruster, and four electric thrusters are symmetrically installed in pairs and obliquely on the four sides of the upper back floor of the satellite. Two electric thrusters on each diagonal form a pair, a total of two pairs of electric thrusters. α is the angle between the projection of the thrust direction vector of the electric thruster installed in the northwest (NW) on the x-z plane of the satellite itself and the z-axis, and θ is the thrust direction vector of the electric thruster installed in the northwest (NW) direction in the satellite itself. The angle between the y-z plane projection of the system and the y-axis. This method is calculated at the beginning of a period of variation of the vector adjustment mechanism of an electric thruster, and the steps are as follows:
[01...