

Crawling driving system of artillery barrel robot
A technology for artillery barrels and drive systems, which is applied to motor vehicles, weapon accessories, and weapon testing. It can solve the problems of high assembly difficulty, inability to guarantee quantification, and low accuracy. It can maintain axial movement and be easy to disassemble and maintain. , the effect of improving accuracy
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2019-08-30
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
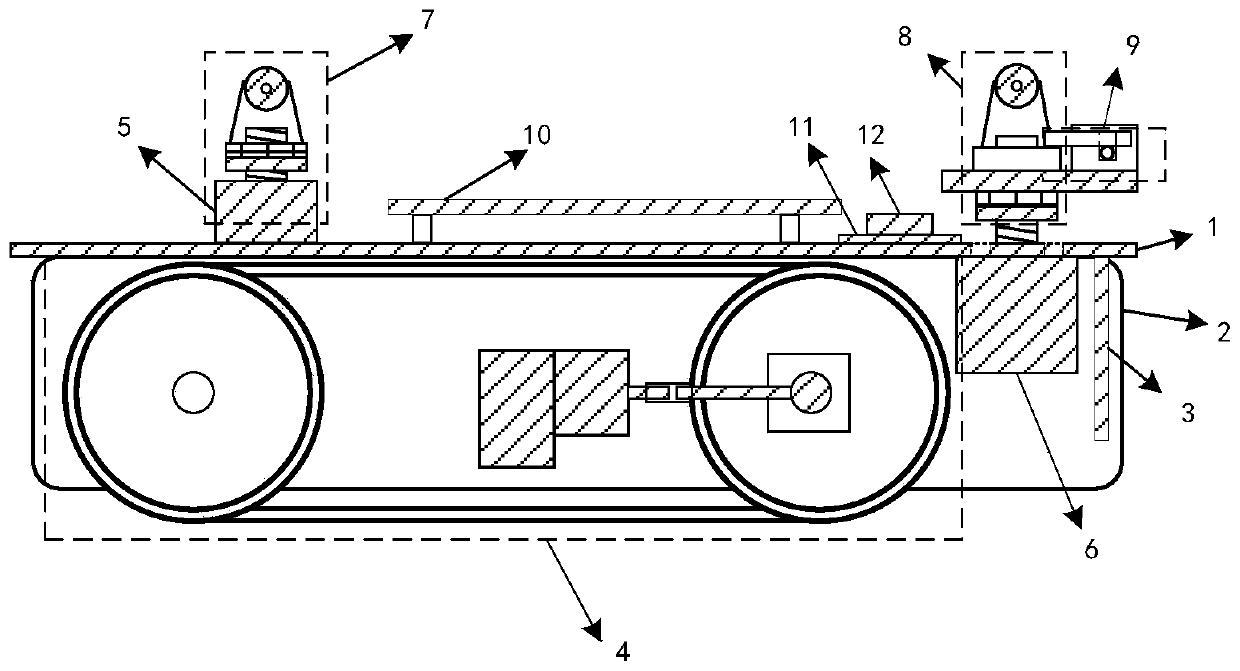
Figure 1 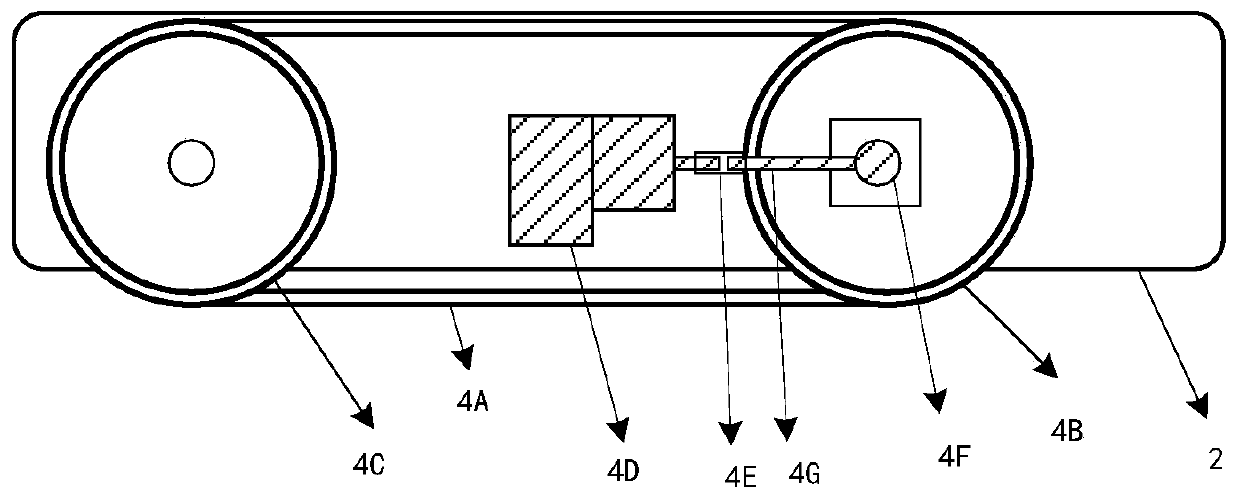
Figure 2 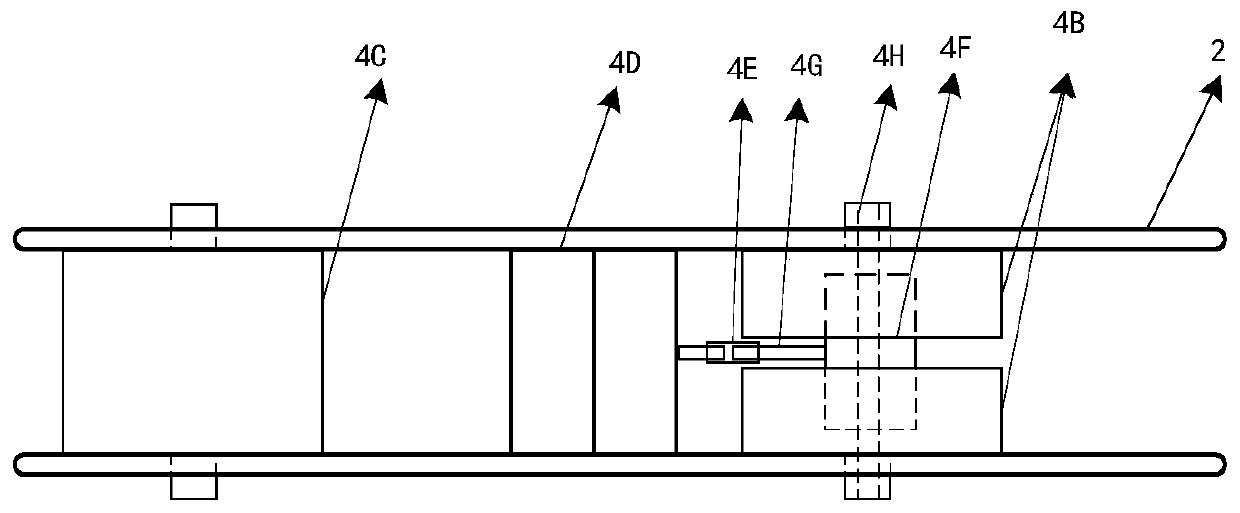
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a crawling drive system, in particular to a crawling drive system for a gun barrel robot. Background technique
[0002] Artillery has the advantages of low price and mature technology in military industry, and plays an important role in military industry weapons. Moreover, due to the special features of the military industry, it is even more necessary to ensure the reliability and safety of the pipeline. The inner wall of the pipeline must be measured regularly to scientifically and quantitatively determine the quality and defect loss of the pipeline. However, the inner bore of the artillery barrel has the characteristics of long length (about 10 meters), small diameter (diameter of 100 mm), and complex internal structure (with rifling and flaws). Compared with qualitative measurement, it is more required to be able to measure the pipeline quantitatively and accurately. Pipeline robots designed for measurement are generally ...
Examples
Embodiment Construction
[0024] The present invention will be further described below in conjunction with accompanying drawing.
[0025] as attached figure 1 As shown, the artillery barrel robot crawling drive system of the present invention includes two vertical support plates 2 arranged in parallel intervals along the vertical direction, and the left and right sides of a horizontal top plate 1 arranged in the horizontal direction are supported and fixed on the left and right sides respectively. On the two vertical support plates 2 mentioned above. A connection plate 3 is fixed at the front end between the two vertical support plates 2, and the connection plate is used to install a measurement subsystem for measuring the shape information of the gun barrel tube wall. The measurement subsystem adopts the existing Systems, such as small industrial cameras and mechanical components or laser displacement sensors and their mechanical components.
[0026] A pulley shaft arranged in the horizontal directi...