
A trajectory tracking control method for underactuated surface ships based on model predictive control
A technology of model predictive control and control method, applied in the direction of adaptive control, general control system, control/regulation system, etc., can solve the problems that model predictive control is difficult to guarantee stability, practical constraints and given performance cannot be satisfied.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2020-07-14
Smart Images
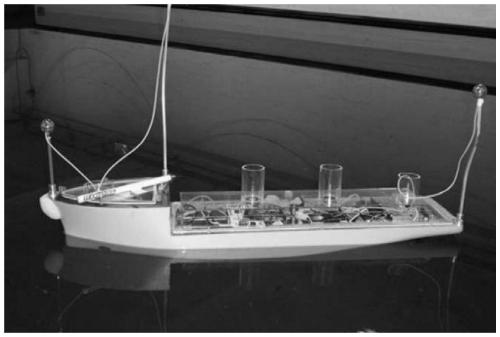
Figure 1 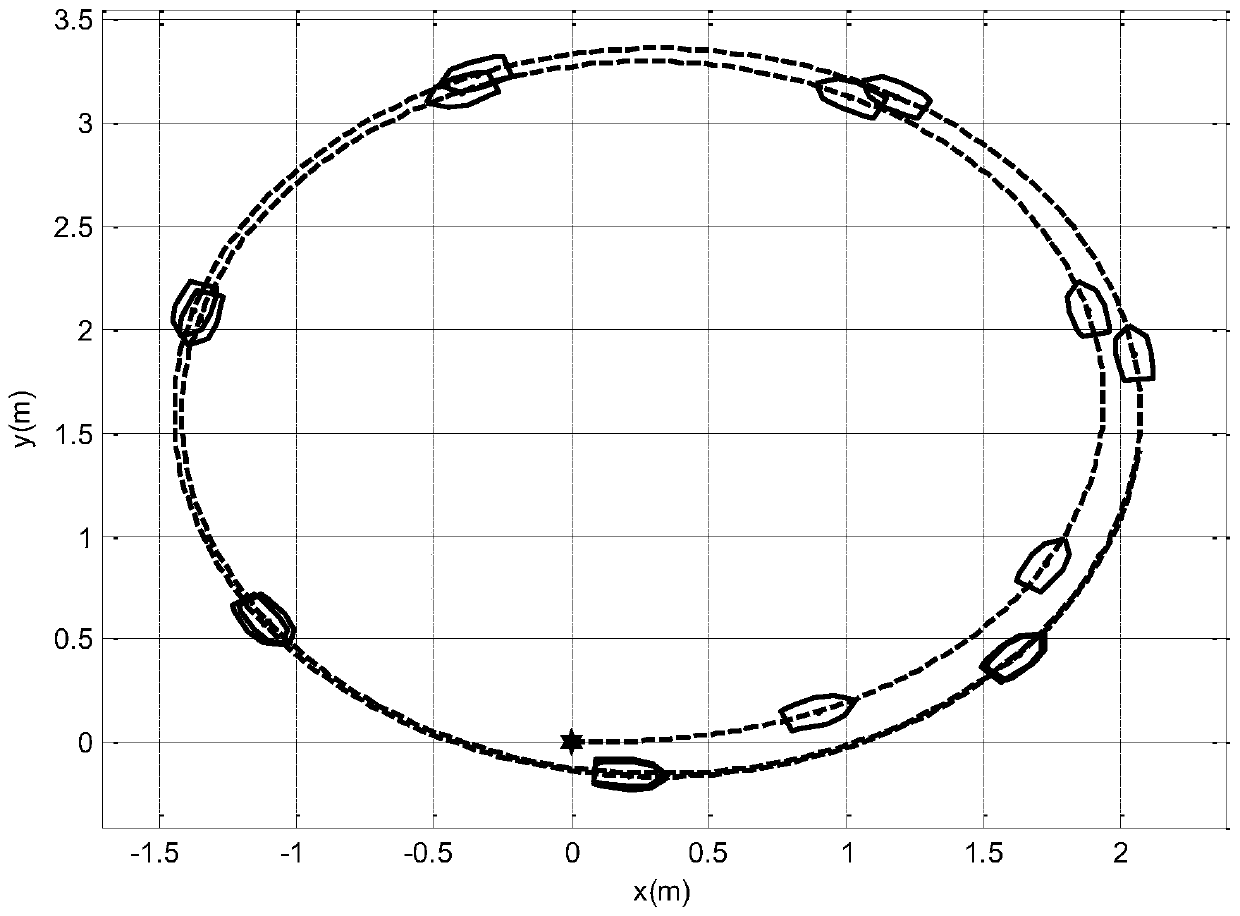
Figure 2 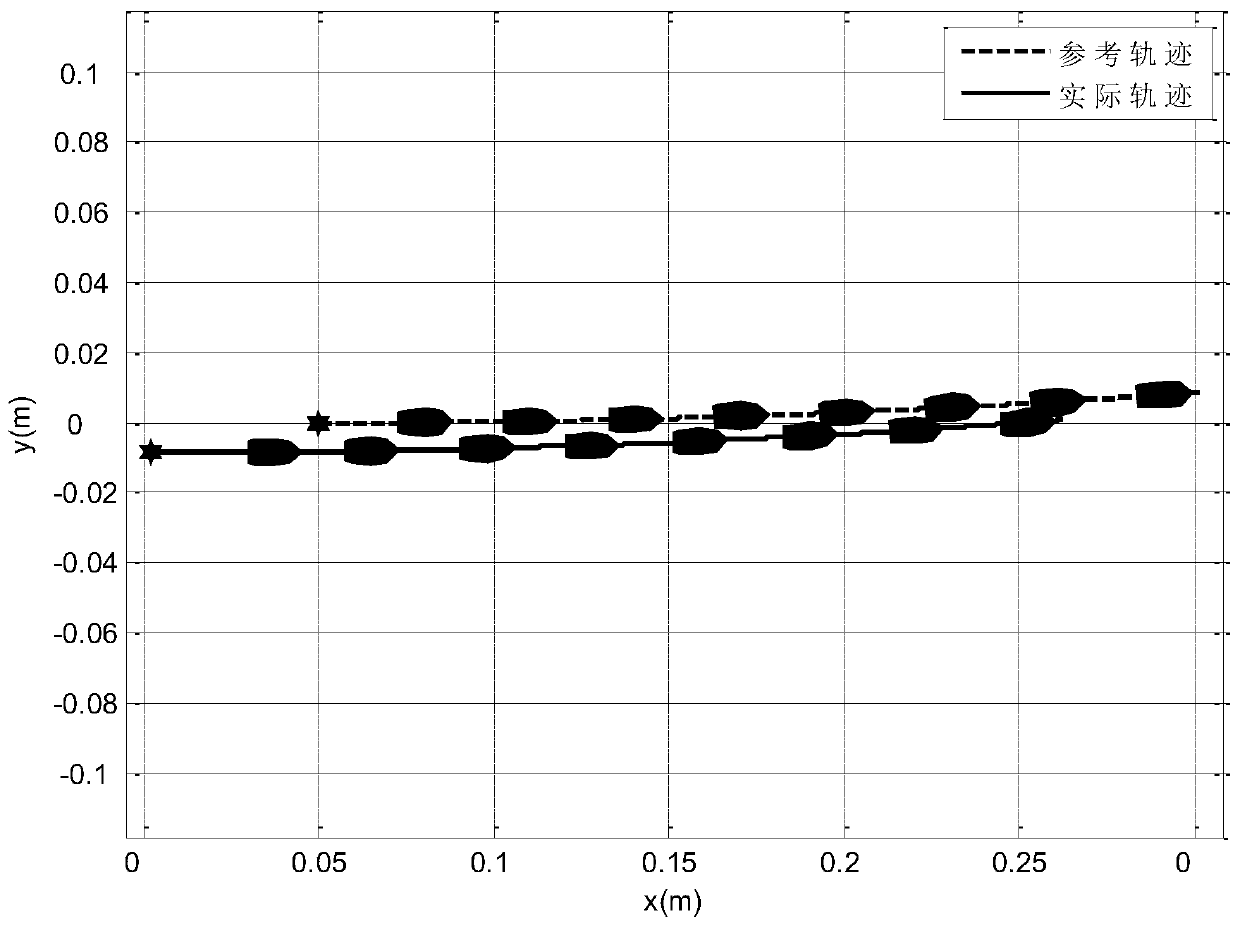
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of surface ship motion control, in particular to an underactuated surface ship trajectory tracking control method based on model predictive control. Background technique
[0002] As the main carrier platform for marine resource exploration, development and marine military applications, marine vehicles have played an extremely important role in both civilian and military applications due to their autonomy, intelligence, multi-function, and strong adaptability. The attention and attention of various developed countries. The main civilian applications are the exploration of marine resources, the survey of seabed topography, the detection of underwater equipment, and deep-sea salvage services. The main application in the military is to understand the underwater battlefield environment in advance (reconnaissance and detection in the theater), destroy enemy equipment and facilities, eliminate underwater dangers, ...
Examples
Embodiment Construction
[0073] Now in conjunction with embodiment, accompanying drawing, the present invention will be further described:
[0074] The principle of the underactuated surface ship trajectory tracking control method based on model predictive control proposed by the present invention is to project the tracking error model into the body coordinate system, and use the Lyapunov direct method and backstepping method to design the control that the tracking error asymptotically converges combined with system constraints to obtain a suitable terminal invariant set; sampling the system state at the current moment, constructing an MPC constrained optimization problem with terminal constraints in the finite time domain; solving the constrained optimization problem, and obtaining the optimal control sequence predicted at the current moment, the first An optimal control acts on the system; the new system state is obtained at the new sampling time and the MPC constraint optimization problem is updated...