
Posture control method of six-freedom-degree double electro-hydraulic vibrostand array simulation system
A technology for simulating systems and control methods, applied in vibration testing, testing of machines/structural components, measuring devices, etc., can solve the problem that the control method of a single shaking table cannot be directly applied to the control array simulation system
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2019-04-19
Smart Images
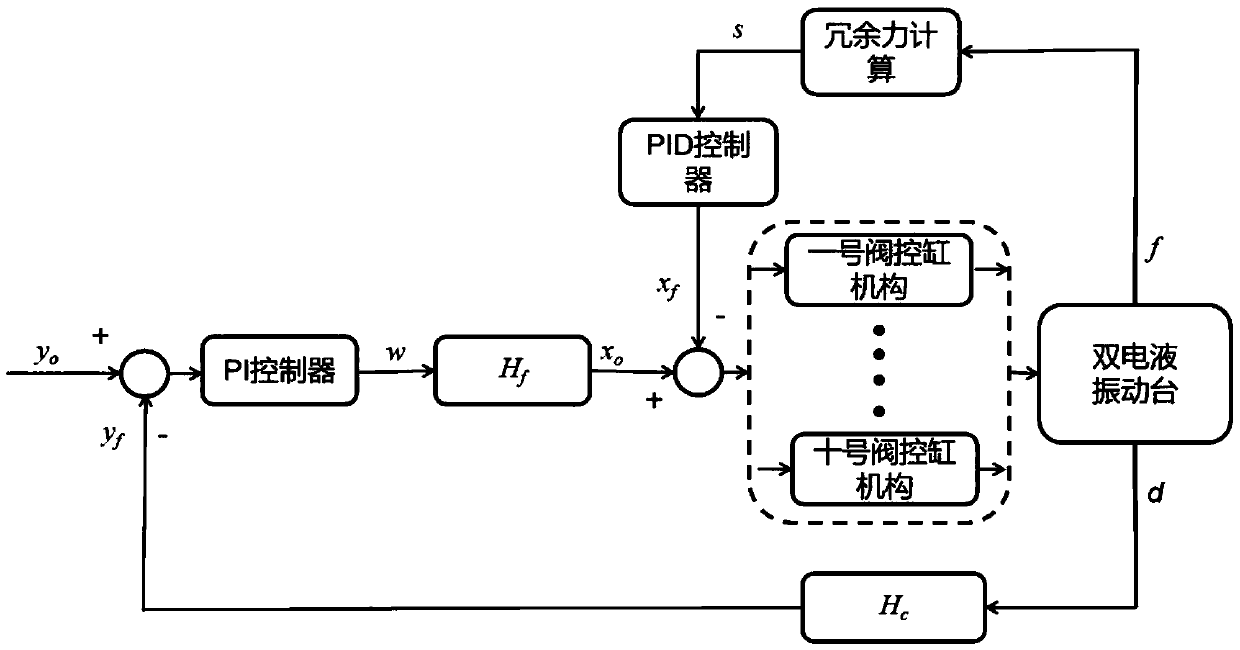
Figure 1 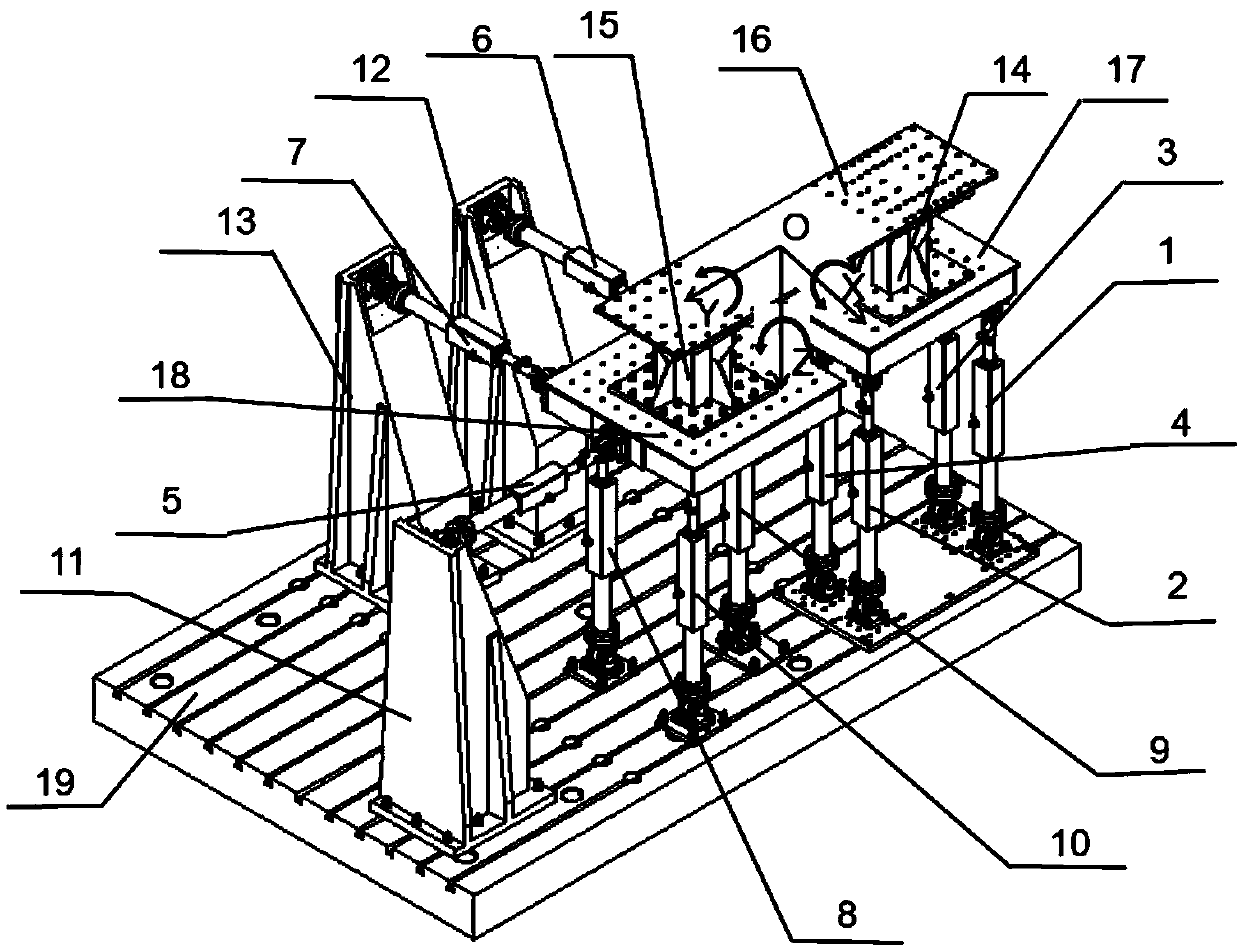
Figure 2 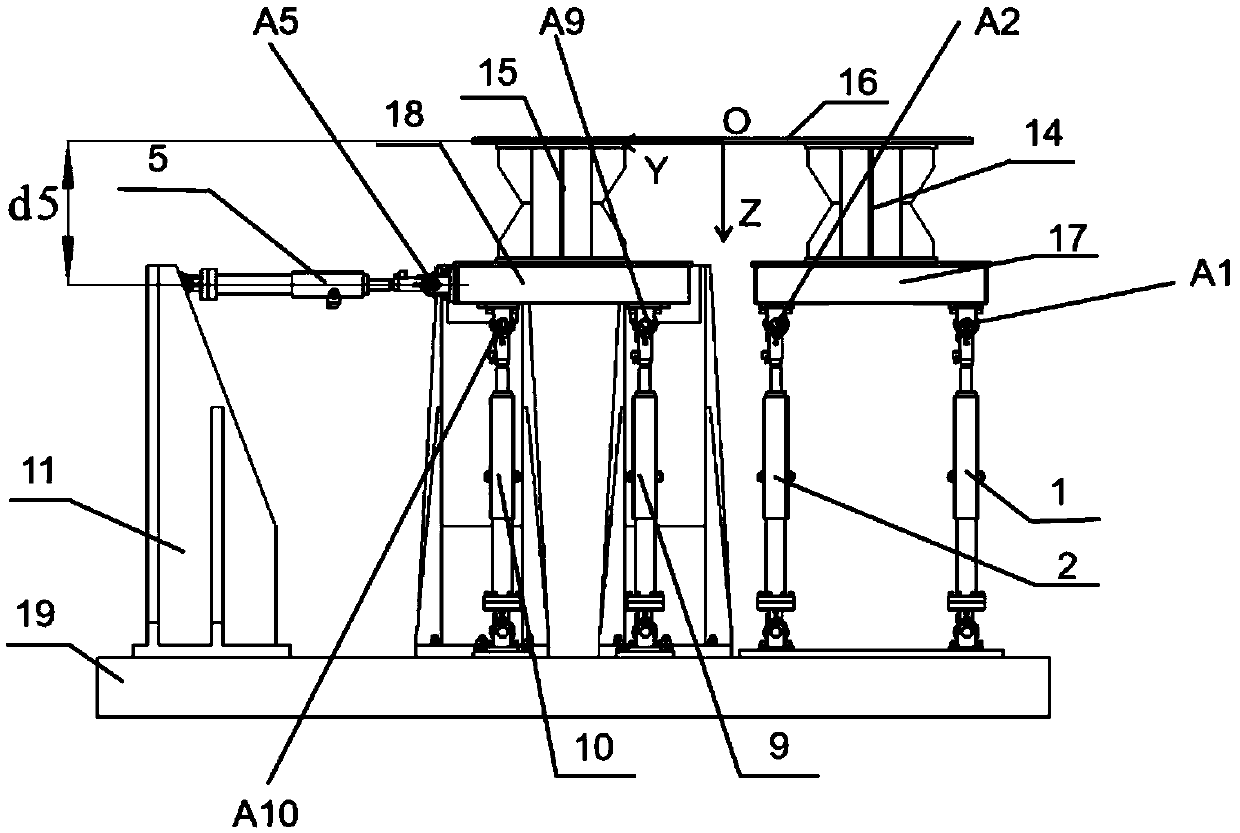
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a six-degree-of-freedom dual electro-hydraulic vibration table, in particular to a pose control method of a six-degree-of-freedom dual electro-hydraulic vibration table array simulation system. Background technique
[0002] Electro-hydraulic vibration table is an important equipment for vibration environment simulation, widely used in aerospace, automobile, ship, bridge and civil engineering construction and other fields. With the development of science and technology, the structural size of the test piece is getting larger and larger. It is difficult to achieve the specified motion state to simulate the real vibration environment in the vibration simulation experiment of a single shaking table. The shaking table array system consists of two or more shaking tables, which creates the necessary conditions for the vibration simulation test of long-span structural specimens.
[0003] Most of the array systems are redundant drive ...
Examples
Embodiment Construction
[0036] The present invention will be further described below in conjunction with the accompanying drawings. Such as Figure 1-4 As shown, a pose control method of a six-degree-of-freedom dual electro-hydraulic shaking table array simulation system, the described six-degree-of-freedom dual electro-hydraulic shaking table array simulation system includes a lower platform 19, an upper platform A17, and an upper platform B18 , pier A14, pier B15, bridge plate 16, three horizontal valve control cylinder mechanisms, seven vertical valve control cylinder mechanisms and three reaction walls, the three horizontal valve control cylinder mechanisms are respectively No. 5 Valve-controlled cylinder mechanism No. 5, No. 6 valve-controlled cylinder mechanism 6 and No. 7 valve-controlled cylinder mechanism 7. The seven vertical valve-controlled cylinder mechanisms are respectively No. 1 valve-controlled cylinder mechanism 1 and No. 2 valve-controlled cylinder mechanism 2 , No. 3 valve-contro...