
Six-degree-of-freedom automatic path optimization intelligent welding platform and method
An automatic optimization, welding platform technology, applied in welding equipment, auxiliary welding equipment, welding/cutting auxiliary equipment, etc., can solve the problems of not being able to complete the welding at one time, the accuracy cannot be guaranteed, and the completion can not be completed, so as to break through the limitation of space arm length. , Improve the accuracy and process quality, reduce the effect of the process of handling
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2022-07-22
Smart Images
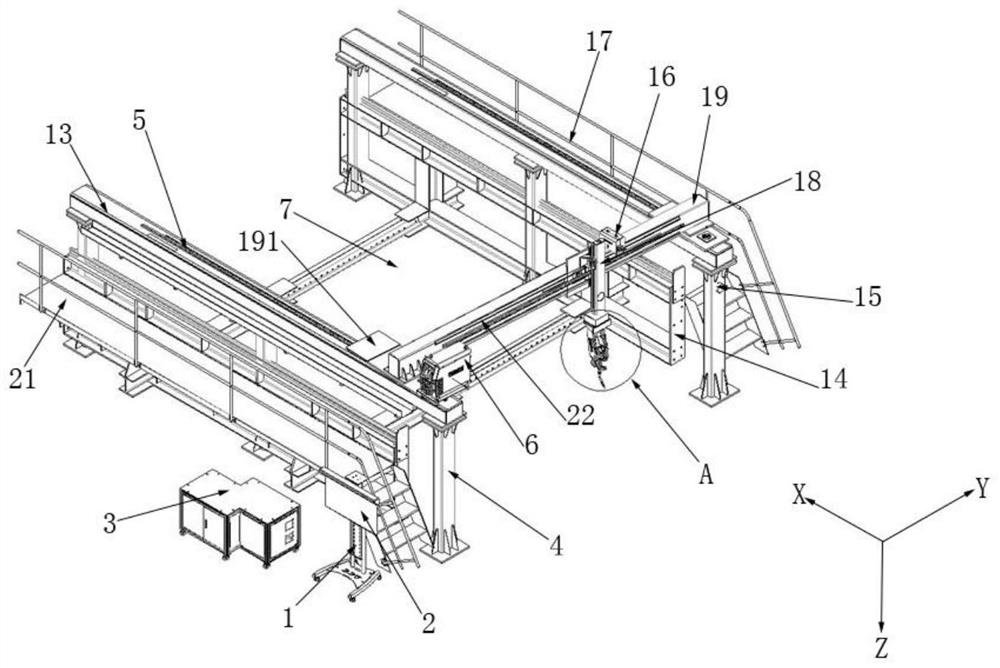
Figure 1 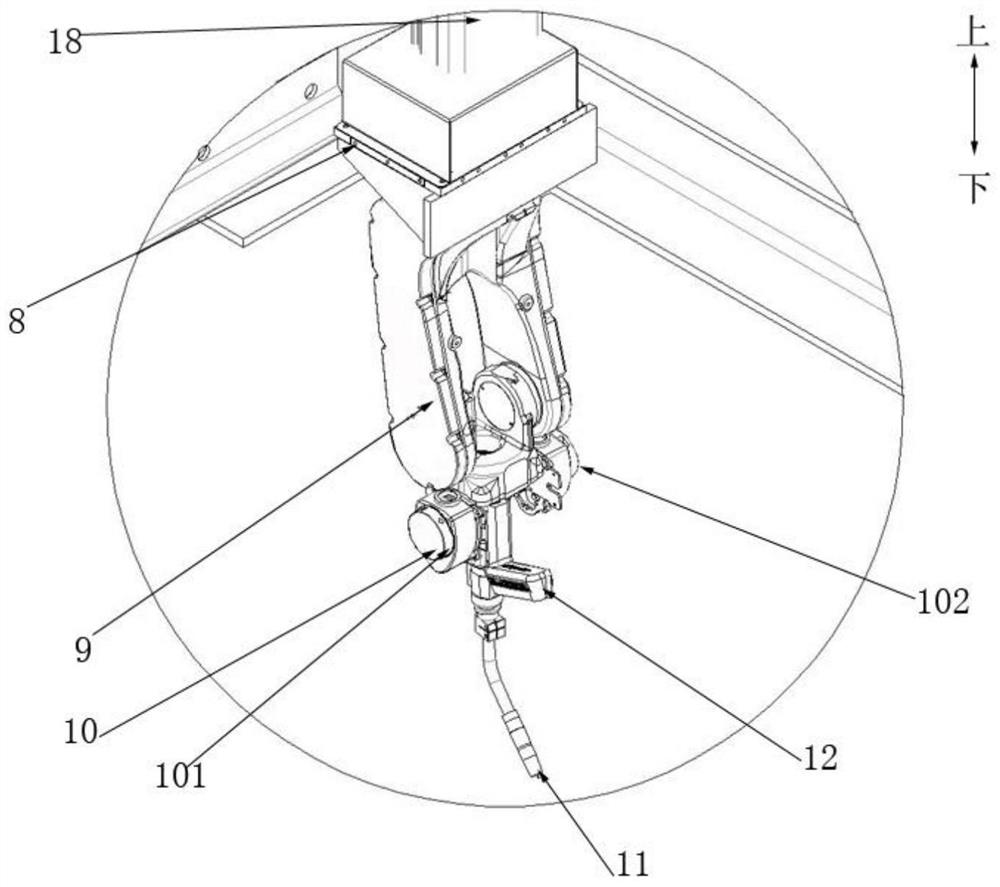
Figure 2 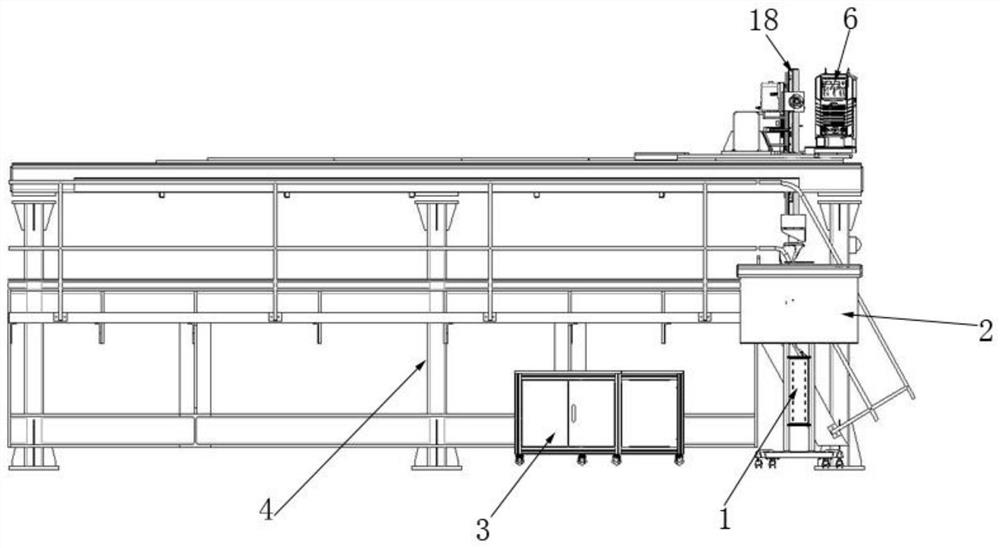
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of industrial robots, in particular to a six-degree-of-freedom automatic optimization path intelligent welding platform and method. Background technique
[0002] The current welding automation solution is generally a welding robot, which can meet the welding requirements of small workpieces. Due to the limitation of the robot arm span, the welding can not be completed at one time for the welding seam with a large spatial span, and the workpiece needs to be welded during the welding process. The secondary clamping or mobile robot uses multiple positioning methods to complete the welding, and the accuracy cannot be guaranteed, and even some long welds with high requirements cannot be completed; and the scheme of using the trolley system and the six-axis welding robot will appear 9 A joint is difficult to solve. The inverse solution of some positions may be difficult to solve, and sometimes there is no solution...
Examples
Embodiment 1
[0042] This embodiment proposes a six-degree-of-freedom automatic optimization path intelligent welding platform, such as Figure 1-3 As shown, the intelligent welding platform with six degrees of freedom automatically optimizes the path includes a welding platform system, the welding platform system is connected with a trolley system, a robot is set on the trolley system, and an intelligent control system controls the robot Weld.
[0043] In the intelligent welding platform with six degrees of freedom automatically optimizing the path described in this embodiment, the welding platform system is connected with the trolley system. On the one hand, this setting enhances the support stability of the welding platform system; Support stability; in addition, it also realizes the intelligent positioning function with three degrees of freedom and large motion range, which improves the welding accuracy. The robot is set on the trolley system, which enables the trolley system to provid...
Embodiment 2
[0091] This embodiment proposes a six-degree-of-freedom automatic optimization path intelligent welding method, and the six-degree-of-freedom automatic optimization path intelligent welding method uses the six-degree-of-freedom automatic optimization path intelligent welding platform described in Embodiment 1, like Figure 4 As shown, the large-scale intelligent welding method for automatically optimizing a path with six degrees of freedom includes the following steps:
[0092] S1, start;
[0093] Step S1 specifically includes the following steps:
[0094] S11. Start:
[0095] S12, the device returns to zero and the system is reset.
[0096] Specifically, step S12 is for the operator to control the reset of the device zero return system.
[0097] S2, clamping the workpiece;
[0098] Step S2 specifically includes the following steps:
[0099] S21, clamping the workpiece.
[0100] Specifically, the operator clamps the workpiece on the welding work platform 7 .
[0101] M...