
Serial robot motion control method and computer storage medium
A technology of robot motion and control method, applied in the direction of program control manipulators, manipulators, manufacturing tools, etc., can solve problems such as low control efficiency and cumbersome solutions, and achieve the effect of improving real-time performance, reducing complexity, and avoiding multi-solution problems.
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2019-04-19
Smart Images
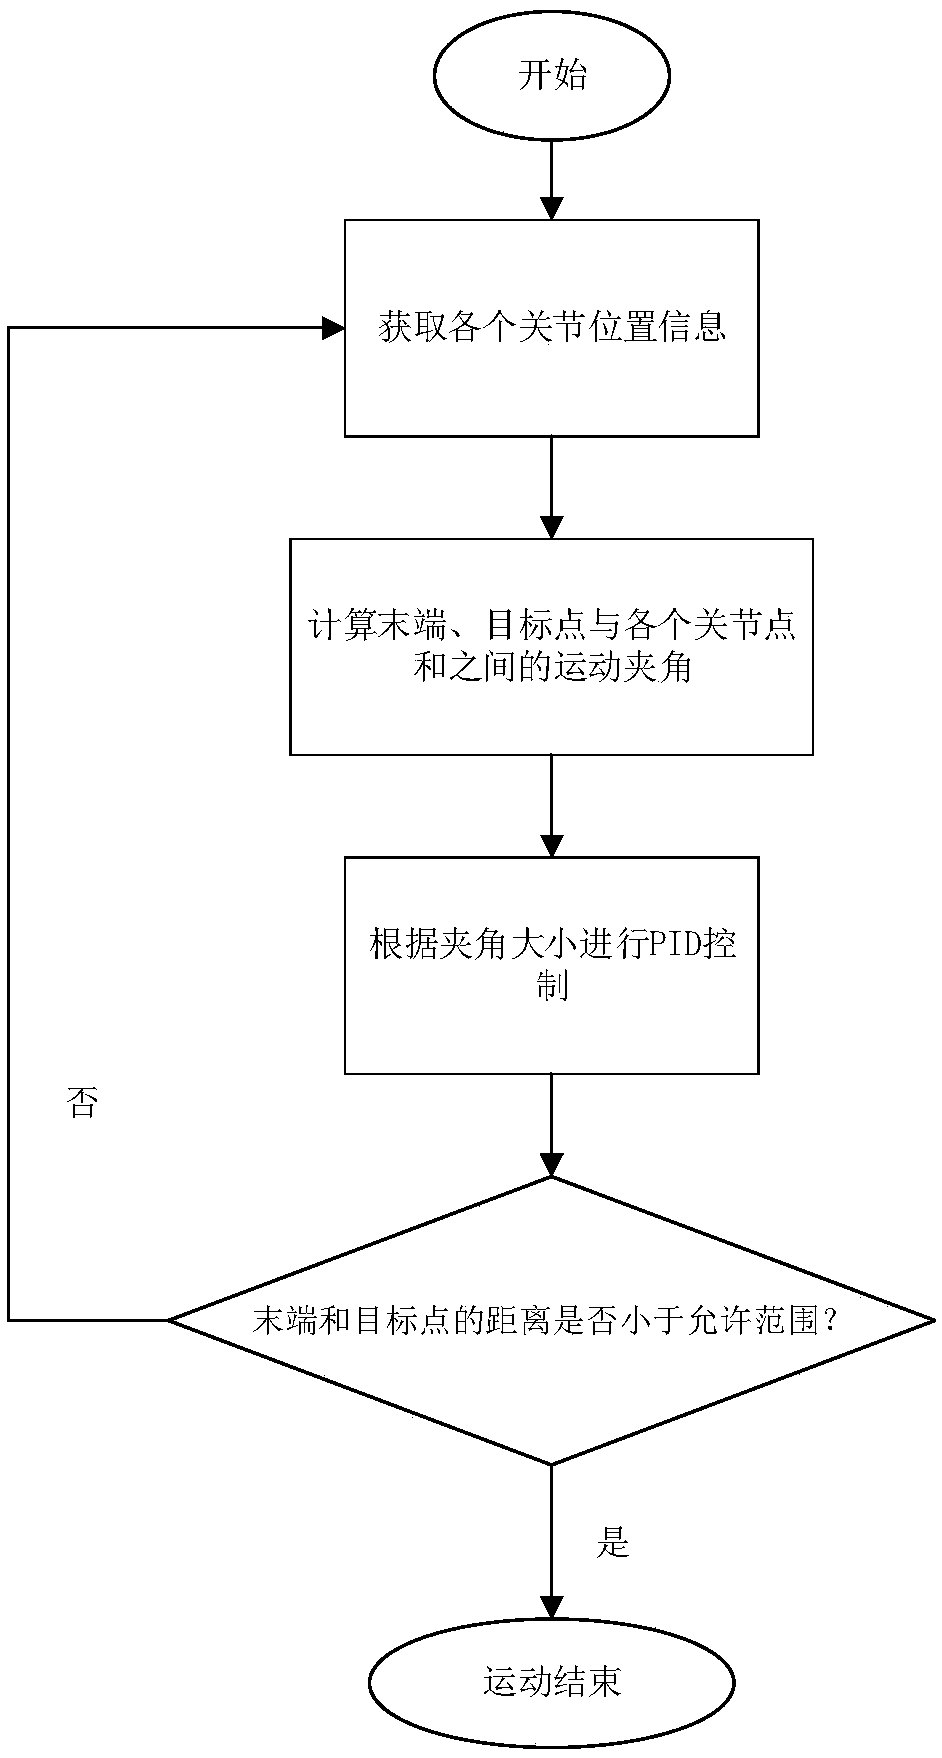
Figure 1 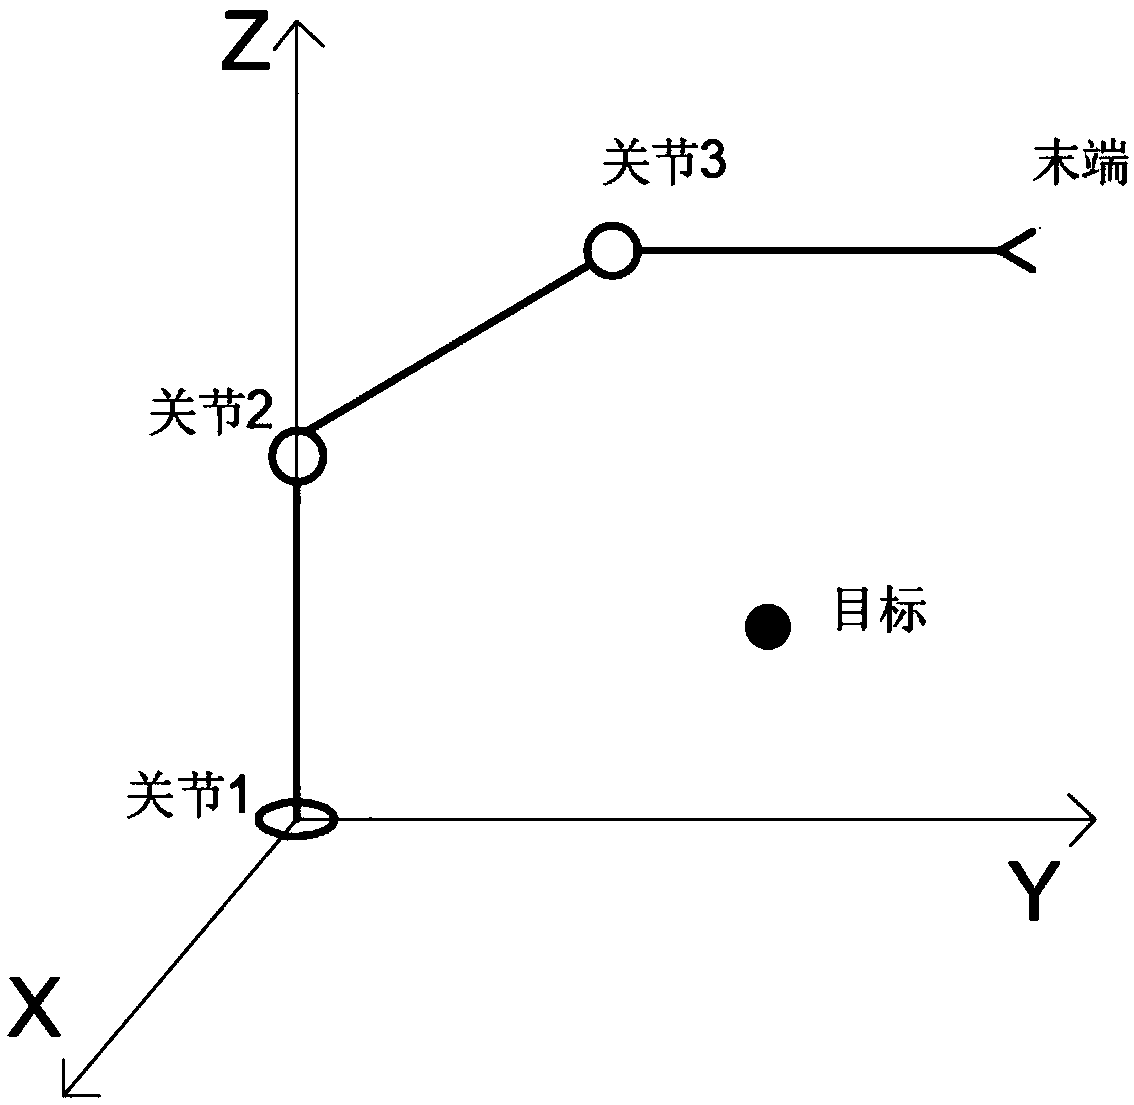
Figure 2 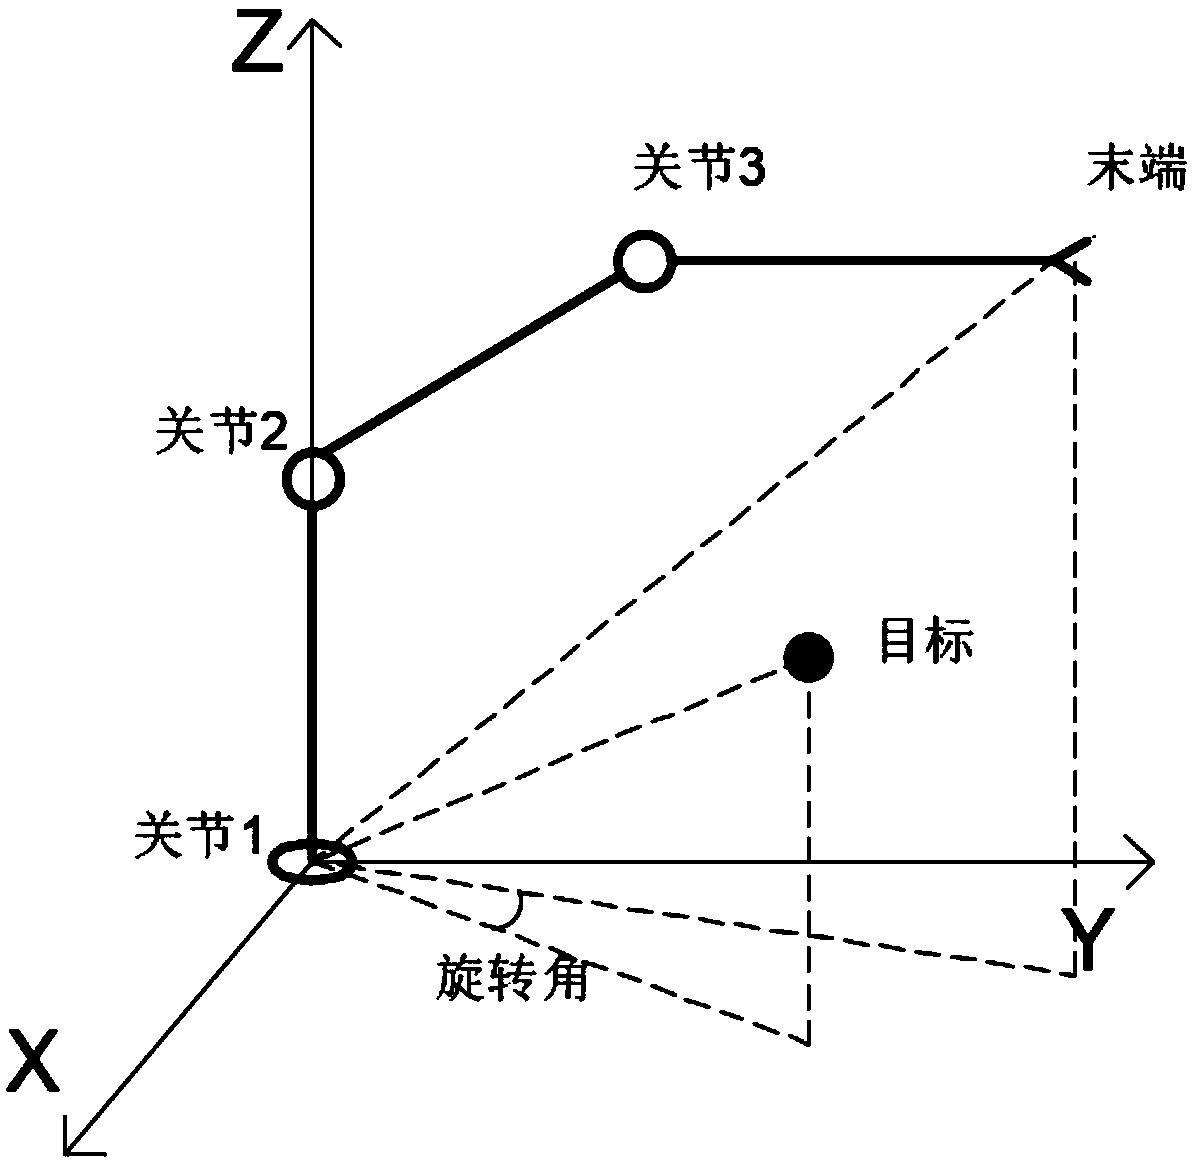
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a motion control method of a serial robot and a computer storage medium, in particular to a motion control method of a serial robot based on joint position information perception and a computer storage medium. Background technique
[0002] At present, robots are widely used in all aspects of human production and life. With the popularity of robots, the performance requirements of robots are also getting higher and higher. The improvement of performance is mainly reflected in flexibility and rapidity. Existing robot control methods are often based on the D-H kinematics model, establishing kinematics matrix equations, and then separating the joint variables to solve them. The solution process of separating variables quickly becomes extremely complicated with the increase of degrees of freedom, and the calculation amount is huge, which cannot overcome the multi-solution problem, which seriously hinders the real-time performance o...
Examples
Embodiment Construction
[0038] In this embodiment, the three-degree-of-freedom series robot arm is taken as an example, and the point-position control of the robot is realized through the perception of joint position information. The specific implementation steps of this method are as follows figure 1 shown.
[0039] (1) Establish a global coordinate system:
[0040] (1.1) The three-dimensional global coordinate system of the series robot is established starting from the first joint point as the coordinate origin, the Z axis is perpendicular to the robot base upwards, the X axis and the Y axis are determined according to the right-hand rule, and the front view is formed by the Z axis and the Y axis floor plan;
[0041] (1.2) Determine its coordinates in the global coordinate system according to the position information of the target point (x o ,y o ,z o );
[0042] Such as figure 2 As shown, it is the initial pose graph and the global coordinate system of the established three-degree-of-freedo...