
Target attitude deep learning tracking acquisition method, learning system and storage medium
A technology of target posture and deep learning, applied in the field of robotics, can solve the problems of large amount of calculation, low degree of intelligence, and low degree of motion restoration, and achieve high degree of imitation restoration, high degree of intelligence, and reduced demand Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2021-04-16
Smart Images
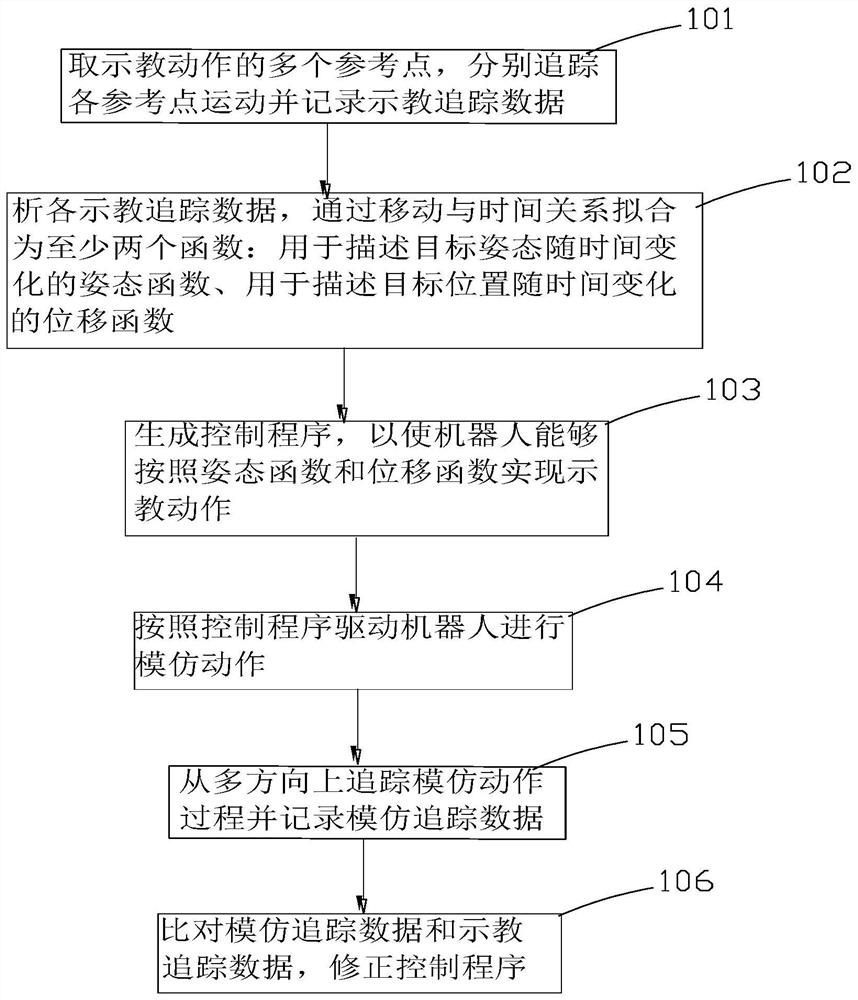
Figure 1 
Figure 2
Abstract
Description
technical field
[0001] The present invention relates to the technical field of robots, and in particular to a tracking acquisition method, a learning system and a storage medium based on deep learning of target posture. Background technique
[0002] A robot (Robot) is a high-tech product with a preset program or principled program inside. After receiving a signal or instruction, it can judge and take actions to a certain extent, such as moving, picking up, and swinging limbs. The task of the robot is mainly to assist or even replace the work of humans in some occasions. The actions and information judgments involved in the actual work scene are often very complicated, and it is difficult to record them all in the robot in the form of a program in advance. Knowledge, self-learning to improve adaptability and intelligence level, that is, robot learning, has become a very hot research focus in the robot industry.
[0003] In the prior art, the process of the robot simulating t...
Examples
Embodiment Construction
[0011] In order to make the object, technical solution and advantages of the present invention clearer, the present invention will be further described in detail below in conjunction with the accompanying drawings and embodiments. It should be understood that the specific embodiments described here are only used to explain the present invention, not to limit the present invention.
[0012] In describing the present invention, it should be understood that the terms "length", "width", "upper", "lower", "front", "rear", "left", "right", "vertical", The orientation or positional relationship indicated by "horizontal", "top", "bottom", "inner", "outer", etc. are based on the orientation or positional relationship shown in the drawings, and are only for the convenience of describing the present invention and simplifying the description, rather than Nothing indicating or implying that a referenced device or element must have a particular orientation, be constructed, and operate in a ...