
Multi-degree-of-freedom hoisting manipulator
A technology of manipulator and degrees of freedom, applied in cranes and other directions, can solve the problems of high noise during the movement of the hoisting mechanism, heavy objects swinging, rotating, and small movement range of the boom, so as to achieve smooth operation, reduce noise, and improve use stability. and the effect of the safety factor
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2018-04-20
Smart Images
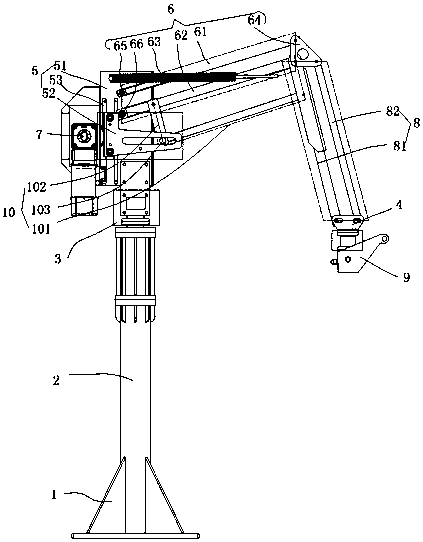
Figure 1 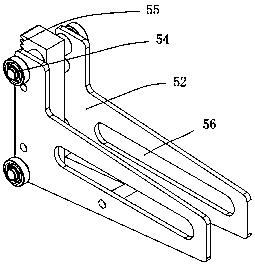
Figure 2 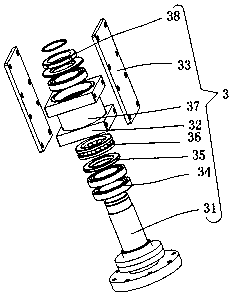
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of mechanical equipment, and in particular relates to a multi-degree-of-freedom hoisting manipulator. Background technique
[0002] At present, the small lifting equipment in China is composed of booms, turntables, frames, outriggers and other parts. The mechanical action of the small crane is realized through the actions of the boom luffing, telescopic, hoisting and other mechanisms, and the lifting operation is realized through the combination of different actions. Control requires human hands to press the hydraulic rod to control the expansion and contraction of the oil cylinder, which is inefficient, time-consuming and laborious, and the leakage of hydraulic oil cannot be completely avoided, causing pollution to the working environment; the movement process of the hoisting mechanism is noisy, the positioning accuracy is low, and heavy objects It is easy to swing and rotate during the lifting process, an...
Examples
Embodiment 1
[0019] Figure 1 to Figure 5 A specific embodiment of the invention is shown in which figure 1 It is a structural schematic diagram of the present invention; figure 2 It is a structural schematic diagram of the moving block in the up and down sliding mechanism of the present invention; image 3 It is an explosion schematic diagram of the first rotating mechanism of the present invention; Figure 4 It is a structural schematic diagram of the second rotating mechanism of the present invention; Figure 5 It is a structural schematic diagram of the machine head of the present invention.
[0020] See Figure 1 to Figure 5 , a multi-degree-of-freedom lifting manipulator, including a base 1, a column 2 arranged on the base 1, and a manipulator structure arranged on the column 2, the manipulator structure includes a first rotation mechanism 3, a second rotation mechanism 4. Up and down sliding mechanism 5, cantilever mechanism 6, reduction motor 7, swing arm mechanism 8 and mach...