
A master-slave electromechanical servo cooperative motion control system
A technology of servo control and cooperative motion, applied in control systems, vector control systems, motor generator control, etc., can solve the problems of large specific power and load requirements, low dynamic performance indicators, etc., and achieve high power-to-mass ratio and low product cost Moderate, compact space layout effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2018-08-31
Smart Images
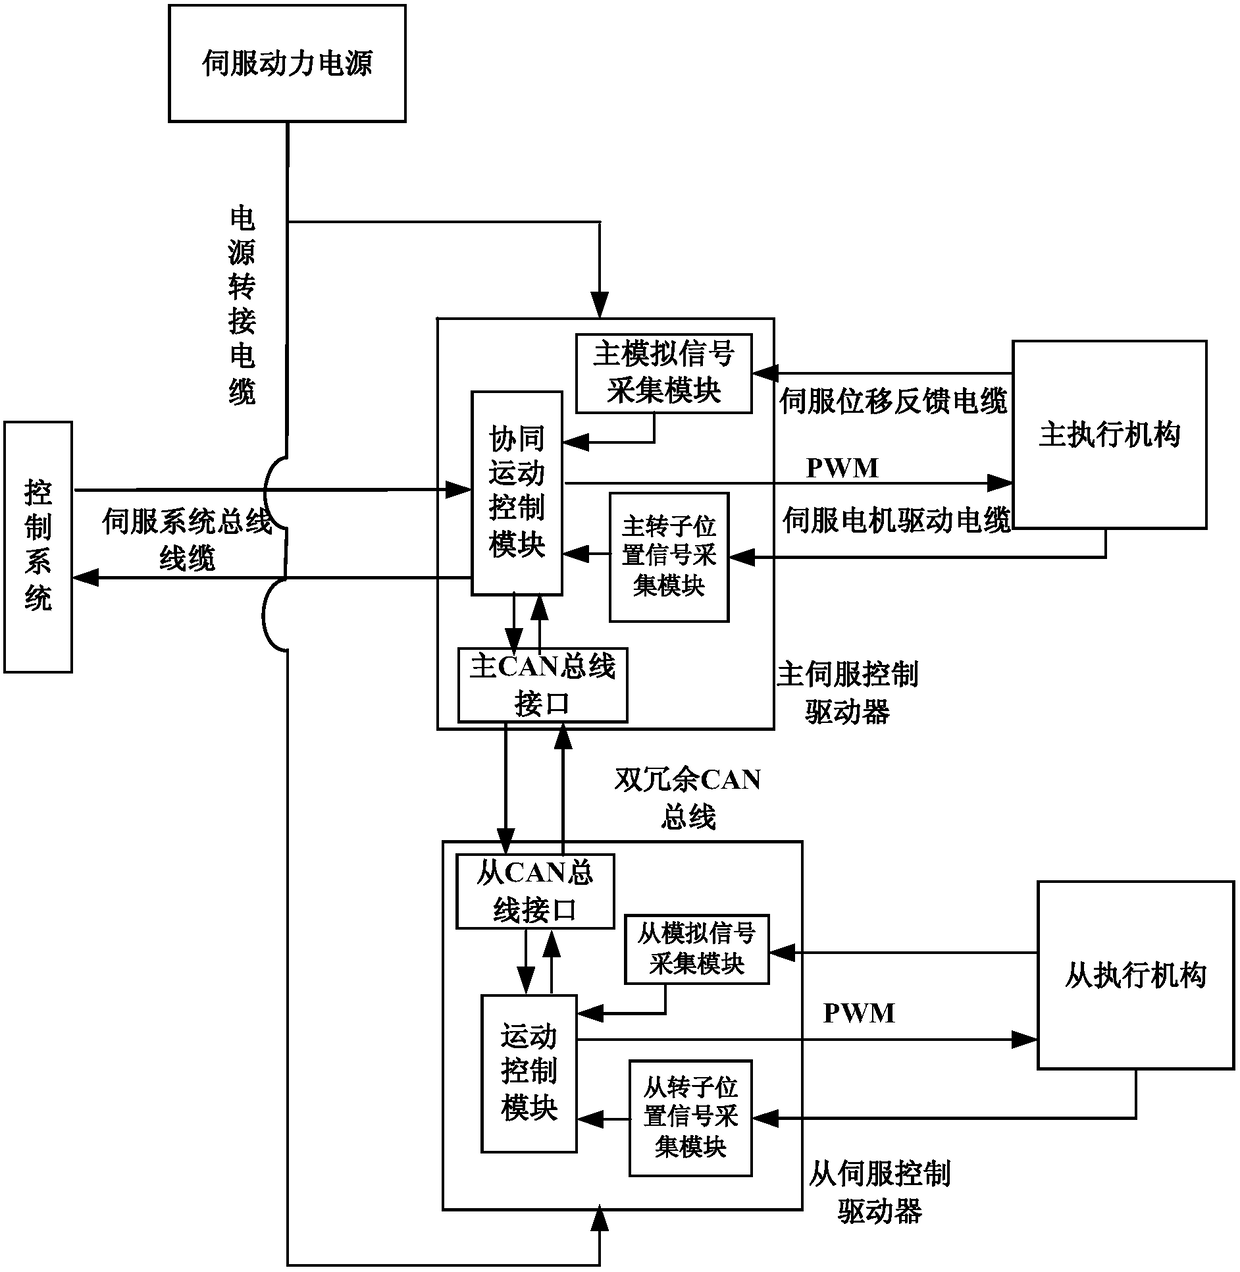
Figure 1 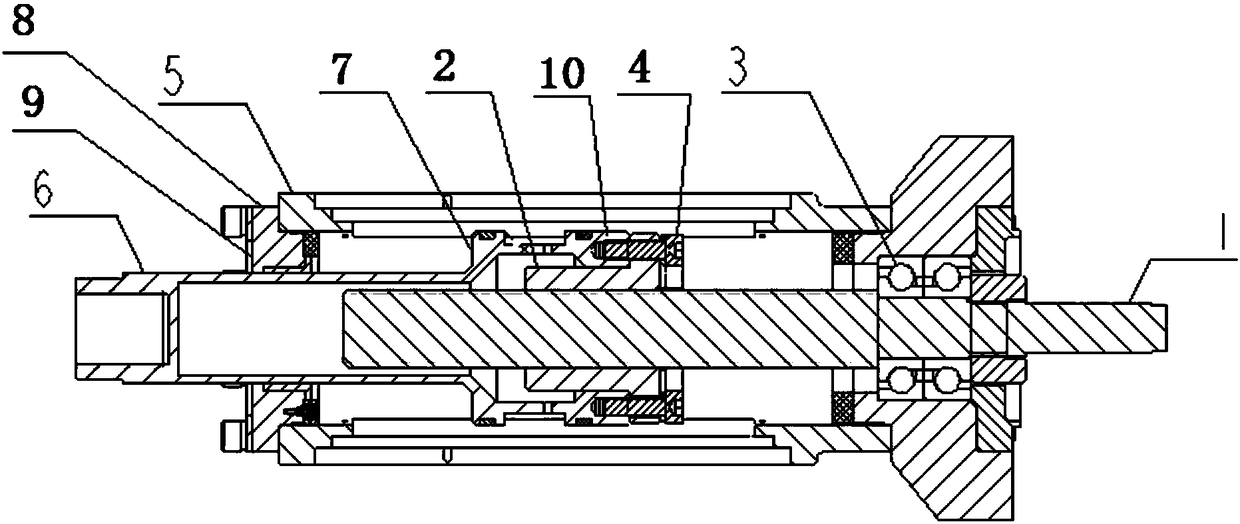
Figure 2
Abstract
Description
technical field
[0001] The invention relates to an application field of aerospace thrust vector control electromechanical servo, in particular to a cooperative motion control system of a master-slave electromechanical servo system. Background technique
[0002] At present, the aerospace application of traditional electromechanical servo is usually concentrated in the fields of instrumentation equipment and small air rudder control. The technical problem of causing nozzle overswing and damage to the nozzle structure is still a difficult problem that needs to be overcome. , the high-power electromechanical servo system above the kilowatt level has the advantages of high specific power, light weight, small size, easy disassembly and maintenance, etc. that cannot be compared with the high-power hydraulic system, so the electromechanical servo thrust vector control of the high-power level above the kilowatt level The system requirements are becoming more and more urgent, especial...
Examples
Embodiment Construction
[0031] Below in conjunction with accompanying drawing and specific embodiment the present invention is described in further detail:
[0032] The main task of the main servo control driver is to receive all kinds of instructions issued by the control system, generate an interrupt after receiving the bus message of the control system and enter the interrupt service program, and perform various operations required by the bus protocol; and communicate through the dual redundant CAN bus Query whether a new CAN message is received in the timer interrupt service program, and receive the running status of the slave servo control driver and the slave actuator in real time. According to the required nozzle swing angle, calculate the expansion and contraction lengths corresponding to the master and slave actuators in real time, and adjust the acceleration factor and jerk factor of the master and slave motion trajectories in real time to realize the master and slave actuators. Real-time m...