
High-precision lead screw adjusting structure
A technology with adjustment structure and high precision, which is applied to transmission devices, instruments, measuring devices, etc., can solve the problems that the operation accuracy is not easy to meet the use requirements, the mechanical motion accuracy and the use requirements of different application modes are high, and the adjustment effect is good and the accuracy is improved. , high precision effect
Patent Information
- Authority / Receiving Office
- CN · China
- Current Assignee / Owner
- Publication Date
- 2021-10-01
Smart Images
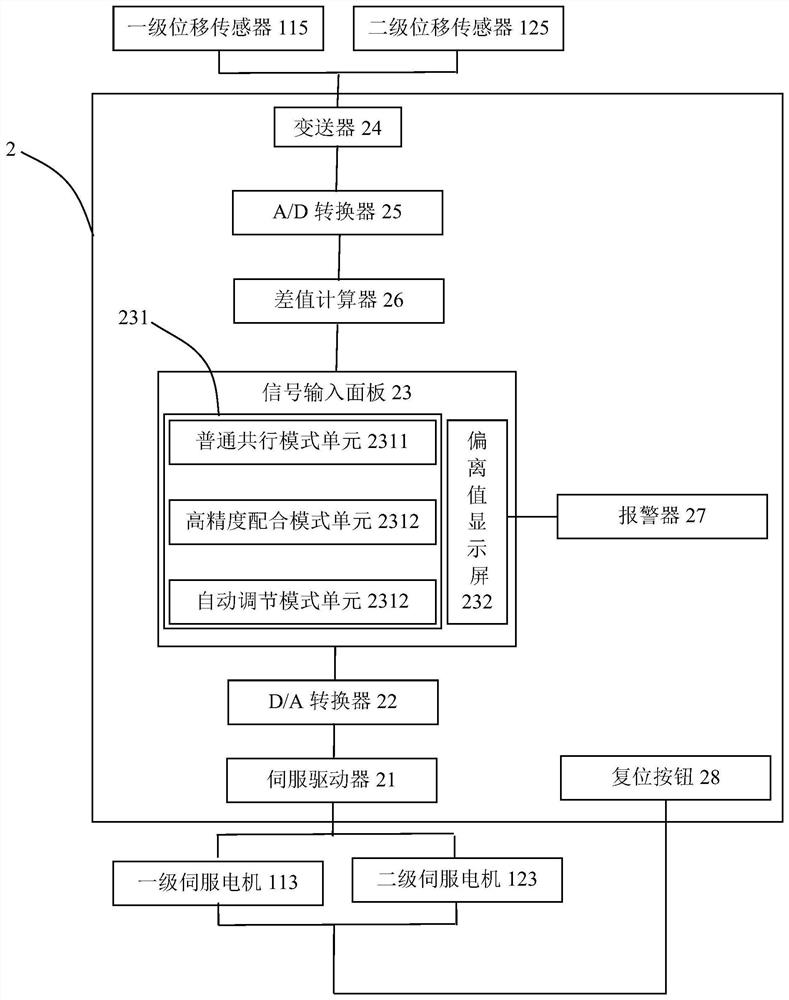
Figure 1 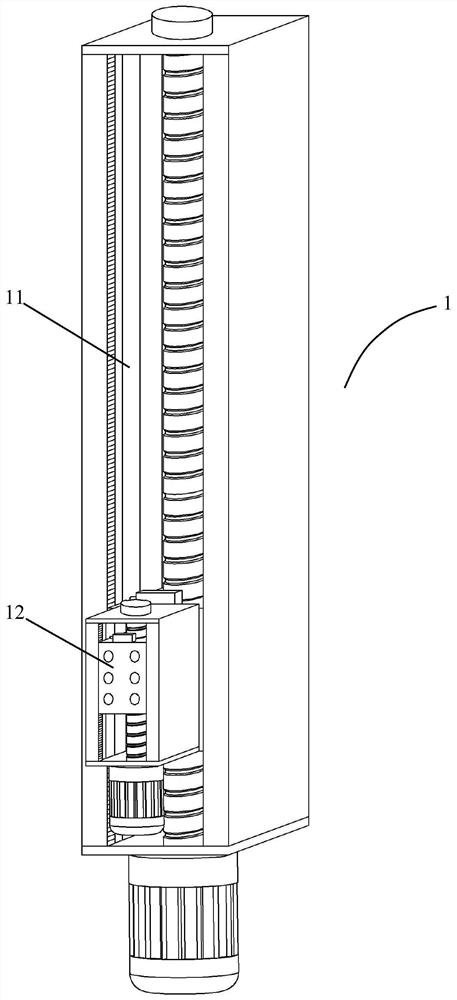
Figure 2 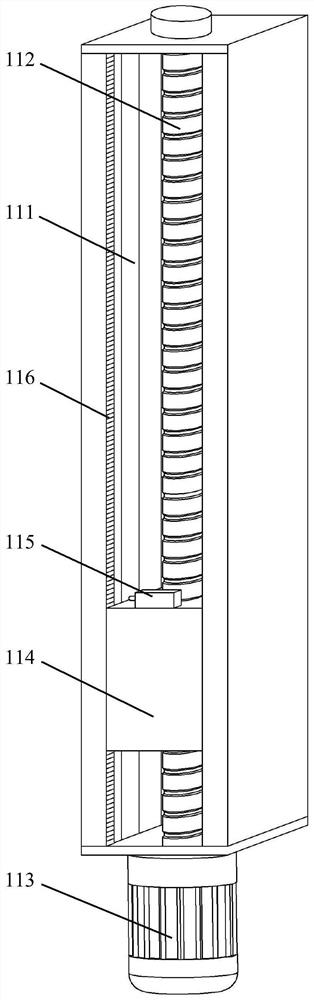
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of automatic linear track operation adjustment, and more specifically relates to a high-precision screw adjustment structure. Background technique
[0002] The screw nut mechanism is also called the screw transmission mechanism. It is mainly used to convert rotary motion to linear motion or convert linear motion to rotary motion. There are those that mainly transmit energy, such as screw presses, jacks, etc.; there are also those that mainly transmit motion, such as the feed screw of the machine tool workbench; there are also screw transmission mechanisms that adjust the relative positions between parts, etc.
[0003] When converting rotary motion into linear motion, although the ordinary screw nut mechanism can be realized, it is not easy to meet the use requirements in terms of operating accuracy. With the increasing requirements of automation development, the mechanical motion accuracy and different appl...
Examples
Embodiment Construction
[0035]The following will clearly and completely describe the technical solutions in the embodiments of the present invention with reference to the accompanying drawings in the embodiments of the present invention. Obviously, the described embodiments are only some, not all, embodiments of the present invention. Based on the embodiments of the present invention, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts belong to the protection scope of the present invention.
[0036] See attached figure 1 to attach Figure 4 , the embodiment of the present invention discloses a high-precision screw adjustment structure, including a driving part 1 and a control part 2;
[0037] The driving part 1 includes a primary screw adjustment assembly 11 and a secondary screw adjustment assembly 12; the primary screw adjustment assembly 11 and the secondary screw adjustment assembly 12 are respectively driven by a primary servo motor 113 and a ...