
Virtual flexible body deformation operation simulation system supporting haptic feedback
A simulation system and tactile feedback technology, which is applied in the field of virtual flexible body surgery simulation system, can solve the problems of unreliability, high difficulty of vascular distribution structure surgery, and inability to feel force tactile feedback in advance, so as to achieve stable force tactile feeling and realistic simulation effect , the effect of meeting the requirements of fine work and real-time performance
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2011-10-05
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
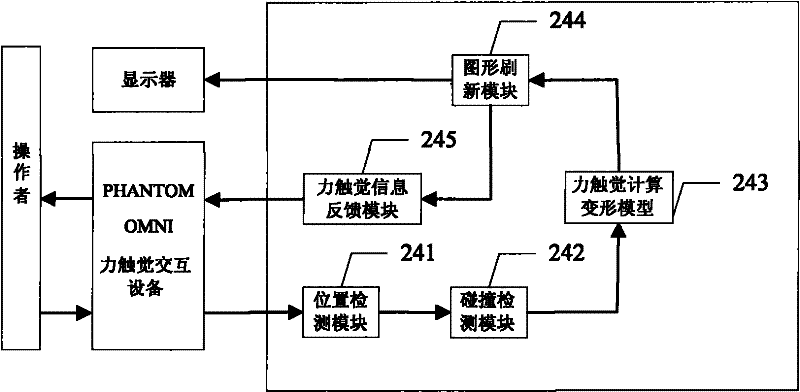
Figure 1 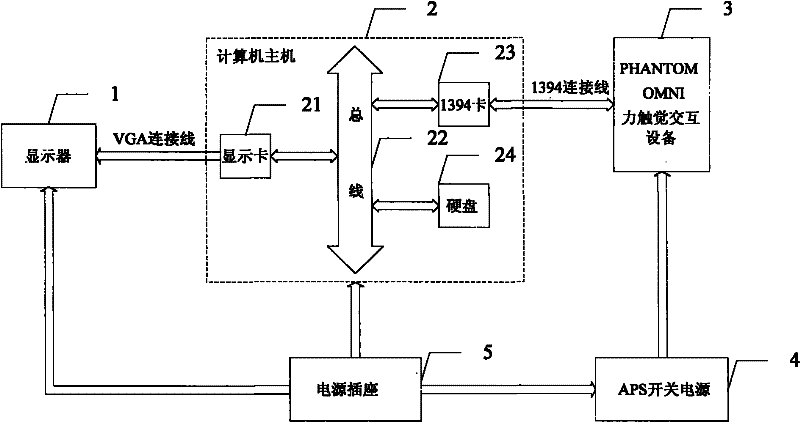
Figure 2 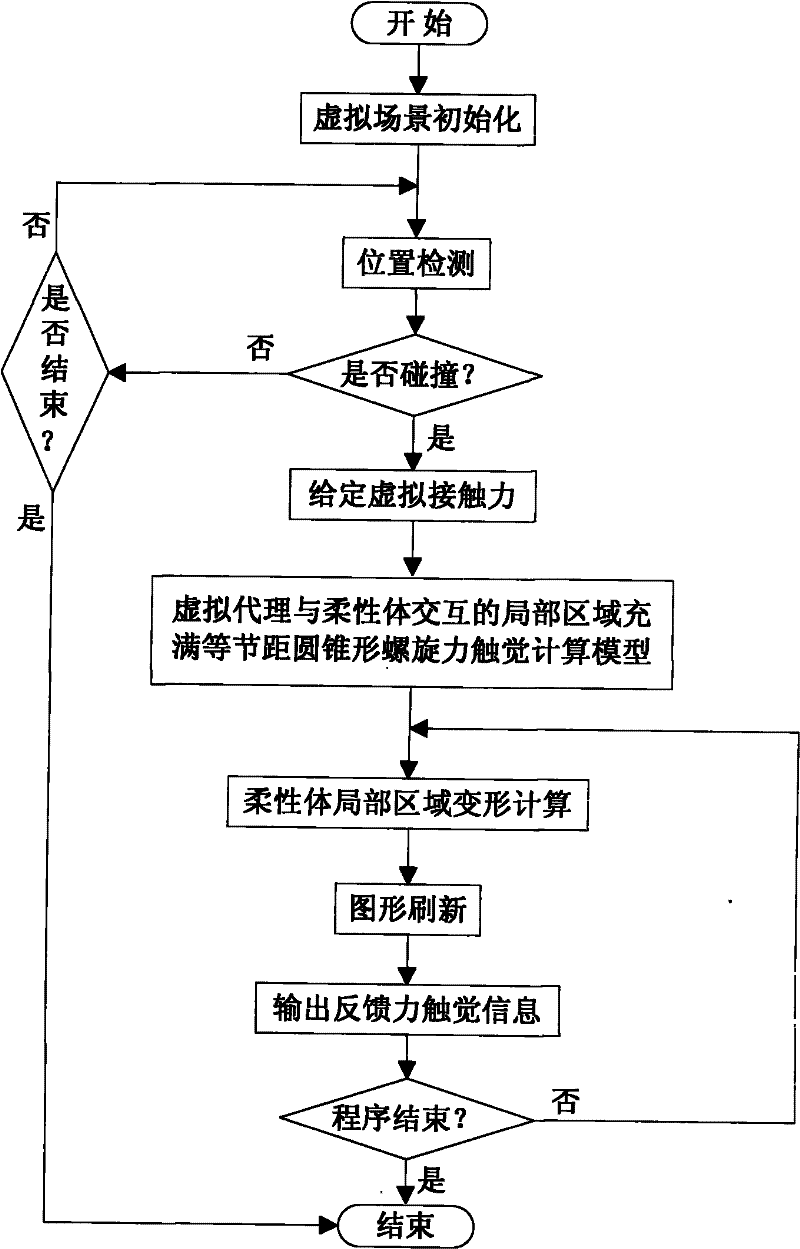
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a virtual flexible body operation simulation system supporting force tactile feedback, which belongs to the field of virtual reality human-computer interaction. Background technique
[0002] With the rapid development of haptic human-computer interaction technology, more and more researchers are applying haptic interaction equipment to virtual surgery, so that doctors can not only see but also pass through the movement and virtual flexibility of the arm during the surgical simulation process. interact with the virtual object, so as to form a complete understanding of the virtual surgical environment, and can truly feel the force-tactile information generated when interacting with the virtual object in real time like operating a real object, which will undoubtedly make surgical training more realistic, accurate, and reliable.
[0003] Most of the organs or tissues of the human body are flexible bodies, and the flexible body of ...
Examples
Embodiment 1
[0051] A haptic feedback simulation system for a virtual flexible body, comprising: a host computer 2 and a haptic interaction device 3, a display 1 is connected to the host computer 2, and the host computer 2 includes at least a hard disk 24 and a 1394 card 23, its features That is, the hard disk 24 includes at least: a position detection module 241 for detecting the position of the virtual agent, a collision detection module 242 for detecting whether the virtual agent collides with the virtual flexible body, a force-tactile calculation deformation module 243, and a force-tactile calculation deformation module 243. The graphics refresh module 244 and the force-tactile information feedback module 245 of the latest force-tactile deformation information sent by the deformation module 243 refresh the graphics. The deformation information of the flexible body surface generated by the tactile calculation deformation module 243 is transmitted to the haptic interaction device 3,
[0...
Embodiment 2
[0084] A haptic feedback simulation system for a virtual flexible body, comprising: a host computer 2 and a haptic interaction device 3, a display 1 is connected to the host computer 2, and the host computer 2 includes at least a hard disk 24 and a 1394 card 23, its features That is, the hard disk 24 includes at least: a position detection module 241 for detecting the position of the virtual agent, a collision detection module 242 for detecting whether the virtual agent collides with the virtual flexible body, a force-tactile calculation deformation module 243, and a force-tactile calculation deformation module 243. The graphics refresh module 244 and the force-tactile information feedback module 245 of the latest force-tactile deformation information sent by the deformation module 243 refresh the graphics. The deformation information of the flexible body surface generated by the tactile calculation deformation module 243 is transmitted to the haptic interaction device 3,
[0...