
Endoscope operating hand and operating method thereof
A technique for manipulating hands and endoscopes, applied in the fields of surgery, medical science, diagnosis, etc., can solve the problems of screen shake, increase the risk of surgery, and affect the viewing of the endoscope, achieve accurate positioning, meet the viewing intention, and solve the problem of holding the endoscope. Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2015-11-11
Smart Images
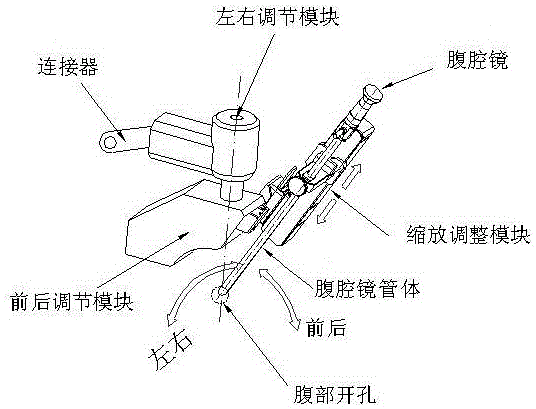
Figure 1 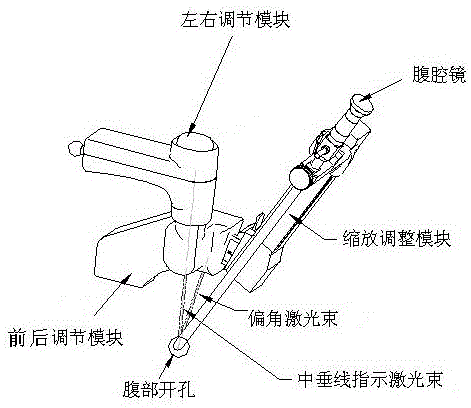
Figure 2 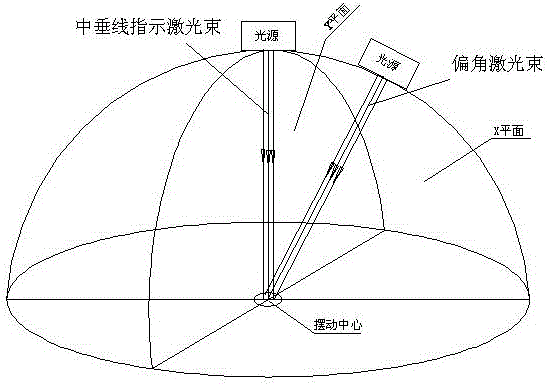
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a laparoscopic operating hand and an operating method thereof, in particular to a laparoscopic operating hand suitable for laparoscopic surgery medical instruments and an operating method thereof. Background technique
[0002] Traditional minimally invasive surgery requires a laparoscope to watch the whole process, and a doctor must hold the laparoscope all the way. The doctor must also be very aware of the surgeon's intentions in order to move the endoscope in the correct direction. However, the doctor is prone to fatigue when operating the endoscope for a long time. Unstable factors such as the doctor's emotion or physiological activities will also cause hand shaking. Since the displayed image is enlarged, tiny arm tremors may cause shocking effects on the display screen. Annoying jitter affects endoscopic viewing, wastes human resources, and increases surgical risks. It is very necessary to develop a "robot hand" that can ...
Examples
Embodiment Construction
[0024] In order to make the object, technical solution and advantages of the present invention clearer, the present invention will be further described in detail below in conjunction with the accompanying drawings and embodiments. It should be understood that the specific embodiments described here are only used to explain the present invention, not to limit the present invention.
[0025] Any feature disclosed in this specification (including the abstract and drawings), unless specifically stated, can be replaced by other equivalent or similar purpose alternative features. That is, unless expressly stated otherwise, each feature is one example only of a series of equivalent or similar features.
[0026] "Laparoscopic robot hand" is a surgical robot with a specific purpose. It holds the endoscopic tube during the whole process of endoscopic surgery. It has the characteristics of precise positioning, no fatigue, and real-time remote control. It meets the viewing intention of th...