
Offline programming method for six-axis grinding and polishing industrial robot
An industrial robot, offline programming technology, applied in the polishing field, can solve the problem that the simulated motion trajectory cannot obtain the actual motion trajectory, and achieve the effect of simplifying the offline programming process
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2016-02-03
Smart Images
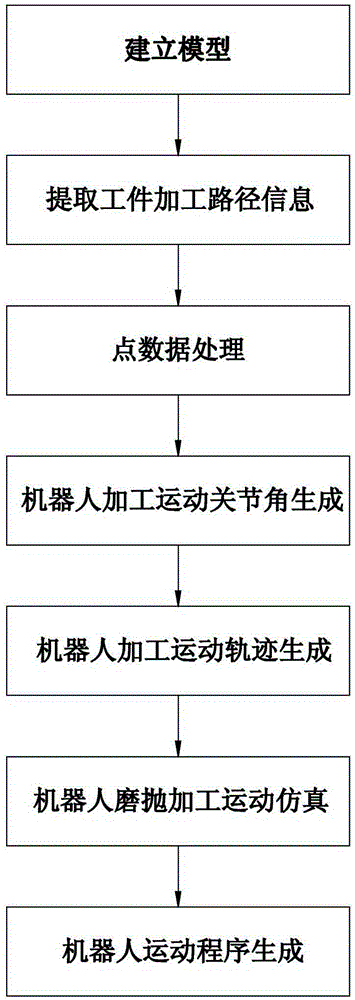
Figure 1 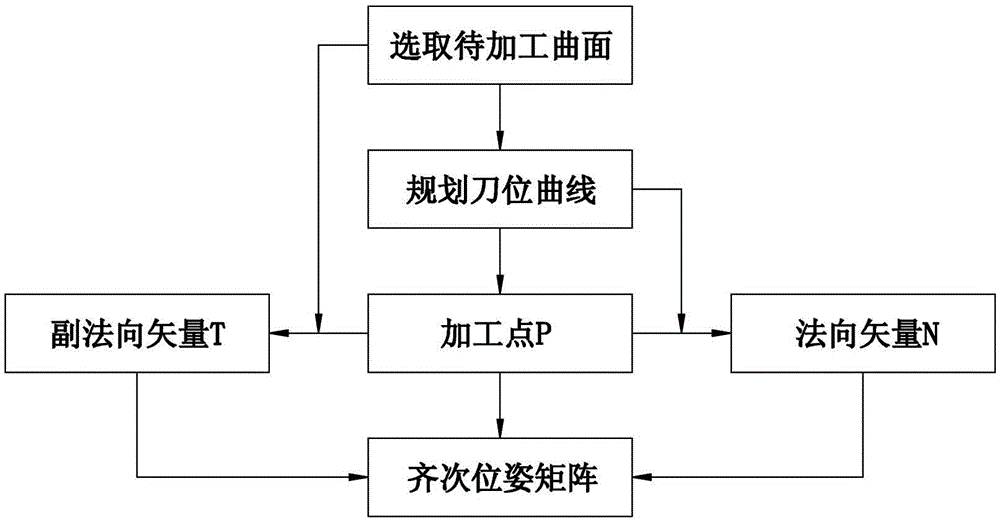
Figure 2 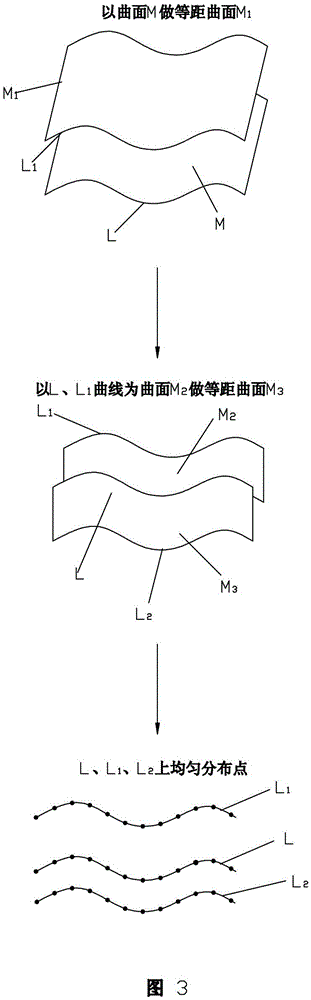
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of polishing, in particular to an off-line programming method for a six-axis grinding and polishing industrial robot. Background technique
[0002] With the continuous development of industrial automation, people began to pay attention to the application of industrial robots. The development of robot technology is gradually replacing people in various production operations, freeing humans from heavy, repetitive and monotonous, harmful to health and dangerous production operations. . In the field of grinding and polishing, industrial robots are gradually being used for grinding and polishing. At present, the polishing of workpieces in industrial production is usually done manually. There are shortcomings such as unstable polishing quality, low precision, high labor costs, and low production efficiency. The work is monotonous and repetitive. , Polishing noise and dust seriously affect the health of workers. Therefore,...
Examples
Embodiment Construction
[0025] The technical solutions in the embodiments of the present invention will be clearly and completely described below in conjunction with the accompanying drawings in the embodiments of the present invention. Obviously, the described embodiments are only some, not all, embodiments of the present invention. Based on the embodiments of the present invention, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts fall within the protection scope of the present invention.
[0026] This embodiment implements an off-line programming method for a six-axis grinding and polishing industrial robot based on the 3D software Solidworks. Refer to figure 1 , including the following ten main steps:
[0027] 1. Build a model
[0028] The first part of model building is to establish a 3D model of the grinding and polishing system through the 3D software Solidworks. The 3D model of the grinding and polishing system includes a six-axis industri...