
An odometer-assisted vehicle dynamic alignment method
A technology for odometers and auxiliary vehicles, which is applied in the directions of measuring distance, instruments, surveying and navigation, etc. It can solve the problems of stationary vehicles, meet the needs of driving and navigation, improve the maneuverability of vehicles, and improve the speed and flexibility sexual effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2020-09-01
Smart Images
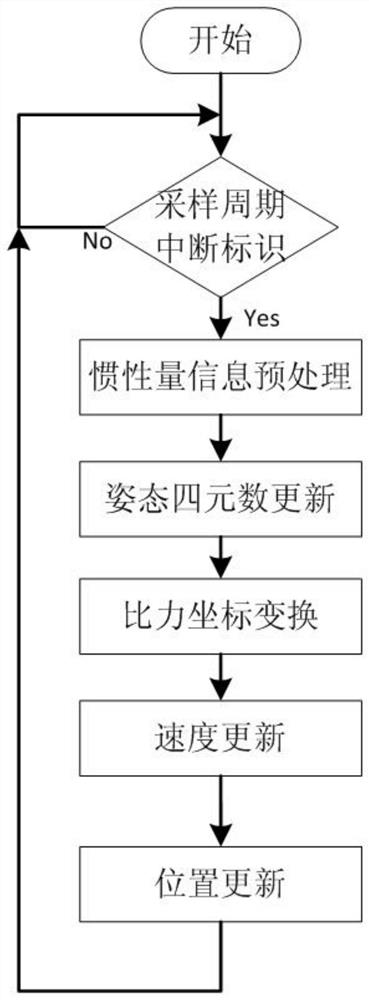
Figure 1 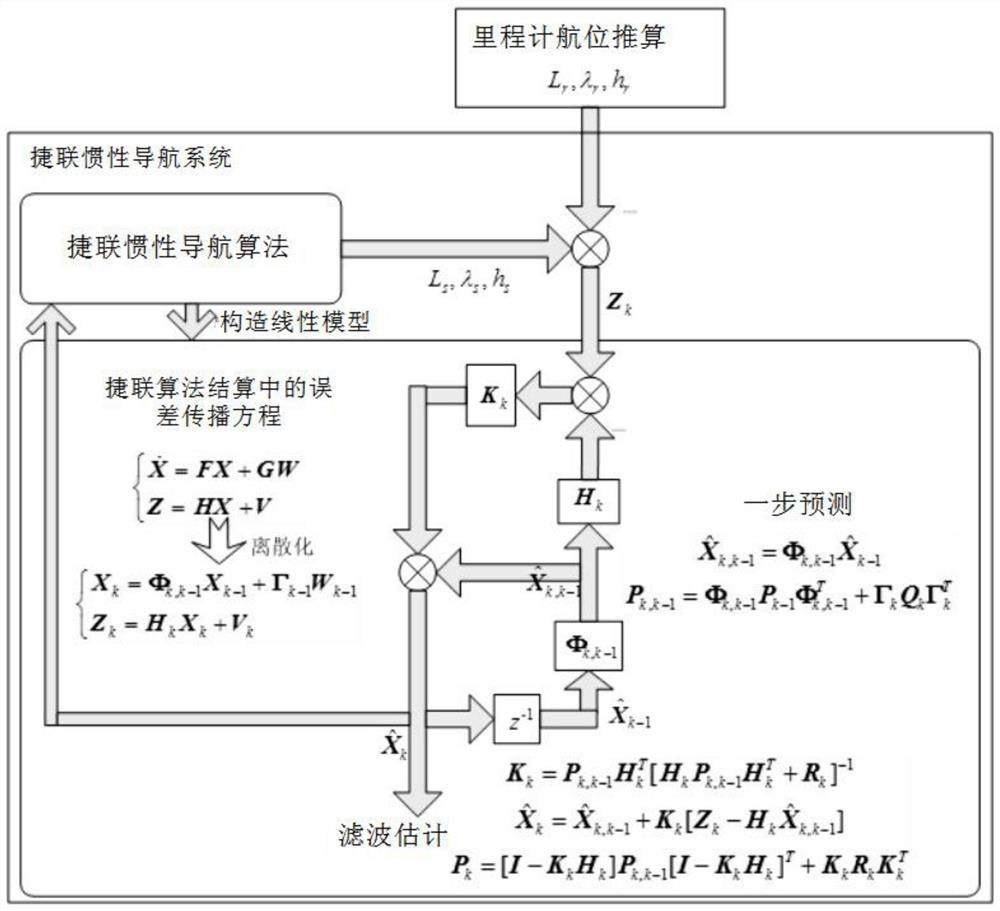
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of land vehicle navigation, in particular to an odometer-assisted vehicle dynamic alignment method. Background technique
[0002] A land vehicle navigation system generally consists of an inertial measurement unit and an odometer. The inertial measurement unit consists of three gyroscopes and three accelerometers, which are sensitive to carrier angle increments and velocity increments; the odometer measures the displacement increments of the vehicle. The inertial measurement unit constitutes the inertial navigation system, and the navigation calculation can be performed after the initial position of the bookbinding is aligned. The inertial navigation system can also be combined with the odometer to form a vehicle dead reckoning system, which can decompose the displacement increment measured by the vehicle odometer through the attitude and heading of the inertial navigation system, so as to complete the vehi...
Examples
Embodiment Construction
[0023] Embodiments of the present invention will be described in further detail below in conjunction with the accompanying drawings.
[0024] An odometer-assisted vehicle dynamic alignment method, implemented in a vehicle navigation system including an inertial measurement unit and an odometer, which uses the angular increment and velocity increment output of the inertial measurement unit to perform inertial navigation calculation; the vehicle using the odometer The displacement incremental output and the attitude angle calculated by the inertial navigation are decomposed into mileage to complete the dead reckoning; then using the Kalman filter, the error model of the inertial navigation system and the error model of the dead reckoning are used as the propagation equation of the error state, and the The attitude angle error of the inertial navigation system is estimated and calibrated. Specifically include the following steps:
[0025] Step 1. In the inertial navigation syste...