
Direction-adjusting blade driving mechanism for intelligent underwater robot
An underwater robot and driving mechanism technology, applied in the field of robots, can solve the problems of limited driving direction of the driving mechanism and inability to change the driving direction, etc.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2018-08-07
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
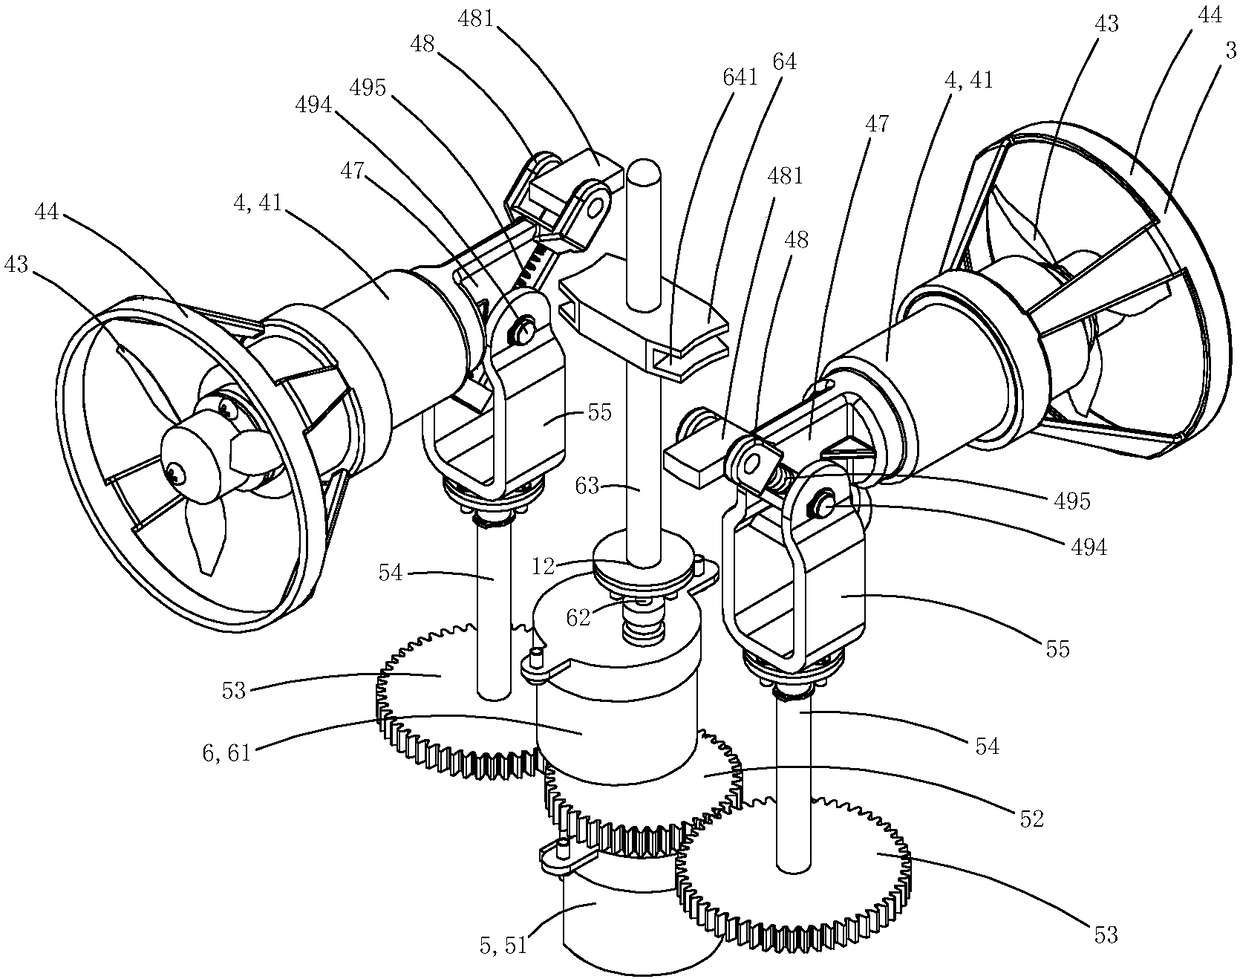
Figure 1 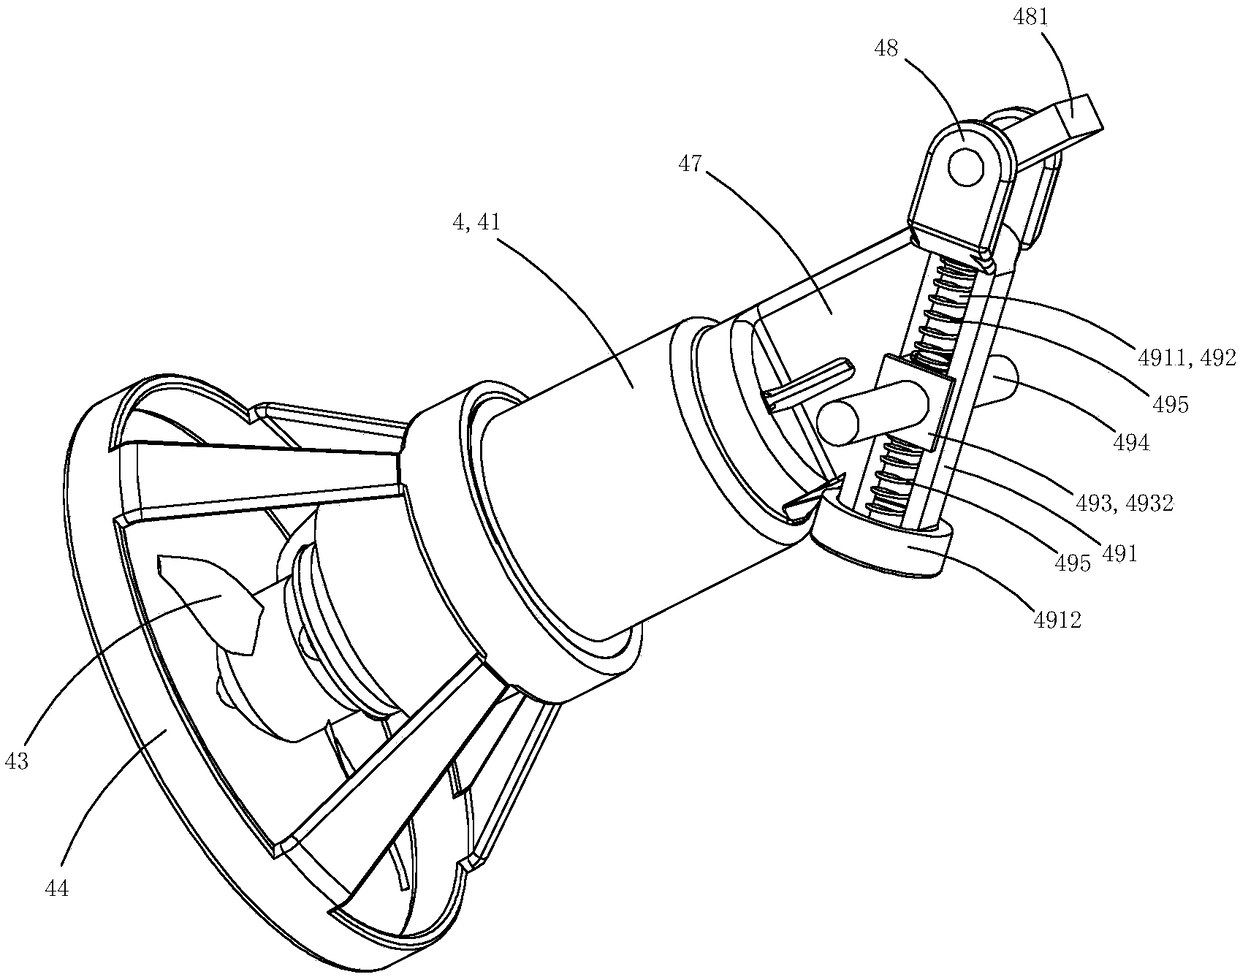
Figure 2 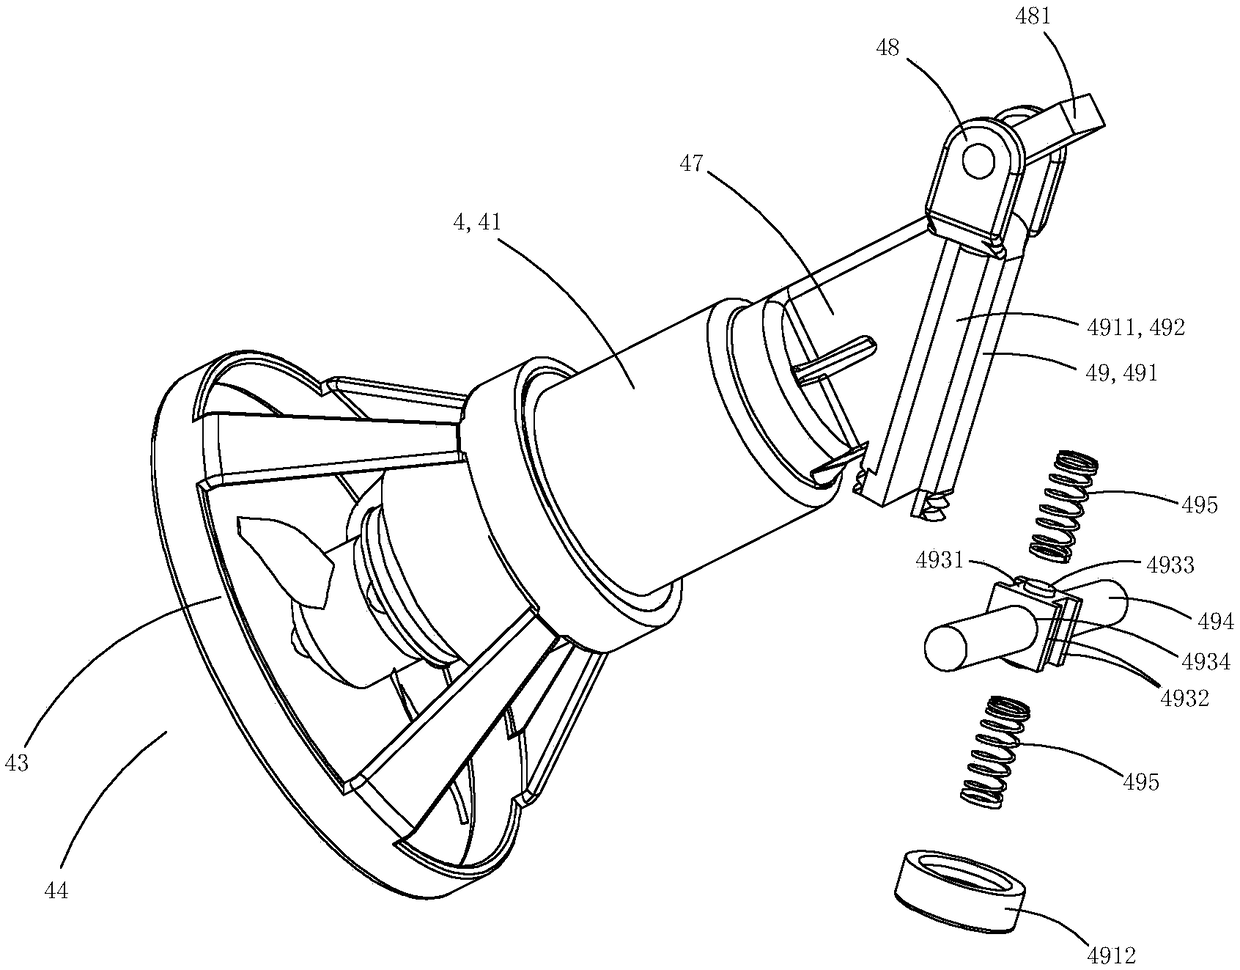
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the technical field of robots, and in particular relates to a steering blade driving mechanism for an intelligent underwater robot. Background technique
[0002] Most underwater robots have cameras or cameras, which are generally used in hydrological research, underwater monitoring, underwater exploration, underwater rescue, underwater salvage, nuclear power plant water monitoring, and underwater oil operation platform cleaning and other fields.
[0003] Most of the existing underwater robots add mobile modules to the underwater camera to complete autonomous or controlled movement. However, the driving direction of the driving mechanism is limited, and the driving direction cannot be changed arbitrarily underwater. Contents of the invention
[0004] The purpose of the present invention is to provide a steering blade driving mechanism for an intelligent underwater robot with adjustable power direction.
[0005] The technical ...
Examples
Embodiment 1
[0023] This embodiment is a kind of steering blade drive mechanism for intelligent underwater robot, see Figure 1 to Figure 3 As shown, the steering blade drive mechanism 3 includes two blade drivers 4, a first steering mechanism 5 for synchronously driving the two blade drivers to rotate in the first plane, and a first steering mechanism 5 for driving the blade drivers to rotate in the first plane. The second direction adjustment driving mechanism 6 rotating in the second plane; the first plane is perpendicular to the second plane; when the present embodiment is in a free state only under the action of gravity, the first plane is a horizontal plane, and the second plane is a vertical plane .
[0024] Each paddle driver 4 comprises a sealed chamber 41, a power supply arranged in the sealed chamber, a paddle 43 which is rotated to be arranged on the sealed chamber, a protective cover 44 arranged on the outer wall of the sealed chamber for protecting the paddle, and a protectiv...