
A five-degree-of-freedom time-sharing drive power-assisted manipulator with mechanical locking function
A time-sharing driving and mechanical locking technology, applied in manipulators, claw arms, manufacturing tools, etc., can solve the problem of less time-sharing driving of joint power sources, and achieve the effects of high-precision control, weight reduction, and burden reduction.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2021-09-28
Smart Images
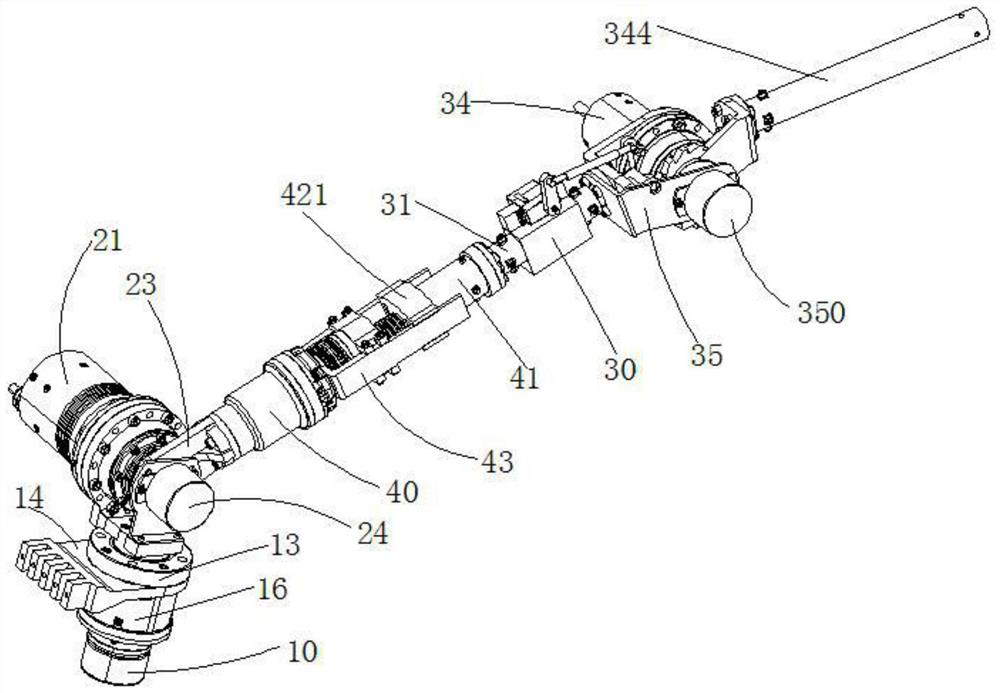
Figure 1 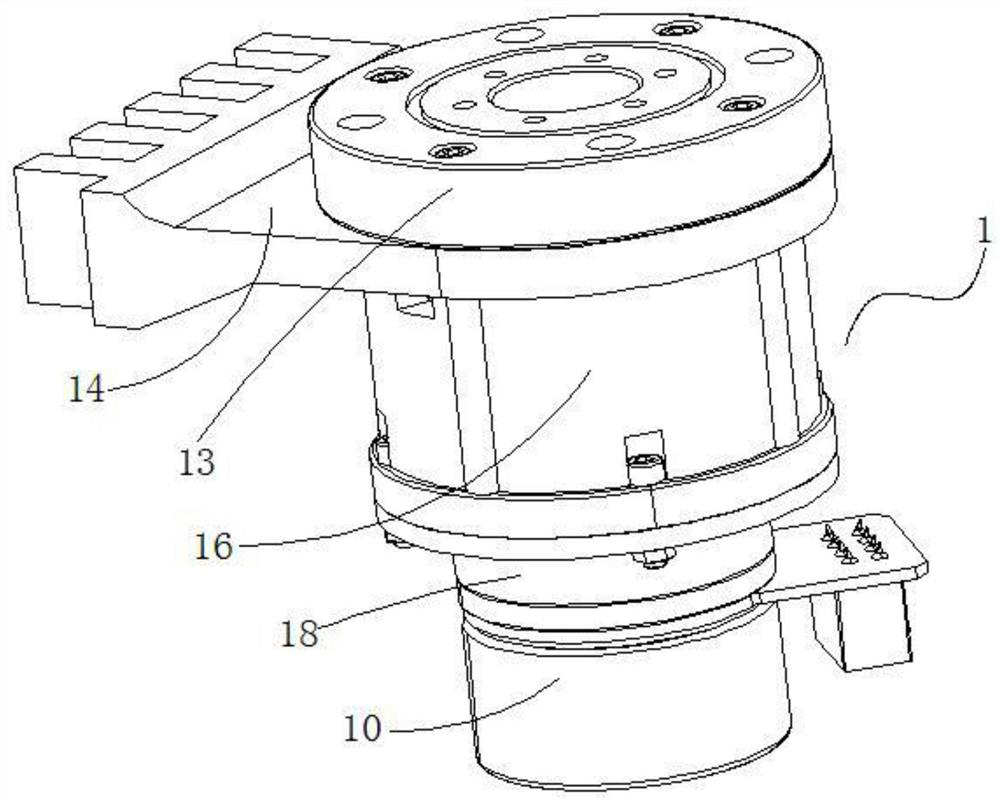
Figure 2 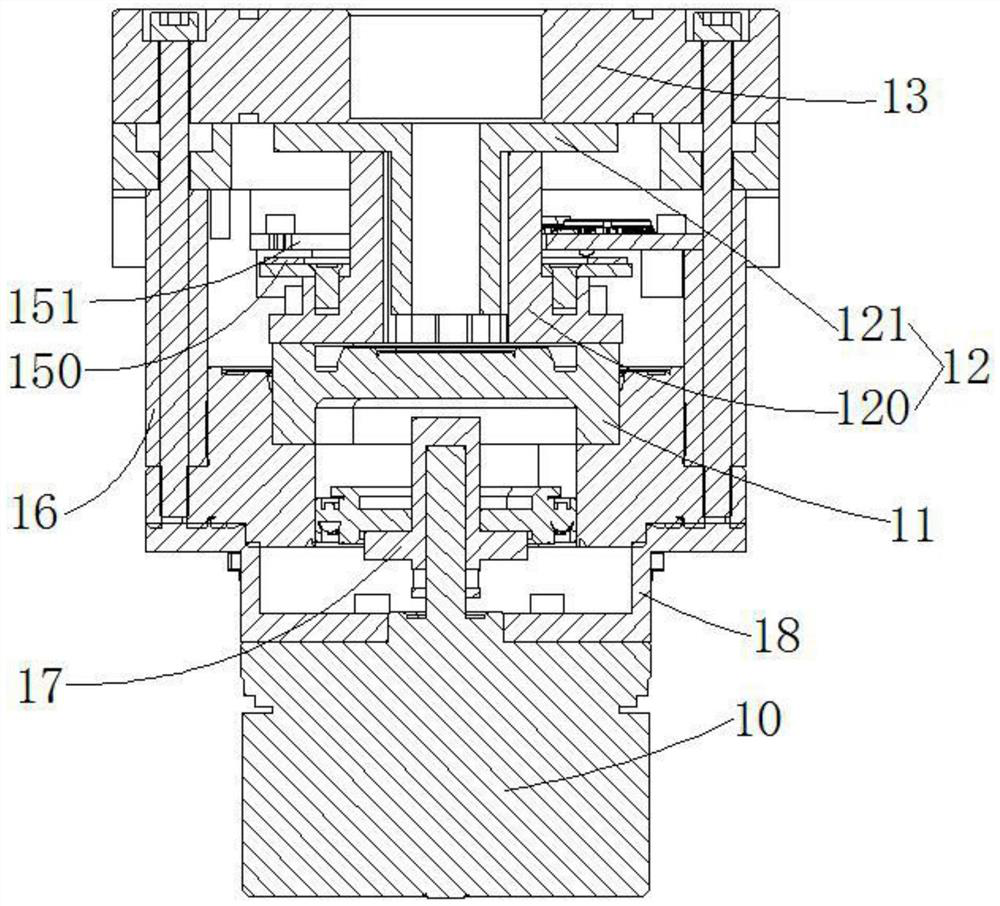
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of robot automation, and more specifically relates to a five-degree-of-freedom time-sharing driving power-assisted mechanical arm with a mechanical locking function. Background technique
[0002] The outer limb cooperative robot arm is a new type of robot arm different from the disabled prosthesis and exoskeleton robot. As the expansion and extension of human limited limbs, the external limb cooperative robotic arm can assist humans to complete tasks that are impossible to complete with only two arms. It has a wide range of applications in the aviation industry, military engineering, and emergency operations. In many typical scenarios that require the cooperation of multiple people, such as lifting and screwing bolts, high-altitude suspension operations, etc., the external limb collaborative robot arm can play an extremely important role. The verification machines for external limb collaborative robotic arms in vario...
Examples
Embodiment 1
[0039] Such as Figure 1-17 As shown, a five-degree-of-freedom time-sharing driving power-assisted mechanical arm with a mechanical locking function includes joint one 1, joint two 2, joint three 3 and a central time-sharing drive mechanism 4, and the joint one 1 includes a joint-servo motor 10. Joint-reducer 11 and joint-cross roller bearing 13, the output shaft of the joint-servo motor 10 is connected to the input end of the joint-reducer 11, and the output end of the joint-reducer 11 is connected to the joint-cross The inner ring of the roller bearing 13, the joint-reducer 11 is a harmonic reducer, and the output shaft of the joint-servo motor 10 is connected to the input end of the joint-reducer 11 through the joint-coupling 17 (that is, the joint An elliptical wheel of a reducer 11), the output end of the joint-reducer 11 is connected to the inner ring of the joint-crossed roller bearing 13 through the transmission flange 12. The output shaft of the joint-servo motor 10 ...