
Loop tracking method and system.
A loop tracking and branching technology, applied in the field of satellite navigation applications, can solve the problem that the GPS receiver cannot track the satellite signal loop and cannot achieve positioning and navigation.
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2016-06-01
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
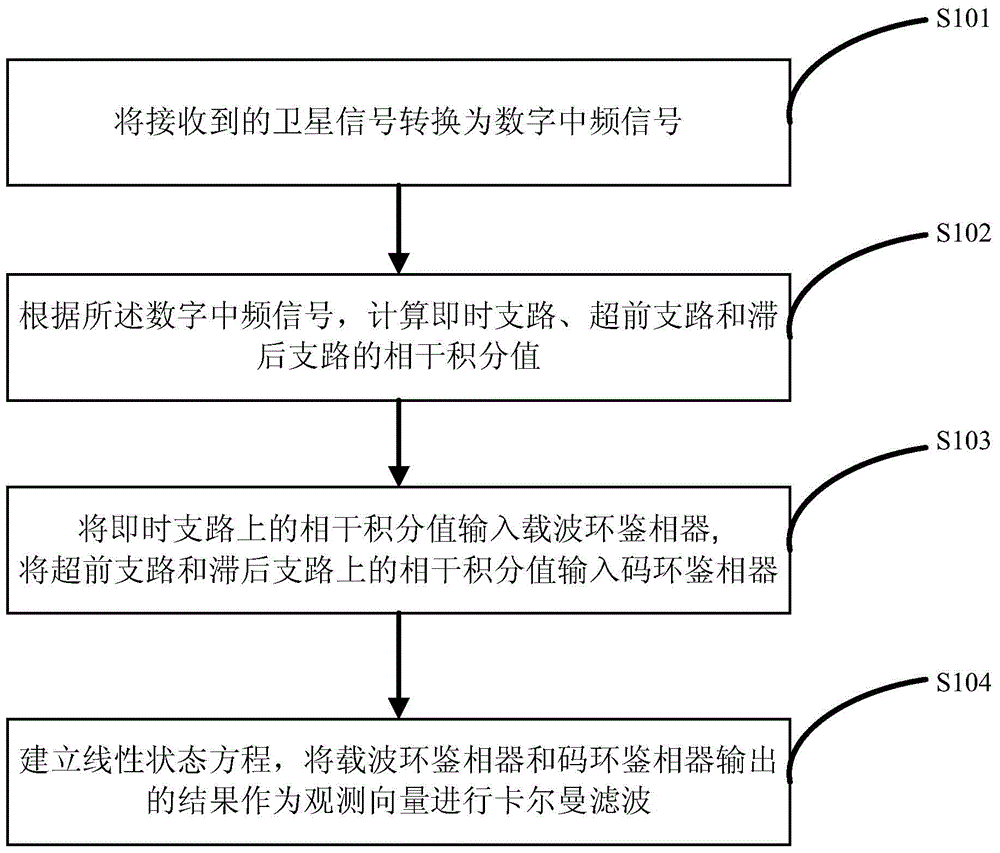
Figure 1 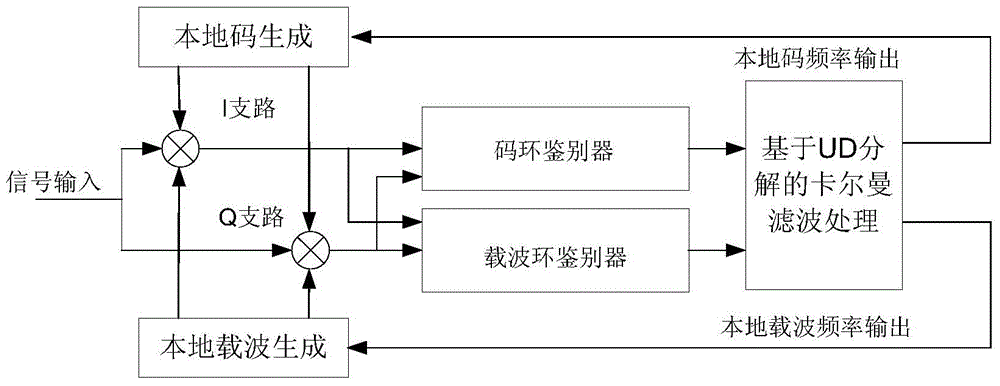
Figure 2 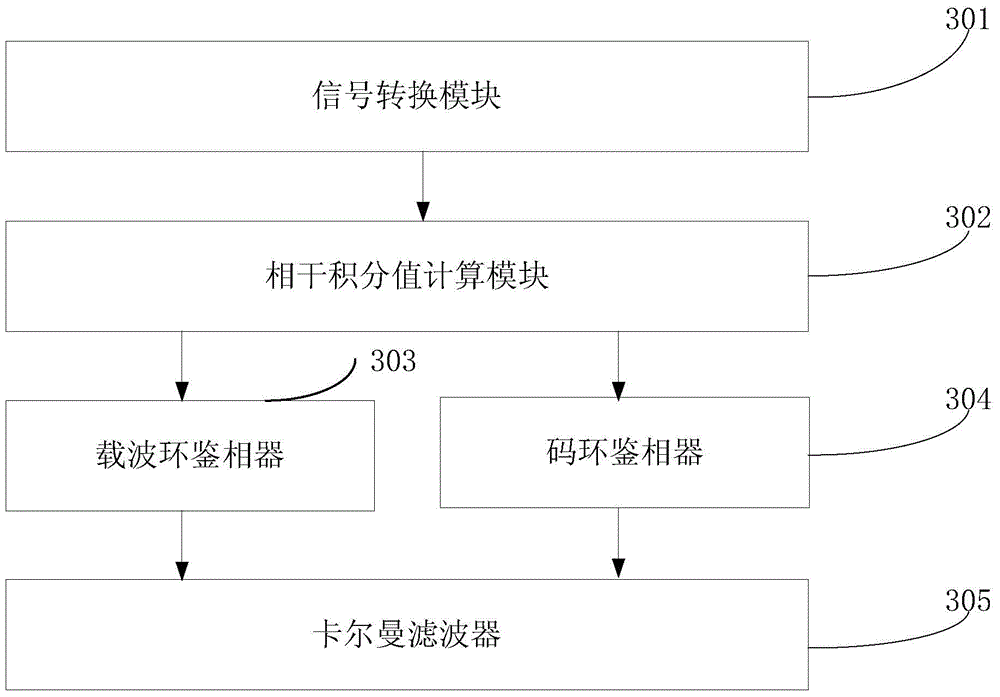
Figure 3
Abstract
Description
Technical field
[0001] The invention belongs to the field of satellite navigation applications, and particularly relates to a satellite signal loop tracking method and system that can be used in a high dynamic environment. Background technique
[0002] With the development of national defense and military, the dynamics of advanced weapons and equipment such as missiles and fighters are getting higher and higher, which makes it impossible for traditional GPS receivers to navigate and locate them. The existing loop tracking scheme must be improved. In a high dynamic environment, the receiver and the satellite have relatively large relative speeds, accelerations and even jerk. For example, the overload capacity of close-range combat bombs can reach 40g, that of medium-range bombs is about 20g, and cruise missiles are about a few g.
[0003] In the above-mentioned high dynamic environment, the GPS signal received by the GPS receiver contains a large Doppler frequency shift and its rate...
Examples
Embodiment 2
[0065] On the basis of the method provided in the first implementation, this embodiment combines specific application scenarios and engineering implementation cases to provide a better technical specific implementation and simulation verification results:
[0066] The selection of the Kalman filter state vector:
[0067] X k =[τ k θ k f k f k '] T
[0068] The 4th-order linear state equation:
[0069] X k+1 = F k+1,k X k +G k f k +W k
[0070] τ θ f f ′ k + 1 = 1 0 Δt λ Δt 2 2 λ 0 1 2 πΔt πΔ t 2 0 0 1 Δt 0 0 0 1 τ θ f f ′ k + - Δt 0 0 - Δt 0 0 0 0 ω code f carr + W k
[0071] In the above equation of state, τ k It is the difference between the real code phase and the local reproduced code phase, the unit is the number of C / A ...
Embodiment 3
[0088] Corresponding to the methods provided in the first and second embodiments, this embodiment also provides a loop tracking system, such as image 3 The shown system composition architecture diagram, the system includes:
[0089] The signal conversion module 301 is used to convert the received satellite signal into a digital intermediate frequency signal;
[0090] The coherent integral value calculation module 302 is configured to calculate the coherent integral value of the instant branch, the leading branch and the lagging branch according to the digital intermediate frequency signal;
[0091] The carrier loop phase detector 303 is used to process the coherent integral value input on the instant branch;
[0092] The code loop phase detector 304 is used to process the coherent integral input from the leading branch and the lagging branch;
[0093] The Kalman filter 305 is used to establish a linear state equation, and perform Kalman filtering with the output results of the carrier ...