
A Nonlinear Predictive Control Method of lpv Model Based on Interior Point Method
A technology of nonlinear prediction and control methods, which is applied in the direction of adaptive control, general control system, control/regulation system, etc., and can solve problems such as QP problem solving becomes a bottleneck, large amount of online calculation, and low solution accuracy
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2017-11-24
Smart Images
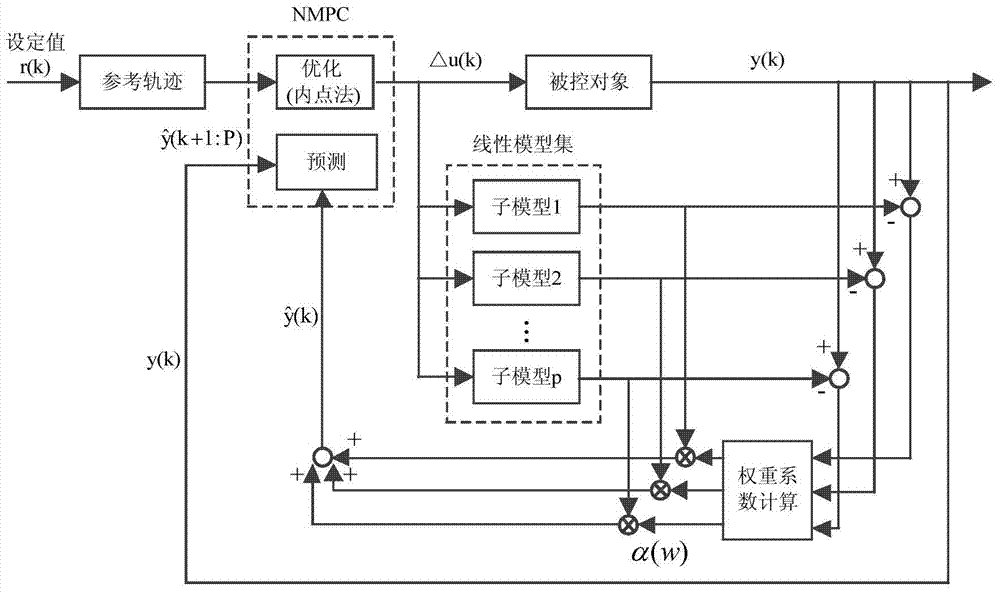
Figure 1 
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of industrial process control and relates to an LPV model nonlinear predictive control method based on an interior point method. Background technique
[0002] In actual industry, with the continuous pursuit of production efficiency and stricter environmental protection, industrial processes have become more and more complex, and most of them have strong nonlinear characteristics, and are complex chemical objects with constraints on control quantities. Using a single linear model to describe such a system and design a controller cannot meet the control performance requirements, and even cause system instability. Therefore, it is necessary to explore multi-model methods. The linear variable parameter model (LPV) in the multi-model method has the advantages of simple algorithm and can use the main factors that cause the nonlinearity of the system as scheduling variables. Therefore, the present invention uses the LPV mode...
Examples
Embodiment Construction
[0058] The present invention will be described in further detail below in conjunction with the accompanying drawings and specific embodiments.
[0059] like figure 1 Shown is the block diagram of the control system of the present invention, wherein the sub-model i, (i=1, 2, . . . p ) is a linear model set obtained after selecting working points in the operating space of the system. Since the working point variable is one of the input variables, at the sampling time k, the weight coefficient α(w) of each linear sub-model is calculated by using the weight function formula according to the distance between the actual output of the controlled object and each working point; according to the global The LPV model obtains the predicted output from time k+1 to P; at time k, use the interior point method to solve an optimization proposition on a finite time domain [k, k+P], and solve the current control increment Δu(k) act on the system. At the next sampling time, the nonlinear predic...