
Air pump telescopic type spatial overturning grabbing walking robot
A walking robot, telescopic technology, applied in manipulators, motor vehicles, program-controlled manipulators, etc., can solve problems such as high risk of operation, complex environment, complex and heavy rescue machinery and equipment, and achieve the effect of reducing life-threatening
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2019-04-26
Smart Images
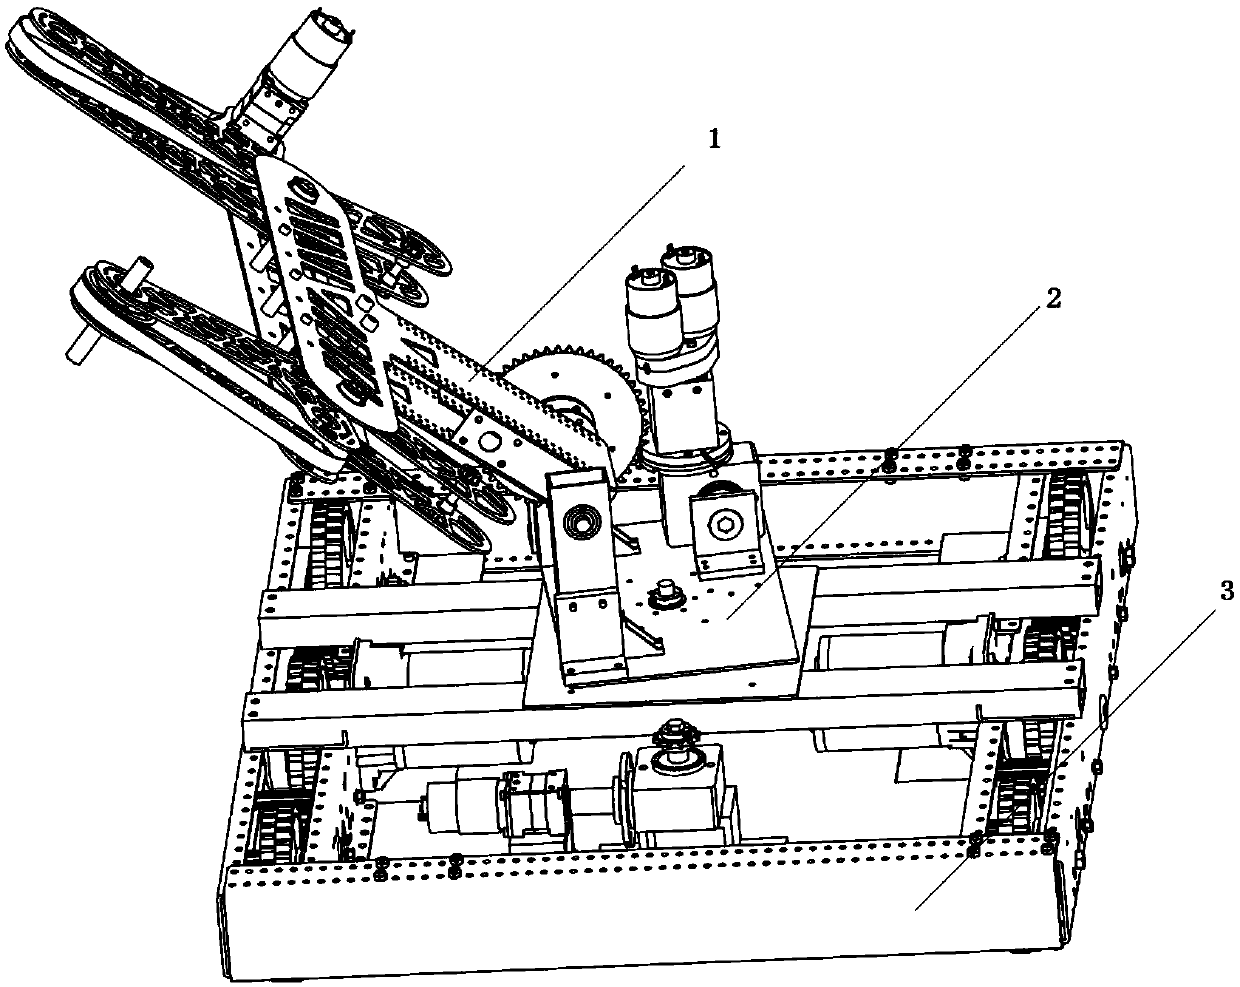
Figure 1 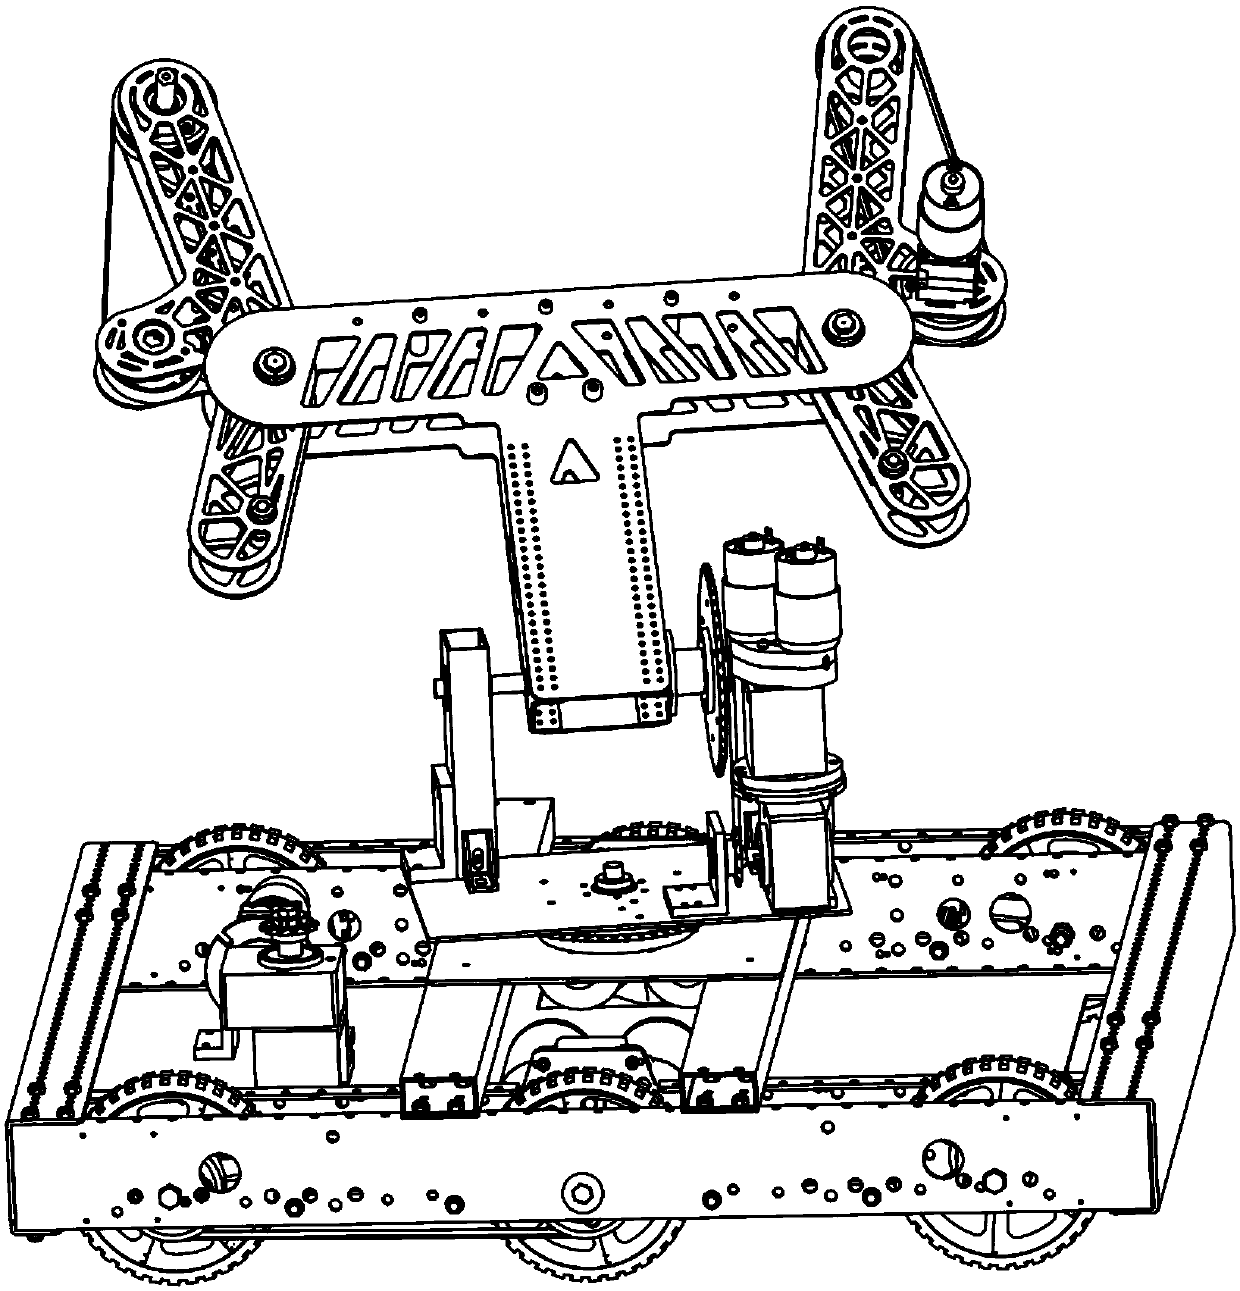
Figure 2 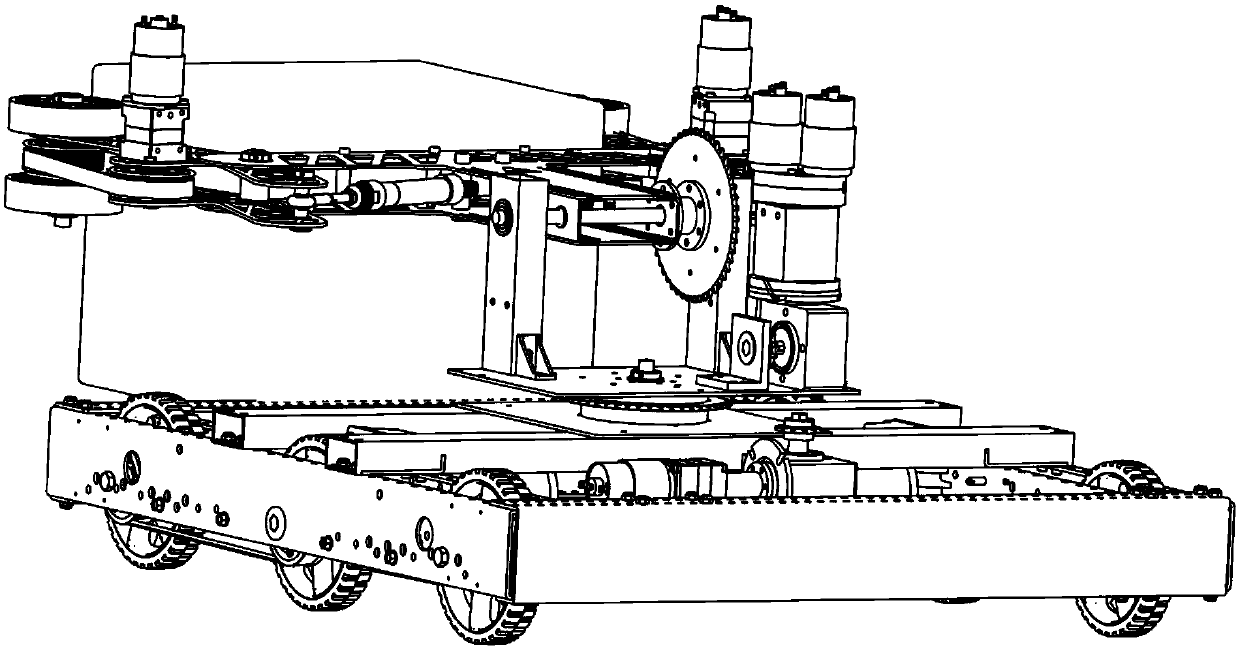
Figure 3
Abstract
Description
technical field
[0001] The invention relates to an air pump telescopic space flip grab walking robot, which belongs to the technical field of special robot manufacturing. Background technique
[0002] The existing special rescue operation environment is complicated, and it is highly dangerous to rely solely on rescuers wearing protective equipment. The existing rescue machinery and equipment are complex and heavy, and cannot flexibly perform telescopic, flipping and grabbing operations in the space. Therefore, it is necessary to base on the existing Advanced intelligent manufacturing technology develops air pump telescopic space flip grabbing walking robot, which effectively solves the problem of dexterous telescopic flip grab operation under the complex space conditions of dangerous special rescue operation environment, and effectively solves the complex space in dangerous special rescue operation environment The research and development of space flip auxiliary operation eq...
Examples
Embodiment Construction
[0023] The present invention will be further described below in conjunction with the accompanying drawings. The following examples are only used to illustrate the technical solution of the present invention more clearly, but not to limit the protection scope of the present invention.
[0024] Such as figure 1 , figure 2 , image 3 , Figure 4 and Figure 5 , the present invention proposes an air pump telescopic space flip grab walking robot, including up and down flip grab mechanism 1, space flip sub-mechanism 2, walking robot chassis 3, space flip sub-mechanism 2 is co-located above the walking robot chassis 3 , the up and down flip grabbing mechanism 1 is coupled to the space flipping sub-mechanism 2 .
[0025] As a preferred embodiment, the space inversion sub-mechanism 2 is provided with a longitudinal inversion pair 216 , and the input end of the up and down inversion grasping mechanism 1 is coupled with the space inversion sub-mechanism 2 through the longitudinal i...