
An Attitude Determining Method Based on Combination of Mems with Arbitrary Attitudes Without Initial Alignment
An initial alignment and attitude technology, applied in the field of navigation and guidance, can solve the problems of shortening the launch preparation time and reducing the combat effectiveness of weapons, and achieve the effect of shortening the launch preparation time
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2020-11-10
Smart Images
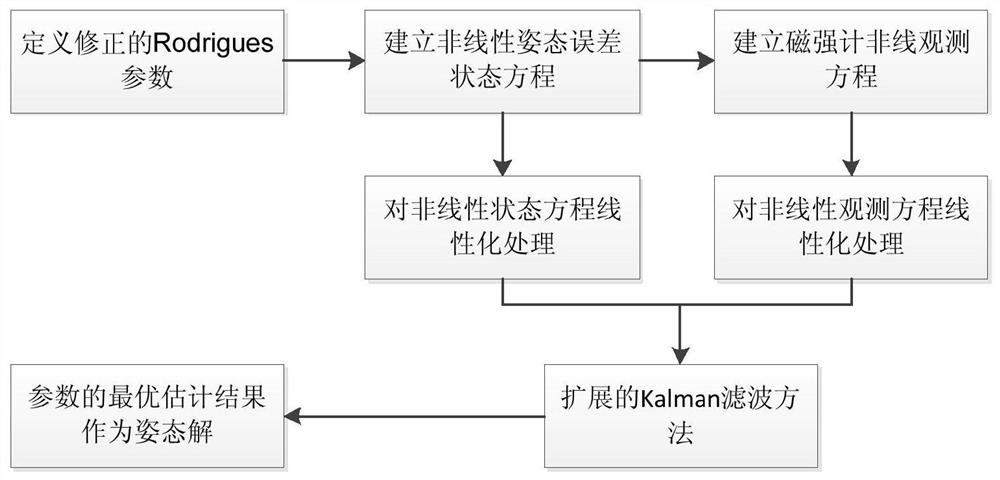
Figure 1 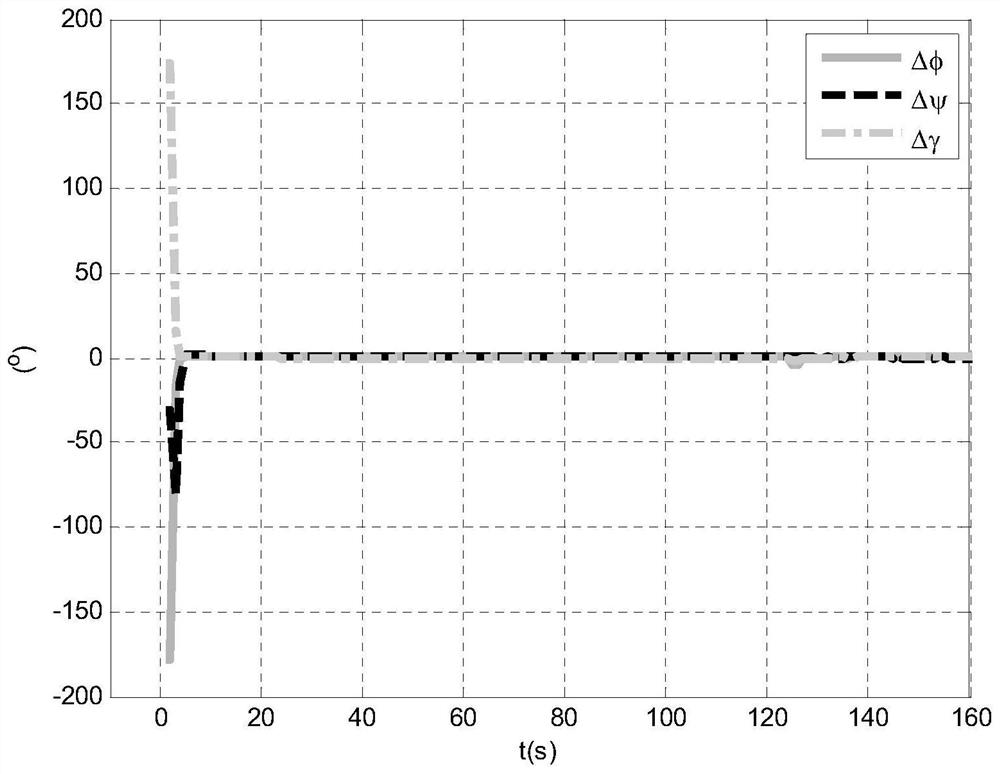
Figure 2 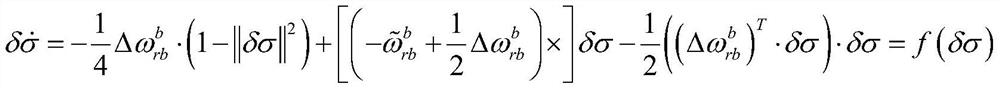
Figure 3
Abstract
Description
technical field
[0001] The invention belongs to the field of navigation and guidance, and relates to an arbitrary attitude MEMS combined attitude determination method without initial alignment. Background technique
[0002] The navigation system is built with MEMS inertial devices as the main navigation equipment to achieve attitude determination and positioning through integral calculations, so initial alignment is required before launch. Generally, the commonly used initial alignment scheme needs to establish a reference point on the ground, and conduct optical aiming through the ground photoelectric theodolite to obtain the initial attitude information of the initial navigation system. It needs to be equipped with corresponding ground equipment and production operation procedures, which takes a long time for alignment and complicated combat preparations. The initial alignment time consumption is an important factor affecting the launch preparation time, and shortening th...
Examples
Embodiment Construction
[0036] This project proposes a method to obtain the three-axis attitude information of the missile weapon system by using only the inertial group and the three-axis magnetometer without any initial attitude information. In the absence of any prior attitude information, the attitude error is no longer a small deviation, and the traditional small deviation linear equation cannot be used to establish the attitude error model. The quaternion model is usually used to describe the nonlinear attitude error. The quaternion has four variables, but only three are independent, so there is a redundancy problem, which will make the state error covariance matrix singular, and the quaternion solution is used at the same time There is still a problem of standardization. The traditional processing method is to use the vector part of the quaternion to model, and ignore the scalar part in the quaternion, that is, the size of the rotation angle, that is, assume that the quaternion error is a smal...