
Robot and its steering control method
A steering control and robot technology, applied in steering mechanism, non-deflectable wheel steering, vehicle components, etc., can solve problems such as robot steering offset, achieve effective obstacle avoidance, precise and stable steering, and avoid rotation, translation or offset Effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2022-02-18
Smart Images
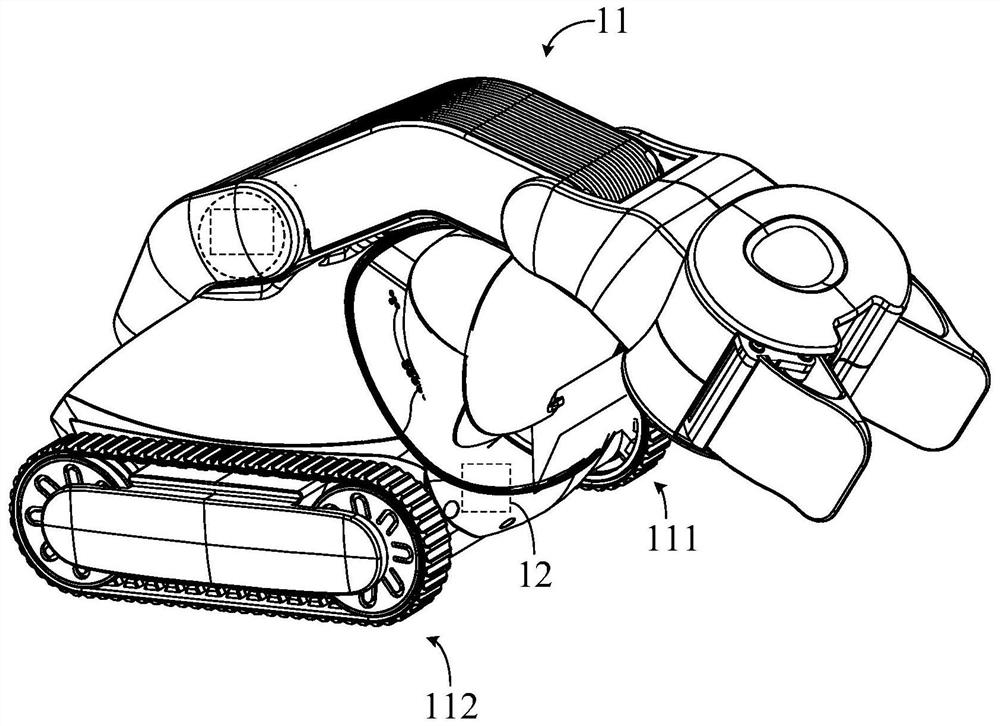
Figure 1 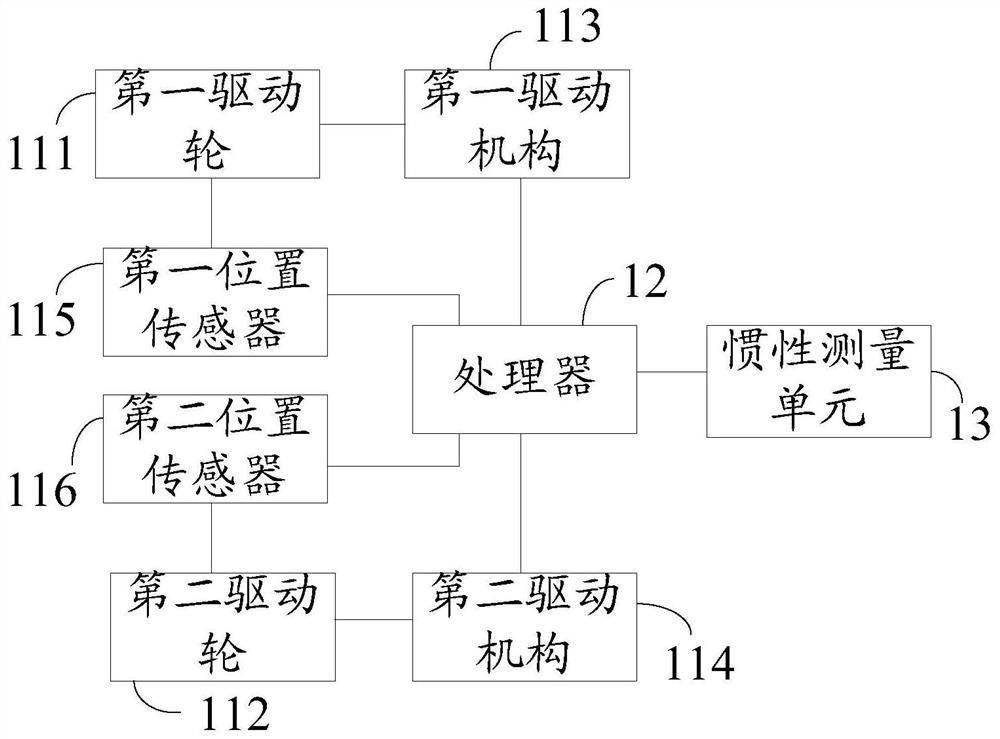
Figure 2 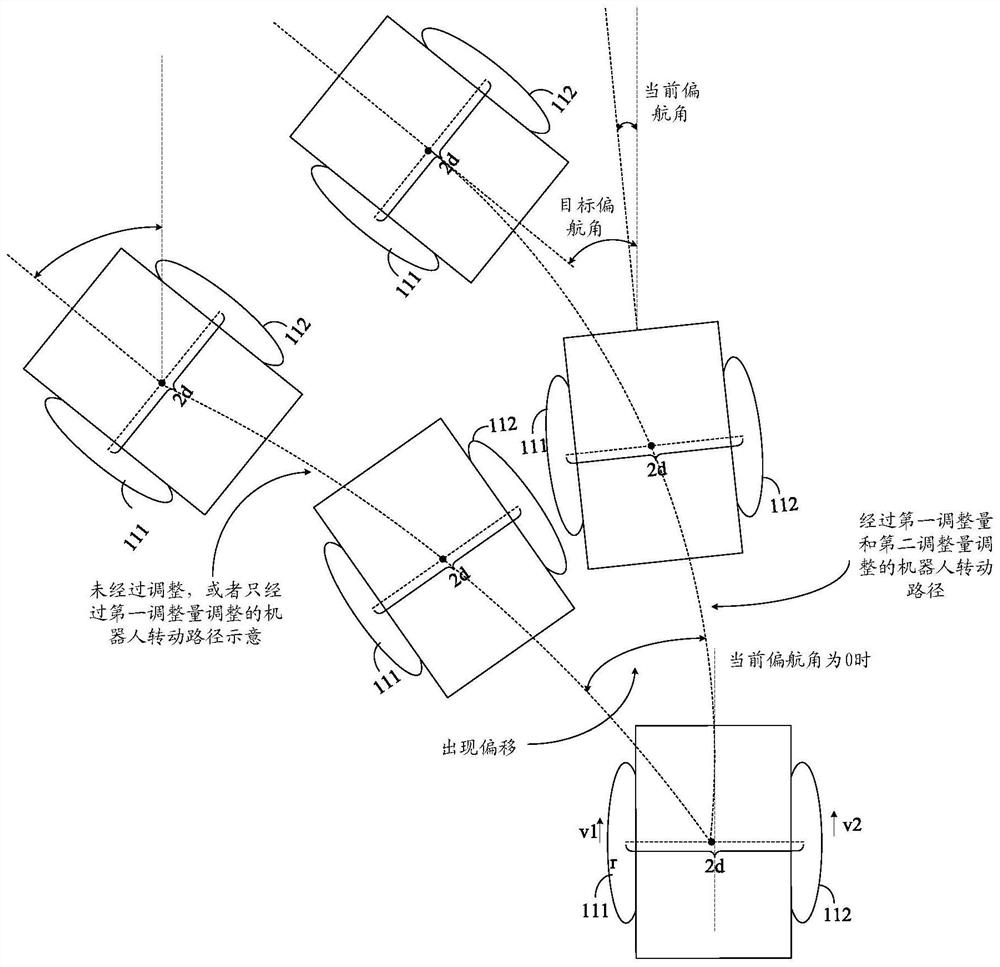
Figure 3
Abstract
Description
technical field
[0001] The present application relates to the technical field of robot control, in particular to a robot and its steering control method. Background technique
[0002] In the prior art, most robots are manufactured and assembled, for example, there are differences in the design, manufacture, and structural installation of various parts, especially motors. When turning, it is easy to cause the robot to deviate and make the travel path prone to deviation. The target yaw angle or path inconsistency makes it difficult for the robot to effectively avoid obstacles or travel to the target point. Most of the existing robots cannot effectively control their steering direction when they are turning due to the above problems. Contents of the invention
[0003] The main technical problem to be solved by this application is to provide a robot and its steering control method, which can improve the phenomenon such as deviation when the robot turns in the prior art. [00...
Examples
Embodiment Construction
[0019] The following will clearly and completely describe the technical solutions in the embodiments of the present application with reference to the drawings in the embodiments of the present application. Obviously, the described embodiments are only some of the embodiments of the present application, not all of them. Based on the embodiments in this application, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts belong to the scope of protection of this application.
[0020] In the prior art, there are differences in the manufacturing and assembly of most robots, such as the design, manufacture, and structural installation of various parts, especially the motors. When the machine turns, due to the differences in the design and installation of the motors and wheels on both sides of the robot. The steering speed of the wheels on both sides is different from the design speed, which will easily cause the robot to deviate and mak...