
Fruit double-line operation picking robot
A technology for picking robots and fruits, applied in the field of agricultural robots, can solve the problems of low operation efficiency, time-consuming and laborious fruit picking, etc., and achieve the effects of reducing labor costs, reducing picking damage, and working stably
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-06-11
Smart Images
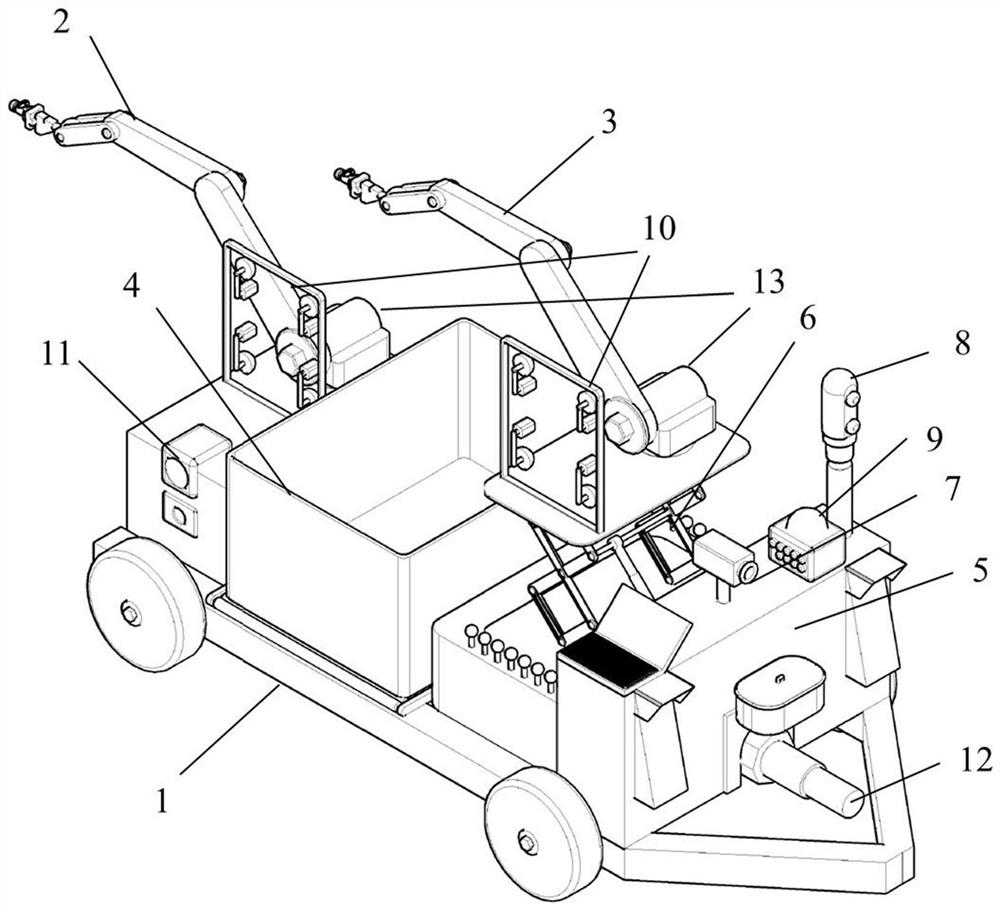
Figure 1 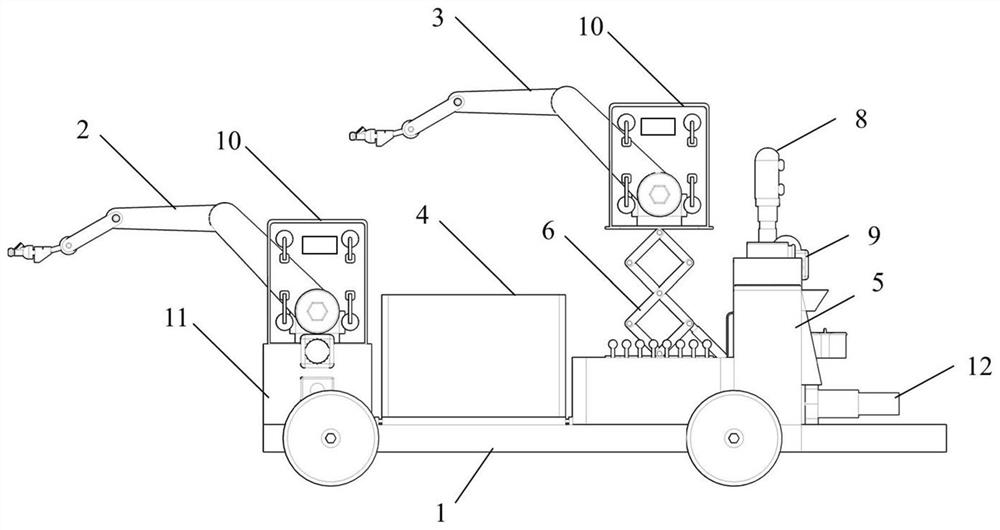
Figure 2 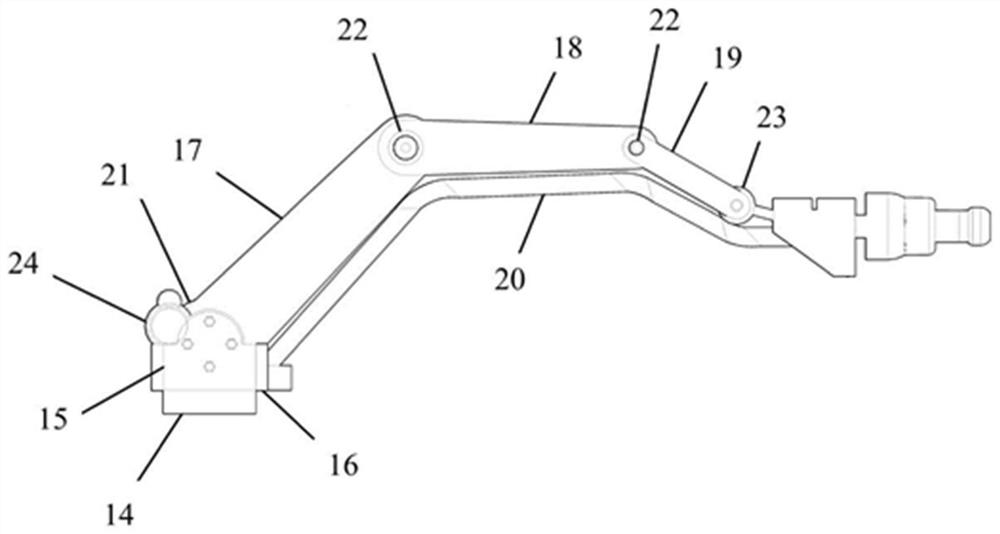
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the technical field of agricultural robots, in particular to a fruit picking robot with two-line operation. Background technique
[0002] With the development of my country's economy and society, agricultural production is constantly changing to scale, intensification, and precision, and the demand for automated and intelligent agricultural machinery and equipment is increasing. Due to the complexity of fruit picking operations, fruit picking in my country still relies mainly on manual work, which is time-consuming, laborious and inefficient, and there are certain risks. Therefore, it is becoming more and more urgent to develop an intelligent fruit picking robot to realize automatic fruit picking, which is of great significance. Contents of the invention
[0003] The invention provides a fruit picking robot with two-line operation, which is used to solve the problems of time-consuming and labor-intensive manual fruit picking...
Examples
Embodiment Construction
[0040] In order to make the purpose, technical solutions and advantages of the present invention clearer, the technical solutions in the present invention will be clearly and completely described below in conjunction with the accompanying drawings in the present invention. Obviously, the described embodiments are part of the embodiments of the present invention , but not all examples. Based on the embodiments of the present invention, all other embodiments obtained by persons of ordinary skill in the art without creative efforts fall within the protection scope of the present invention.
[0041] At present, my country's fruit production is changing from a traditional production mode to a modern production mode, and new cultivation techniques, agronomic techniques, and management techniques have been widely applied. Especially in apple planting, the application of "fence wall cultivation mode" makes apple planting more conducive to the development of agricultural mechanization,...