
High-precision control method for three-axis inertially stabilized platform based on internal model principle and self-adaptive time-varying bandwidth observer
A technology based on time-varying bandwidth and internal model principle, applied in adaptive control, general control system, control/regulation system, etc., can solve the problem that control performance is easily affected by external interference, and achieve fast response of observation performance and dynamic parameters , the effect of avoiding the chattering phenomenon
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-12-28
Smart Images
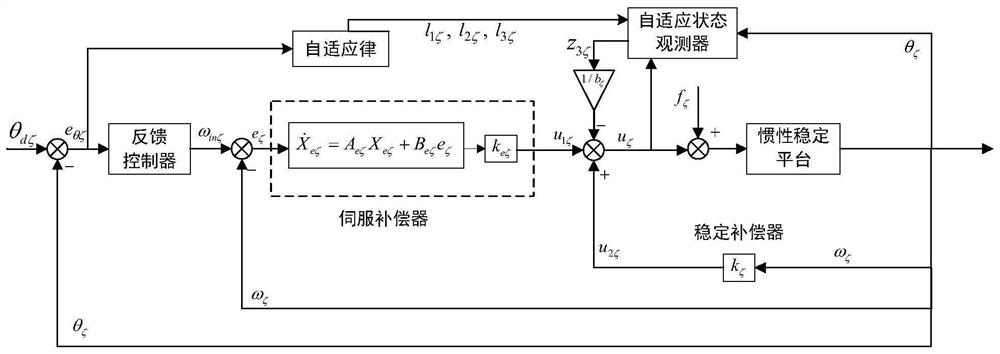
Figure 1 
Figure 2 
Figure 3
Abstract
Description
technical field
[0001] The invention relates to a high-precision control method of a three-axis inertial stable platform based on an internal model principle and an adaptive time-varying bandwidth observer, which is suitable for the field of high-precision control of aeronautical surveying and mapping stable platforms. Background technique
[0002] The three-axis pod platform is fixed to the flight carrier through the base, supports and stabilizes the remote sensing load, and isolates the influence of the non-ideal attitude motion of the flight carrier on the boresight of the remote sensing load to improve the imaging quality of the remote sensing load, which has a wide application prospect.
[0003] As a complex multi-frame coupling system, the three-axis inertial stabilization platform has the characteristics of nonlinearity, strong coupling, and high control difficulty. In addition, the three-axis inertial stabilized platform has wind disturbance during flight, the angula...
Examples
Embodiment Construction
[0032] Such as figure 1 Shown, the concrete realization of the present invention is as follows
[0033] (1) Construction of servo compensator and stable compensator based on internal model principle
[0034] The standard model of the angular velocity system of the three-axis inertial stabilized platform is expressed as:
[0035]
[0036] Among them, when ζ = r, it means the roll channel, when ζ = p, it means the pitch channel, when ζ = a, it means the heading channel, x ζ is the state variable of the ζ-axis angular velocity system, y ζ is the output of the ζ-axis angular velocity system, x ζ =y ζ = ω ζ is the actual angular velocity of the ζ axis, u ζ is the ζ-axis control voltage, f ζ is the system ζ-axis lumped disturbance, and its first derivative f ζ Bounded, A ζ =[0],B ζ =[b ζ] is the ζ-axis motor control coefficient, C ζ =[1],D ζ =[0],E ζ =[b fζ ] is the ζ-axis interference coefficient, F ζ =[0];
[0037] Design a servo compensator and a stable compen...