
Industrial robot
An industrial and robotic technology, applied in manipulators, scientific instruments, semiconductor/solid-state device manufacturing, etc., can solve the problems of lower resonance frequency, insufficient rigidity of the hand fork, high cost, etc., so as to suppress the generation of defective products and improve the actual The effect of the job rate
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Patents(China)
- Current Assignee / Owner
- Publication Date
- 2006-07-26
Smart Images
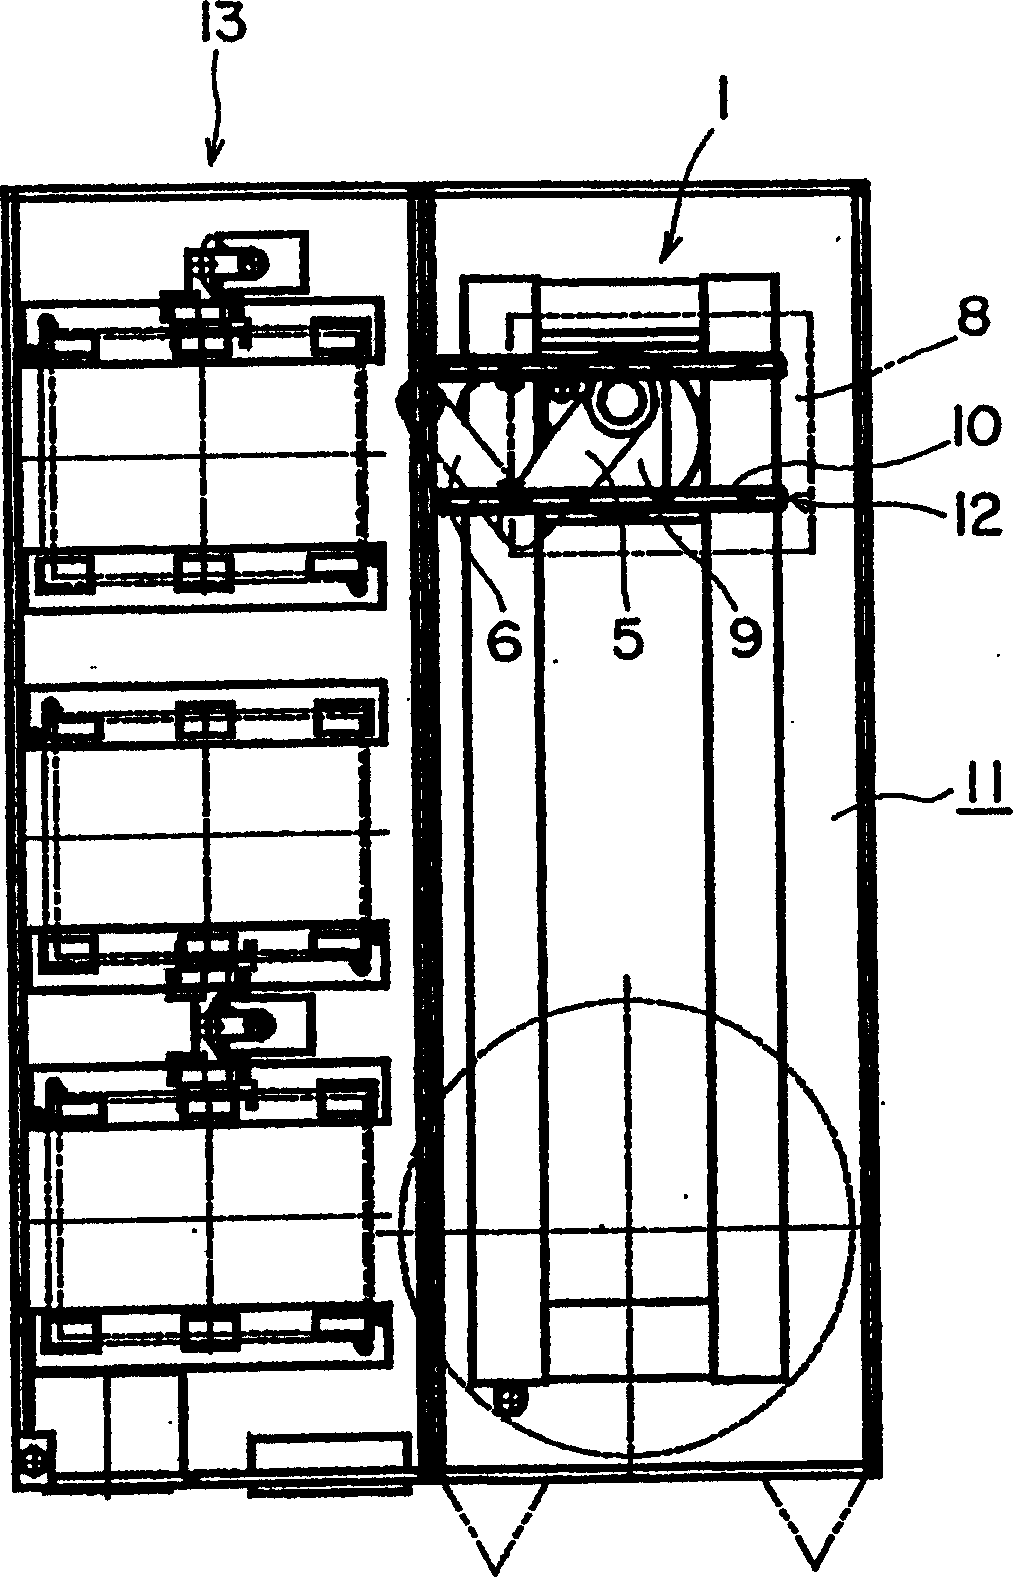
Figure 1 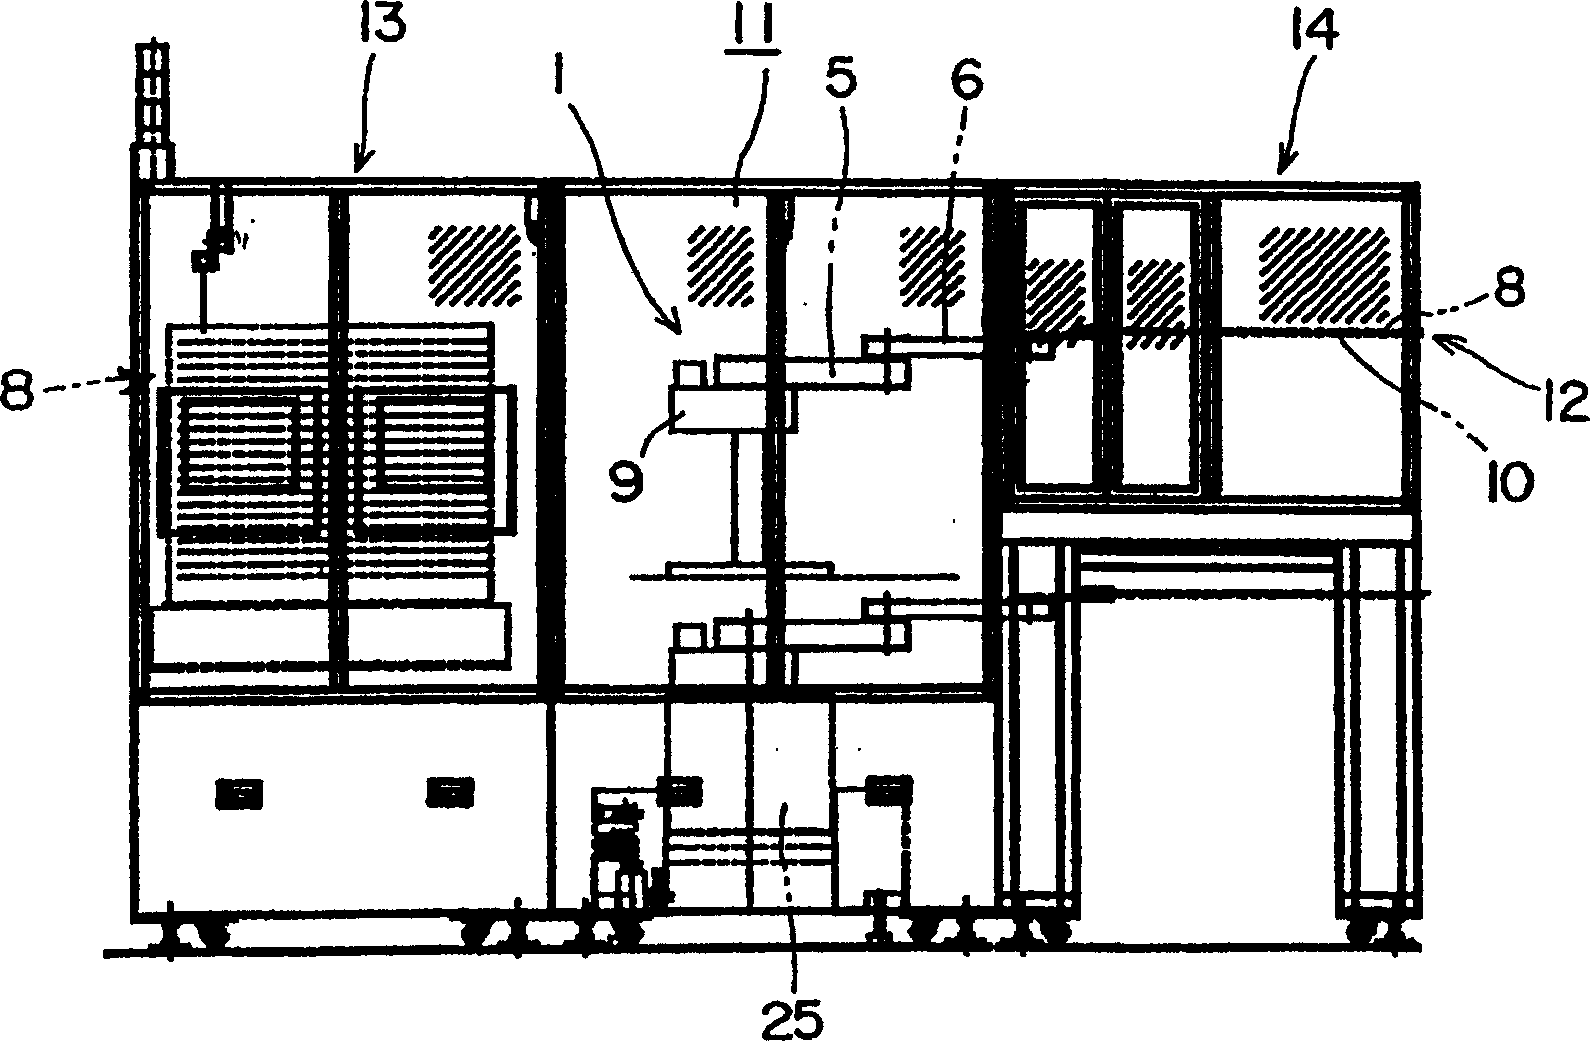
Figure 2 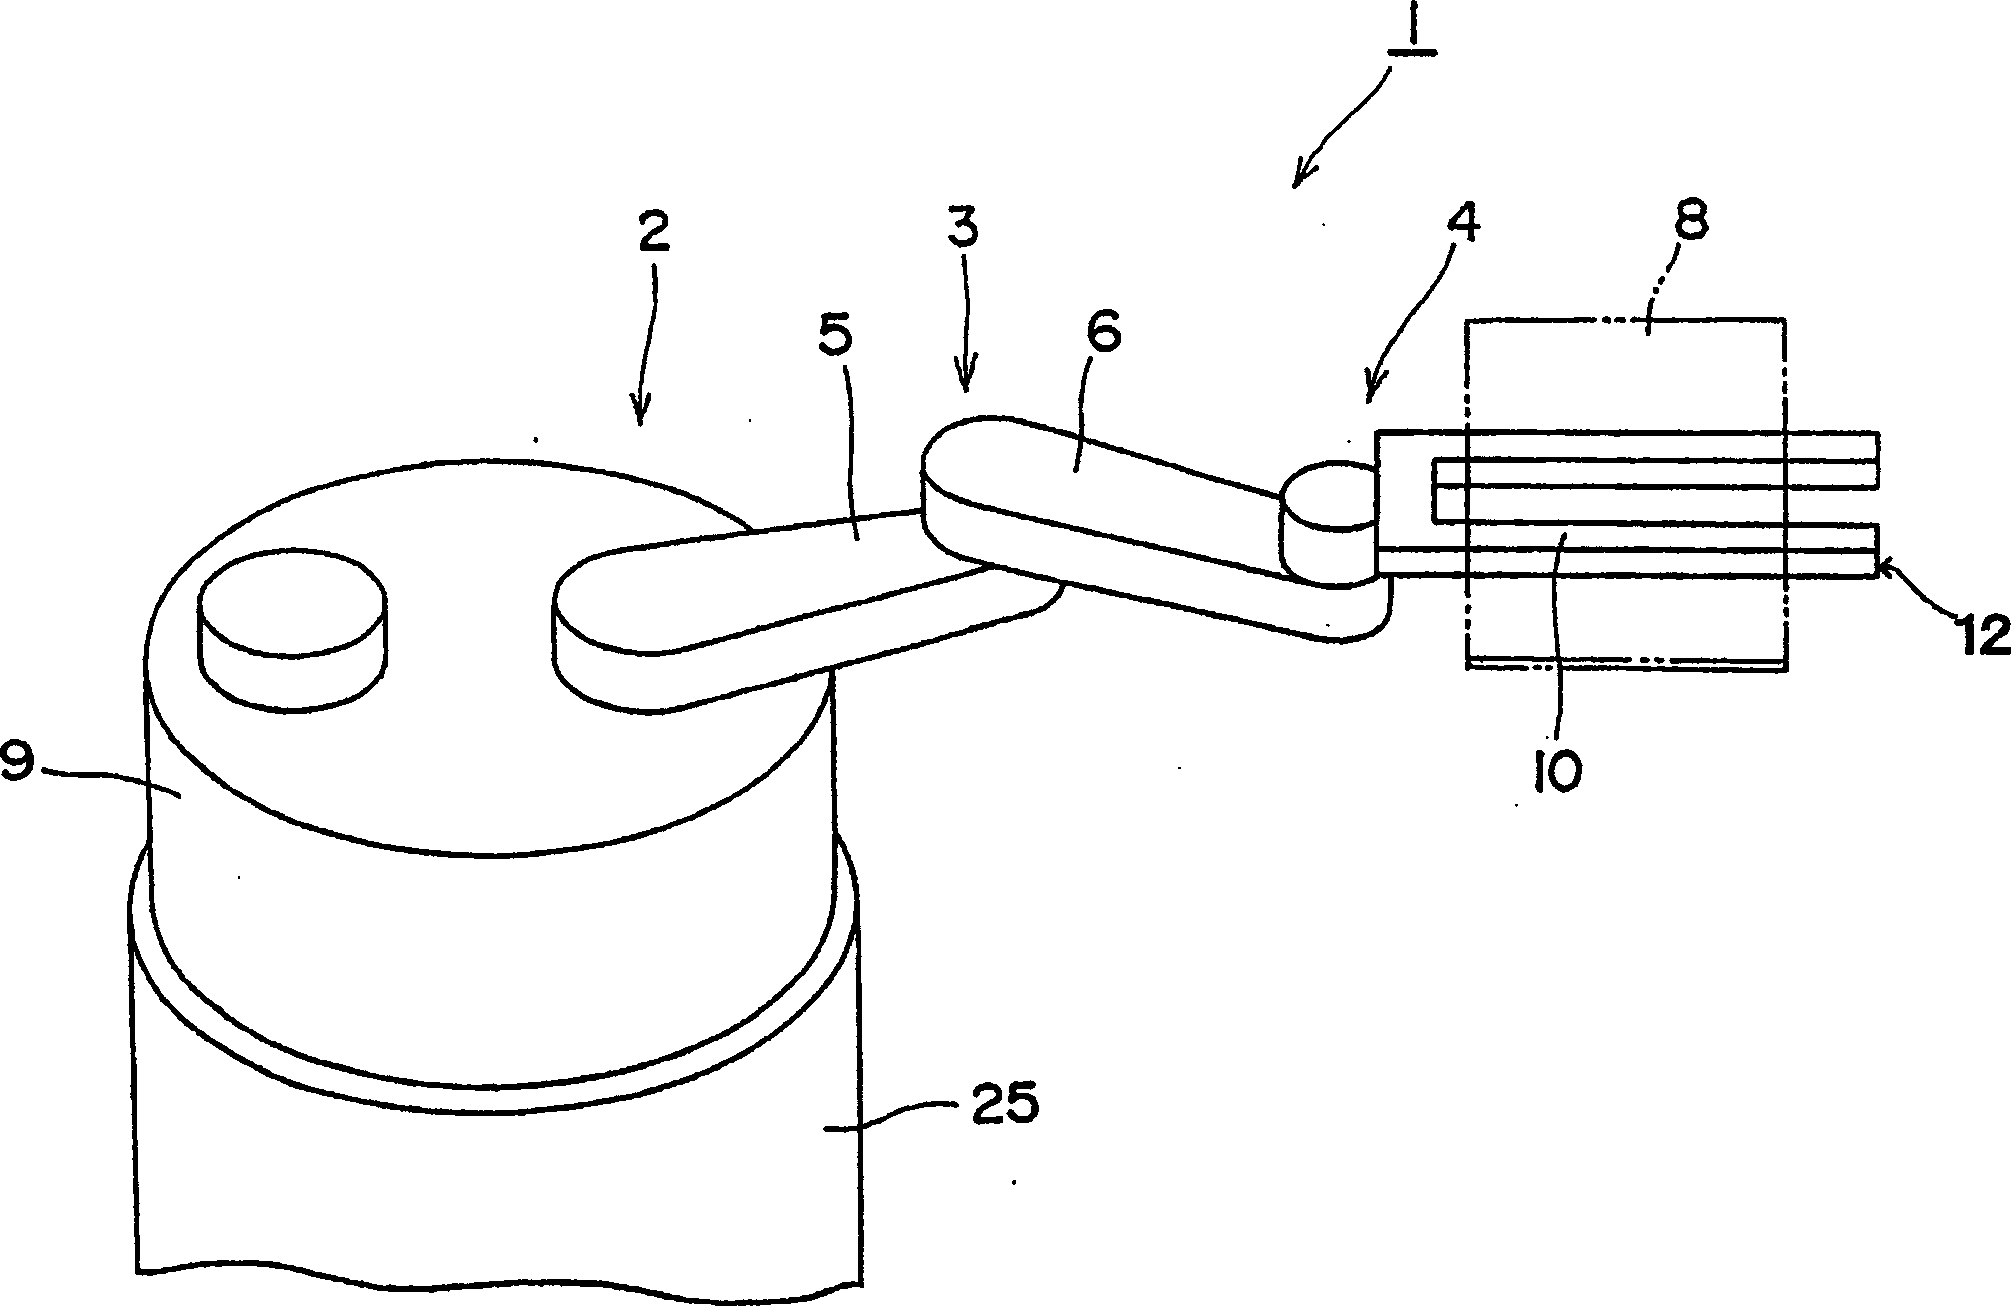
Figure 3
Abstract
Description
technical field
[0001] The present invention relates to an industrial robot, in particular to an industrial robot performing operations such as assembly, processing, and transportation in a clean space.
[0002] In addition, the present invention relates to a particle counter applicable to an industrial robot for measuring the number of particles in a gas using light scattering characteristics, and particularly relates to an improvement in the shape of a laser beam irradiated to a sample fluid. Background technique
[0003] Such robots include a robot that moves semiconductor wafers or liquid crystal panels from boxes to other devices in a clean room. When handling these semiconductor wafers and liquid crystal panels, the number of particles in the clean room has a great influence on the yield, so there are several methods for inspection.
[0004] For example, workers sometimes set up particle counters at defined locations in cleanrooms for periodic inspections. In additio...
Examples
Embodiment Construction
[0049] The composition of the present invention will be described in detail below with reference to the preferred embodiments shown in the accompanying drawings.
[0050] Figure 1 to Figure 5 Embodiment 1 of the industrial robot 1 of the present invention is shown. This industrial robot 1 performs operations such as assembly, processing, and transportation in the clean space 11 . Further, a particle counter for measuring the cleanliness in the clean space 11 is provided on the hand 10 of the industrial robot 1 . Therefore, the amount of particles near workpieces 8 such as semiconductor wafers and liquid crystal panels placed on the hand 10 can be measured by the particle counter, so accurate inspection can be performed.
[0051] This industrial robot 1 is, for example, an arm drive device that transports the workpiece 8 from the cassette 13 to the manufacturing device 14 . These industrial robots 1, boxes 13, and manufacturing devices 14 are all installed in a clean room 1...