
Numerically controlled workshop automatic delivery vehicle scheduling method
A scheduling method and a technology for delivering vehicles, applied in data processing applications, instruments, logistics, etc., can solve problems such as low efficiency and single delivery method, achieve high convergence, achieve optimal scheduling, and improve utilization
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2013-09-04
Smart Images
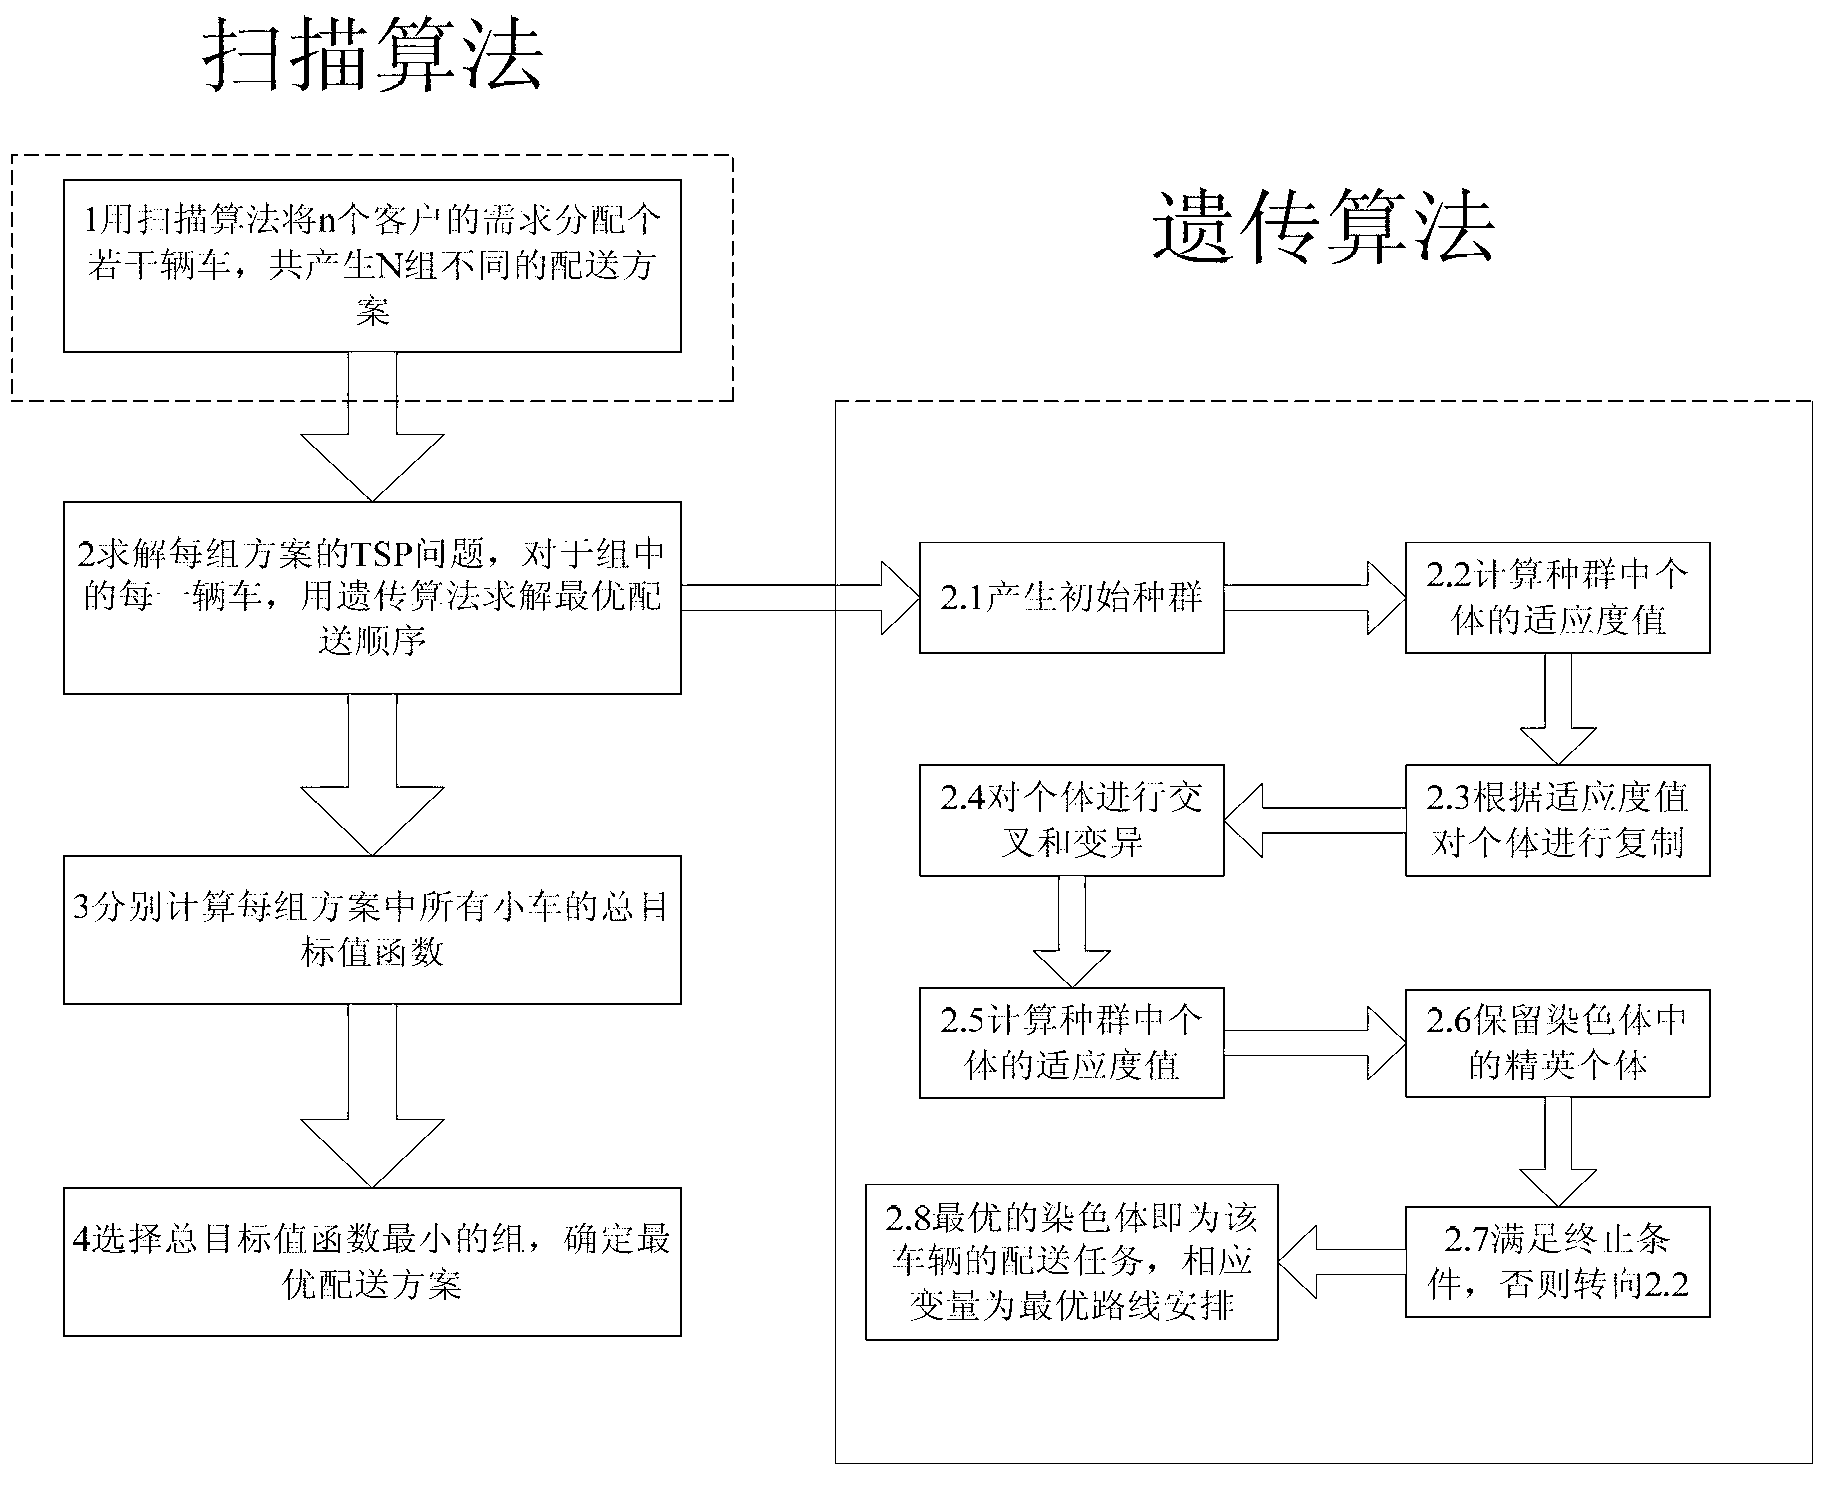
Figure 1 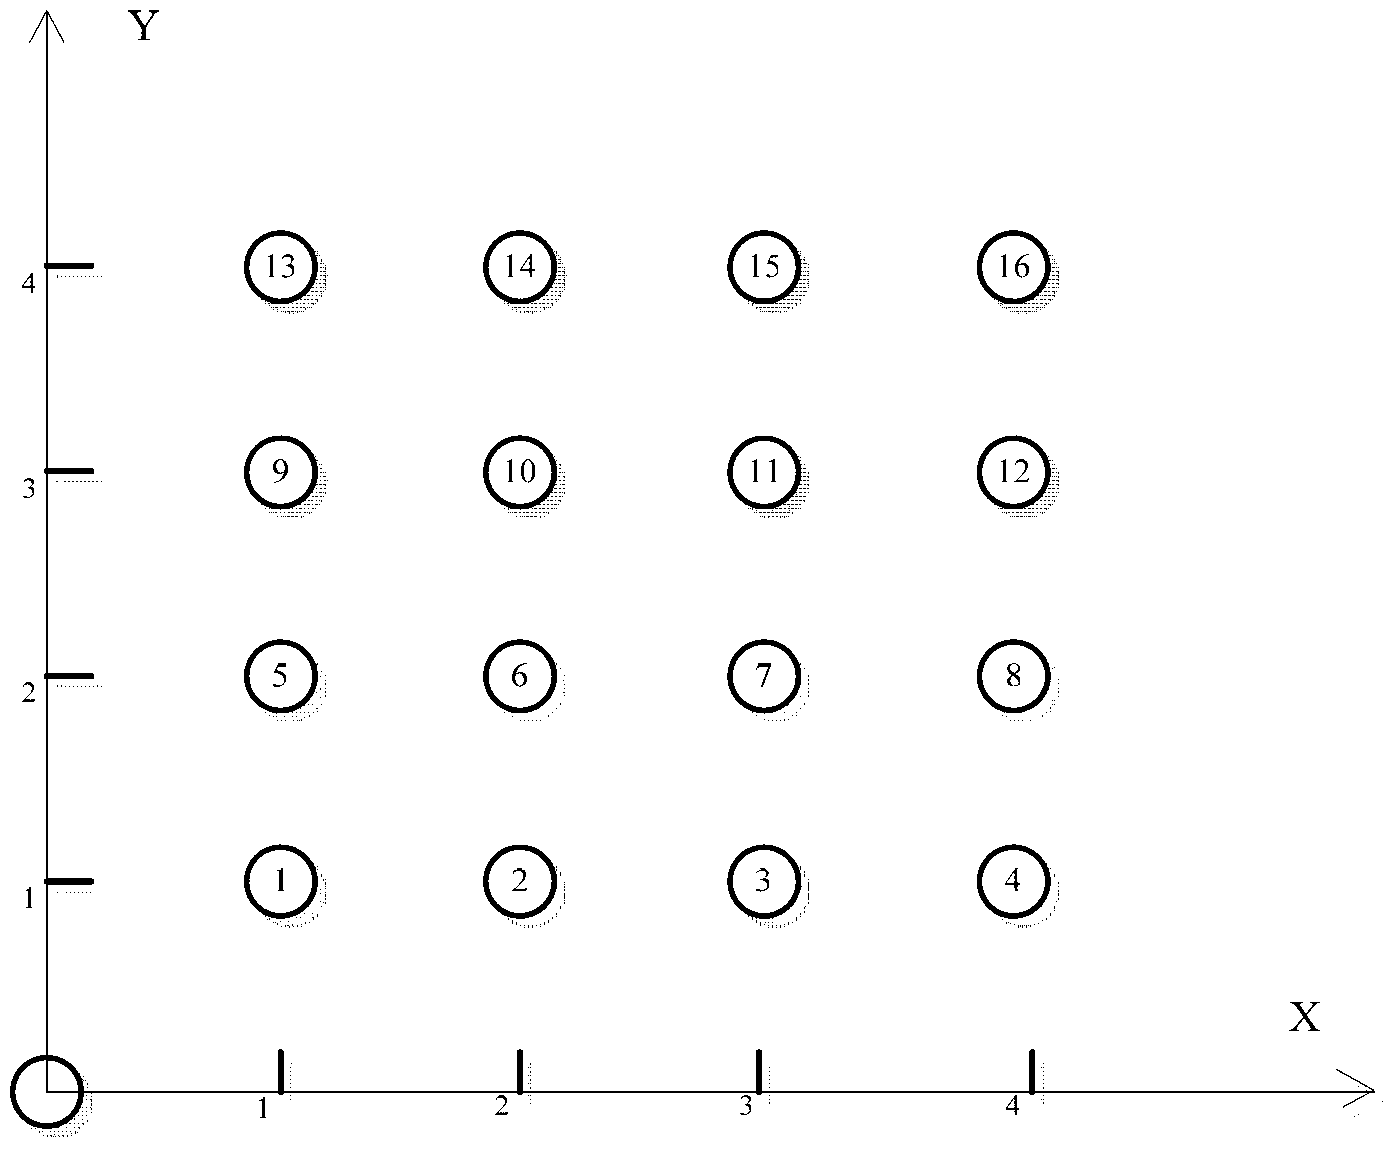
Figure 2 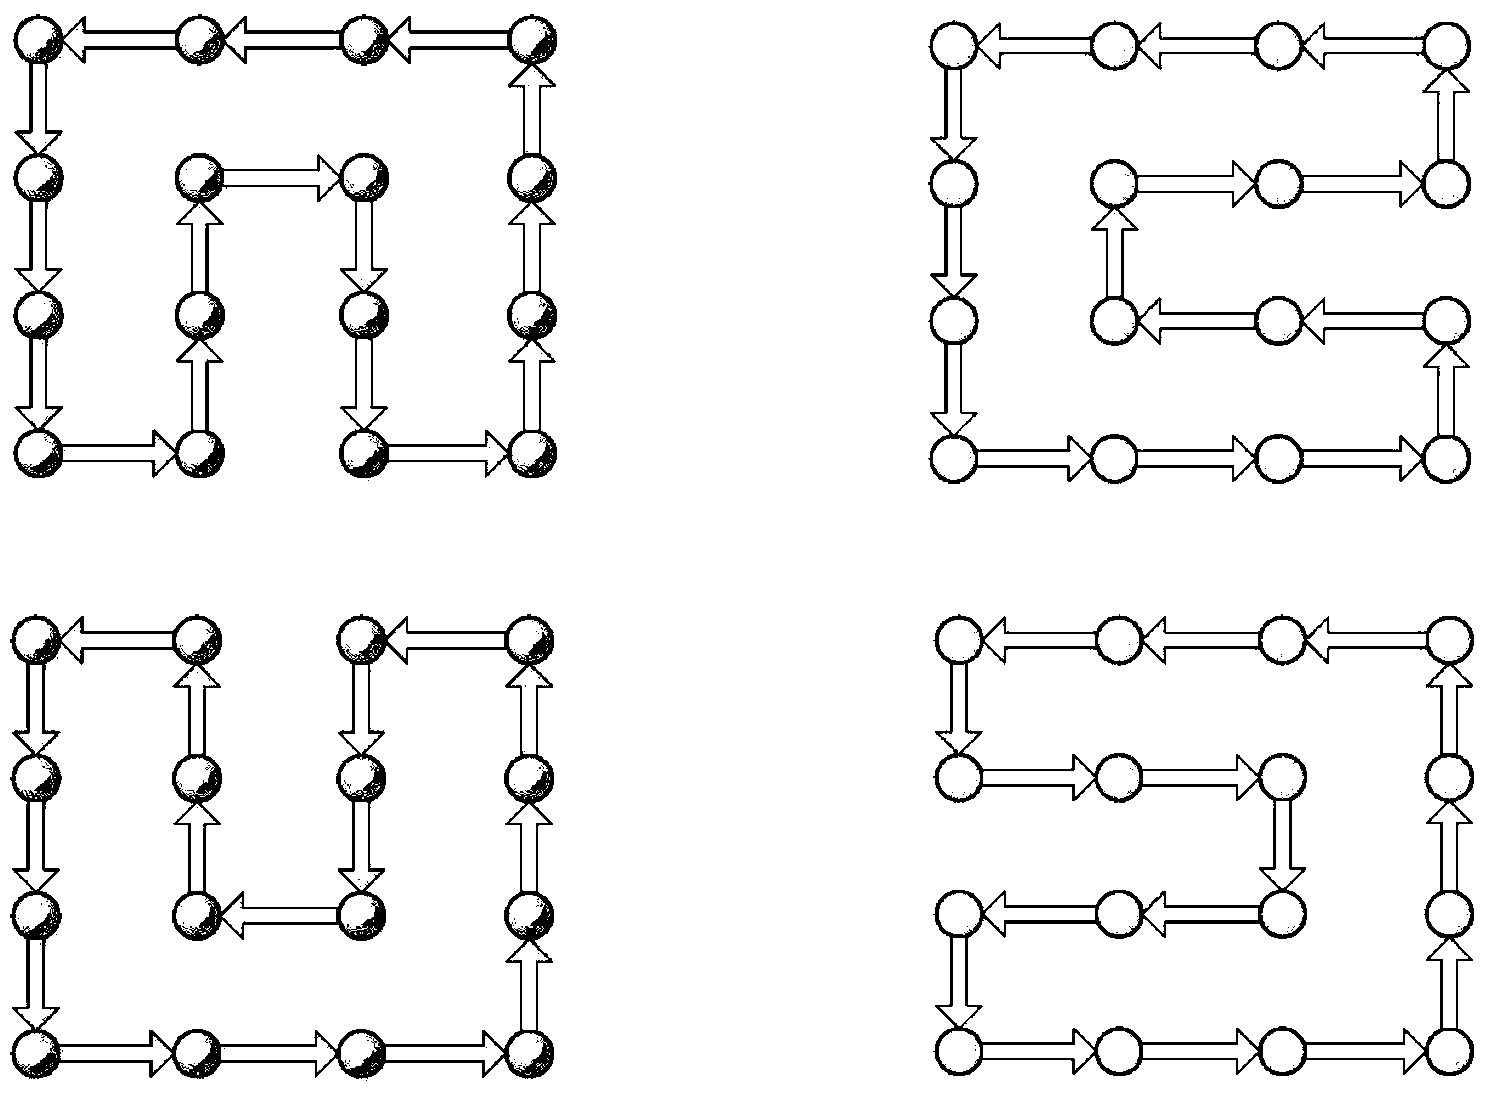
Figure 3
Abstract
Description
technical field
[0001] The present invention relates to a kind of logistics technology, especially a kind of logistics distribution technology in numerical control processing workshop, specifically a kind of automatic distribution vehicle dispatching method of numerical control workshop based on matrix scanning, golden section and genetic algorithm, which uses matrix scanning The method assigns tasks to different vehicles and uses the genetic algorithm to solve the TSP (Traveling Salesman Problem, Traveling Salesman Problem) of a single vehicle, and finally obtains the optimal vehicle scheduling scheme. Background technique
[0002] In the study of modern logistics distribution, the transportation scheduling problem, which is to effectively control the inventory cost, transportation cost and transportation time in the distribution, has become the core and goal of the research. The vehicle scheduling problem in logistics distribution is to deliver a reasonable quantity of goo...
Examples
Embodiment Construction
[0052] The present invention will be further described below in conjunction with the accompanying drawings and the distribution example in the numerical control workshop.
[0053] Such as figure 1 shown.
[0054] A method for scheduling automatic distribution vehicles in a numerical control workshop, comprising the following steps:
[0055] (1) The delivery center obtains the delivery instruction information. The delivery center refers to the place where materials are delivered in the CNC workshop. The delivery instruction information includes: user demand, user location, and delivery time window required by the user;
[0056] (2) According to the user's location and demand, under the condition of satisfying the load constraints of the distribution vehicles, the matrix scanning method is used to assign the distribution tasks of each user to different vehicles. According to the different scanning starting points, the scanning method produces different results. Vehicle task di...