
Implementation method of multithread distributed SLAM system based on ROS environment
An implementation method and multi-threading technology, applied in radio wave measurement systems, electromagnetic wave re-radiation, complex mathematical operations, etc., can solve the problems of small amount of calculation, no real-time data processing and timeliness, etc., to optimize system performance and improve the system performance effect
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2019-11-15
- Estimated Expiration
- Not applicable · inactive patent
Smart Images
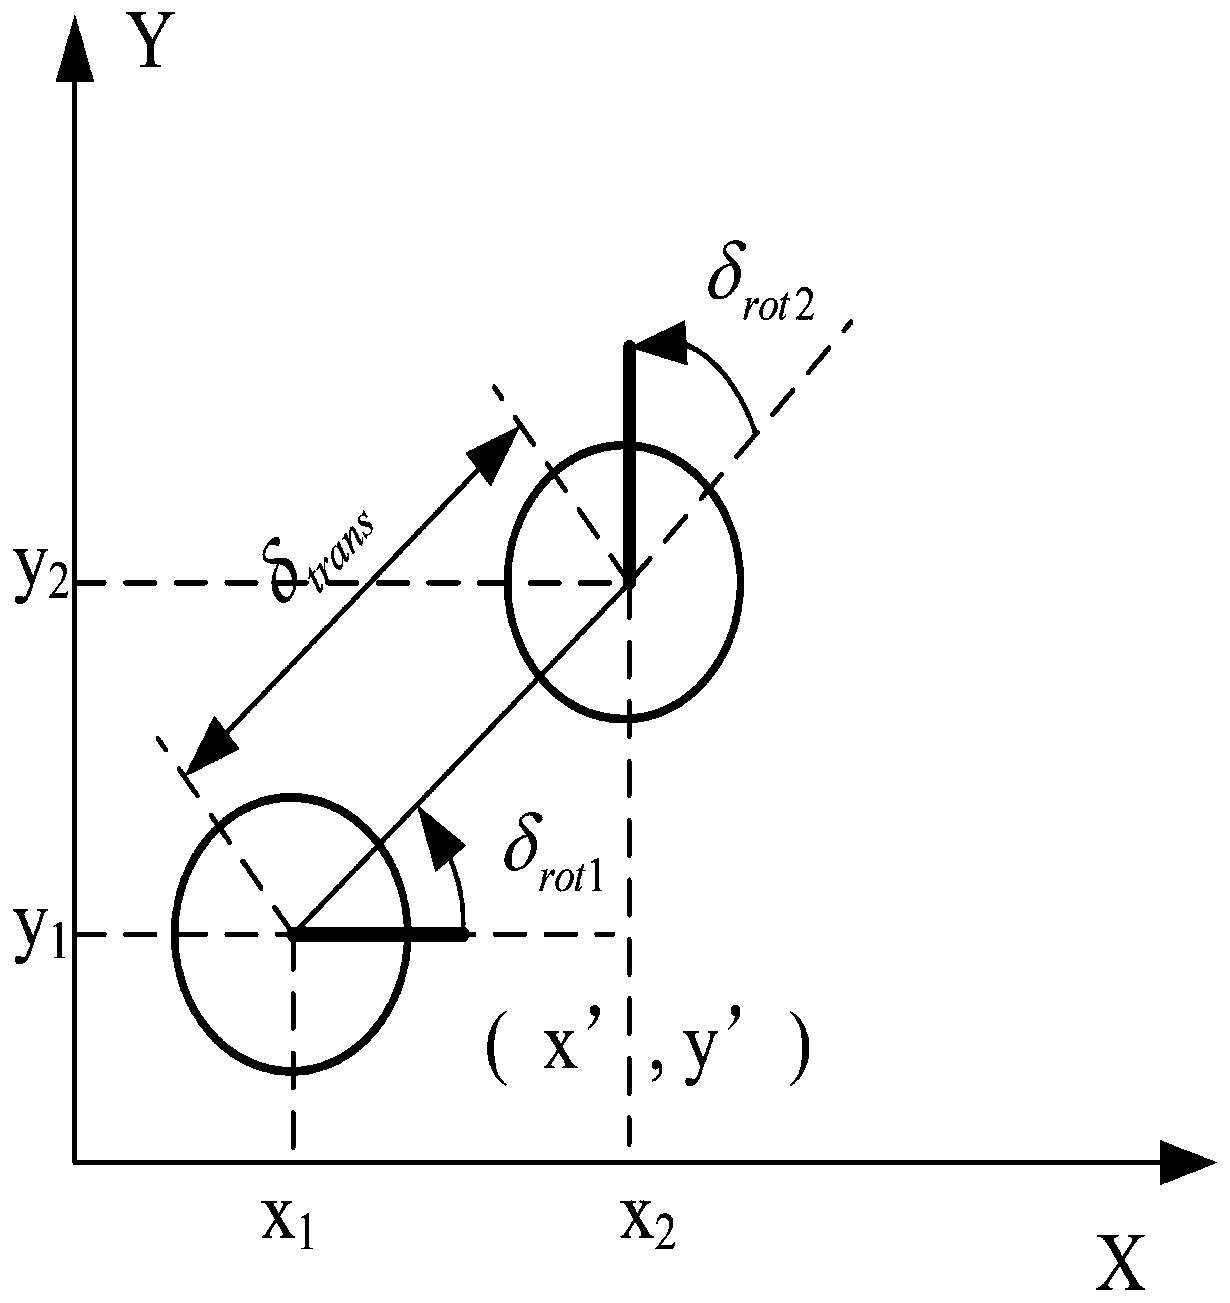
Figure 1 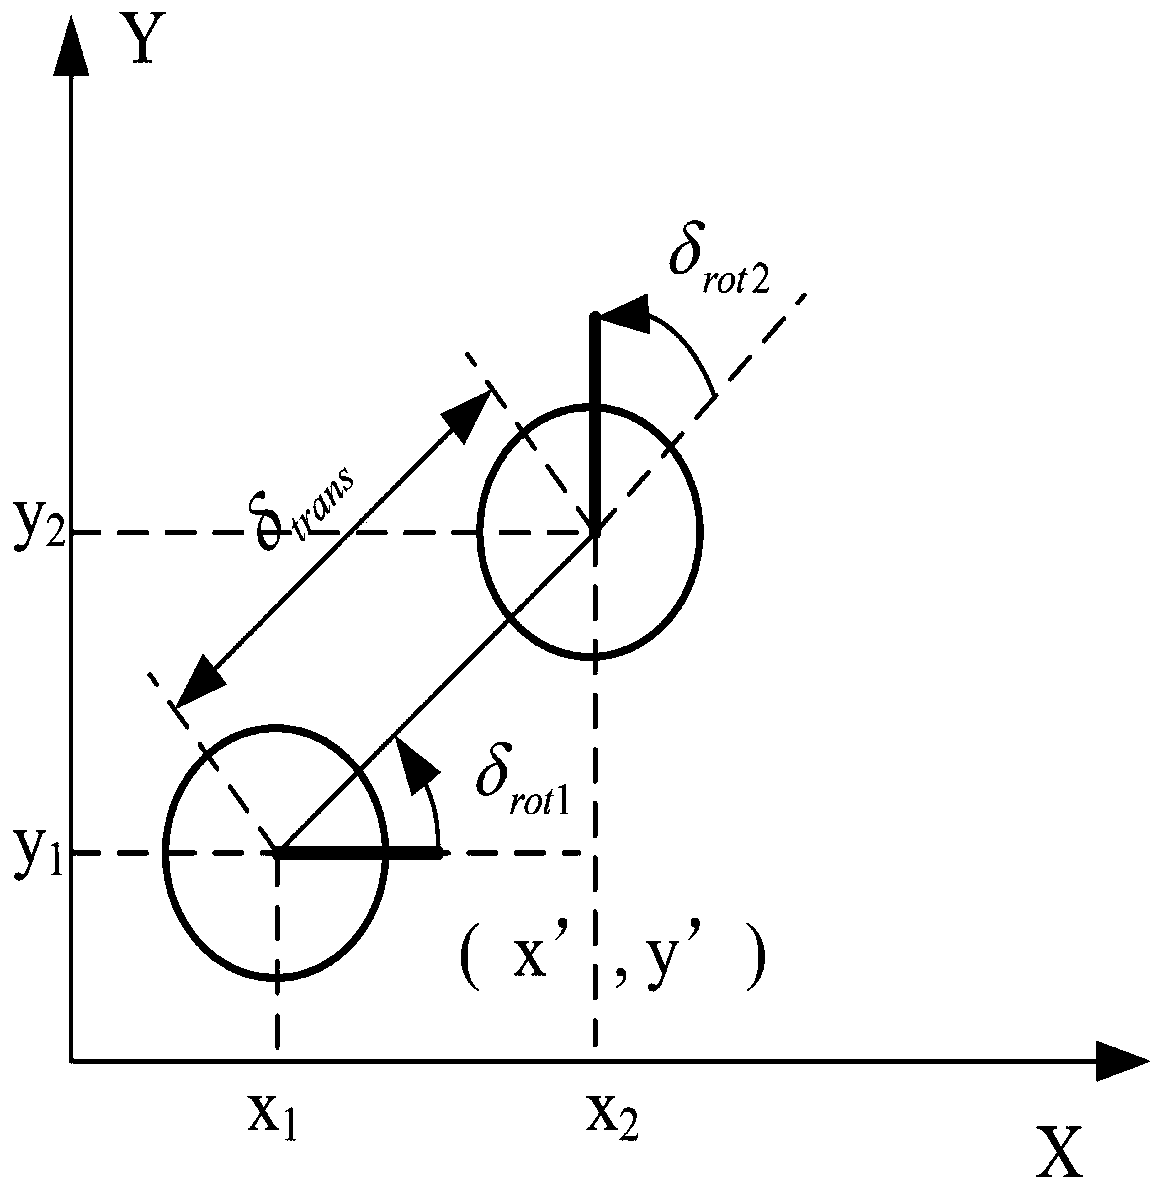
Figure 2 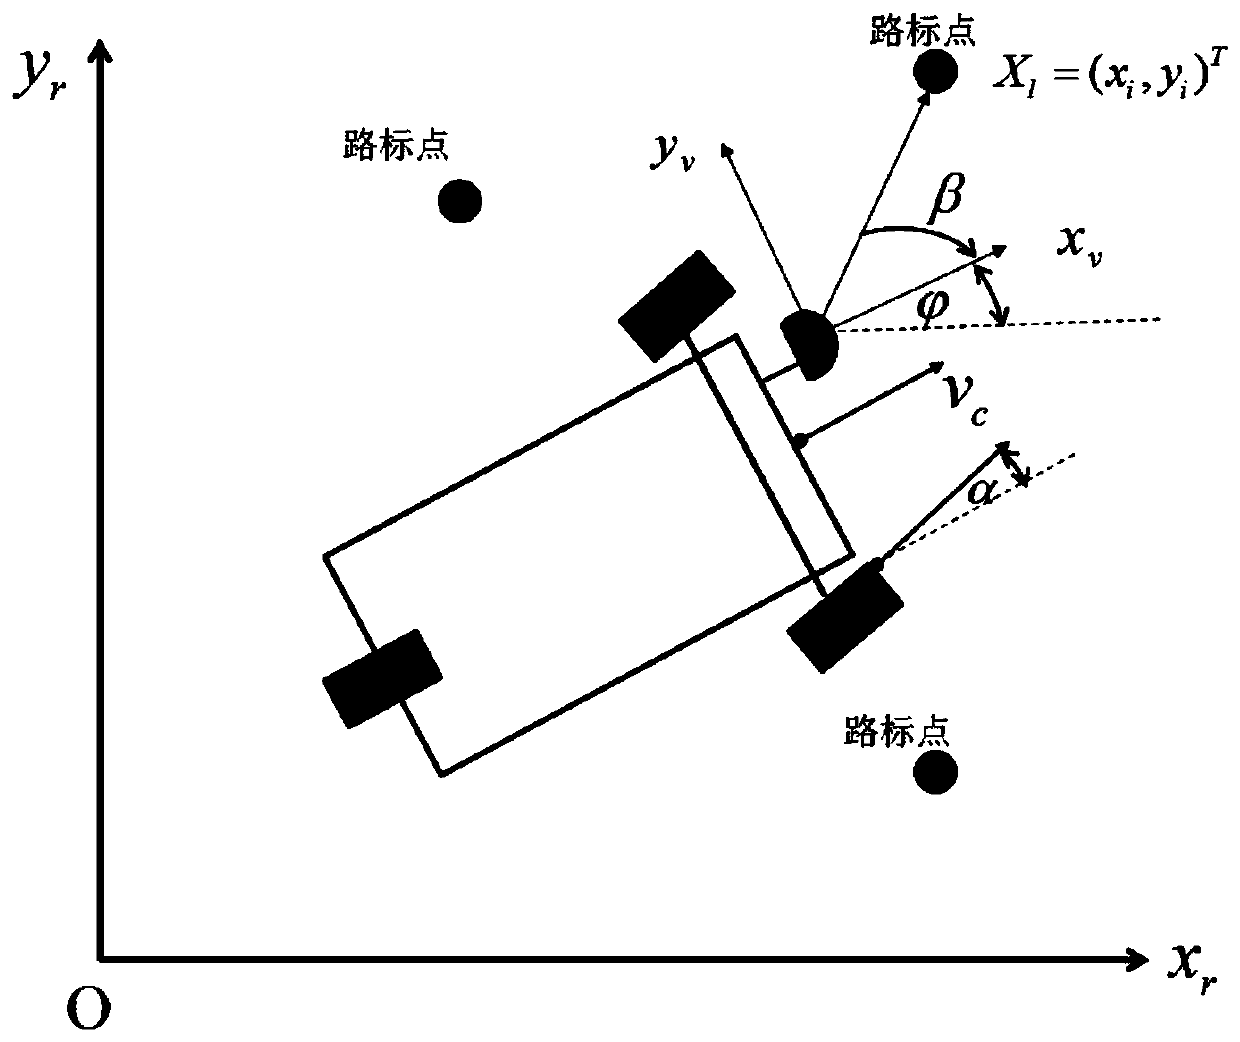
Figure 3
Abstract
Description
technical field
[0001] The design of the present invention uses a distributed structure to divide the entire state vector into five-dimensional states of robot pose estimation and landmark estimation, adopts the distributed processing of the system model, and establishes multiple threads for multiple effective landmark points, forming a parallel independent The model structure of the sub-filter is formed, and then the pose estimation result of the robot of the sub-filter is fused in the main filter through the main thread, and the position estimation result of the robot is finally obtained through the fusion result of the sub-filter, so as to realize the autonomous positioning of the robot and map. Thus, a multi-sensor information data acquisition system equipped with laser, odometer, magnetic compass and other sensors and a multi-threaded distributed EKF-SLAM system prototype based on ROS environment were constructed, and the system performance was improved and optimized. B...
Examples
Embodiment Construction
[0094] The present invention will be described in detail below in conjunction with the accompanying drawings and embodiments.
[0095] The technical scheme that the present invention adopts is the realization method based on the multi-threaded distributed SLAM system under ROS environment, and the concrete steps of this realization method are as follows:
[0096] Step 1: Build an information data collection system.
[0097] According to the information collection and transmission methods between the sensors, a multi-sensor information data collection system with lasers, odometers, magnetic compass and other sensors is constructed. After power-on, the laser sensor and magnetic compass start data collection and data transmission, and clock match different sensor data, and save the odometer data, laser scanning data, and compass heading data in a unified data format, so that Distributed SLAM algorithm for subsequent multi-threading.
[0098] Step 2: Model establishment.
[009...