
Mechanical arm motion control delay measuring system based on visual inspection and method thereof
A technology of motion control and visual inspection, applied to manipulators, manufacturing tools, etc., can solve problems such as not considering robot differences, interference with normal robot operation, and distortion of measurement results
Patent Information
- Authority / Receiving Office
- CN · China
- Patent Type
- Applications(China)
- Current Assignee / Owner
- Publication Date
- 2021-09-10
Smart Images
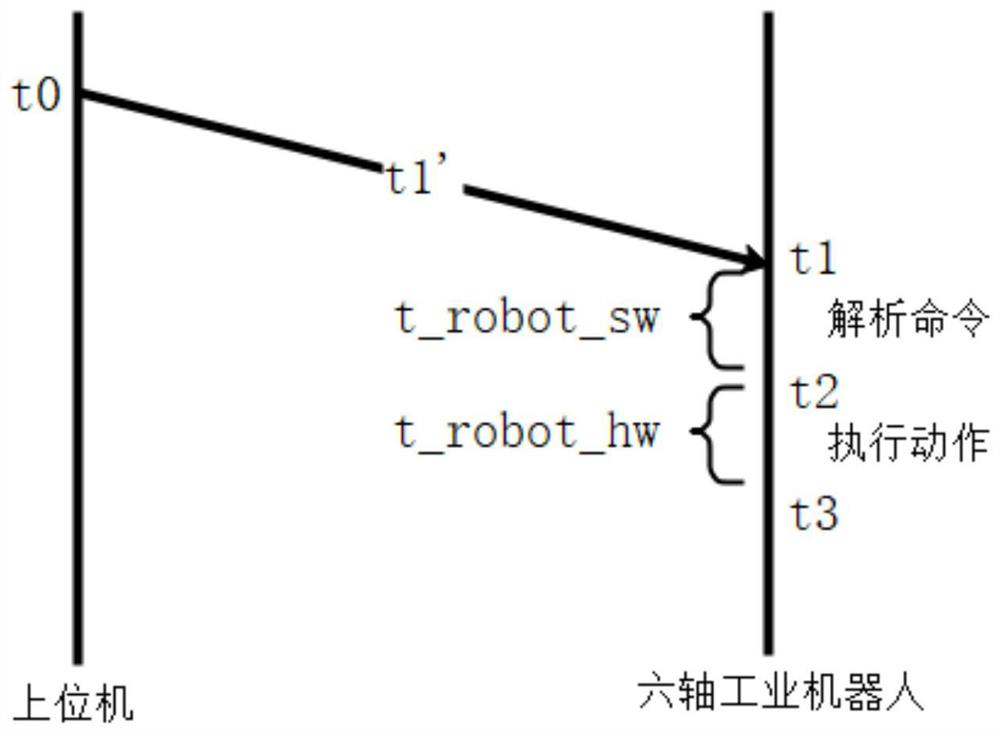
Figure 1 
Figure 2 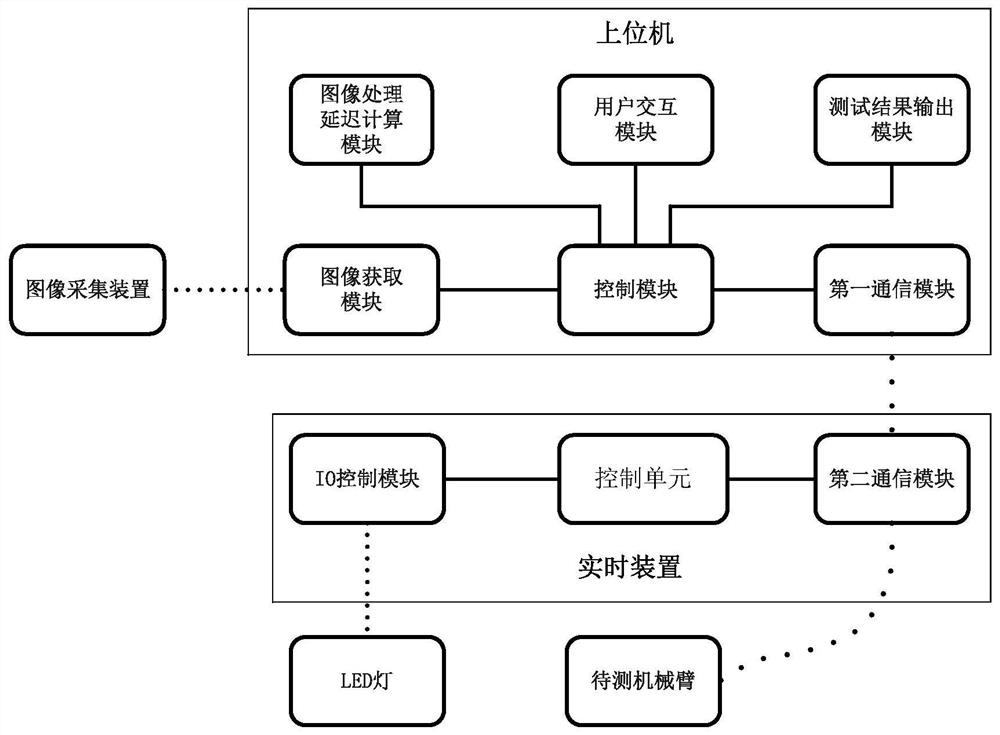
Figure 3
Abstract
Description
technical field
[0001] The invention relates to the field of industrial manipulator testing, in particular to a vision detection-based manipulator motion control delay measurement system and a method thereof. Background technique
[0002] As the scale of industrial production continues to expand, collaboration between industrial equipment becomes more frequent. Multi-axis industrial robots are widely used as important equipment. For an industrial system, especially in high-precision multi-machine collaborative applications, device control delay is crucial to the stable operation of the system. Usually, the upper computer sends execution commands to the robot body processor through the network / serial port and other buses, and the robot body processor receives the command content, analyzes and processes it, and drives the motor to work and execute actions. The time distribution of each stage is as follows figure 1 As shown, the bus transmission delay t1' (millisecond level)...
Examples
Embodiment Construction
[0036] The present invention will be further described in detail below in conjunction with the accompanying drawings and specific embodiments.
[0037] refer to image 3 , a kind of mechanical arm motion control delay measurement system based on vision detection of the present embodiment, comprises upper computer, real-time device, image acquisition device, LED light, upper computer is connected with real-time device, image acquisition device respectively, and real-time device is connected with LED respectively The light and the control interface of the robotic arm are connected. In this implementation, the measured object is the mechanical arm of a six-axis industrial robot, and the image acquisition device is a high-speed camera, specifically a pco.dimaxHS1 high-speed camera with a resolution of 800*600 and a frame rate of up to 13000FPS. The upper computer communicates with the real-time device through Ethernet. The real-time device communicates with the six-axis industri...